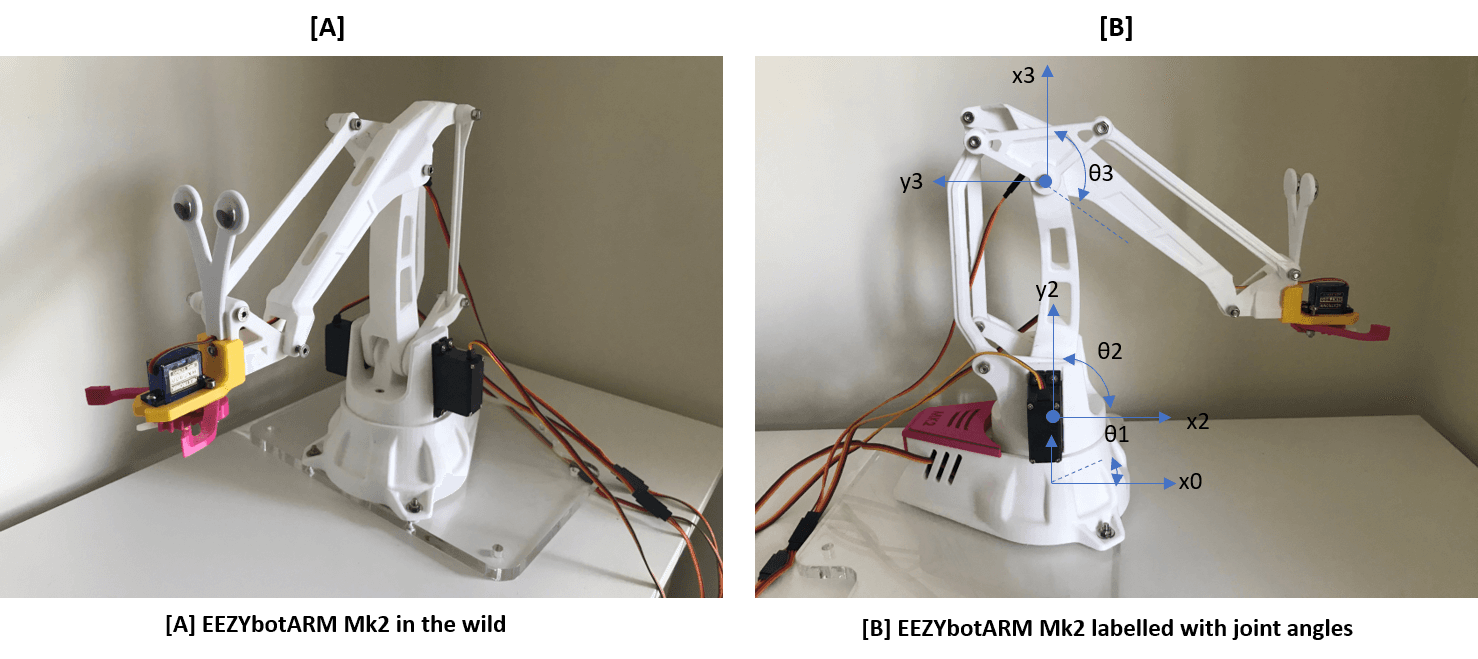
EEZYbotARM
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
Robot armIntermediateBuildability 40/100 · Incomplete documentation
Cost not stated
Robots whose guide reads in English, as written or translated by Robotheca. 197 robots on Robotheca, each with its licenses and its source on GitHub.
Page 6 of 9 · Ready to build first, then by buildability
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A biomimetic robot head with tendon-driven neck controlled via Raspberry Pi and PCA9685 servos.
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
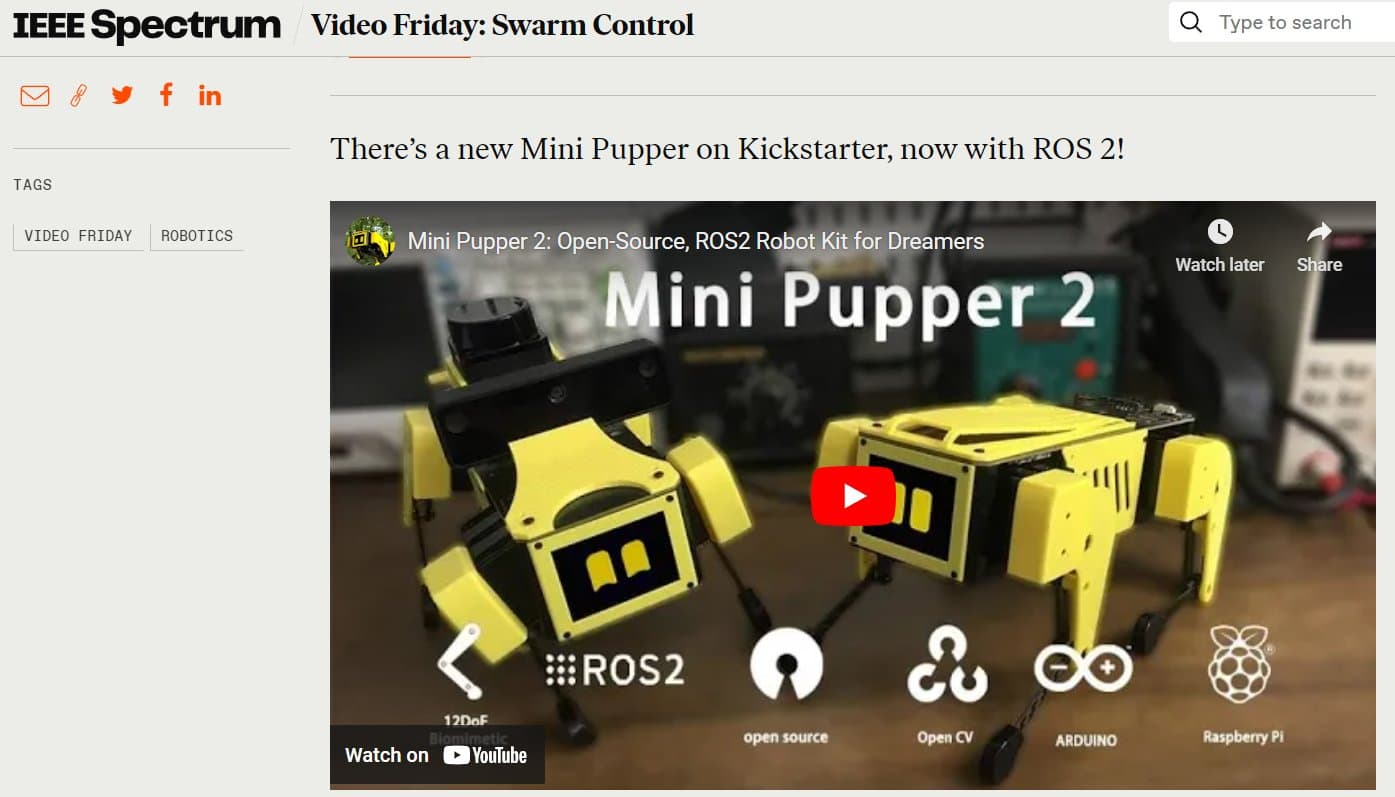
An open-source, ROS-based quadruped robot dog designed for education and research, supporting SLAM, navigation, and OpenCV AI features.
An open-source ESP32-based six-legged robot with Web control, calibration, performance motions, motion sequences and optional voice interaction.
A quadruped robot dog built from 3D-printed PLA parts, driven by ODrive-controlled motors with AS5047 absolute encoders and a remote-controlled walking mode.
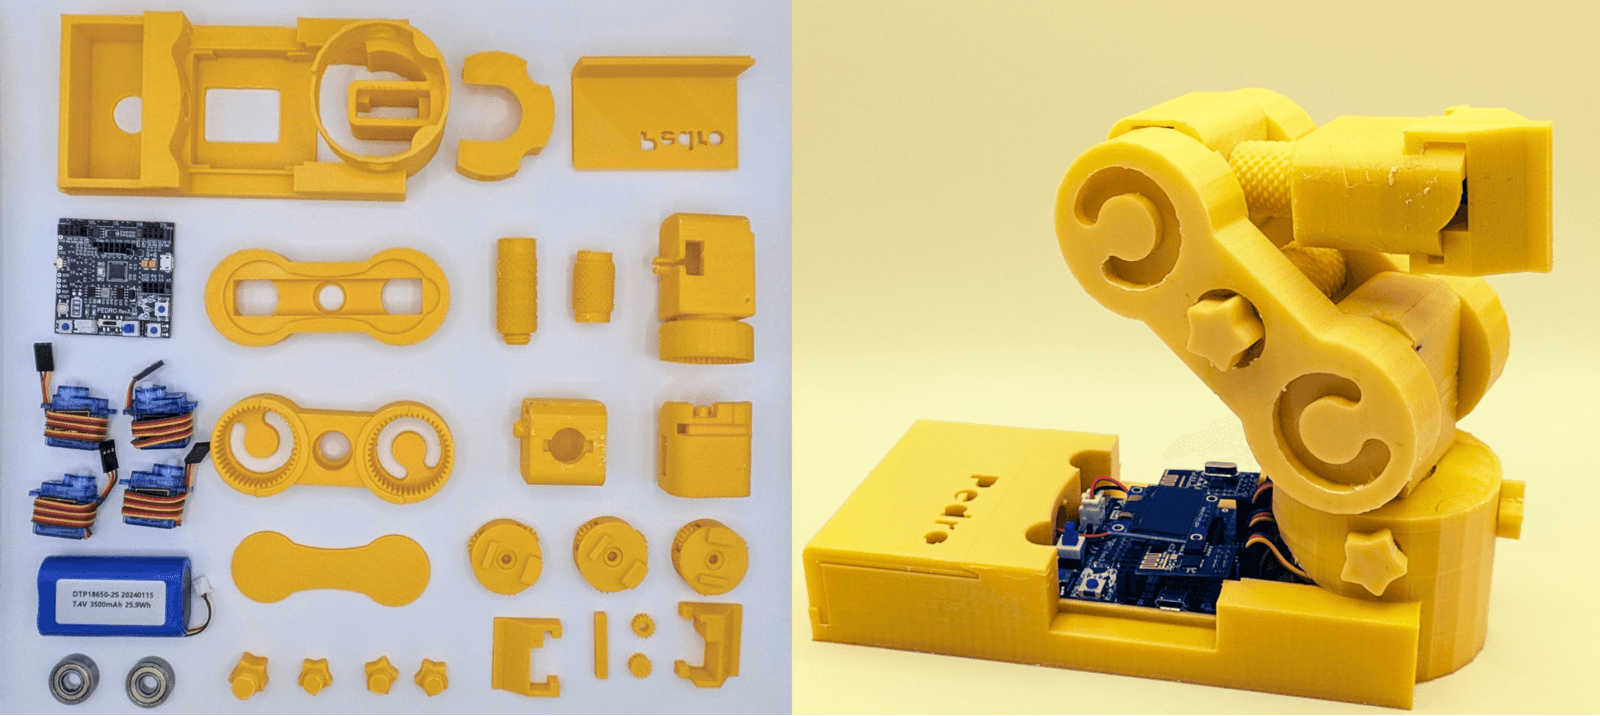
Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.
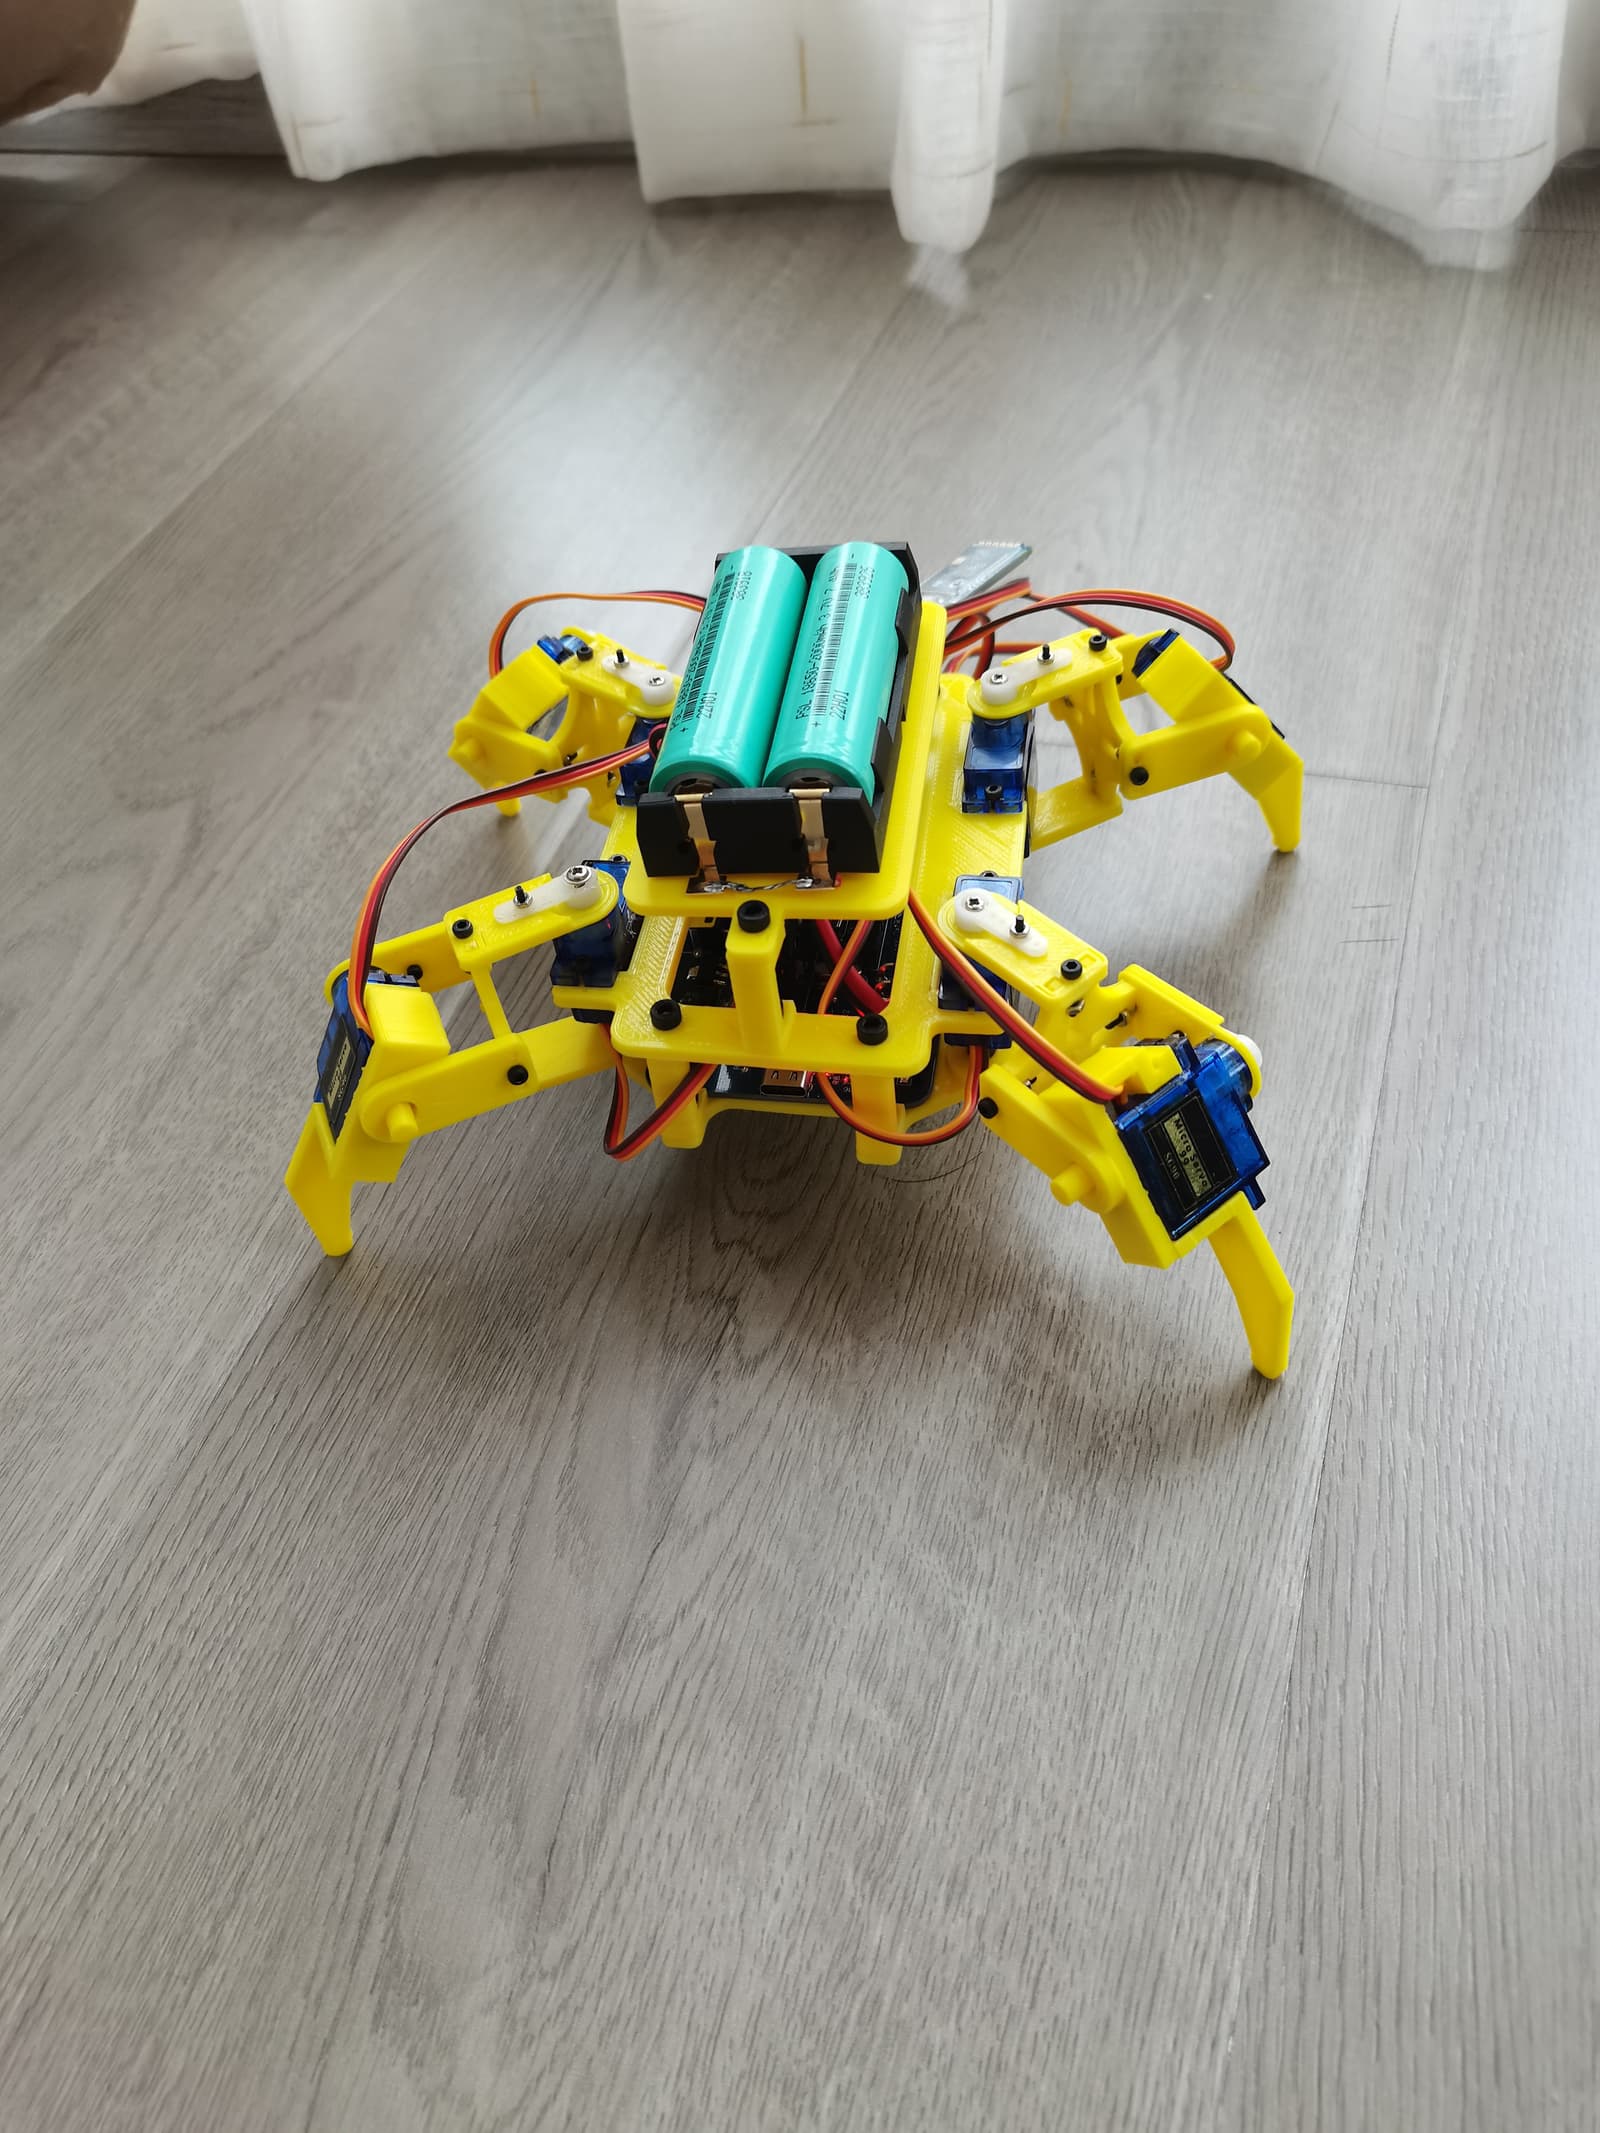
A four-legged robot designed for research and education in legged locomotion.
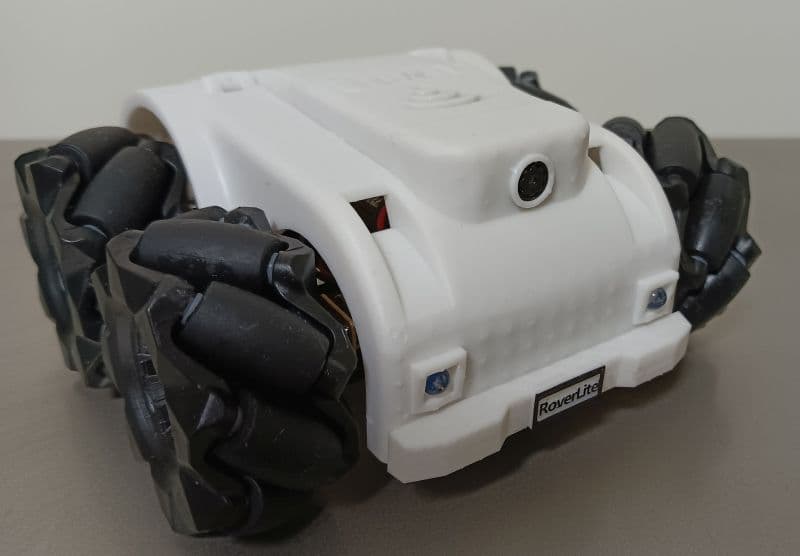
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
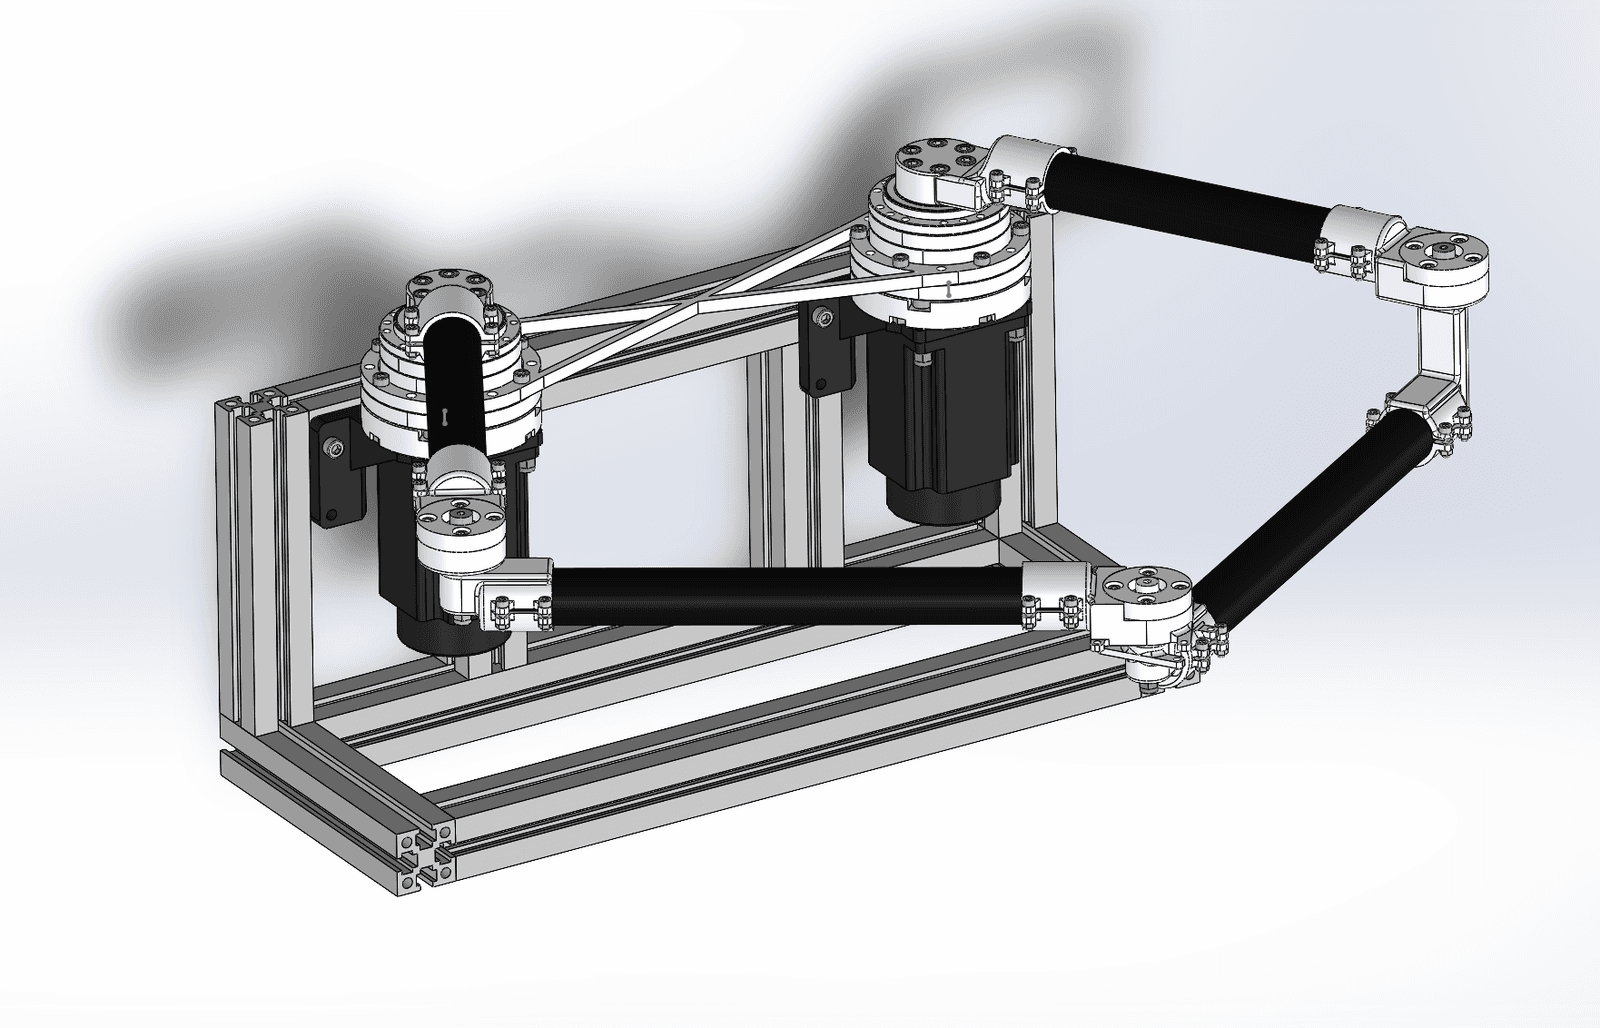
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
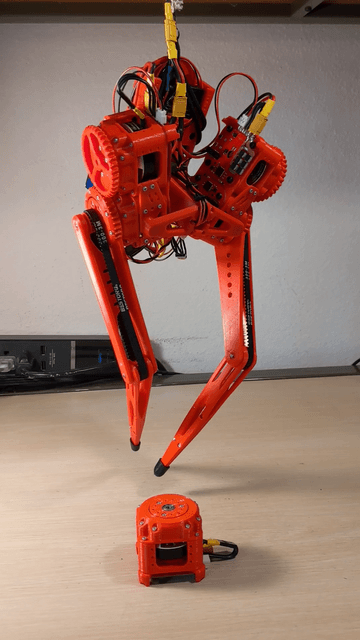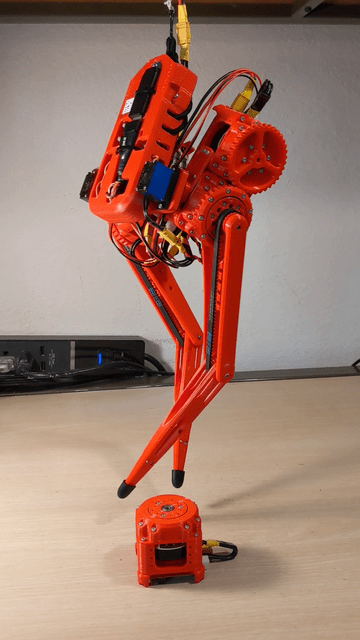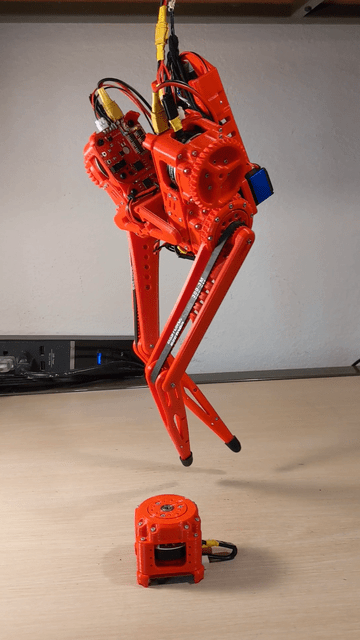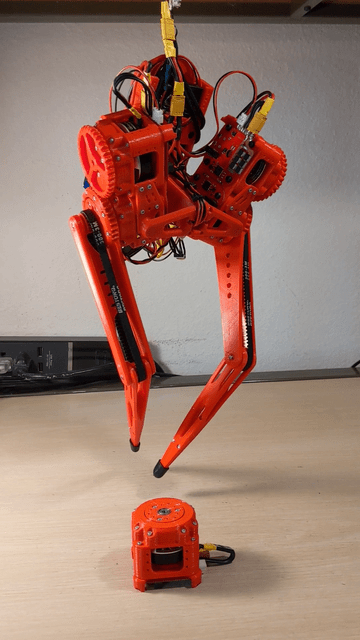
A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.
Open-source wheeled biped robot with wheels for balance and legs for uneven terrain, controllable in simulation and on hardware.
A small quadrotor drone based on STM32 that can fly stably.
A 3D-printable robot arm, current version V4 (Green), designed for printing and assembly by hobbyists.
A writing robot with a 2040 aluminum frame and Core-XY structure that automates handwriting tasks.

A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.
An educational wheeled rover controlled by a Raspberry Pi Zero W, with a DRV8835 motor driver, OLED display, 9-axis sensor and LEDs.
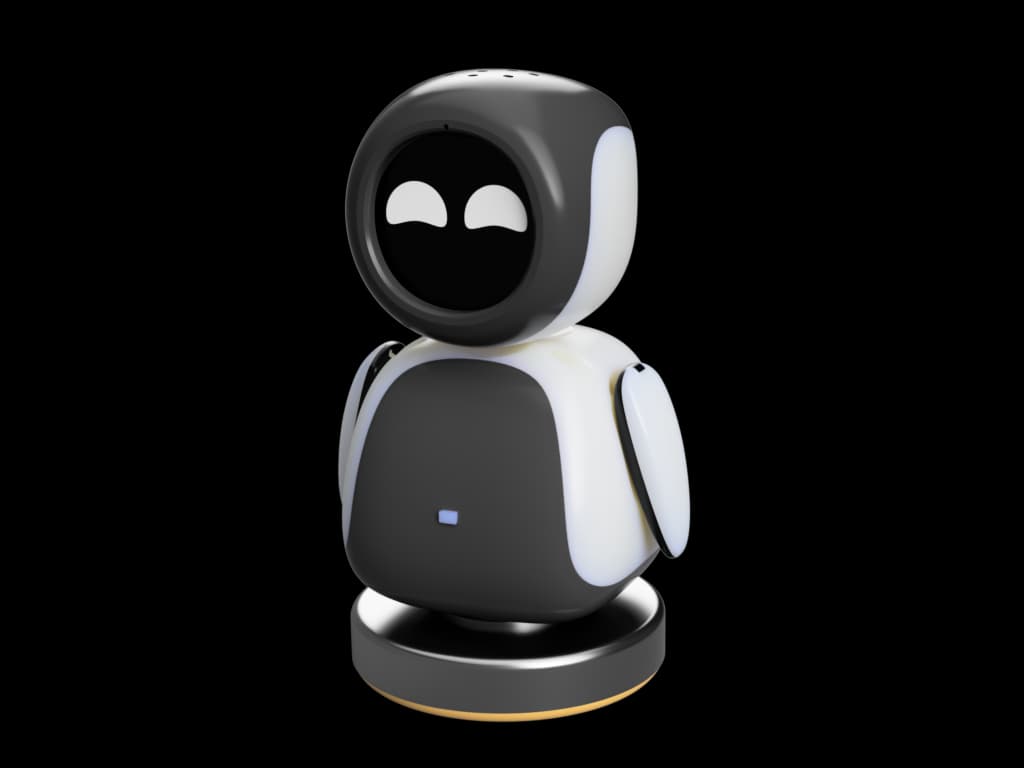
A desktop-sized open-source robot with 6 degrees of freedom, enhanced with AI capabilities via ESP32, designed for education and maker projects.
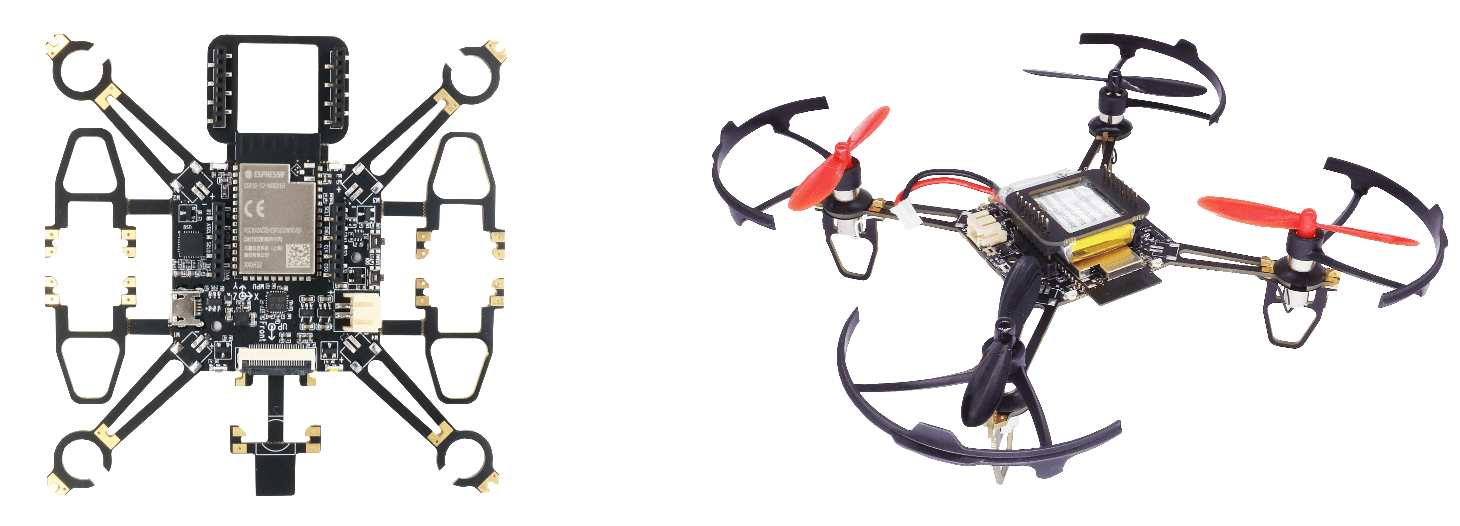
An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
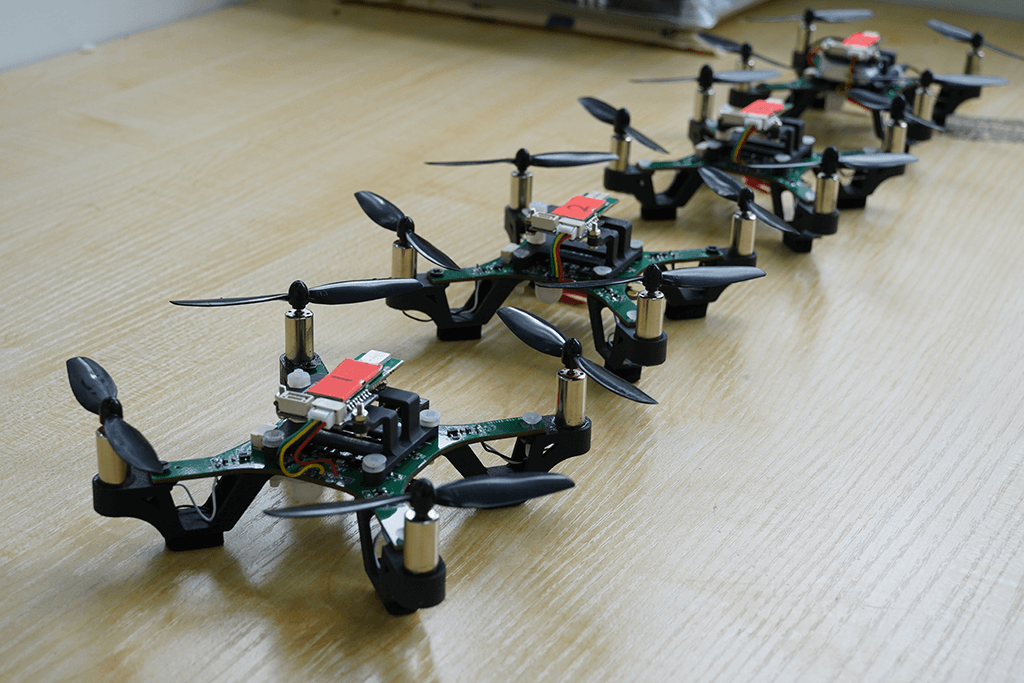
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
Robots 121–144 of 197