Skip to content

Robots you may use commercially

Robots whose licenses allow commercial use. 182 robots on Robotheca, each with its licenses and its source on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

182 robots of 270

Page 3 of 8 · Ready to build first, then by buildability

  • Humanoid

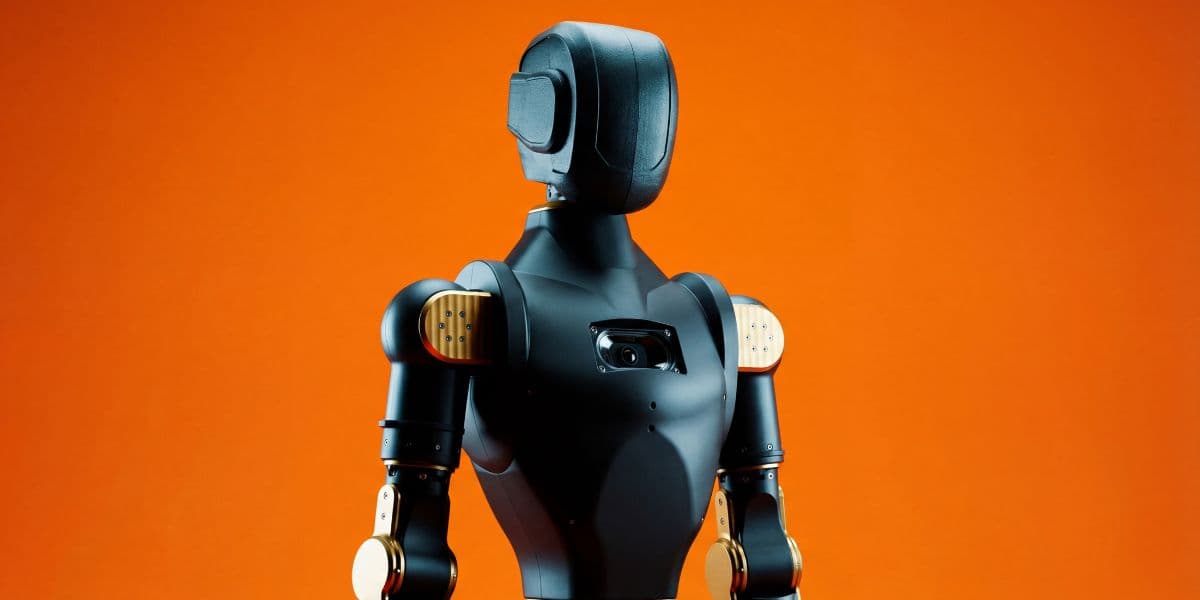
    Asimov 1

    An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

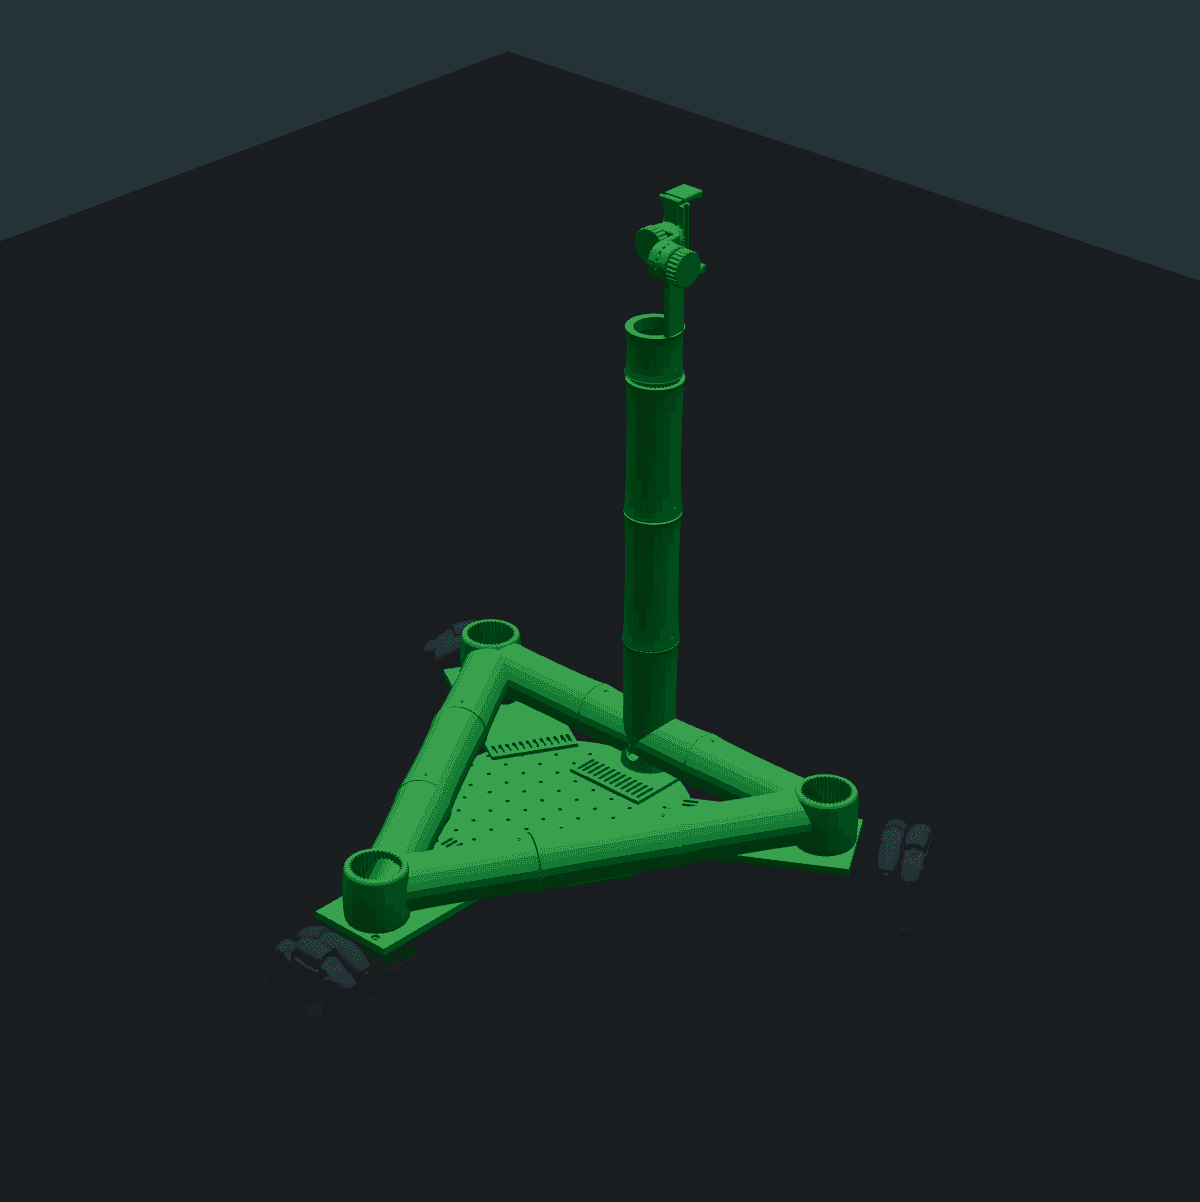
    Balance Ball

    A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Humanoid

    Bambot

    An open-source, low-cost humanoid robot designed for AI experimentation and education.

    • Work in progress
    • Works with AI
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    $300≈ €268 (ECB rate, 14 Oct 2026)
  • No photo yet
    Humanoid

    CocoNuts

    An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

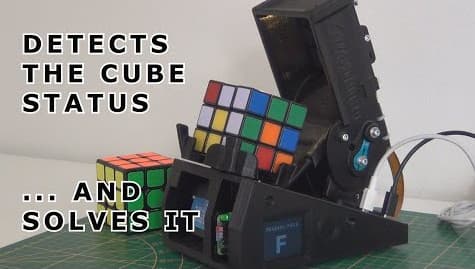
    CUBOTino autonomous

    A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

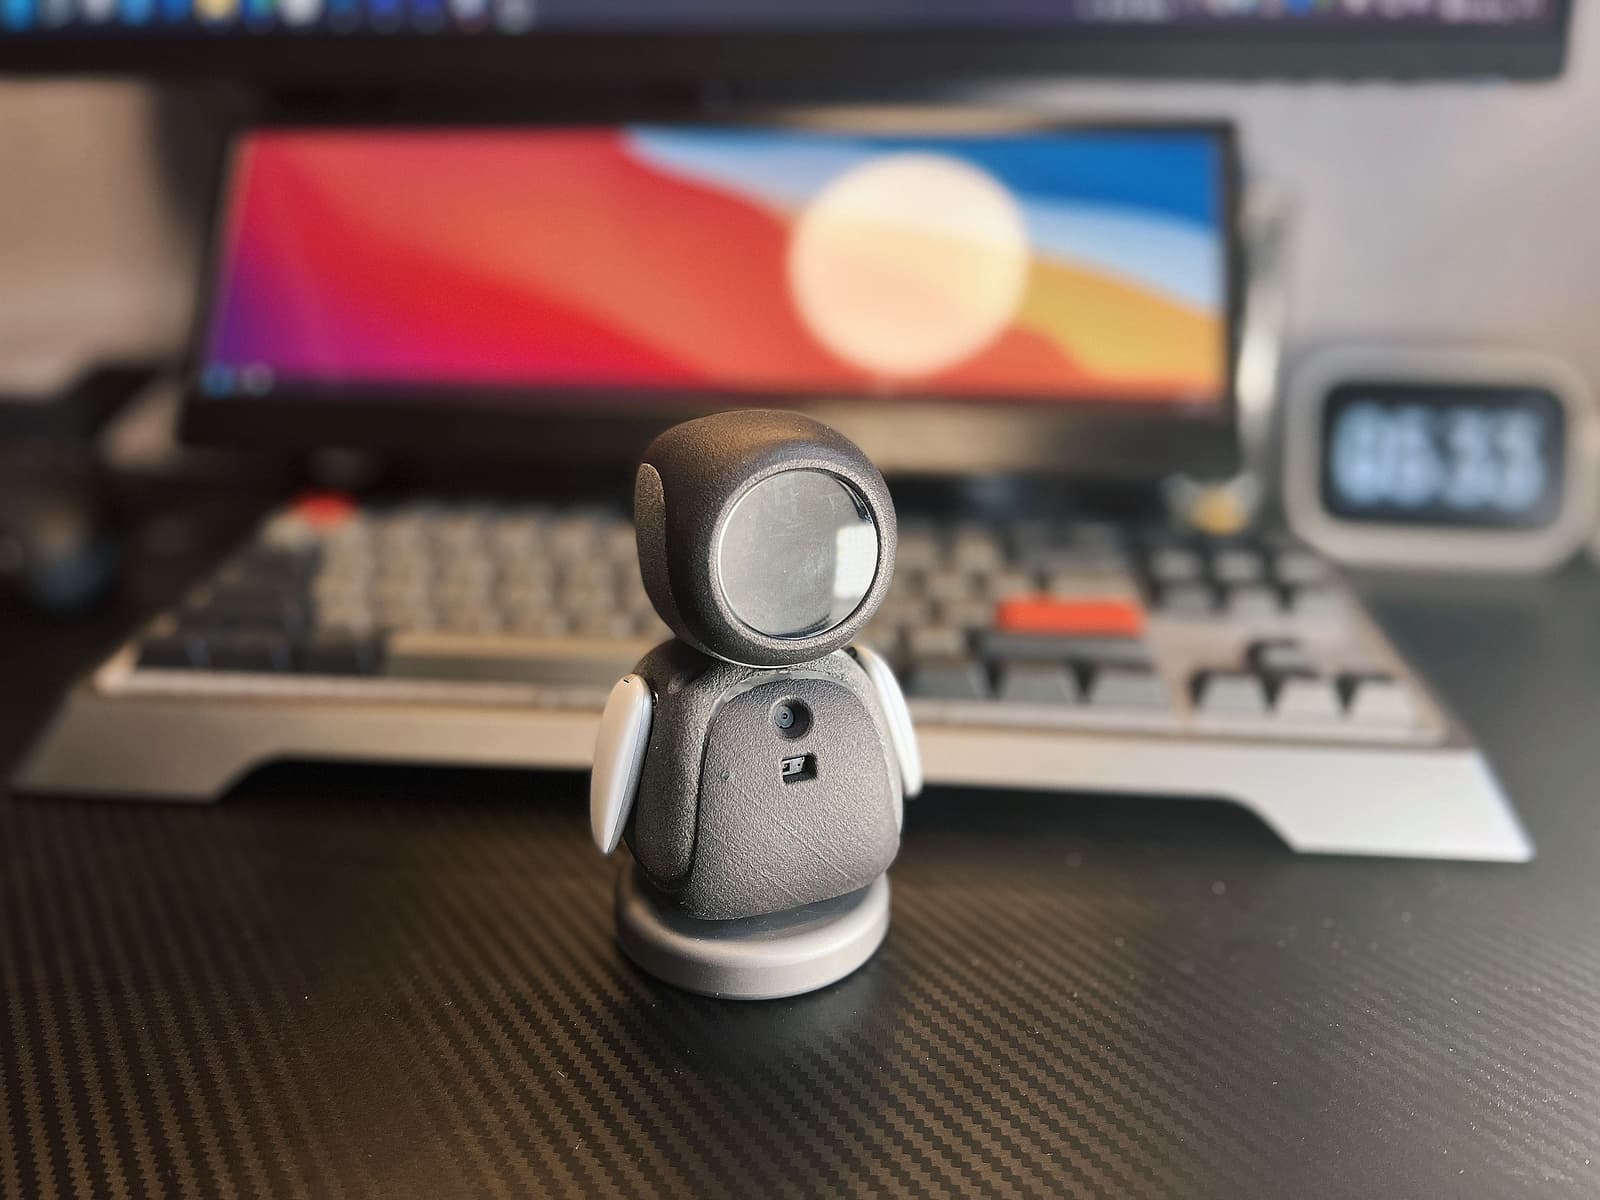
    Dagor Biped

    A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Humanoid

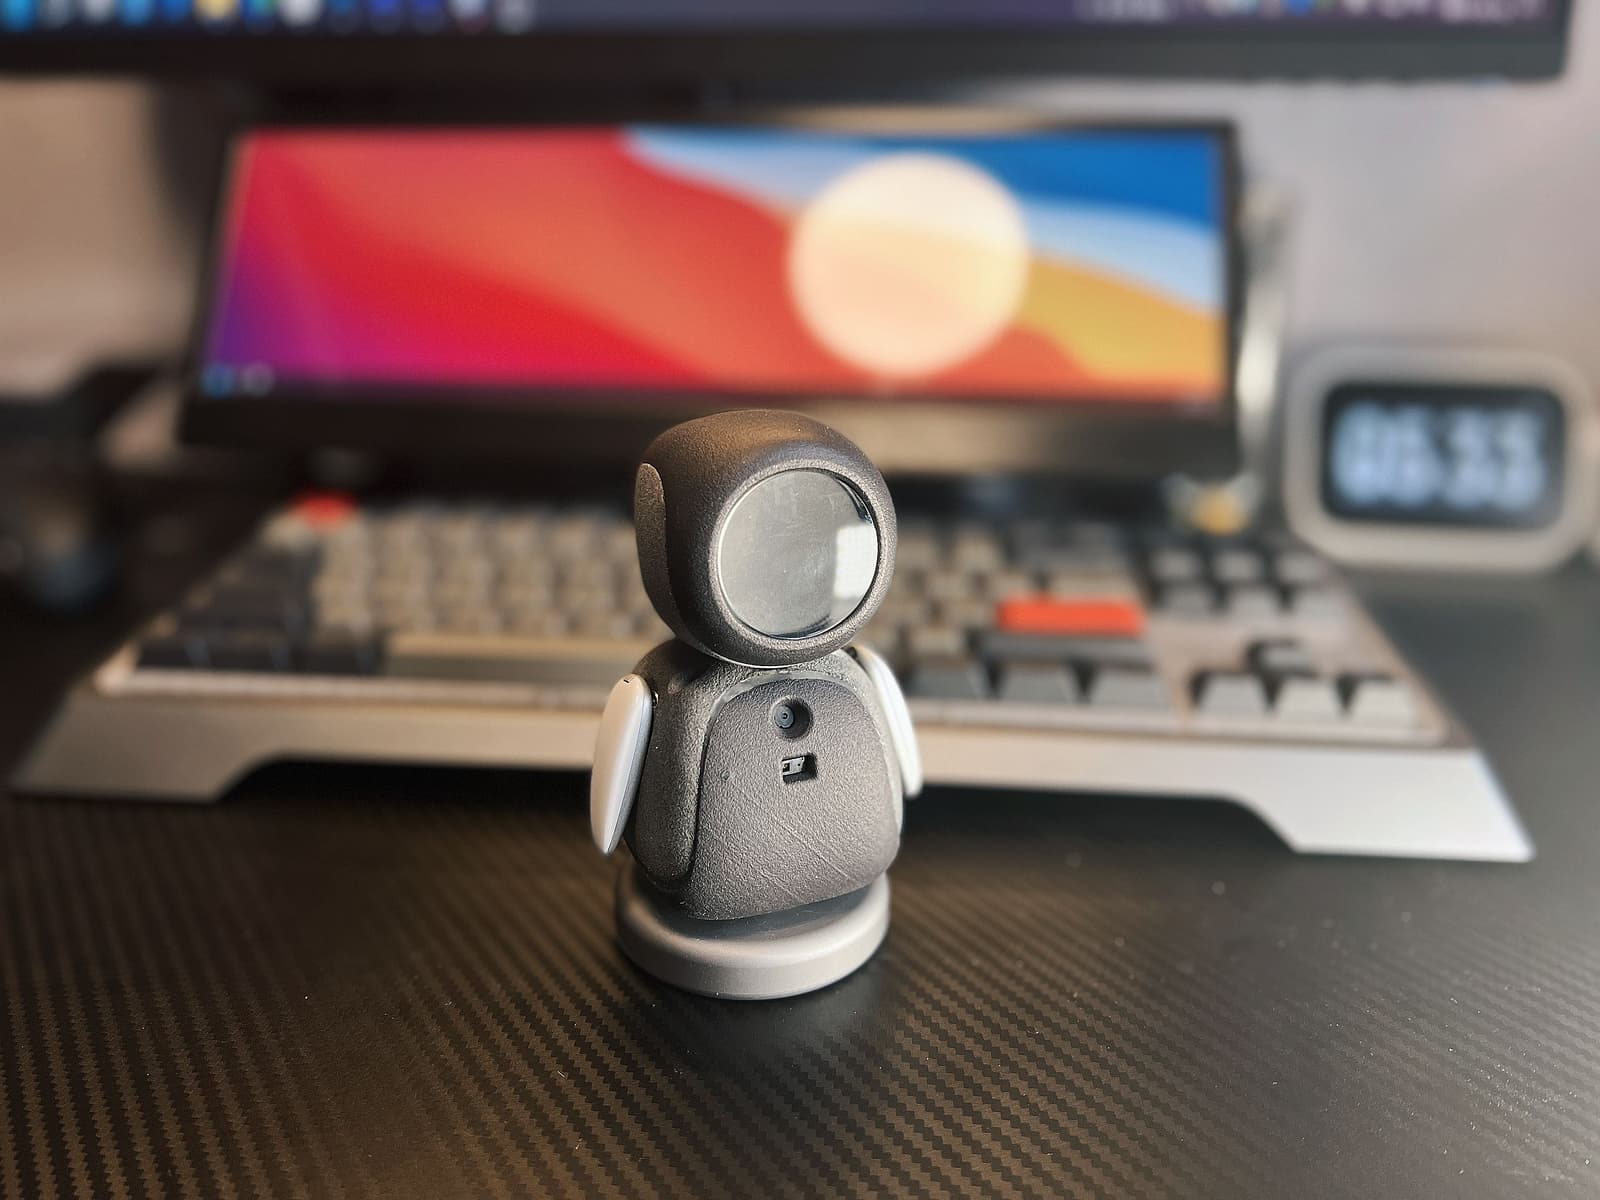
    ElectronBot

    A mini desktop robot with 6 degrees of freedom, USB communication, and a display screen, inspired by WALL-E's EVE.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Robot arm

    ElectronBot

    A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Self-driving 1:10

    EquiCycle

    An autonomous self-balancing bicycle robot designed for outdoor track racing, featuring lane detection, obstacle recognition, and balance control algorithms.
    • Works with AI
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

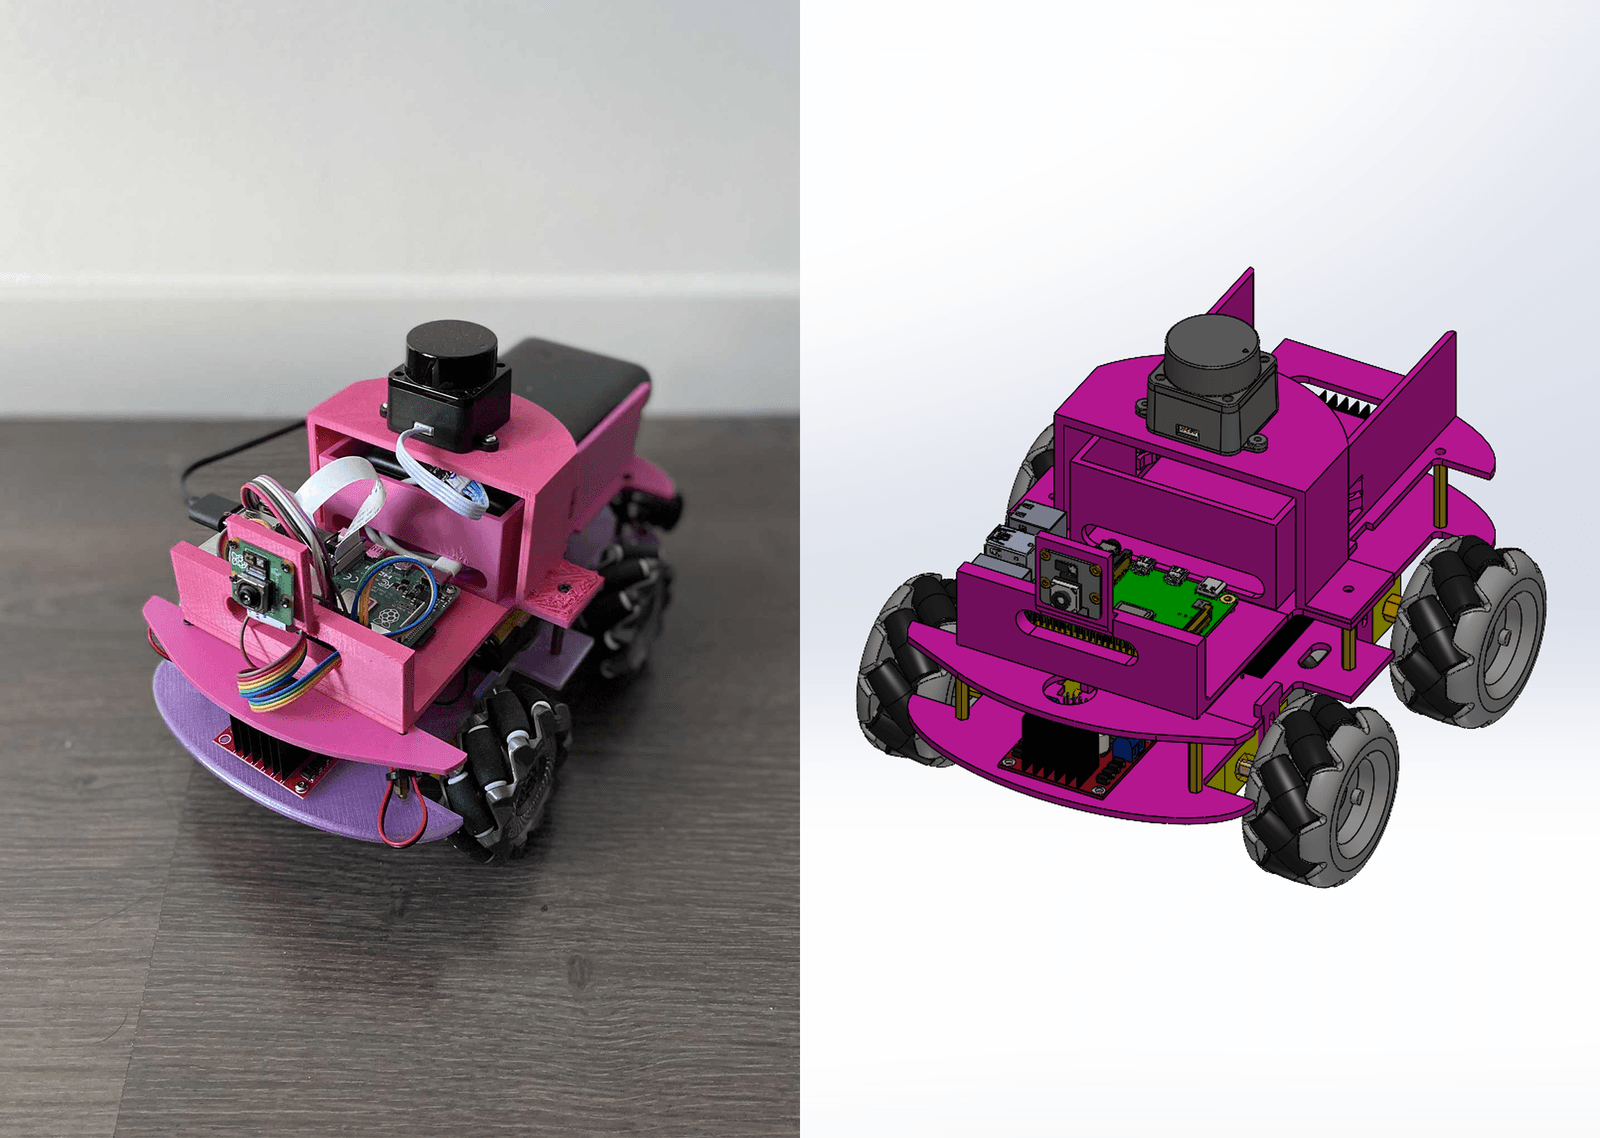
    Just1

    An open-source autonomous mecanum wheel robot for learning and experimentation that navigates manually or autonomously using a Lidar.
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    $250≈ €223 (ECB rate, 14 Oct 2026)
  • Humanoid

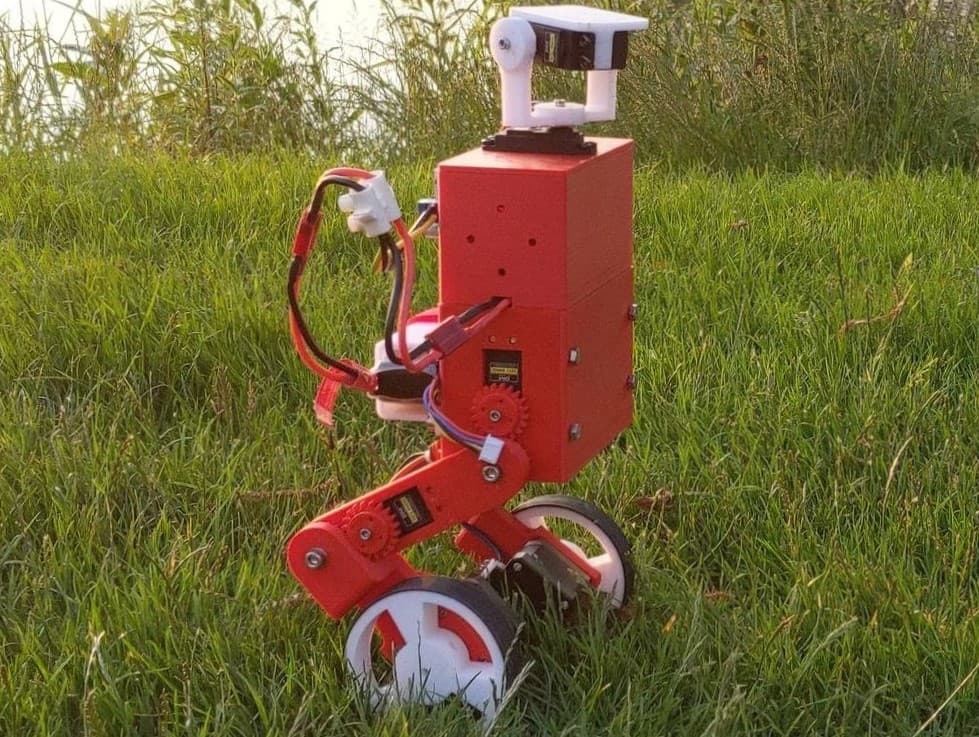
    Kayra

    An easy to modify, 3D printable open-source humanoid robot evolved by the community that walks, lifts and can be simulated.
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

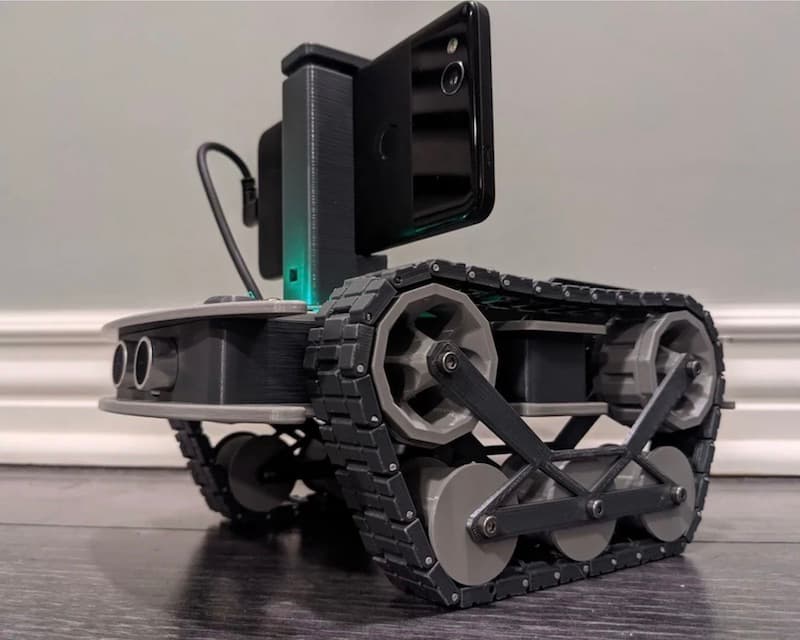
    MABEL

    MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

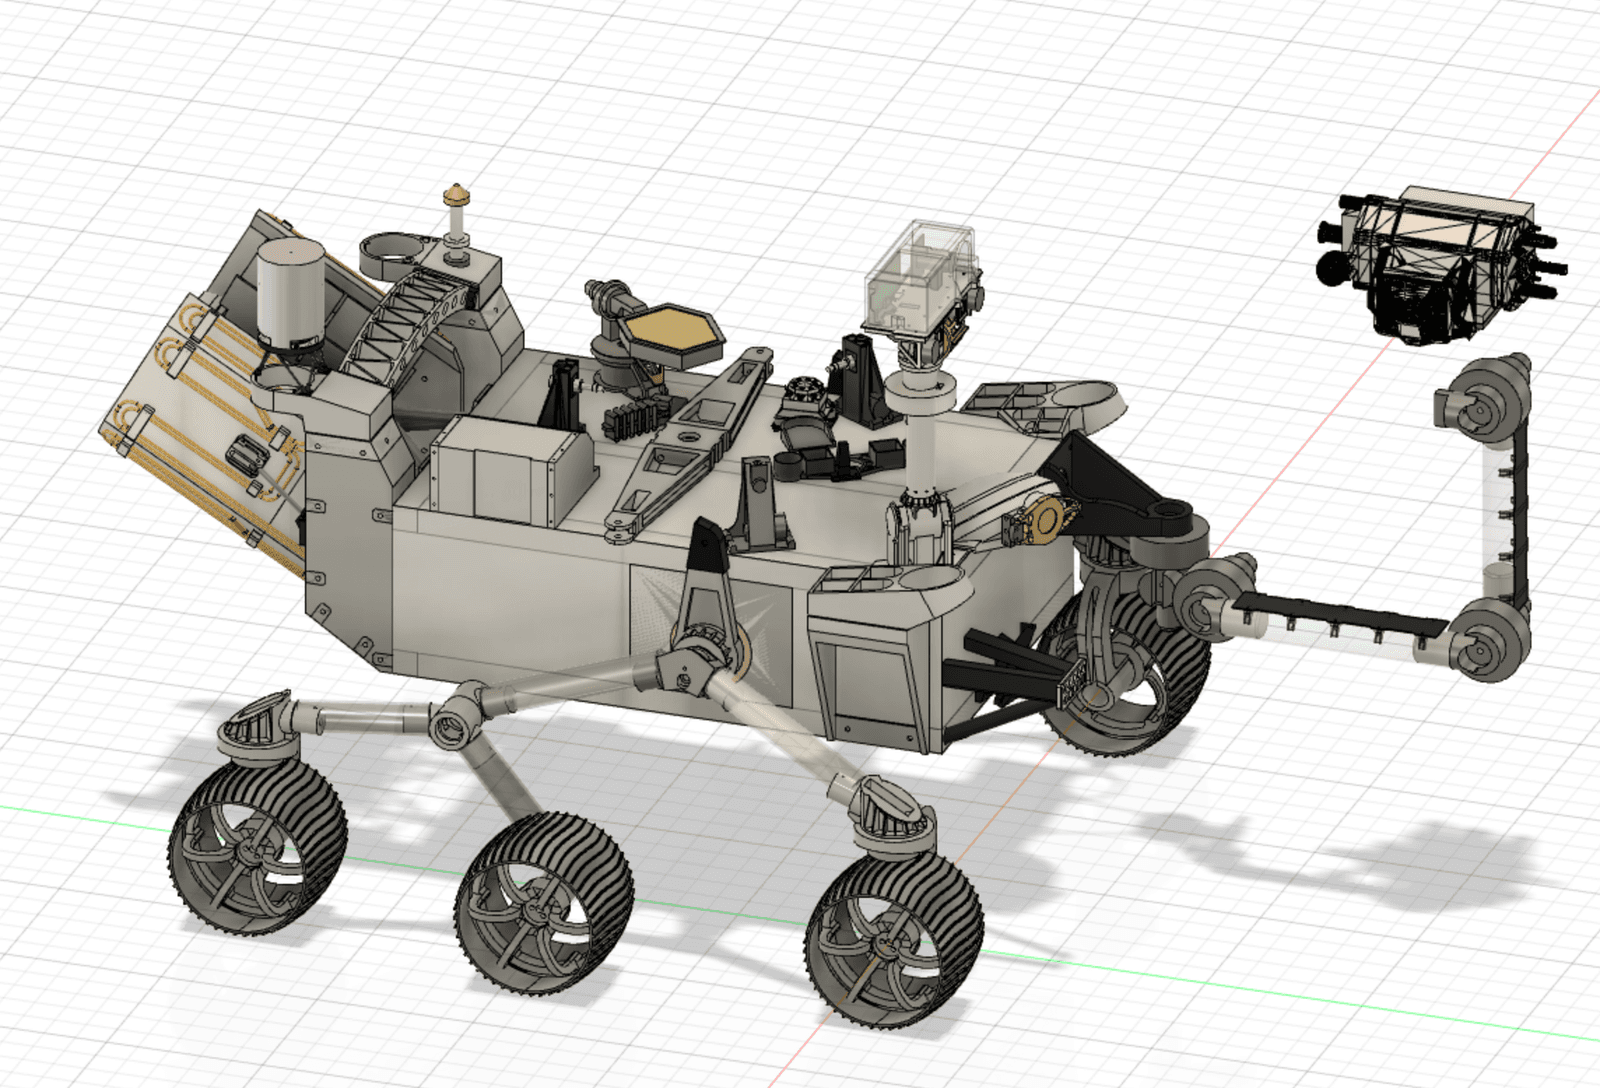
    OpenBot

    A low-cost small electric vehicle body that uses an Android smartphone as its brain, supporting person following and autonomous navigation.
    • Works with AI
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    $50≈ €45 (ECB rate, 14 Oct 2026)
  • Wheeled

    OpenPerseverance

    A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Wheeled

    Papaya Pathfinder

    Open-source, fully 3D-printable ESP32 rover platform with WiFi or ExpressLRS control, available in two variants.

    Level
    Beginner
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    SoftRobotETF

    A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Quadruped

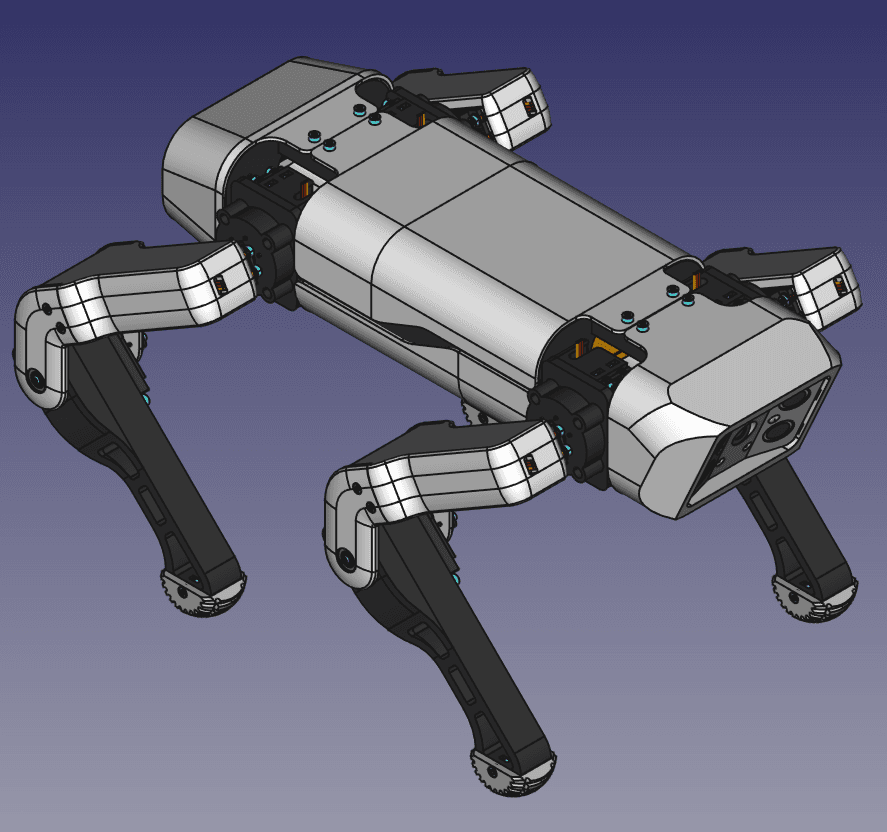
    SpotMicro ESP32

    A 3D-printable quadruped robot dog with support-free printed parts, controlled by an ESP32-DevKitC with heavy computation offloaded to external devices.
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

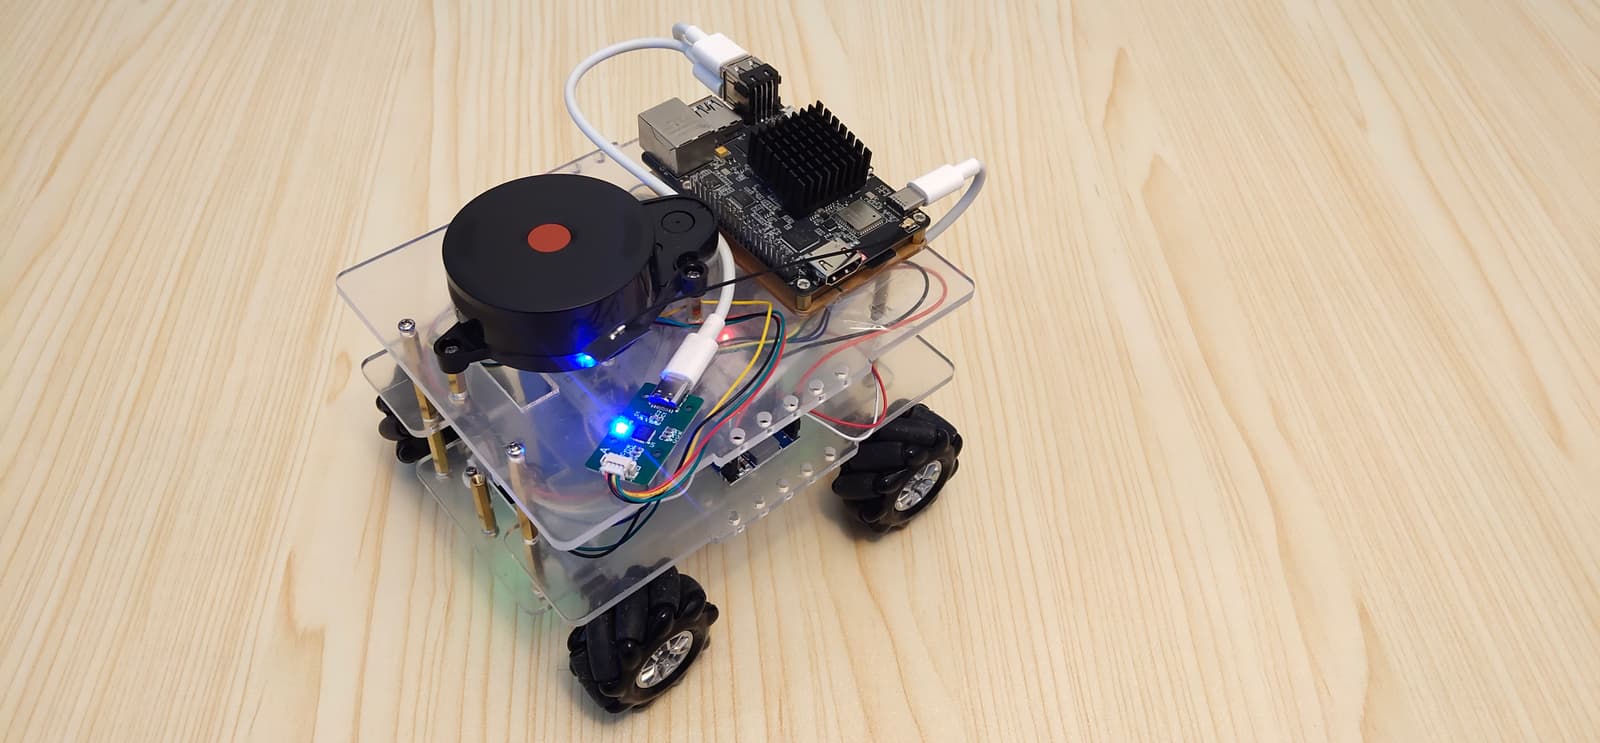
    T-Robot

    A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

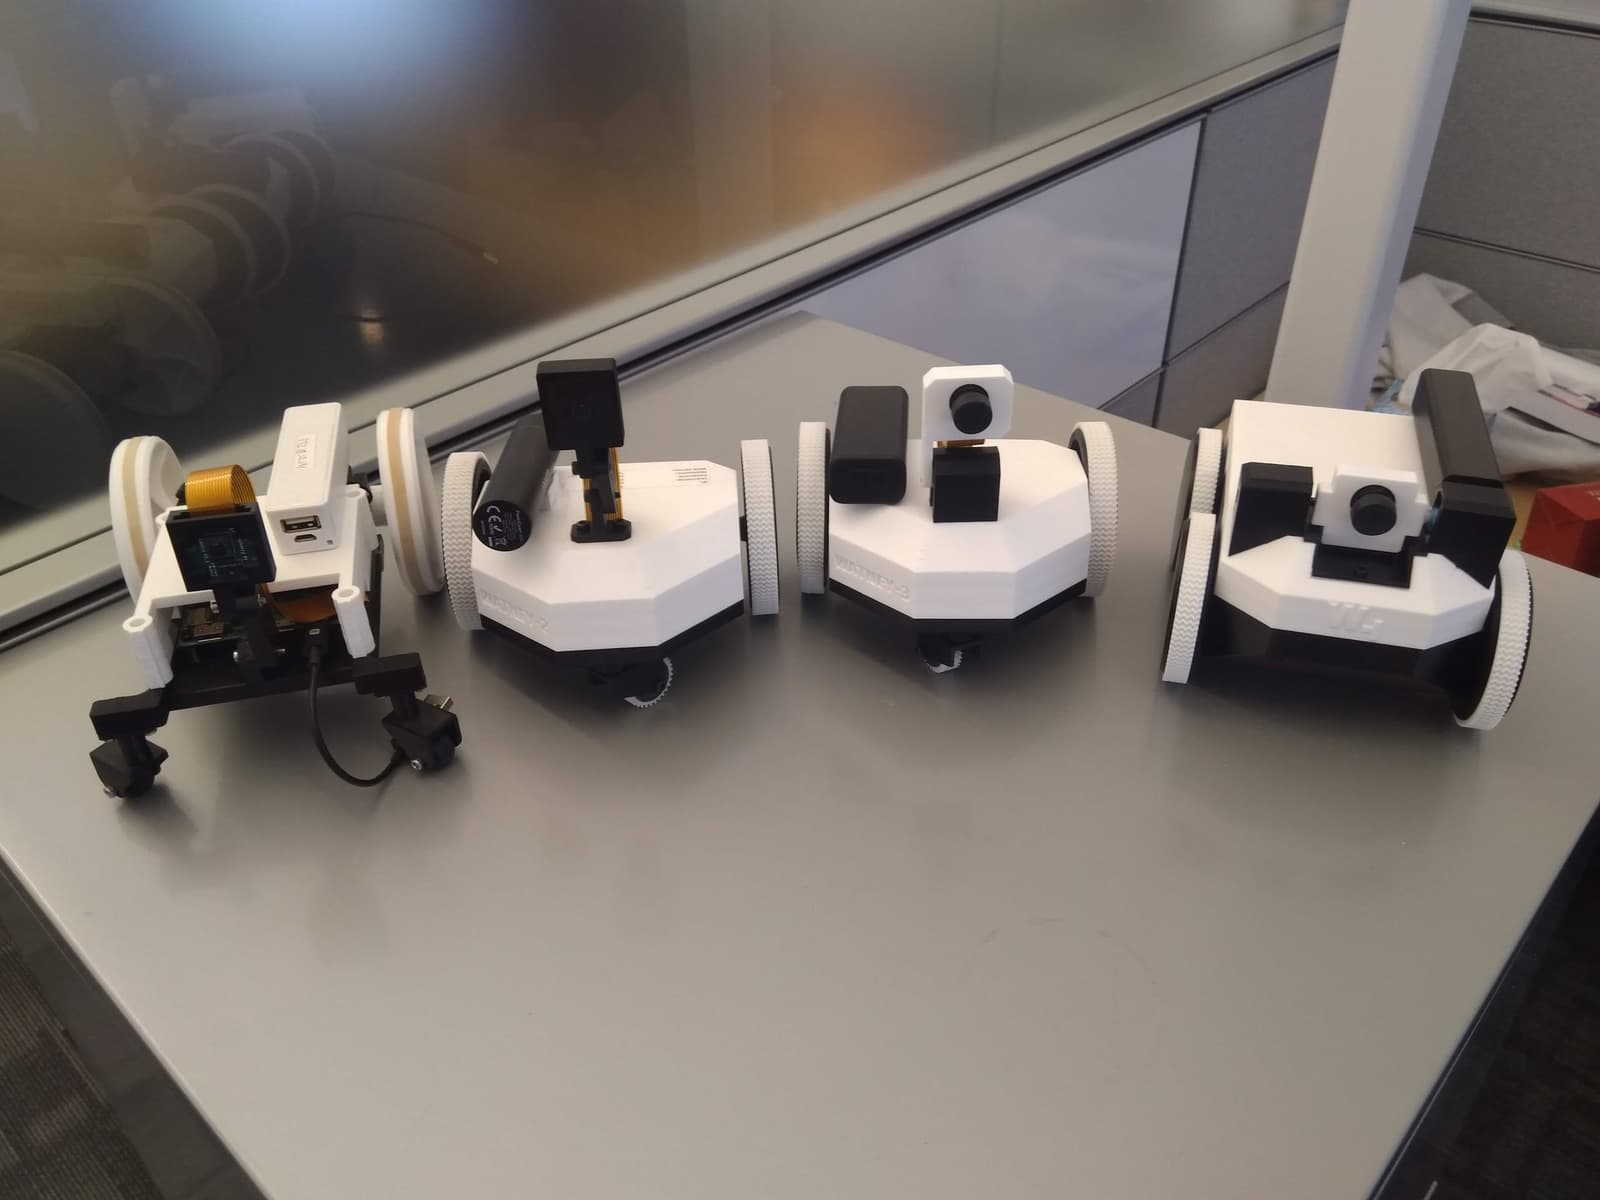
    Watney

    Watney is a low-cost, 3D-printable, Raspberry Pi-based FPV telepresence rover with HD video and bi-directional audio.

    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Quadruped

    Yertle

    A 3D printed quadrupedal robot with 4 limbs of 3 degrees of freedom each, built for locomotion research and reinforcement-learned walking.
    • Works with AI
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    £250≈ €296 (ECB rate, 14 Oct 2026)
  • Drone

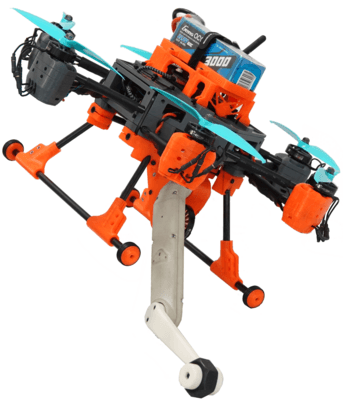
    Borinot

    An open-source, torque-controlled aerial loco-manipulator whose extremity can be reconfigured as a tail for flight, a hand for manipulation, or a leg for hybrid aerial-contact locomotion.

    Level
    Advanced
    Buildability
    51/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    AcroMonk

    A minimalist underactuated brachiating robot that swings along a horizontal ladder bar using one quasi-direct drive actuator and passive grippers.
    • Works with AI
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Antagonistic Tendon Driven Continuum Robot

    A research continuum robot with 4 degrees of freedom that drives two tendons per antagonistic pair with a single servo and measures tendon force with load cells.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Robot arm

    Arduinobot

    An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.

    Level
    Intermediate
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated

Robots 49–72 of 182

More to explore