JetBot
An educational open-source AI robot platform built on NVIDIA Jetson Nano for learning and experimenting with AI-based motion and collision avoidance.
- Wheeled
- Open source
- Works with AI
Suggested by Robotheca, created by @NVIDIA-AI-IOT (opens in a new tab), from github.com/NVIDIA-AI-IOT/jetbot (opens in a new tab). Pinned to commit 3ebfff2 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (19 scripts)
- docker/base/build.sh (opens in a new tab)
- docker/build.sh (opens in a new tab)
- docker/camera/build.sh (opens in a new tab)
- docker/camera/enable.sh (opens in a new tab)
- docker/configure.sh (opens in a new tab)
- docker/disable.sh (opens in a new tab)
- docker/display/build.sh (opens in a new tab)
- docker/display/enable.sh (opens in a new tab)
- docker/enable.sh (opens in a new tab)
- docker/jupyter/build.sh (opens in a new tab)
- docker/jupyter/enable.sh (opens in a new tab)
- docker/models/build.sh (opens in a new tab)
- docker/push.sh (opens in a new tab)
- docker/set_nvidia_runtime.sh (opens in a new tab)
- scripts/configure_jetson.sh (opens in a new tab)
- scripts/create-sdcard-image-from-scratch.sh (opens in a new tab)
- scripts/enable_swap.sh (opens in a new tab)
- scripts/re_enable_gui.sh (opens in a new tab)
- scripts/run-script-and-save-log.sh (opens in a new tab)
Photo and 3D model
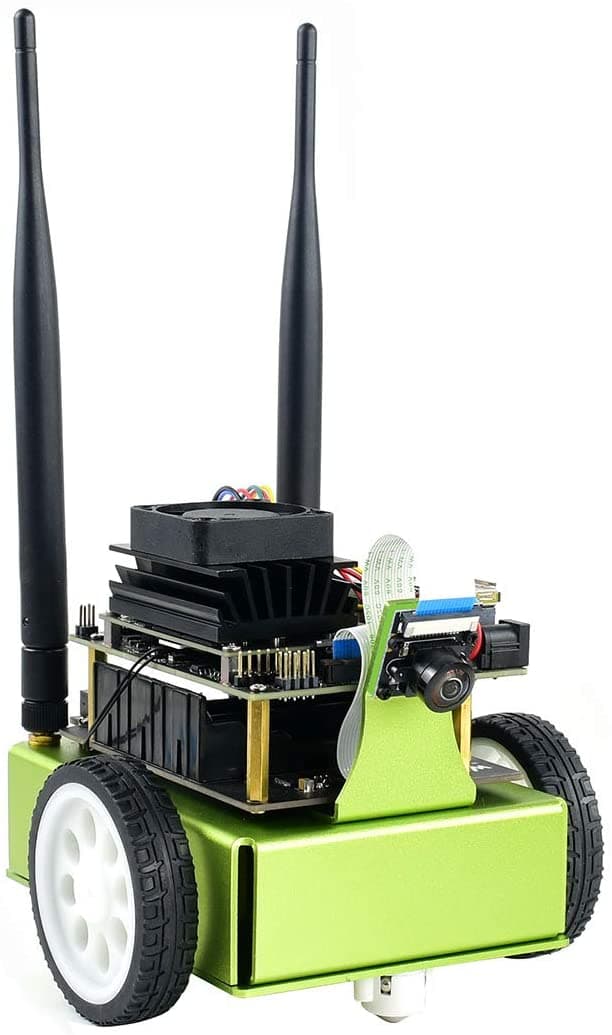
3D preview converted from github.com/NVIDIA-AI-IOT/jetbot at 3ebfff2, under MIT. View the original files from GitHub (3.1 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Serves as an open-source robot platform for AI learning and experimentation, based on NVIDIA Jetson Nano.
- Programmed interactively from a web browser through Jupyter notebooks.
- Supports basic motor motion control, teleoperation with a gamepad, and live camera image streaming.
- Supports AI examples such as collision avoidance, road following, and object following using trained or pre-trained models.
- Includes a camera container that publishes camera images over ZMQ for use by other containers.
Works with AI
Found by Robotheca in the project's files at commit 3ebfff2, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Uses a machine-learning library: TensorRT
In the project files: jetbot/ssd_tensorrt“Serves as an open-source robot platform for AI learning and experimentation, based on NVIDIA Jetson Nano.”
Robotheca's notes: What it can do“Supports AI examples such as collision avoidance, road following, and object following using trained or pre-trained models.”
Robotheca's notes: What it can do
Bill of materials
20 parts20 of 20 parts shown
≈ € amounts use the ECB reference rate of 14 Oct 2026, for comparison only.
4 of 20 parts have no price in the source, so there is no parts total. Read from docs/bill_of_materials.md at the pinned commit.
Build guide
The guide appears here as you scroll.
Guide by @NVIDIA-AI-IOT (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- NVIDIA Jetson Nano is the main computer the robot is based on.
- Motors with a motor driver drive the robot.
- A camera is mounted on the chassis.
- WiFi card or USB WiFi dongle (TP-Link Archer T2U Nano or Plus) provides network connectivity.
- Battery and power supply power the robot.
- Optional PiOLED display with header.
Connections
- The documents do not describe how the parts are connected.
Cables and connectors
From the parts list.
- USB cable pack × 1
