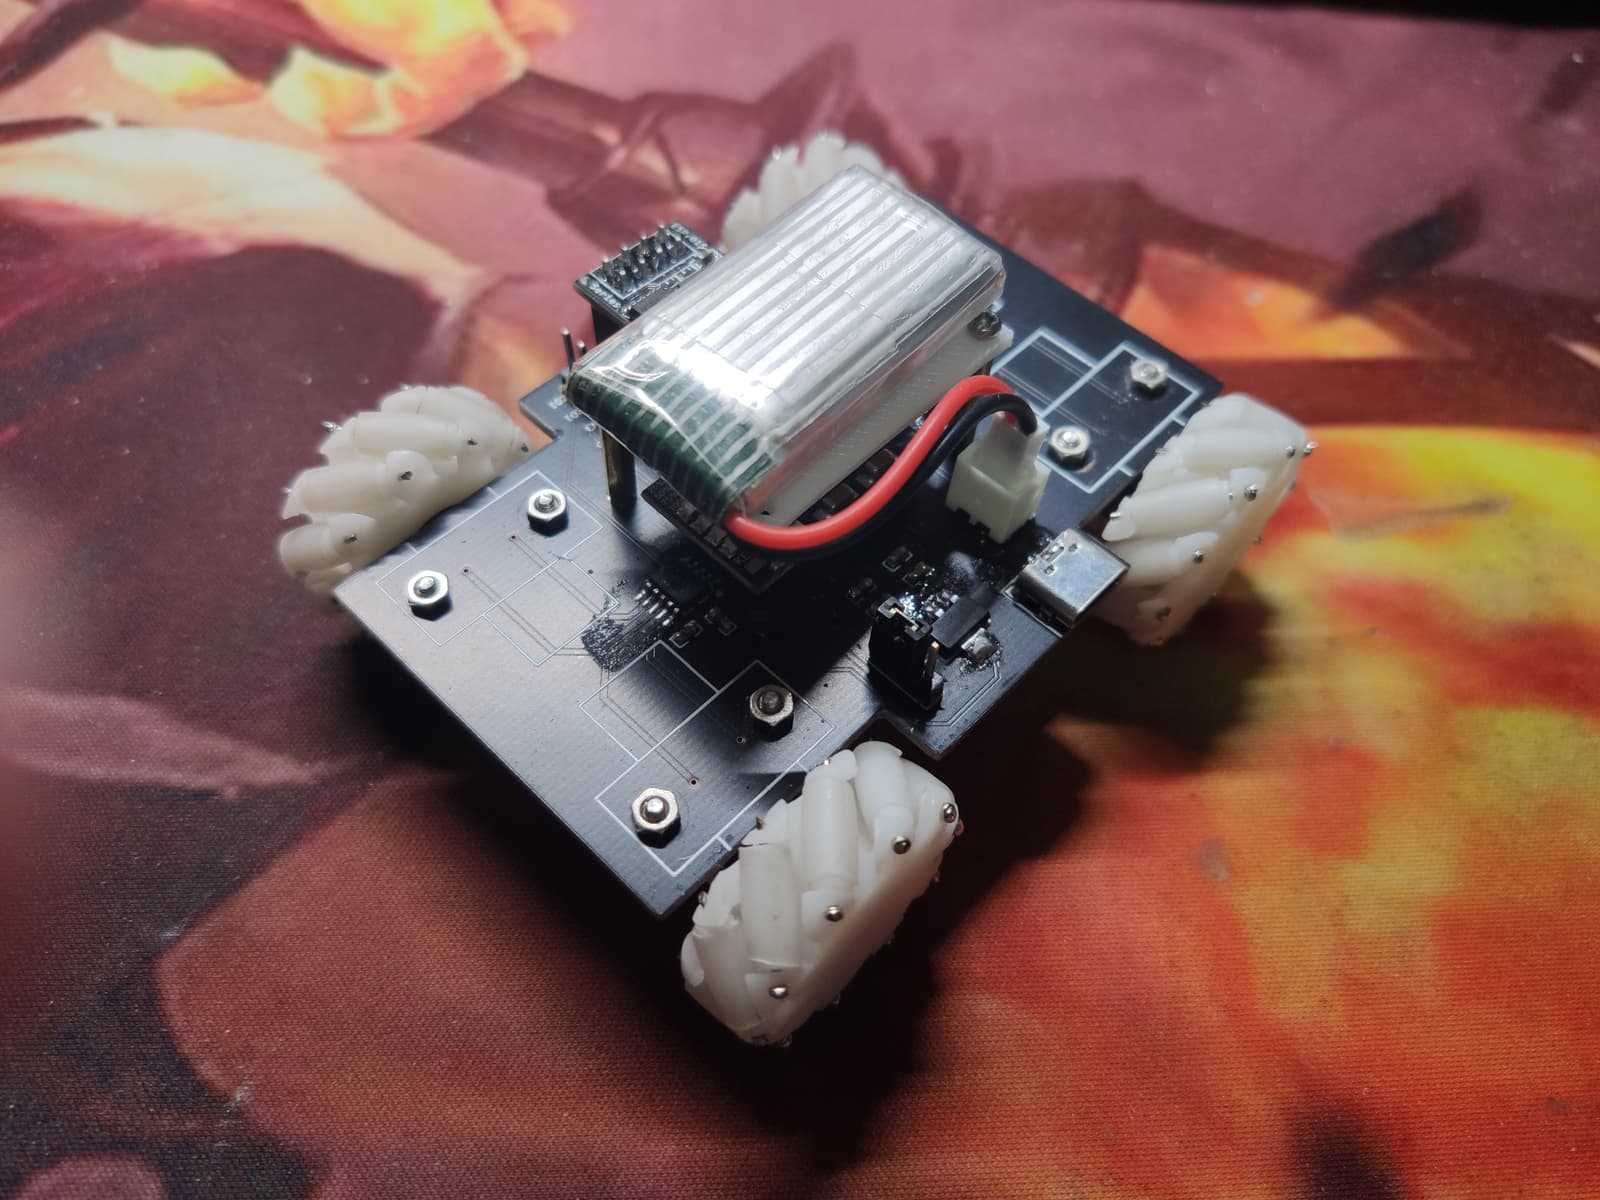
 Wheeled
MCar
A small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.
- Level
- Intermediate
- Buildability
- 50/100
- Buildable with some effort
- Cost
- ¥40≈ €5 (ECB rate, 15 Oct 2026)
Robots whose build needs a 3D printer for their parts. 233 robots on Robotheca, each with its licenses and its source on GitHub.
Page 4 of 10 · Ready to build first, then by buildability
WheeledA small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.
 Quadruped
A desktop quadruped robot based on ESP8266 with voice control, gesture recognition, web remote, and AI conversation.
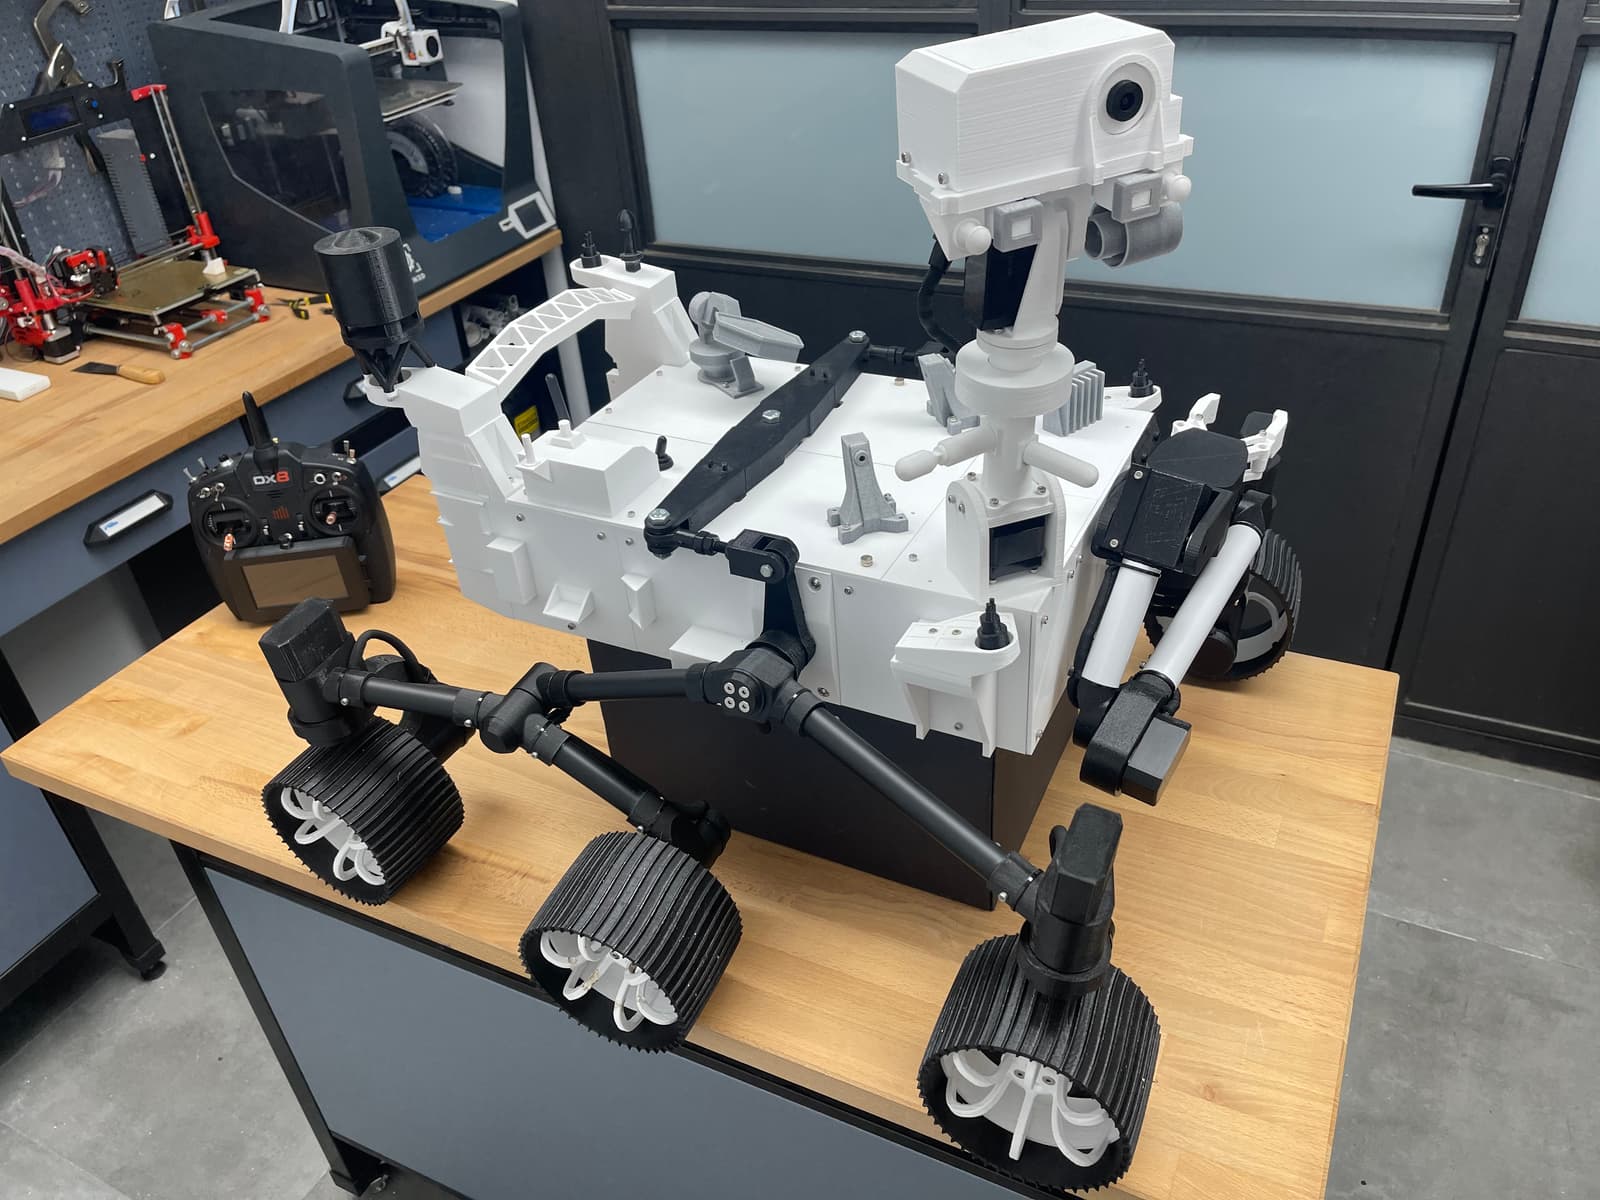 Wheeled
A 3D-printed Mars Perseverance-style rover replica with a 6-wheel drive, 4-axis robotic arm, and remote control with touchscreen and web dashboard.
A small, low-cost 6-degree-of-freedom 3D-printed robot arm driven by Dynamixel XL-320 motors and controlled from a Raspberry Pi.
An open-source autonomous quadrotor drone built by the NEU REAL Lab, with a high-load, stable-localization design for autonomous obstacle avoidance flight.
 Other
A JavaScript-driven, super-kawaii desktop robot built on the M5Stack platform, with open-source firmware, MODs, and printable cases.
 Wheeled
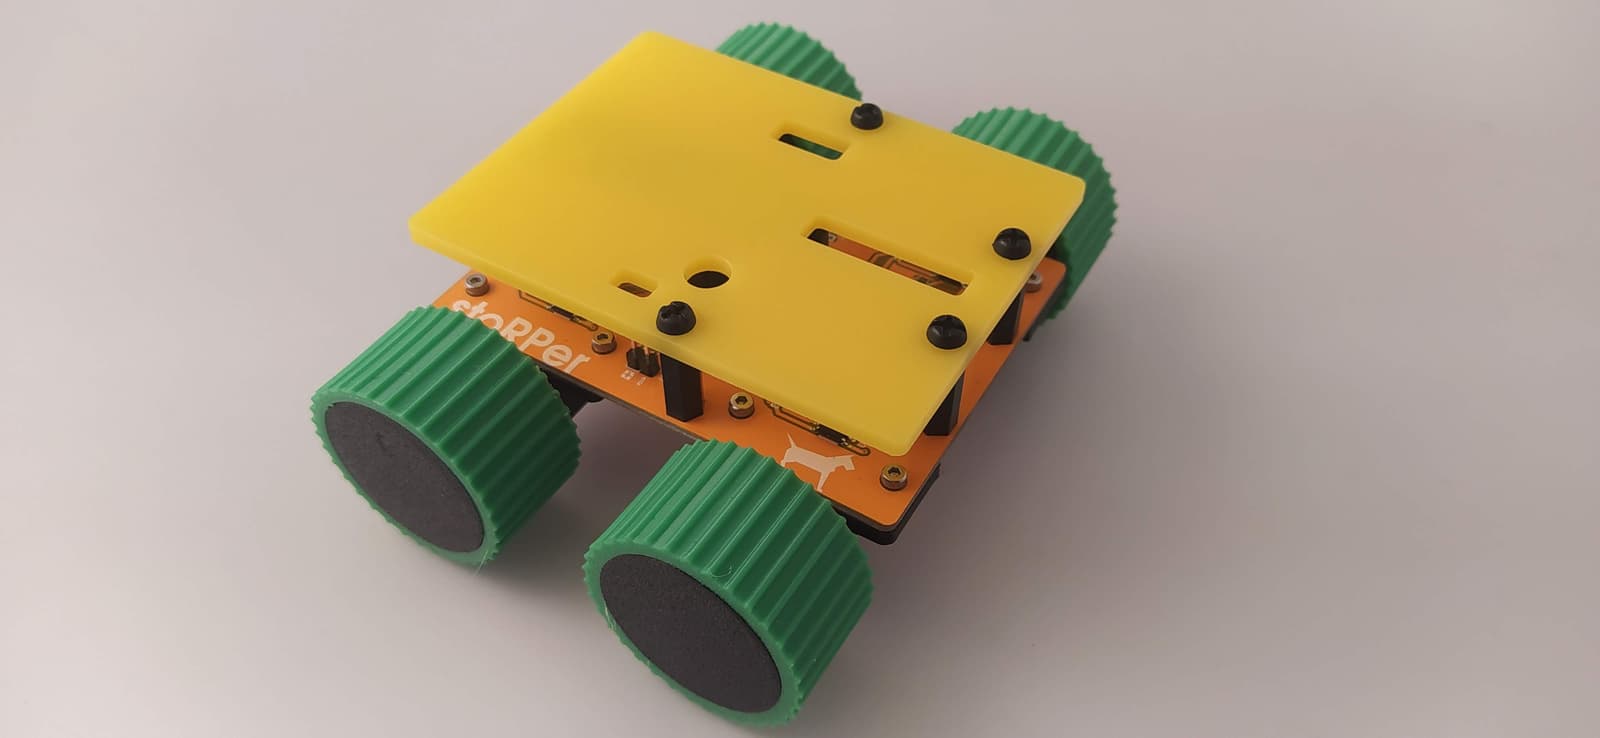
A modular, adaptable all-wheel-drive rover built around a Raspberry Pi Pico board, with 3D-printed motor mounts and optional add-on bumpers and decks.
 Wheeled
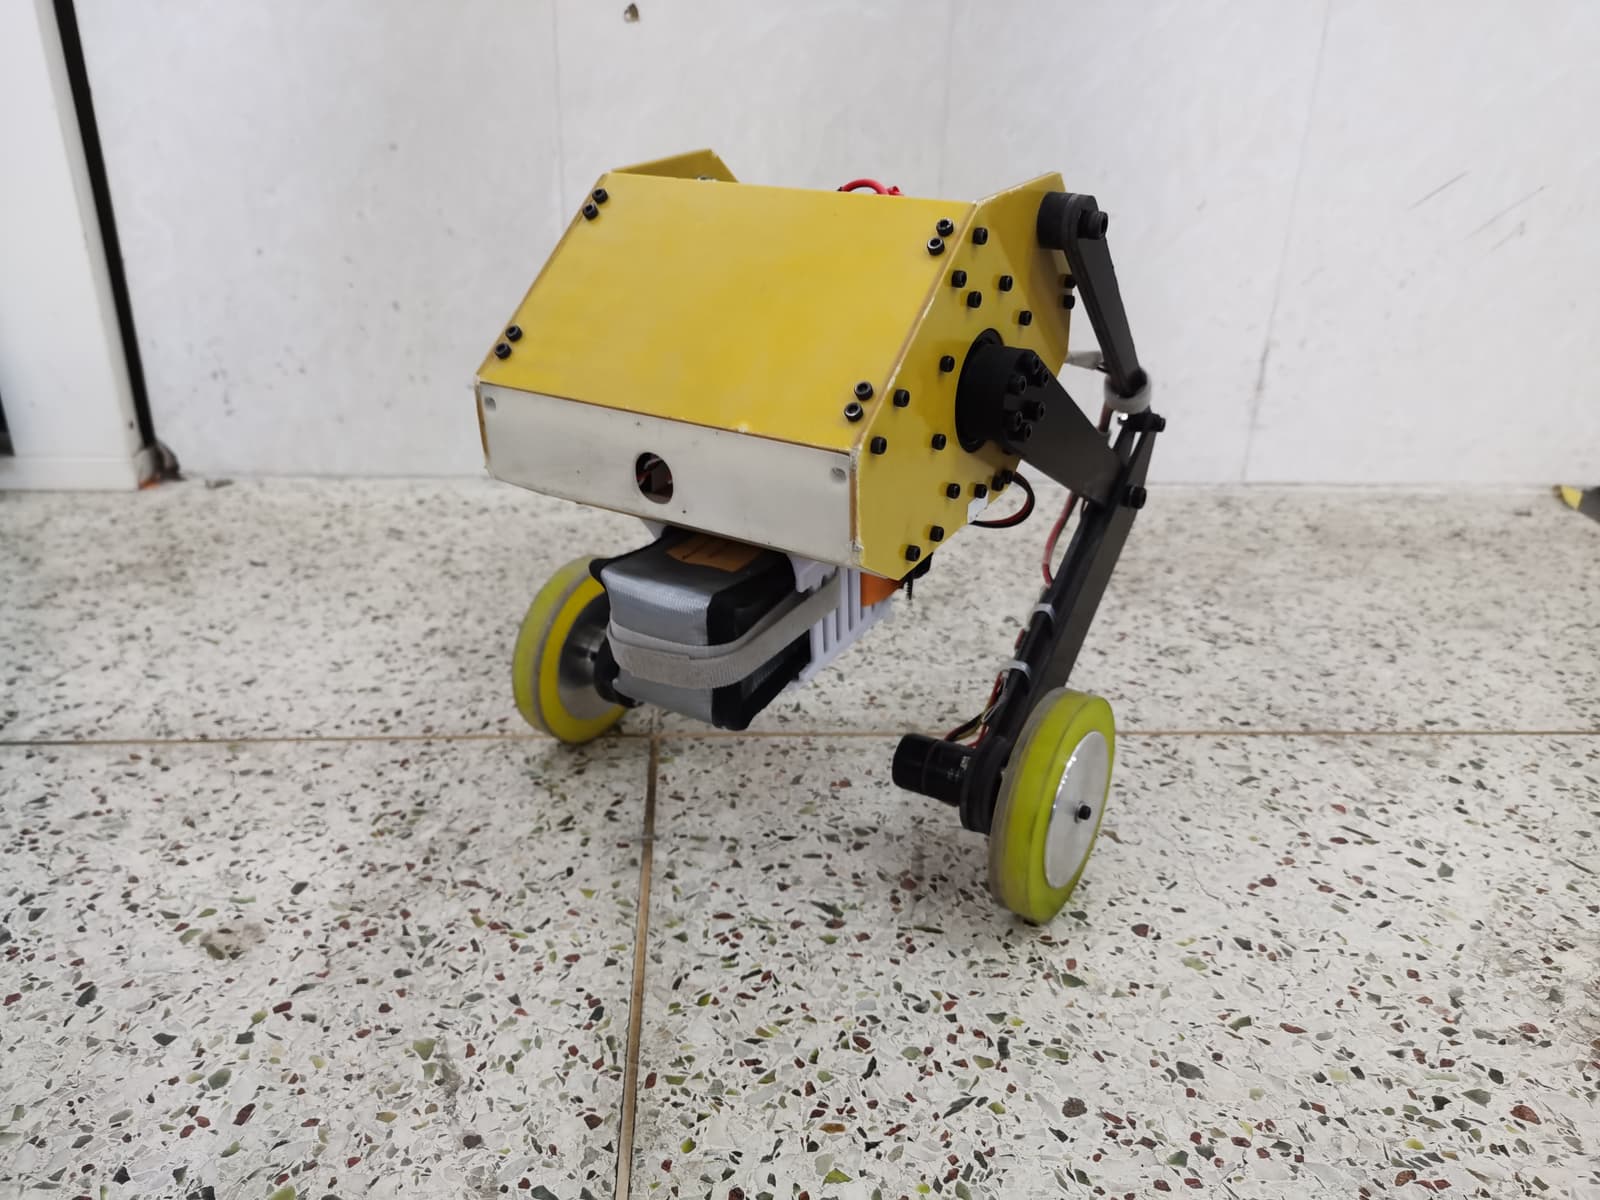
A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.
 Wheeled
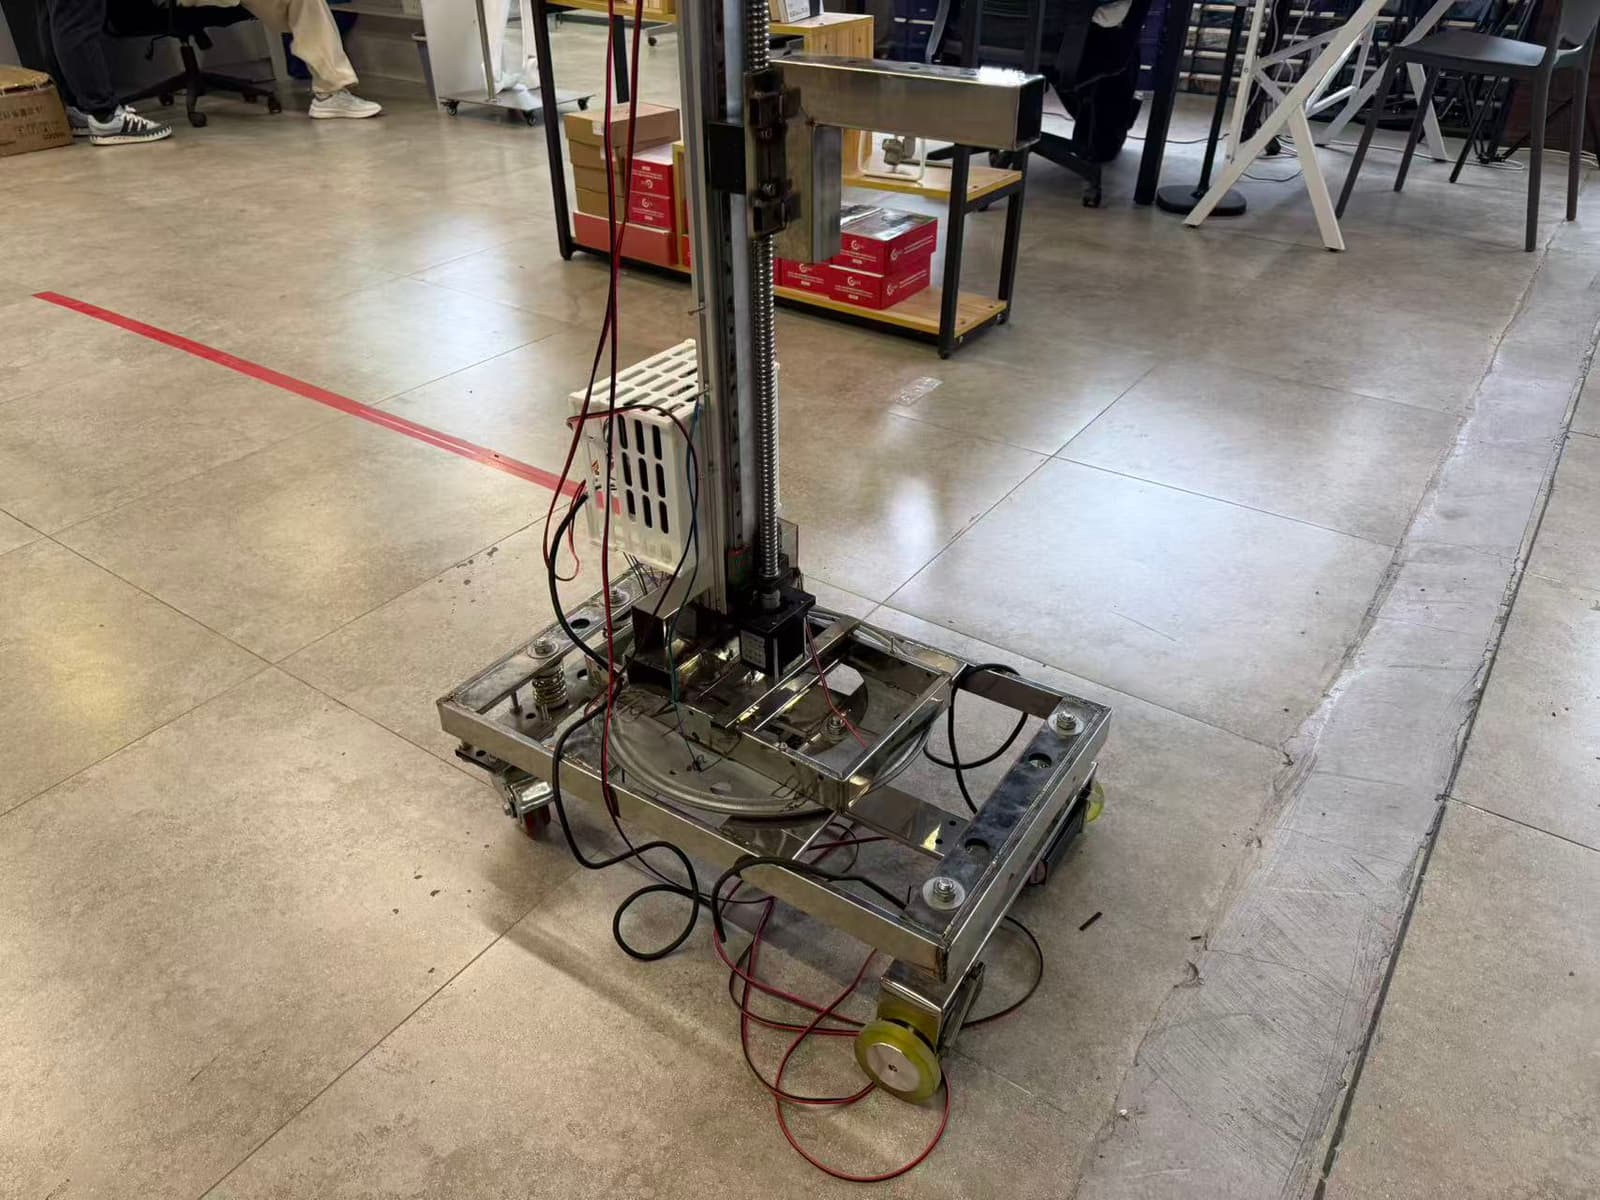
An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.
A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
 Other
An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.
A small 4-degree-of-freedom robot arm with 3D printed parts, driven by four SG90 servos and an Arduino Nano.
 Wheeled
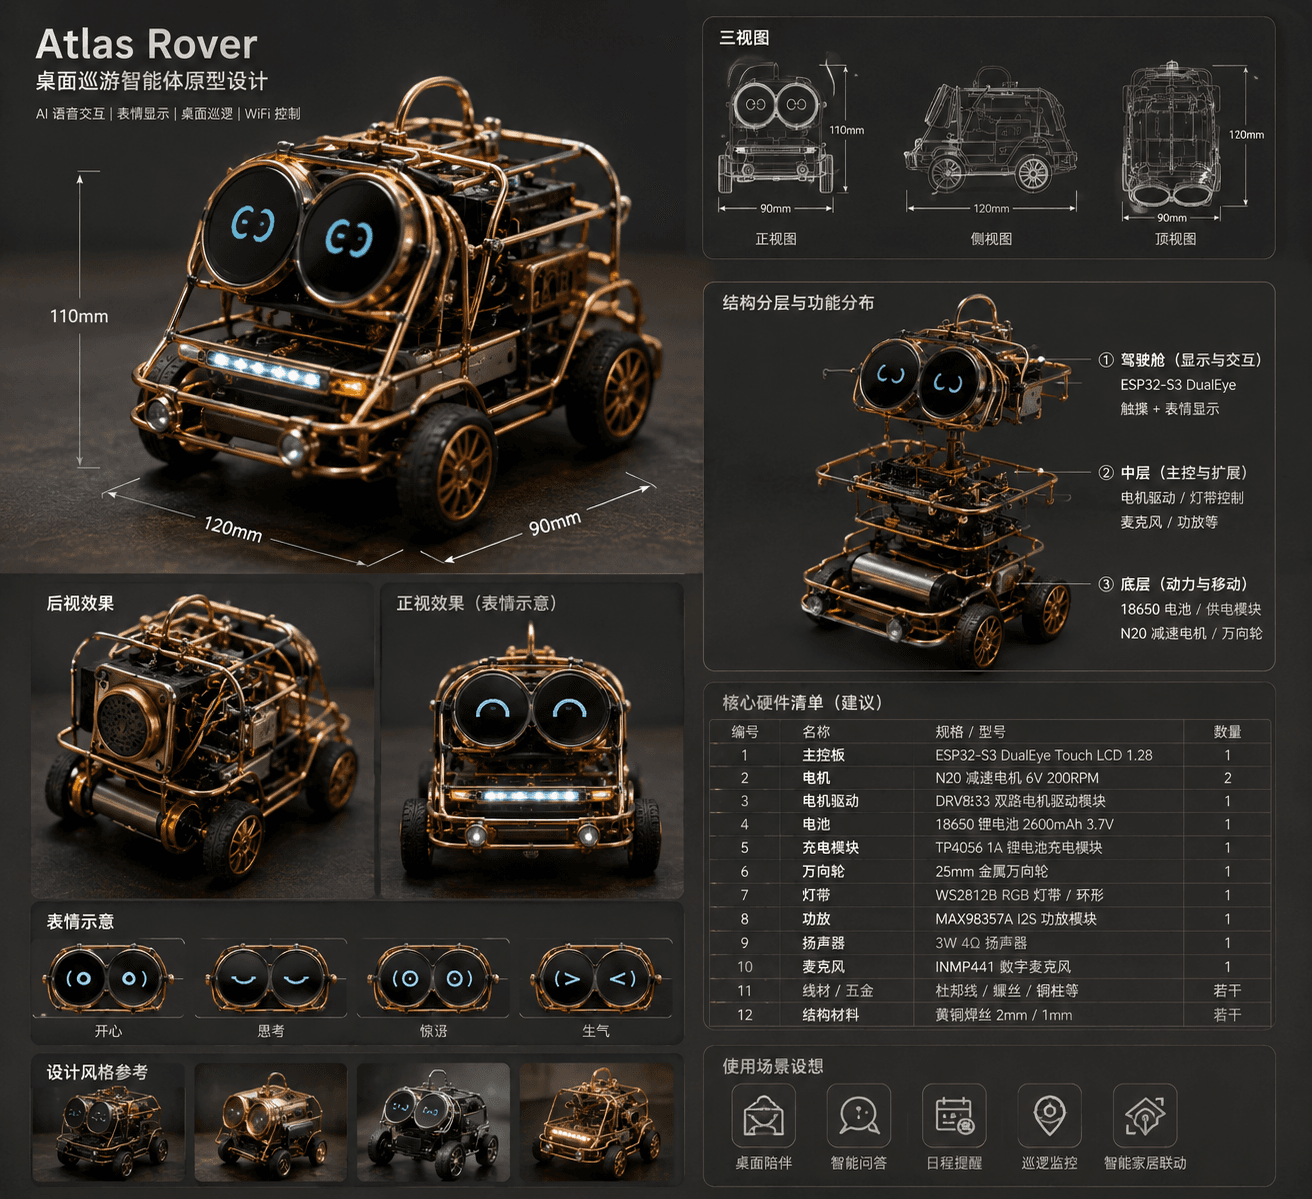
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
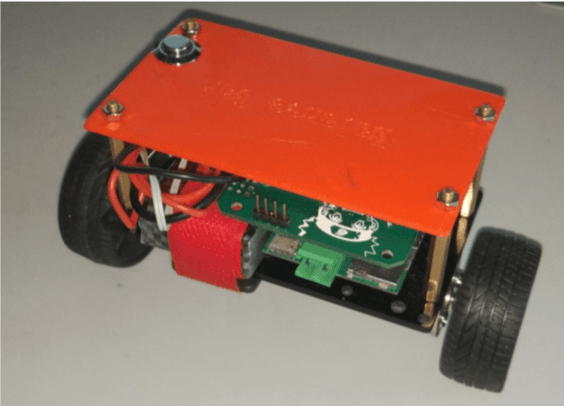 Wheeled
A self-balancing robot car controlled via Bluetooth with STM32 and Android support.
 Robot arm
A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.
 Robot arm
A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
An open-source 250mm autonomous quadrotor drone that flies in unknown environments and avoids obstacles using VINS visual-inertial odometry and EGO-Planner.
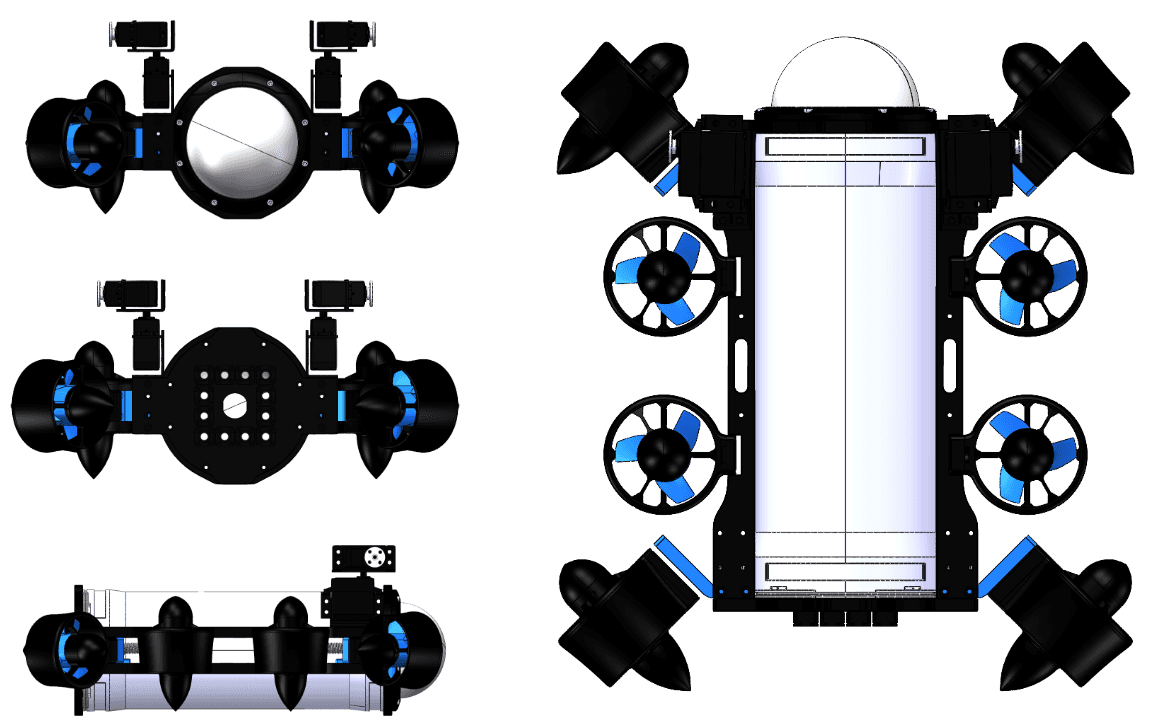 Drone
FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
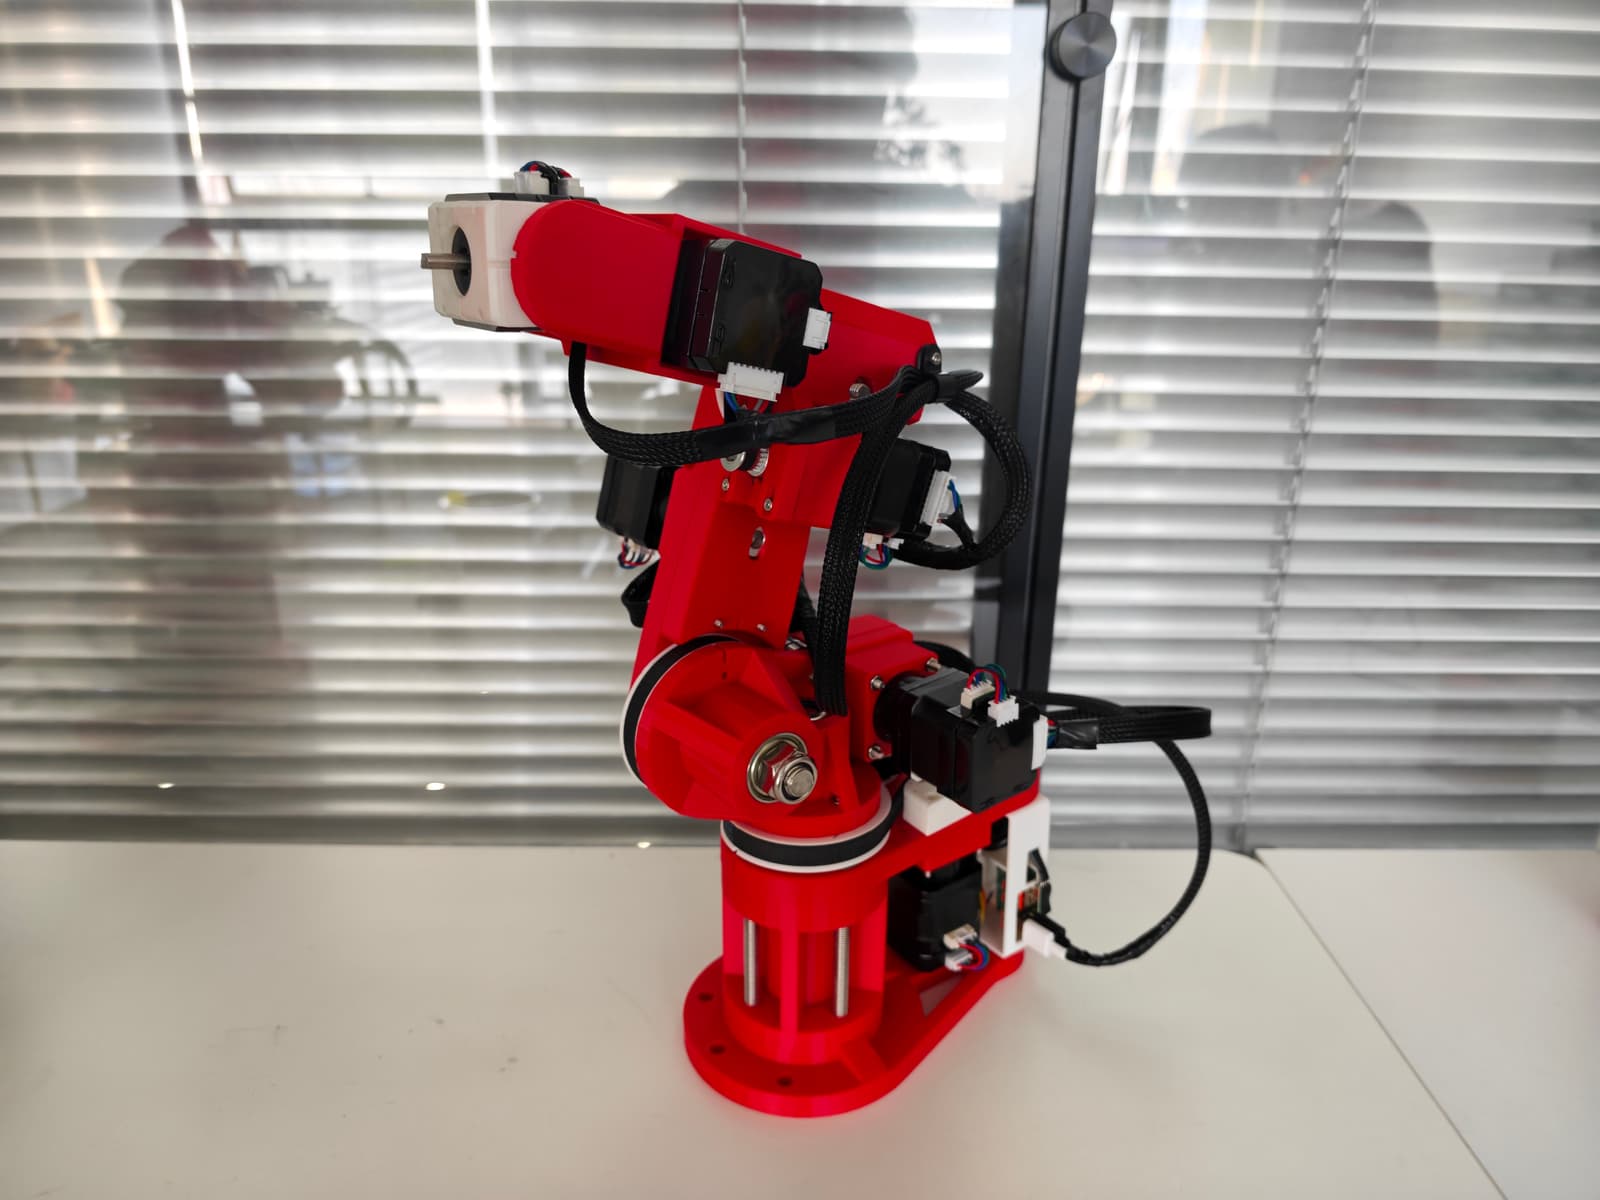 Robot arm
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
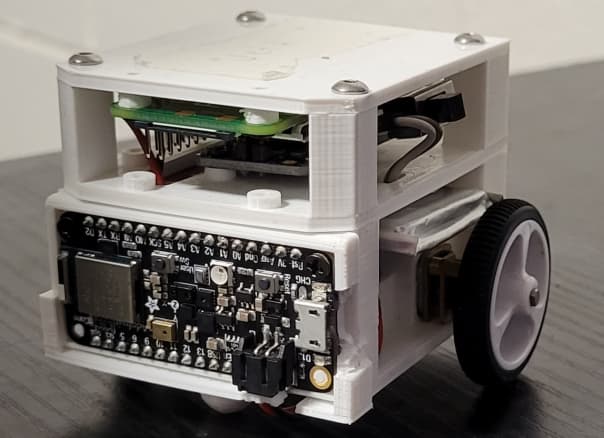 Wheeled
A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.
 Other
A family of 18-DOF, 3D-printed hexapod walking robots powered by an ESP32, controlled over WiFi or live pose streaming.
 Other
A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.
 Quadruped
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
A two-wheeled, four-bar-linkage wheel-leg balancing robot modeled on the ASCENTO, controlled with LQR on an STM32H723 board.
Robots 73–96 of 233