Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 15 Oct 2026. Robots without a known cost are hidden unless you include them.

270 robots

Page 8 of 12 · Ready to build first, then by buildability

  • Photo on GitHub
    Humanoid

    MicroDuck

    An independent hobbyist recreation of the MicroDuck 3D model, provided as SolidWorks source files and a STEP export for a small robot.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Humanoid

    Microduck Replica

    A 15-degree-of-freedom open-source humanoid robot replica with editable SolidWorks CAD and assembly instructions.

    • No license
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    ¥828≈ €110 (ECB rate, 15 Oct 2026)
  • No photo yet
    Quadruped

    Moco-Minitaur LTS

    An open-source 8-DOF desktop quadruped robot platform with force control capabilities.

    • No license
    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Naviton

    Naviton is an open-source robot whose CAD data and electronic circuit designs are published in this repository.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    OmniNxt

    A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Humanoid

    OpenZero

    A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.

    • Work in progress
    • No license
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Peeqo

    A desktop robot that responds entirely in its own voice, built from 3D-printed parts and custom electronics.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Quadruped

    PiHexa V1

    A hexapod robot powered by Raspberry Pi Zero 2 W and controlled using Python, featuring 18 servo motors and remote operation via Bluetooth.

    • No license
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    ProtoBot

    An ultra cheap, simple two-motor robot with four sensors that a middle schooler can build in several hours.

    Level
    Beginner
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
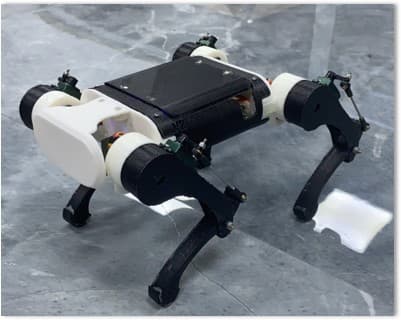
    Quadruped

    Py-Apple BLDC Quadruped Robot

    An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
    • Work in progress
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

    Py-Apple Dog

    An open-source quadruped robot designed for easy DIY with low-cost hardware and software.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Quadruped

    Py-Apple Structure Quadruped

    An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Raspberry Pi Cat

    A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Raspberry Pi Mouse

    A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Wheeled

    RoboChassis F427

    A universal electronic control software architecture for a Mecanum wheel chassis robot based on STM32F427, designed for Robocon 2024 R1.

    • No license
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    RR1: Real Robot One

    A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
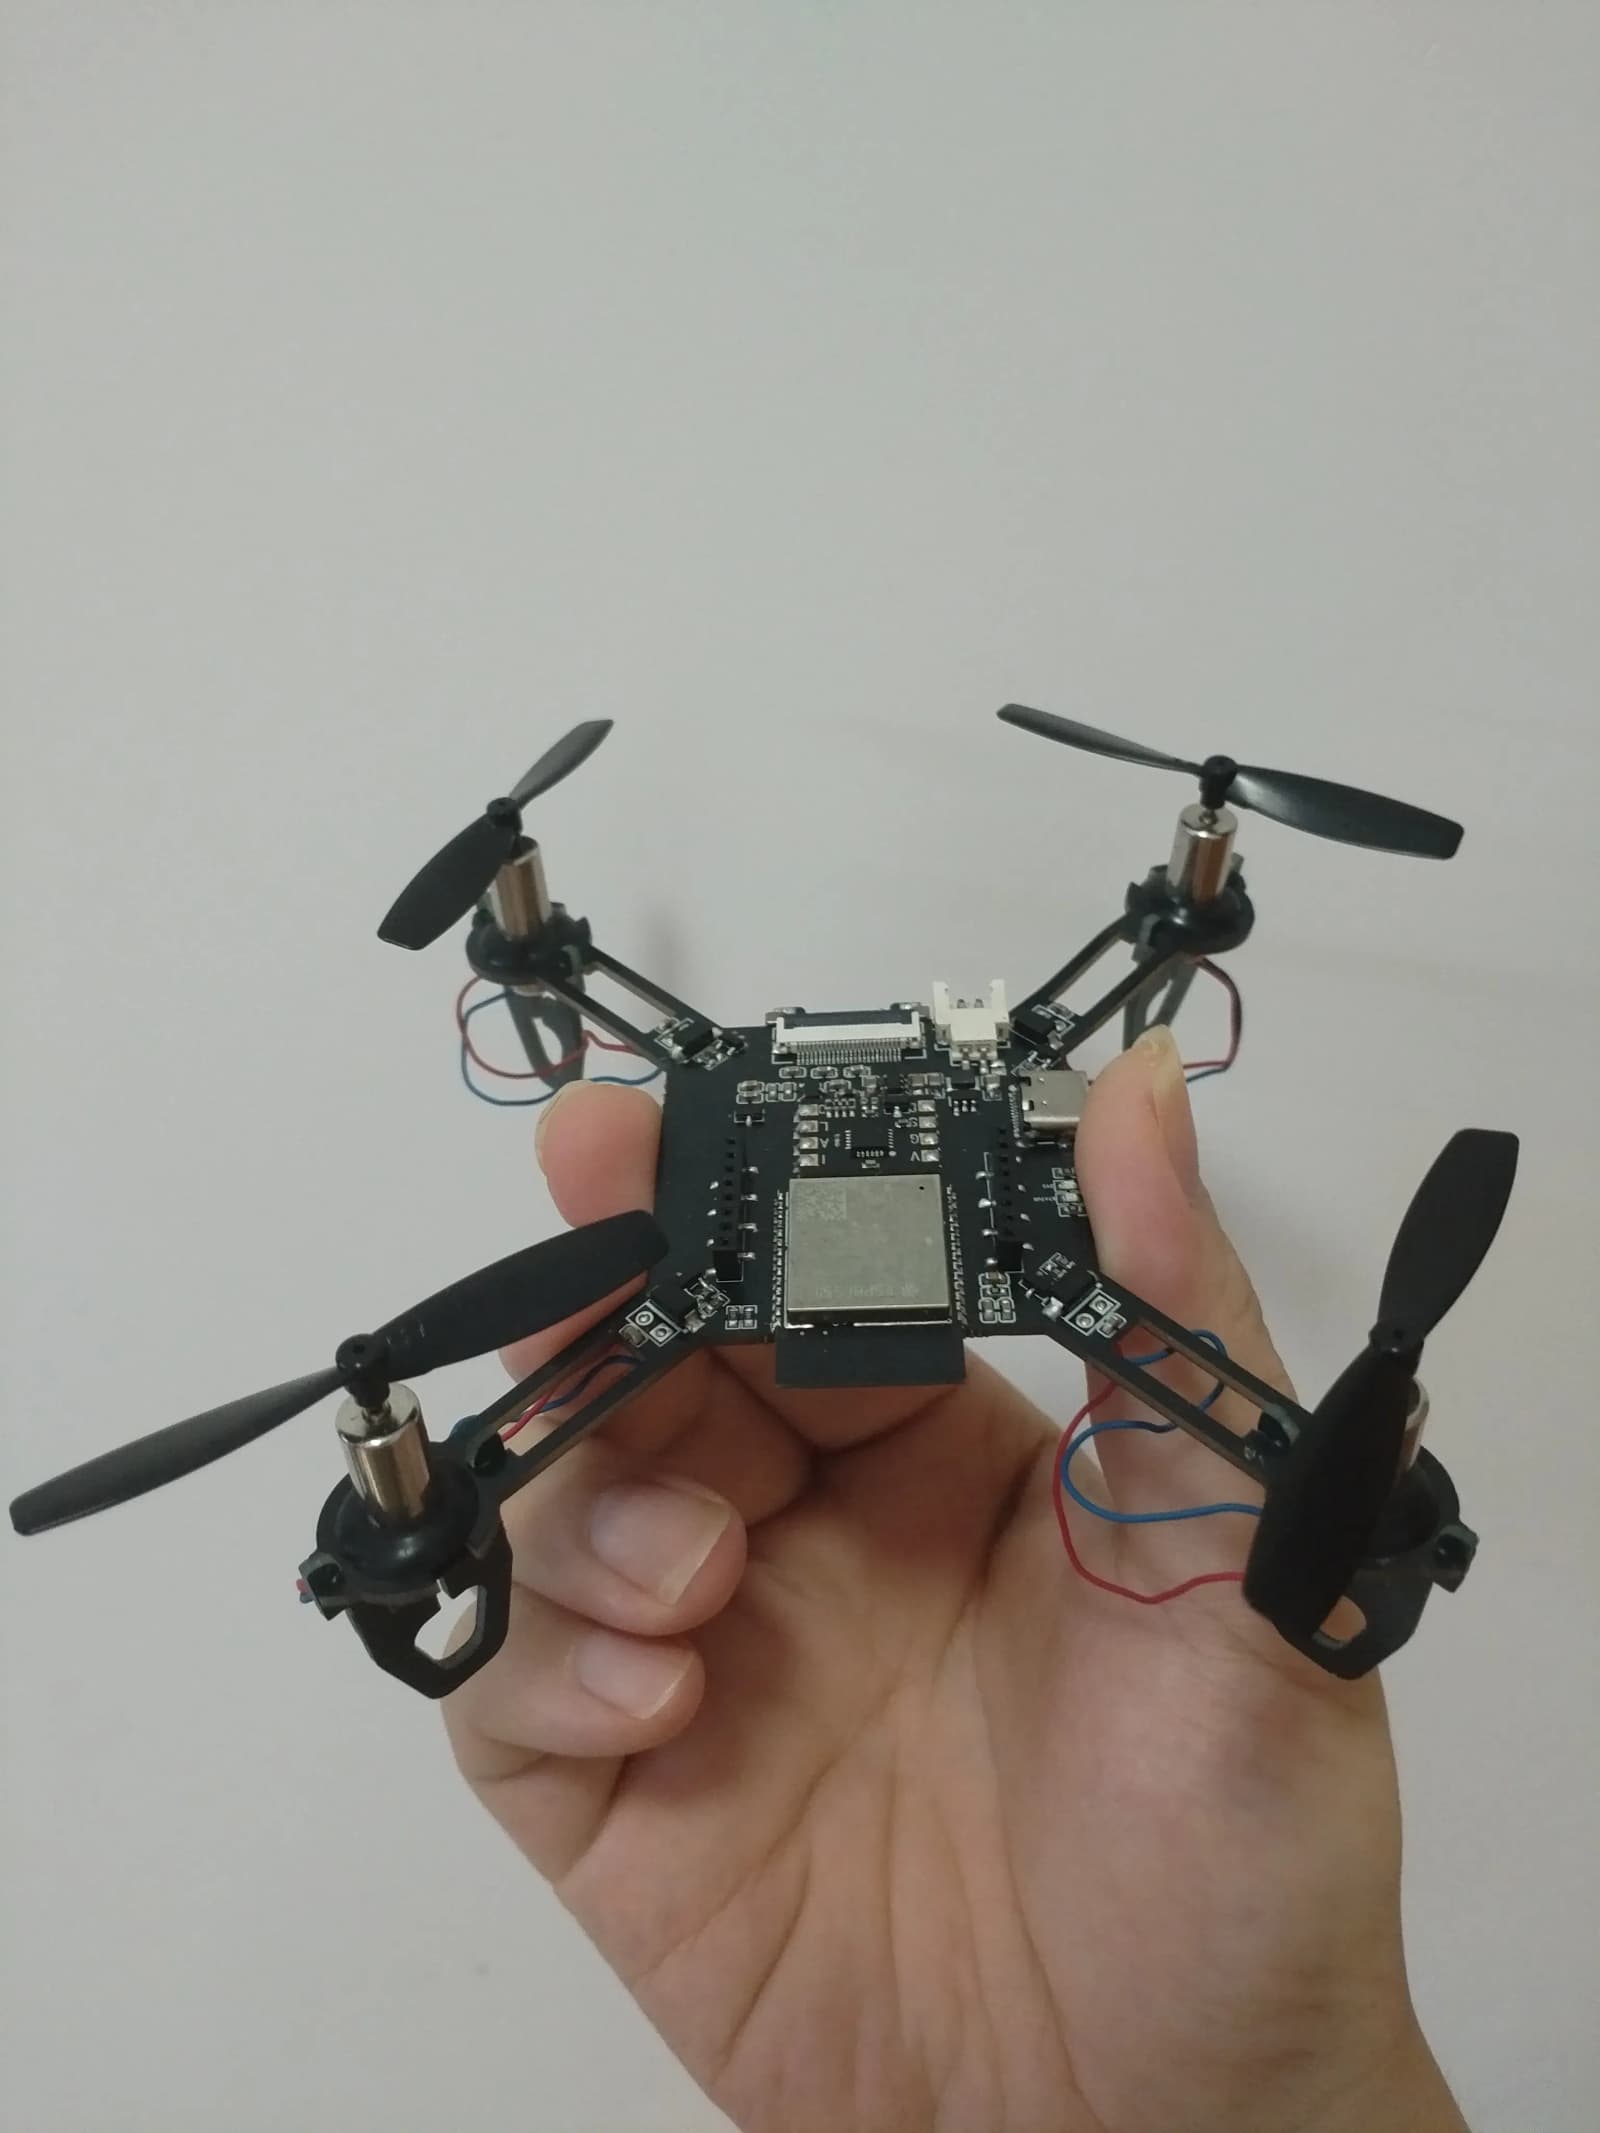
    Quadruped

    STM32 Quadruped Robot

    A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    Tiny-Drone

    An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.

    • Work in progress
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
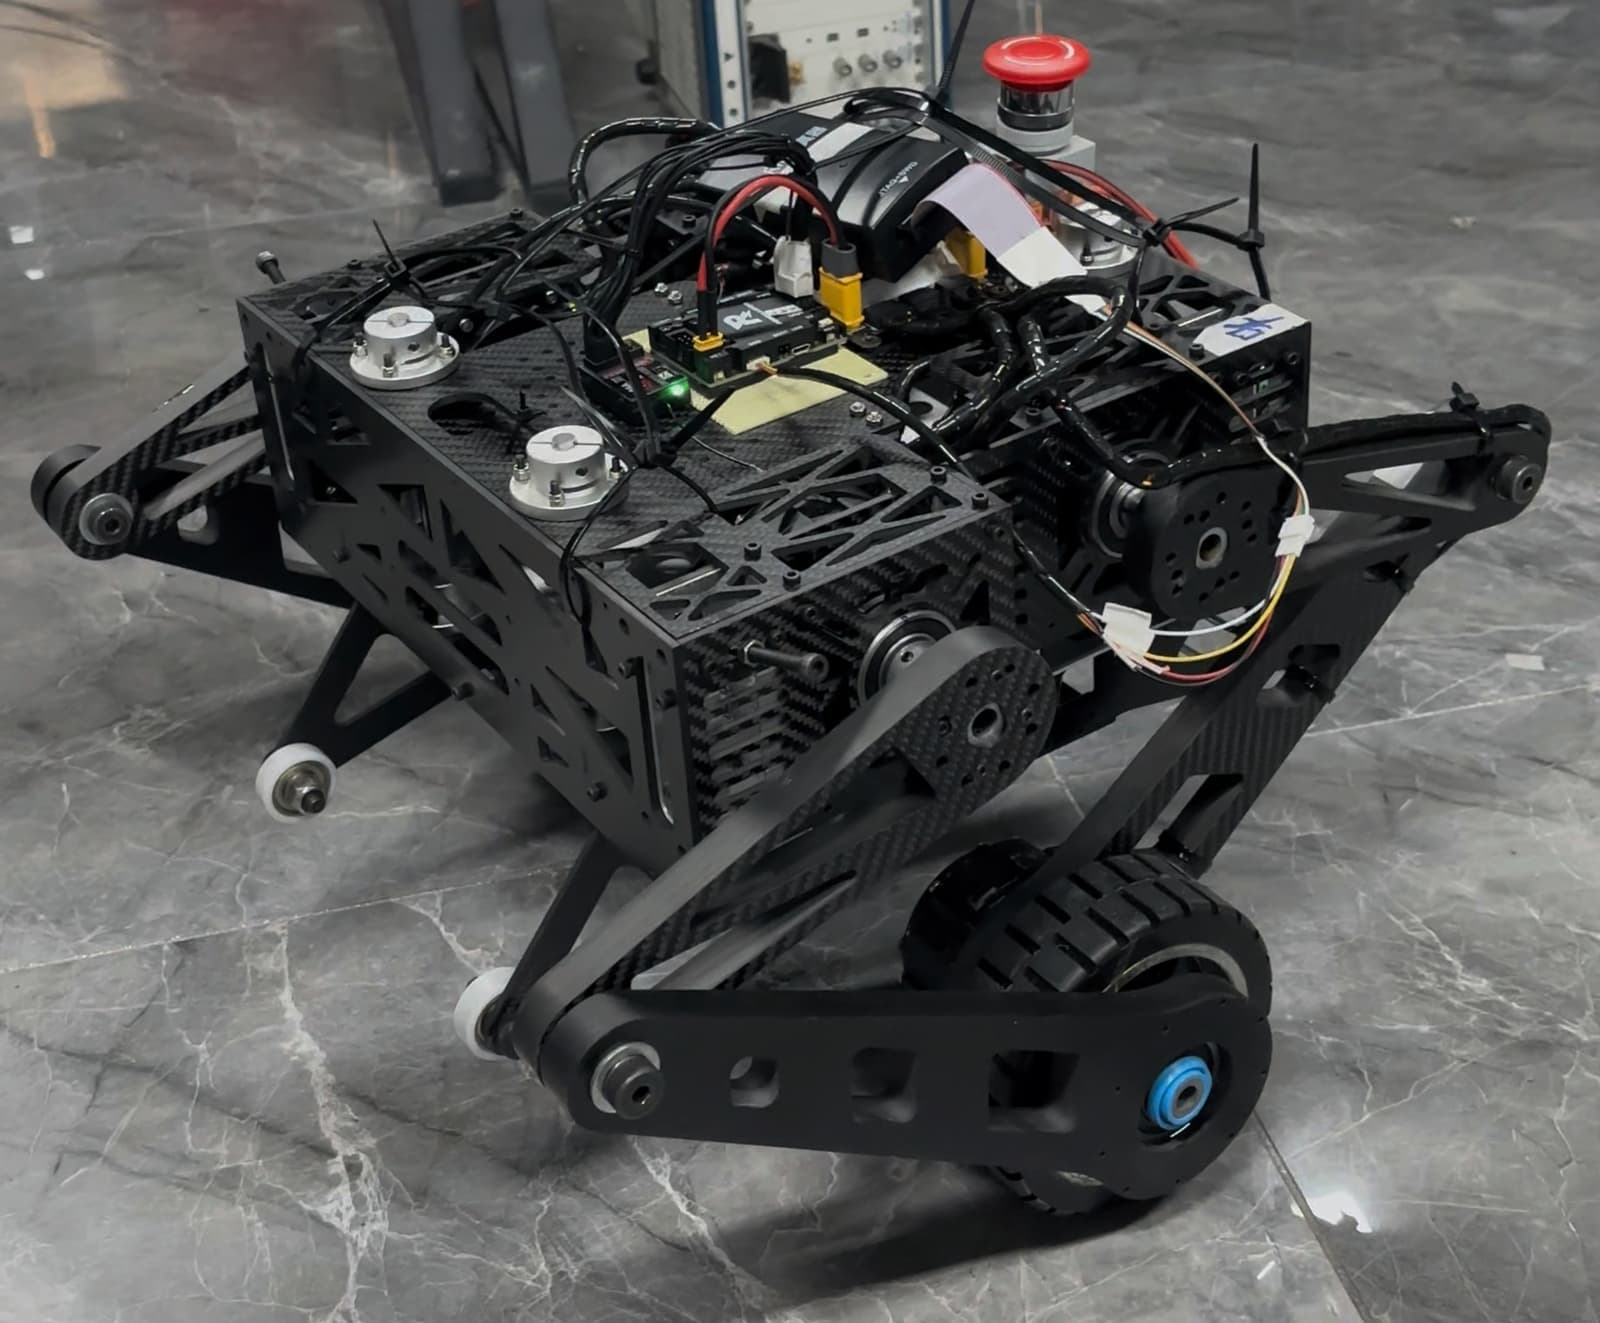
    Wheeled

    Training Tracer Ver.3

    A line-following robot hardware documentation set with CAD files, 3D printable parts and circuit schematics for the TrainingTracer Ver.3 educational robot.
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Wheel-legged Robot

    A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Wheel-legged Robot (Balance Leg V2)

    A wheel-legged balancing robot with leg-joint motors and hub-wheel motors, controlled by a custom STM32H723 board using LQR and VMC.

    • No license
    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
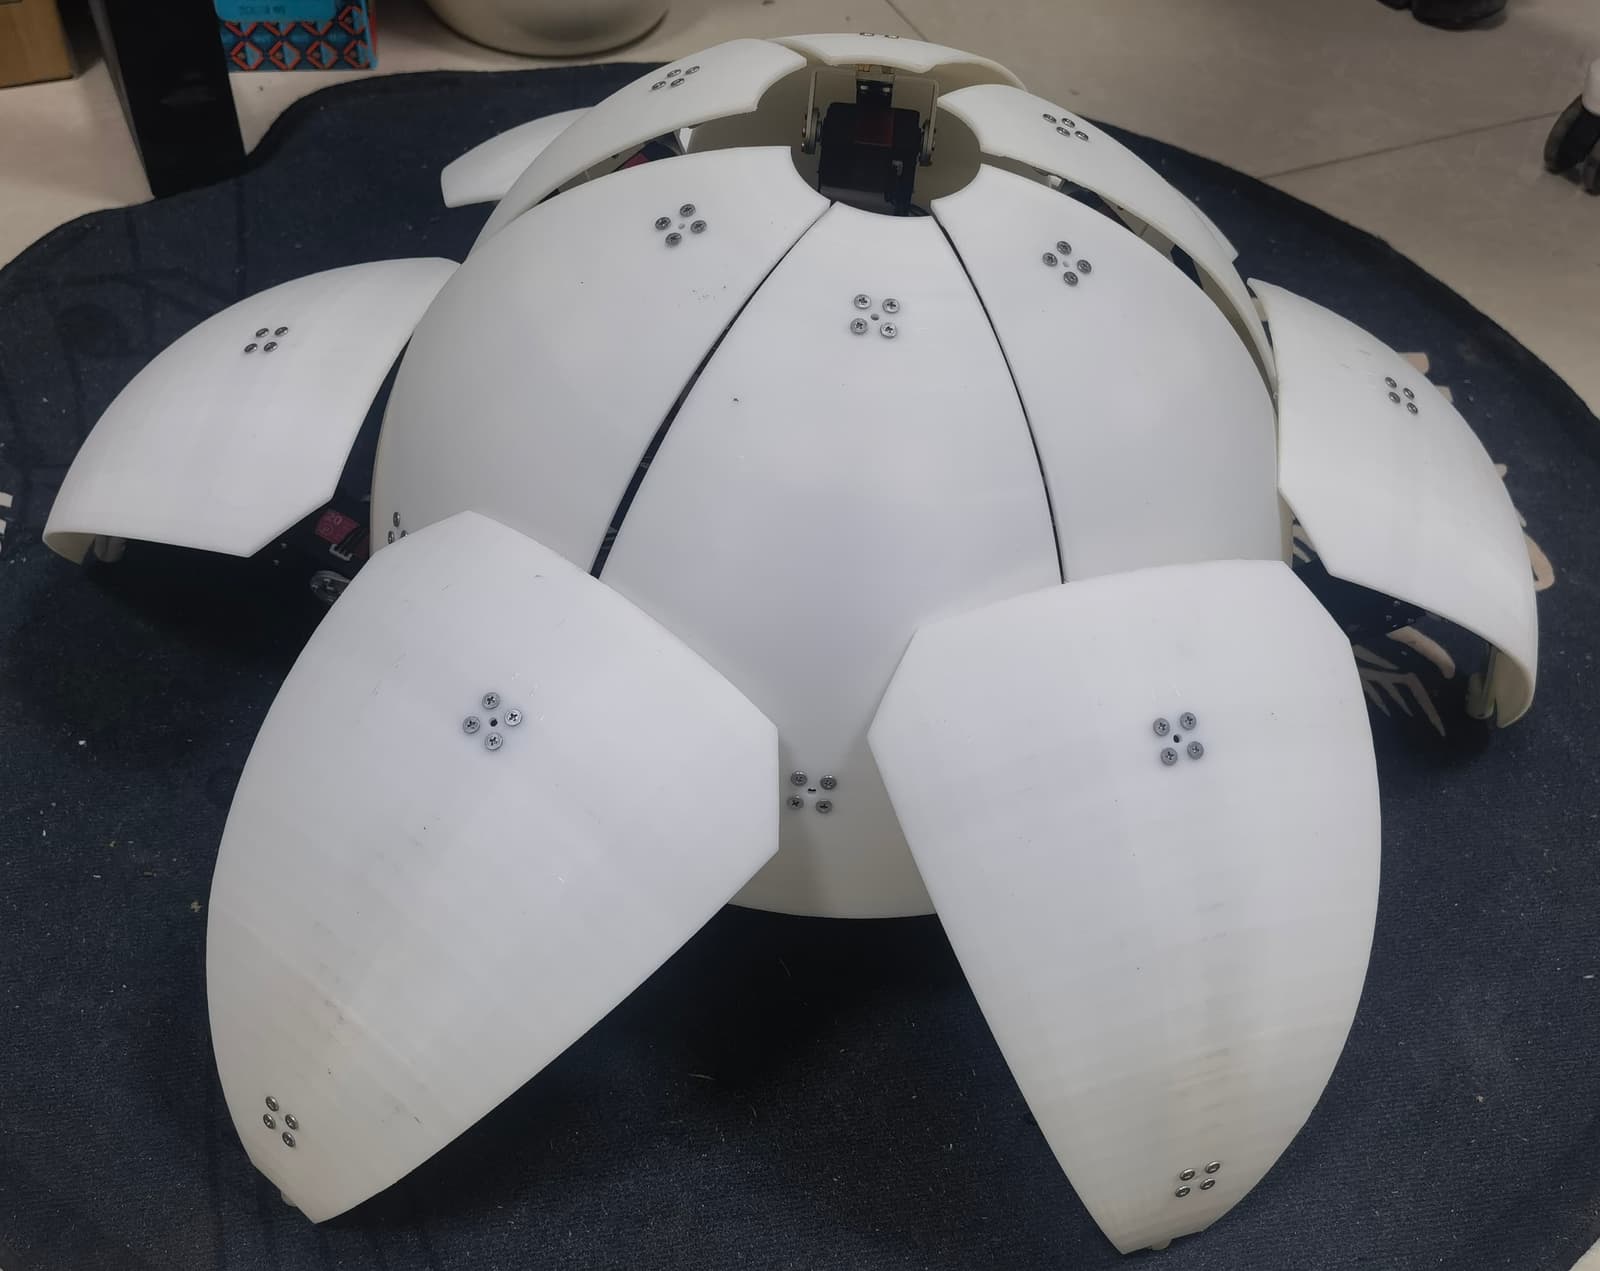
    Other

    Wheelbot

    A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    ZGPS-01

    A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Acme-Flight

    An open-source quadcopter framework providing schematics and flight control source code.

    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated

Robots 169–192 of 270

More to explore