ANTi Self-Driving Car
A compact autonomous self-driving vehicle built by Team ANTi for the WRO 2025 Future Engineers challenges, navigating open and obstacle courses.
- Self-driving 1:10
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @atakanersoy (opens in a new tab), from github.com/atakanersoy/WRO2025_FE_ANTi (opens in a new tab). Pinned to commit 2631c62 (opens in a new tab).
- Hardware license
- AGPL-3.0-only (opens in a new tab)
- Software license
- AGPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo
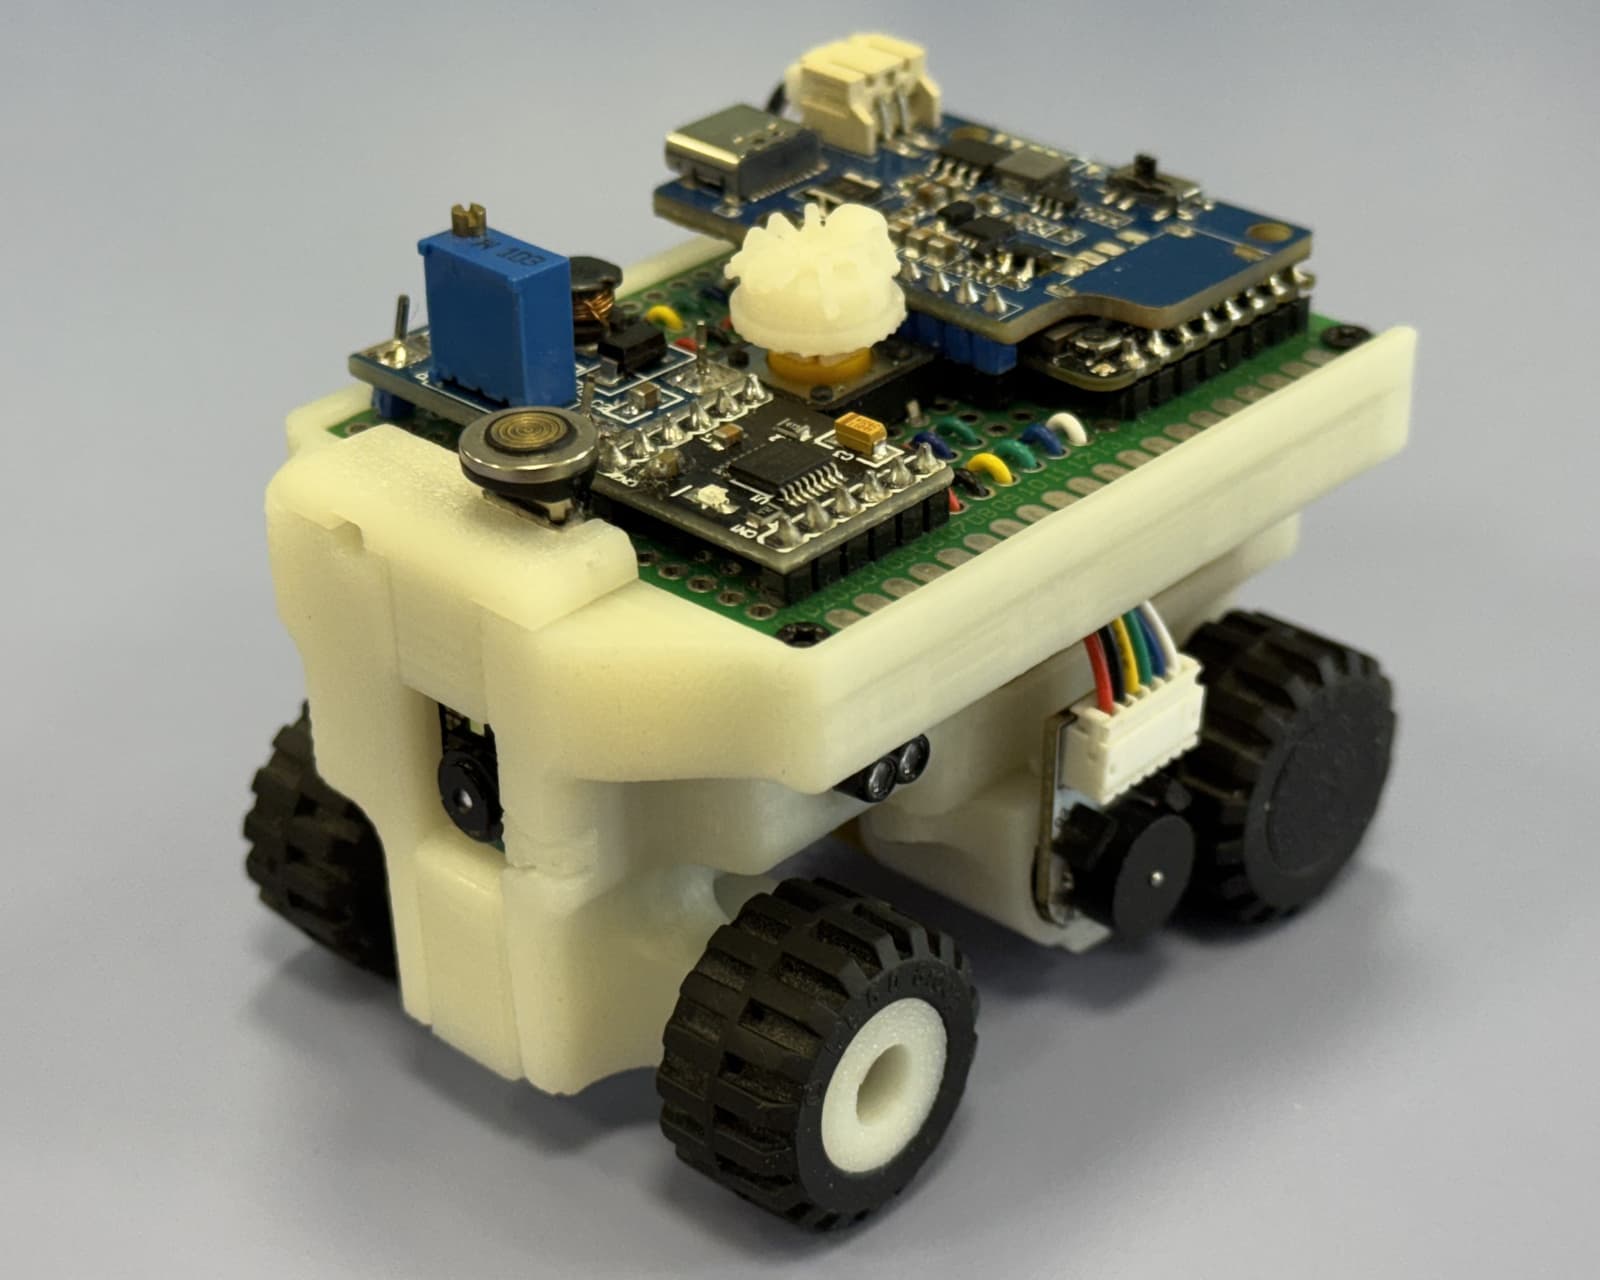
- Weight
- 130 g
- Height
- 69 mm
What it can do
Written by Robotheca from the project's documents.
- Autonomous self-driving robot built for WRO 2025 Future Engineers Open and Obstacle challenges
- Camera-based track following with color detection of traffic signs using LAB colorspace
- Obstacle avoidance and parallel parking using time-of-flight distance sensors
- Rear-wheel drive with Ackermann steering, controlled by PWM and PID
- Start button controls the run
Bill of materials
29 parts29 of 29 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | STM32H747 | 1 | – | – |
| 2 | nRF52832 | 1 | – | – |
| 3 | GC2145 Camera | 1 | – | – |
| 4 | VL53L3CX ToF | 2 | – | – |
| 5 | VL53L1X ToF | 1 | – | – |
| 6 | LSM6DSOX IMU | 1 | – | – |
| 7 | DRV8833 Driver | 1 | – | – |
| 8 | BOB-12009 | 1 | – | – |
| 9 | SX1308 Booster | 1 | – | – |
| 10 | Feetech FS0307 | 1 | – | – |
| 11 | 1500 RPM N20 | 1 | – | – |
| 12 | PX103035 Battery | 1 | – | – |
| 13 | LiPo Rider Plus | 1 | – | – |
| 14 | KLS7-TS1204 | 1 | – | – |
| 15 | LEGO 87697 | 4 | – | – |
| 16 | Main Chassis | 1 | – | – |
| 17 | 4-Gear Differential | 1 | – | – |
| 18 | Front Rim Assembly | 2 | – | – |
| 19 | Steering Arm | 2 | – | – |
| 20 | Steering Linkage | 1 | – | – |
| 21 | 25T Spur Gear | 1 | – | – |
| 22 | 26T Spur Gear | 1 | – | – |
| 23 | 12T Bevel Gear | 4 | – | – |
| 24 | Motor Enclosure | 1 | – | – |
| 25 | Long Rear Rim | 1 | – | – |
| 26 | Short Rear Rim | 1 | – | – |
| 27 | Front Upper Cover | 1 | – | – |
| 28 | Front Lower Cover | 1 | – | – |
| 29 | Button Interface | 1 | – | – |
29 of 29 parts have no price in the source, so there is no parts total. Read from README.md at the pinned commit.
Build guide
The guide appears here as you scroll.
Guide by @atakanersoy (README.md), under AGPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- STM32H747 dual-core microcontroller for vision processing
- NRF52832 microcontroller for sensor fusion
- GC2145 2MP camera
- VL53L1X time-of-flight sensor at the front
- Two VL53L3CX time-of-flight sensors on the sides
- LSM6DSOX 6-axis IMU
- DRV8833 dual H-bridge motor driver
- 1500 RPM N20 DC motor with encoder
- BOB-12009 level shifter, SX1308 booster, LiPo battery with LiPo Rider Plus charger
Connections
- Microcontrollers and sensors communicate with the controllers through connections described in the wiring diagram
- BOB-12009 converts signals between the 3.3V microcontrollers and the 5V steering servo
- SX1308 steps up voltage to drive the DRV8833 motor driver
- A power switch controls the 5V rail, and the 3.3V regulator input was rerouted to that switched rail
- Parts are mounted in double-layer pertinax sockets
