Desktop Robot Arm
A compact 3D-printed desktop robot arm with a rotating base and gripper, controlled through a browser joystick over its own Wi-Fi access point.
Robot armIntermediateBuildability 50/100 · Buildable with some effort
Cost not stated
Robot arms, from desk arms for learning to arms for robot learning and research. 52 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 3 · Ready to build first, then by buildability
A compact 3D-printed desktop robot arm with a rotating base and gripper, controlled through a browser joystick over its own Wi-Fi access point.
A small, low-cost 6-degree-of-freedom 3D-printed robot arm driven by Dynamixel XL-320 motors and controlled from a Raspberry Pi.
A small 4-degree-of-freedom robot arm with 3D printed parts, driven by four SG90 servos and an Arduino Nano.

A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.

A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
An open source six degree of freedom industrial robot arm that can hold 2kg at 80cm.
An open-source dexterous hand system that uses gesture recognition to control a 3D-printed robotic hand and play music.
A 6-DOF robotic arm built with 3D-printed parts and Feetech STS3215 bus servos, controlled via LeRobot.
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
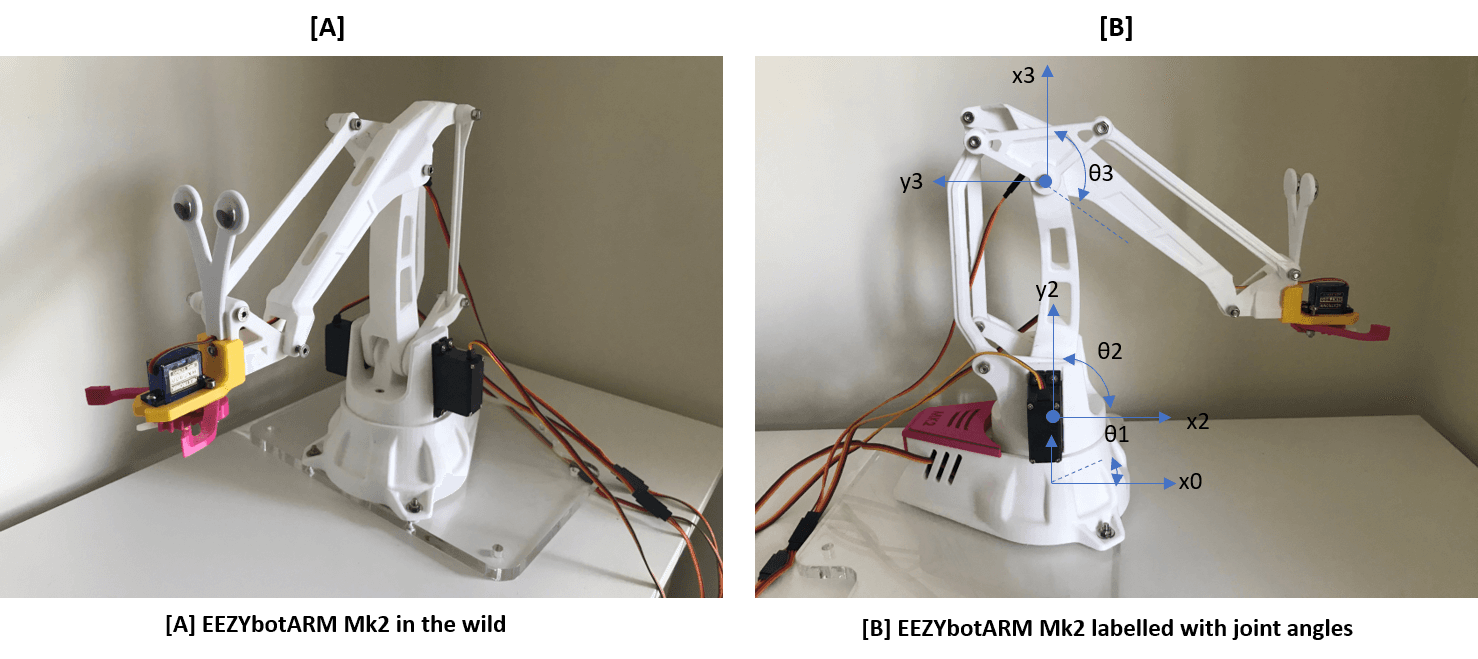
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
An open-source 3D-printed robotic arm with 5 degrees of freedom and a gripper.
A desktop robotic arm designed for easy 3D printing with minimal parts, featuring a 3D-printed structure and basic electronic components.
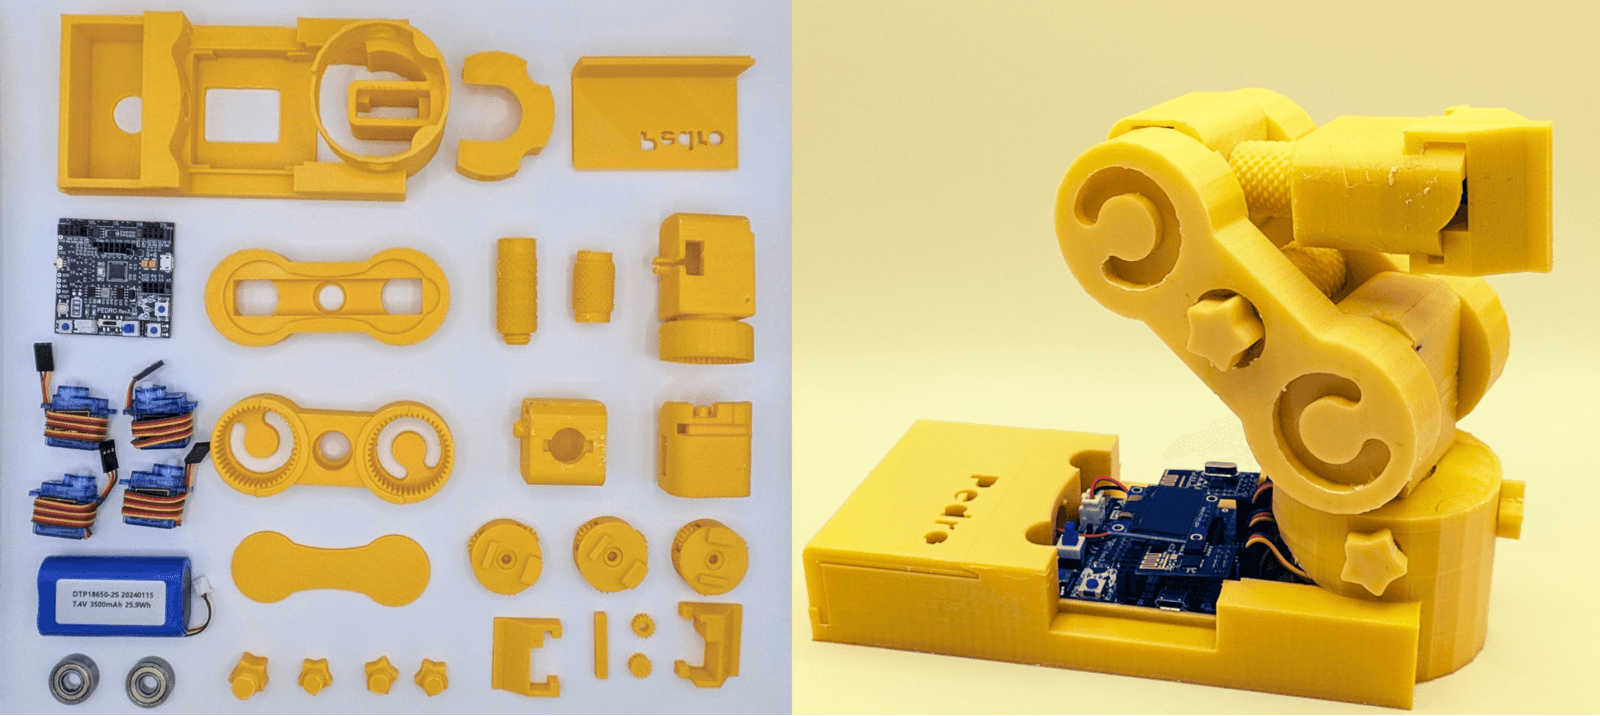
Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.
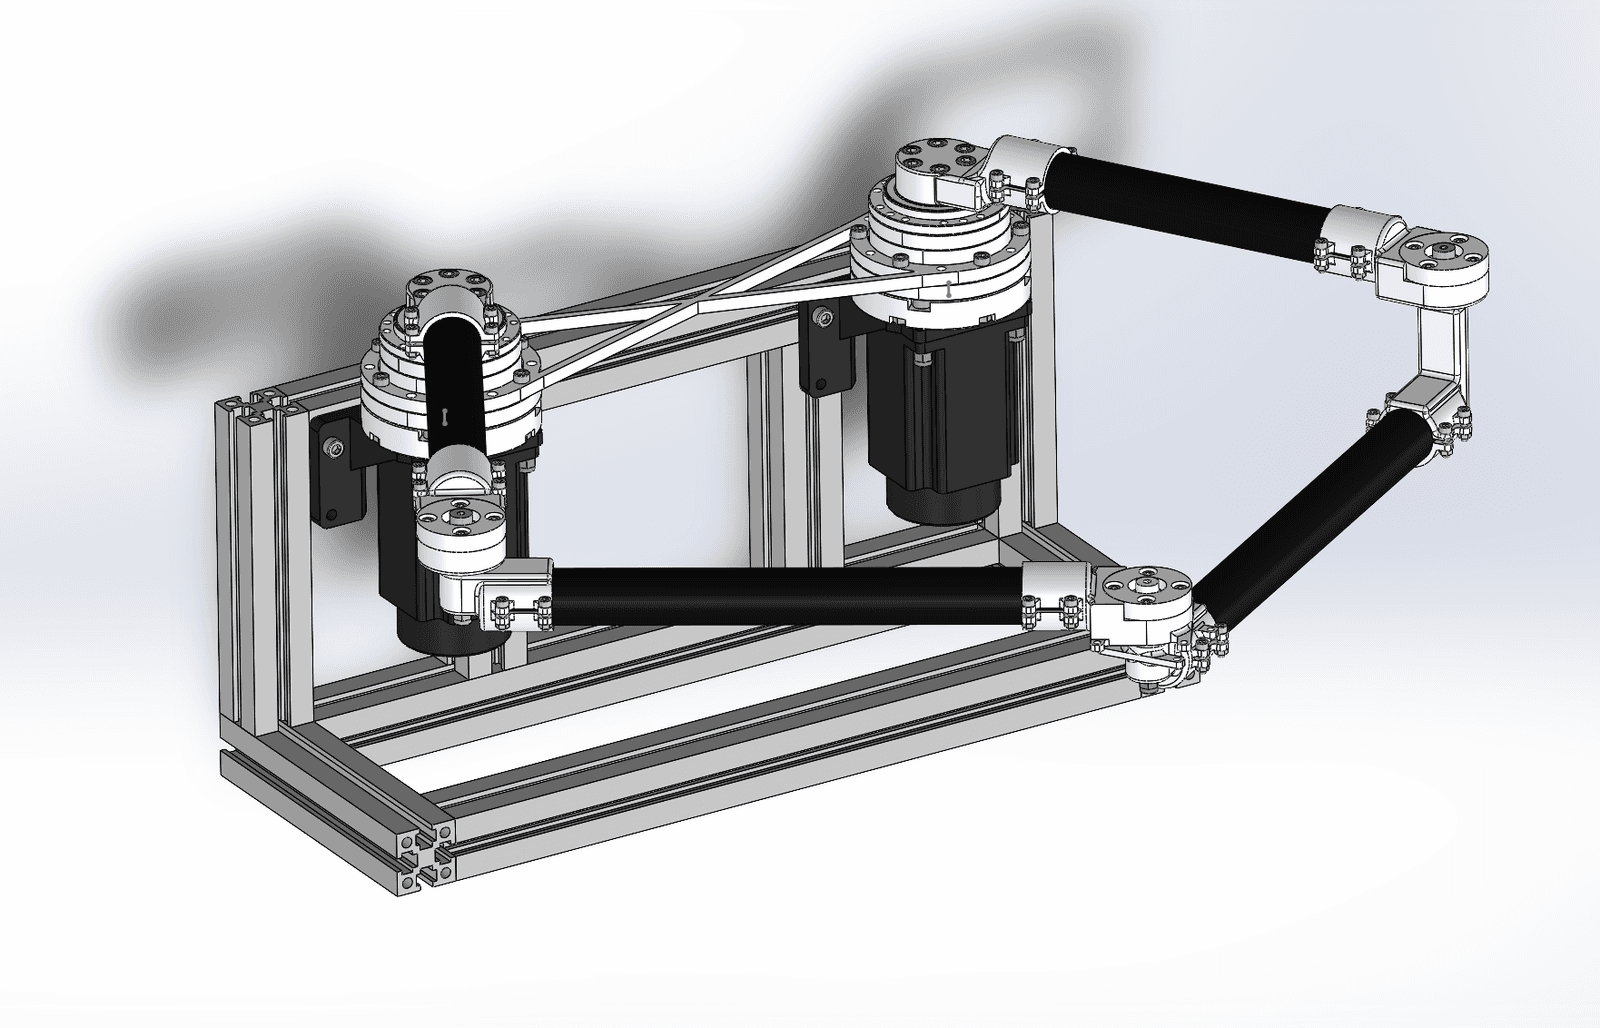
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
A tiny open-source writing robot arm designed for AI drawing applications.
A 3D-printable robot arm, current version V4 (Green), designed for printing and assembly by hobbyists.
A compact smart robotic arm with 6 degrees of freedom, designed for educational and hobbyist use.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
An open-source single-arm mobile robot that adds a 7-degree-of-freedom arm to a mobile chassis for grasping and carrying tasks in complex environments.

A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.
A writing robot based on ESP8266 that can perform manual timekeeping, weather forecasting, and function as a general-purpose robotic arm.
The Ruishi modular exoskeleton: joint and slip-ring modules, the hardware and joint-motor lists, and installation examples.
Robots 25–48 of 52