ESP-Drone
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
DroneIntermediateBuildability 40/100 · Incomplete documentation
Cost not stated
Robots whose build needs a 3D printer for their parts. 233 robots on Robotheca, each with its licenses and its source on GitHub.
Page 6 of 10 · Ready to build first, then by buildability
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A biomimetic robot head with tendon-driven neck controlled via Raspberry Pi and PCA9685 servos.
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
An open-source 3D-printed robotic arm with 5 degrees of freedom and a gripper.
A desktop robotic arm designed for easy 3D printing with minimal parts, featuring a 3D-printed structure and basic electronic components.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
A biomimetic butterfly robot controlled via ESP32C3 using ESP-NOW wireless communication.
An open-source ESP32-based six-legged robot with Web control, calibration, performance motions, motion sequences and optional voice interaction.
A quadruped robot dog built from 3D-printed PLA parts, driven by ODrive-controlled motors with AS5047 absolute encoders and a remote-controlled walking mode.
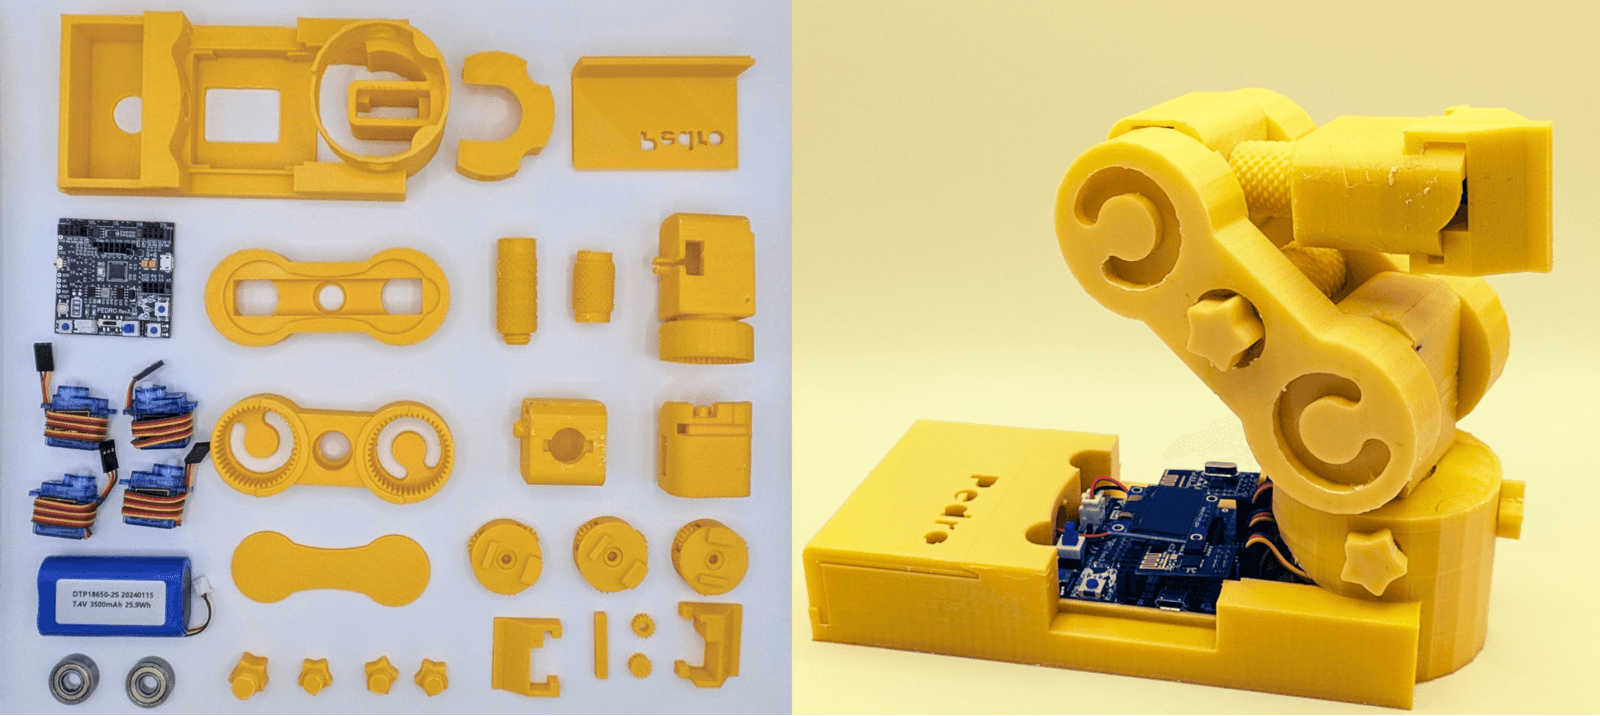
Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.
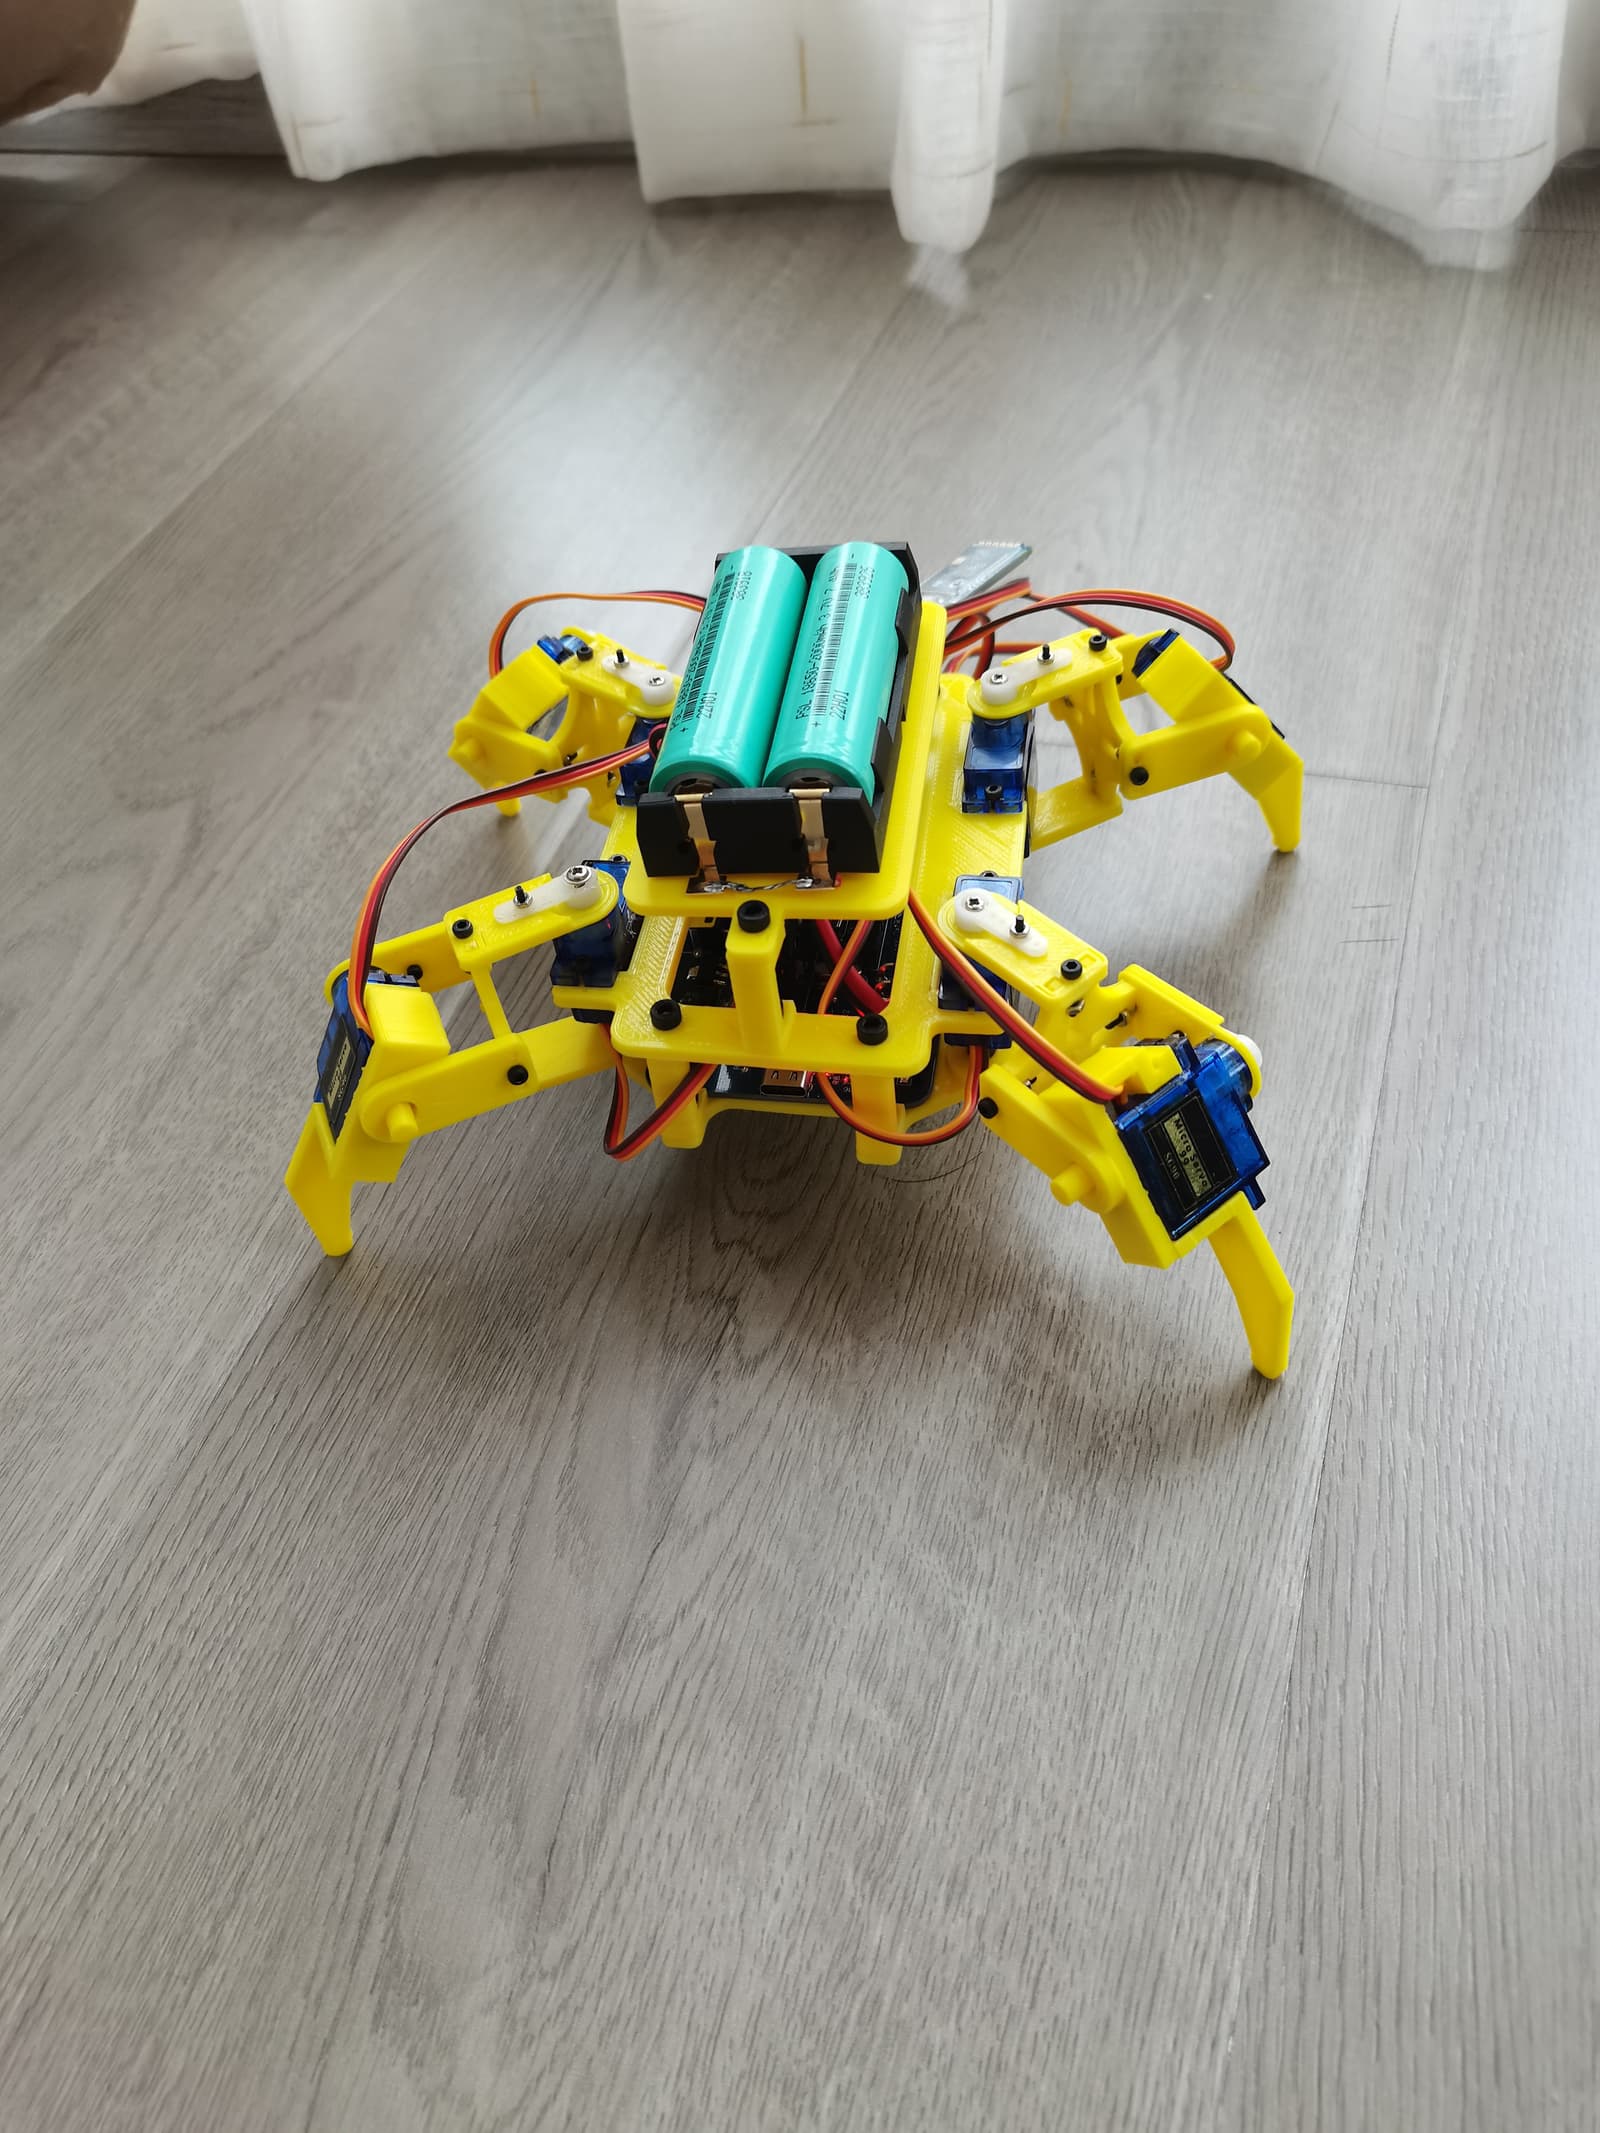
A four-legged robot designed for research and education in legged locomotion.
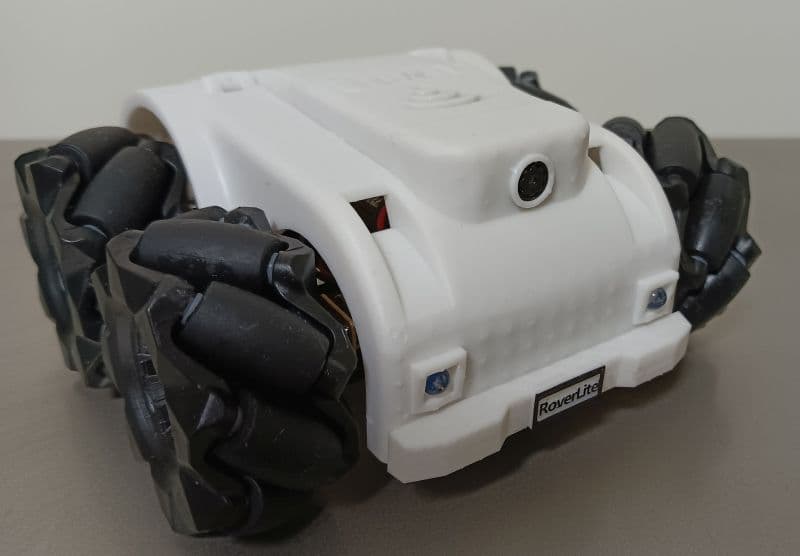
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
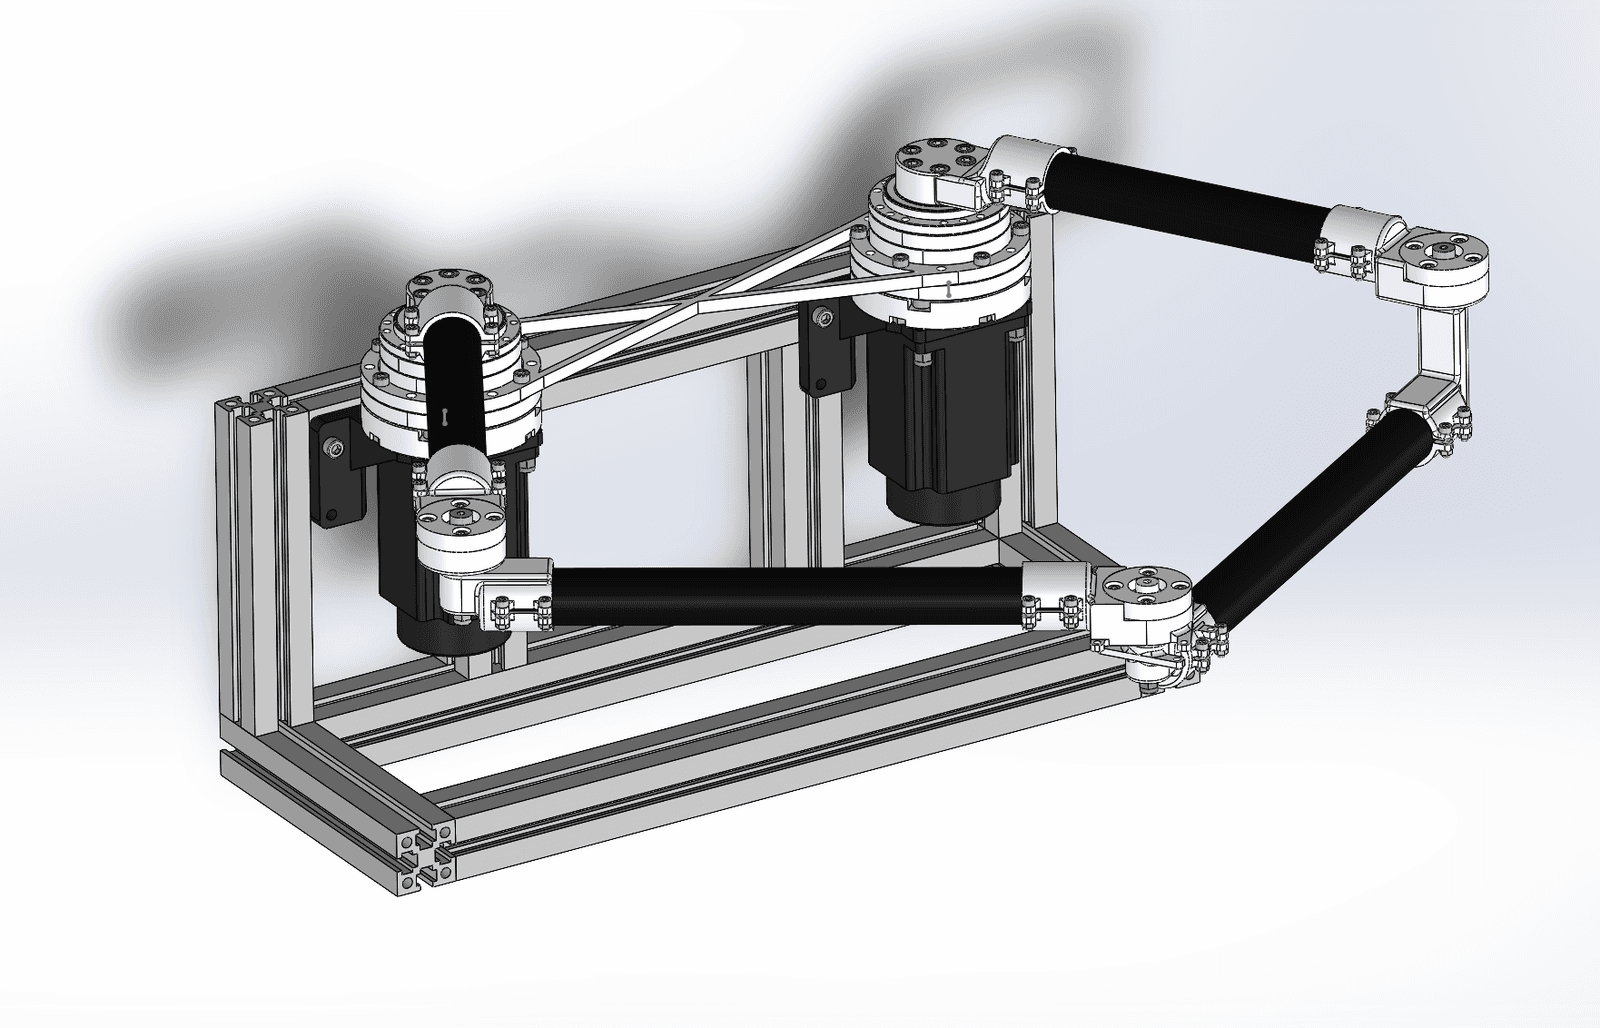
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
A self-balancing robot using STM32F103C8T6 with Mahony algorithm for attitude estimation.
An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
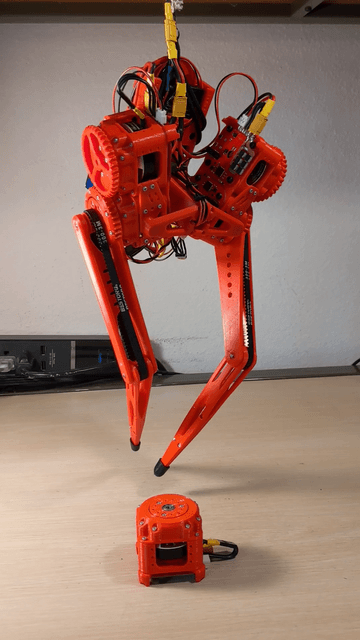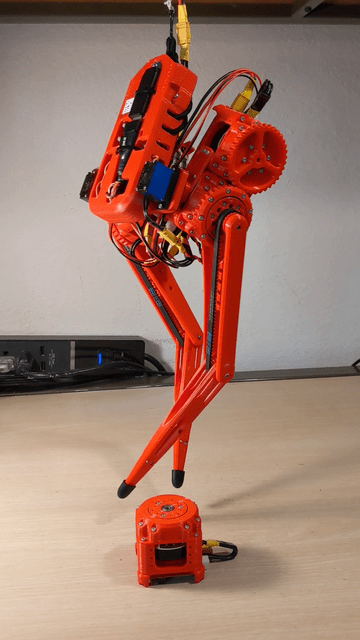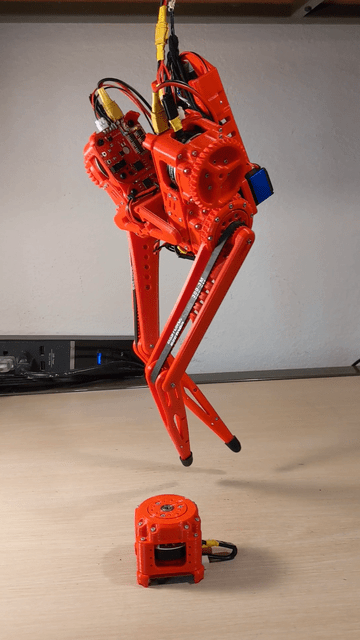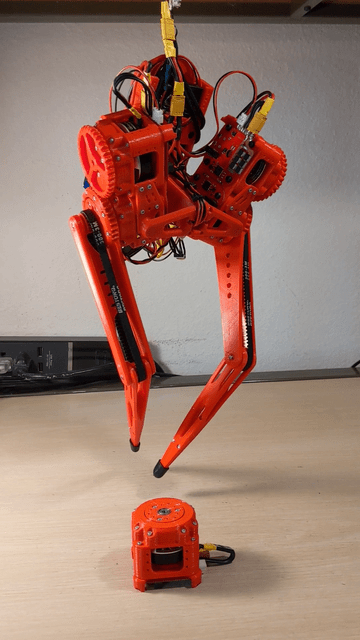
A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.
An ROV/AUV underwater robot controlled by STM32 and Raspberry Pi for navigation and sensor data processing.
A low-cost DIY writing machine that draws on a vertical surface using two stepper motors and a servo-controlled pen.
A tiny open-source writing robot arm designed for AI drawing applications.
A quadcopter flight controller based on STM32F103 with remote control, PCB, 3D models, and ROS 2/PX4 simulation support.
A small quadrotor drone based on STM32 that can fly stably.
A 3D-printable robot arm, current version V4 (Green), designed for printing and assembly by hobbyists.
A compact smart robotic arm with 6 degrees of freedom, designed for educational and hobbyist use.
Robots 121–144 of 233