AhaRobot
A modular humanoid robot designed for research and education with ROS2 integration.
HumanoidIntermediateBuildability 55/100 · Buildable with some effort
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 7 · Ready to build first, then by buildability
A modular humanoid robot designed for research and education with ROS2 integration.
An open-source, low-cost humanoid robot designed for AI experimentation and education.
A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
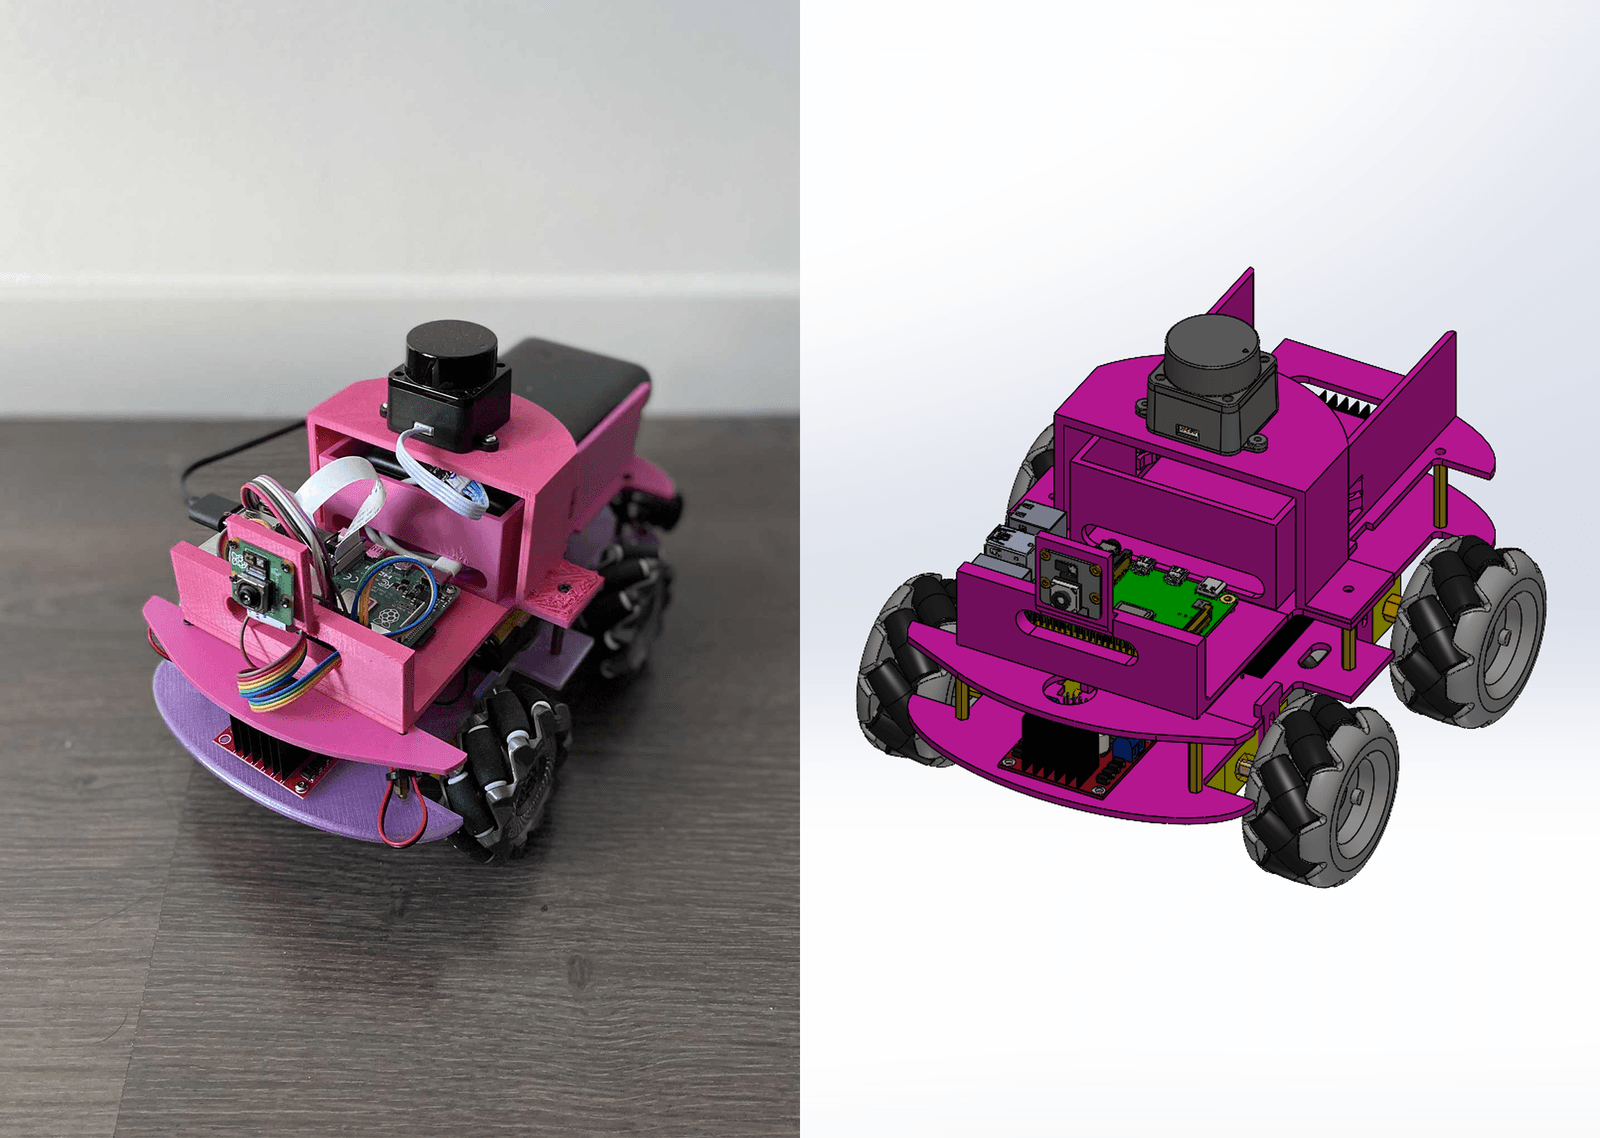
An open-source autonomous mecanum wheel robot for learning and experimentation that navigates manually or autonomously using a Lidar.
An easy to modify, 3D printable open-source humanoid robot evolved by the community that walks, lifts and can be simulated.
A tiny desktop two-wheeled legged robot with ESP32 control and brushless motors.
A low-cost small electric vehicle body that uses an Android smartphone as its brain, supporting person following and autonomous navigation.
A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
Watney is a low-cost, 3D-printable, Raspberry Pi-based FPV telepresence rover with HD video and bi-directional audio.
An open-source 3D printed robot arm powered by ROS 2, designed as a low-cost learning tool for manipulators.
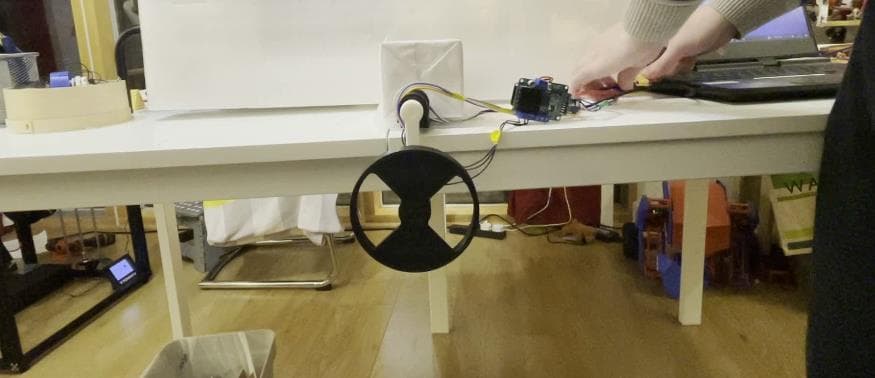
A low-cost, small inverted pendulum robot using DengFOC motor driver and SimpleFOC for balance control.
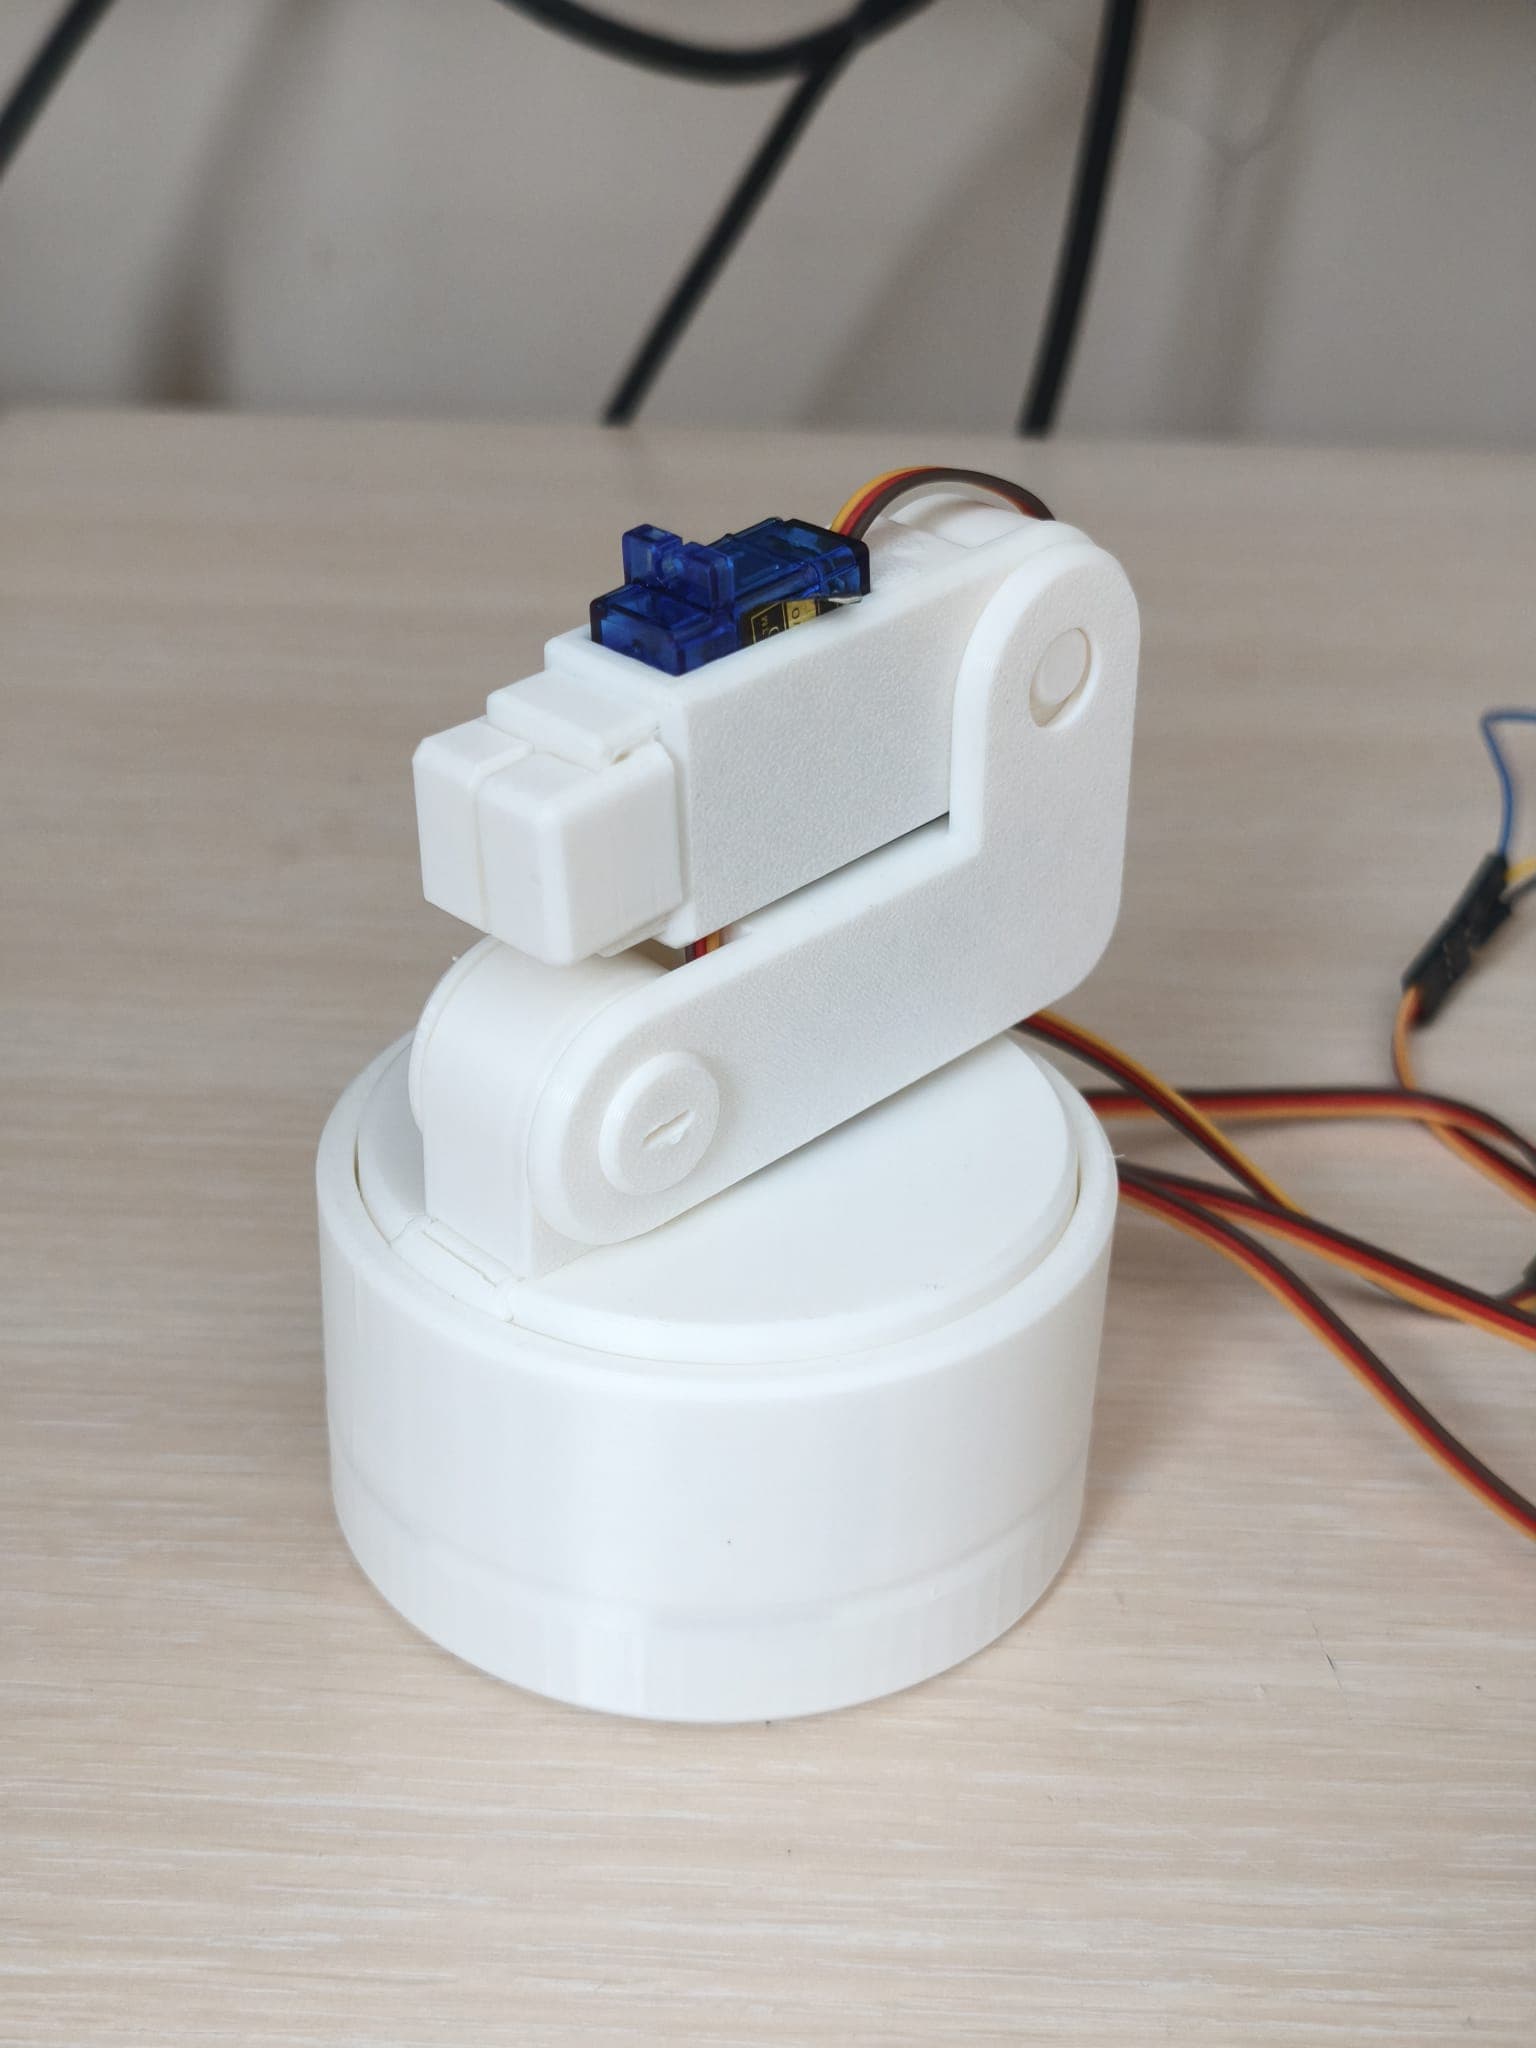
A compact 3D-printed desktop robot arm with a rotating base and gripper, controlled through a browser joystick over its own Wi-Fi access point.
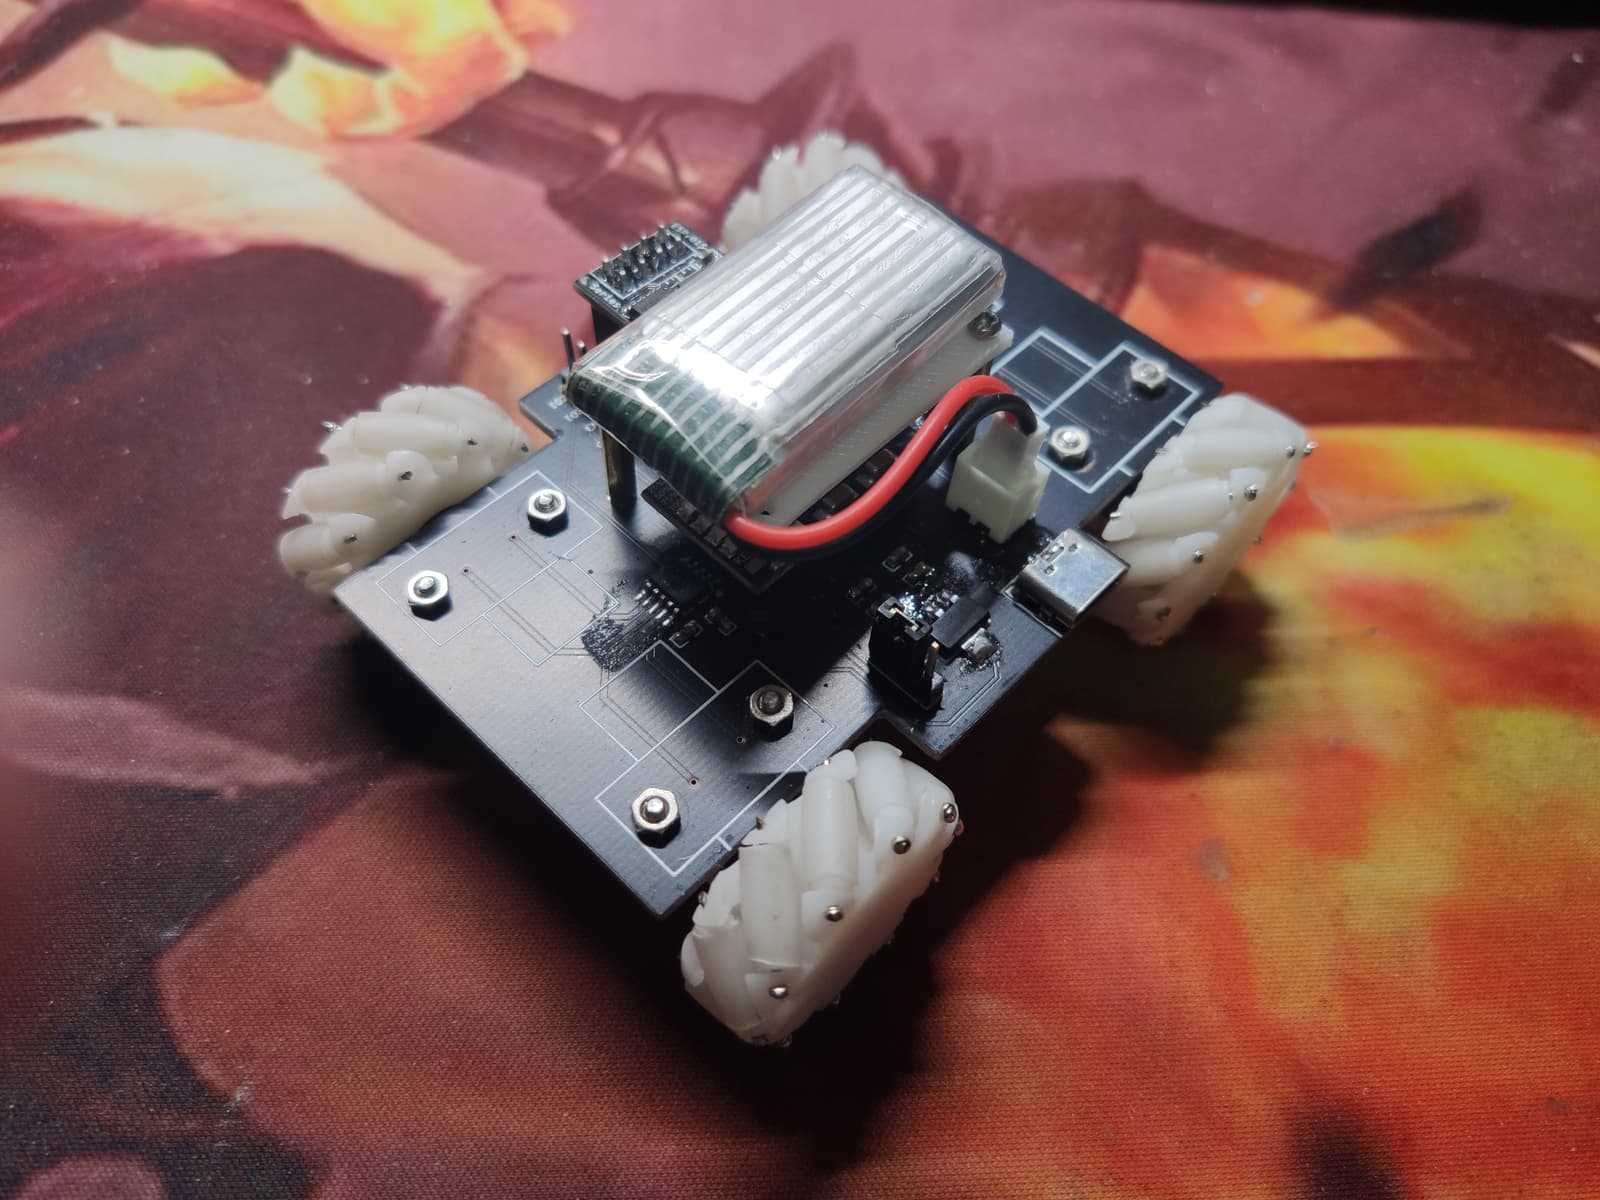
A small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.
A desktop quadruped robot based on ESP8266 with voice control, gesture recognition, web remote, and AI conversation.
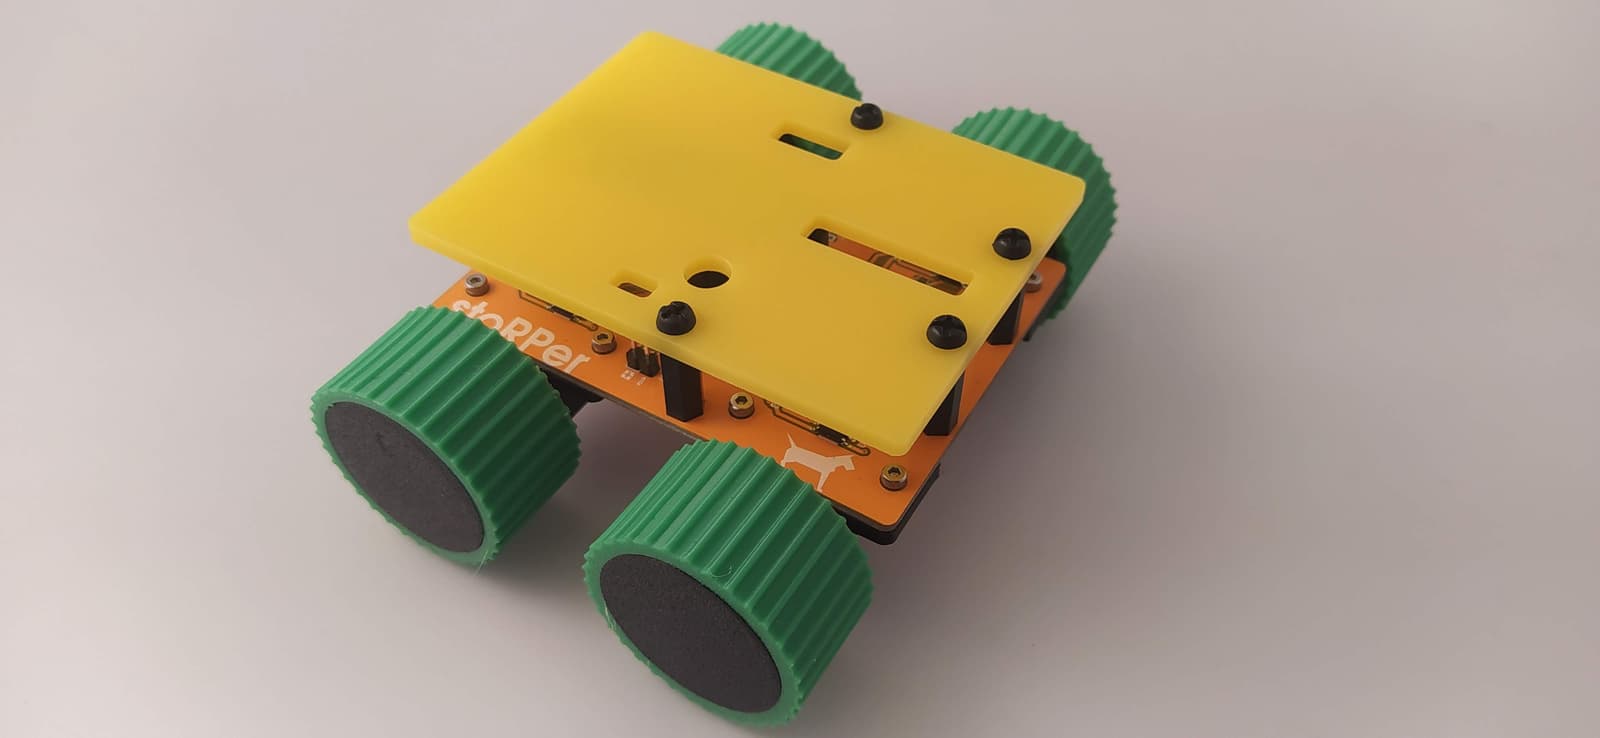
A modular, adaptable all-wheel-drive rover built around a Raspberry Pi Pico board, with 3D-printed motor mounts and optional add-on bumpers and decks.
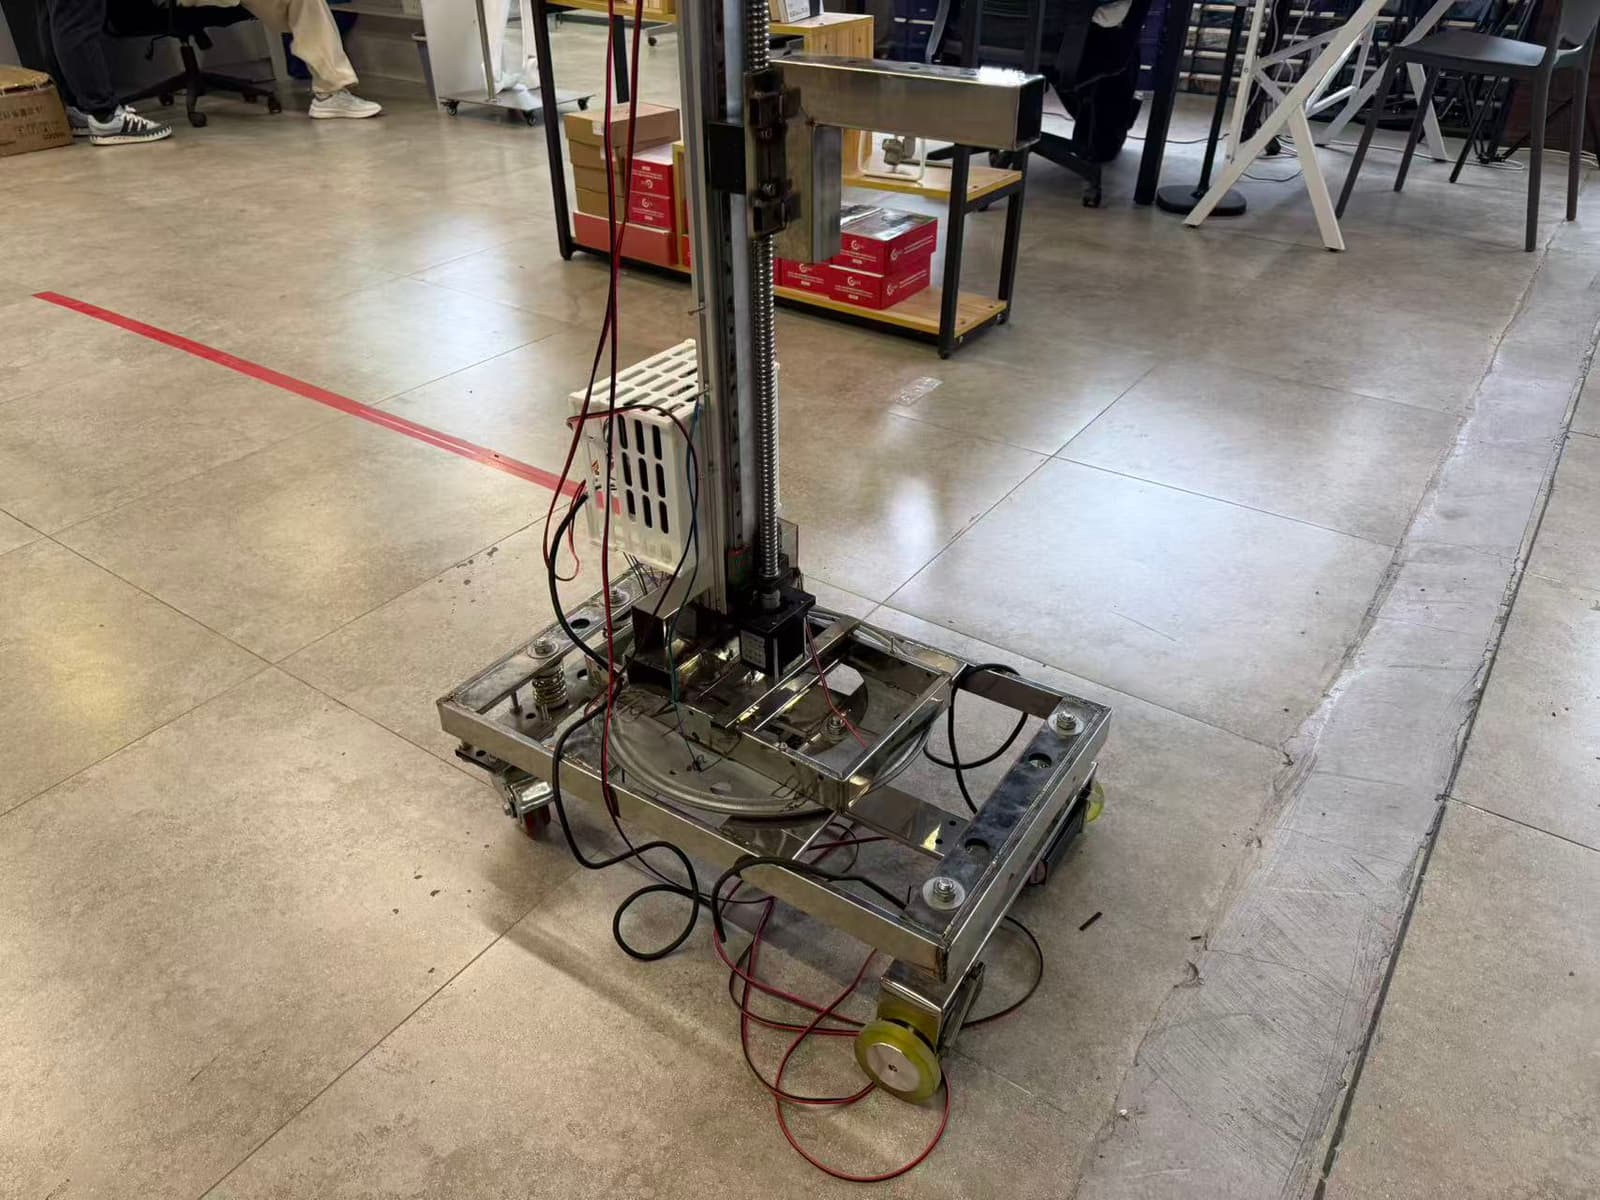
An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.
A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
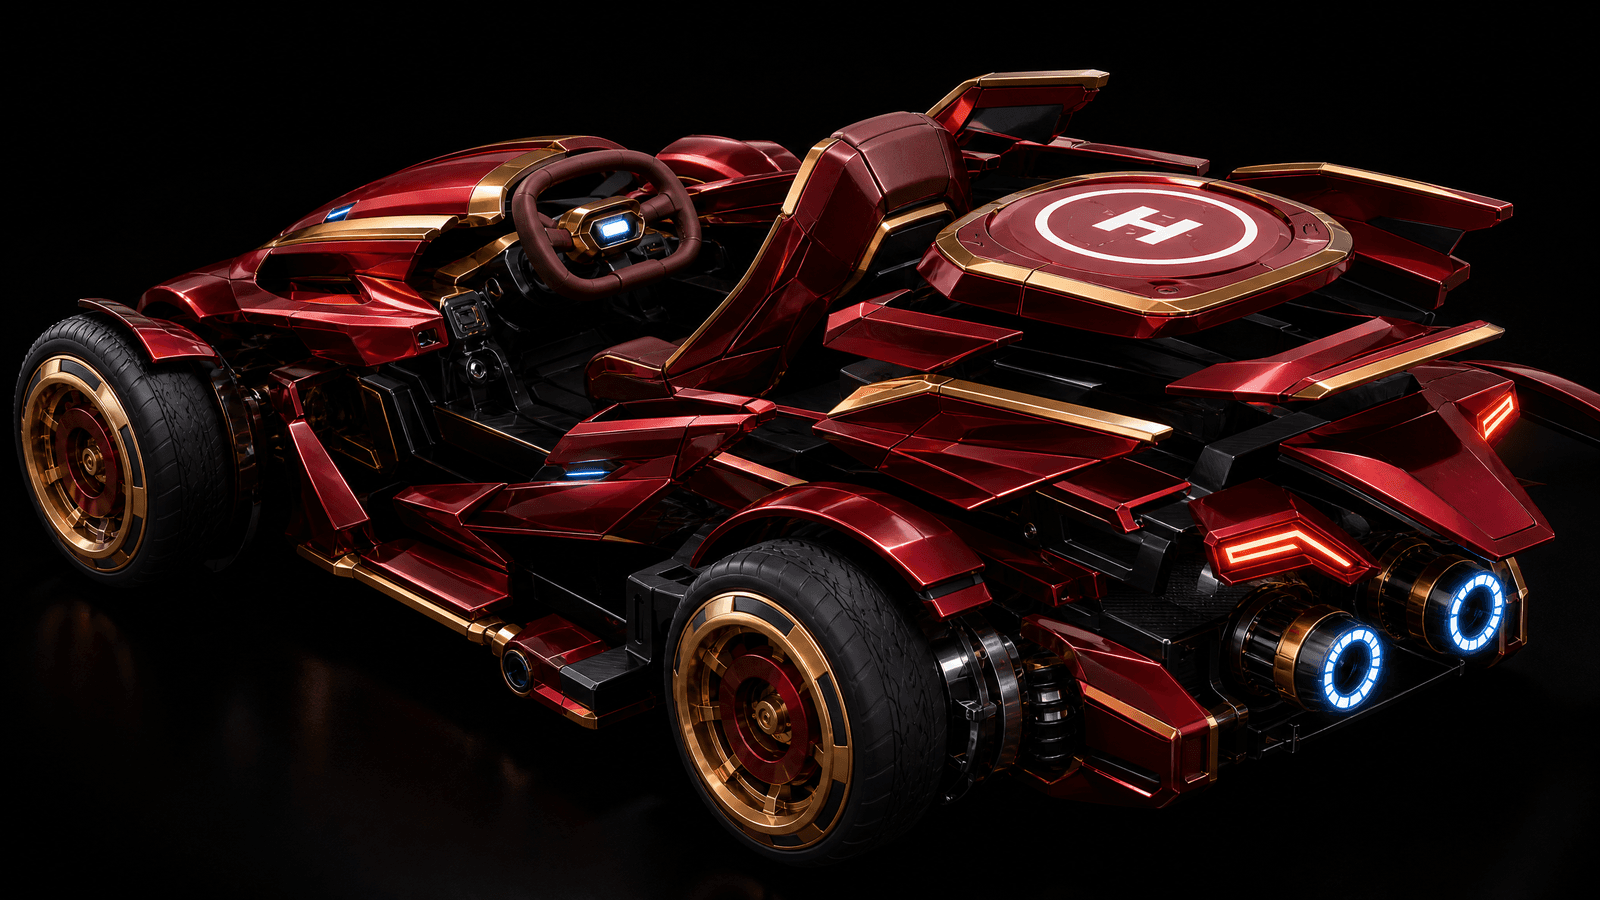
An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.
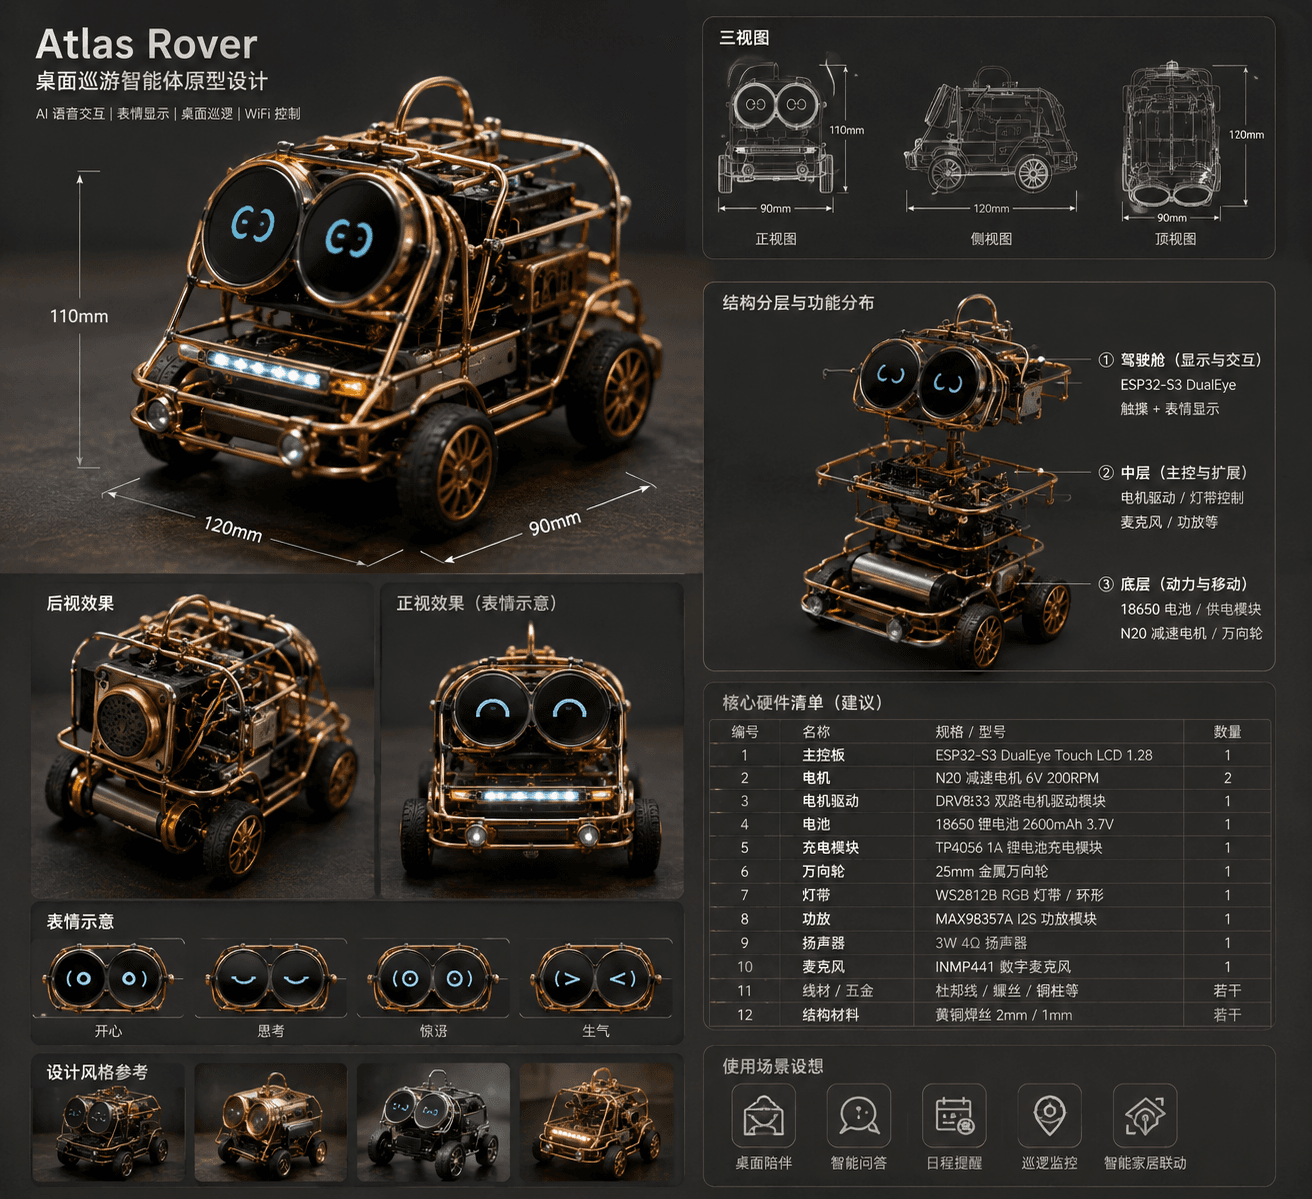
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
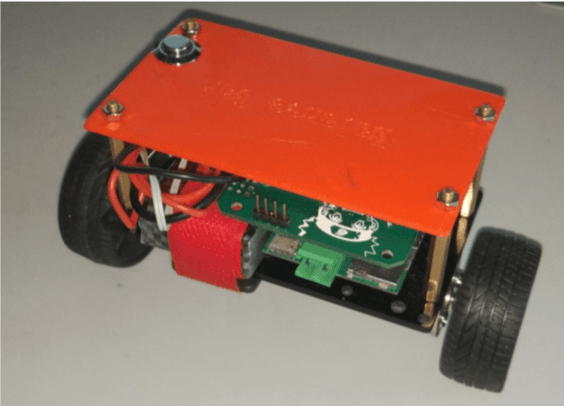
A self-balancing robot car controlled via Bluetooth with STM32 and Android support.

A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
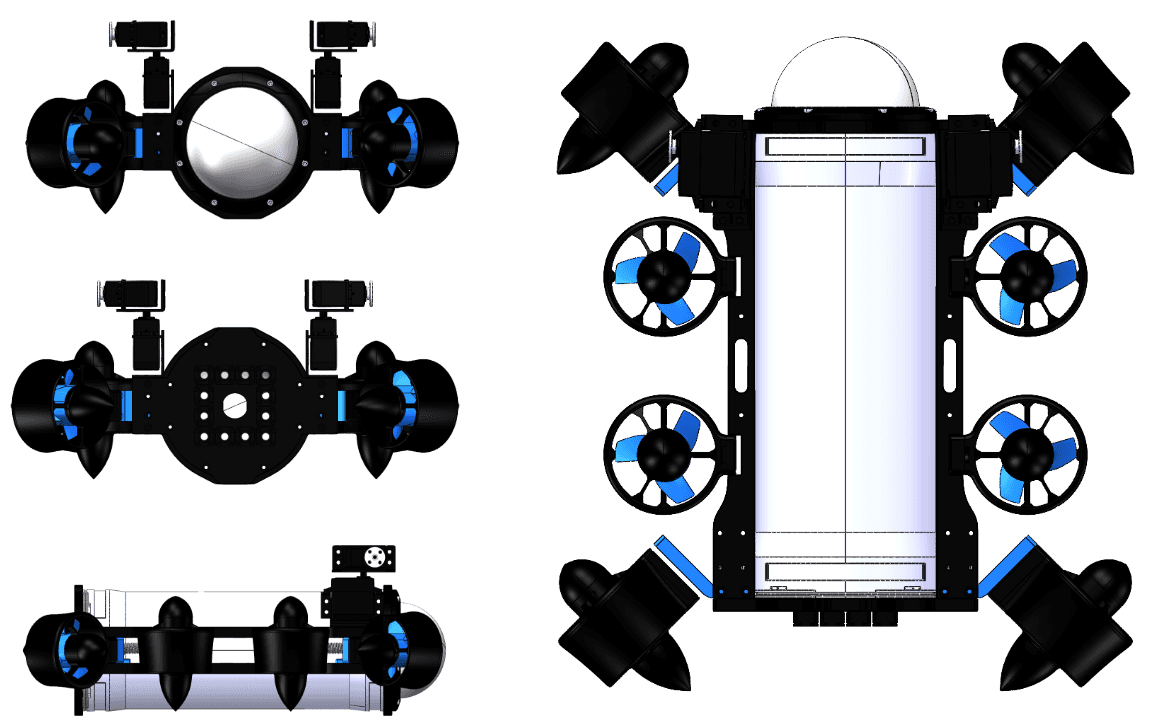
FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
A foldable flex PCB that folds into a tiny rover robot.
Robots 25–48 of 161