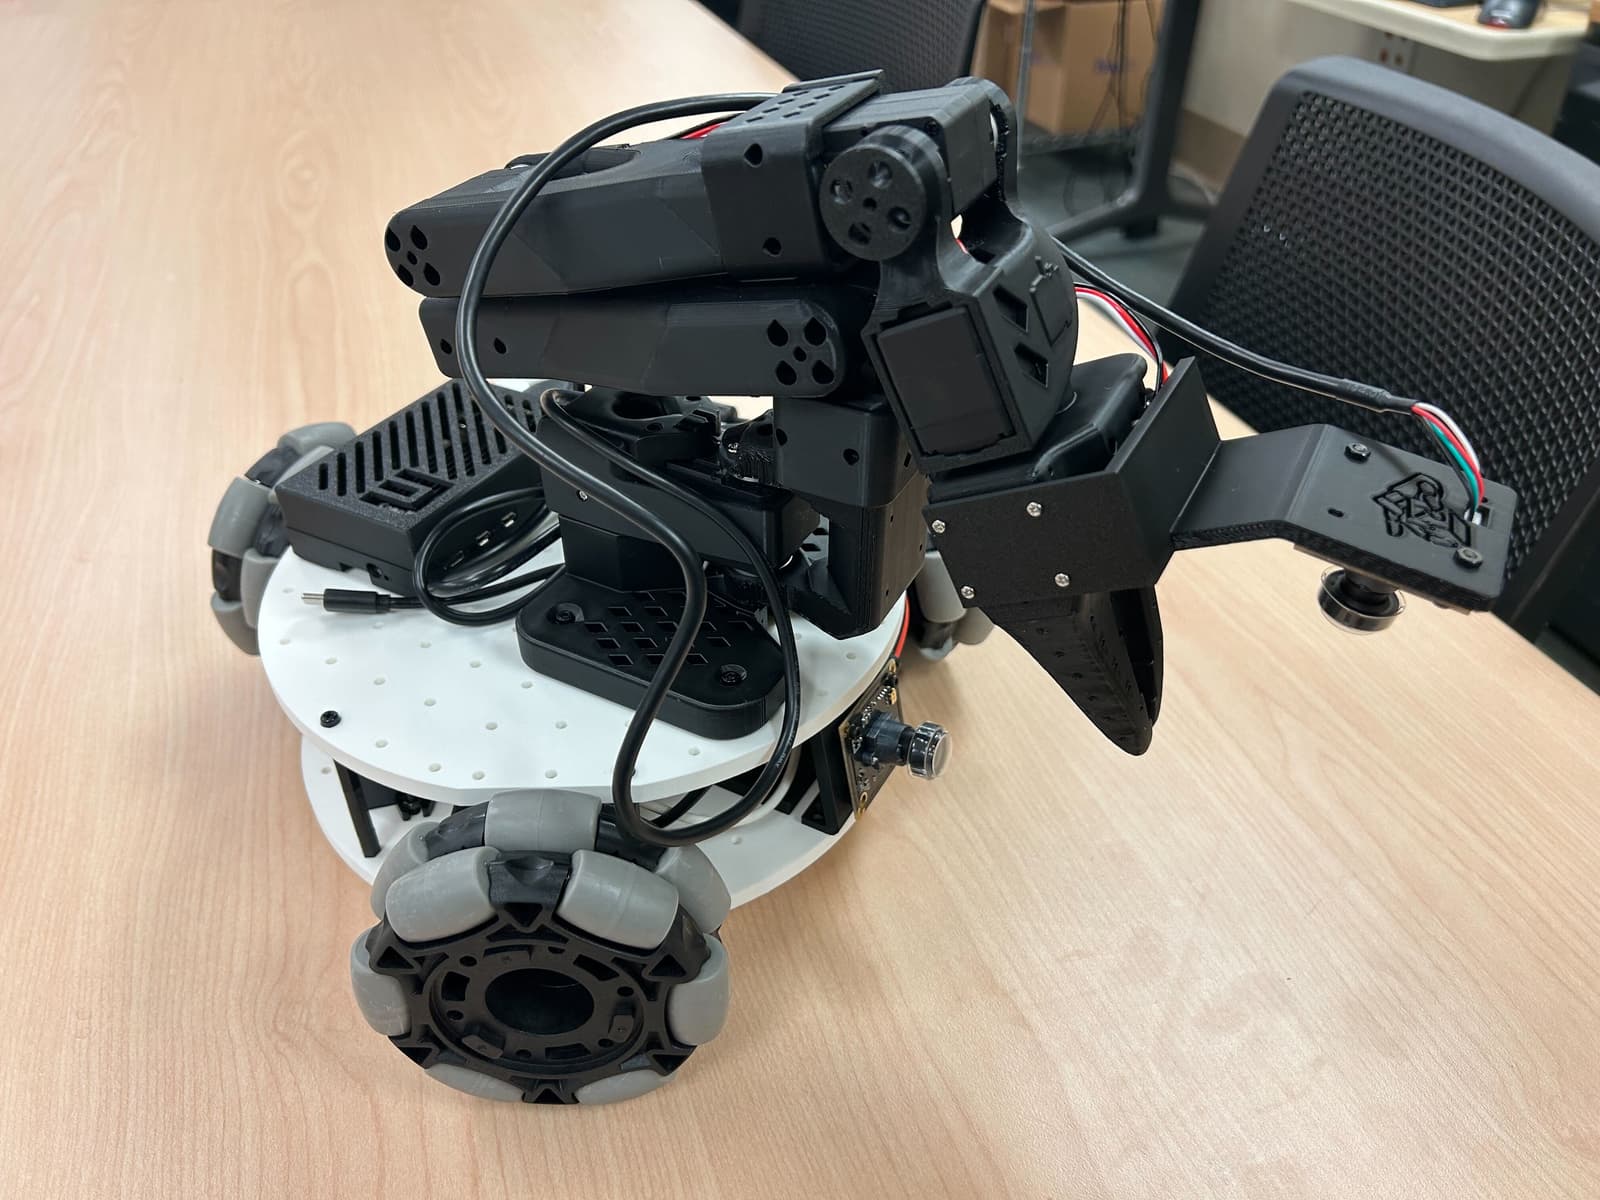
 Wheeled
LeKiwi
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
- Works with AI
- Level
- Intermediate
- Buildability
- 90/100
- Ready to build
- Cost
- €537.65
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 7 · Ready to build first, then by buildability
WheeledA low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
A 3D-printed bipedal robot about 42 cm tall, inspired by Disney's BDX droids, that walks with reinforcement-learning policies trained in MuJoCo.
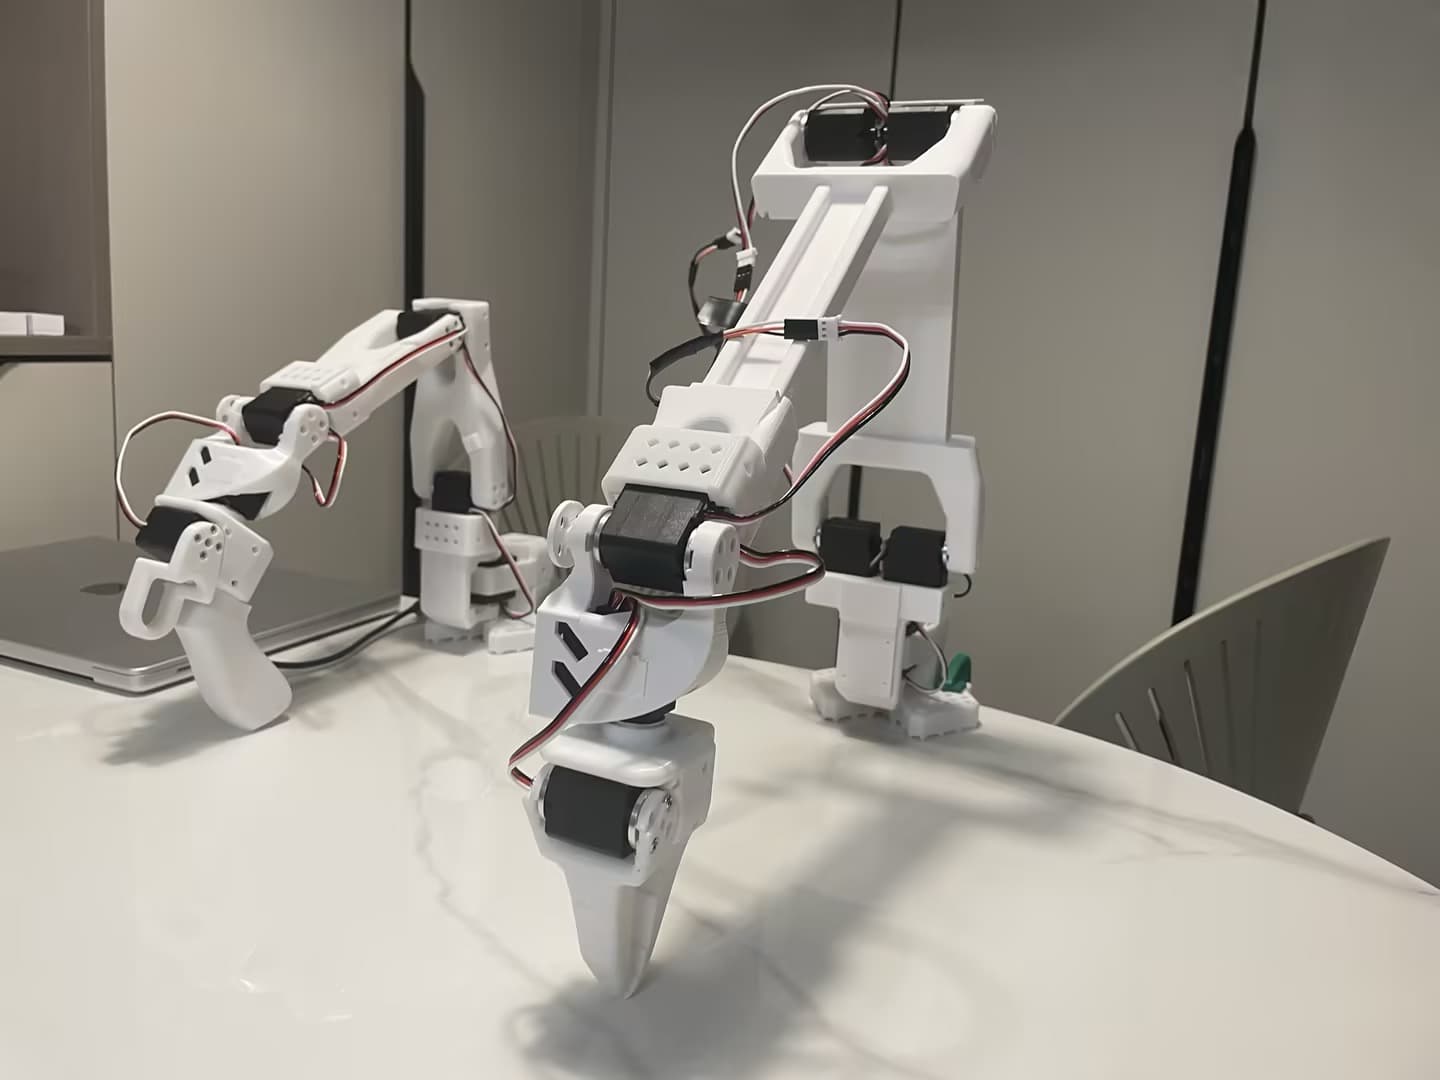 Robot arm
A low-cost, human-arm-scale open-source robotic arm compatible with Lerobot, based on the SO-100 arm, with a 600mm span and up to 500g payload.
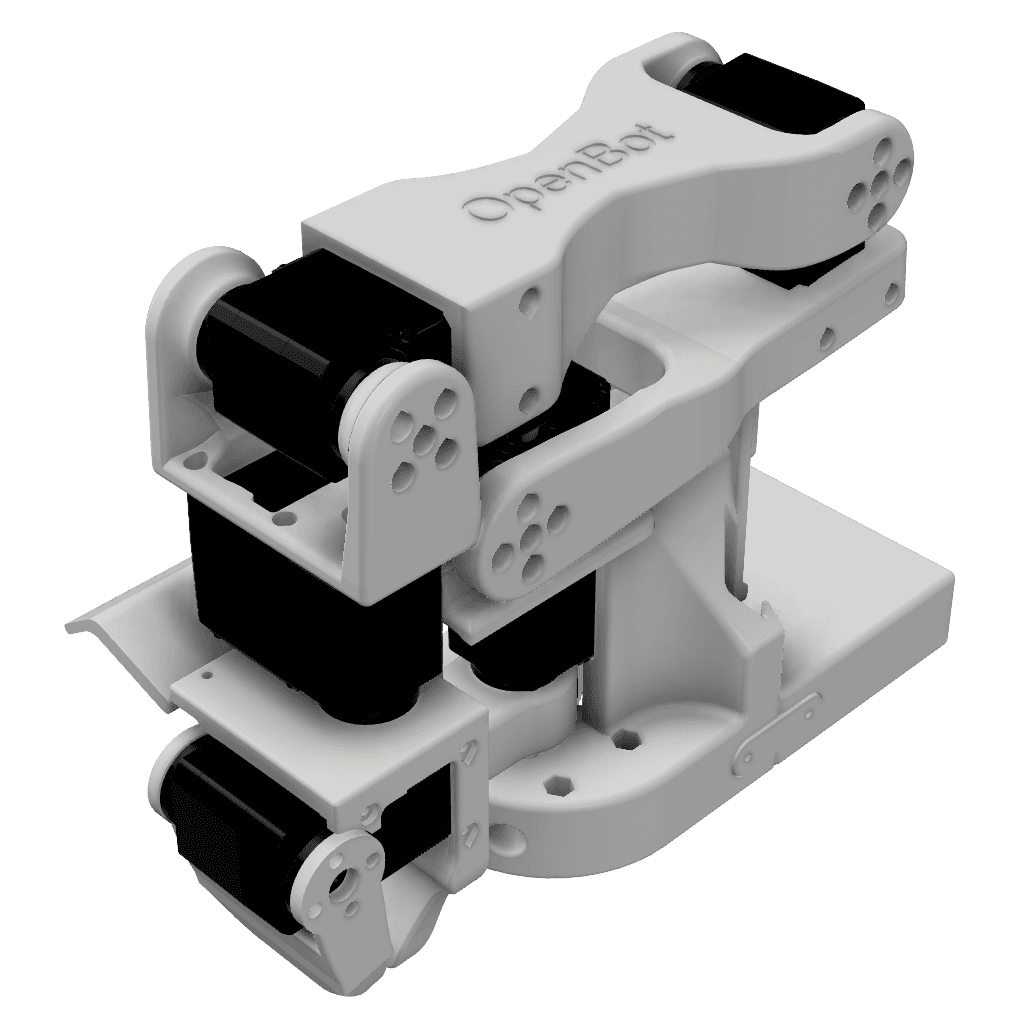 Robot arm
A cost-effective, ROS2-compatible 5-DoF robotic manipulator with a leader-follower teleoperation setup, designed to lower the barrier to entry for Embodied AI.
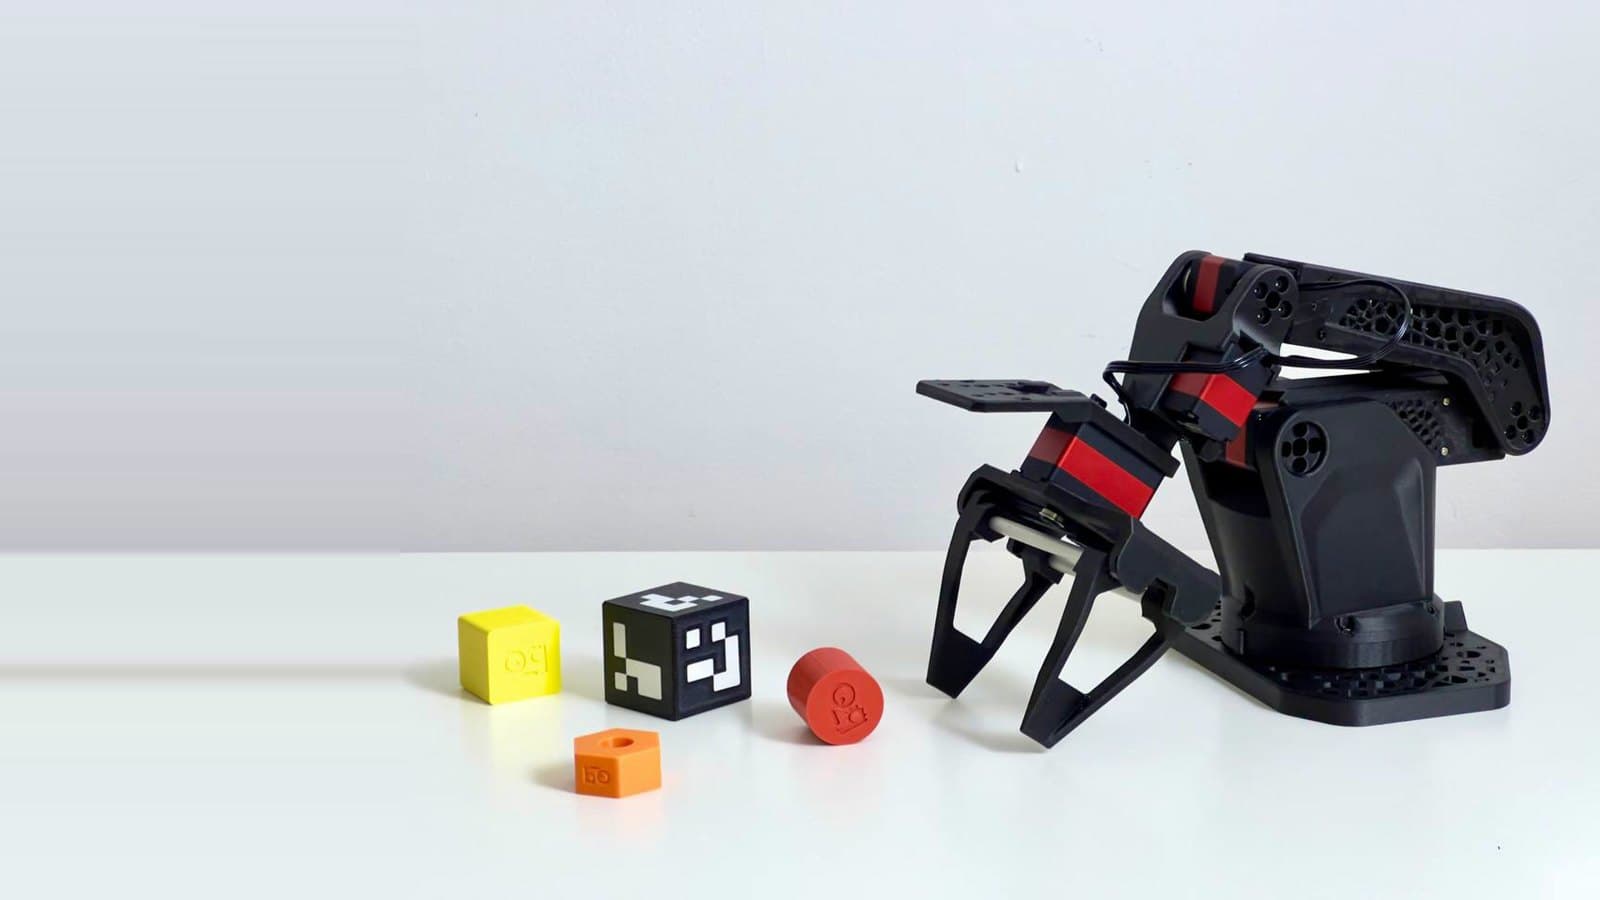 Robot arm
An open-source leader and follower robot arm kit with 5 degrees of freedom plus a gripper, for teleoperation and imitation learning.
A low-cost desktop 6-DOF robotic arm controlled via ROS, using Arduino UNO, an I2C servo driver, and six servos.
 Other
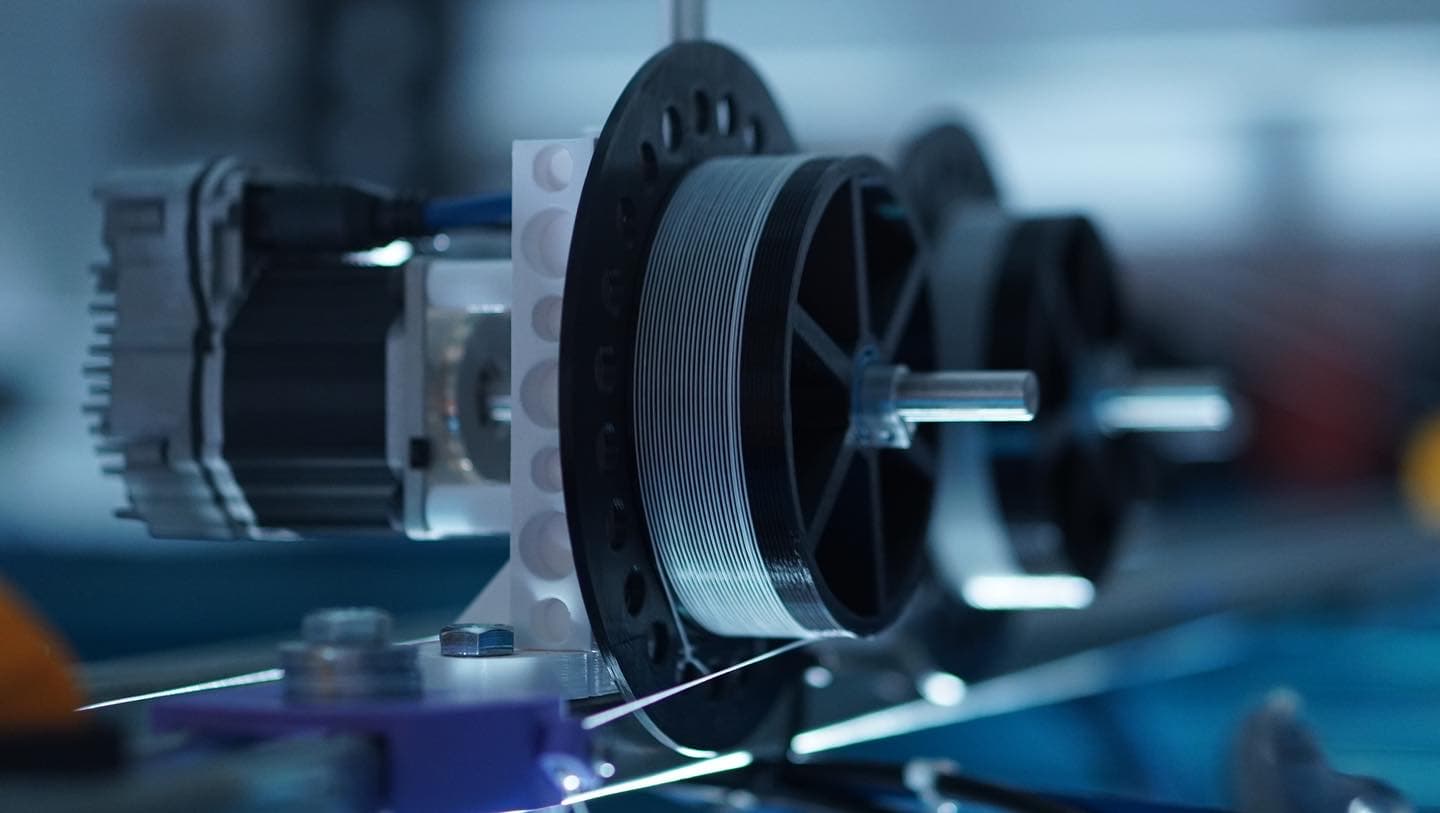
A toolkit for cable-driven robots that move objects through the air, built from 3D-printed cable drums on industrial servo motors, made for art installations.
 Wheeled
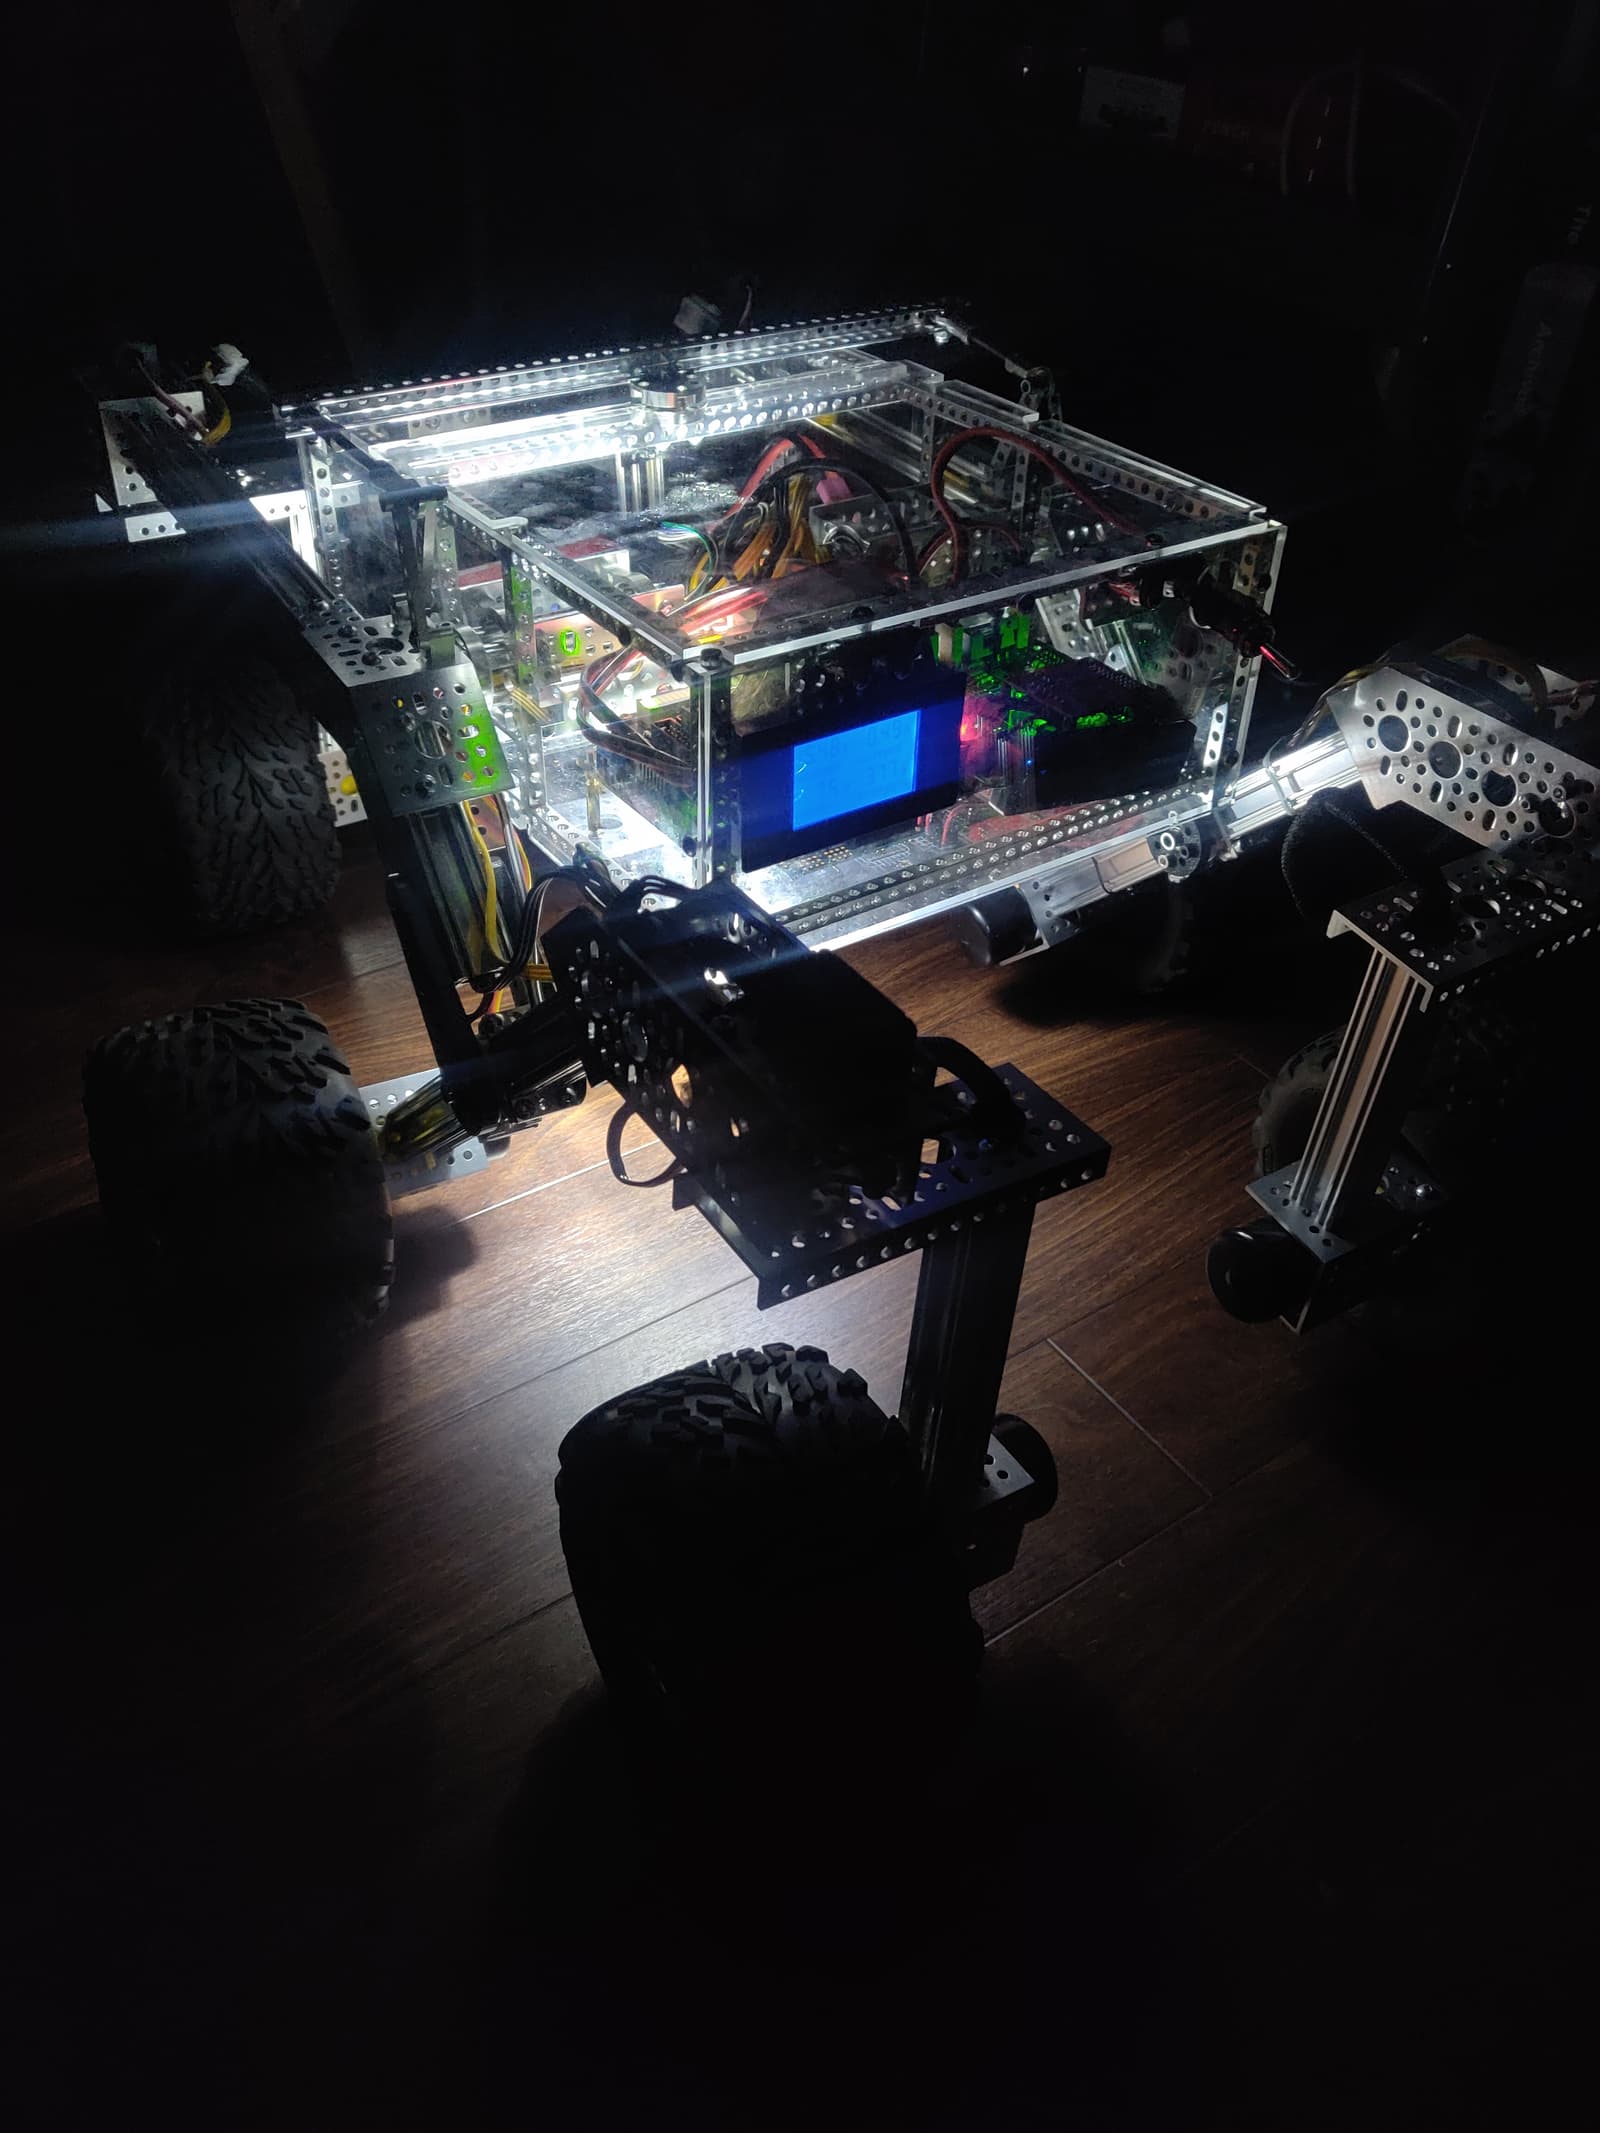
A build-it-yourself, six-wheeled rover scaled down from the JPL Mars rover design, made from consumer off-the-shelf parts.
 Robot arm
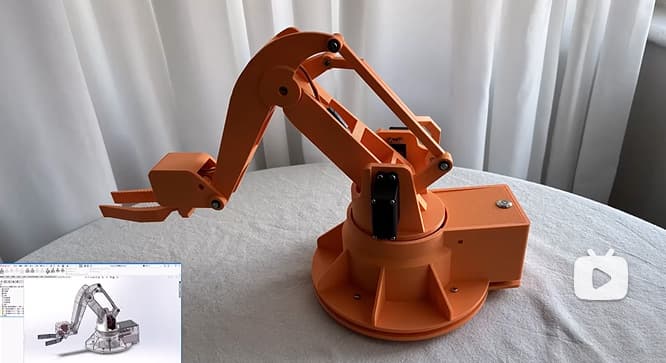
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
 Robot arm
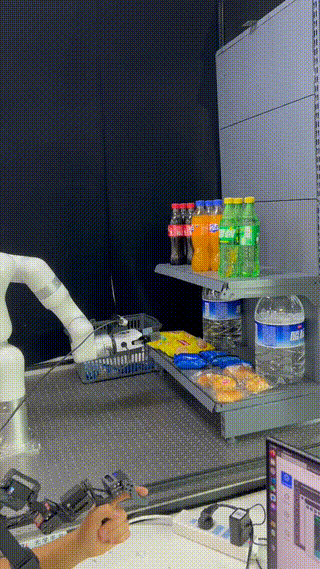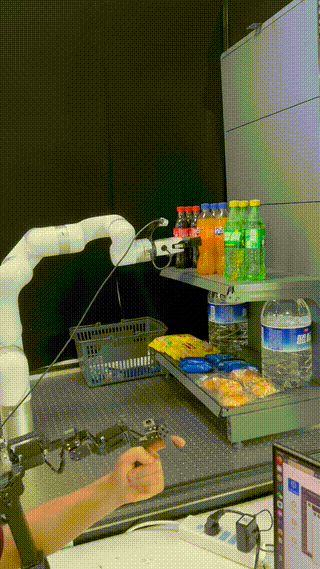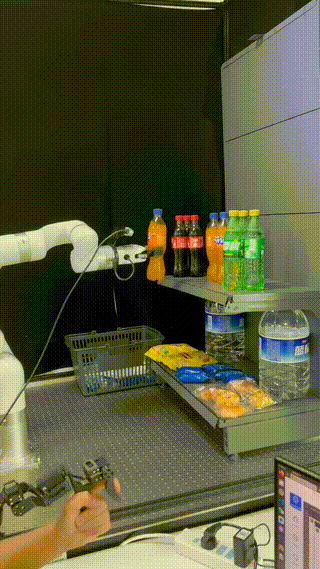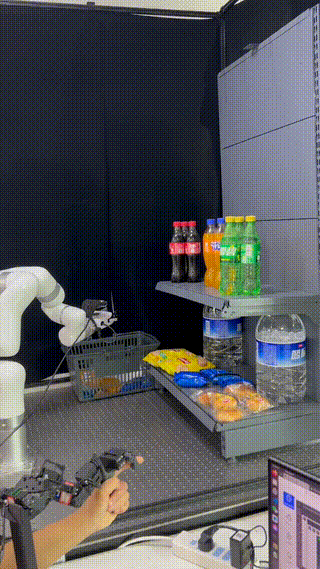
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
 Home
A lightweight home robot with modular architecture, supporting remote control, voice interaction, and human following.
An autonomous AI racecar built on the NVIDIA Jetson Nano that moves at high speeds and follows roads using neural networks.
 Other
An ultra-low-cost self-balancing robot that can run a neural network to stay balanced and be controlled wirelessly, built for teaching RL, ML, AI and control.
A low-cost six-axis robotic arm using DAMIAO motors and sheet metal structural parts, designed for students and hobbyists.
 Quadruped
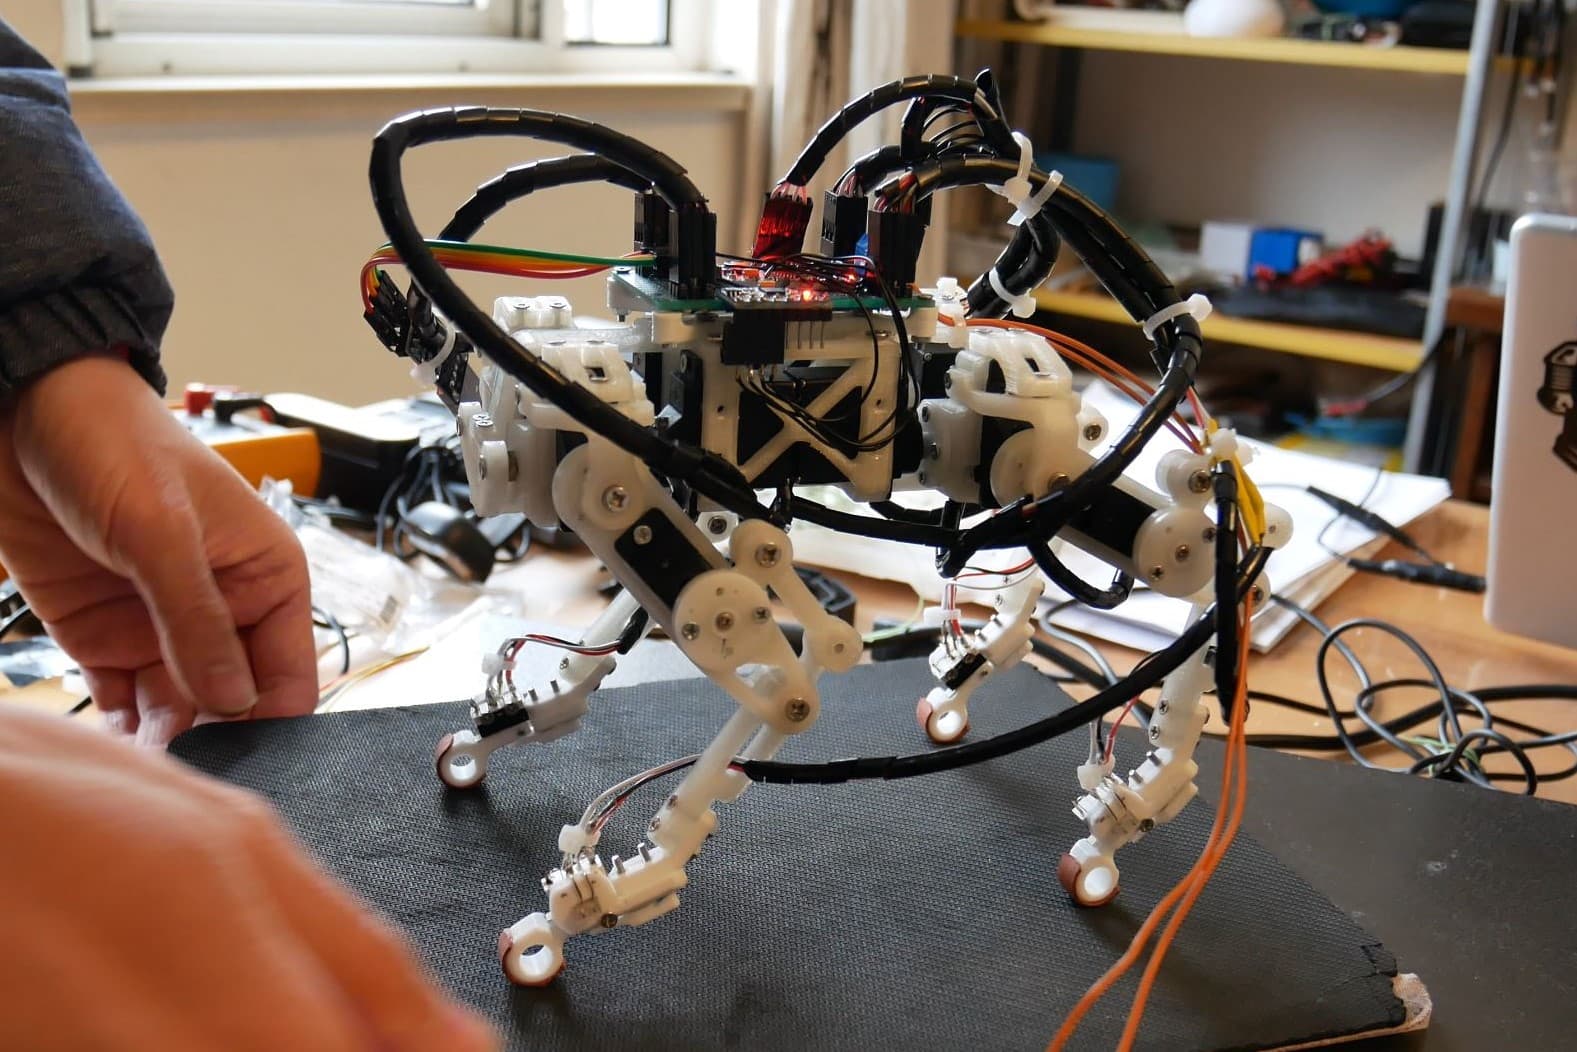
A low-cost 12-DOF quadruped robot actuated by hobby servos, with optional feet sensors and a trot gait firmware.
An open-source 6-degree-of-freedom robotic arm designed for simulation, kinematics research, and reinforcement learning-based end-effector control.
 Robot arm
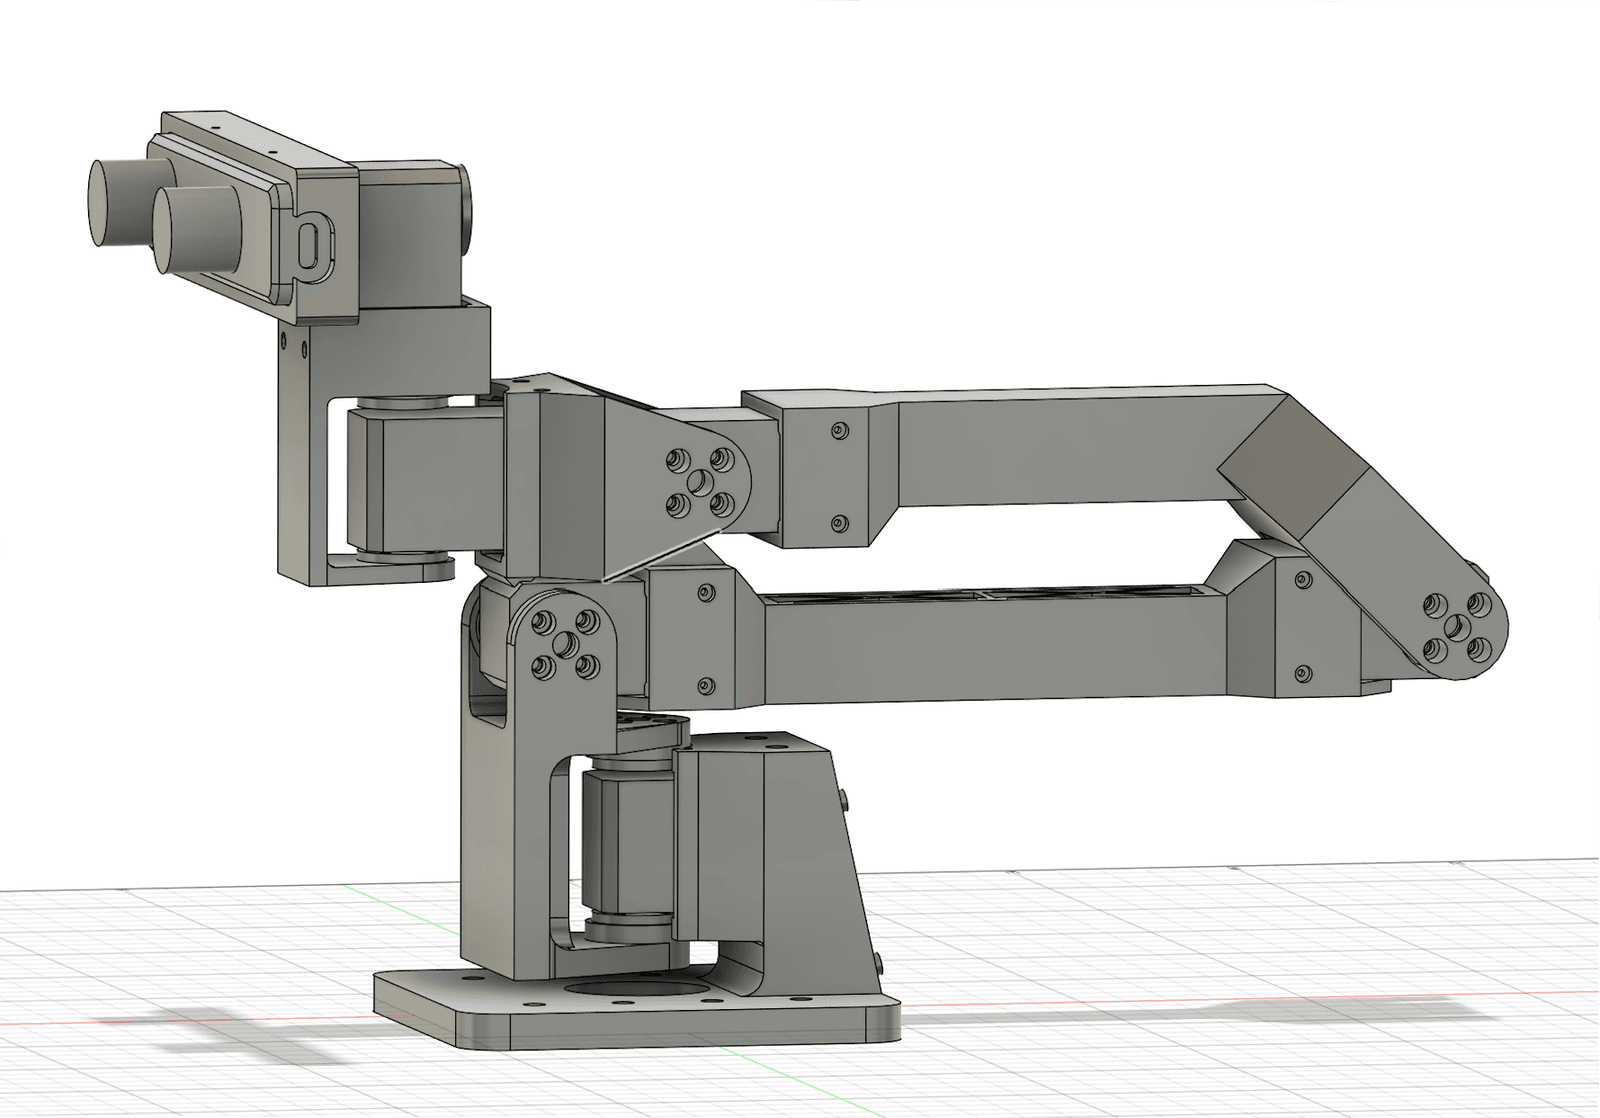
A 6-DOF camera arm with a ZED Mini stereo camera that streams video to a WebXR VR headset and follows head tracking for teleoperation.
 Robot arm
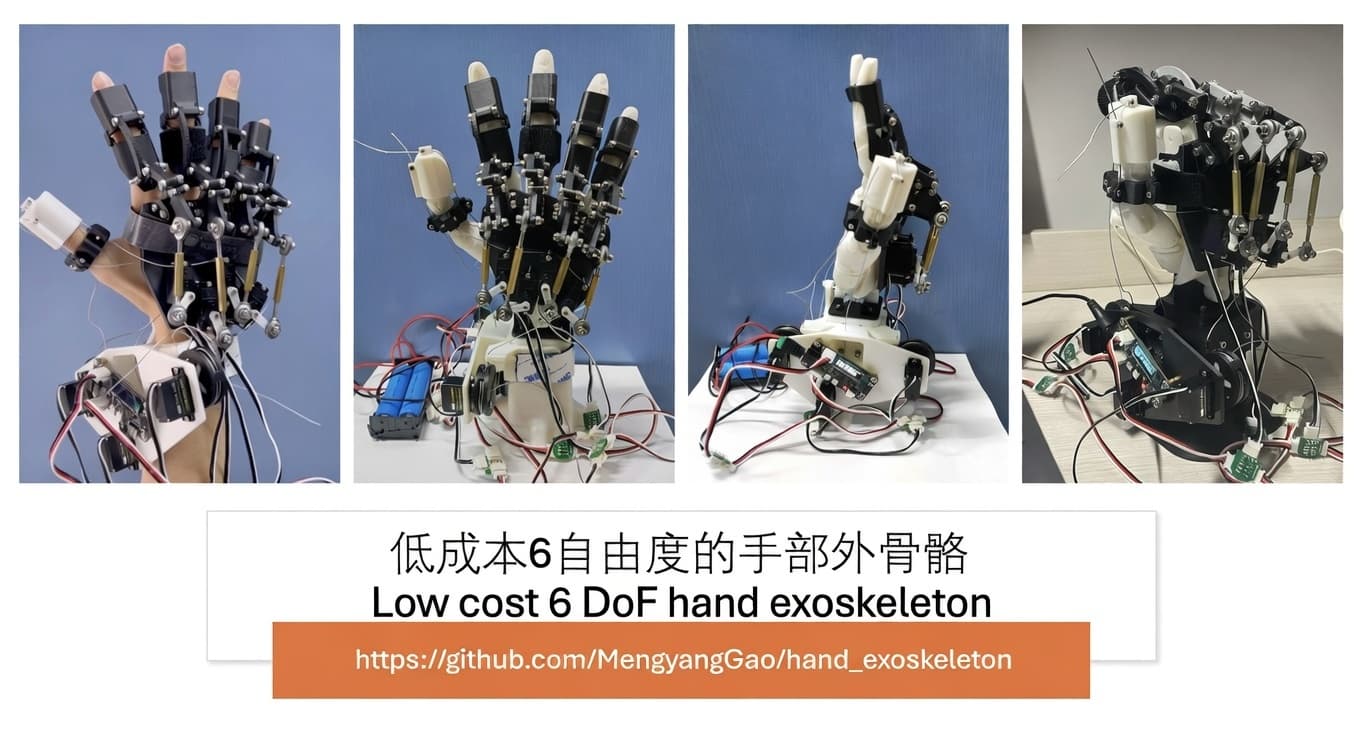
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
An open-source desktop quadruped robot featuring high-torque HTDW4438 motors, URDF models, and real-machine SDK for development and Sim2Real integration.
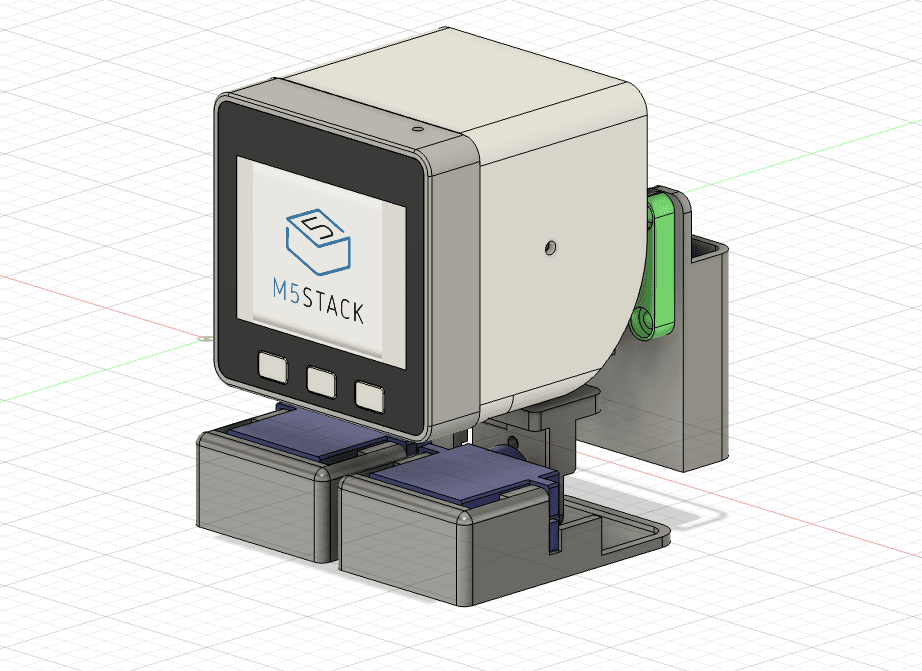 Other
A small bipedal walking robot controlled by an M5Stack board, with a sliding battery that shifts its balance between legs.
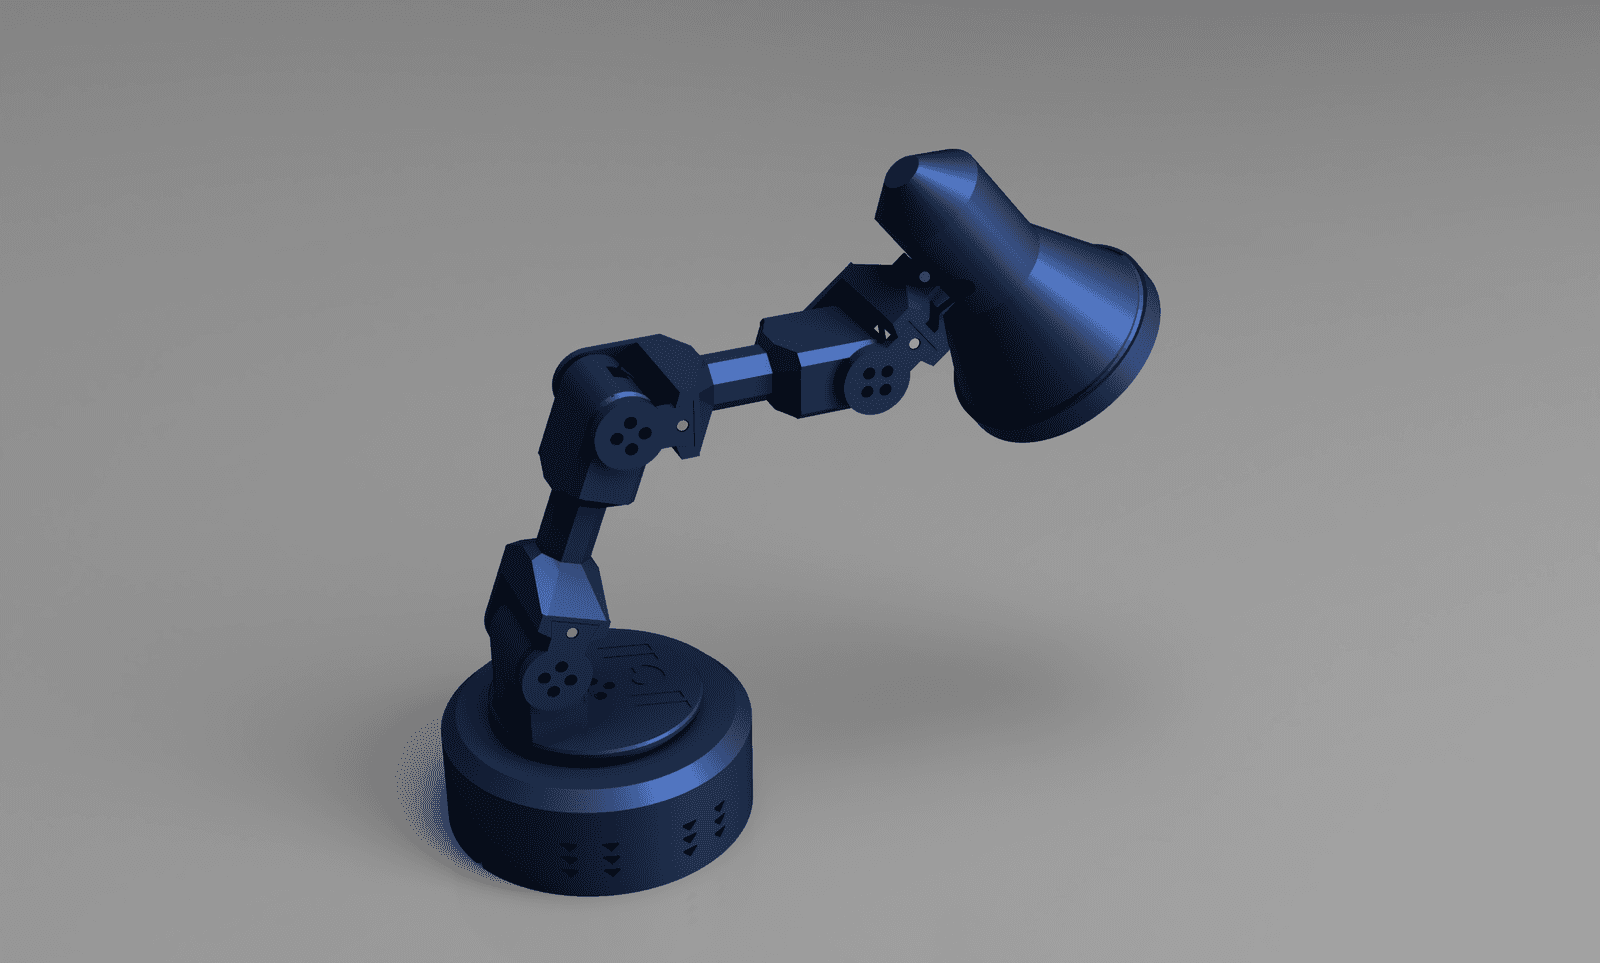 Robot arm
NormaCore is a unified open-source toolkit and platform for developing and operating physical systems, including a 7+1 DoF 3D-printed robotic arm (ElRobot) and a desk lamp.
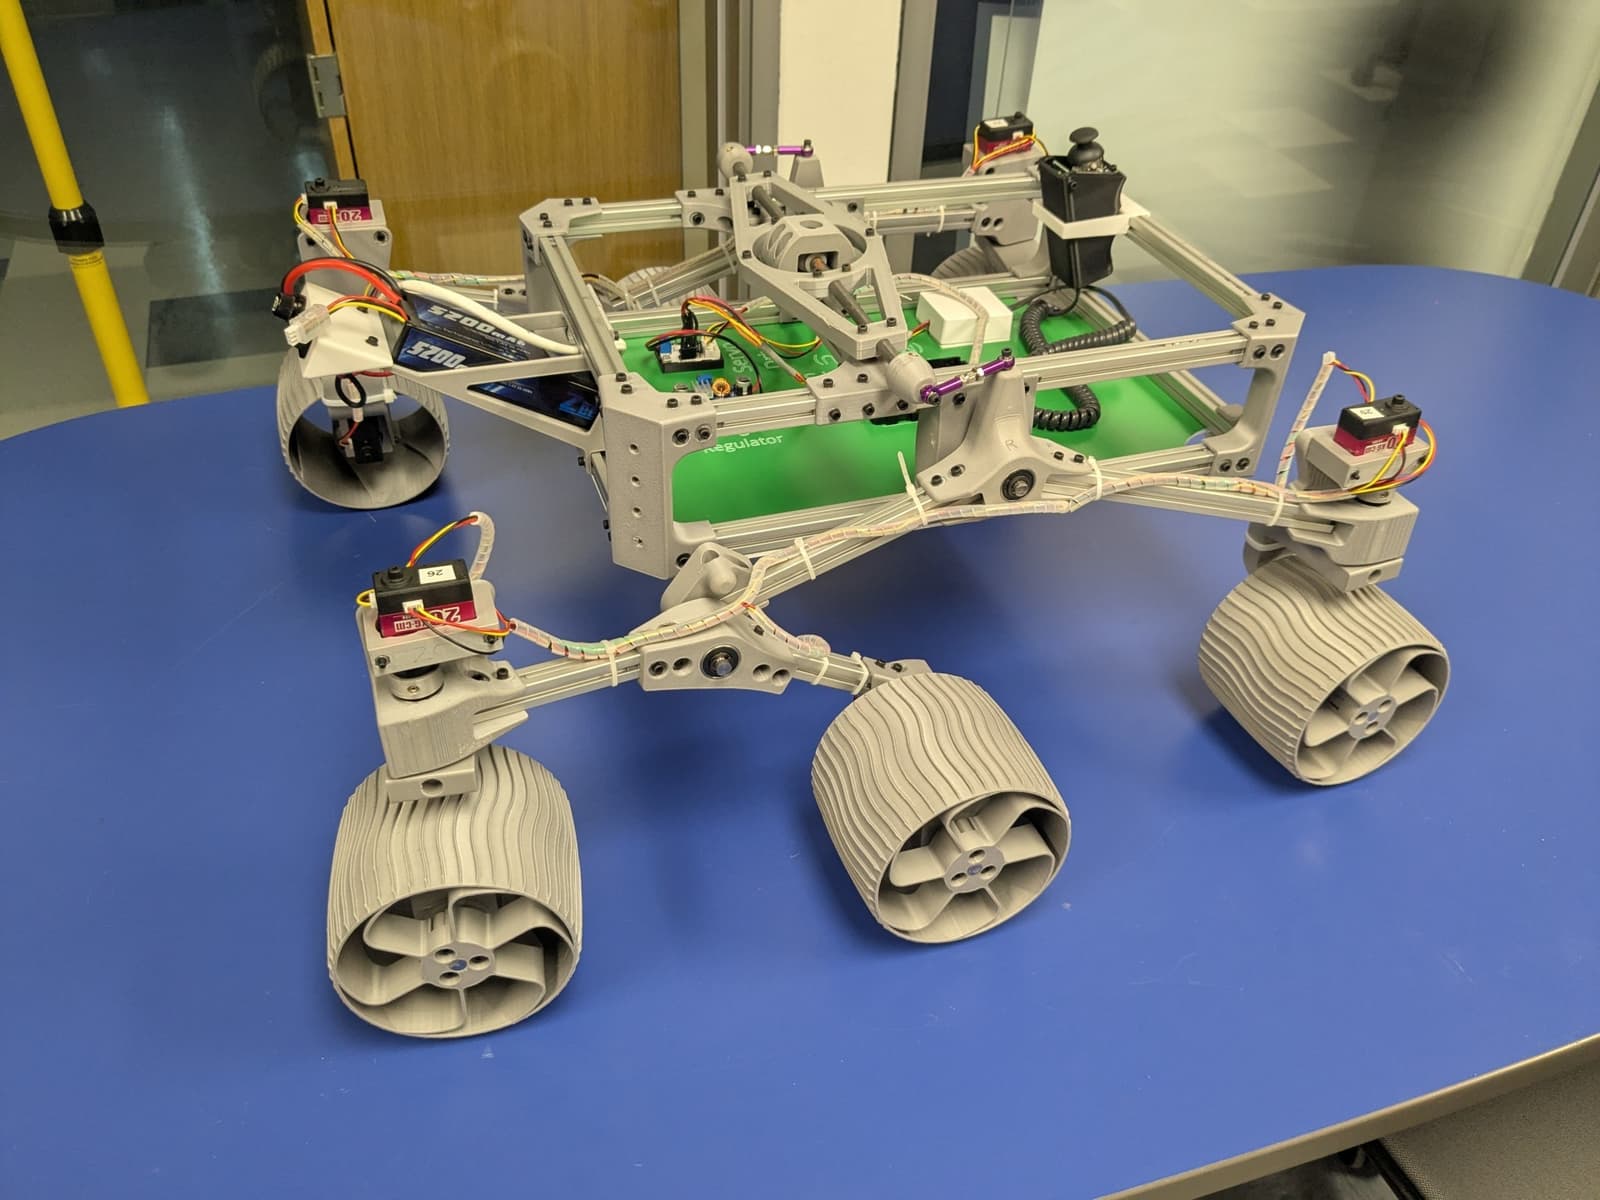 Wheeled
A motorized model of Mars rovers Curiosity and Perseverance that reproduces Rocker-Bogie suspension, built with 3D-printed parts and serial bus servo wheels.
A self-balancing robot car driven by two BLDC motors using the SimpleFOC library and ESP32 microcontroller.
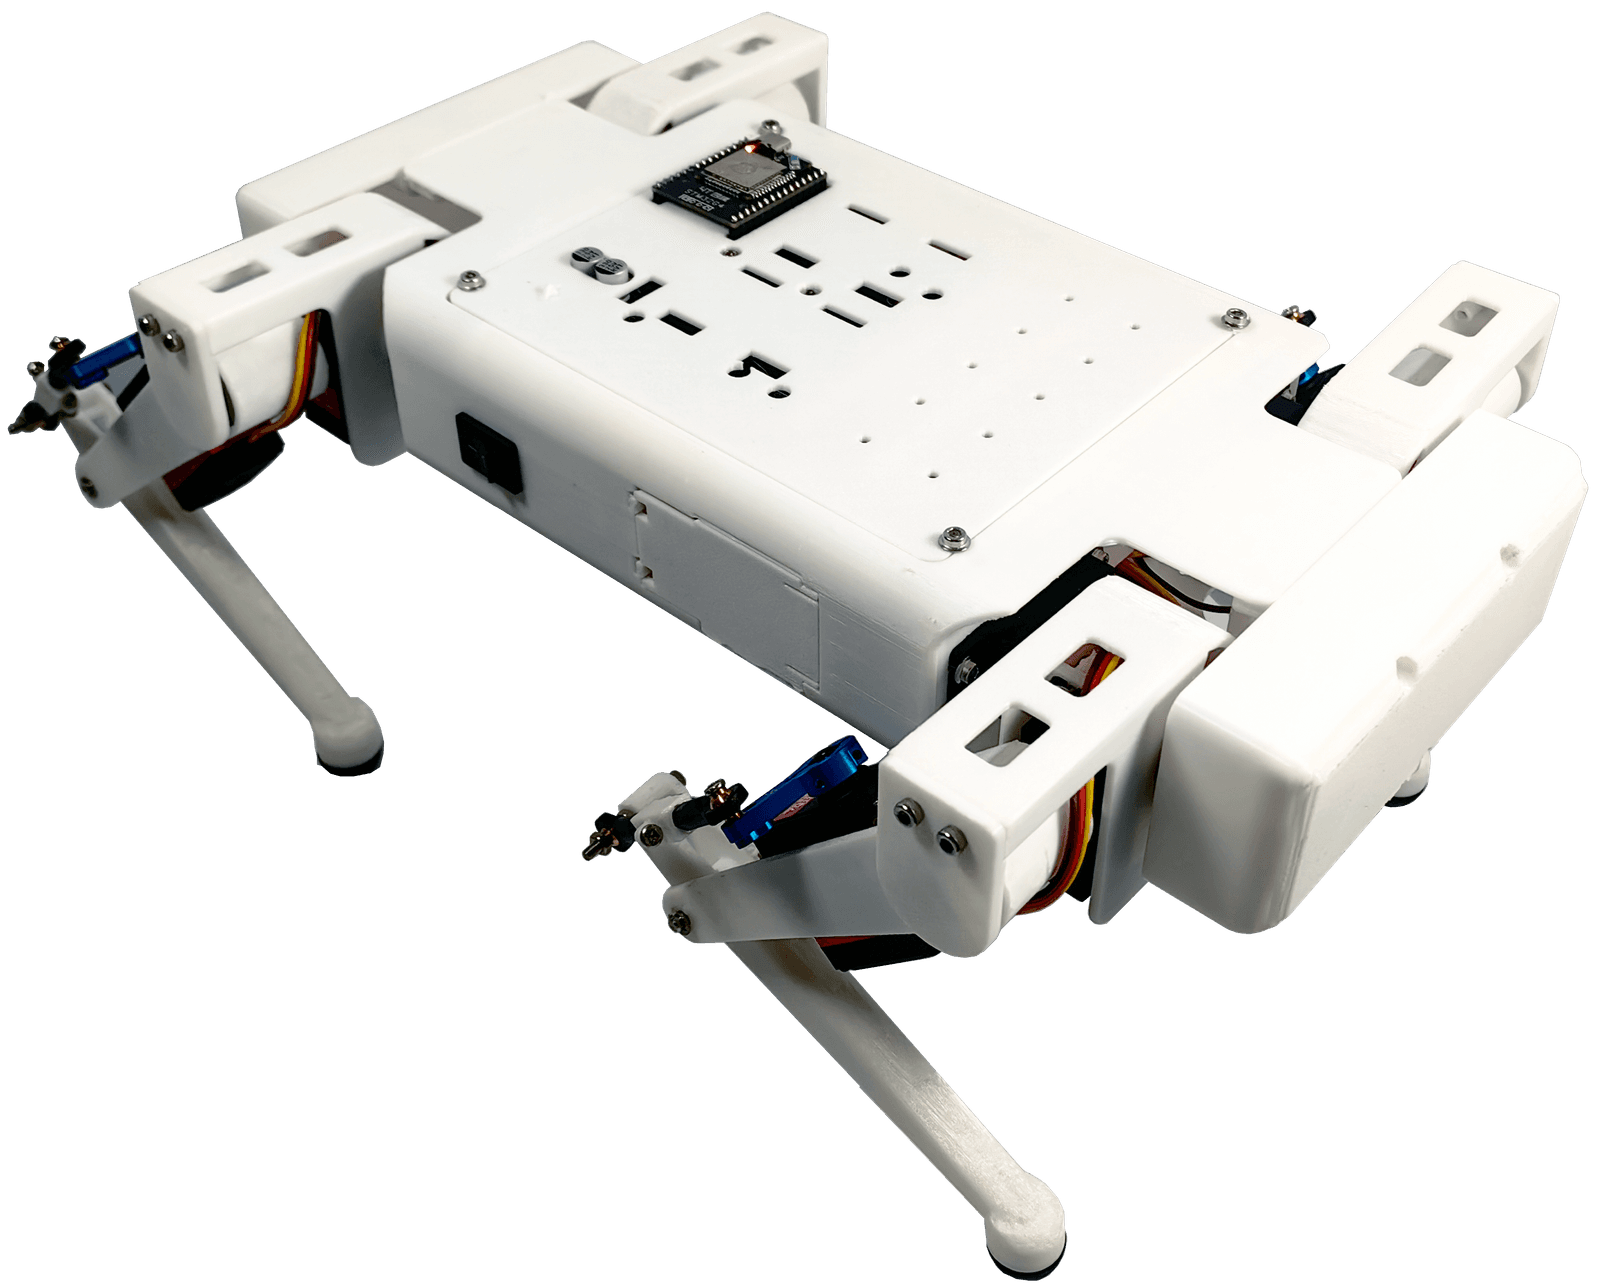 Quadruped
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
Robots 1–24 of 161