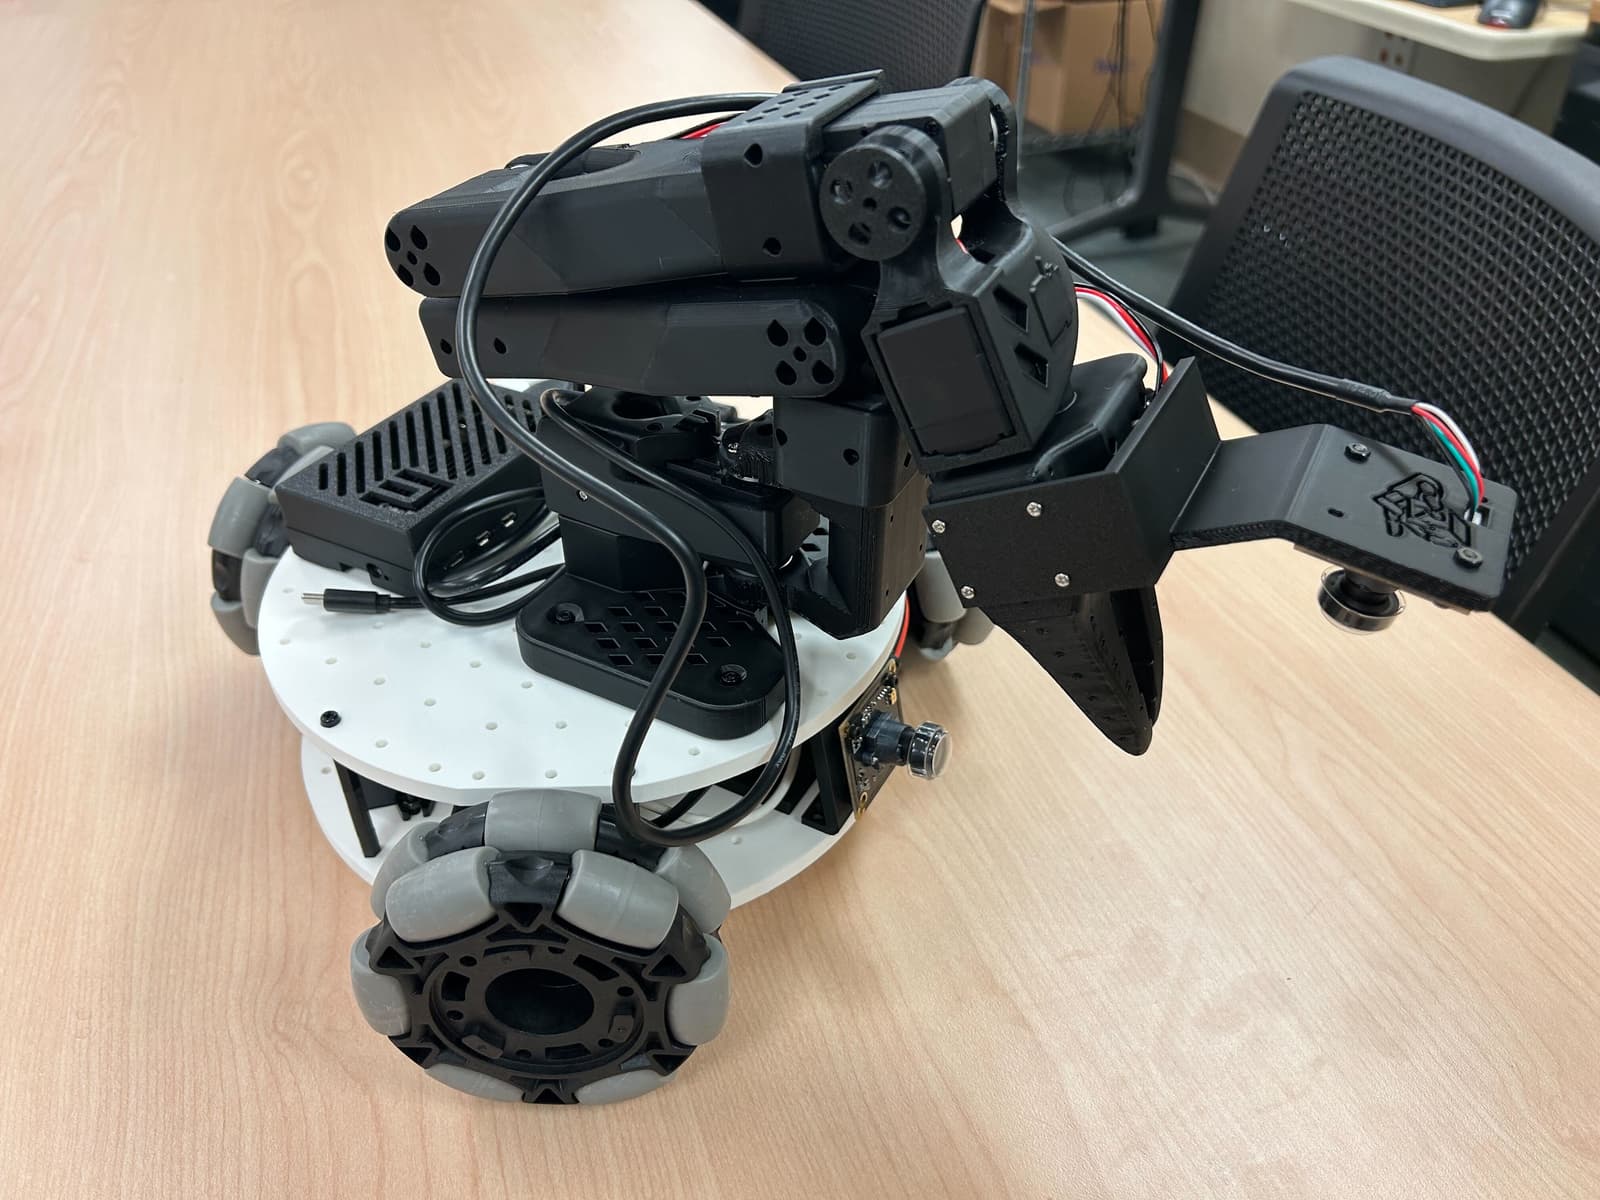
LeKiwi
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
WheeledIntermediateBuildability 90/100 · Ready to build
- Works with AI
€537.65
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 2 · Ready to build first, then by buildability
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
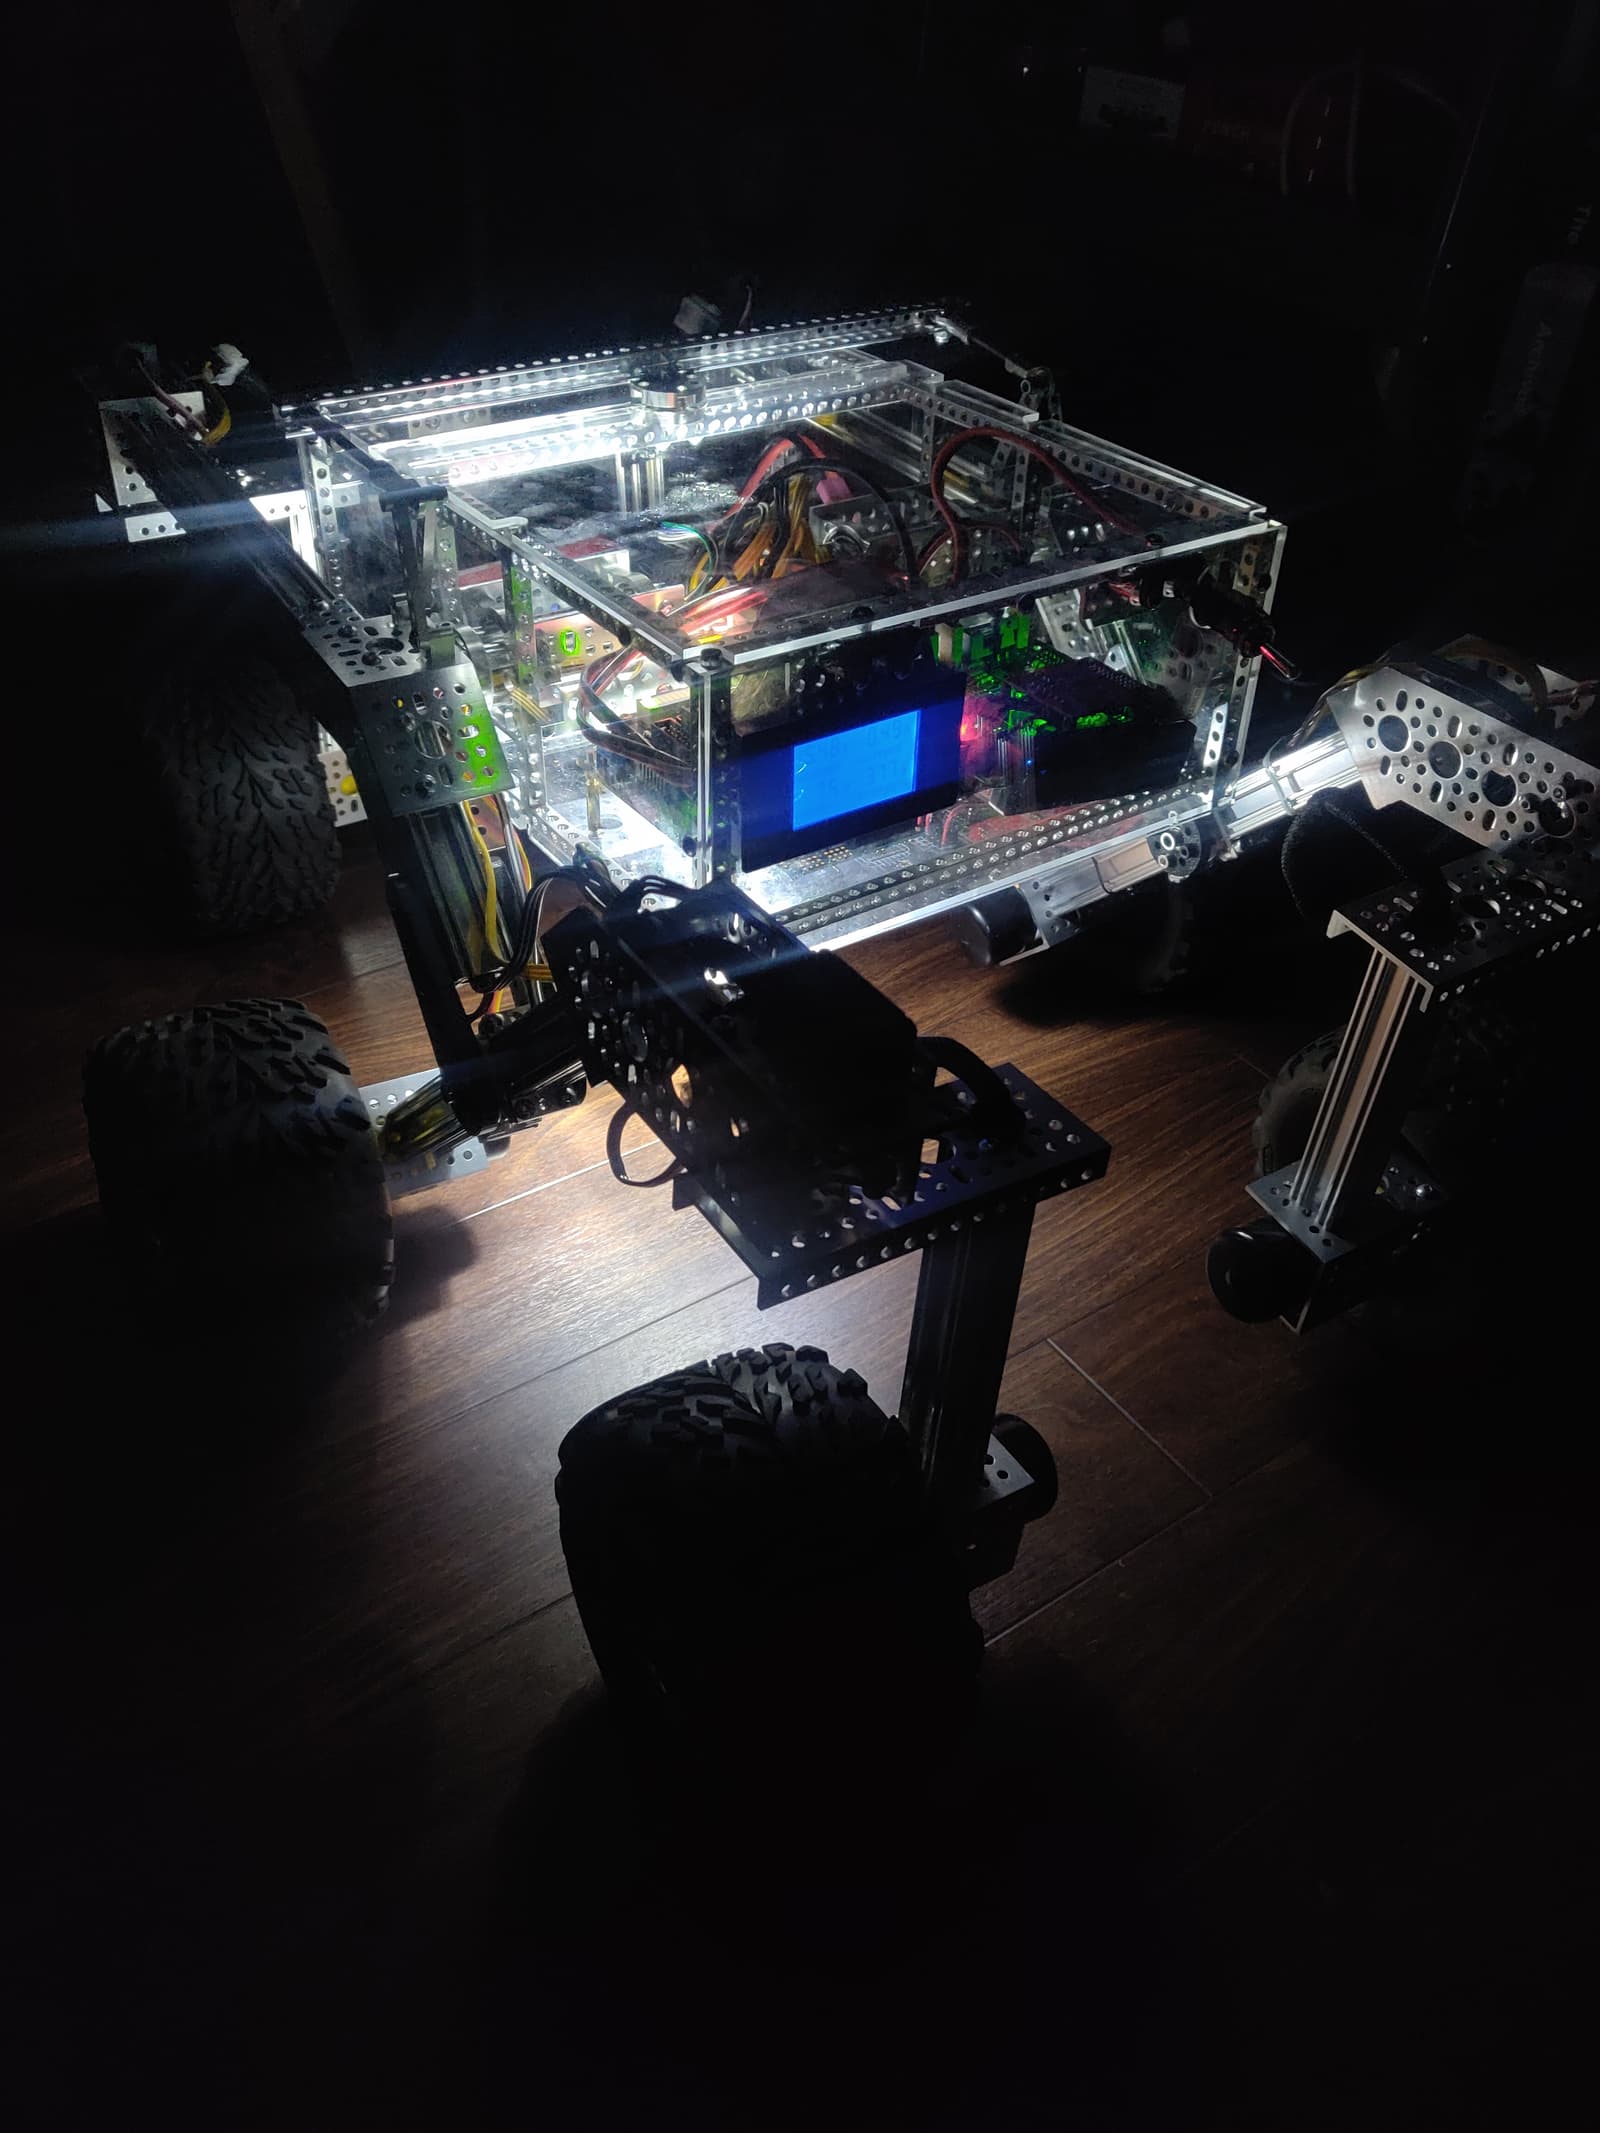
A build-it-yourself, six-wheeled rover scaled down from the JPL Mars rover design, made from consumer off-the-shelf parts.
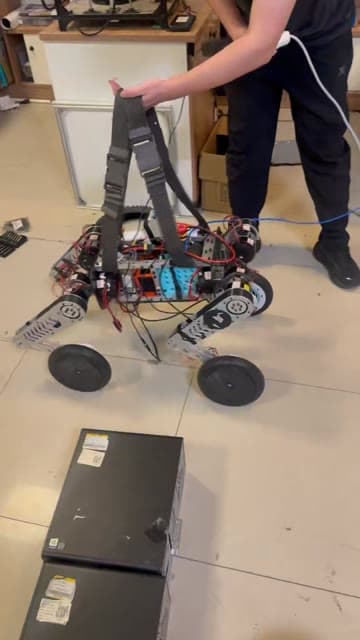
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
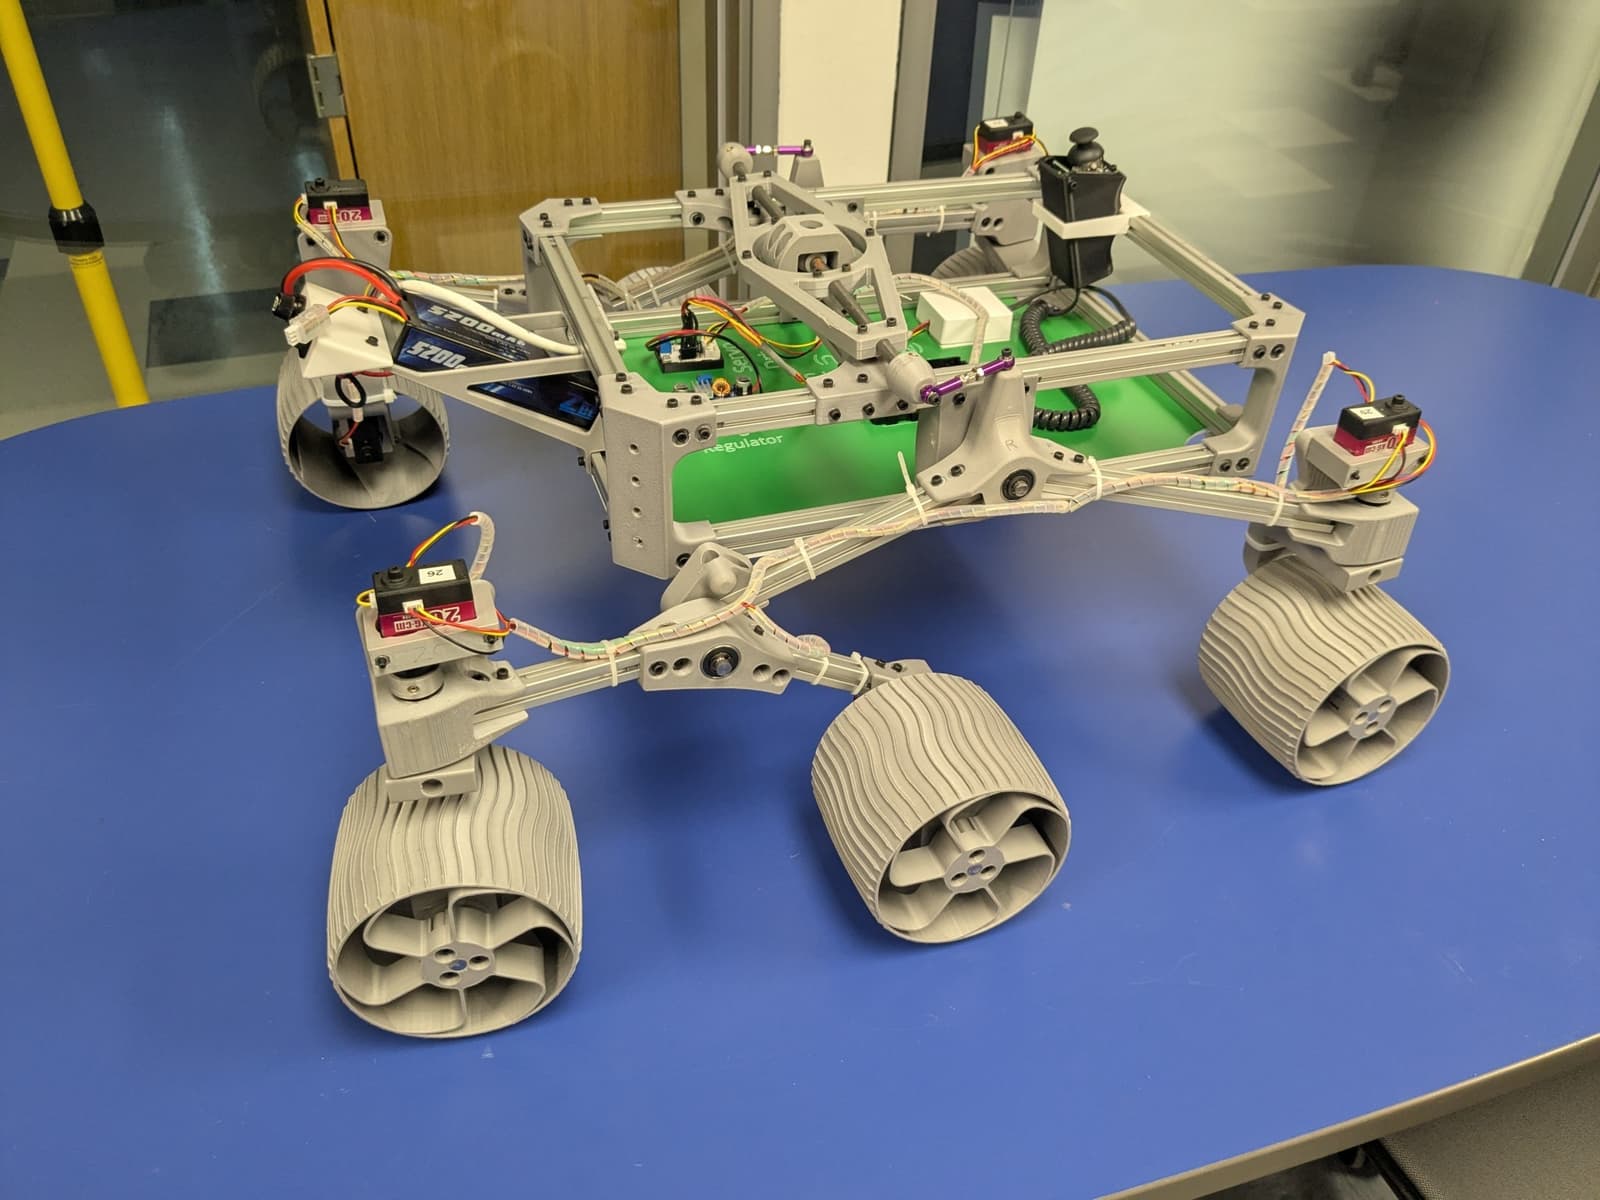
A motorized model of Mars rovers Curiosity and Perseverance that reproduces Rocker-Bogie suspension, built with 3D-printed parts and serial bus servo wheels.
A self-balancing robot car driven by two BLDC motors using the SimpleFOC library and ESP32 microcontroller.
A tiny desktop two-wheeled legged robot with ESP32 control and brushless motors.
A low-cost small electric vehicle body that uses an Android smartphone as its brain, supporting person following and autonomous navigation.
A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.
Open-source, fully 3D-printable ESP32 rover platform with WiFi or ExpressLRS control, available in two variants.
A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
Watney is a low-cost, 3D-printable, Raspberry Pi-based FPV telepresence rover with HD video and bi-directional audio.
A small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.
A 3D-printed Mars Perseverance-style rover replica with a 6-wheel drive, 4-axis robotic arm, and remote control with touchscreen and web dashboard.
A modular, adaptable all-wheel-drive rover built around a Raspberry Pi Pico board, with 3D-printed motor mounts and optional add-on bumpers and decks.
A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.
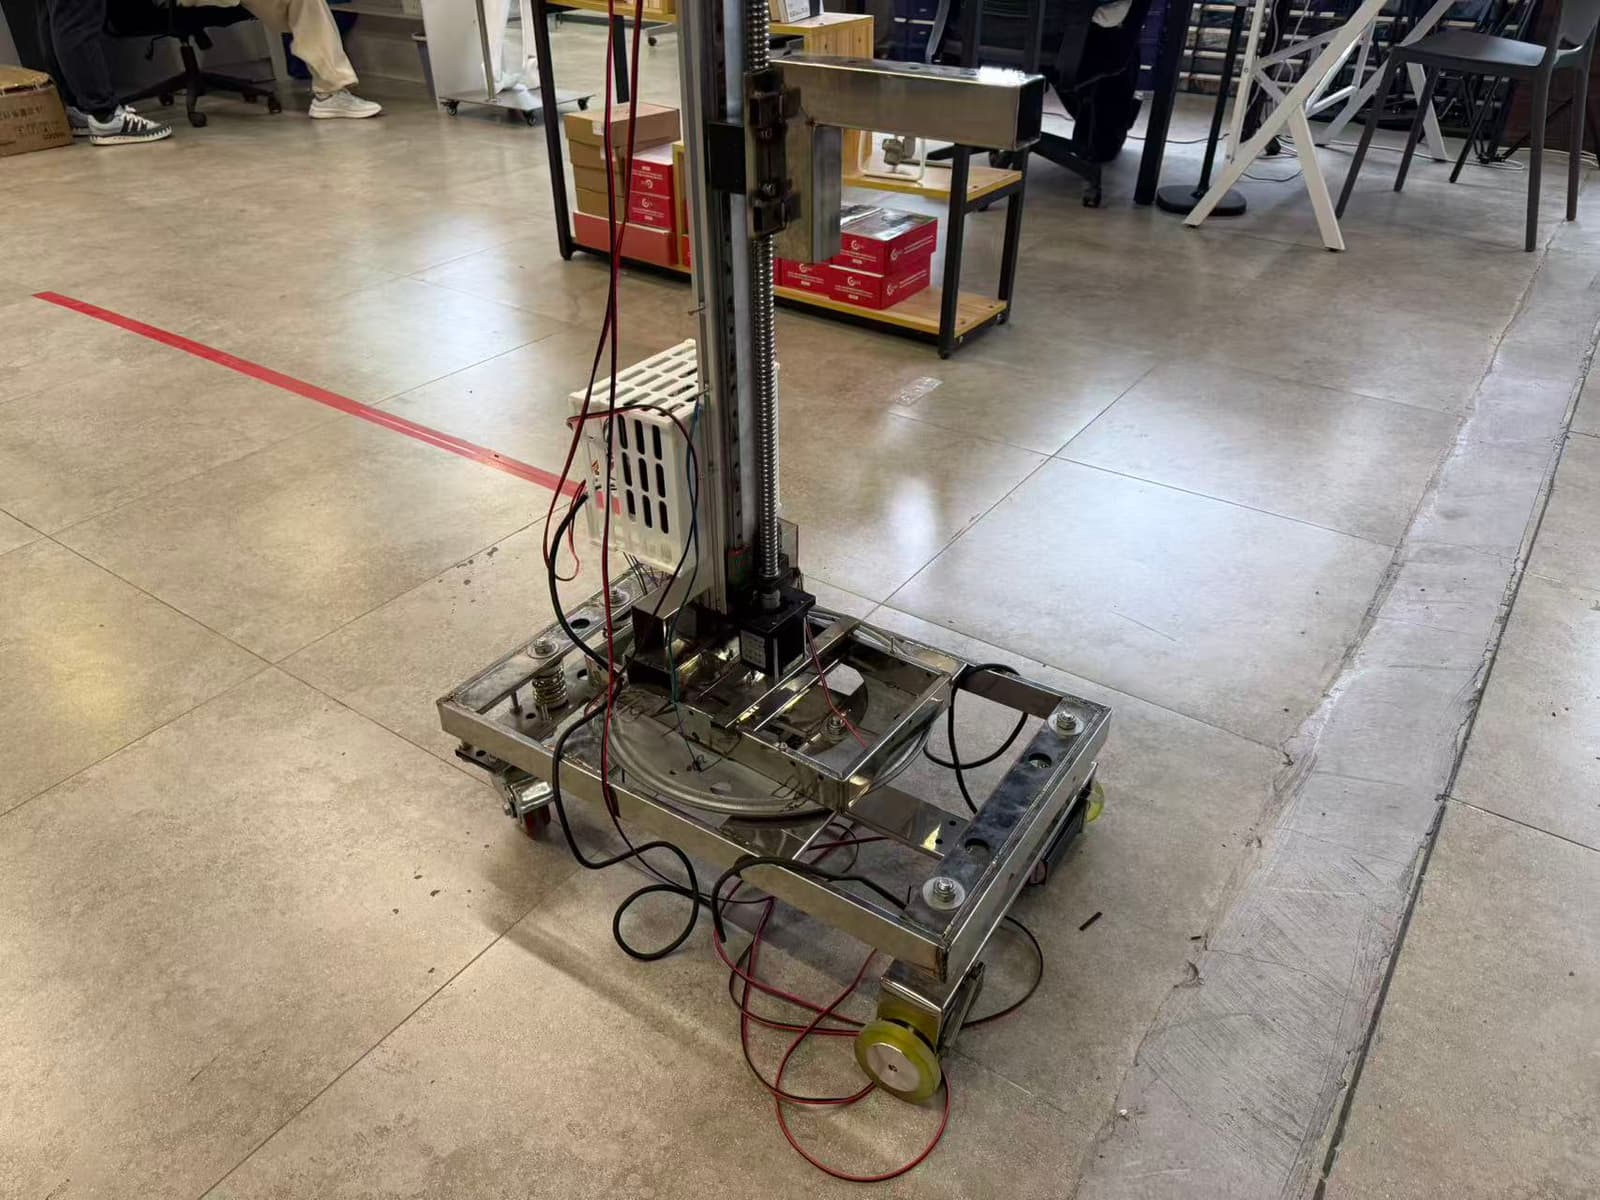
An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.
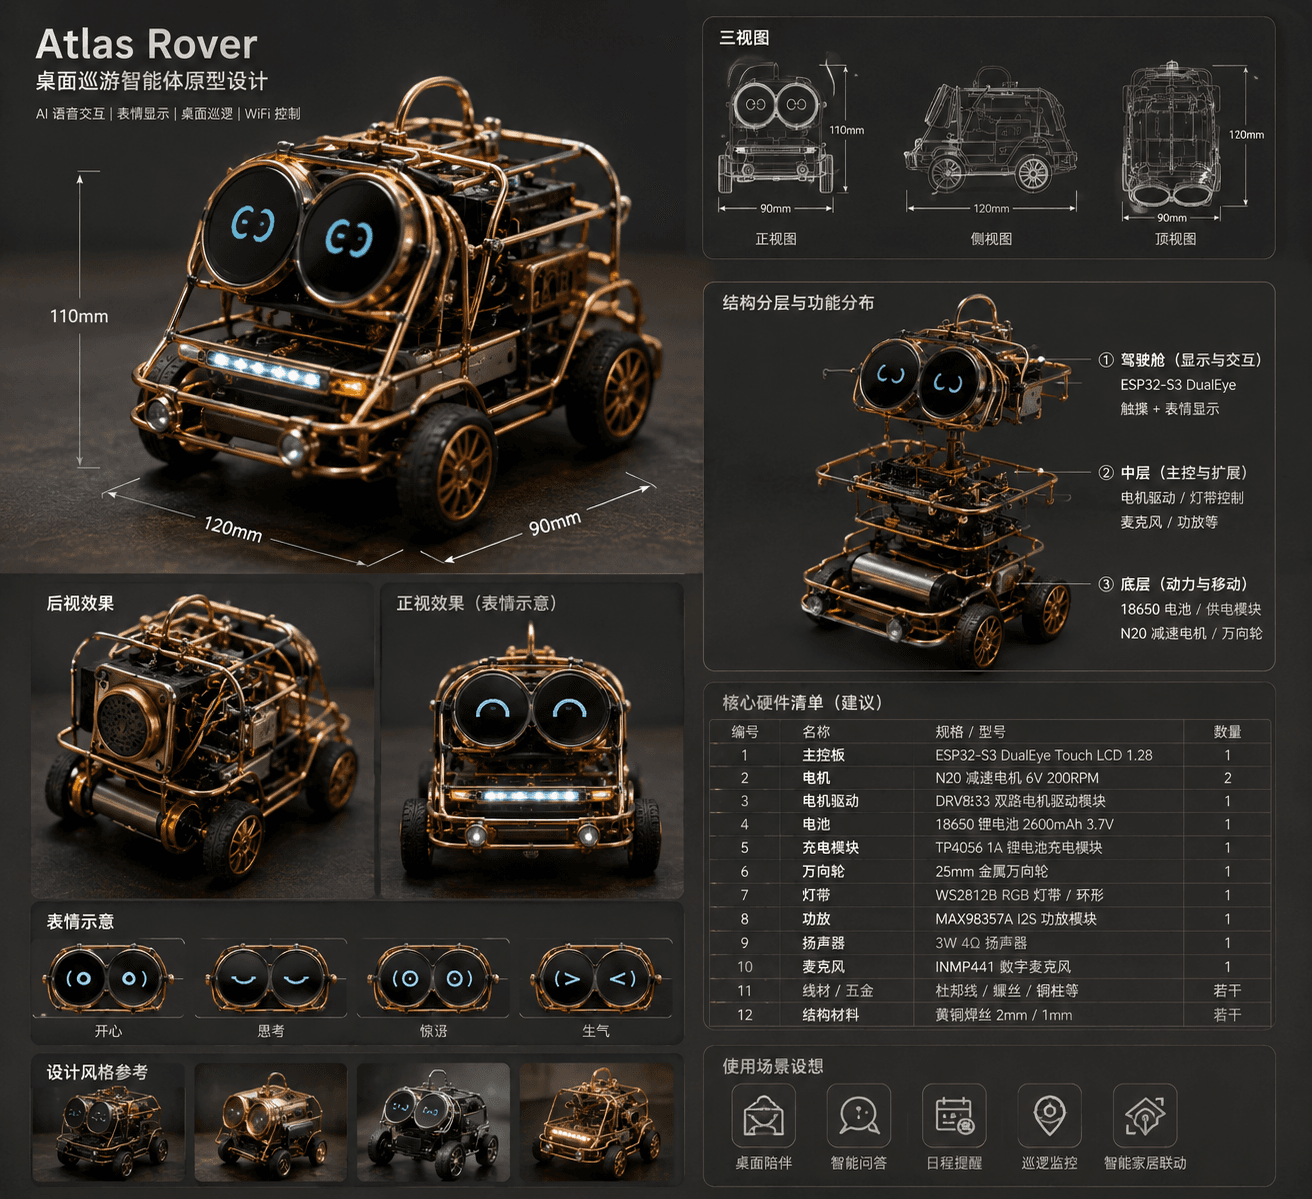
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
A self-balancing robot car controlled via Bluetooth with STM32 and Android support.
A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.
An open-source AGV chassis based on ROS for learning and practical applications.
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
A series of open-source remote-controlled mini car modification projects with multiple chassis sizes and control schemes.
A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.
Robots 1–24 of 44