MuSHR
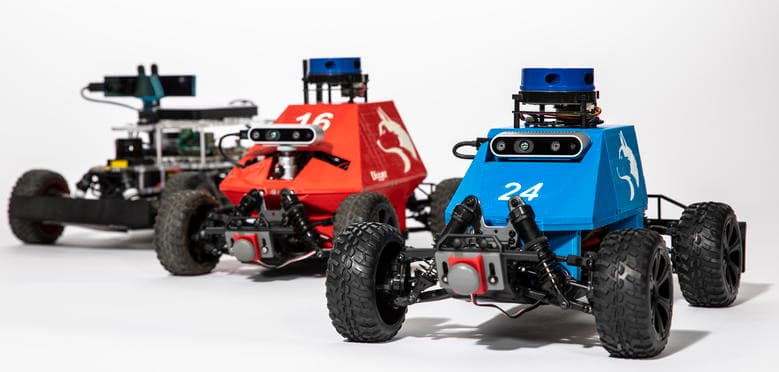
MuSHR is a low-cost 1/10-scale RC car platform for multi-agent non-holonomic racing and autonomous navigation research.
- Wheeled
- Open source
- ROS
Suggested by Robotheca, created by @prl-mushr (opens in a new tab), from github.com/prl-mushr/mushr (opens in a new tab). Pinned to commit 2030b90 (opens in a new tab).
- Hardware license
- BSD-3-Clause (opens in a new tab)
- Software license
- BSD-3-Clause (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (6 scripts)
- mushr_utils/install_scripts/mushr_install_hw_drivers.sh (opens in a new tab)
- mushr_utils/install_scripts/mushr_install_ros.sh (opens in a new tab)
- mushr_utils/install_scripts/mushr_install_stack.sh (opens in a new tab)
- mushr_utils/install_scripts/mushr_install_vesc_tool.sh (opens in a new tab)
- mushr_utils/install_scripts/mushr_install.sh (opens in a new tab)
- mushr_utils/startup/teleop-on-startup.sh (opens in a new tab)
Photo
What it can do
Written by Robotheca from the project's documents.
- Can be driven by a teleop mode that starts automatically at boot when the front bumper button is held.
- Teleop can be stopped remotely over SSH by killing the roslaunch process.
- Built on ROS, with components for simulation, localization, navigation and planning.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @prl-mushr (README.md), under BSD-3-Clause.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- VESC motor controller used to communicate with the car's drive motor.
- Front bumper push button used as a startup input.
- YDLidar laser scanner.
- Intel RealSense camera.
- Battery and power supply are not described in the provided documents.
Connections
- The documents do not describe how these parts are wired together.