 Quadruped
Easy Quadruped Robot
A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.
- Level
- Intermediate
- Buildability
- 35/100
- Incomplete documentation
- Cost
- Not stated
Robots whose build needs a 3D printer for their parts. 233 robots on Robotheca, each with its licenses and its source on GitHub.
Page 7 of 10 · Ready to build first, then by buildability
QuadrupedA simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.
 Humanoid
A desktop-sized open-source robot with 6 degrees of freedom, enhanced with AI capabilities via ESP32, designed for education and maker projects.
A collection of 3D-printable accessories and decorations for the ElectronBot robot.
 Drone
An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.
A fully autonomous mobile robot designed for counter-terrorism, bomb disposal, and rescue tasks, featuring a four-wheel drive chassis, five-degree-of-freedom robotic arm, and multi-vision systems.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
 Drone
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
A small two-wheeled differential-drive mobile platform robot built around a Jetson Nano, with dual cameras and 3D CAD data for its hardware.
 Wheeled
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
A 15-degree-of-freedom open-source humanoid robot replica with editable SolidWorks CAD and assembly instructions.
An open-source 8-DOF desktop quadruped robot platform with force control capabilities.
Naviton is an open-source robot whose CAD data and electronic circuit designs are published in this repository.
A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.
A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.
A desktop robot that responds entirely in its own voice, built from 3D-printed parts and custom electronics.
A hexapod robot powered by Raspberry Pi Zero 2 W and controlled using Python, featuring 18 servo motors and remote operation via Bluetooth.
An ultra cheap, simple two-motor robot with four sensors that a middle schooler can build in several hours.
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
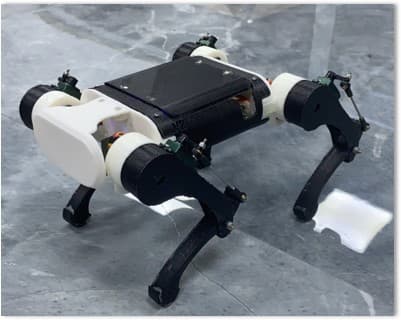 Quadruped
An open-source quadruped robot designed for easy DIY with low-cost hardware and software.
An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.
 Robot arm
A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.
A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.
Robots 145–168 of 233