OpenPerseverance
A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.
- Wheeled
- Open source
- 3D printable
Suggested by Robotheca, created by @JeanetteMueller (opens in a new tab), from github.com/JeanetteMueller/OpenPerseverance (opens in a new tab). Pinned to commit 3832a56 (opens in a new tab).
- Hardware license
- CC0-1.0 (opens in a new tab)
- Software license
- CC0-1.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 script)
Photo and 3D model
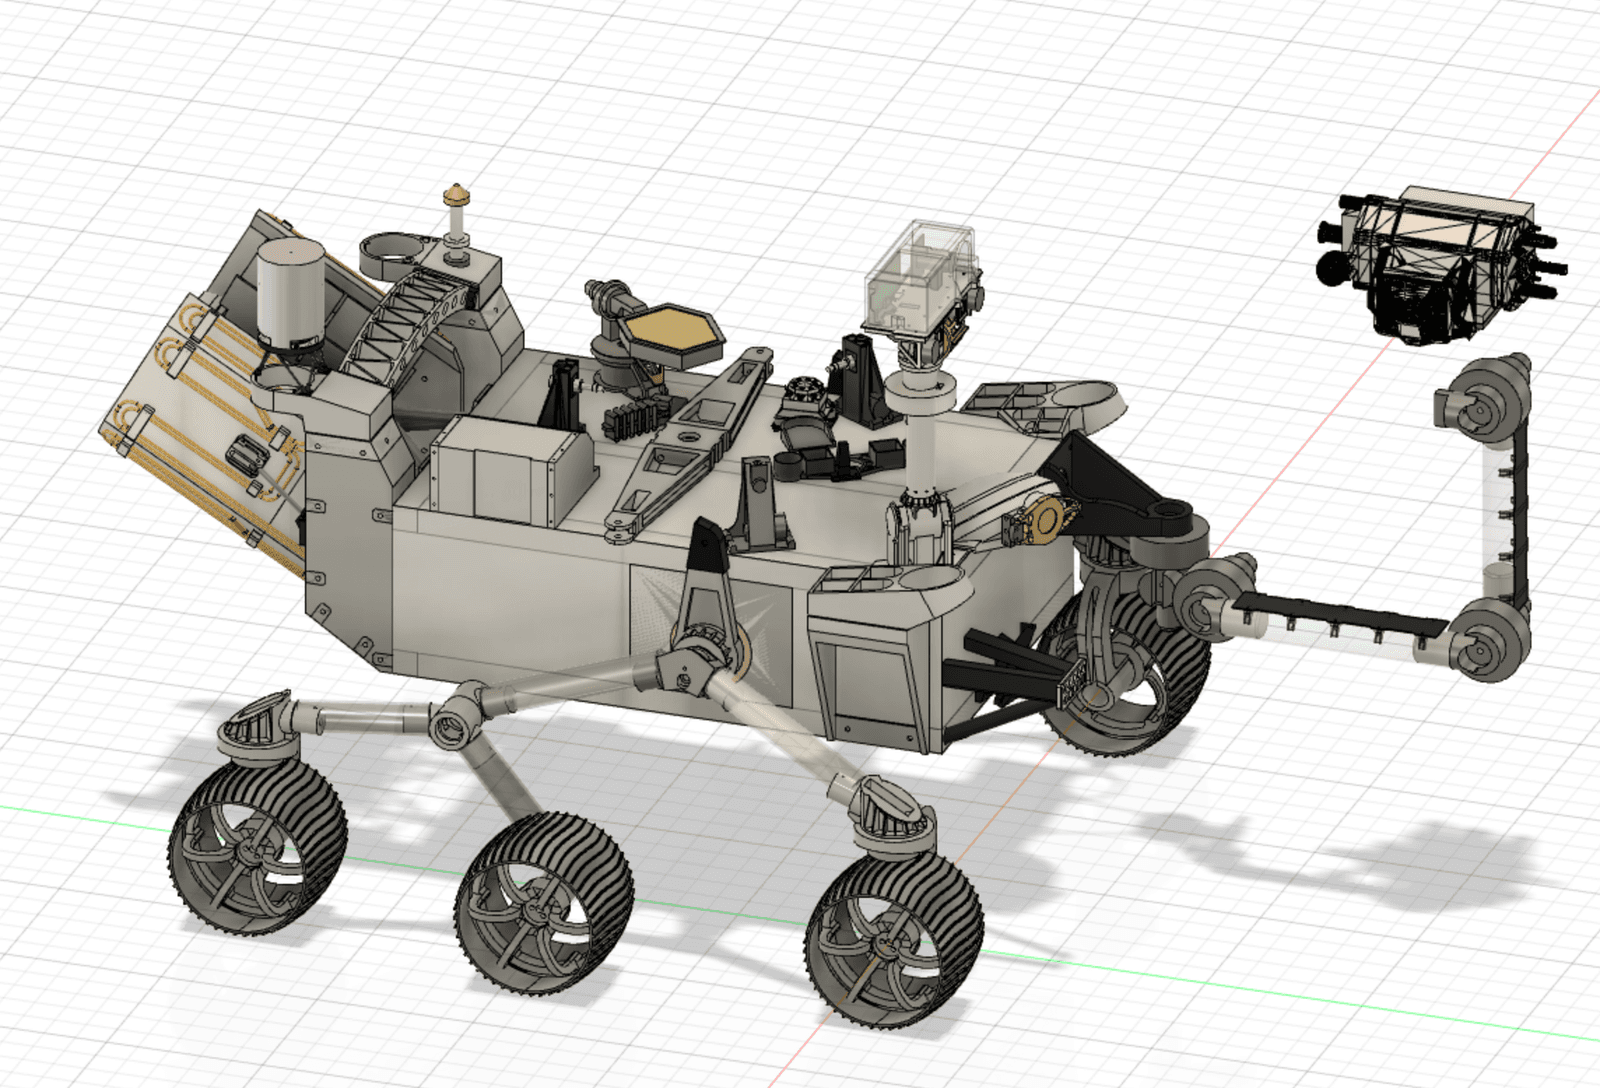
3D preview converted from github.com/JeanetteMueller/OpenPerseverance at 3832a56, under CC0-1.0. View the original files from GitHub (50.9 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Remote-controlled 3D-printed Mars rover modeled on NASA's Perseverance, driven by a PS4 gamepad.
- An iPhone acts as the control brain, translating gamepad input into JSON commands for the rover.
- The iPhone displays camera images from all installed cameras.
- A separate camera tower carries a head-mounted camera and lights around the eyelid.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Print the MainBody parts from stl/MainBody
- 2Print the RockerBogie parts from stl/RockerBogie
- 3Print the HeatExchanger parts from stl/HeatExchanger
- 4Assemble the 20x20 alloy profile main body frame
- 5Install the ball bearings and alloy rods
- 6Mount the JX and MG90s servos
- 7Install the Raspberry Pi 3b and Raspberry Pi Zero W controllers
- 8Mount the Longruner camera and ESP32 with Cam
- 9Build the UHF antenna from carbon rods
- 10Set up the iPhone and PS4 gamepad remote control
The guide appears here as you scroll.
Guide by @JeanetteMueller (README.md), under CC0-1.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi 3b (or newer) as the main rover computer.
- Three motor controller boards and two servo shields on the main computer.
- Raspberry Pi Zero W in the camera tower for the head camera and eyelid lights.
- Longruner camera for Raspberry Pi and an ESP32 with camera.
- Four JX Servo 1181MG servos and two MG90s servos.
- PS4 gamepad connected to the iPhone.
Connections
- Motor controller boards and servo shields are mounted on the Raspberry Pi 3b; the document gives no pin-level wiring details.