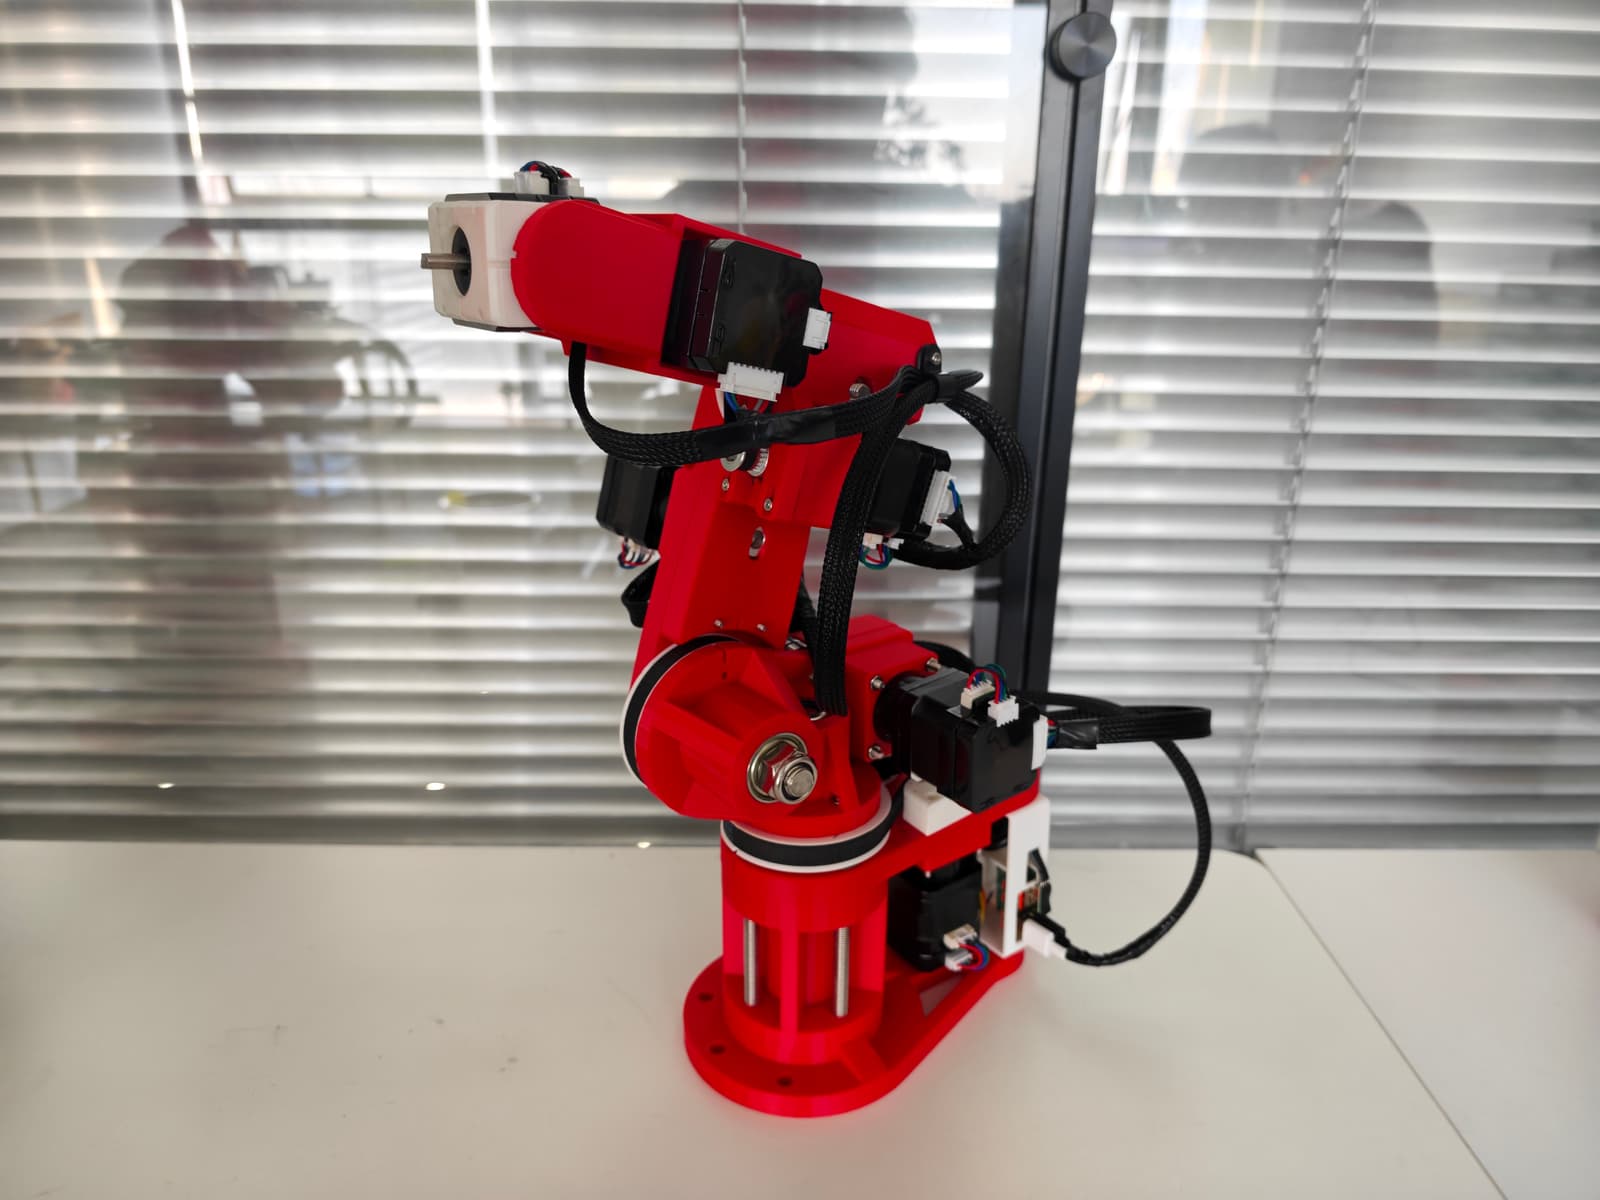
H1 6-Axis 3D-Printed Manipulator
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
Robot armIntermediateBuildability 45/100 · Incomplete documentation
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 3 of 7 · Ready to build first, then by buildability
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
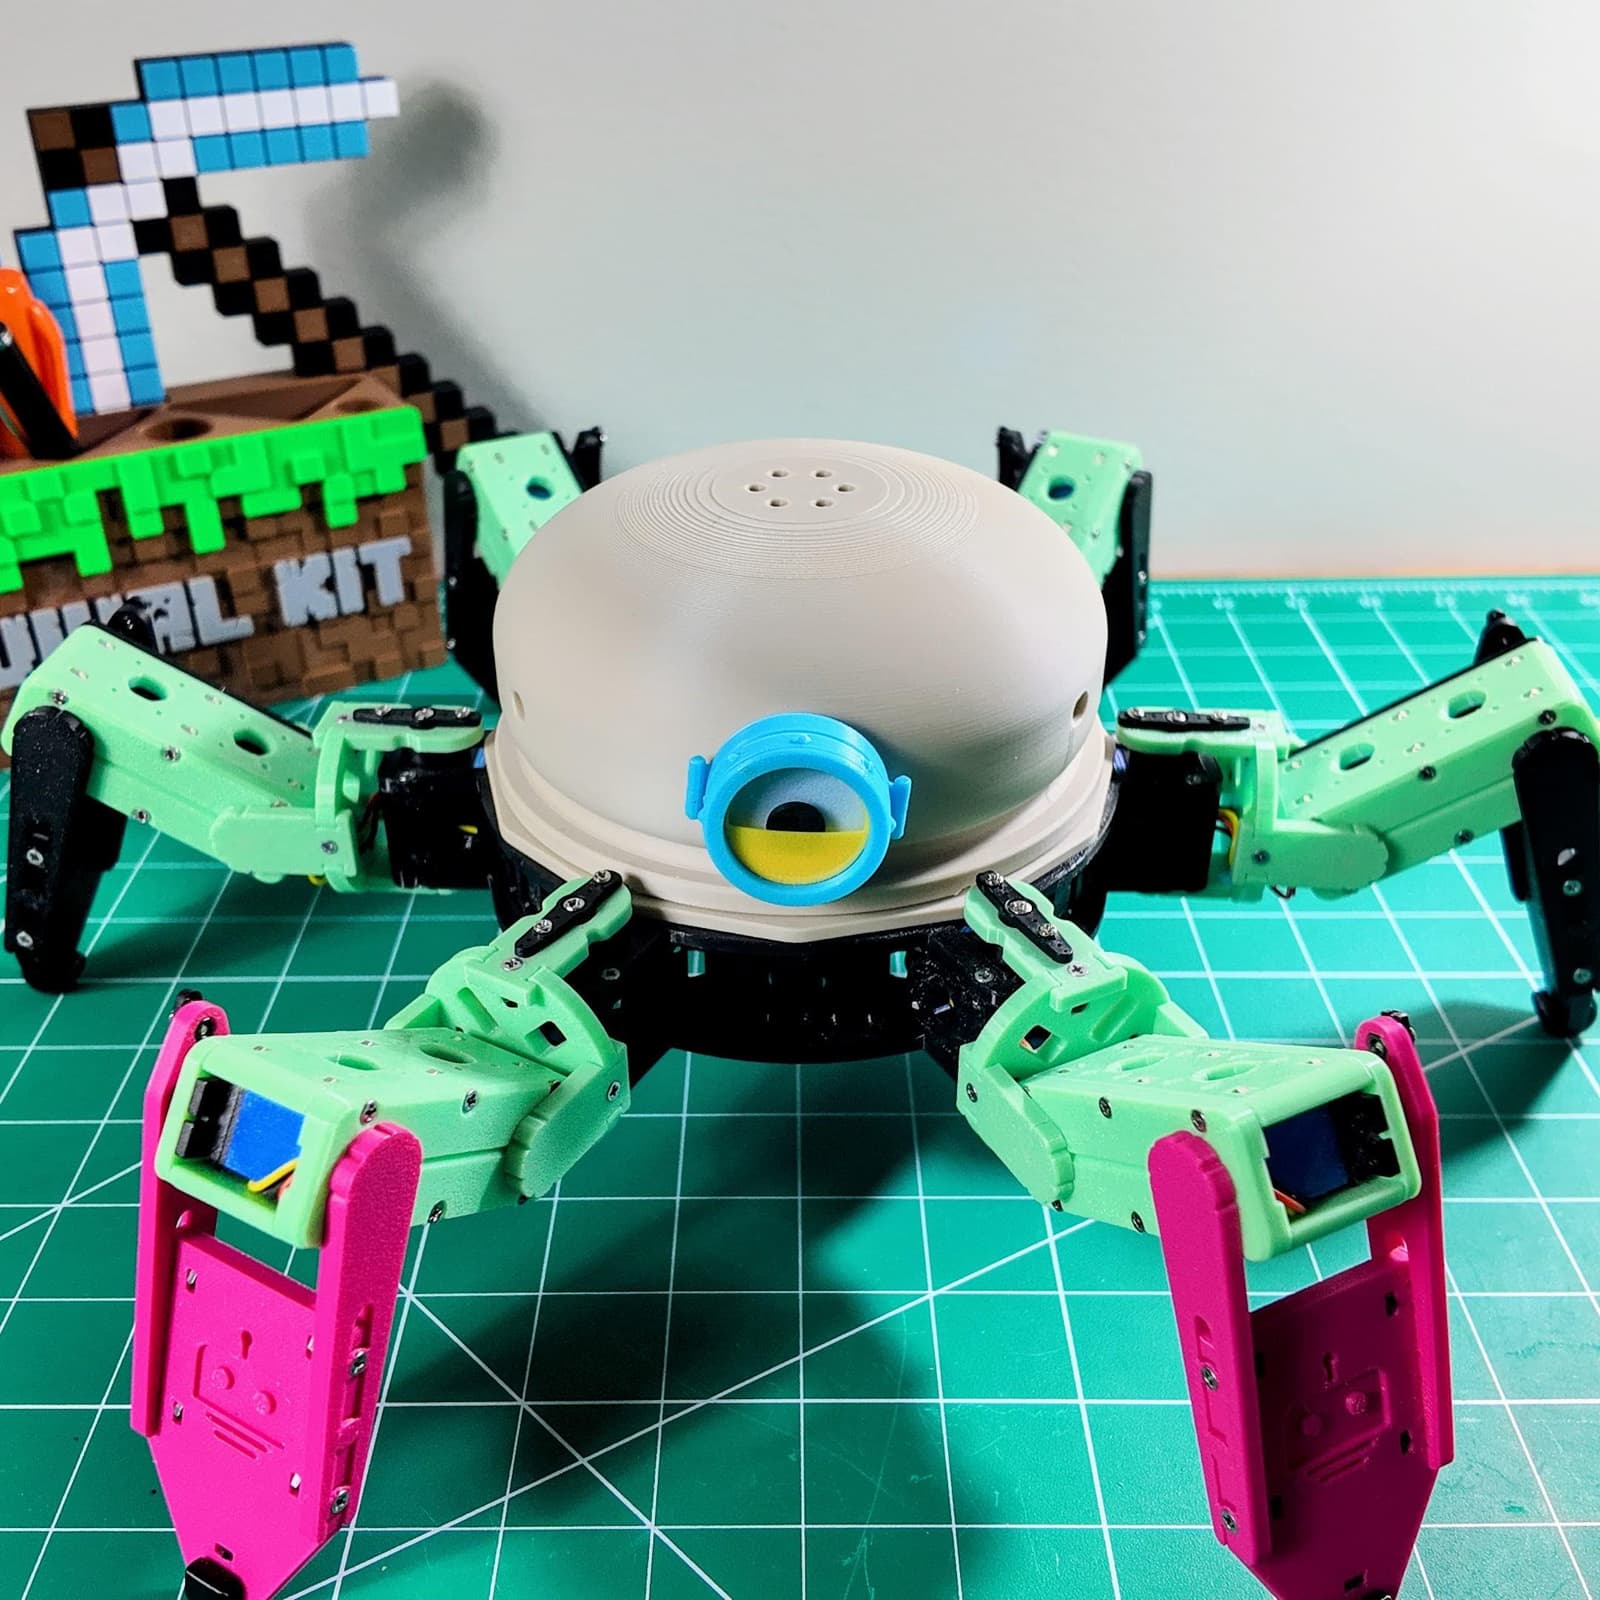
A family of 18-DOF, 3D-printed hexapod walking robots powered by an ESP32, controlled over WiFi or live pose streaming.
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
A 200mm 3D-printed DIY home pet robot that maps rooms with a 360-degree laser distance sensor and drives autonomously, compatible with the Kaia.ai platform.
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
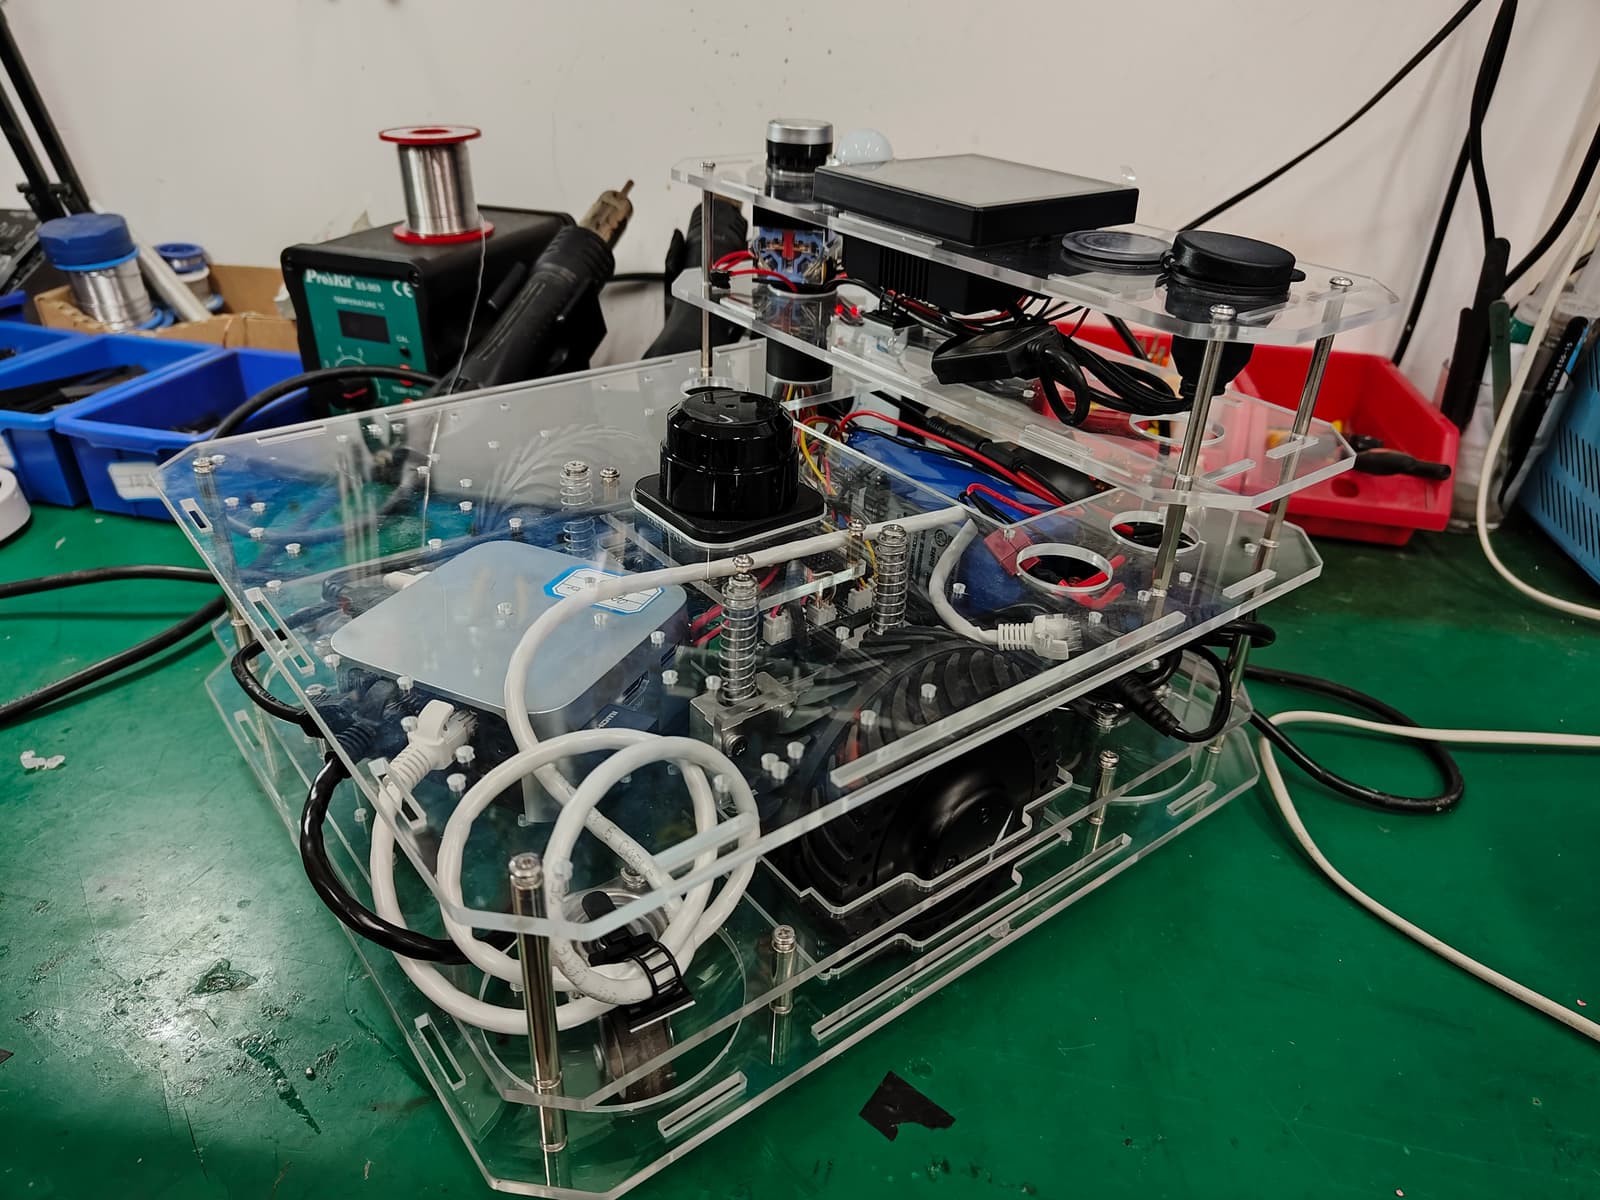
An open-source AGV chassis based on ROS for learning and practical applications.
An OTTO robot enhanced with ESP32 for Bluetooth remote control and a screen.
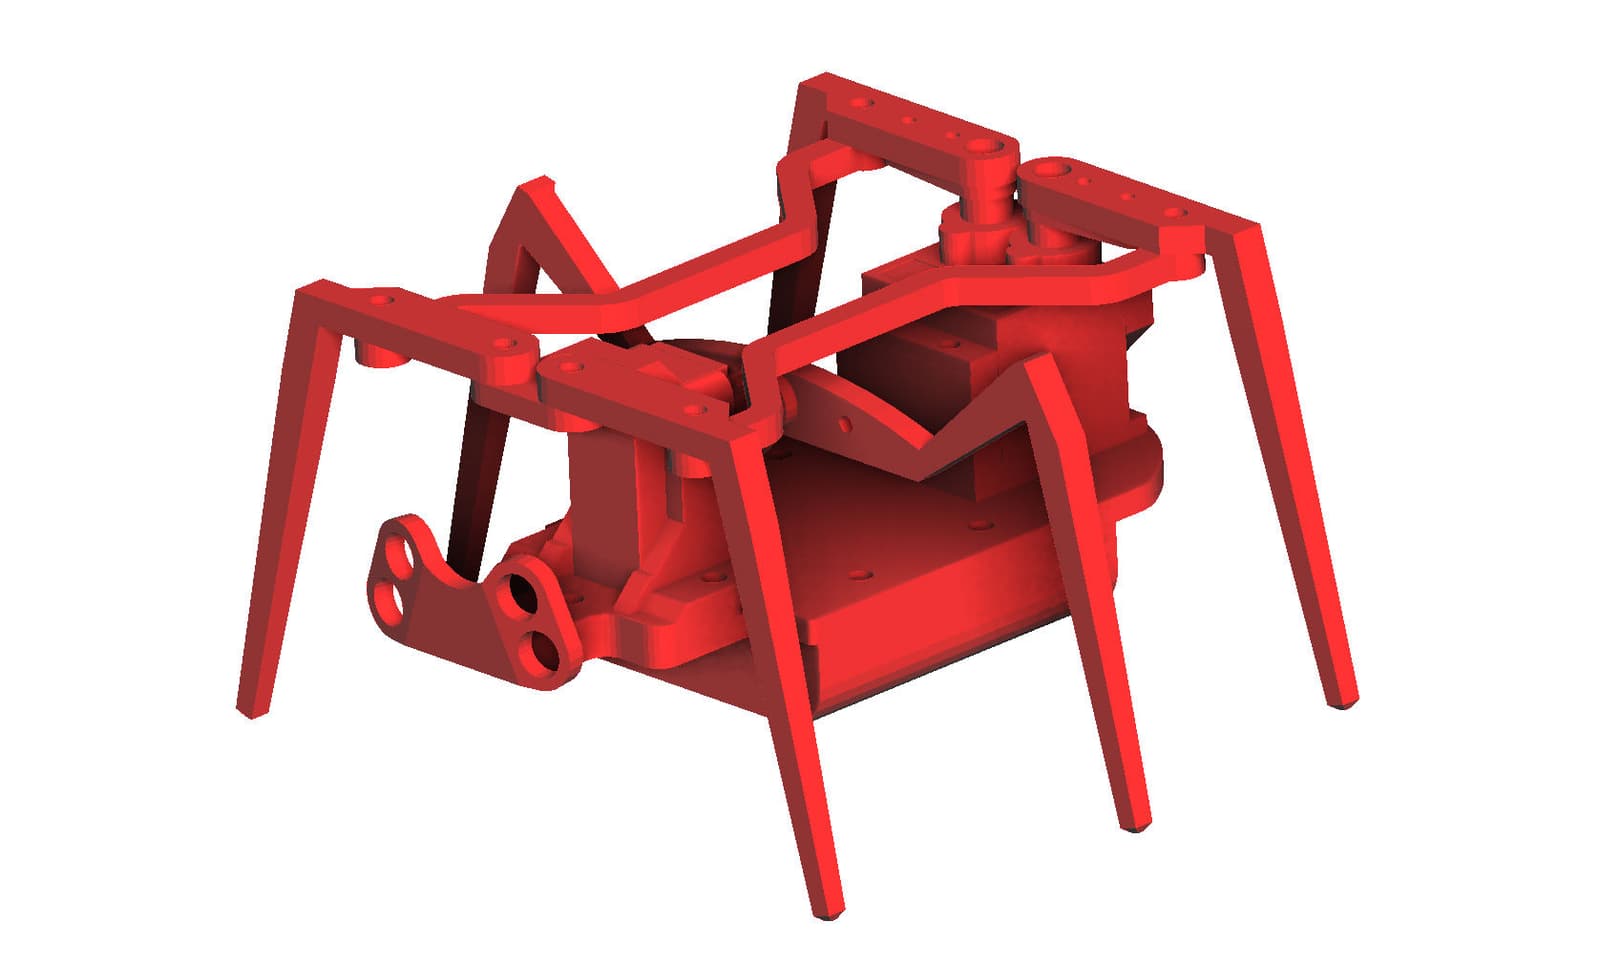
A low-budget three-servo hexapod robot that walks, dances and avoids obstacles using infrared proximity sensors.
A fully open-source, low-cost, 3D-printable bipedal robot designed for hobbyists, educators, and researchers.
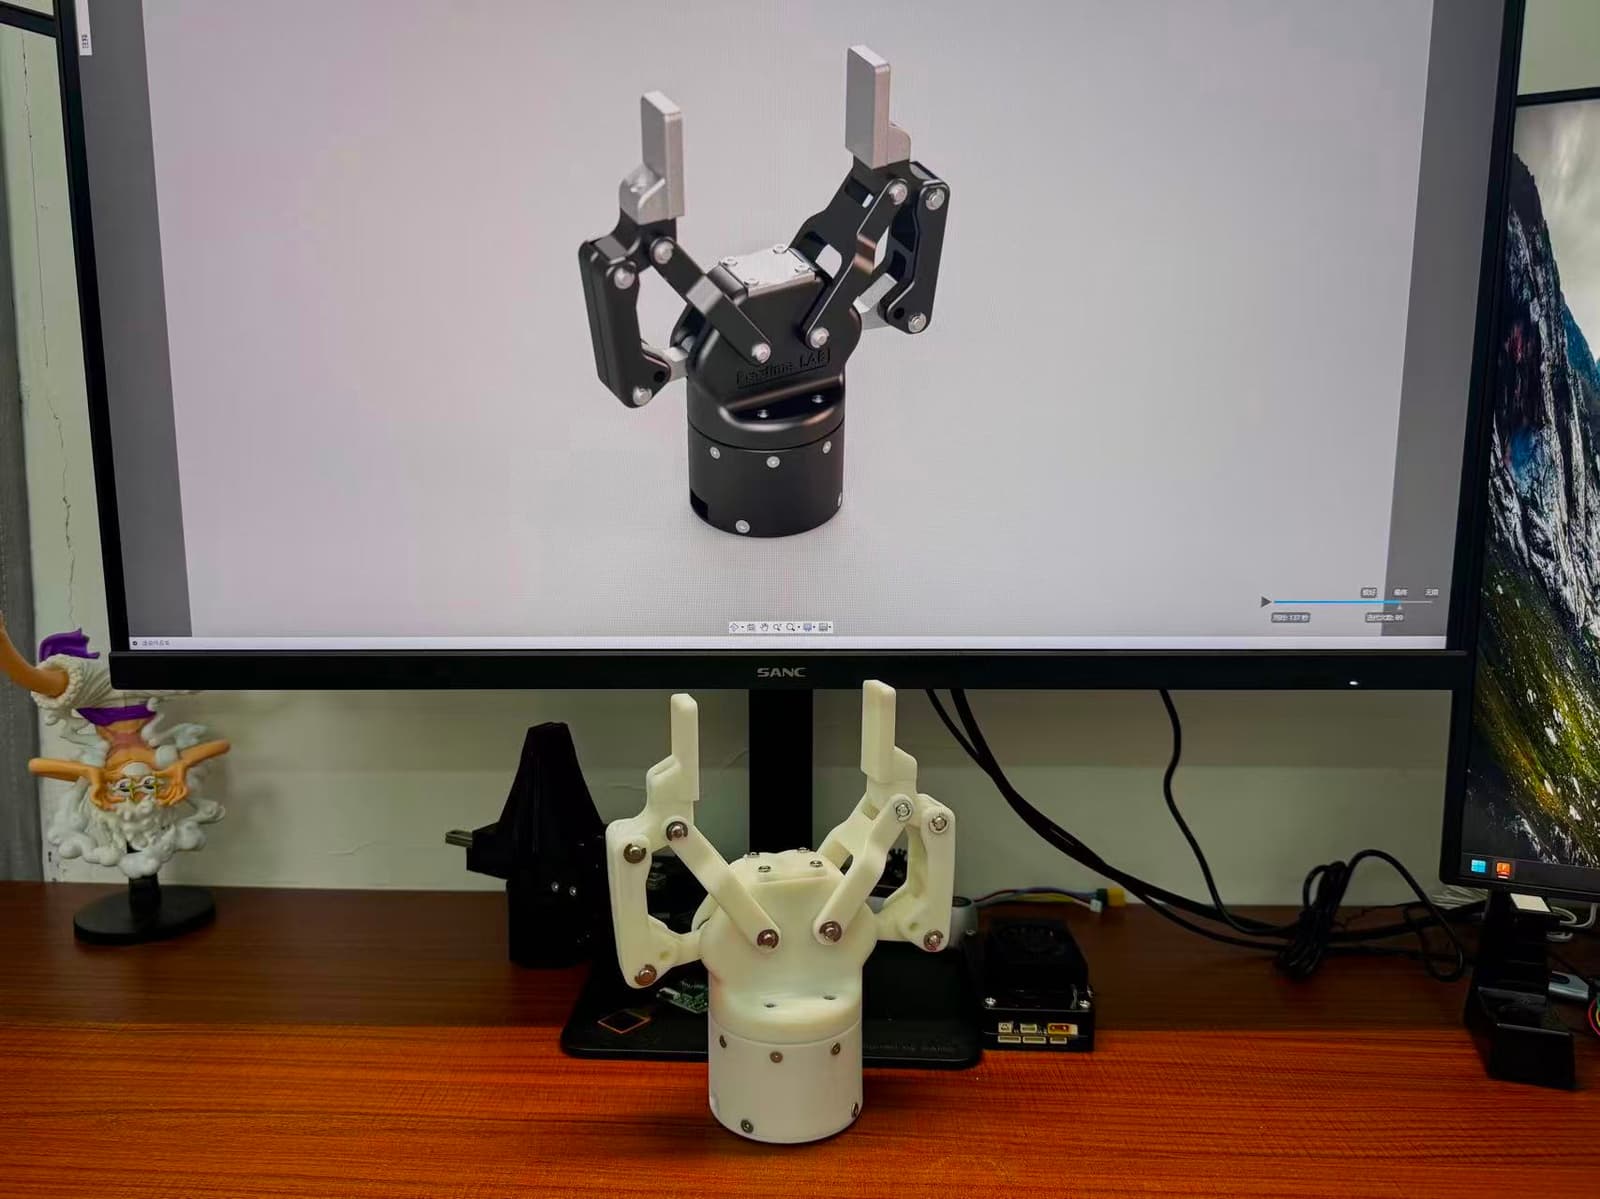
An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.
An open-source autonomous robot arm that cleans, makes beds and organizes rooms in hotels and homes.
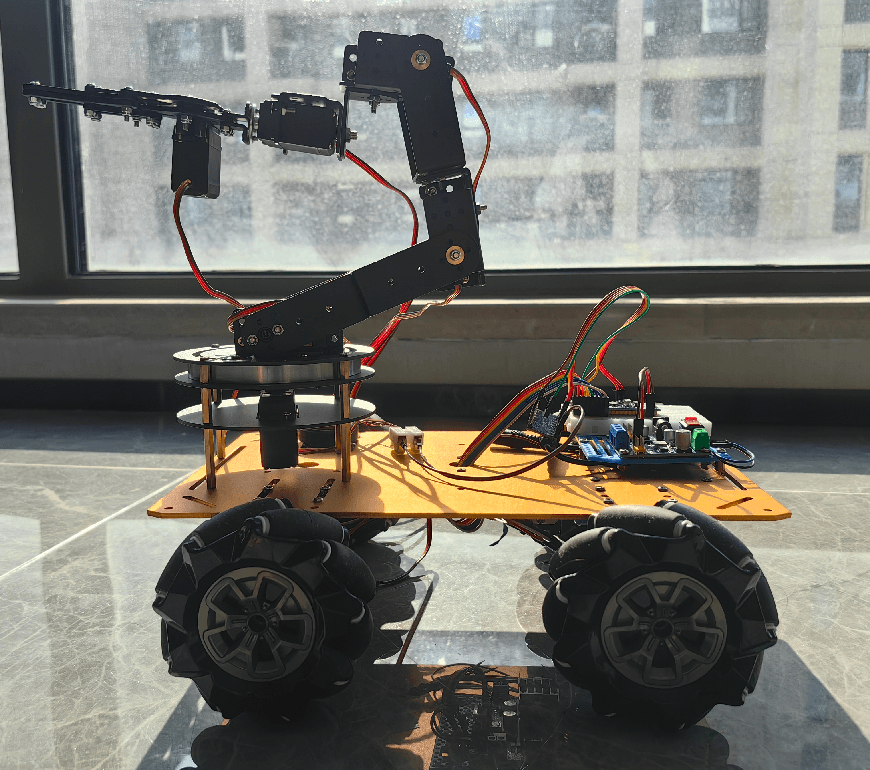
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
An open-source dexterous hand system that uses gesture recognition to control a 3D-printed robotic hand and play music.
A six-legged robot controlled by a Raspberry Pi with remote control and vision capabilities.
A 6-DOF robotic arm built with 3D-printed parts and Feetech STS3215 bus servos, controlled via LeRobot.
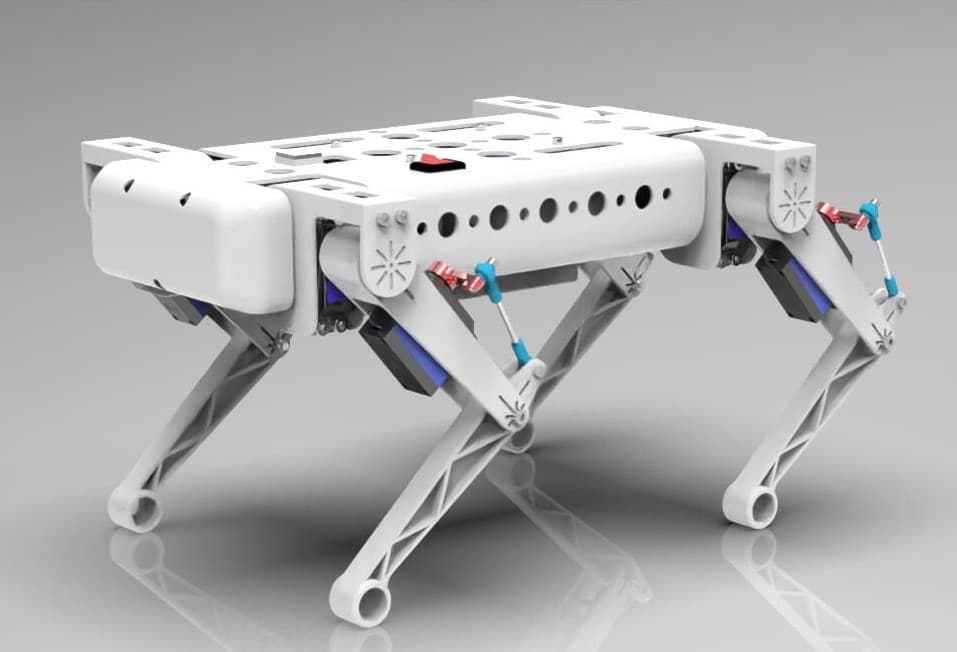
A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
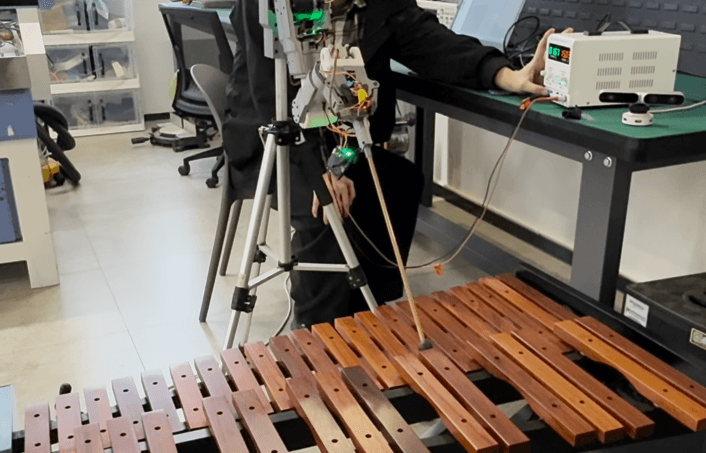
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
A series of open-source remote-controlled mini car modification projects with multiple chassis sizes and control schemes.
A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.
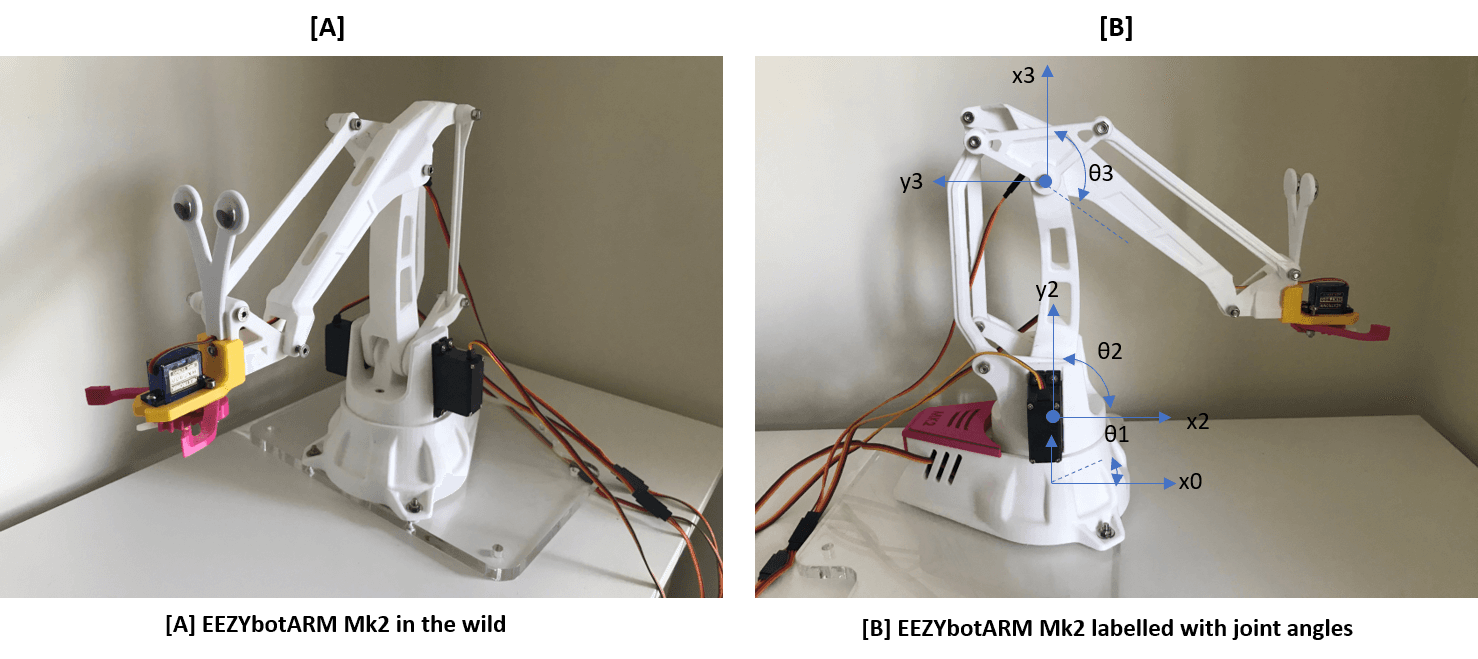
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
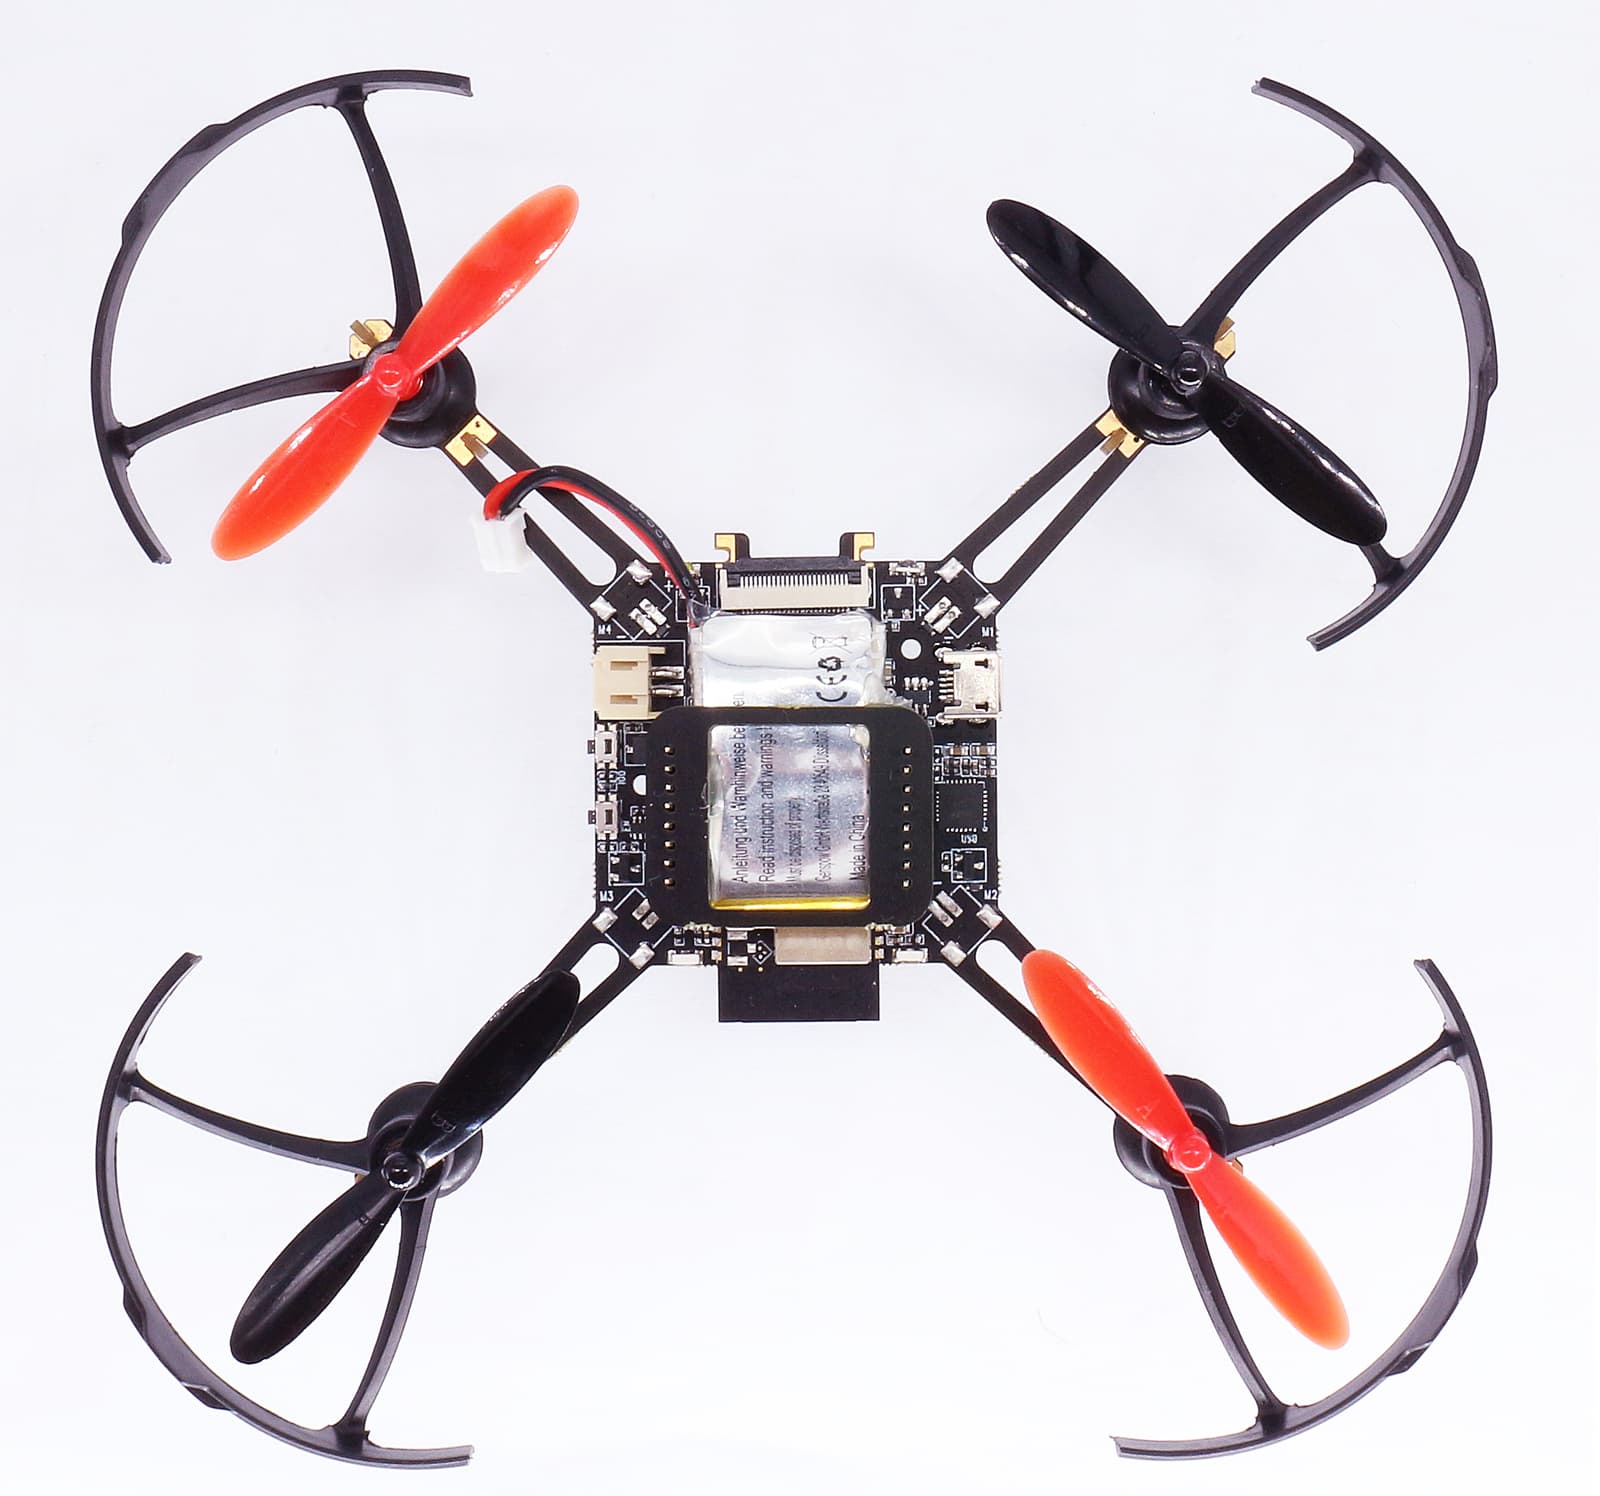
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
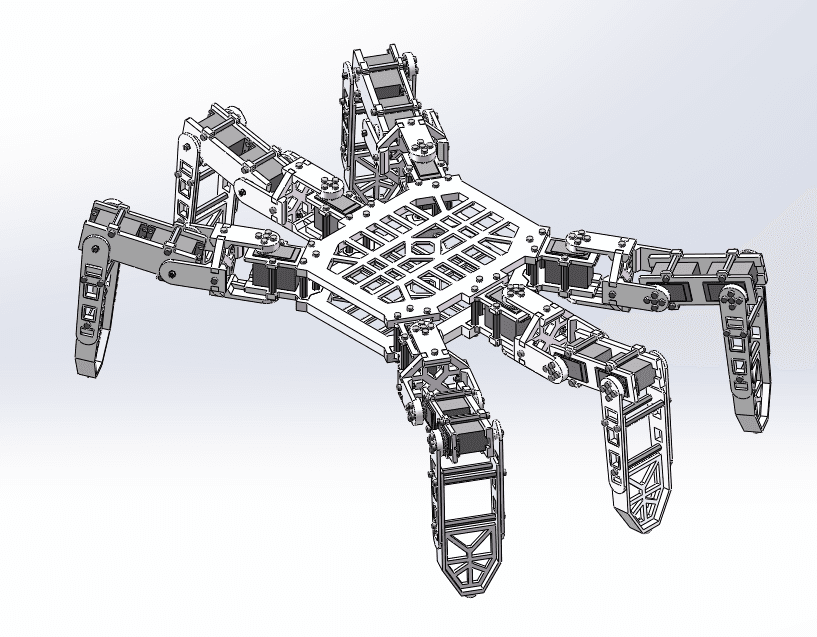
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
An open-source 3D-printed robotic arm with 5 degrees of freedom and a gripper.
A desktop robotic arm designed for easy 3D printing with minimal parts, featuring a 3D-printed structure and basic electronic components.
Robots 49–72 of 161