AlohaMini2
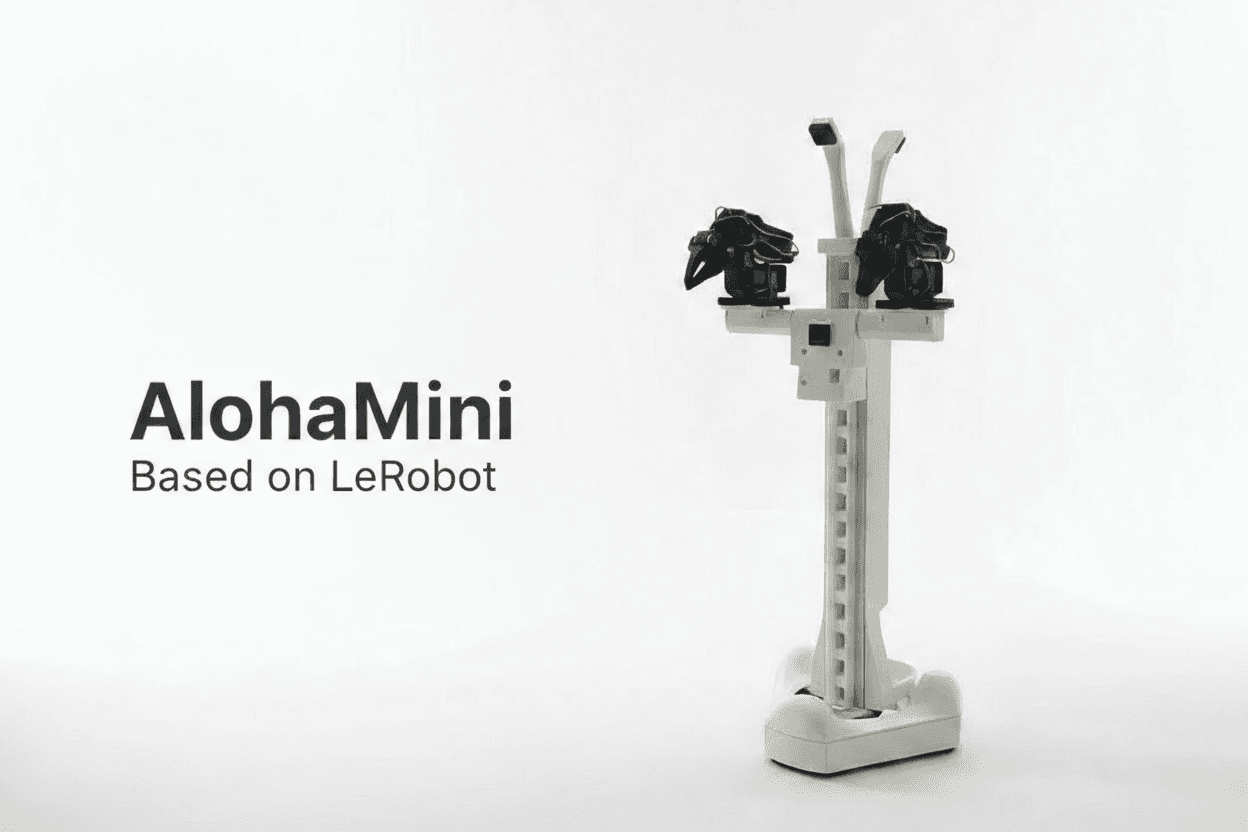
AlohaMini2 is an open-source dual-arm mobile robot with a motorized vertical lift, built for embodied AI research and real-world manipulation.
- Works with AI
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 4 · Ready to build first, then by buildability
AlohaMini2 is an open-source dual-arm mobile robot with a motorized vertical lift, built for embodied AI research and real-world manipulation.
A 6-axis desktop robot arm with a gripper, made of CNC aluminium and 3D-printed parts and driven by CAN bus motors, for robot learning and research.
A fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
A 3D-printed collaborative robot arm for research, education and rapid prototyping in physical AI.
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
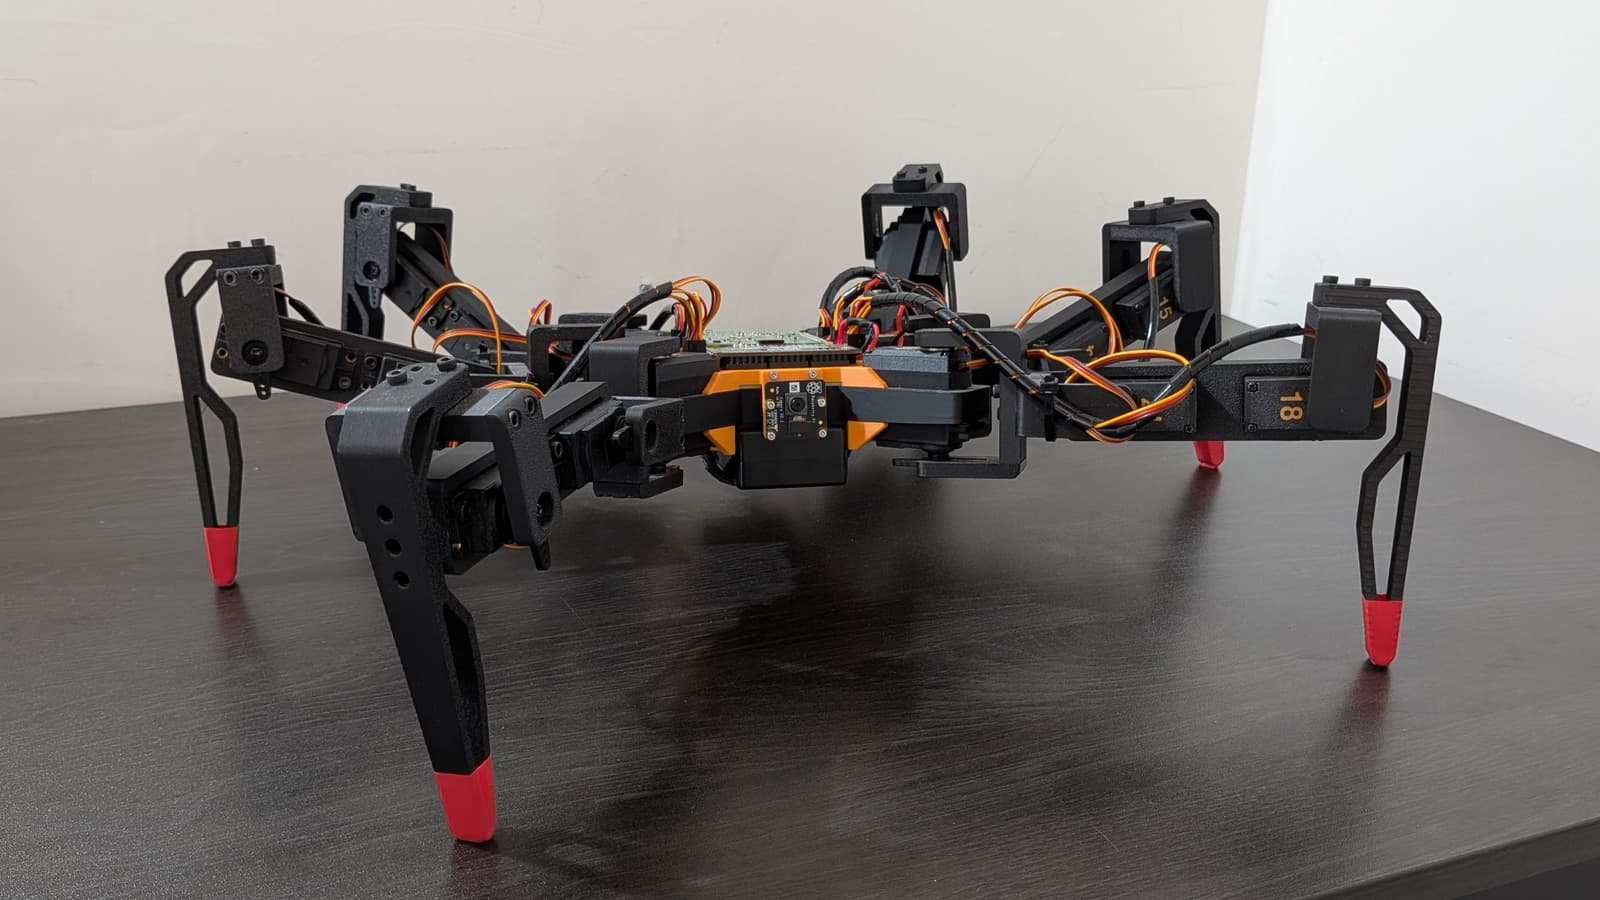
A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.
A small 22-degree-of-freedom humanoid robot designed for reinforcement learning and imitation learning, featuring a rotatable waist, head, and upper limbs.
A 60 cm tall bipedal robot combining Pixar-style and Disney BDX designs, using brushless motors and reinforcement learning.
An open-source 3D-printed quadrupedal robot that performs gait generation with Bezier curves and full 6-axis body pose control.
POPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
A 6-axis 3D-printed desktop robot arm with stepper motors, gearboxes and belts, modelled on industrial arms, with its own control firmware.
A 7-DOF dual-arm bimanual robot platform derived from the SO-101 design, with matching leader arms for teleoperation.
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
A 7-DOF personal robotic arm with ROS-based simulation and control.
A safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
An open-source 6-DOF collaborative robotic arm system with mechanical structure, electronics, and software.
A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
Robots 1–24 of 95