RC WheelLeg
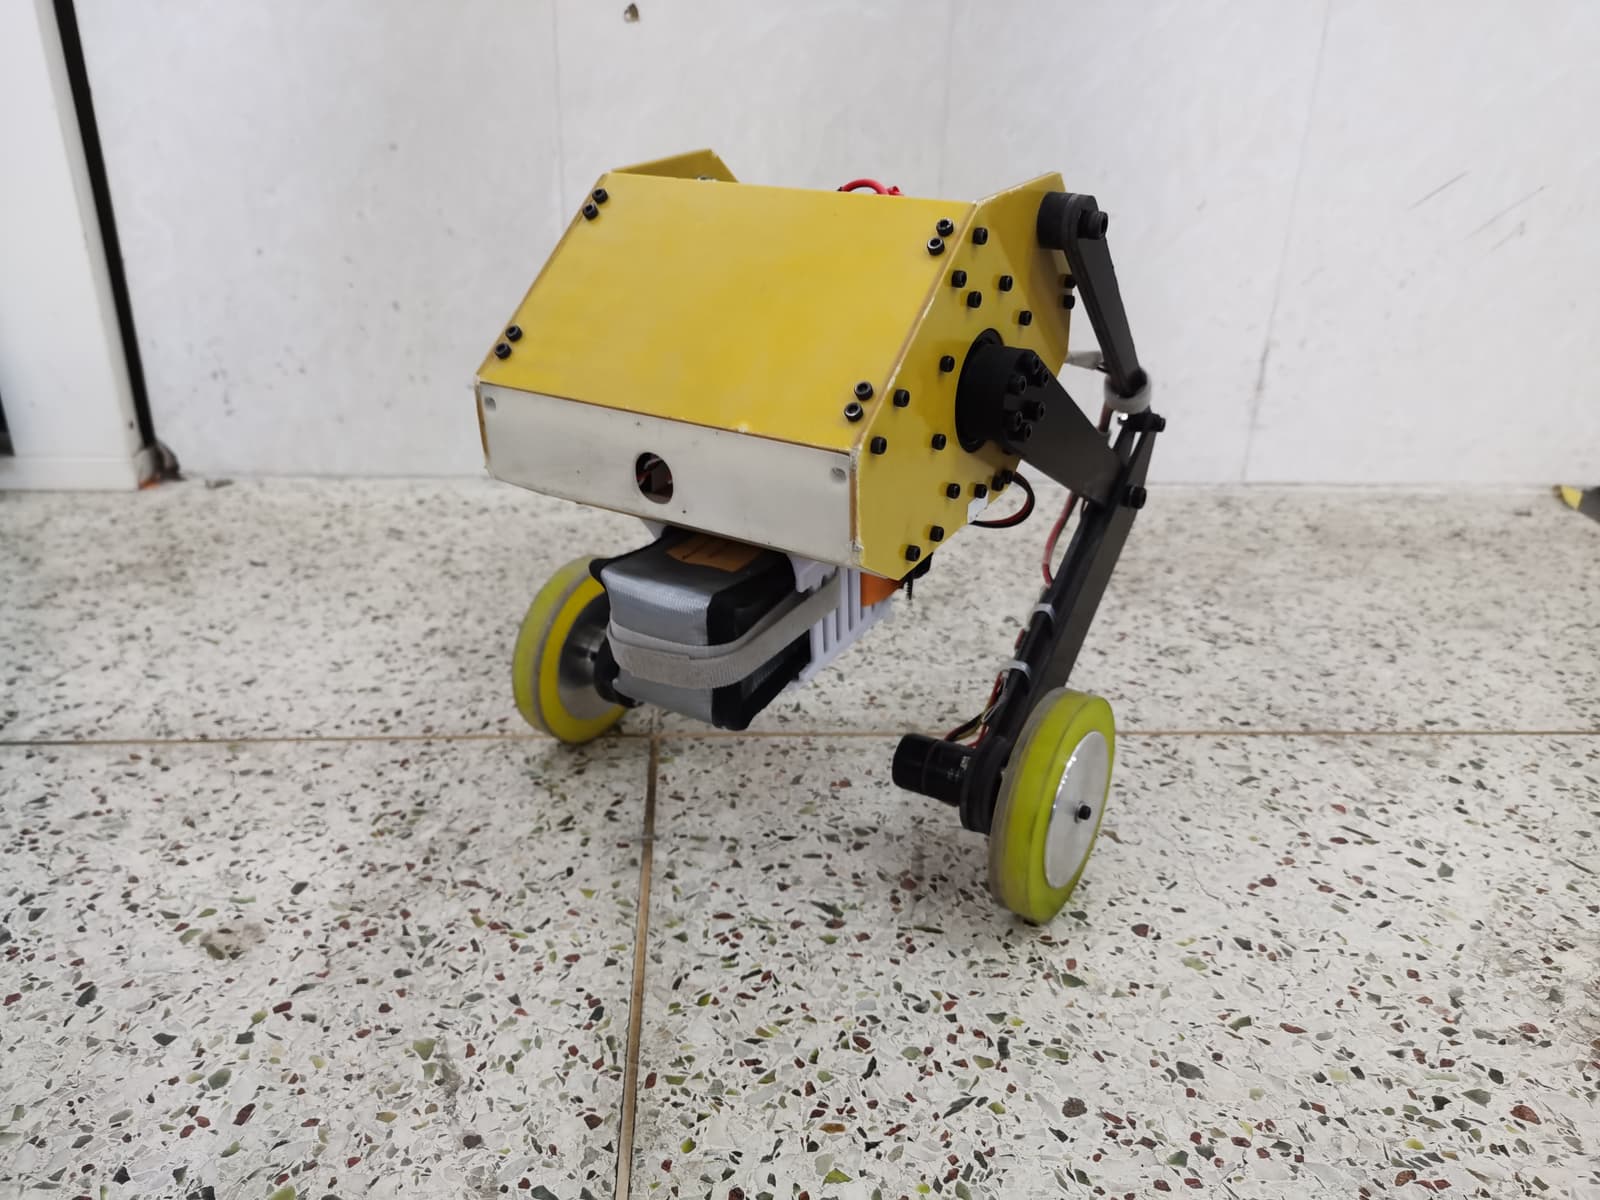
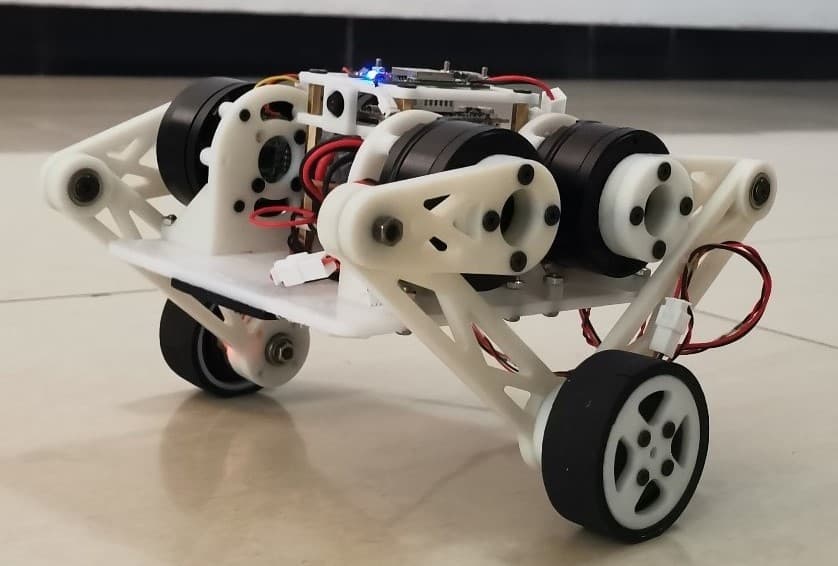
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
- Works with AI
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
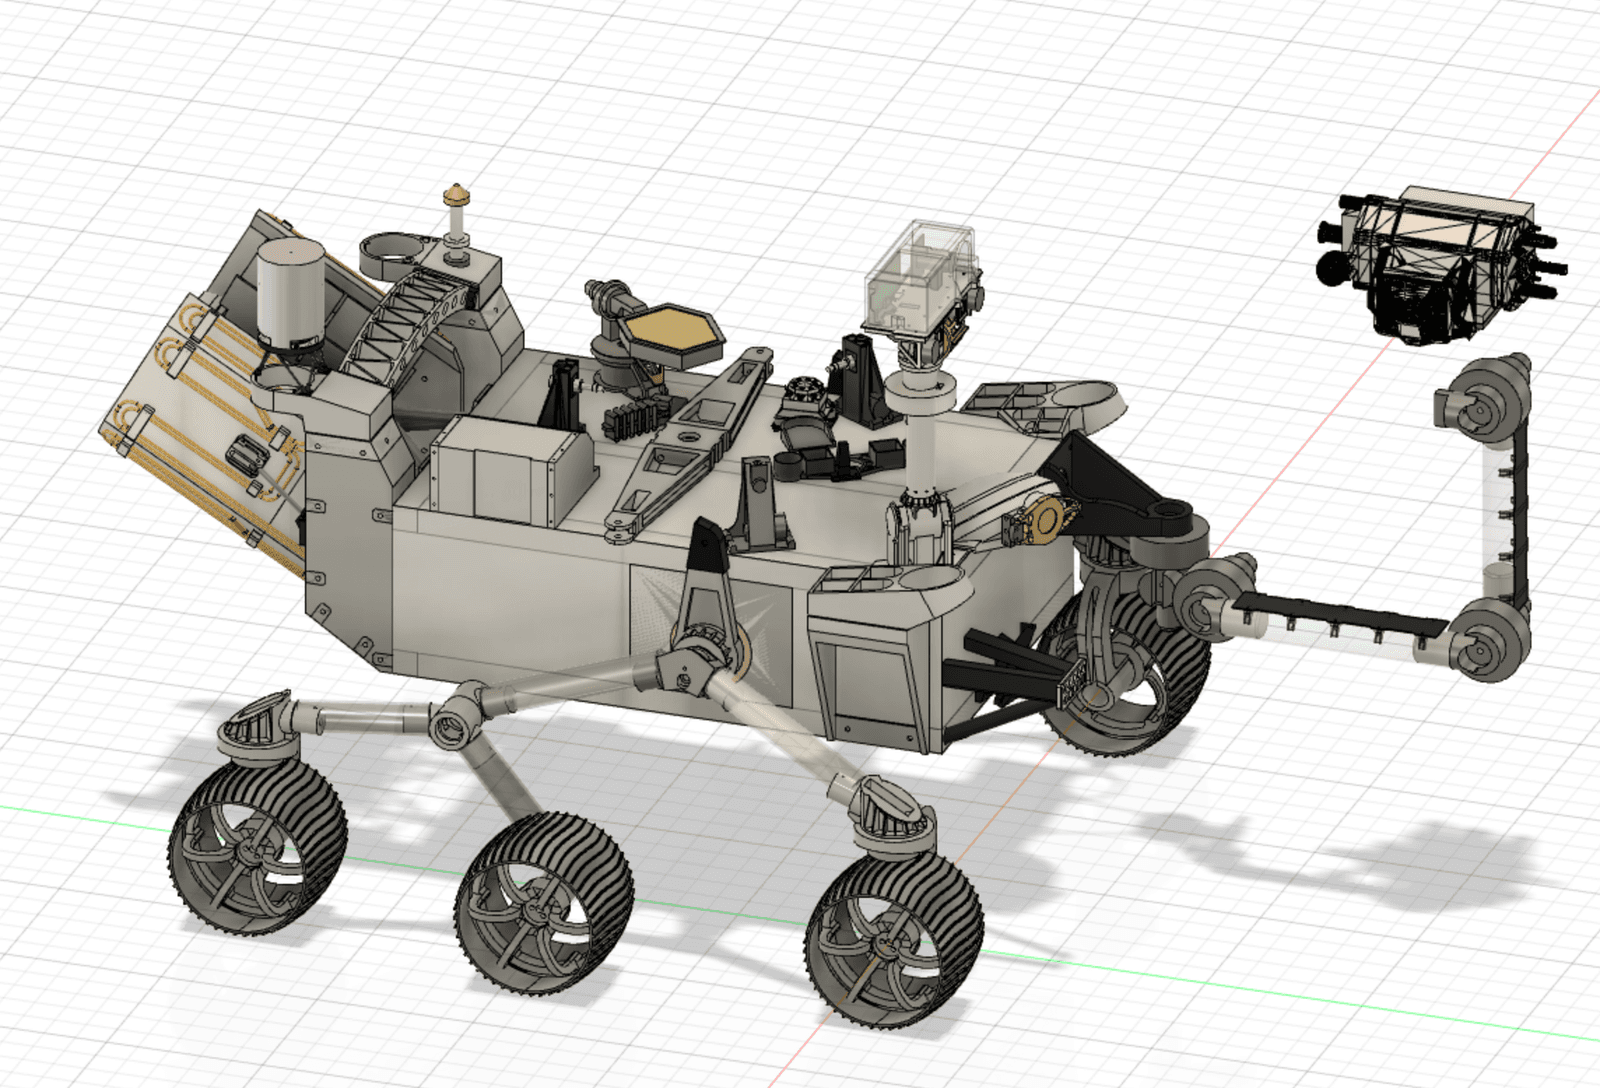
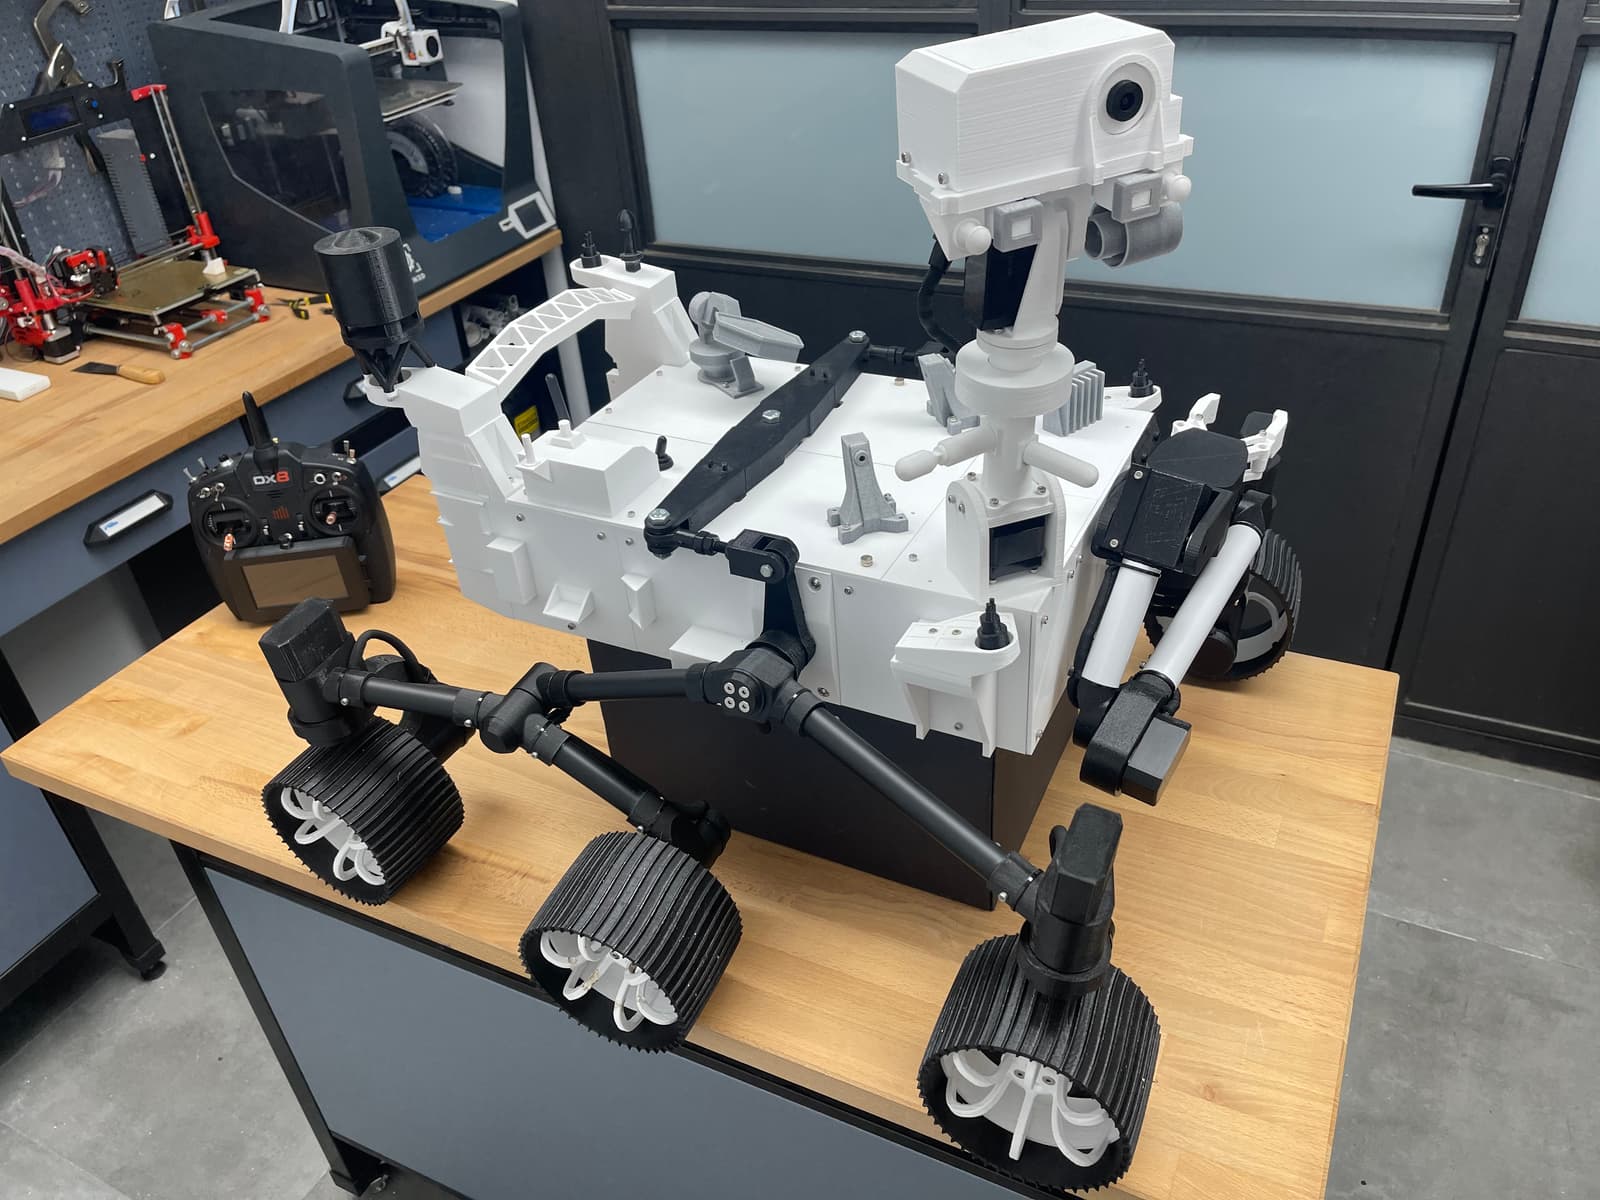
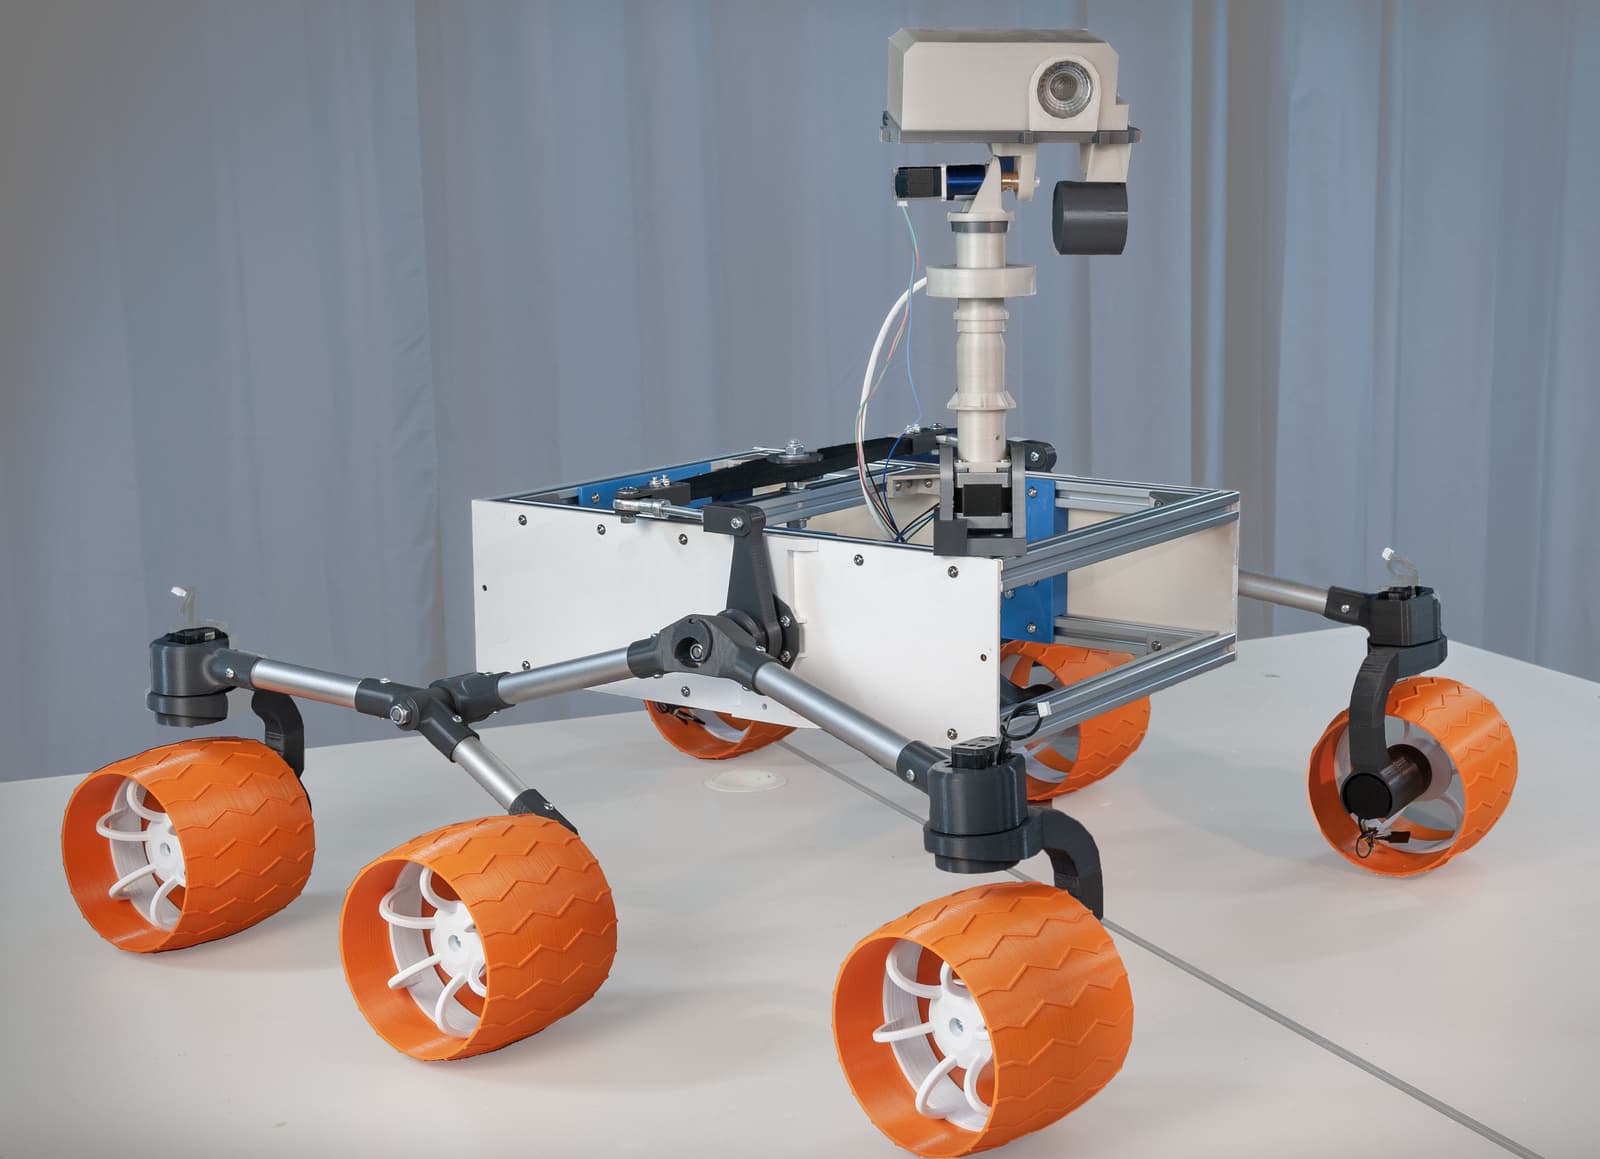
A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.
A 3D-printed Mars Perseverance-style rover replica with a 6-wheel drive, 4-axis robotic arm, and remote control with touchscreen and web dashboard.
A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.
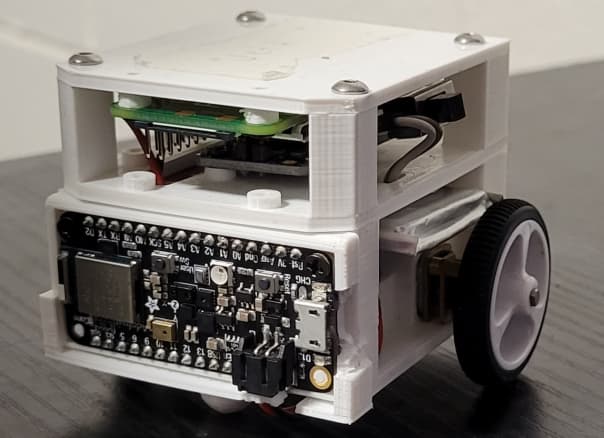
A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
A fully autonomous mobile robot designed for counter-terrorism, bomb disposal, and rescue tasks, featuring a four-wheel drive chassis, five-degree-of-freedom robotic arm, and multi-vision systems.
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.