HeRoSwarm v2
A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.
- Wheeled
- Open source
- ROS
- 3D printable
Suggested by Robotheca, created by @herolab-uga (opens in a new tab), from github.com/herolab-uga/heroswarmv2 (opens in a new tab). Pinned to commit b35b41a (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
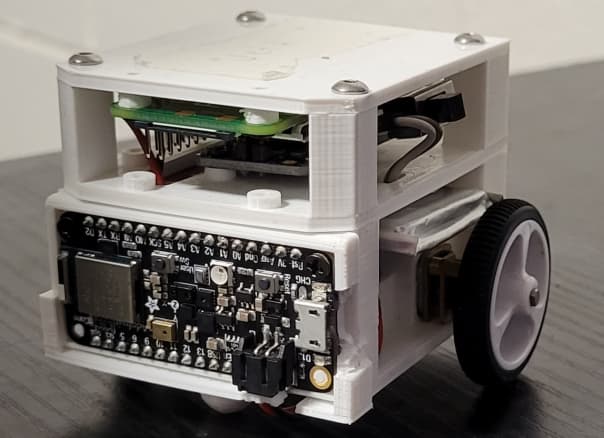
3D preview converted from github.com/herolab-uga/heroswarmv2 at b35b41a, under MIT. View the original files from GitHub (591 KB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Senses proximity, RGB color, sound, inertial (IMU) altitude, humidity and pressure to gather local information.
- Communicates over Wi-Fi and Bluetooth.
- Provides C1-level computing through a Raspberry Pi Zero-based module that can run ROS and advanced programs.
- Multi-level motor control with onboard wheel odometry aided by a microcontroller.
- Dedicated power management with recharging via inductive wireless charging or magnetic coupling.
- Demonstrated multi-robot rendezvous, formation control (square pattern with 9 robots), distribution/coverage and pursuit-evasion.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @herolab-uga (README.md), under MIT.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi Zero-based computing module.
- Microcontroller that aids motor control and wheel odometry.
- Proximity, RGB, sound, IMU, humidity and pressure sensors.
- Wi-Fi and Bluetooth communication hardware.
- Dedicated power management with inductive or magnetic-coupling recharging.
Connections
- The repository includes a condensed schematic image, but the README does not describe the wiring in text.
