Grasshopper
Grasshopper is an autonomous lawn mowing robot with a drive section and a mower section joined by a coupler.
- Wheeled
- Open source
- 3D printable
Suggested by Robotheca, created by @sarnold04 (opens in a new tab), from github.com/sarnold04/Grasshopper (opens in a new tab). Pinned to commit 9d29b42 (opens in a new tab).
- Hardware license
- CC-BY-SA-4.0 (opens in a new tab)
- Software license
- CC-BY-SA-4.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
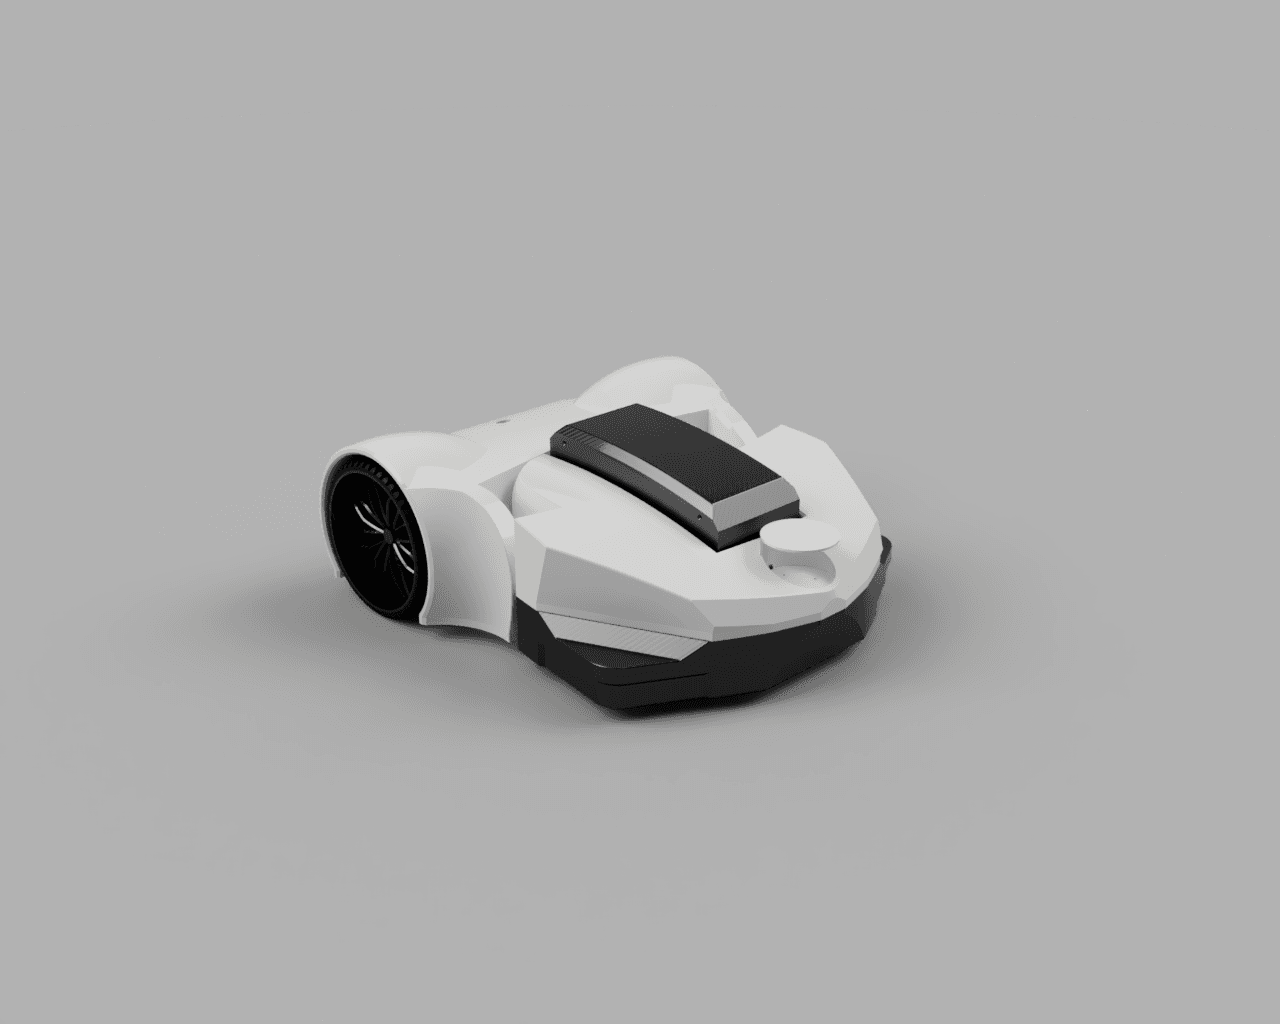
3D preview converted from github.com/sarnold04/Grasshopper at 9d29b42, under CC-BY-SA-4.0. View the original files from GitHub (5.1 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Autonomous lawn mowing robot
- Mower section can rotate up to 15 degrees around the robot's rotational axis to follow changing terrain
- Drive section carries the motors and most electronics and sensors
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @sarnold04 (README.md), under CC-BY-SA-4.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Drive motors
- Mower motor
- YDLIDAR G2 360-degree laser scanner (lidar)
- Battery box in the mower section
- Sensors and electronics housed in the drive section
Connections
- Drive section connects to the mower section through a coupler
- Battery box, mower motor and lidar are located in the mower section