 Wheeled
WhaleBot
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
- Work in progress
- Works with AI
- Level
- Beginner
- Buildability
- 45/100
- Incomplete documentation
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
WheeledAn ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.
 Wheeled
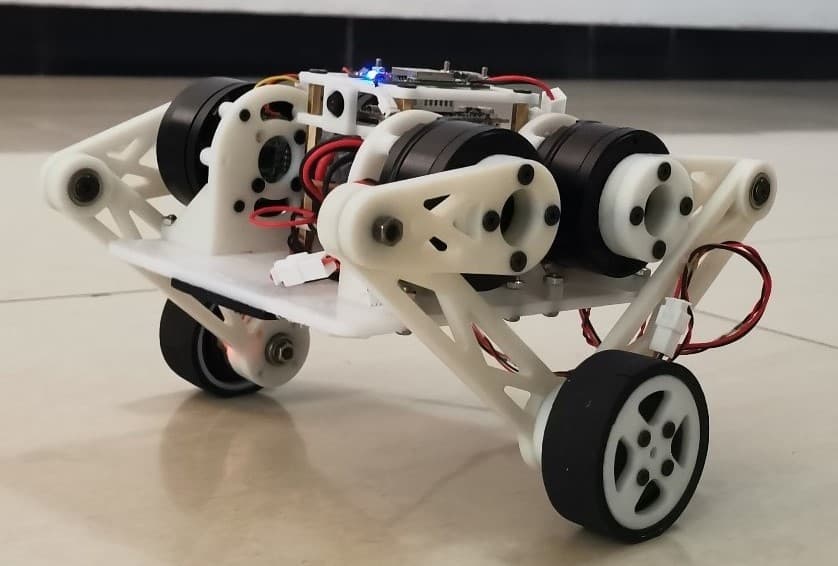
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
 Wheeled
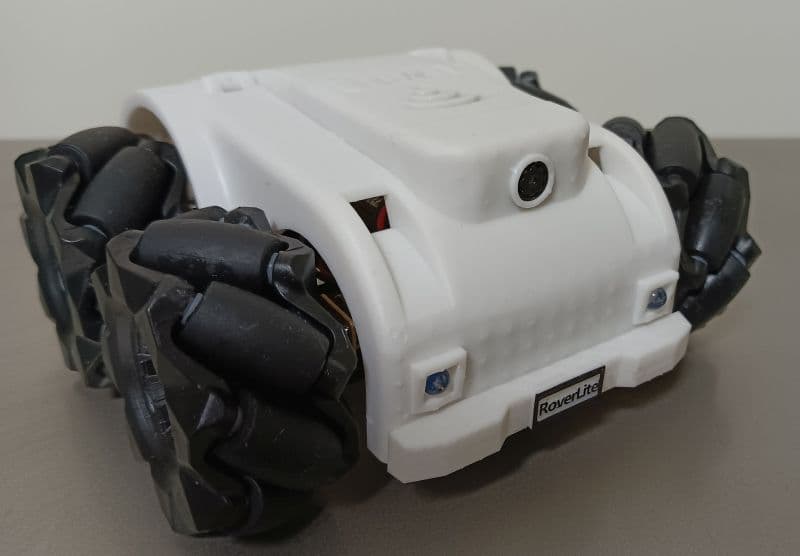
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
An educational wheeled rover controlled by a Raspberry Pi Zero W, with a DRV8835 motor driver, OLED display, 9-axis sensor and LEDs.
A small two-wheeled differential-drive mobile platform robot built around a Jetson Nano, with dual cameras and 3D CAD data for its hardware.
 Wheeled
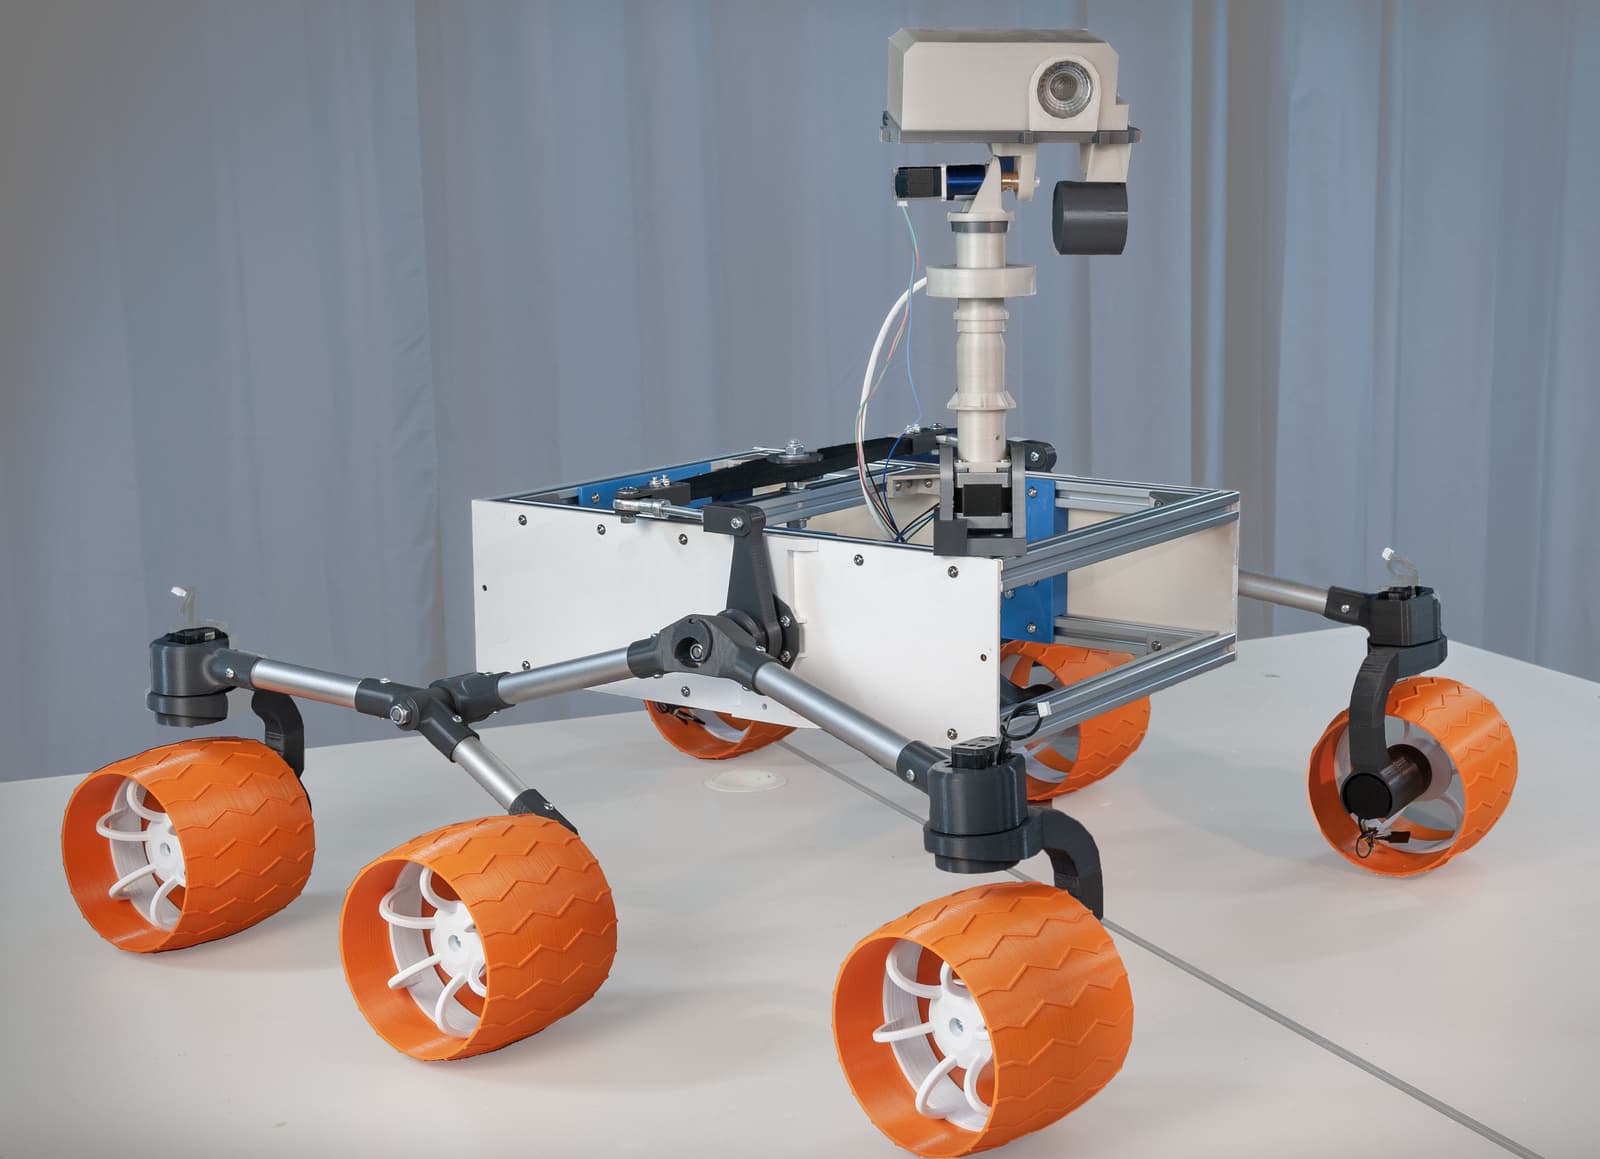
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
Naviton is an open-source robot whose CAD data and electronic circuit designs are published in this repository.
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.
A line-following robot hardware documentation set with CAD files, 3D printable parts and circuit schematics for the TrainingTracer Ver.3 educational robot.
 Wheeled
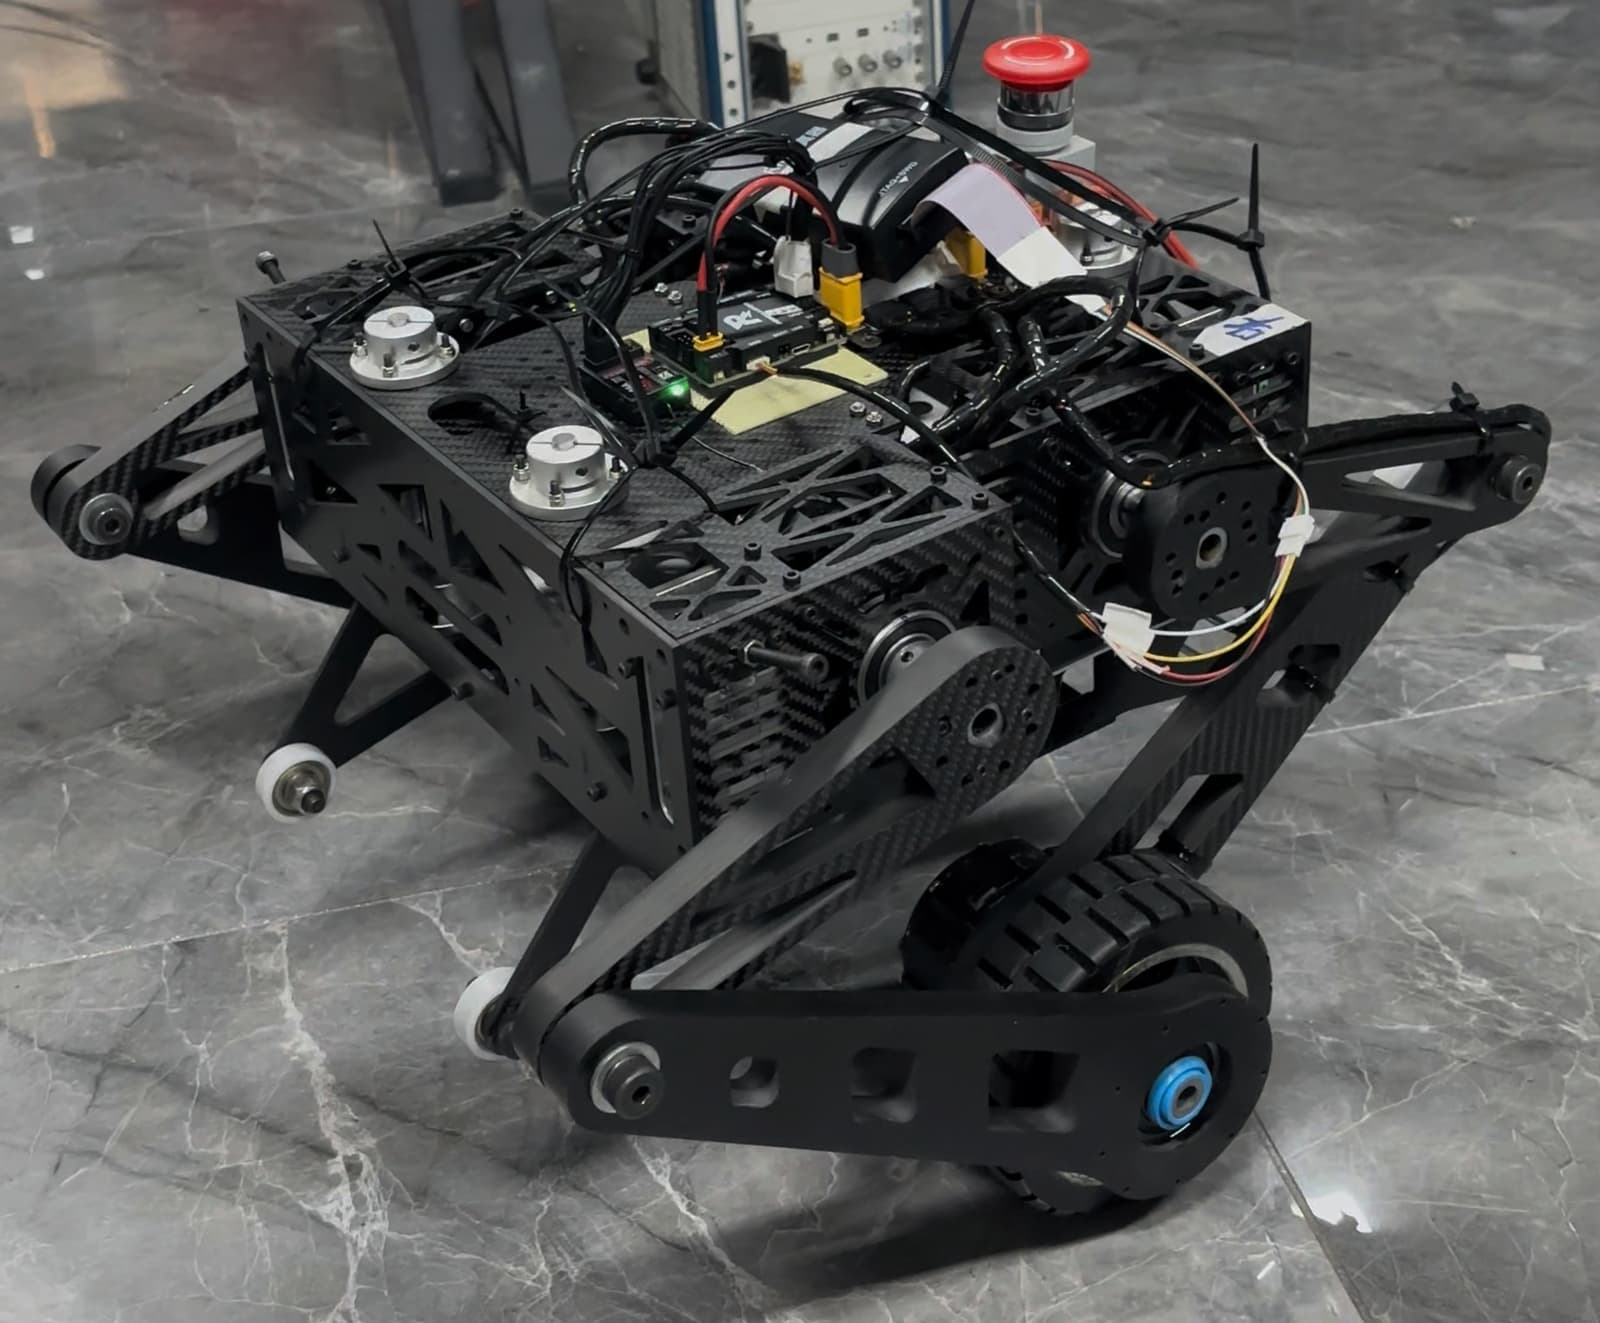
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
 Wheeled
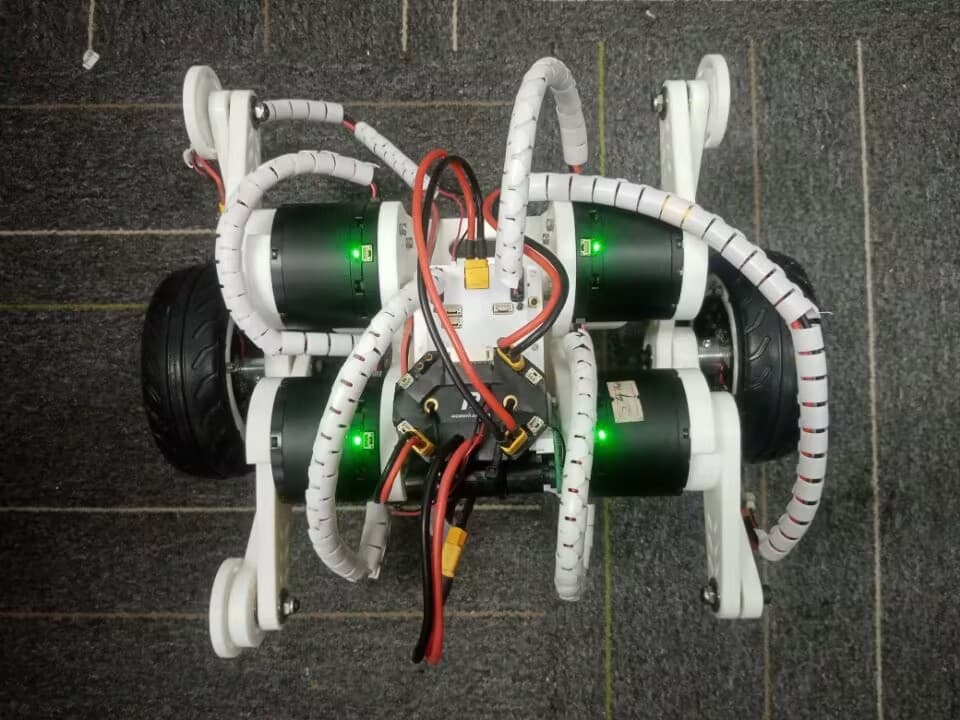
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.
Robots 25–38 of 38