No photo yet
Robot armPoppy Ergo Jr
A small, low-cost 6-degree-of-freedom 3D-printed robot arm driven by Dynamixel XL-320 motors and controlled from a Raspberry Pi.
- Level
- Beginner
- Buildability
- 50/100
- Buildable with some effort
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
A small, low-cost 6-degree-of-freedom 3D-printed robot arm driven by Dynamixel XL-320 motors and controlled from a Raspberry Pi.
A small 4-degree-of-freedom robot arm with 3D printed parts, driven by four SG90 servos and an Arduino Nano.
 Robot arm
A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.
 Robot arm
A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
 Robot arm
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
An open source six degree of freedom industrial robot arm that can hold 2kg at 80cm.
An open-source dexterous hand system that uses gesture recognition to control a 3D-printed robotic hand and play music.
A 6-DOF robotic arm built with 3D-printed parts and Feetech STS3215 bus servos, controlled via LeRobot.
 Robot arm
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
 Robot arm
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
 Robot arm
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
An open-source 3D-printed robotic arm with 5 degrees of freedom and a gripper.
A desktop robotic arm designed for easy 3D printing with minimal parts, featuring a 3D-printed structure and basic electronic components.
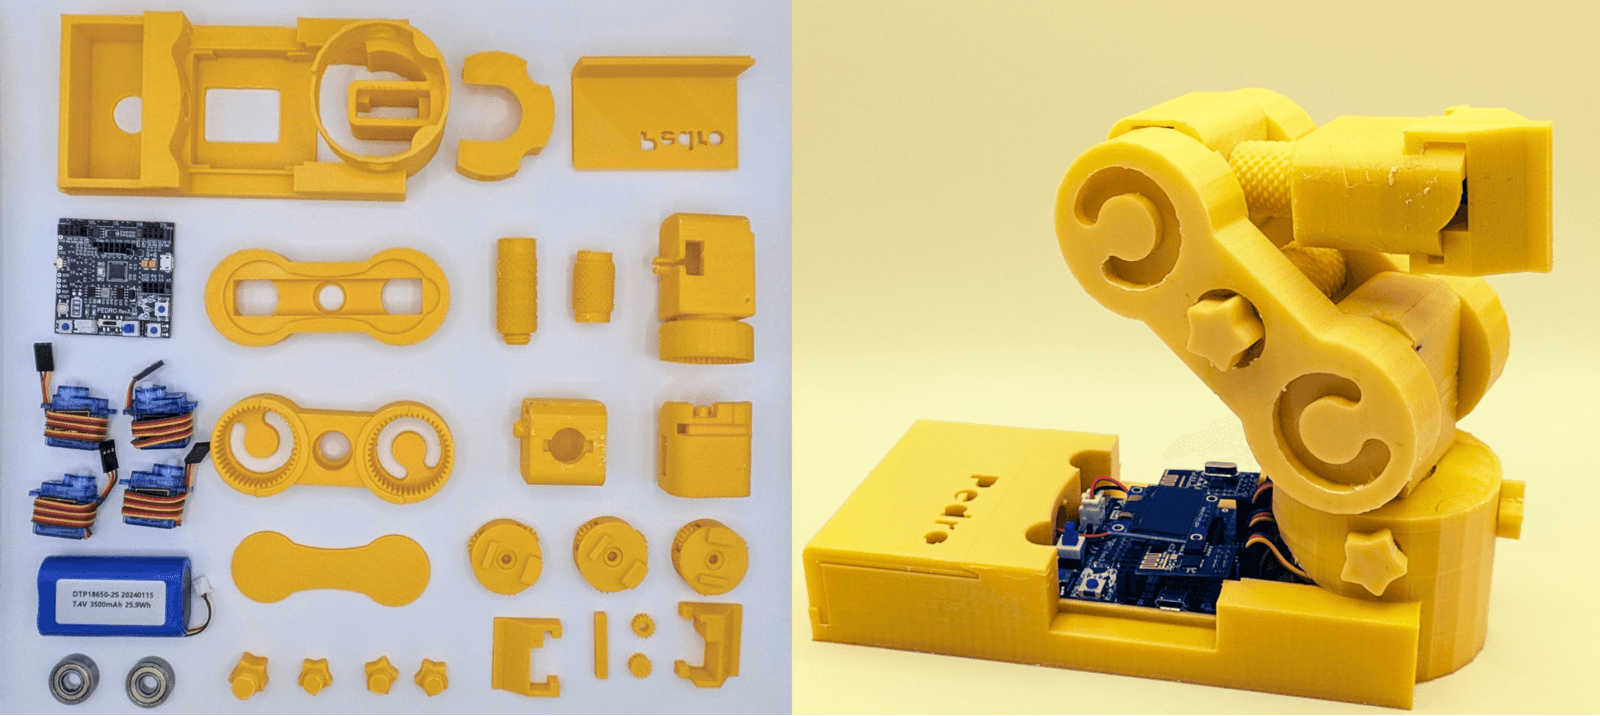 Robot arm
Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.
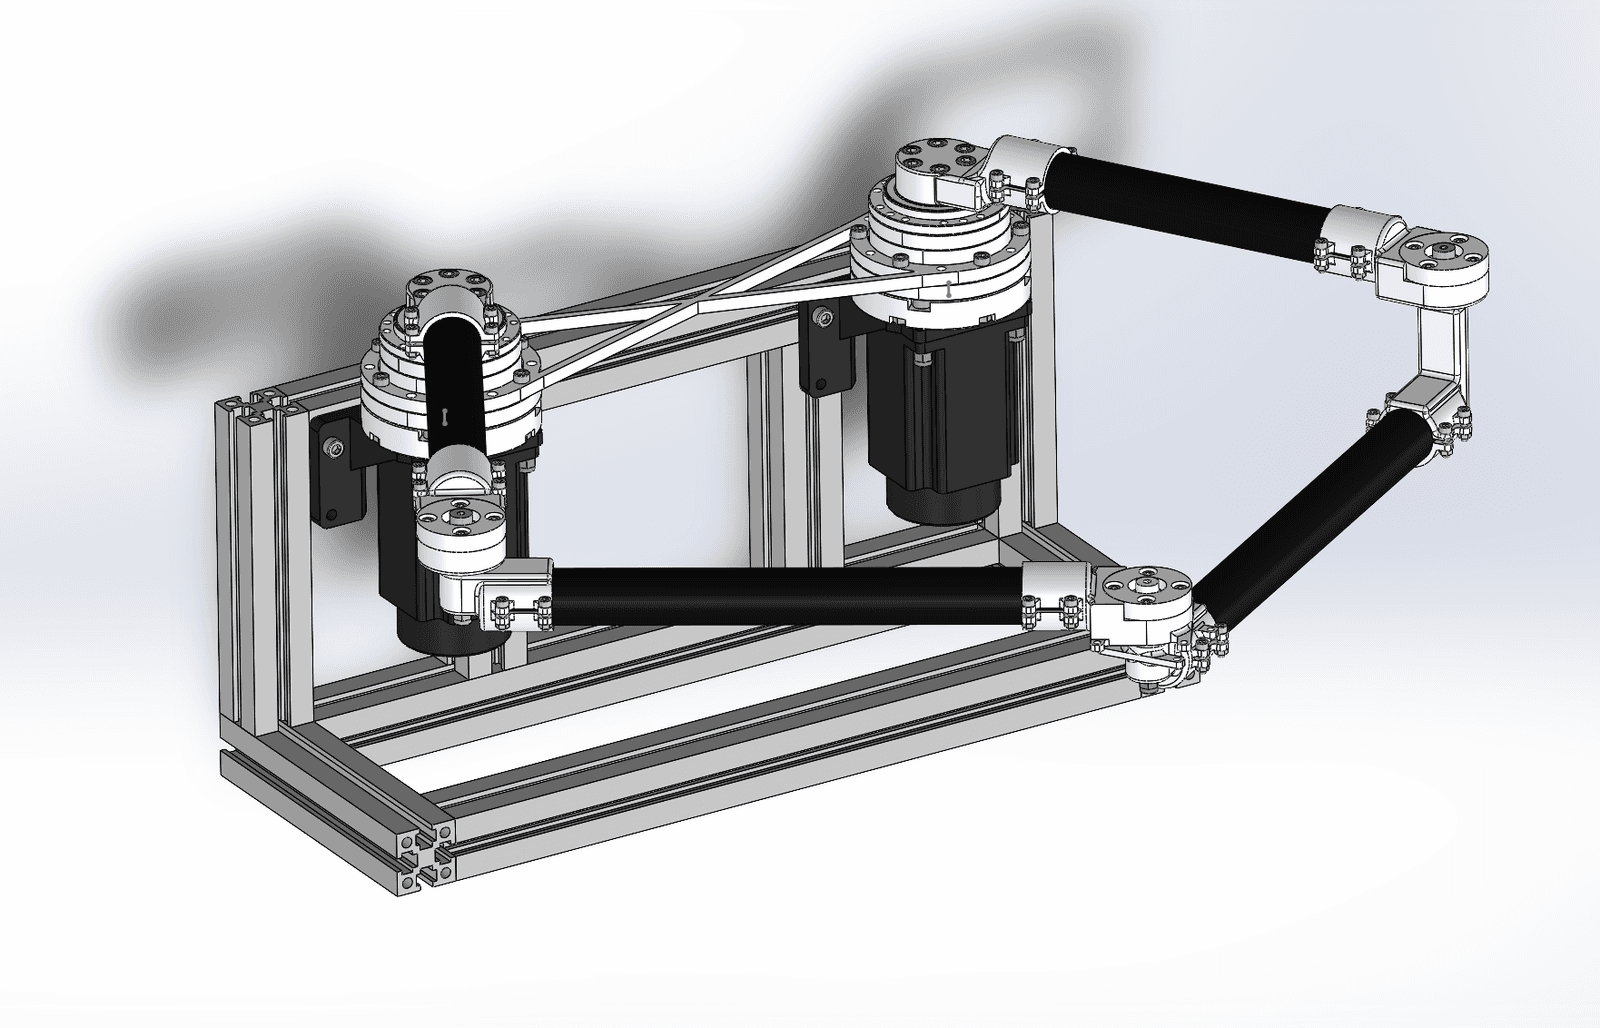 Robot arm
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
A tiny open-source writing robot arm designed for AI drawing applications.
A 3D-printable robot arm, current version V4 (Green), designed for printing and assembly by hobbyists.
A compact smart robotic arm with 6 degrees of freedom, designed for educational and hobbyist use.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
 Robot arm
A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.
A writing robot based on ESP8266 that can perform manual timekeeping, weather forecasting, and function as a general-purpose robotic arm.
A pair of lockable exoskeleton gloves designed to save climbers' energy by locking fingers during climbing.
A replica robotic arm based on the UR5 structure, featuring stepper motors, closed-loop control, and an Android app for interaction.
 Robot arm
A minimalist underactuated robotic hand with one motor per finger, achieving adaptive grasping for humanoid robots.
Robots 25–48 of 48