Rush Mog
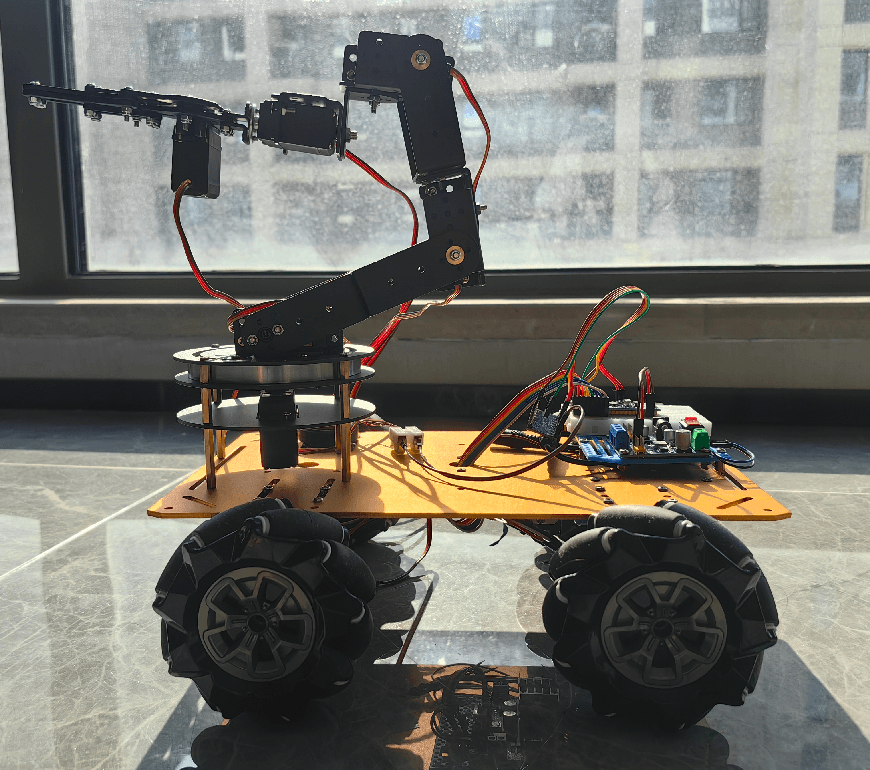
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
- Work in progress
- Works with AI
Robots on wheels: rovers, mobile bases and robots that carry an arm. 54 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 3 · Ready to build first, then by buildability
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
A series of open-source remote-controlled mini car modification projects with multiple chassis sizes and control schemes.
A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
A self-balancing robot using STM32F103C8T6 with Mahony algorithm for attitude estimation.
An educational wheeled rover controlled by a Raspberry Pi Zero W, with a DRV8835 motor driver, OLED display, 9-axis sensor and LEDs.
A fully autonomous mobile robot designed for counter-terrorism, bomb disposal, and rescue tasks, featuring a four-wheel drive chassis, five-degree-of-freedom robotic arm, and multi-vision systems.
A small two-wheeled differential-drive mobile platform robot built around a Jetson Nano, with dual cameras and 3D CAD data for its hardware.
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
Naviton is an open-source robot whose CAD data and electronic circuit designs are published in this repository.
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.
A universal electronic control software architecture for a Mecanum wheel chassis robot based on STM32F427, designed for Robocon 2024 R1.
A line-following robot hardware documentation set with CAD files, 3D printable parts and circuit schematics for the TrainingTracer Ver.3 educational robot.
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
A two-wheeled self-balancing robot controlled by an LQR algorithm on an STM32F103C8T6, with a custom-drawn control board and mechanical structure.
An ESP32-based self-balancing robot car with dual wheels, open-source hardware and software, including 3D models and BOM.
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.
An open-source Mars rover robot with ESP32-based electronics and Arduino firmware for remote control and sensor integration.
A self-balancing robot car built with STM32F103C8T6, MPU6050, MX1508, ESP8266, and OLED.
A self-balancing robot car that uses PID control and features ultrasonic obstacle avoidance, ultrasonic following, and Bluetooth remote control.
Robots 25–48 of 54