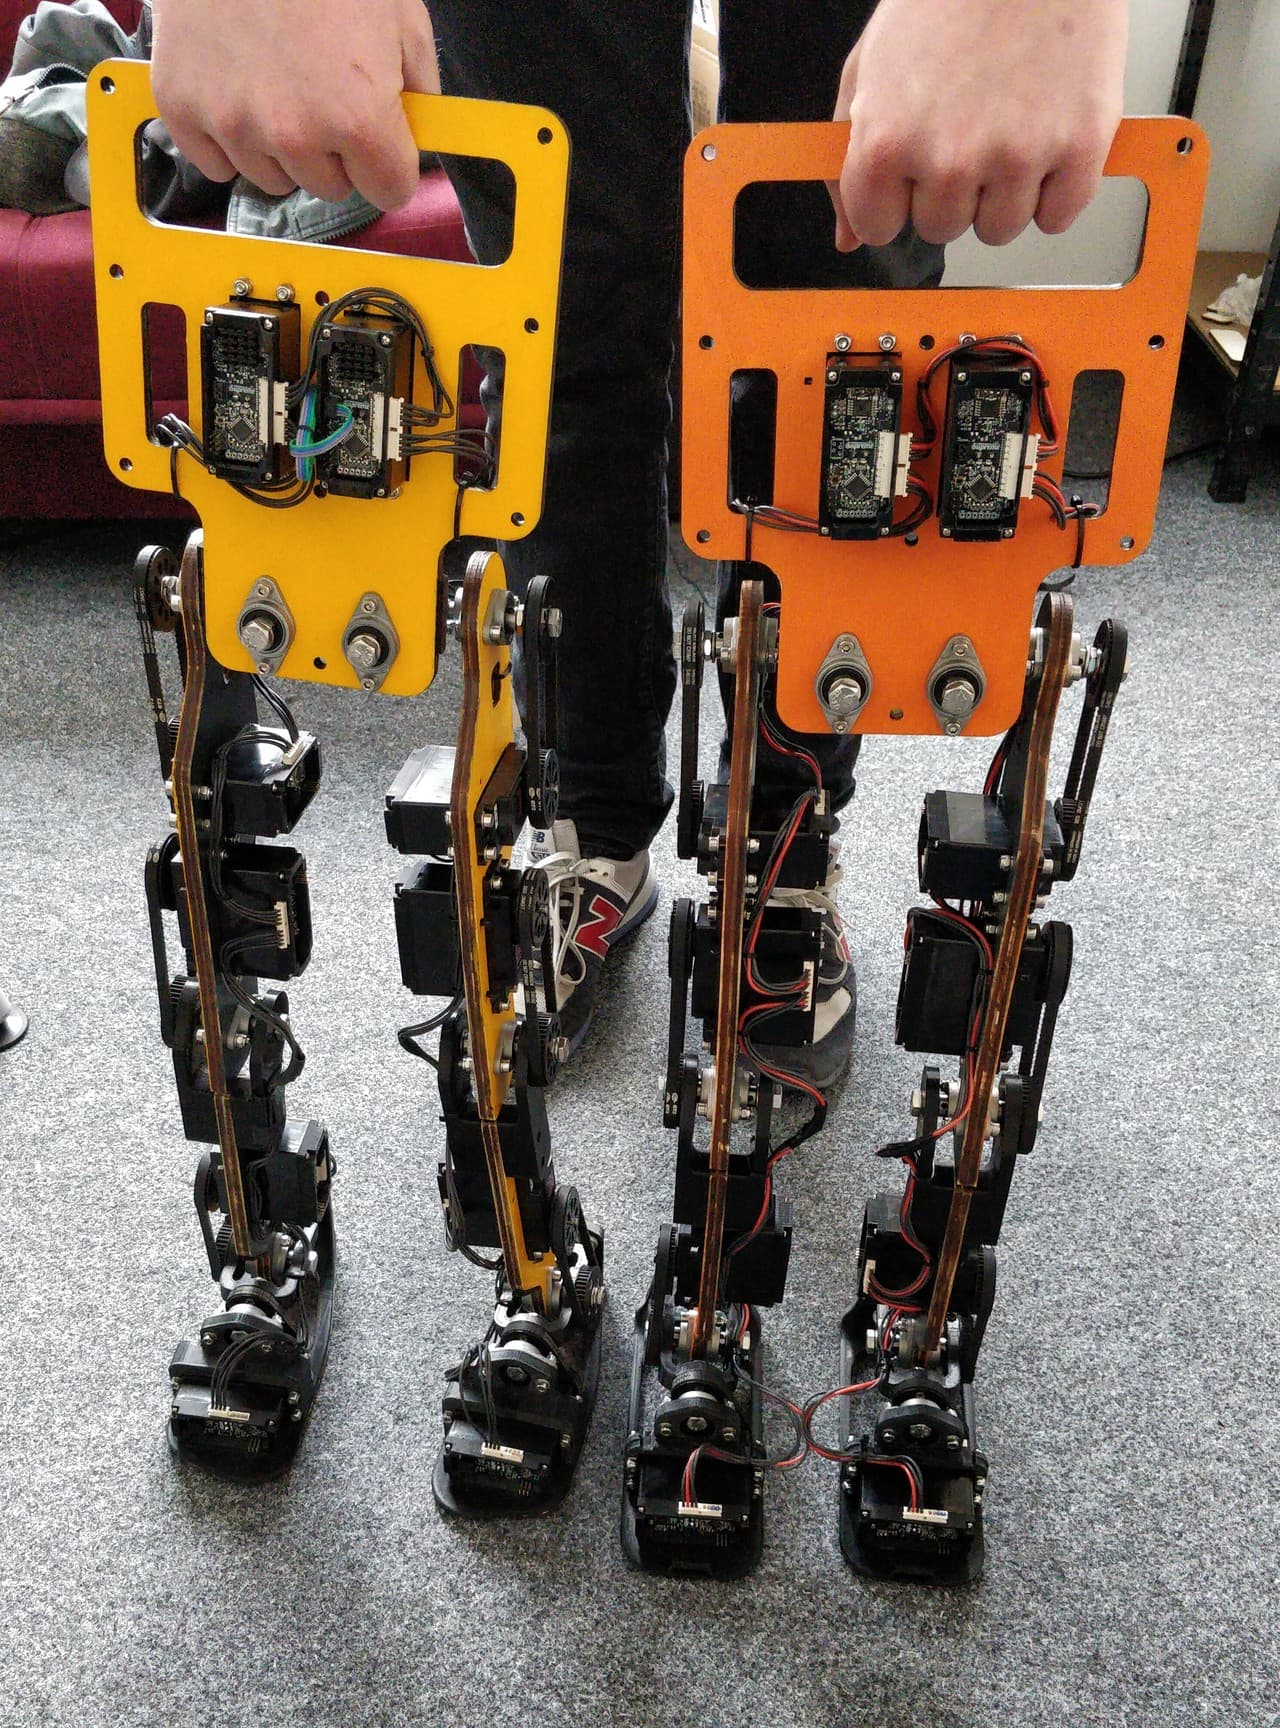
Gretchen
Gretchen is an open-source humanoid robot development platform.
HumanoidAdvancedBuildability 35/100 · Incomplete documentation
Cost not stated
Robots whose guide reads in English, as written or translated by Robotheca. 197 robots on Robotheca, each with its licenses and its source on GitHub.
Page 7 of 9 · Ready to build first, then by buildability
Gretchen is an open-source humanoid robot development platform.
A small two-wheeled differential-drive mobile platform robot built around a Jetson Nano, with dual cameras and 3D CAD data for its hardware.
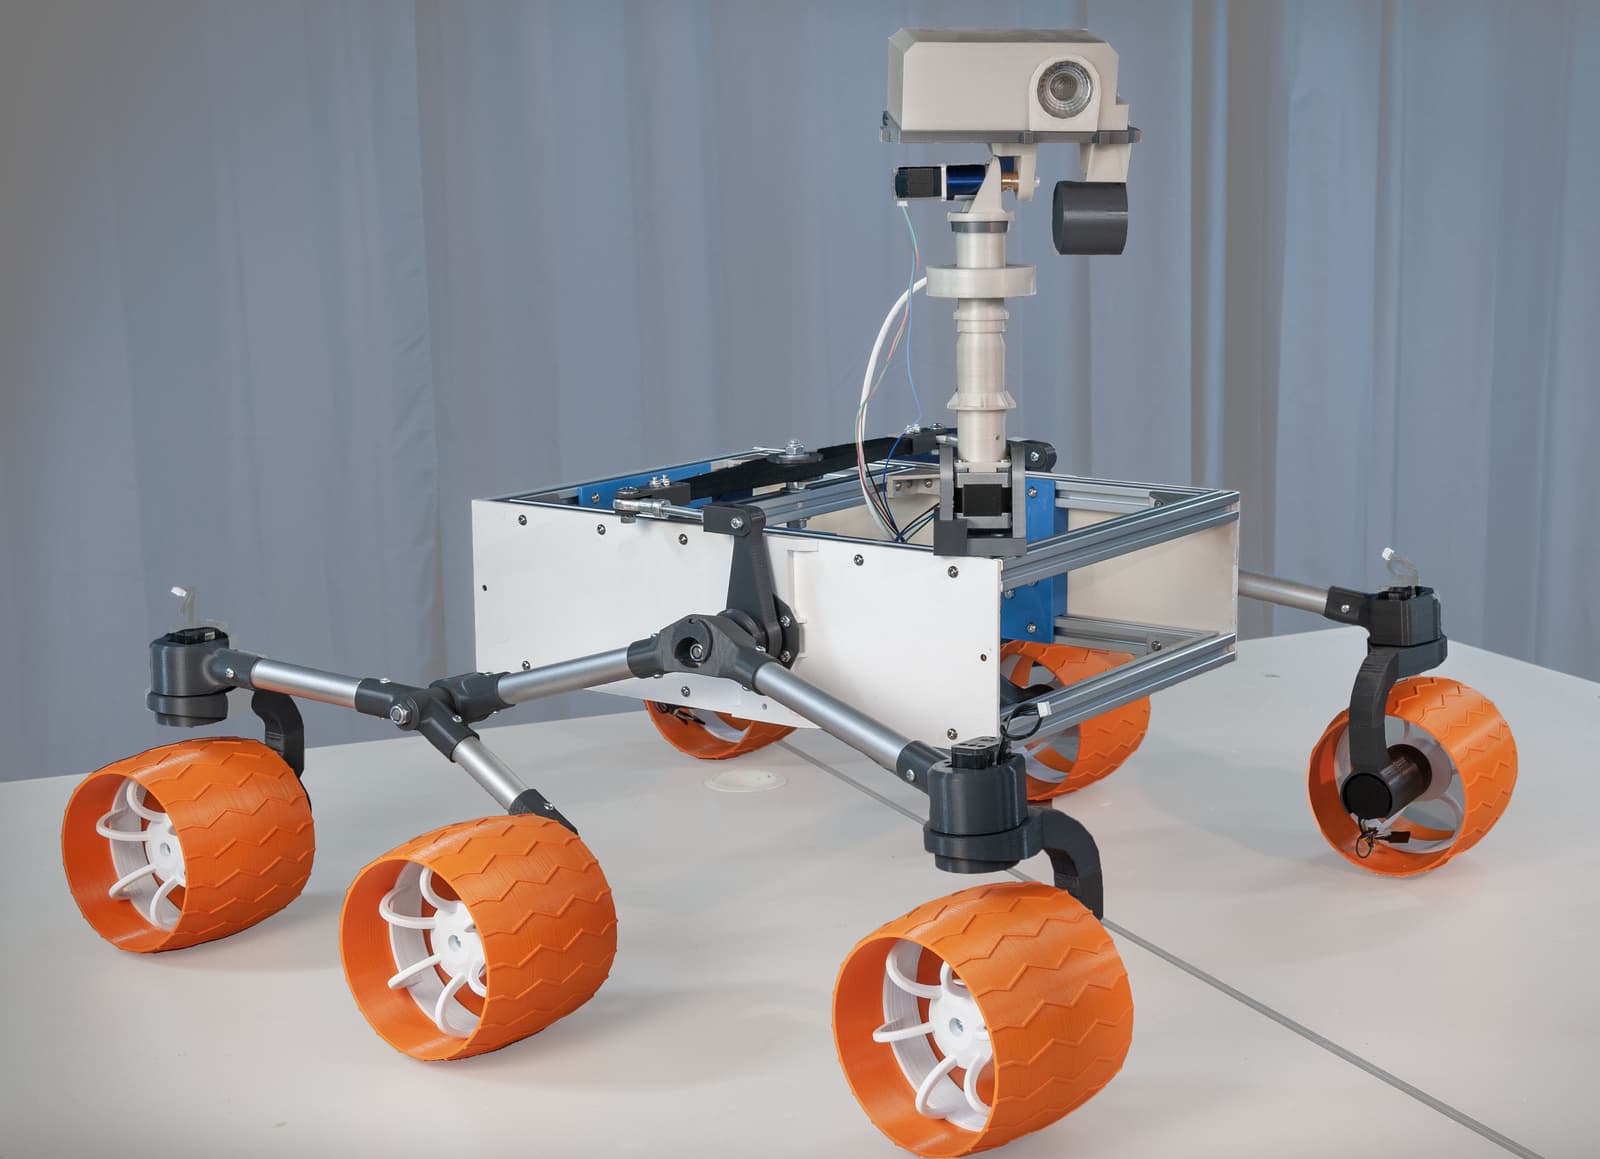
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
An independent hobbyist recreation of the MicroDuck 3D model, provided as SolidWorks source files and a STEP export for a small robot.
Naviton is an open-source robot whose CAD data and electronic circuit designs are published in this repository.
A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.
A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.
A desktop robot that responds entirely in its own voice, built from 3D-printed parts and custom electronics.
A hexapod robot powered by Raspberry Pi Zero 2 W and controlled using Python, featuring 18 servo motors and remote operation via Bluetooth.
An ultra cheap, simple two-motor robot with four sensors that a middle schooler can build in several hours.
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
An open-source quadruped robot designed for easy DIY with low-cost hardware and software.
An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.
A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.
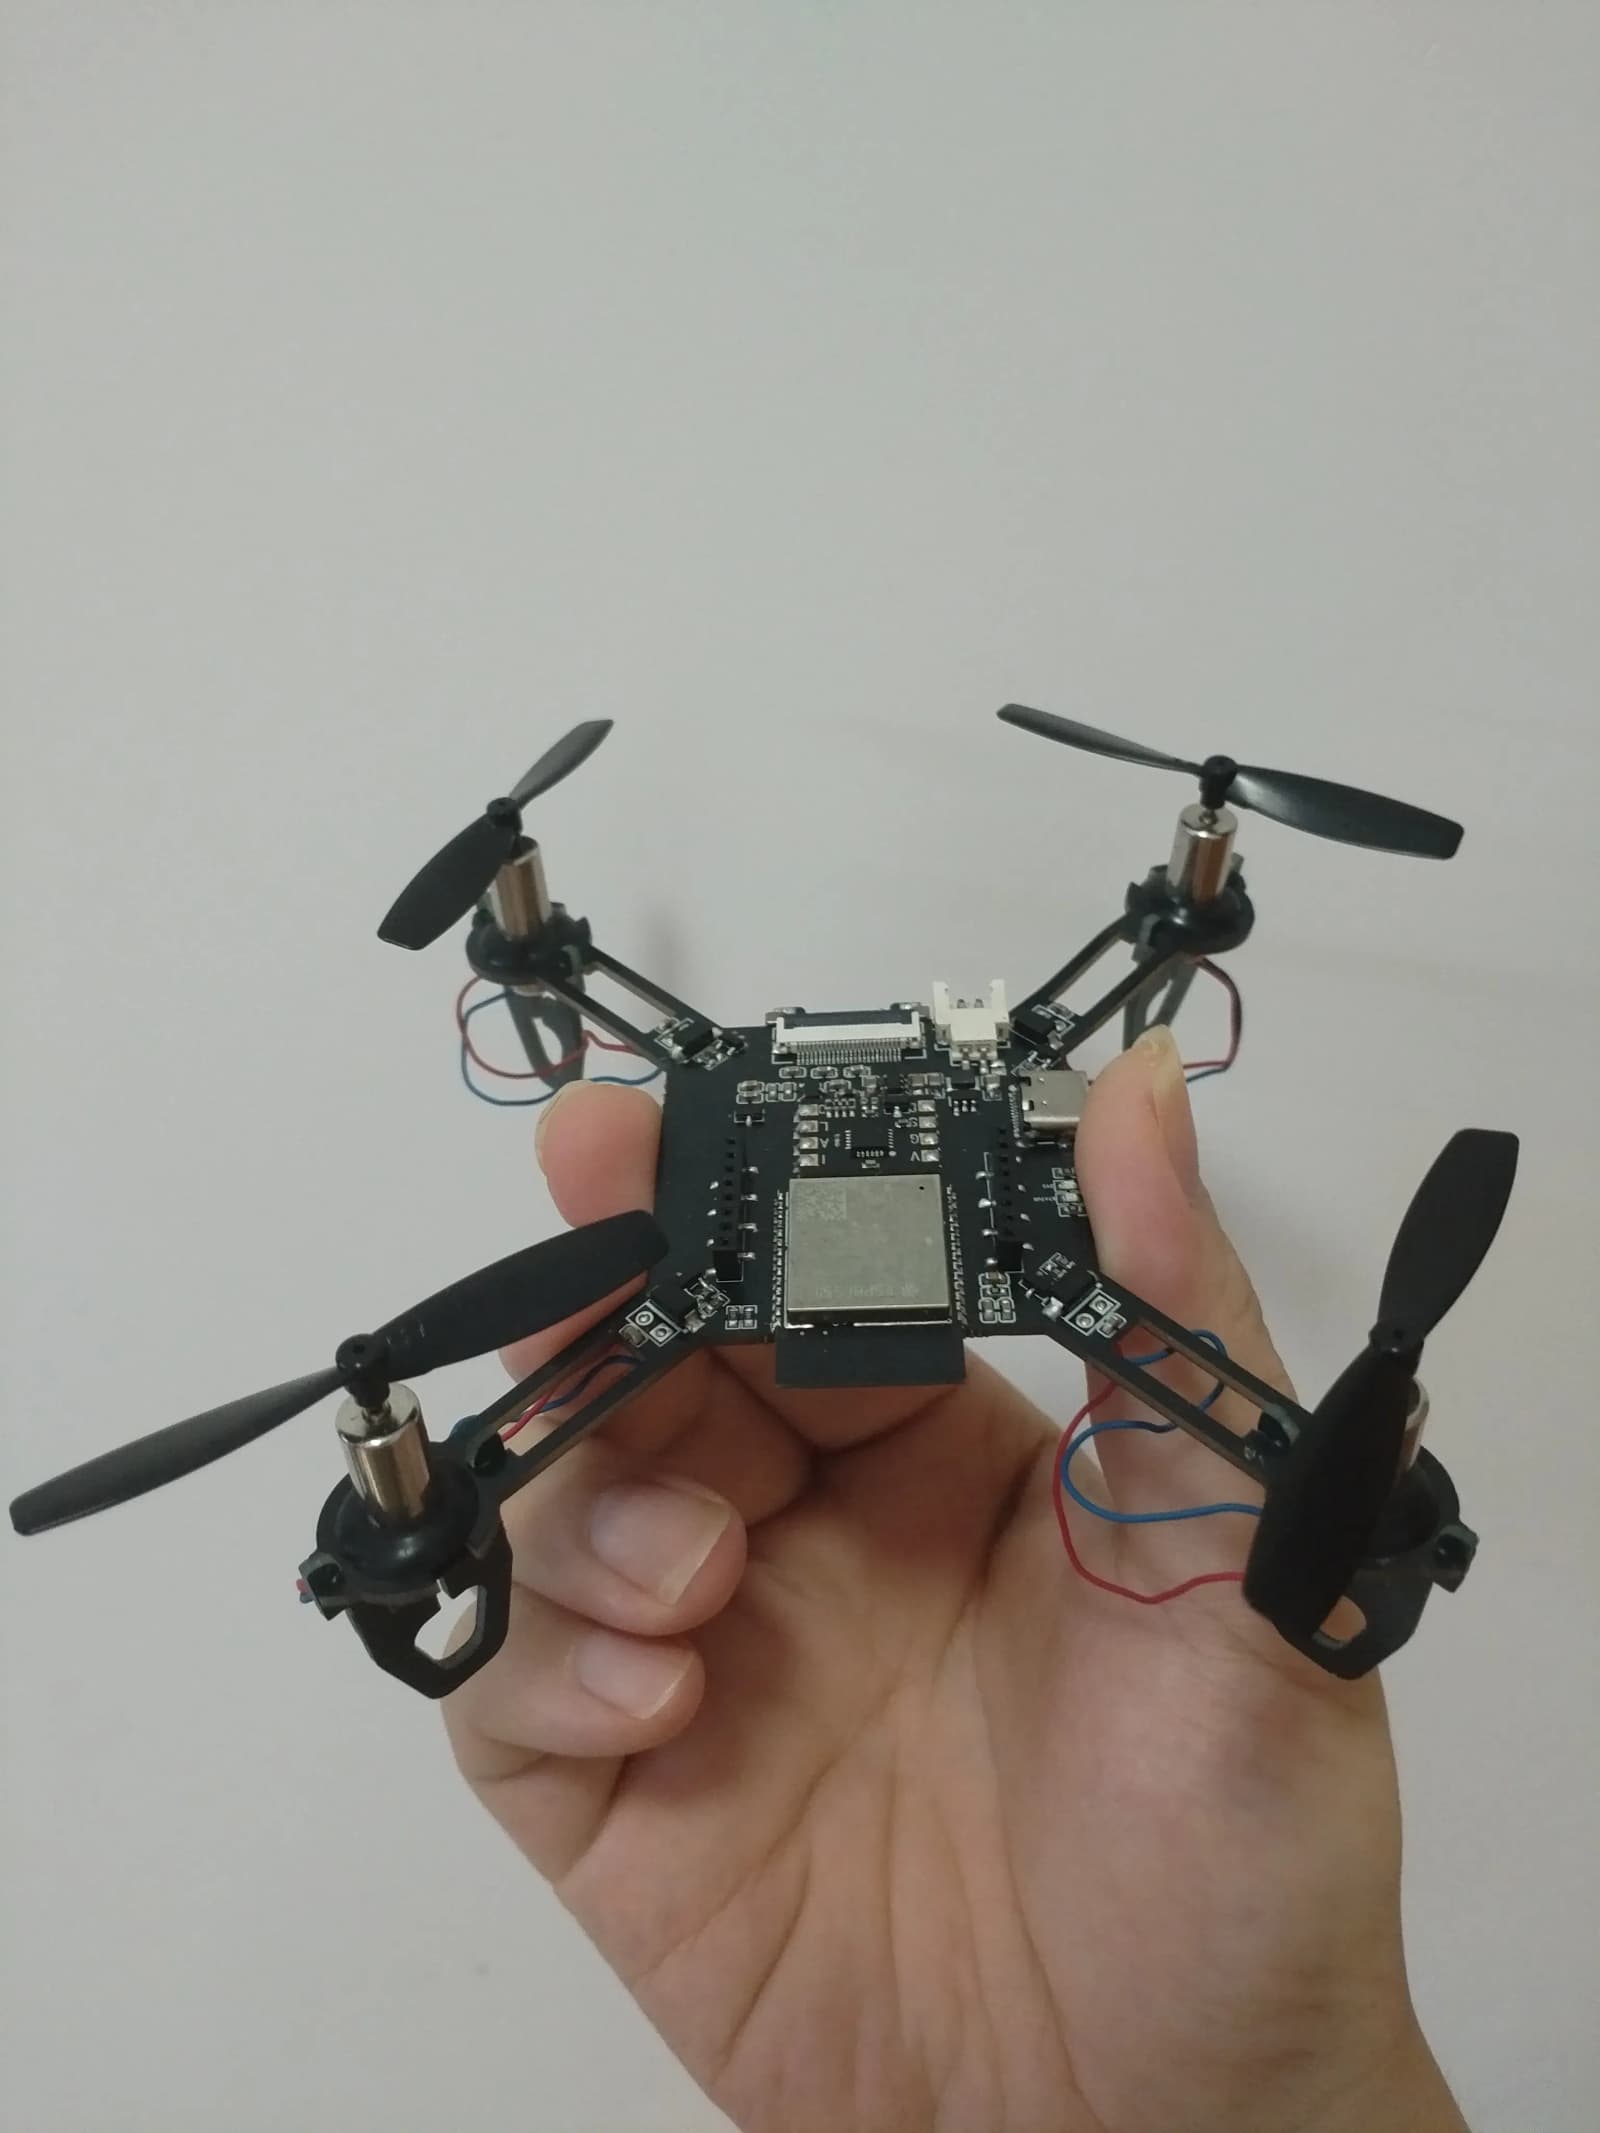
An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.
A line-following robot hardware documentation set with CAD files, 3D printable parts and circuit schematics for the TrainingTracer Ver.3 educational robot.
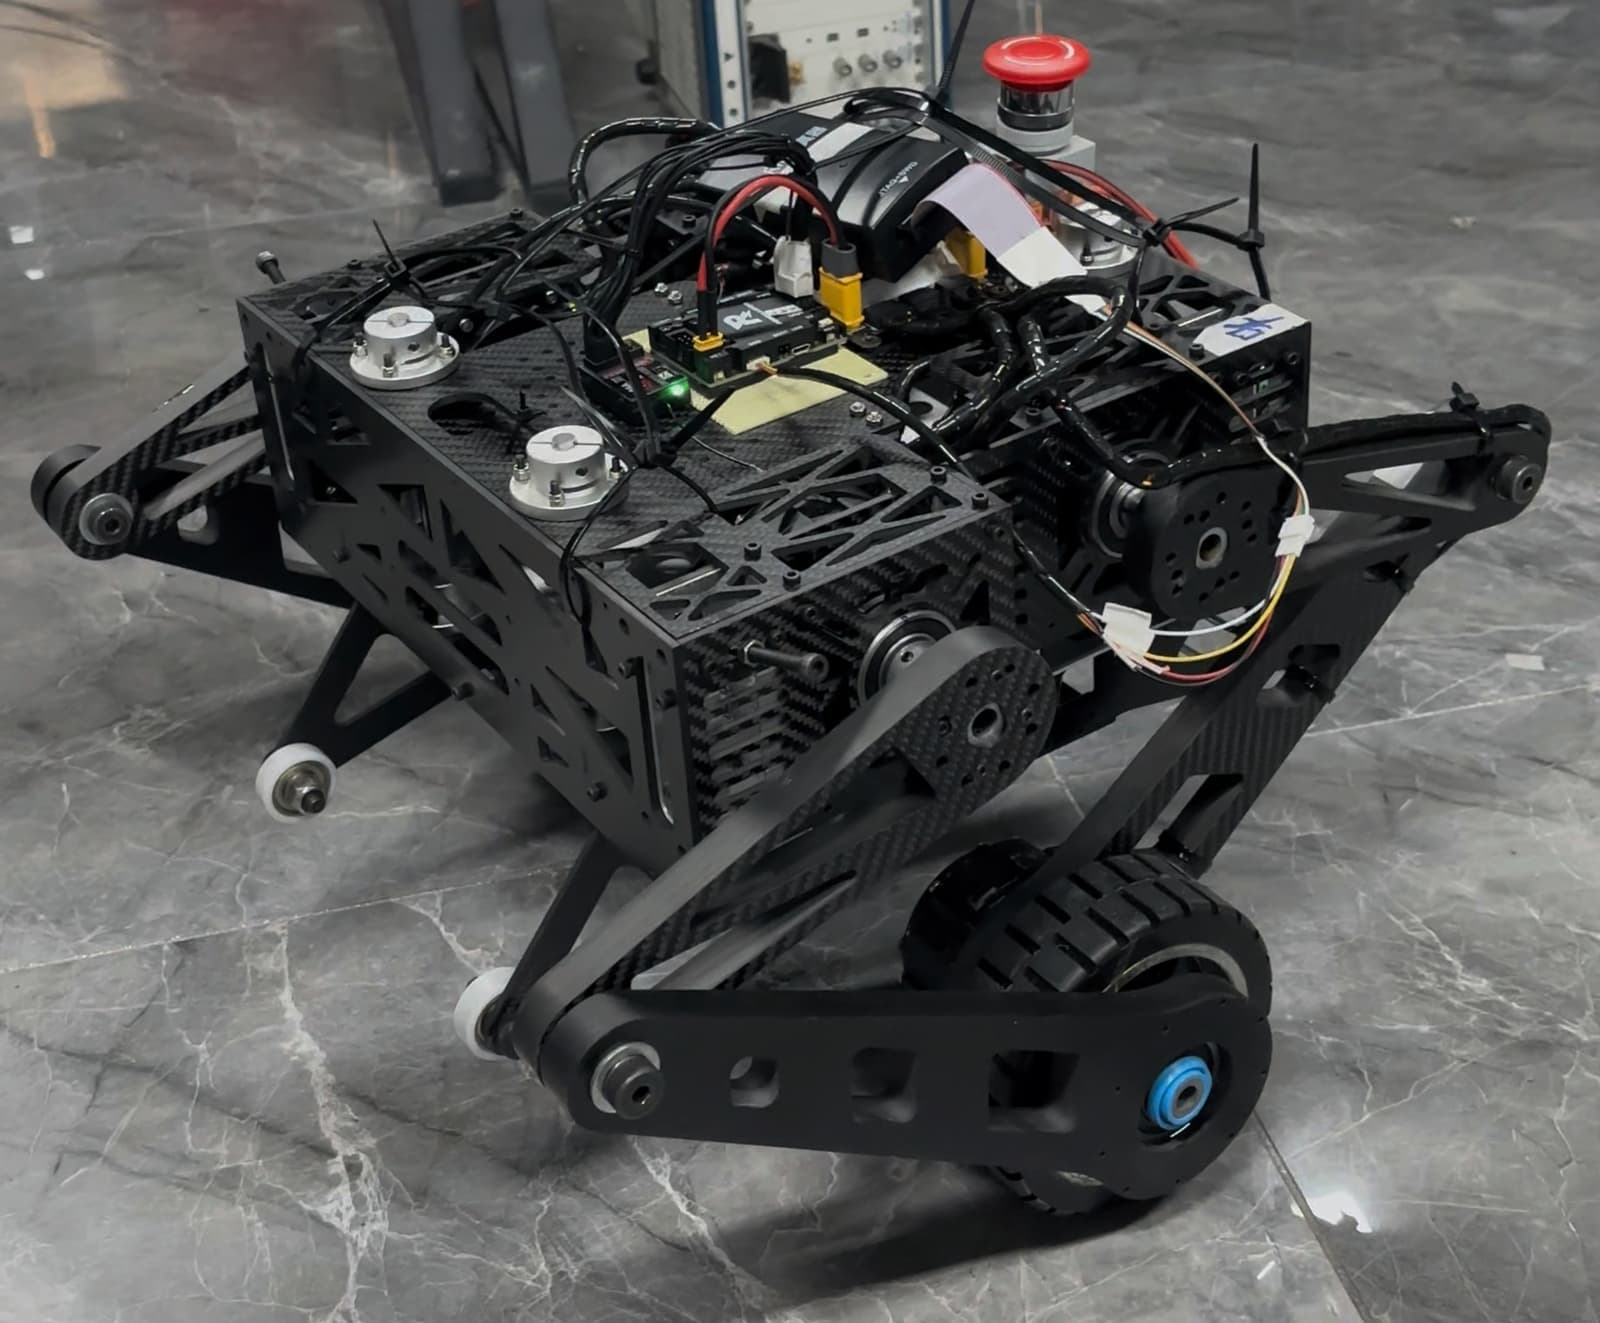
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
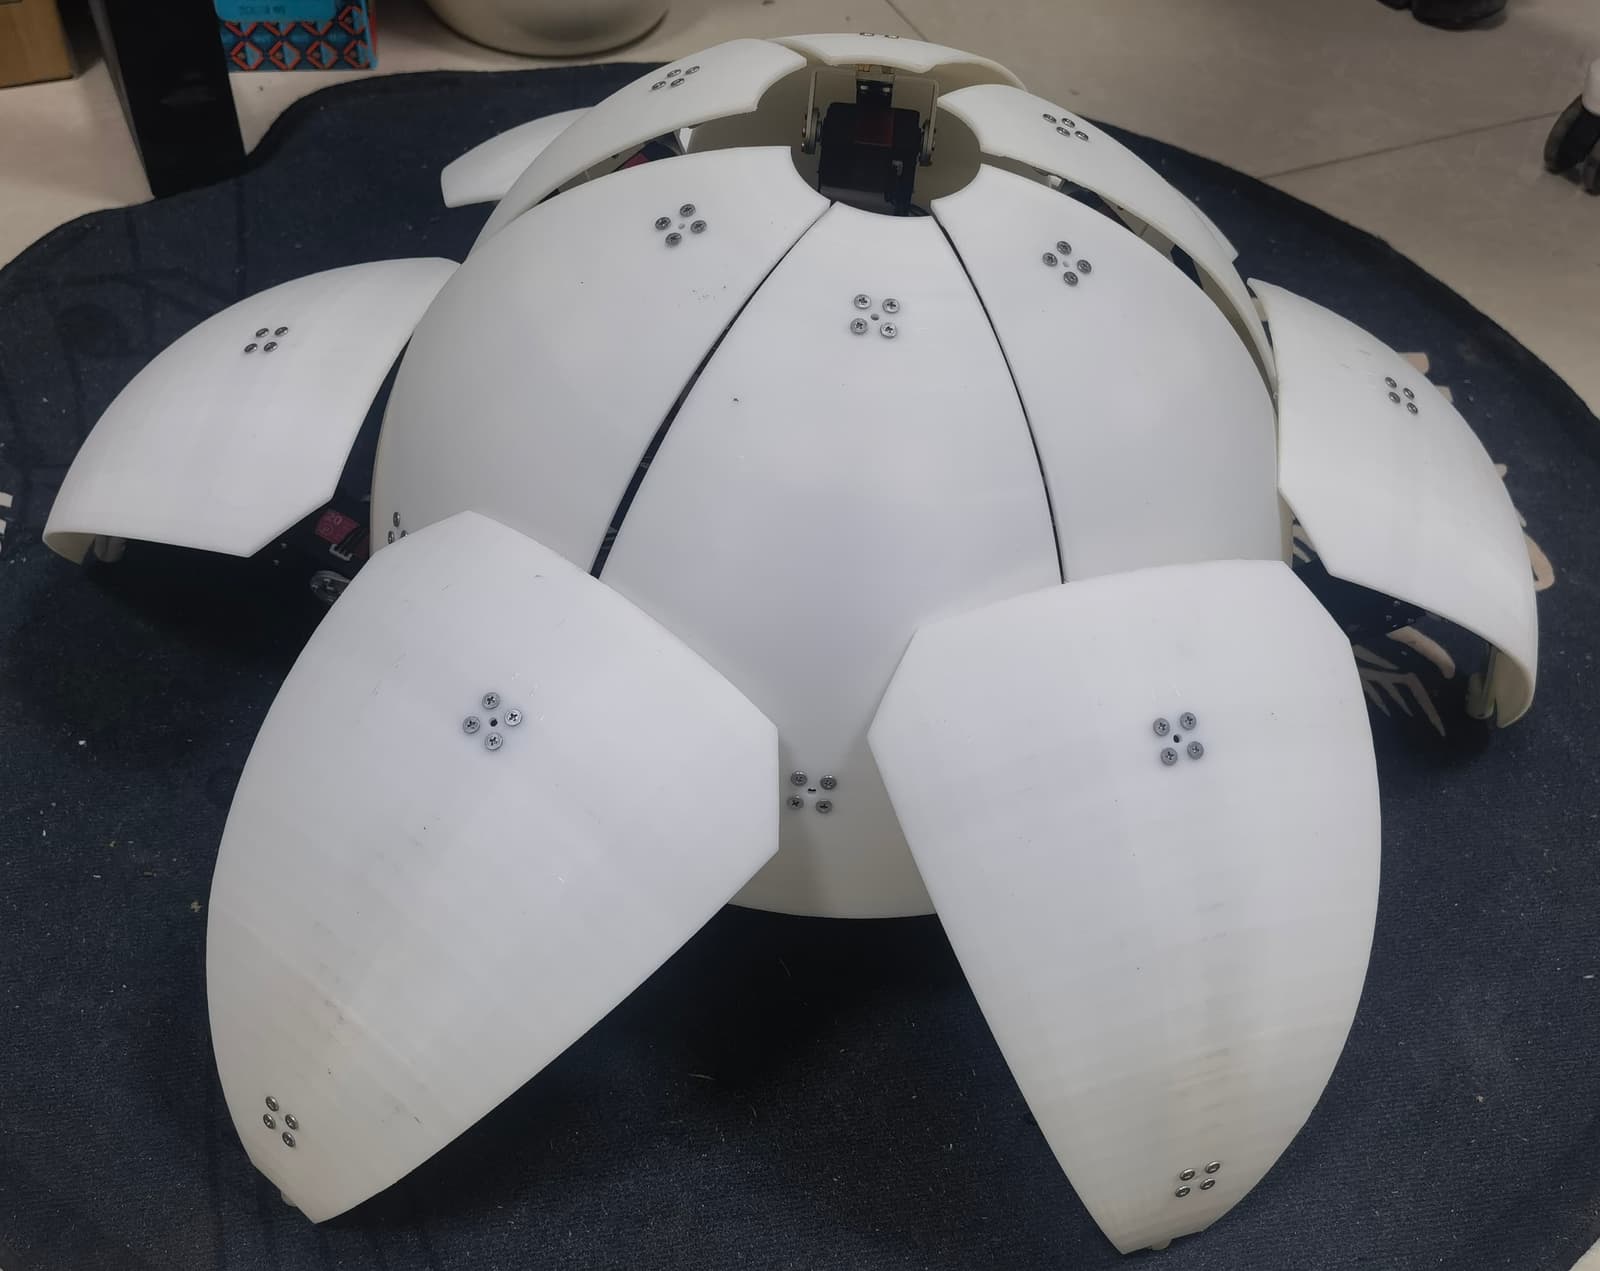
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
An open-source quadcopter framework providing schematics and flight control source code.
An open-source 6-DOF anthropomorphic robotic hand with linkage-based fingers and worm-and-rack transmissions, intended as a low-cost platform for research and education.
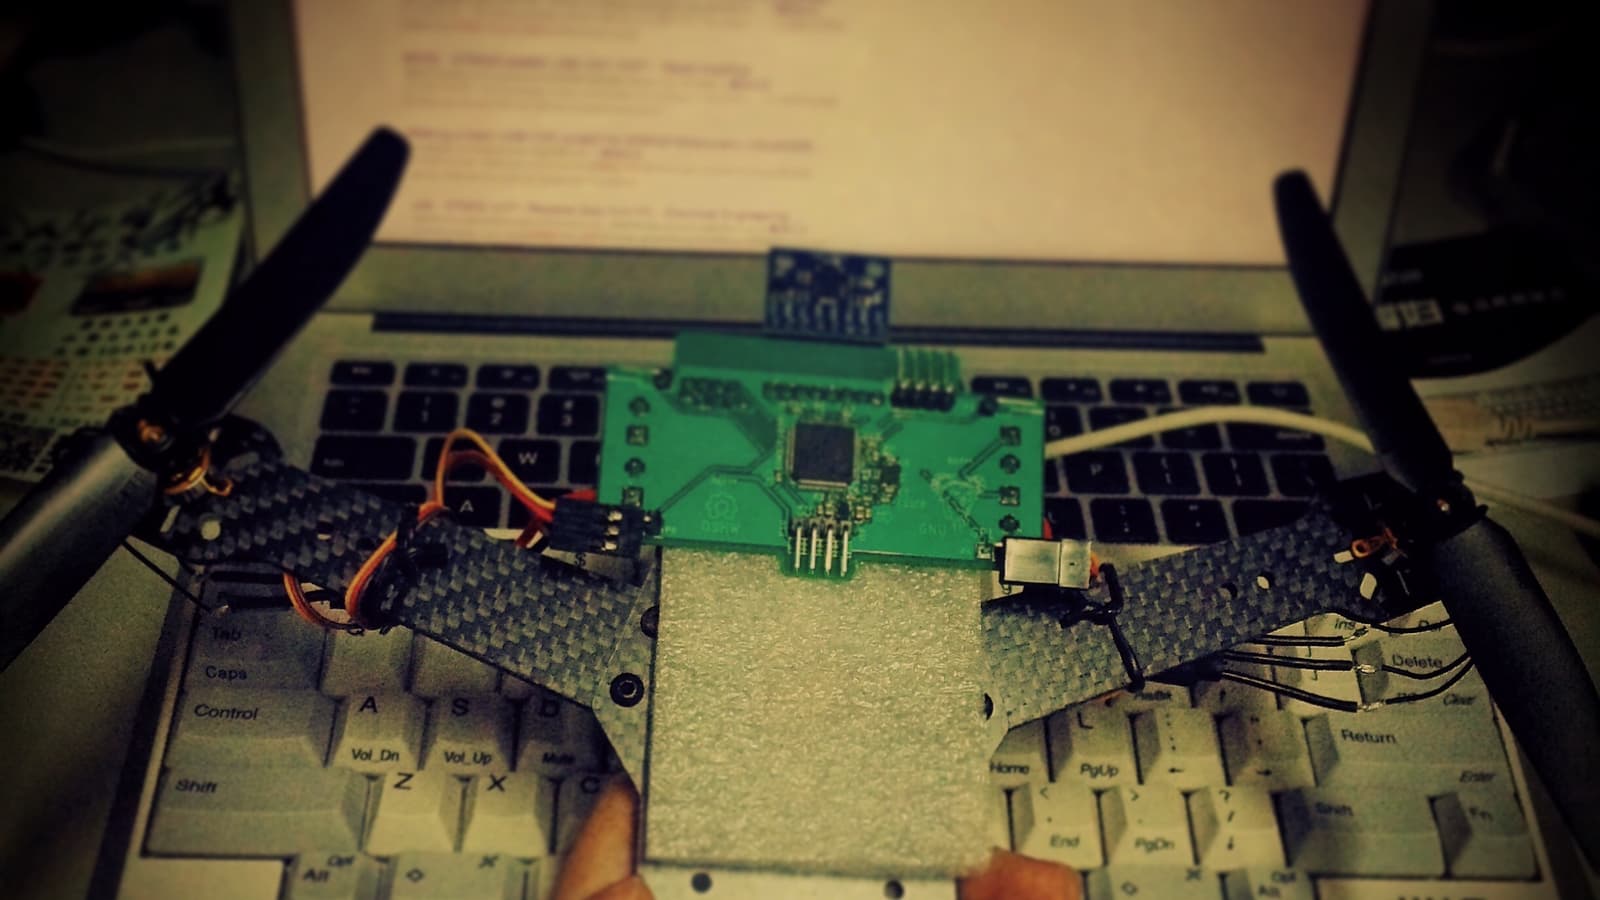
A lightweight drone flight controller using STM32, PID control, and BLDC motors.
Robots 145–168 of 197