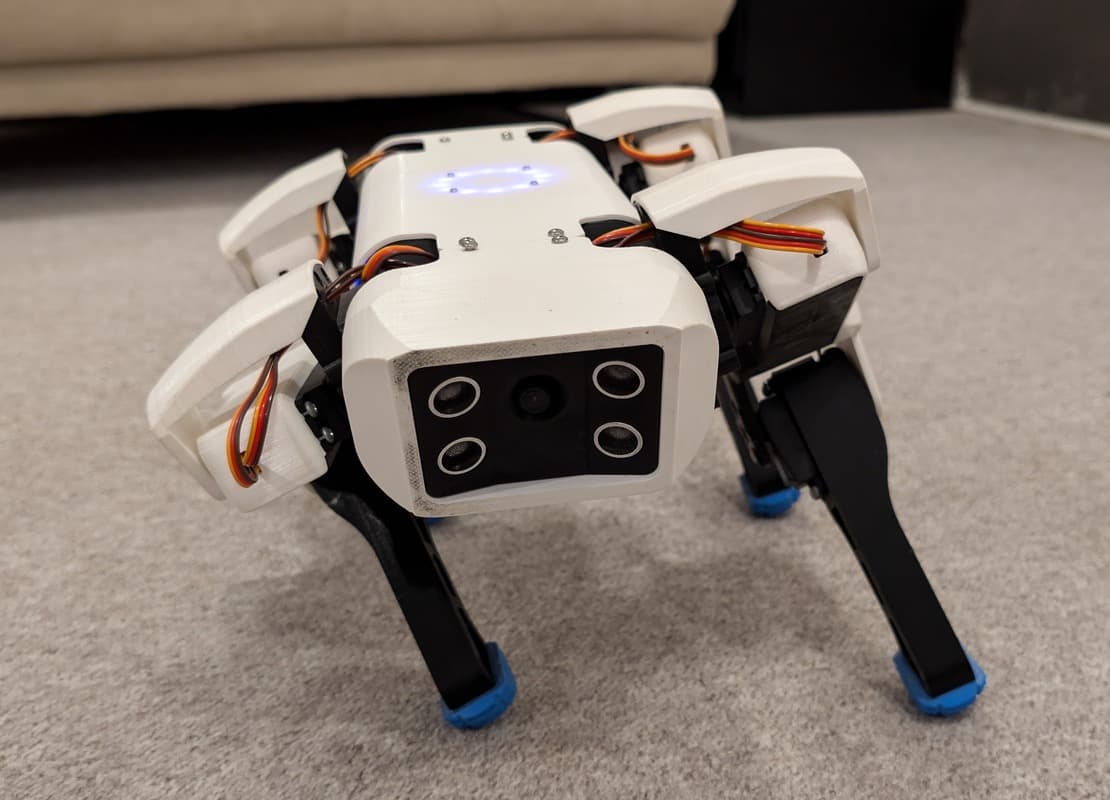
Spot Micro - Leika
An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
QuadrupedAdvancedBuildability 70/100 · Buildable with some effort
Cost not stated
Robots whose guide reads in English, as written or translated by Robotheca. 197 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 9 · Ready to build first, then by buildability
An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
An autonomous AI racecar built on the NVIDIA Jetson Nano that moves at high speeds and follows roads using neural networks.
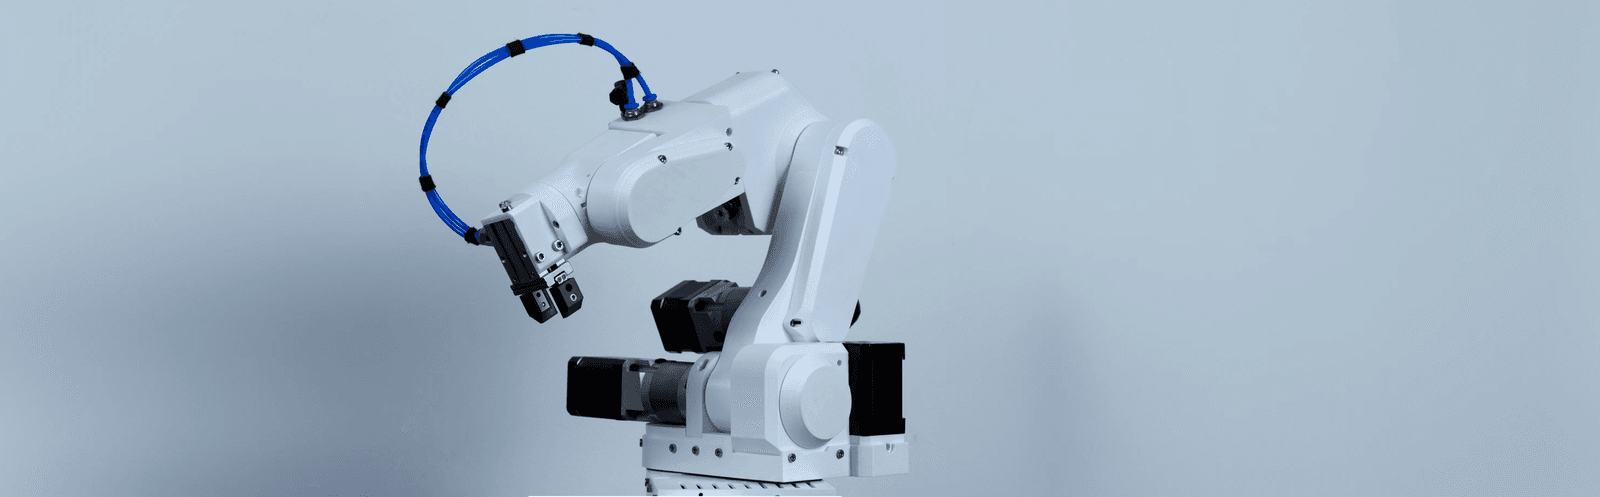
A 6-axis 3D-printed desktop robot arm with stepper motors, gearboxes and belts, modelled on industrial arms, with its own control firmware.
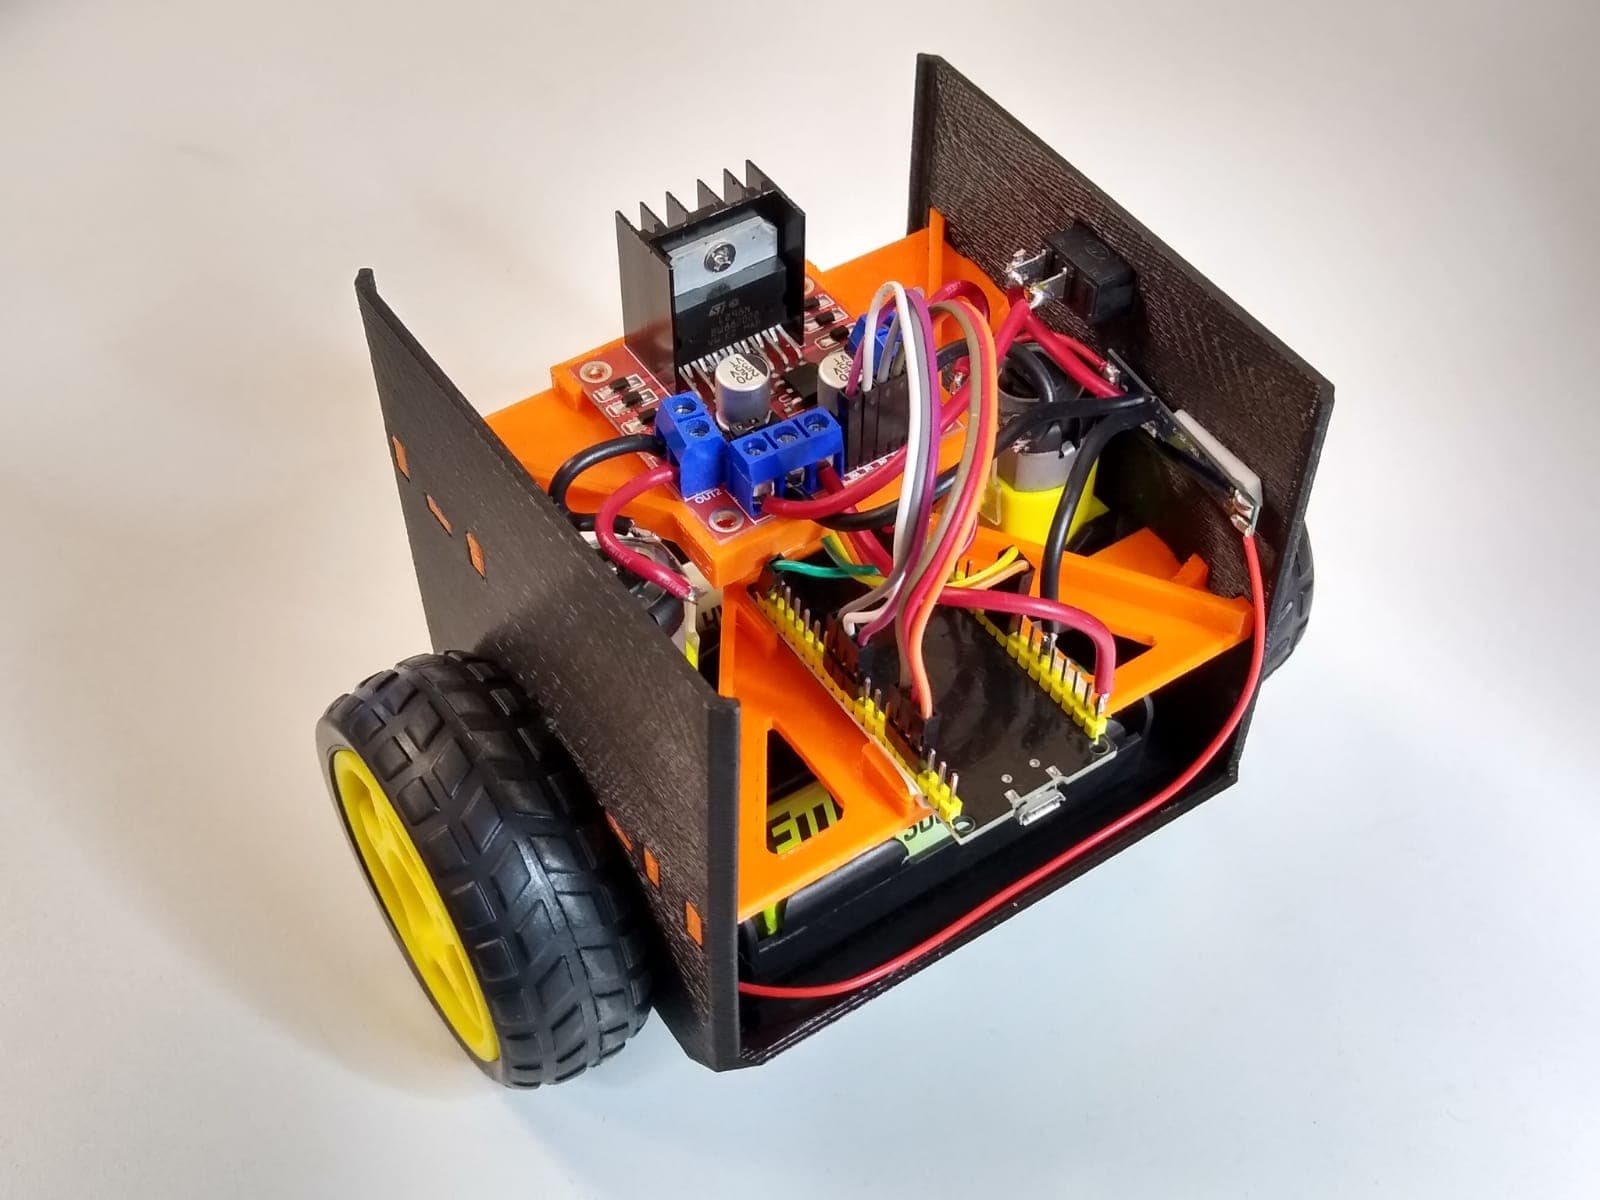
An ultra-low-cost self-balancing robot that can run a neural network to stay balanced and be controlled wirelessly, built for teaching RL, ML, AI and control.
A 7-DOF dual-arm bimanual robot platform derived from the SO-101 design, with matching leader arms for teleoperation.
A low-cost six-axis robotic arm using DAMIAO motors and sheet metal structural parts, designed for students and hobbyists.
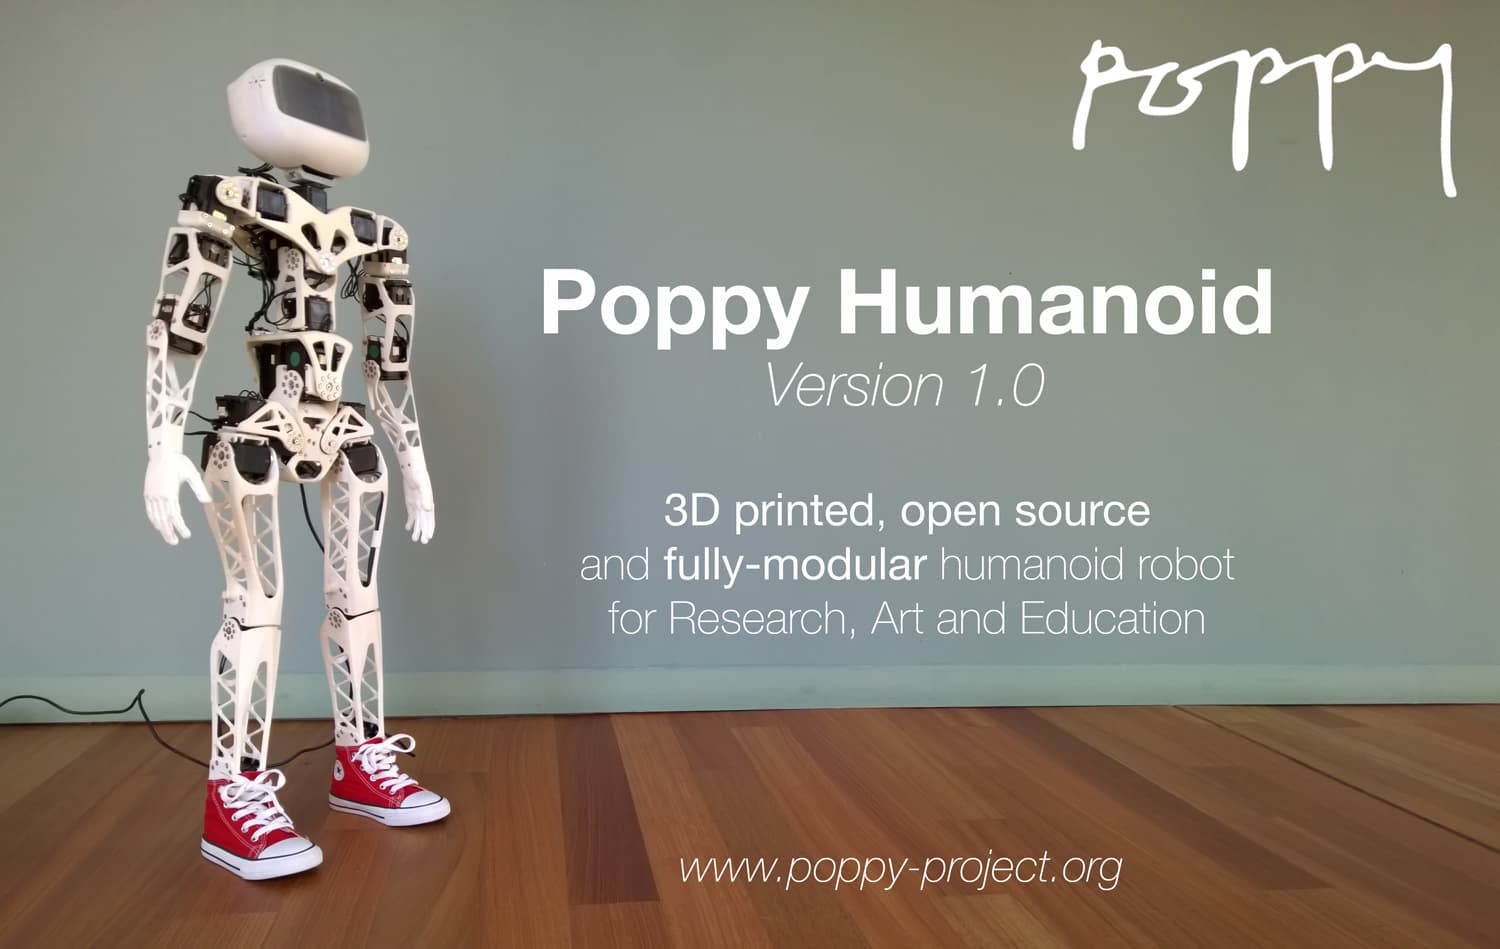
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
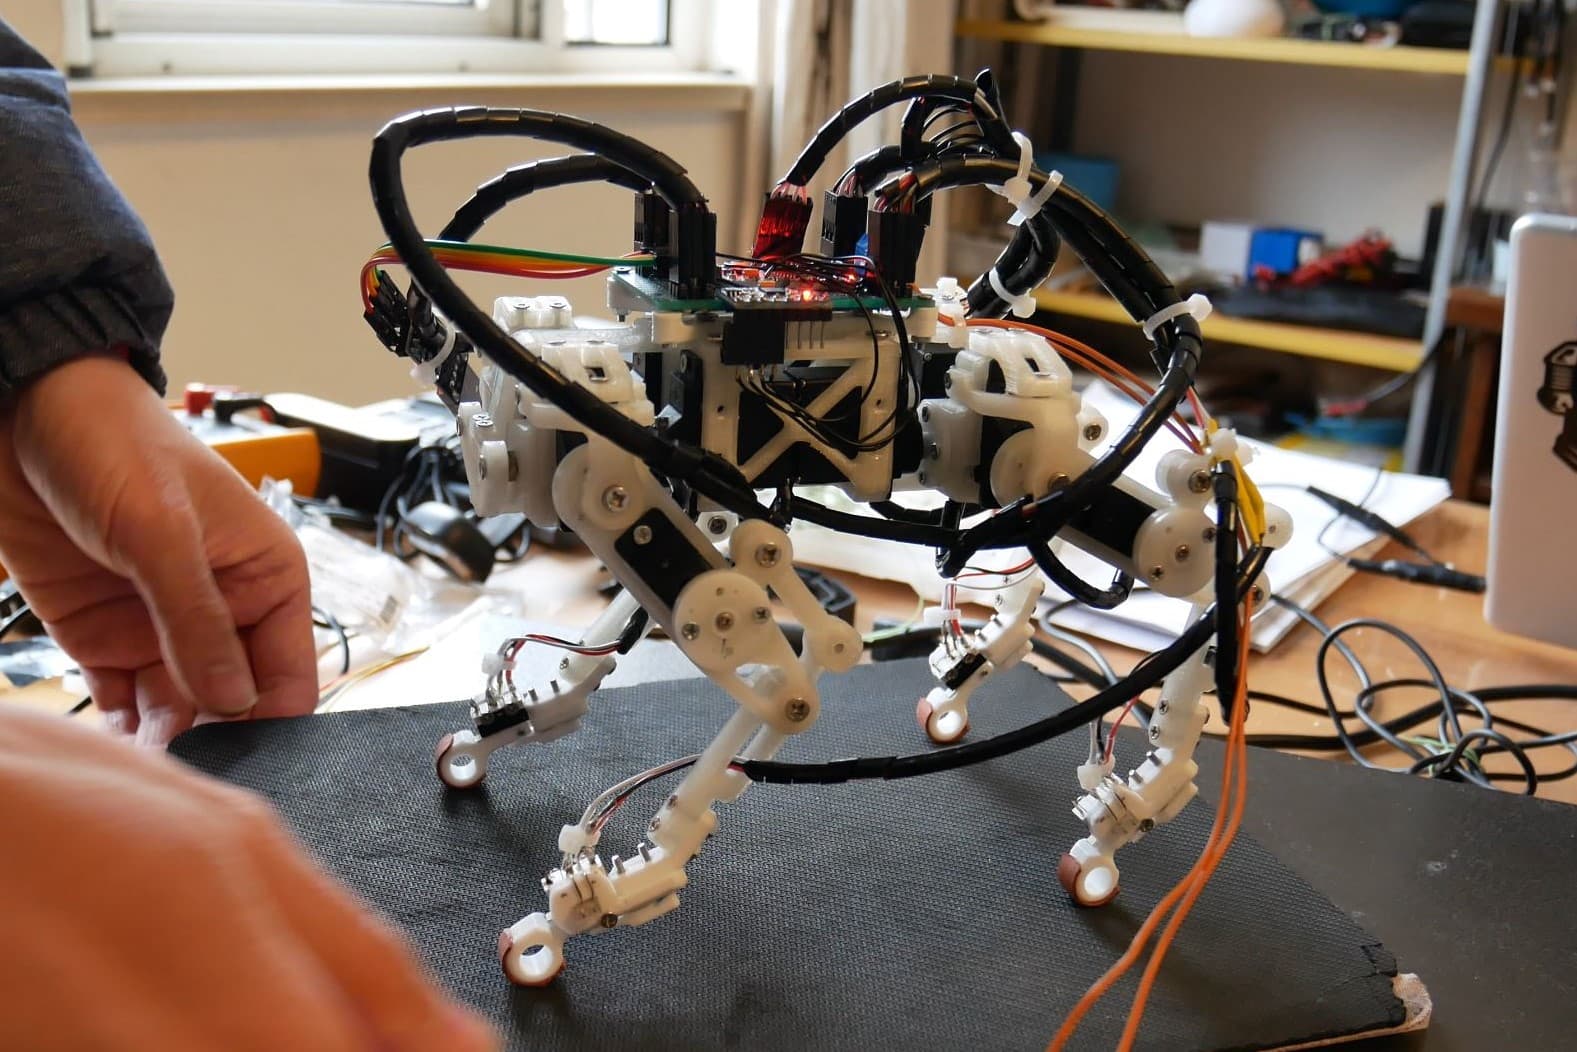
A low-cost 12-DOF quadruped robot actuated by hobby servos, with optional feet sensors and a trot gait firmware.
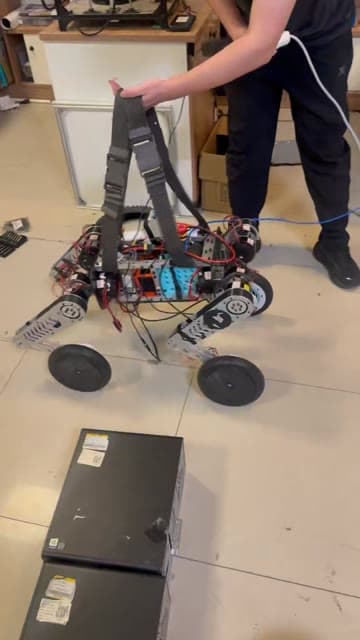
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
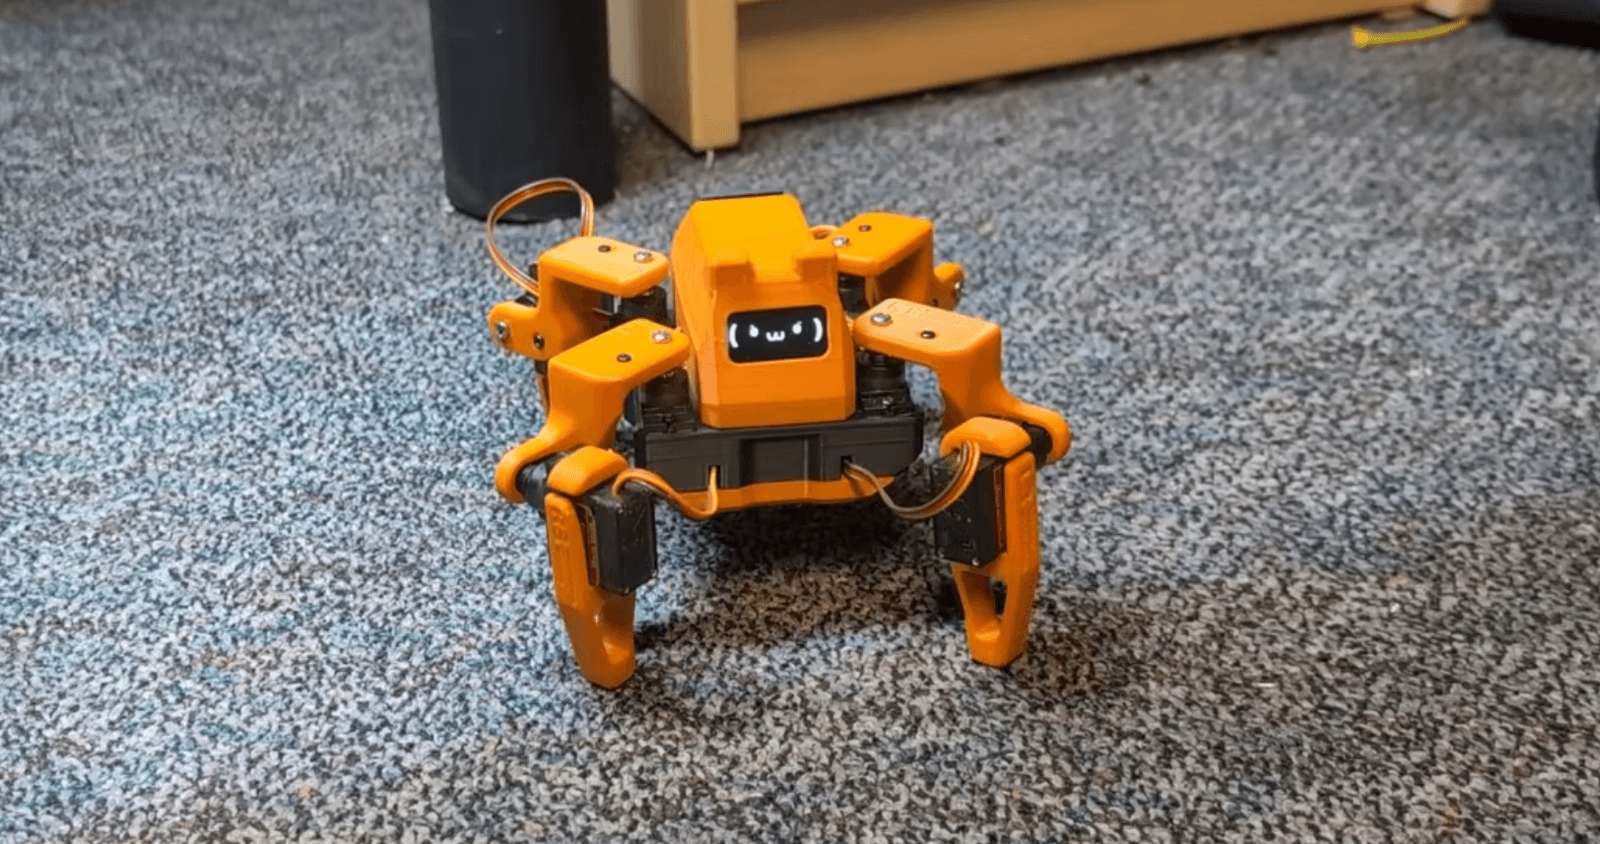
An open and affordable ESP32-based mini quadruped robot with an OLED face that walks, waves and dances.

A 7-DOF personal robotic arm with ROS-based simulation and control.

A safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
An open-source 6-DOF collaborative robotic arm system with mechanical structure, electronics, and software.
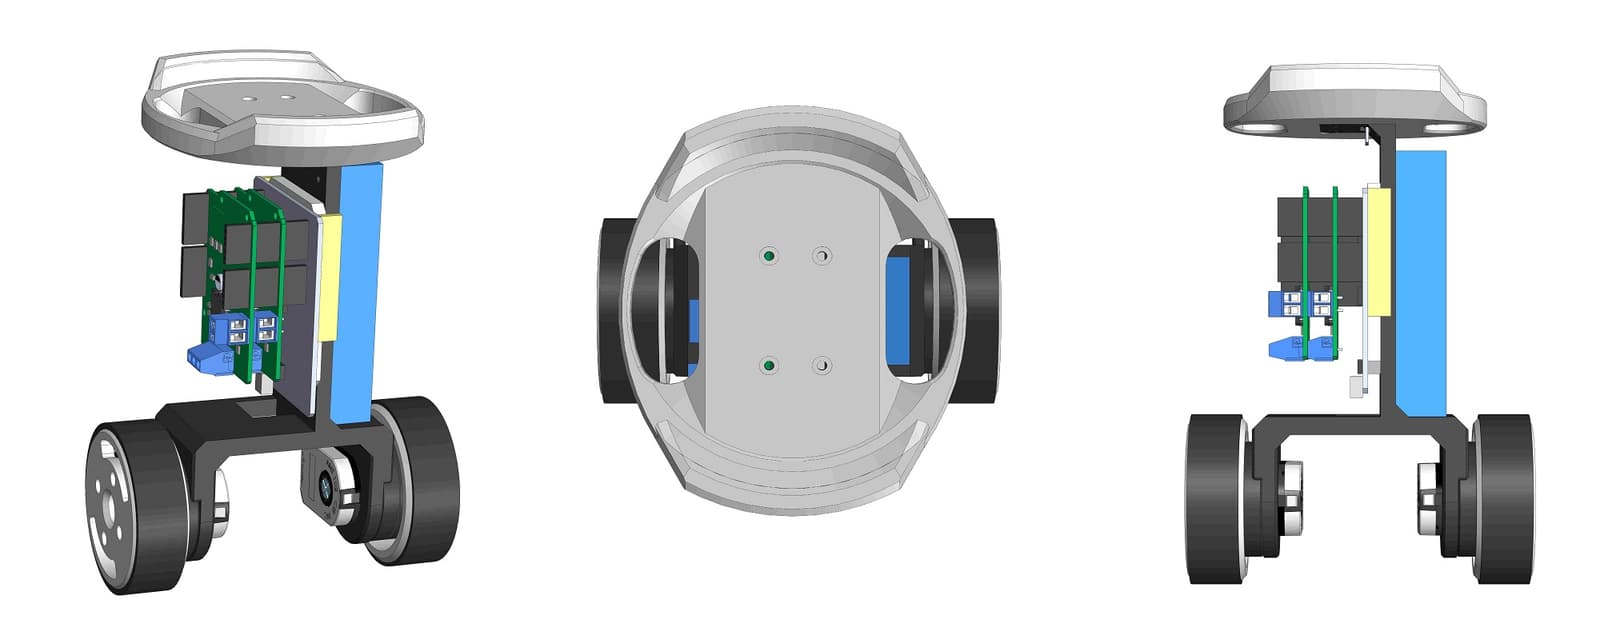
A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.
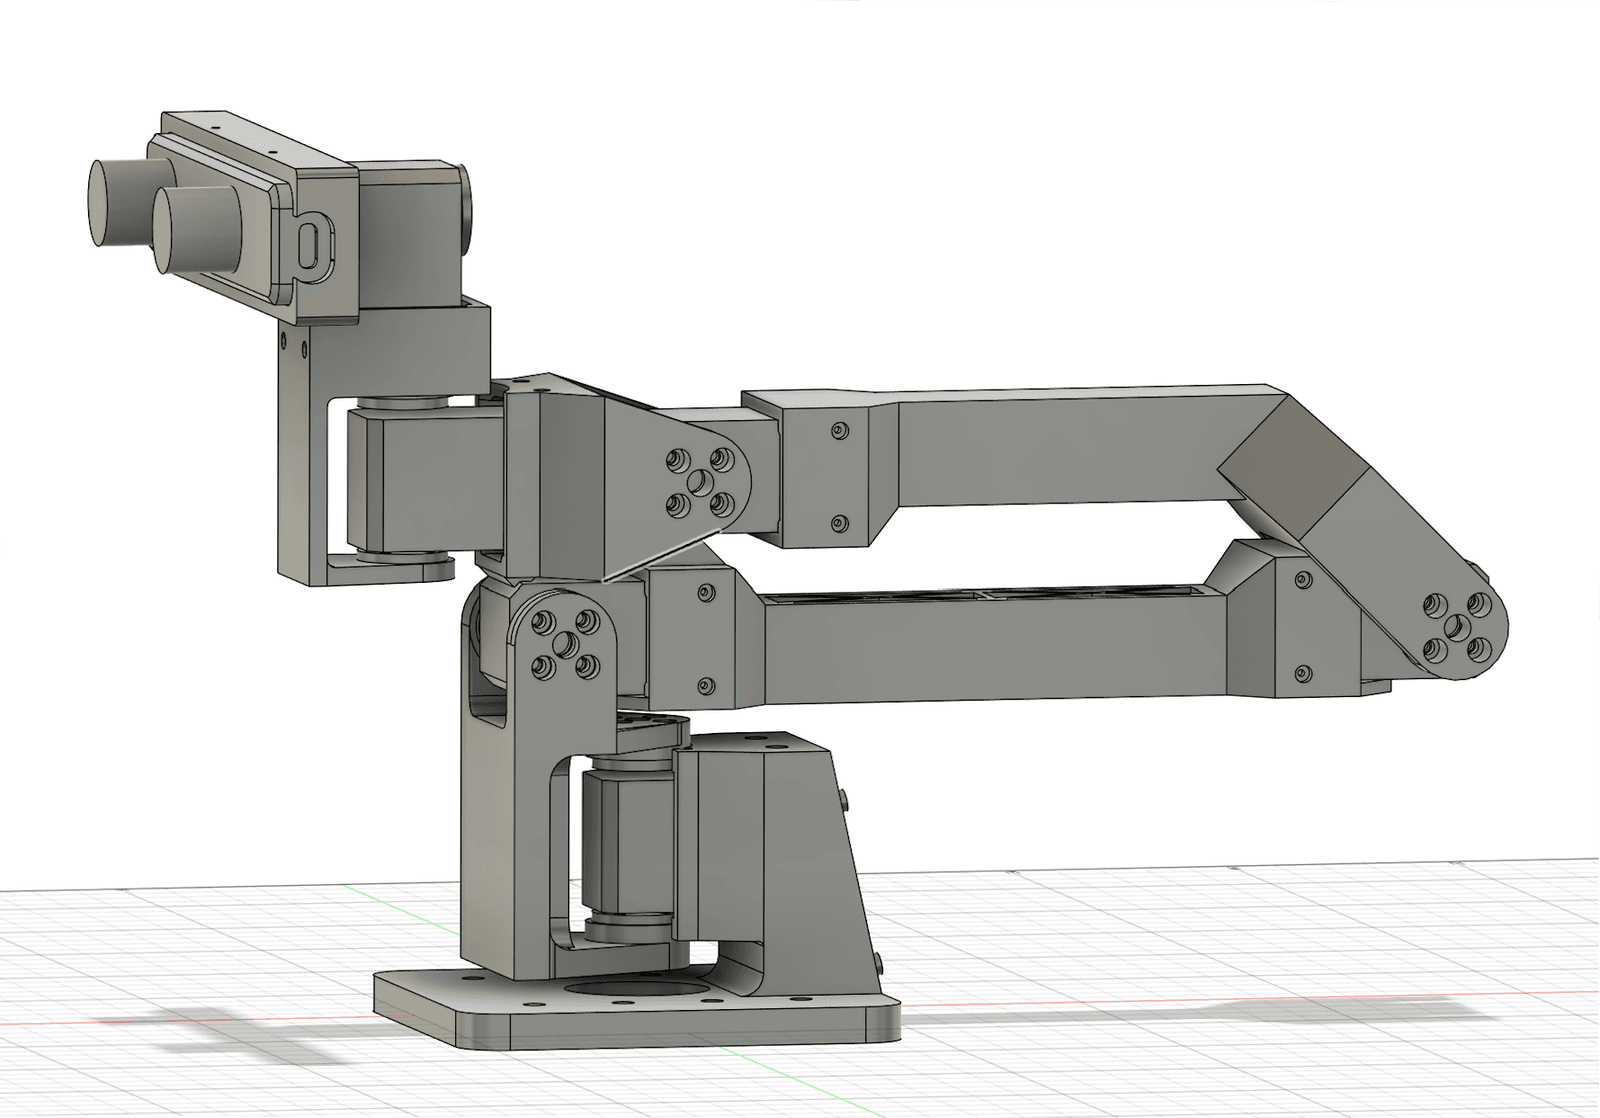
A 6-DOF camera arm with a ZED Mini stereo camera that streams video to a WebXR VR headset and follows head tracking for teleoperation.
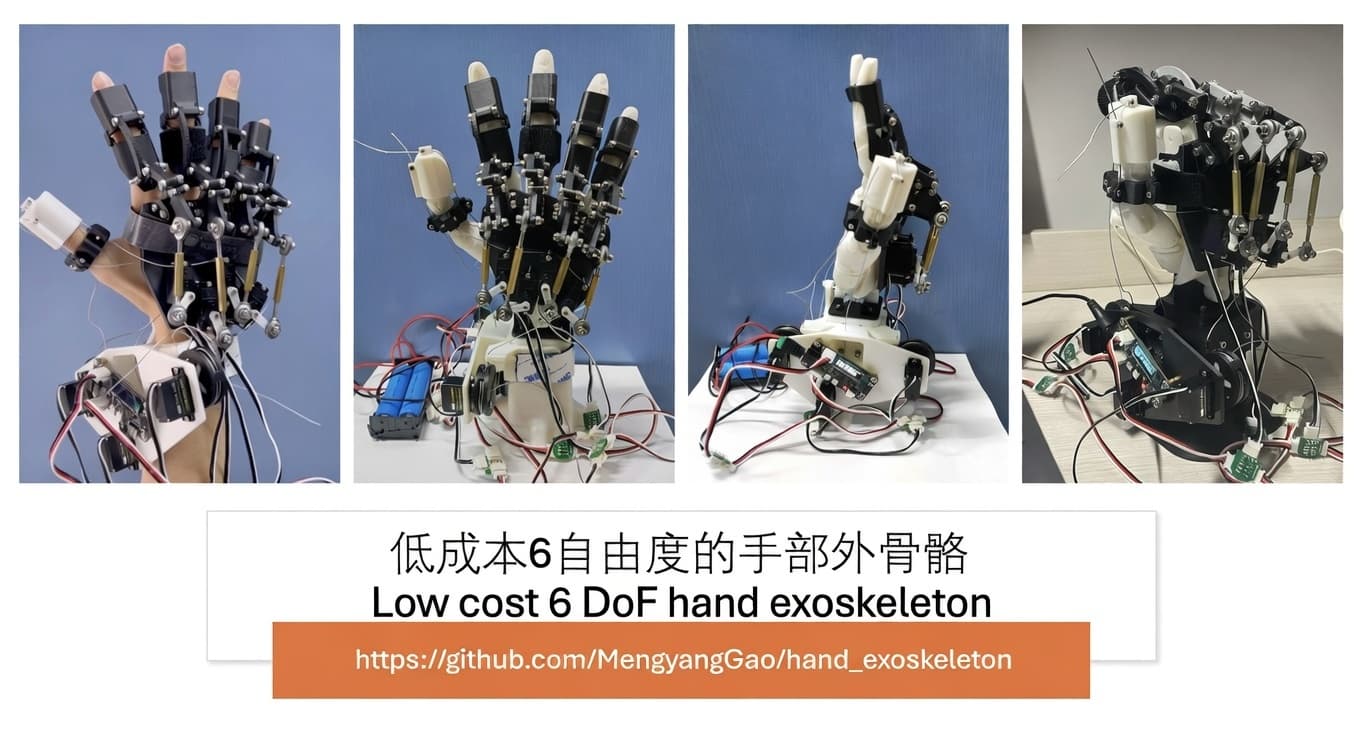
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
An open-source desktop quadruped robot featuring high-torque HTDW4438 motors, URDF models, and real-machine SDK for development and Sim2Real integration.
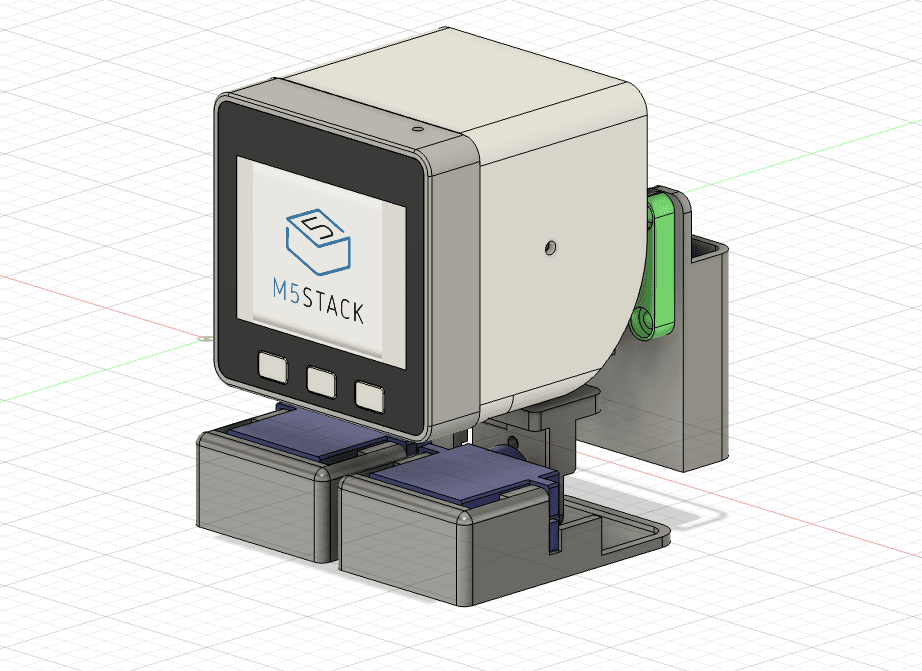
A small bipedal walking robot controlled by an M5Stack board, with a sliding battery that shifts its balance between legs.
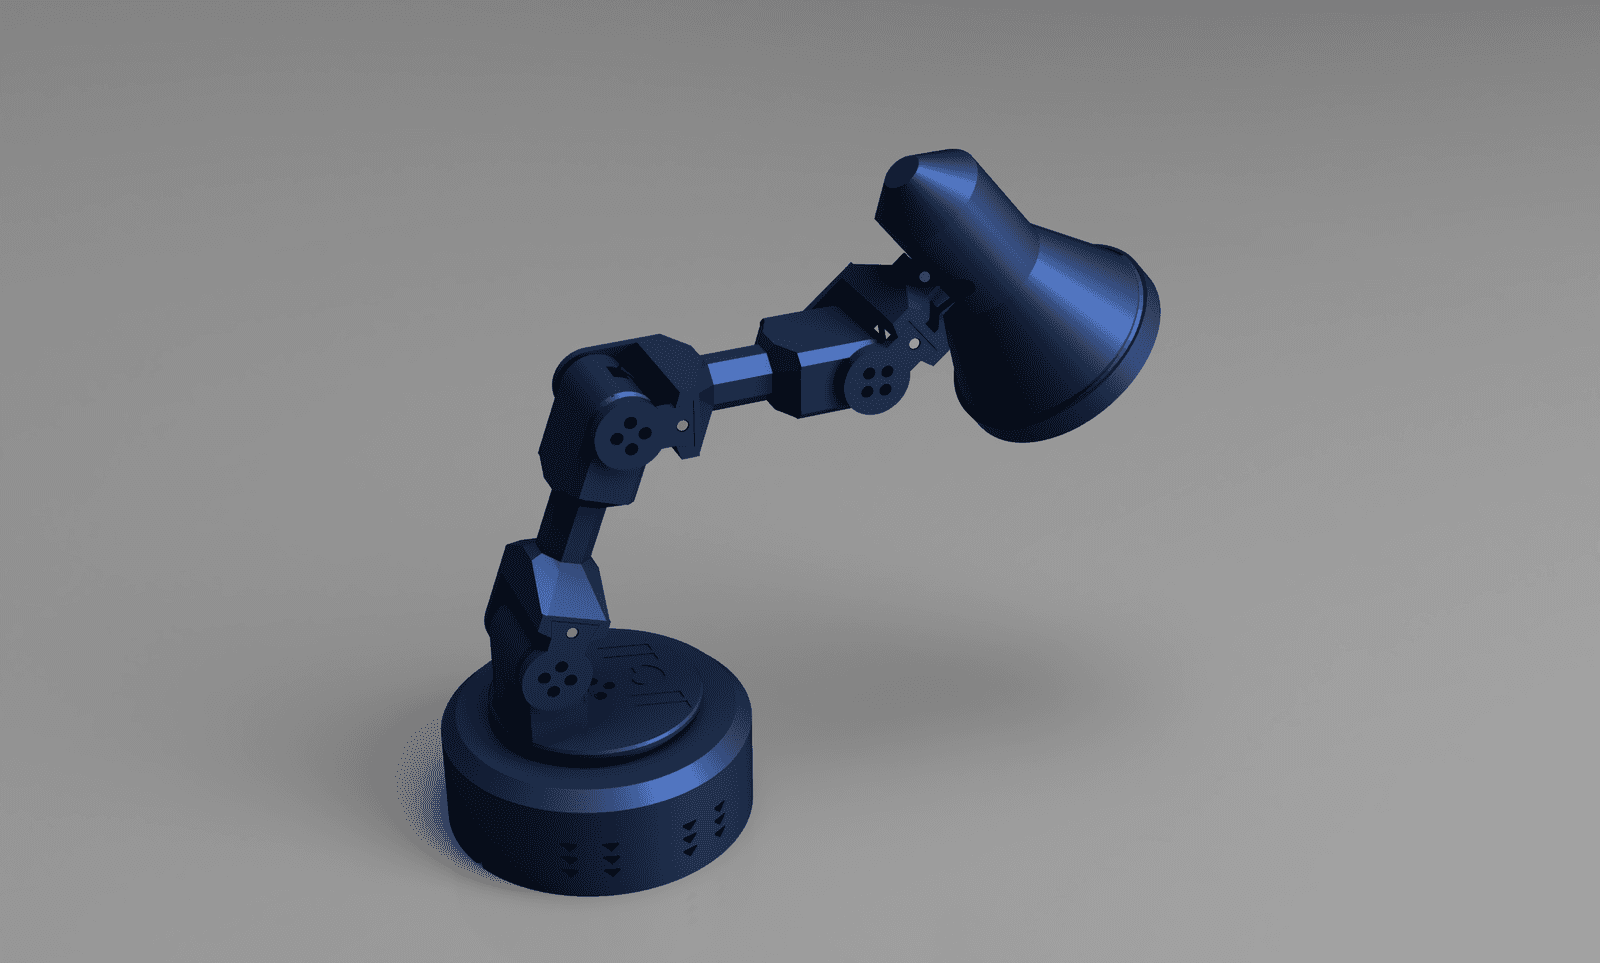
NormaCore is a unified open-source toolkit and platform for developing and operating physical systems, including a 7+1 DoF 3D-printed robotic arm (ElRobot) and a desk lamp.
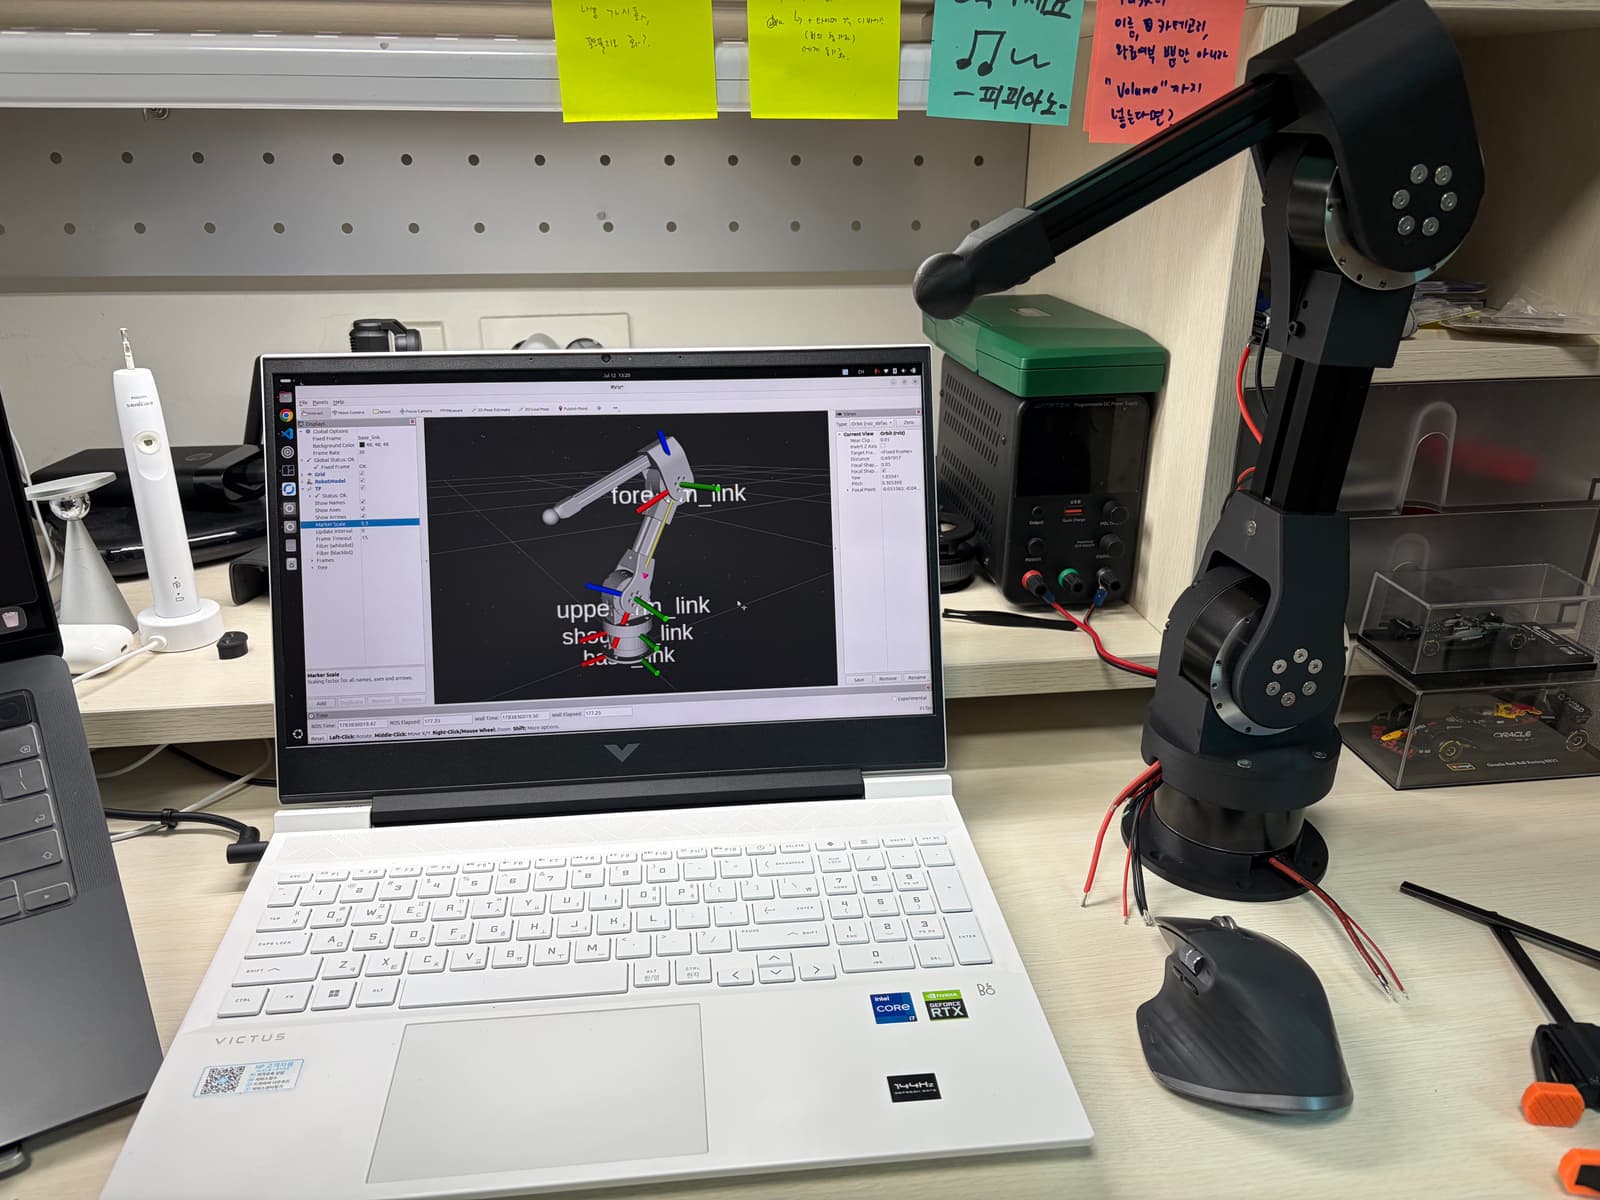
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
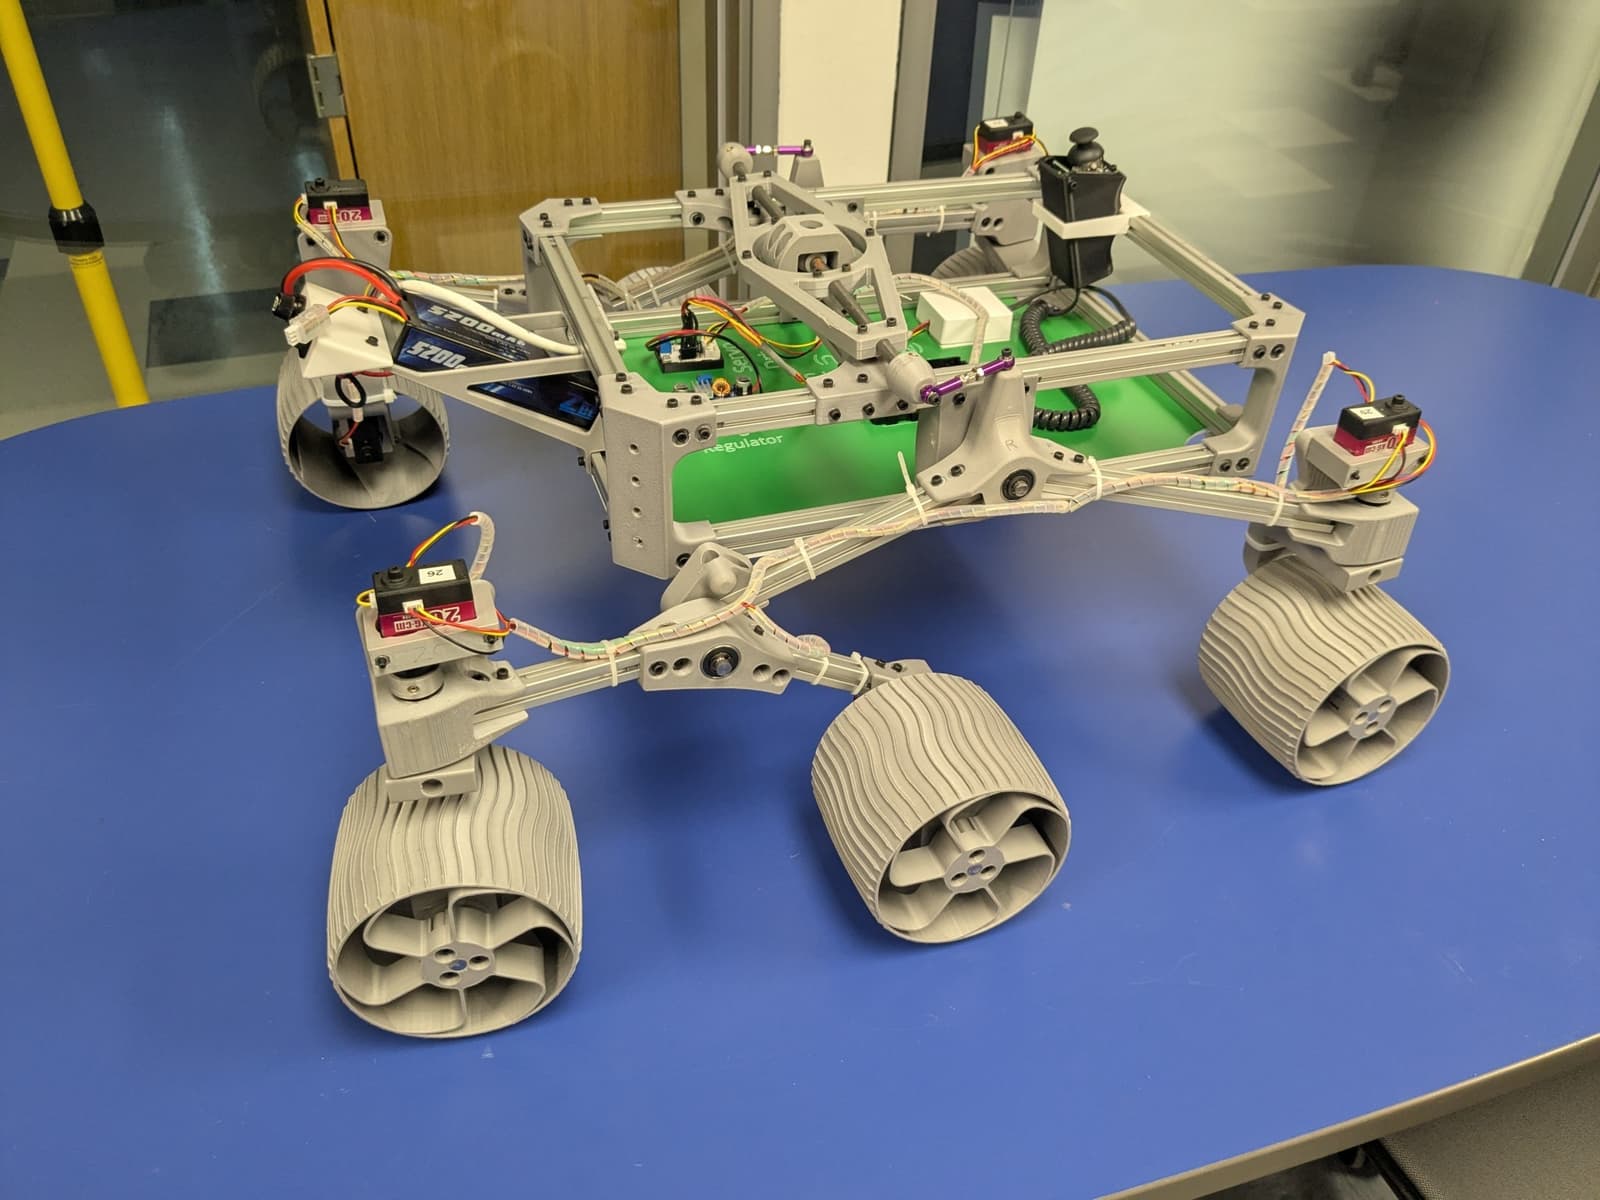
A motorized model of Mars rovers Curiosity and Perseverance that reproduces Rocker-Bogie suspension, built with 3D-printed parts and serial bus servo wheels.
A self-balancing robot car driven by two BLDC motors using the SimpleFOC library and ESP32 microcontroller.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
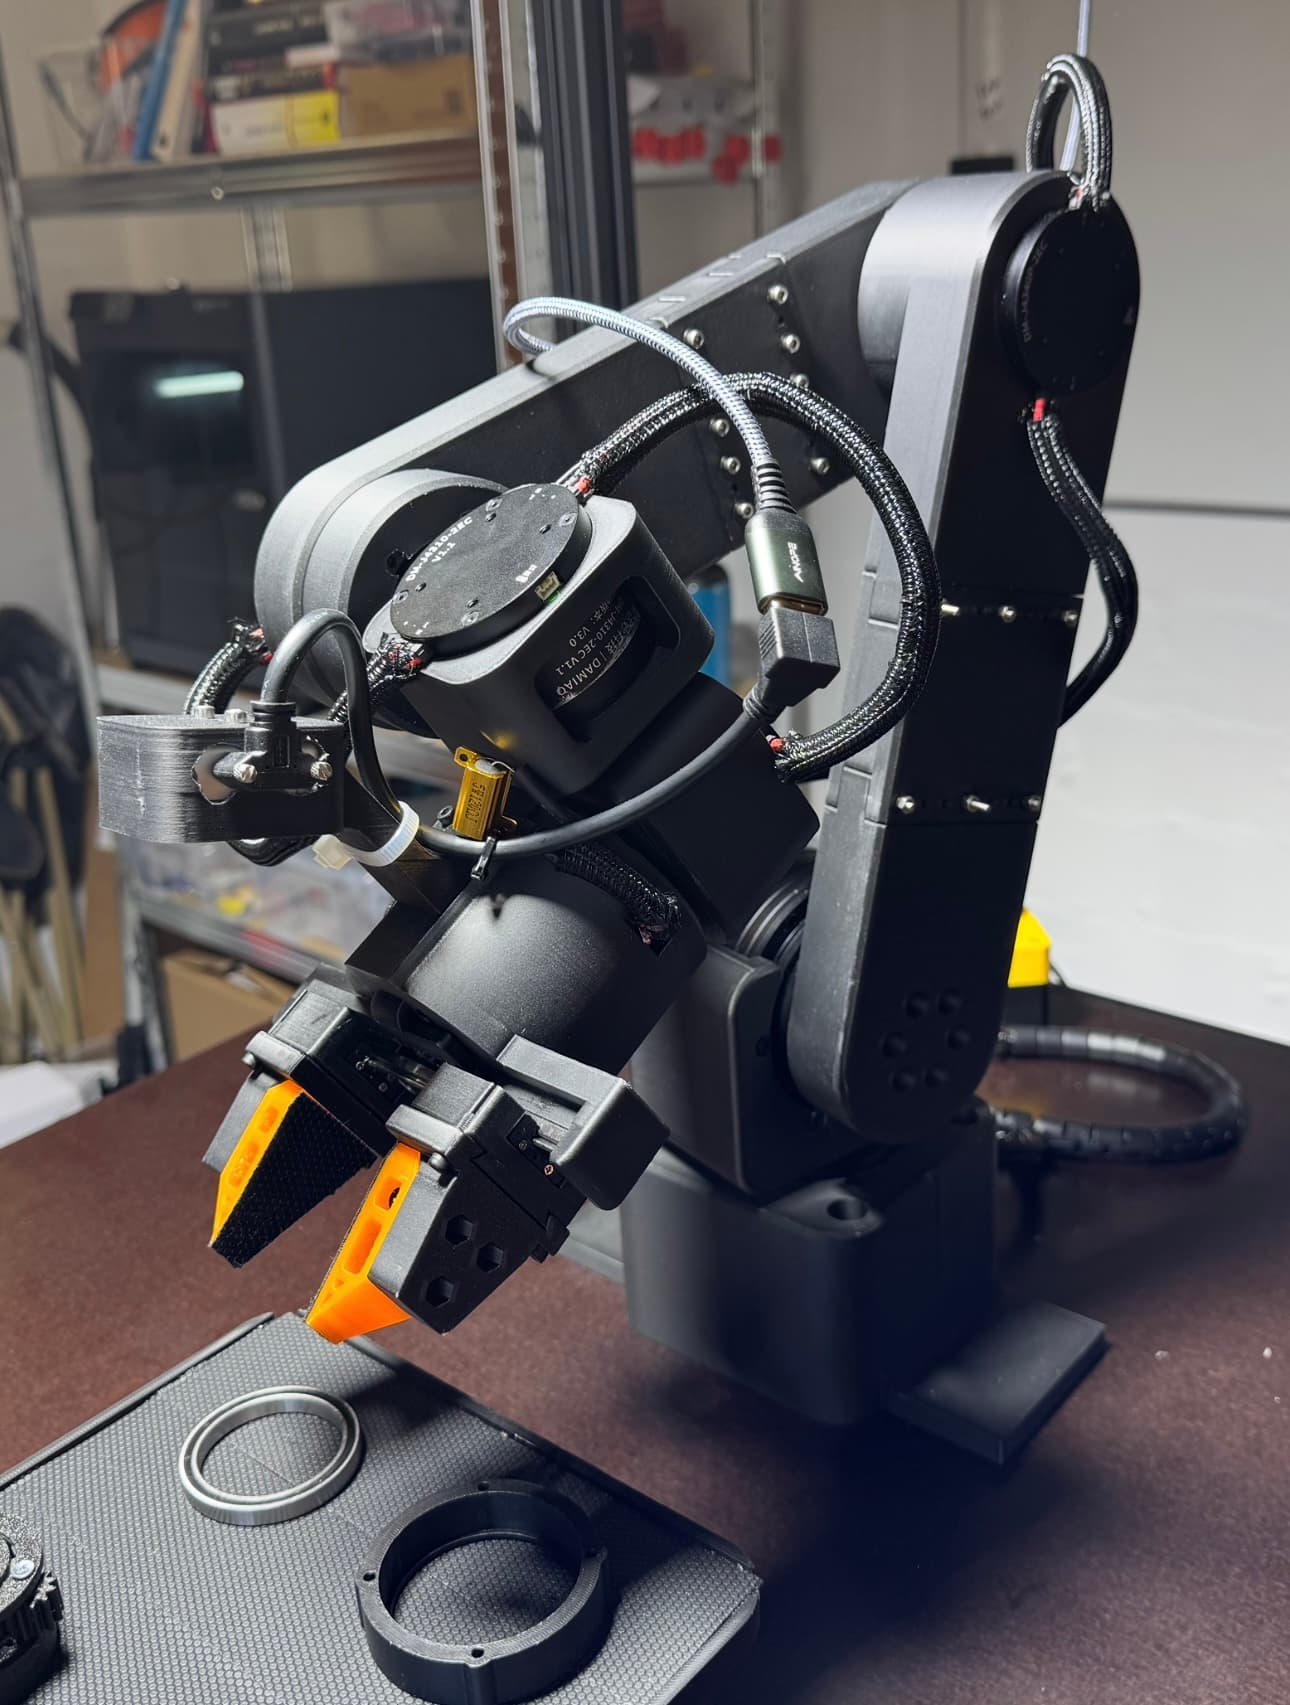
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
Robots 25–48 of 197