Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

24 robots of 270

Page 1 of 1 · Ready to build first, then by buildability

  • Other

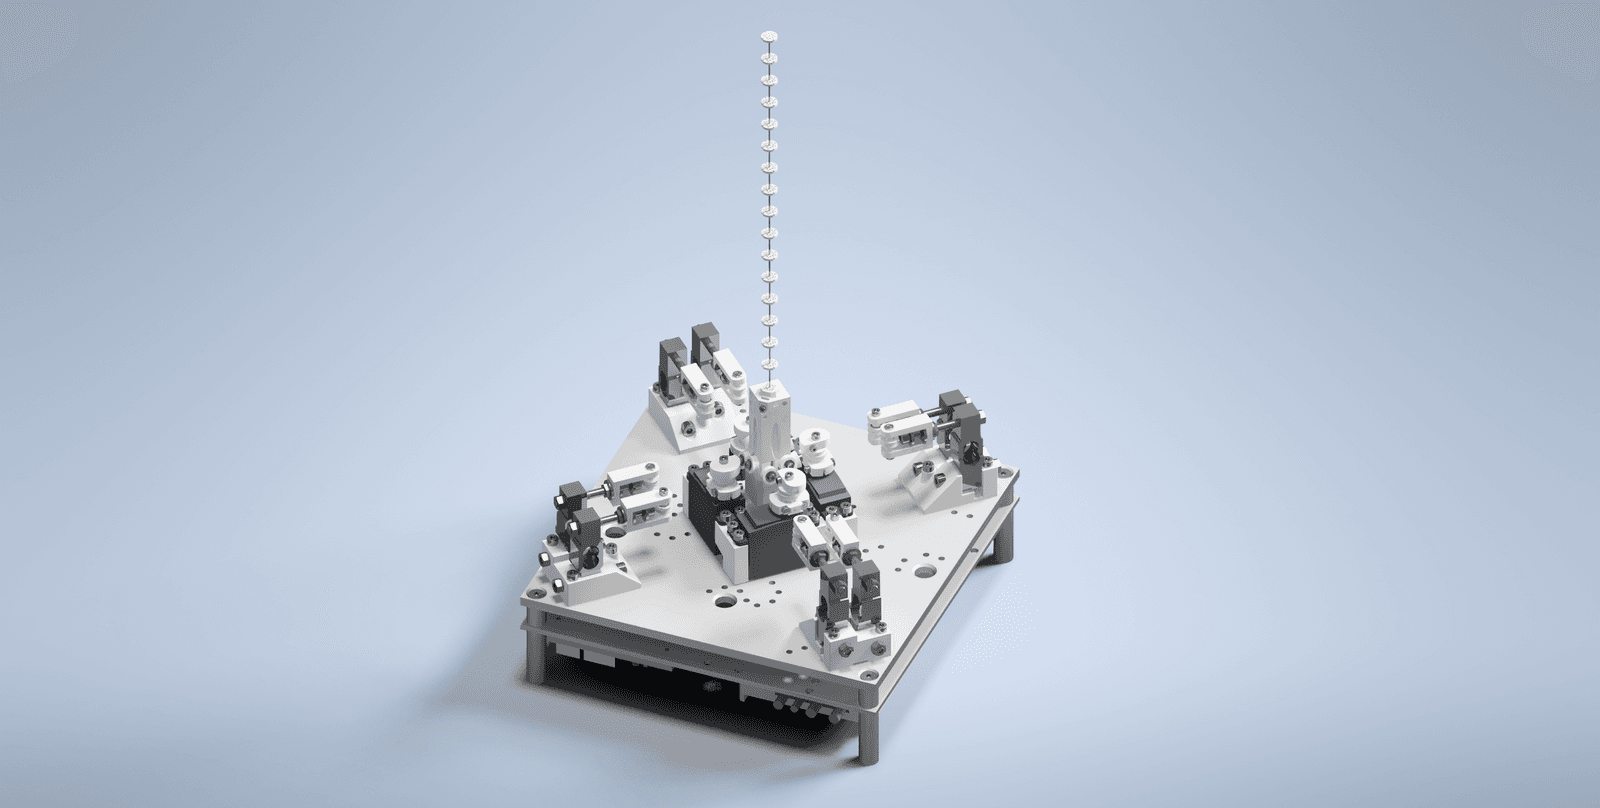
    Koriobots

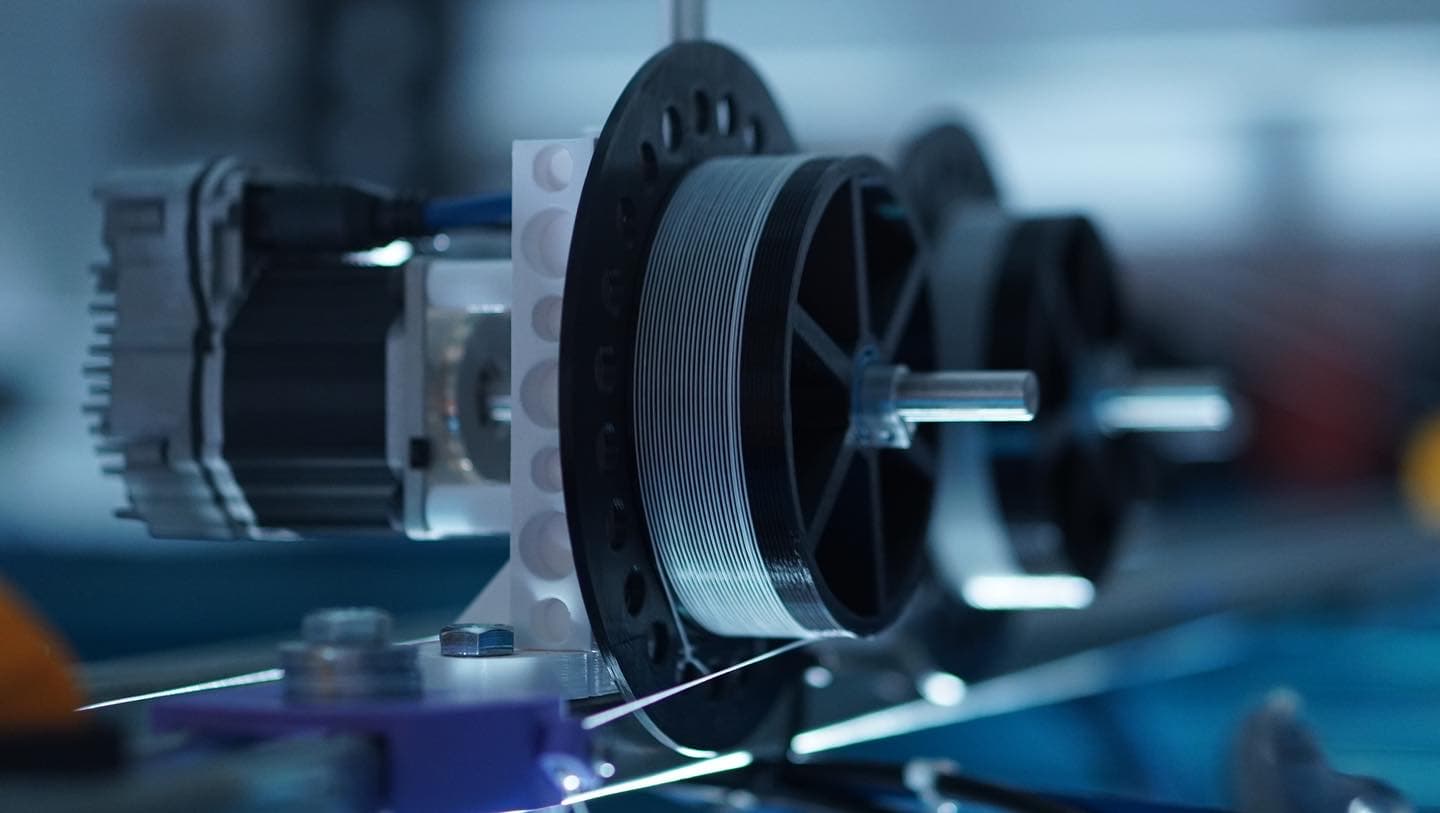
    A toolkit for cable-driven robots that move objects through the air, built from 3D-printed cable drums on industrial servo motors, made for art installations.

    Level
    Intermediate
    Buildability
    78/100
    Buildable with some effort
    Cost
    $972.06≈ €868 (ECB rate, 14 Oct 2026)
  • Other

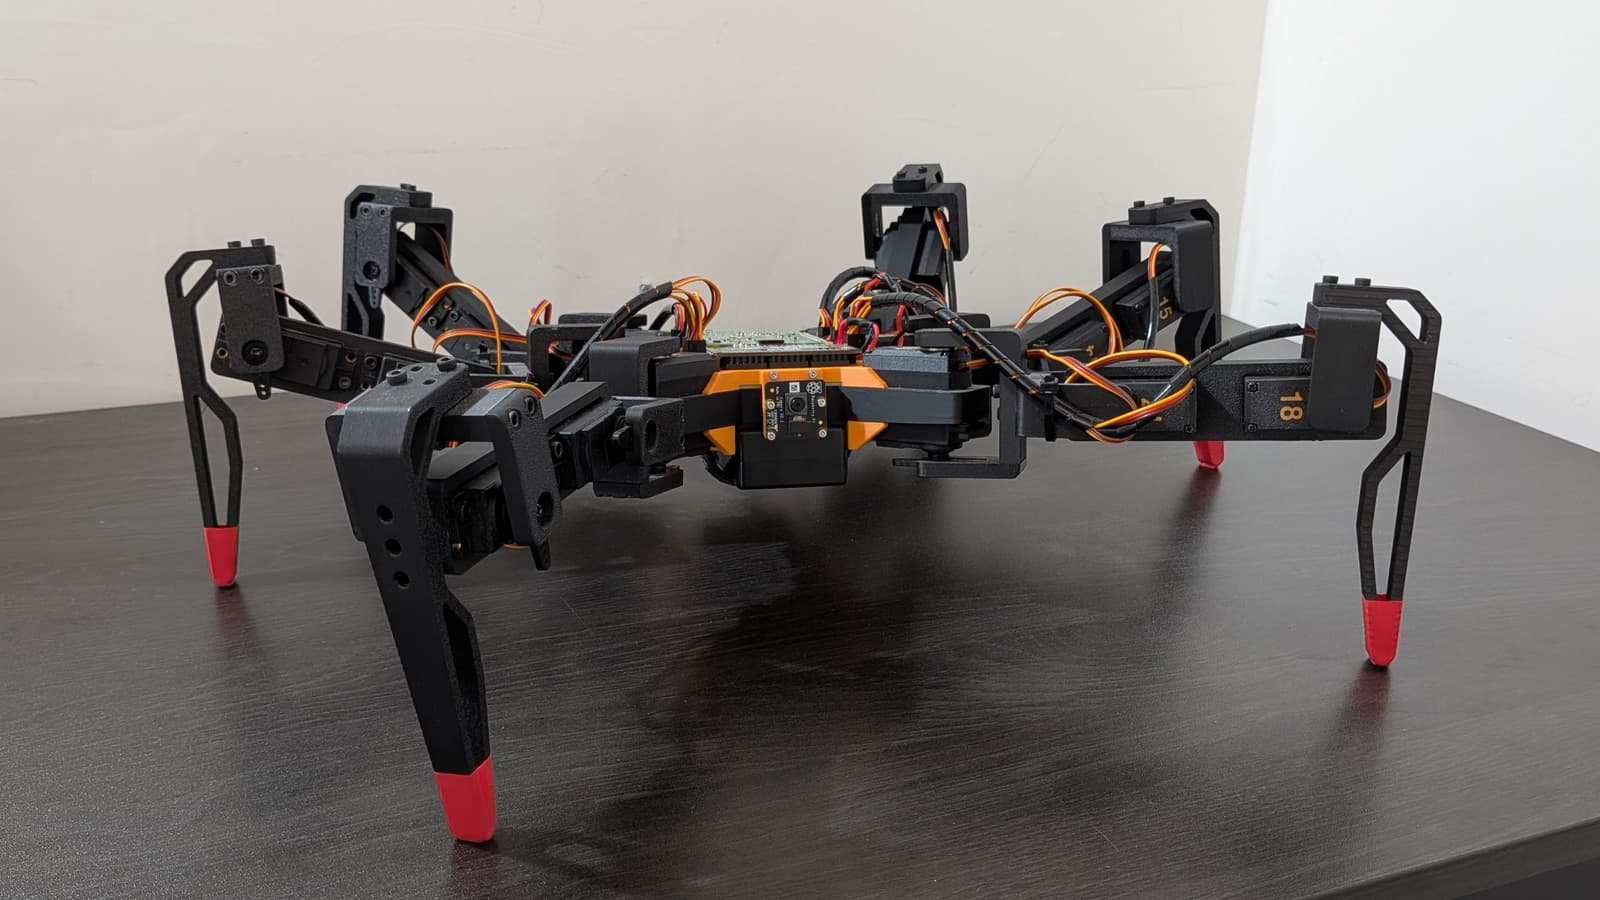
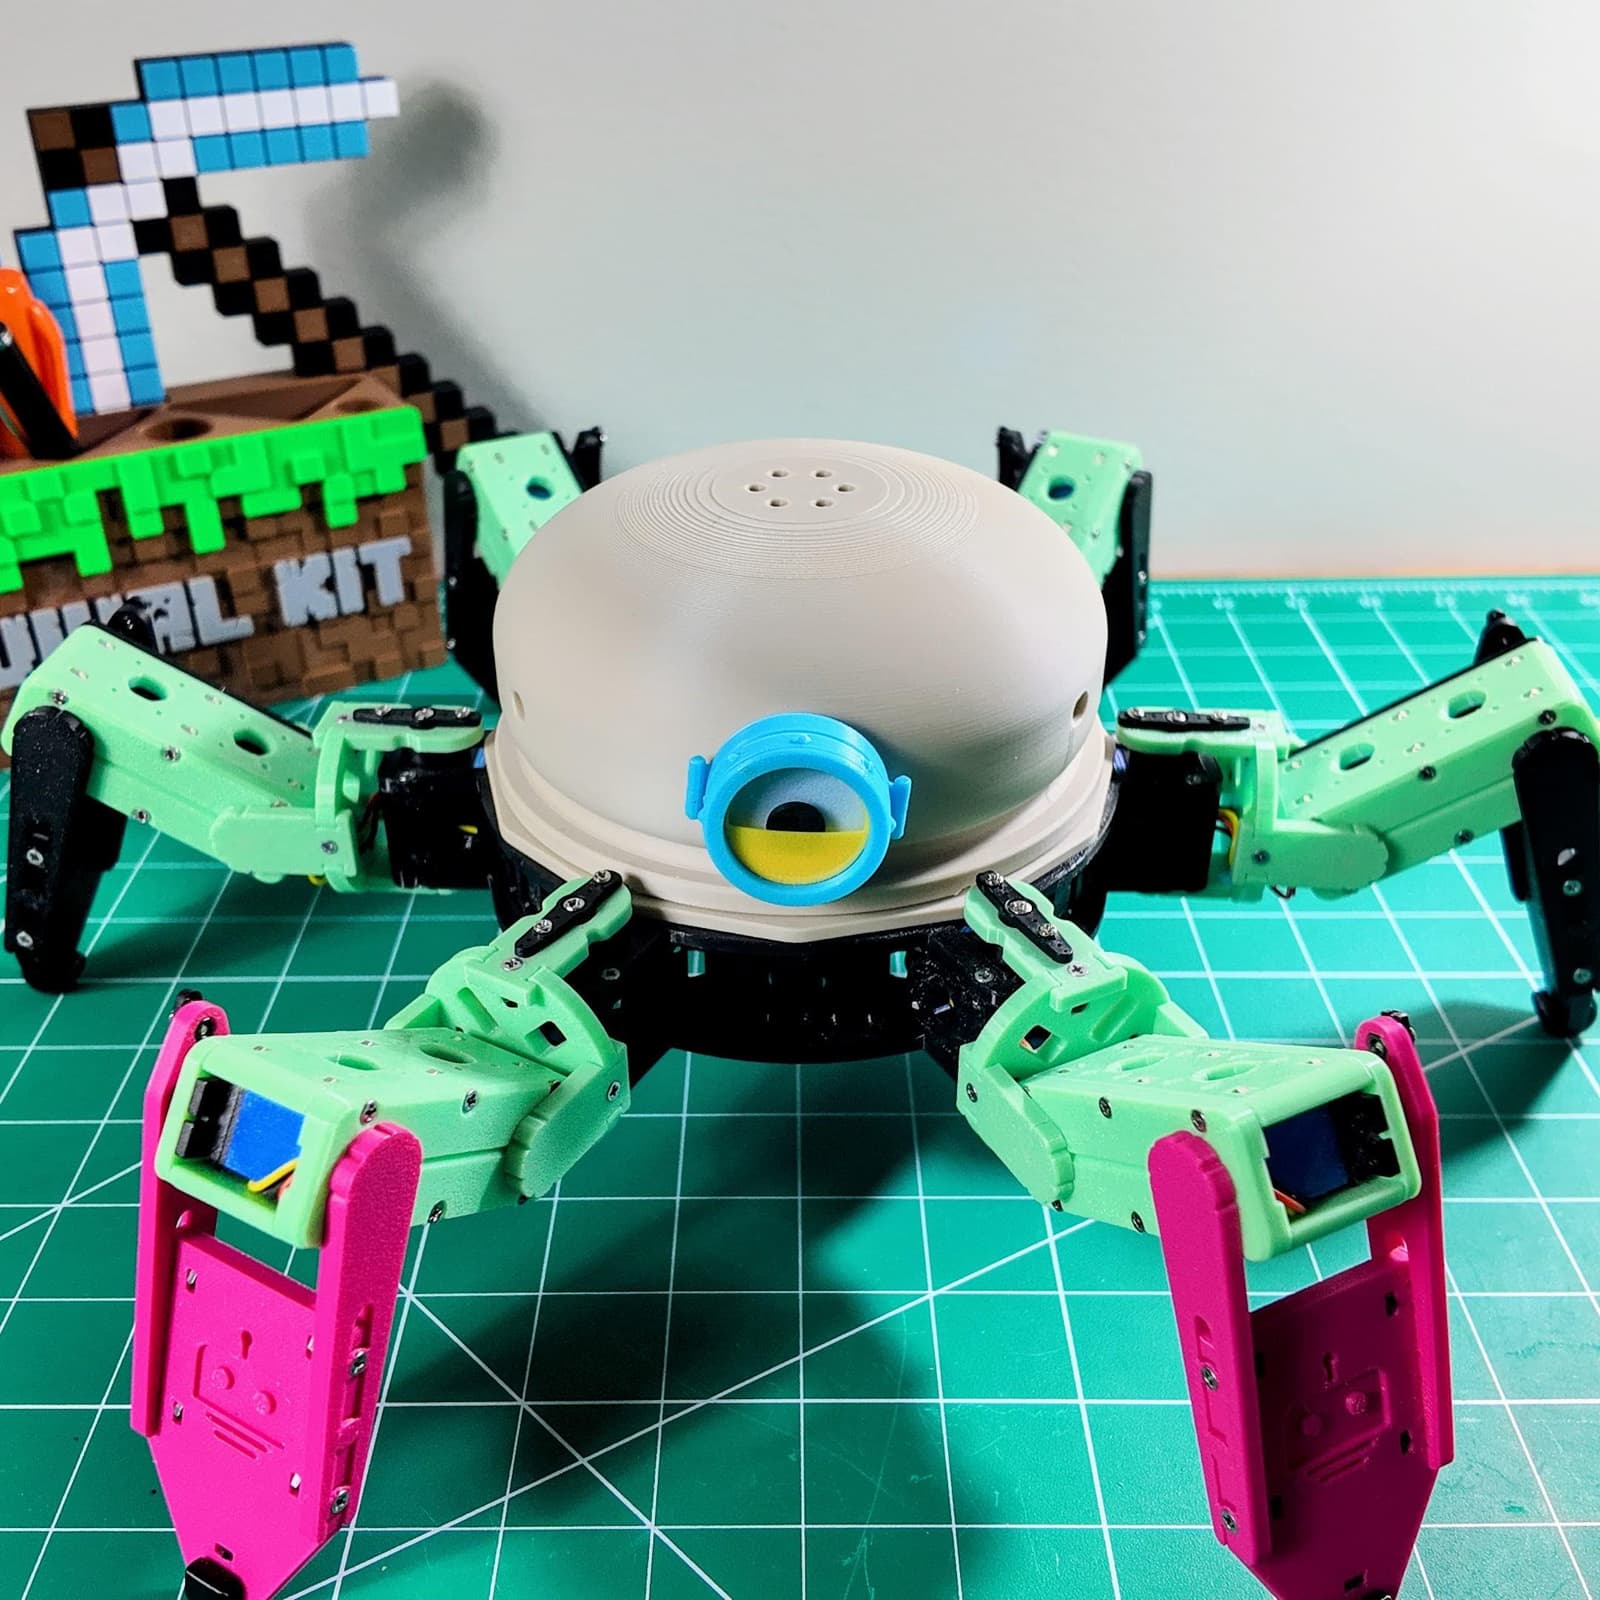
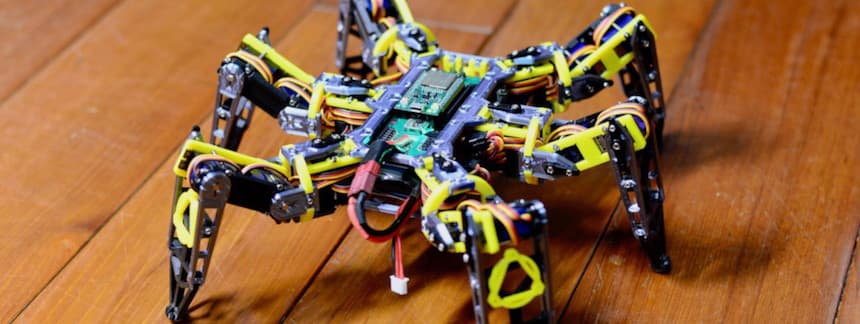
    Hexapod

    A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.

    Level
    Advanced
    Buildability
    71/100
    Buildable with some effort
    Cost
    €280
  • Other

    Balancio-Kit

    An ultra-low-cost self-balancing robot that can run a neural network to stay balanced and be controlled wirelessly, built for teaching RL, ML, AI and control.

    • Works with AI
    Level
    Intermediate
    Buildability
    65/100
    Buildable with some effort
    Cost
    Not stated
  • Other

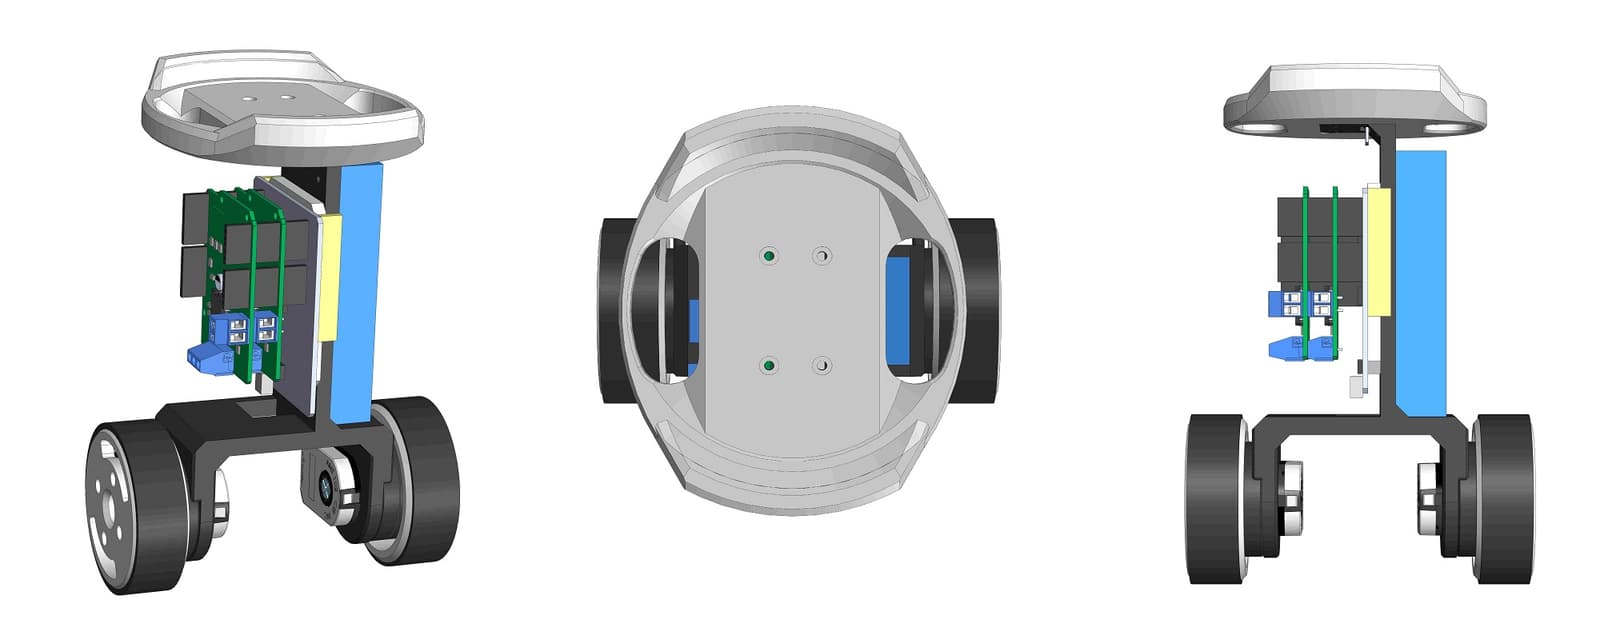
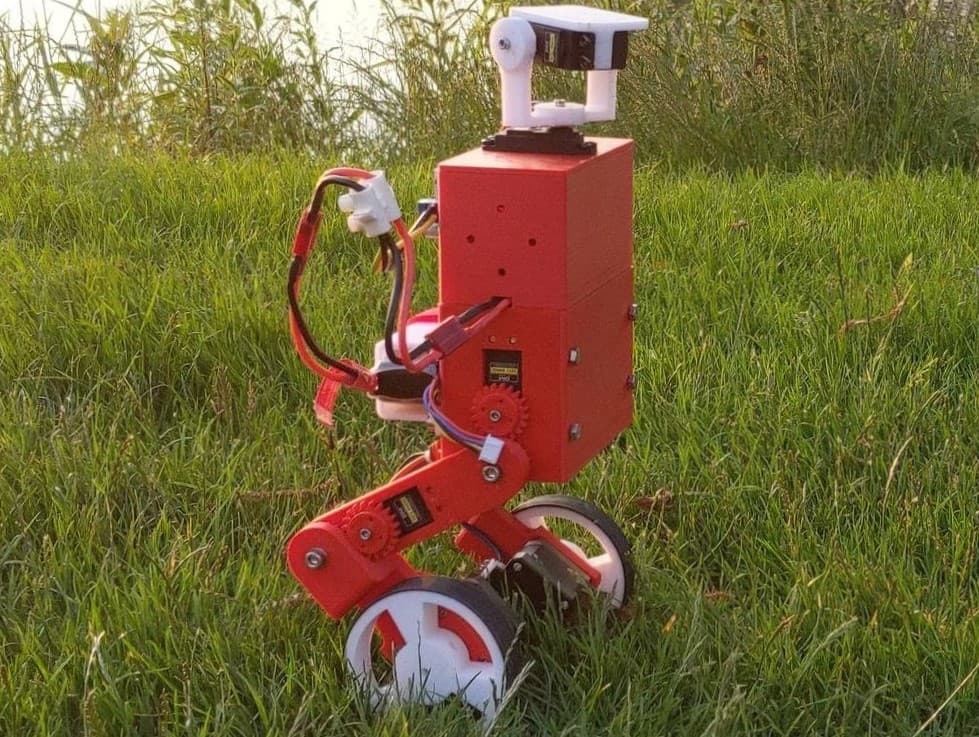
    Arduino SimpleFOC Balancer

    A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.

    Level
    Advanced
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • Other

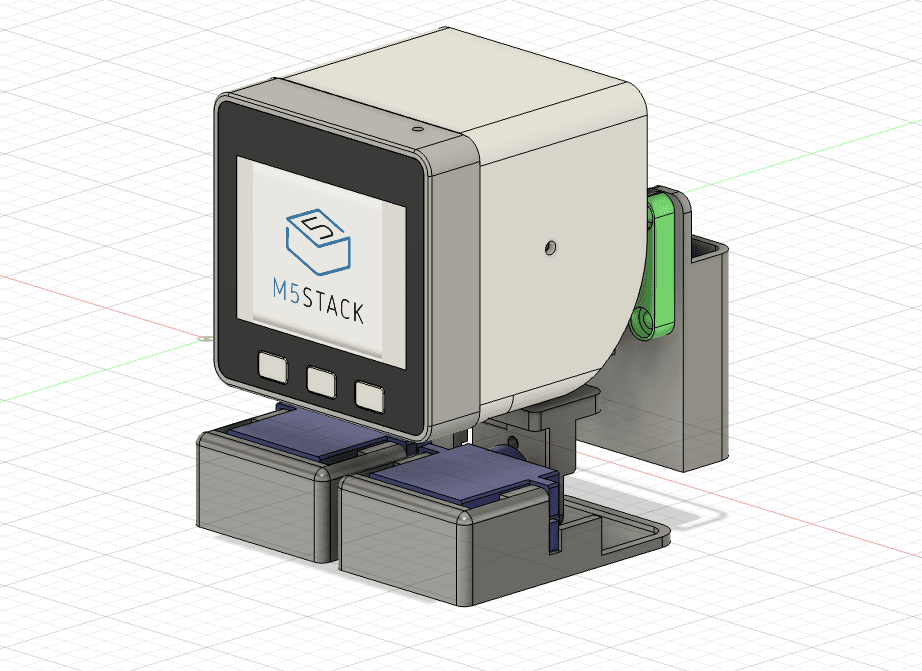
    M5Stack Walk-chan

    A small bipedal walking robot controlled by an M5Stack board, with a sliding battery that shifts its balance between legs.

    Level
    Intermediate
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Balance Ball

    A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Other

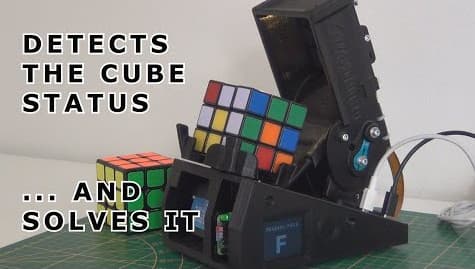
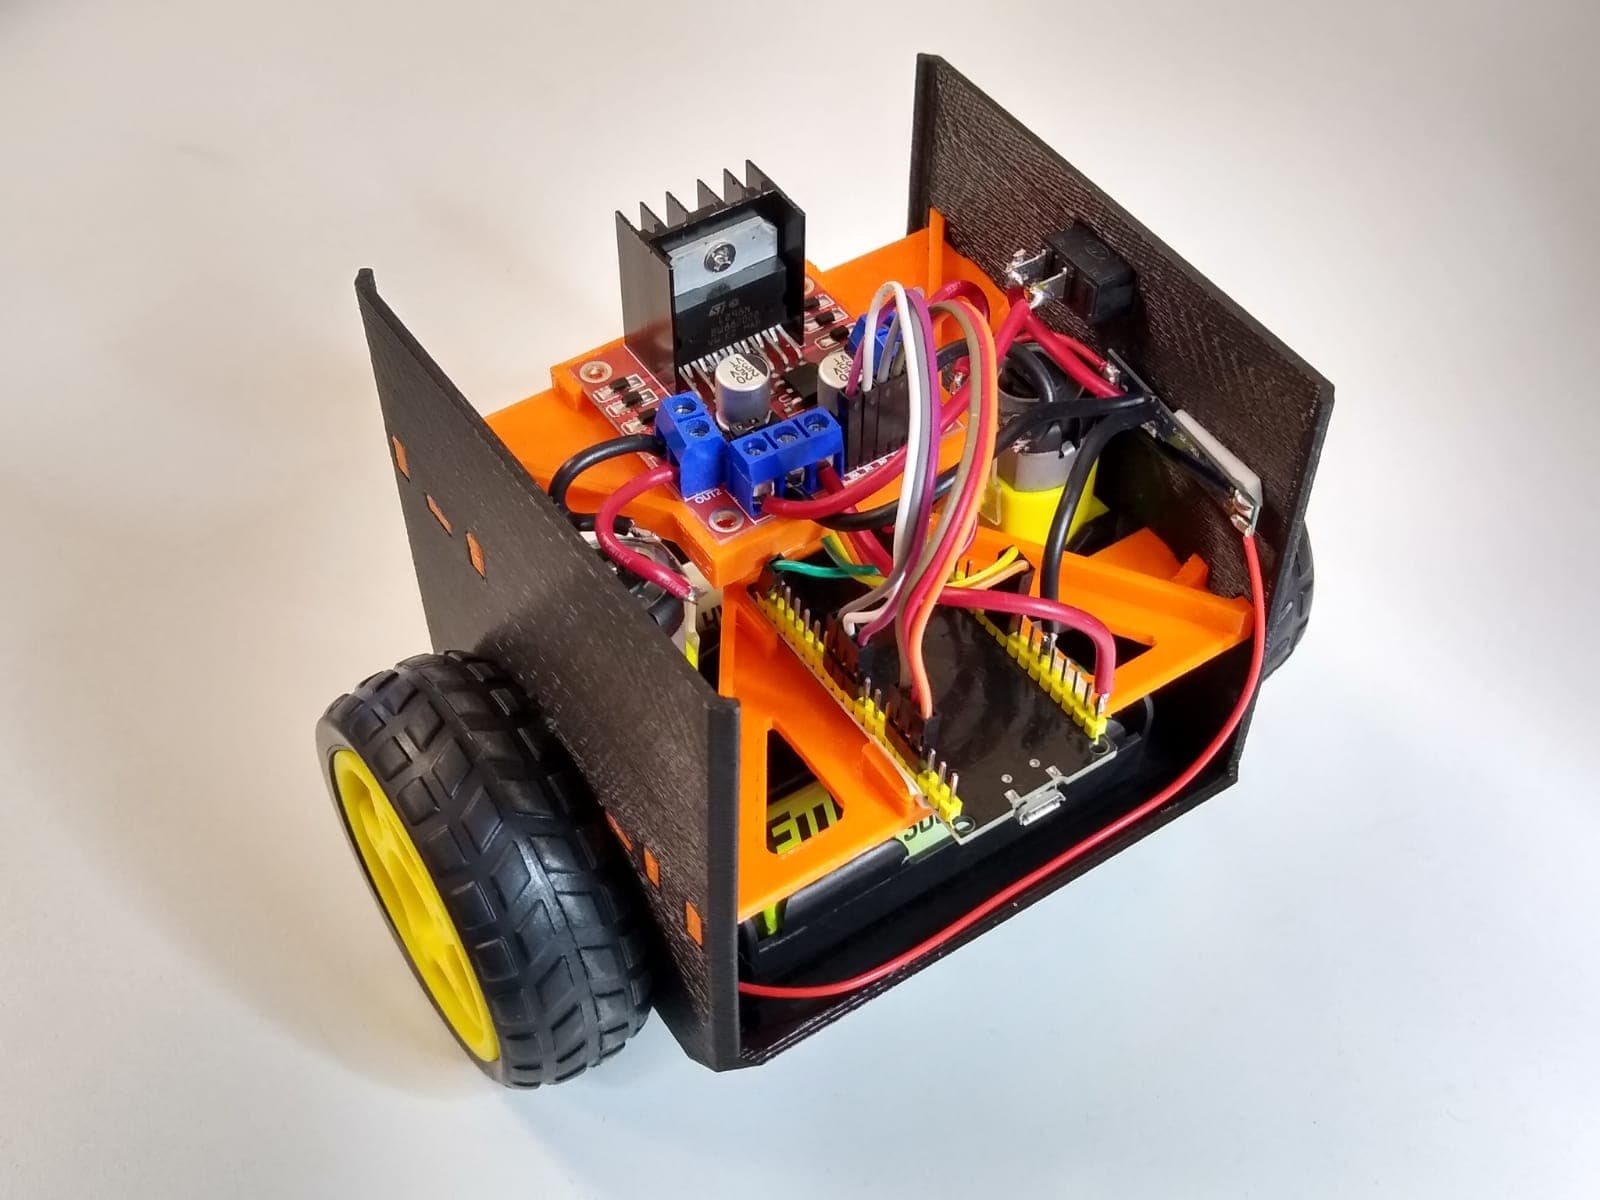
    CUBOTino autonomous

    A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.

    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

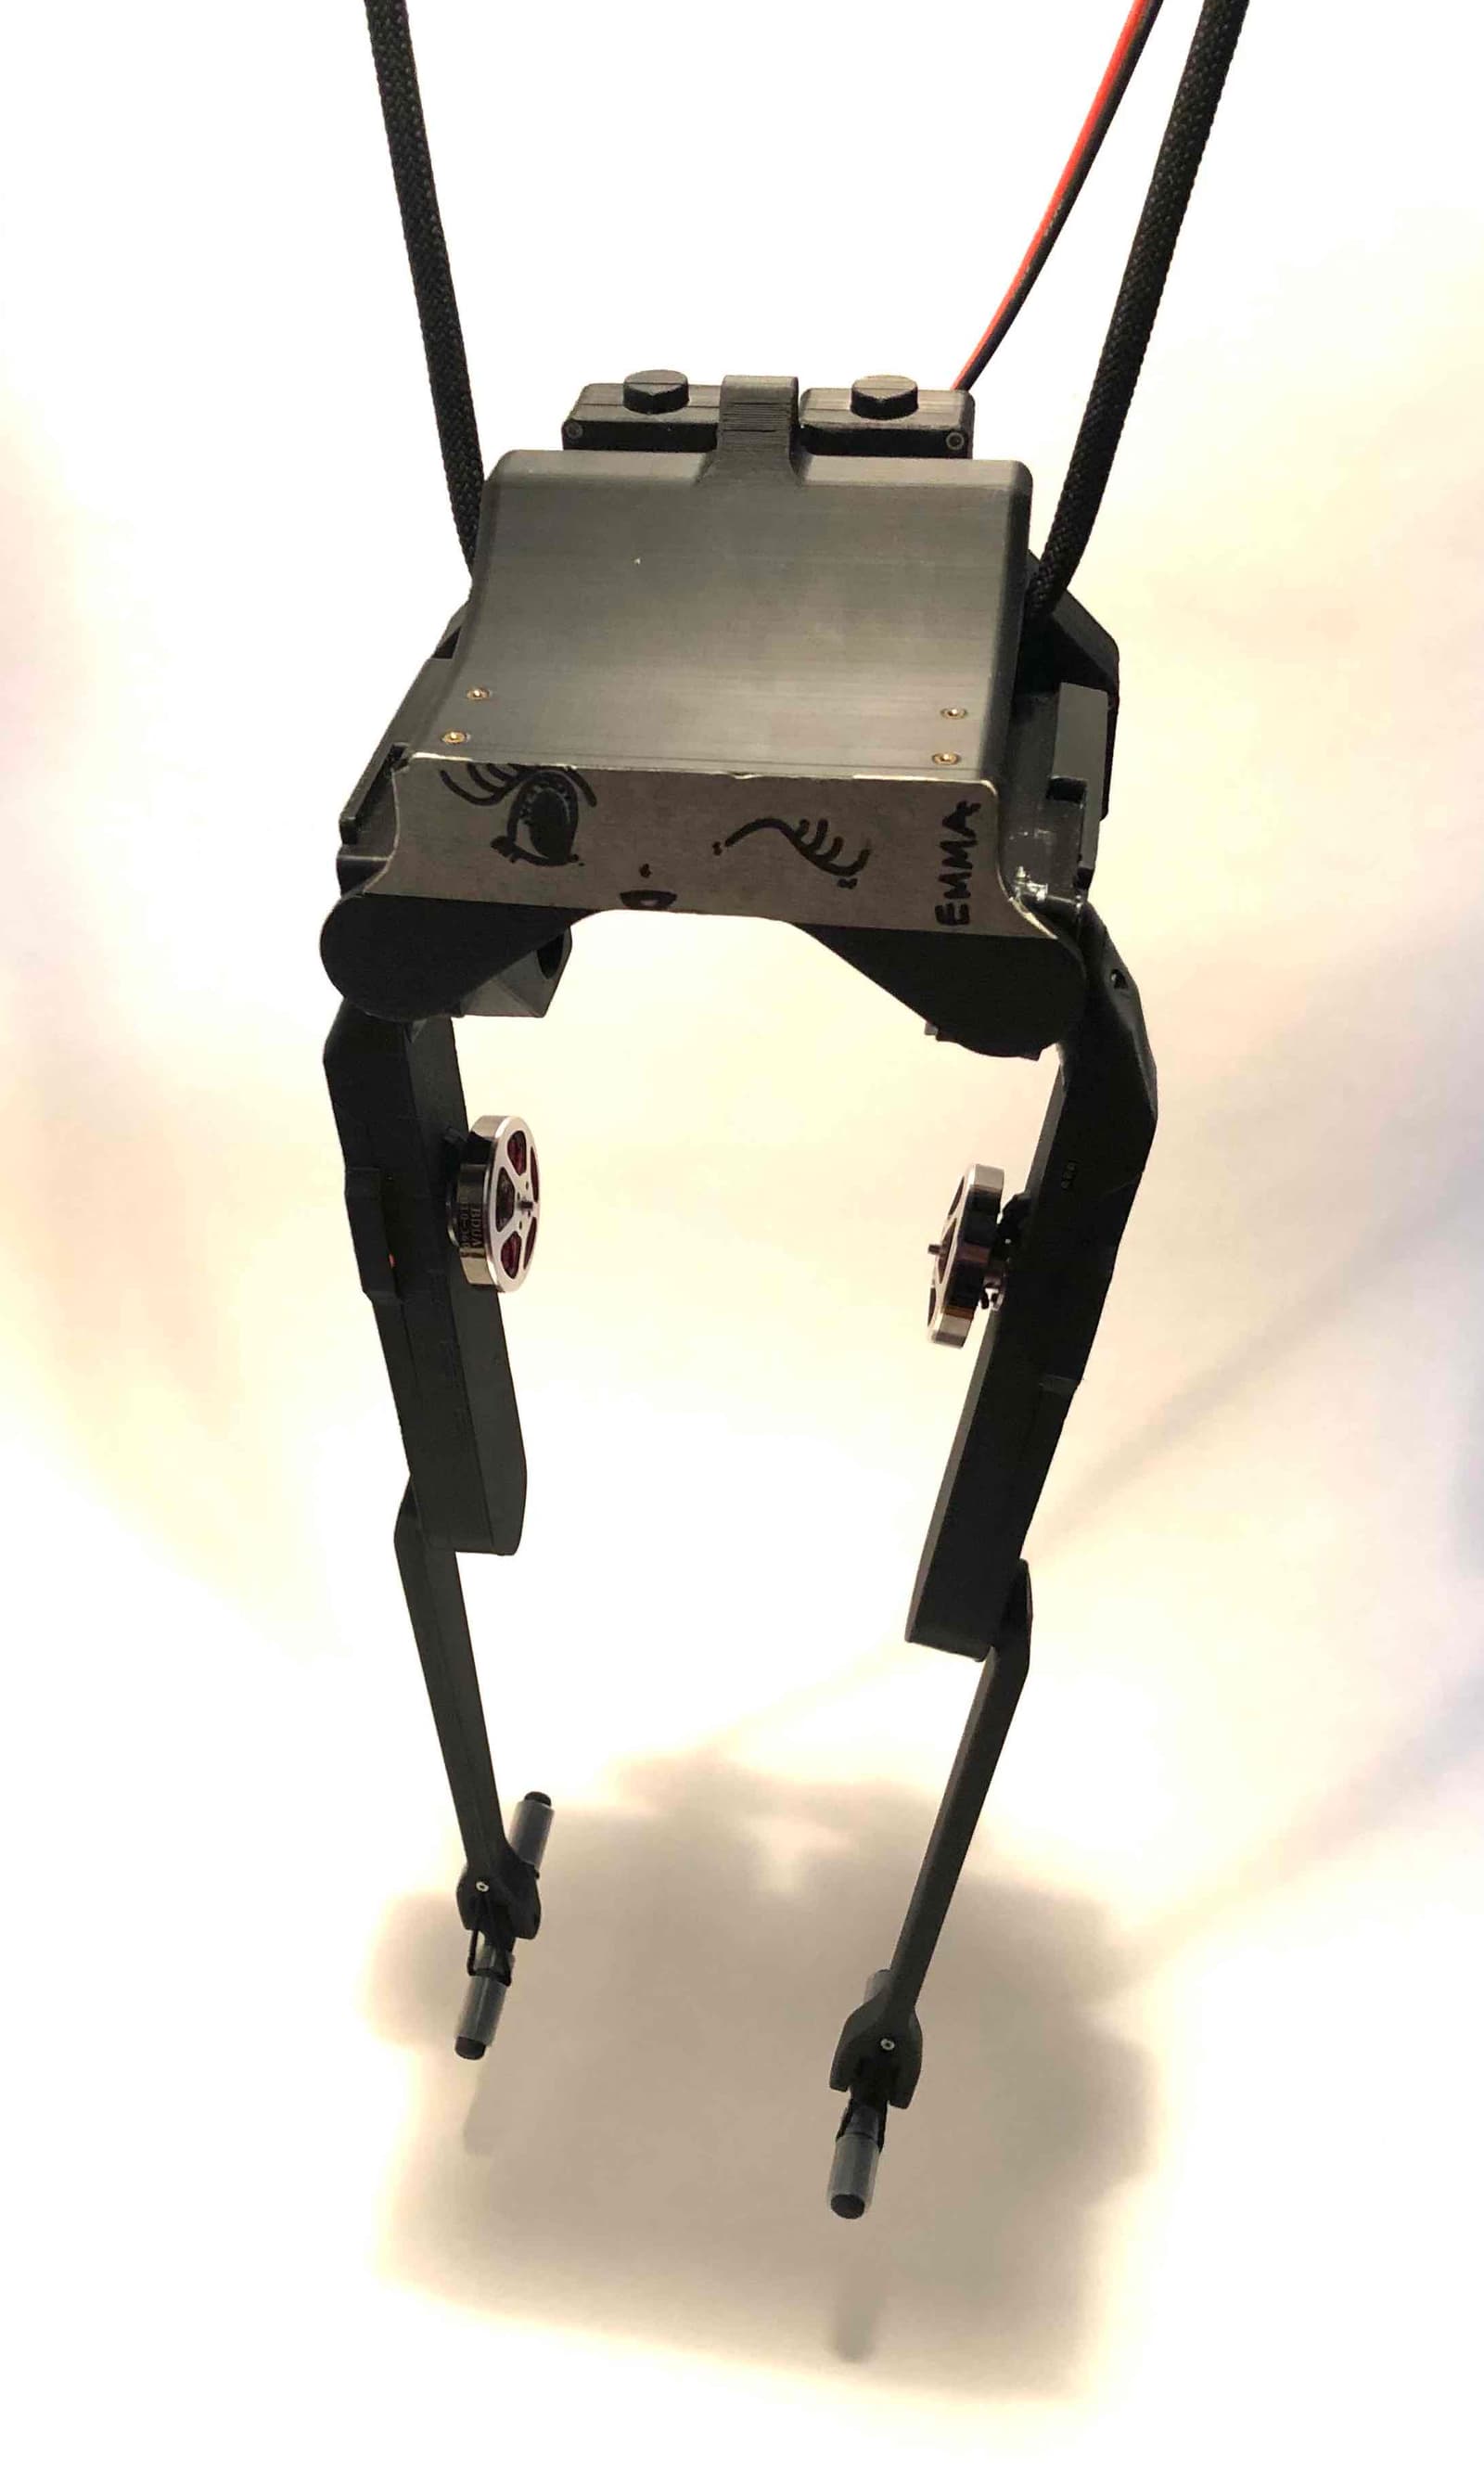
    Dagor Biped

    A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    MABEL

    MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    SoftRobotETF

    A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    AcroMonk

    A minimalist underactuated brachiating robot that swings along a horizontal ladder bar using one quasi-direct drive actuator and passive grippers.

    • Works with AI
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Antagonistic Tendon Driven Continuum Robot

    A research continuum robot with 4 degrees of freedom that drives two tendons per antagonistic pair with a single servo and measures tendon force with load cells.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    DengFOC Inverted Pendulum

    A low-cost, small inverted pendulum robot using DengFOC motor driver and SimpleFOC for balance control.

    Level
    Intermediate
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

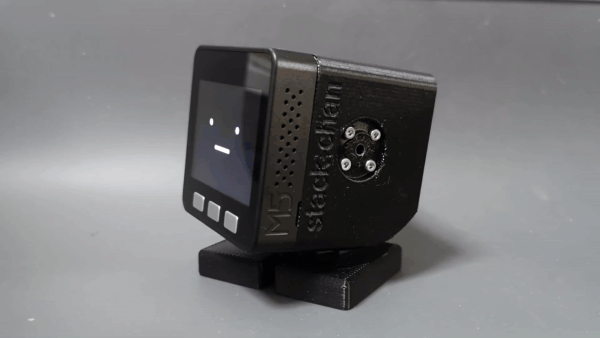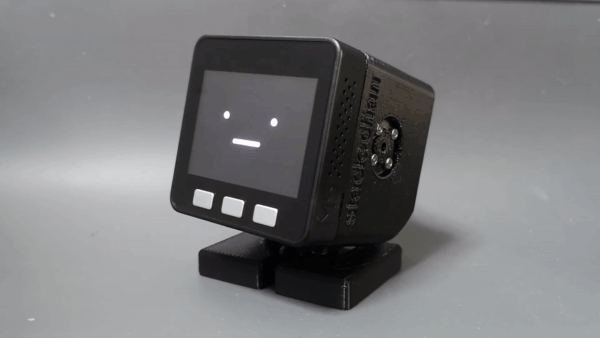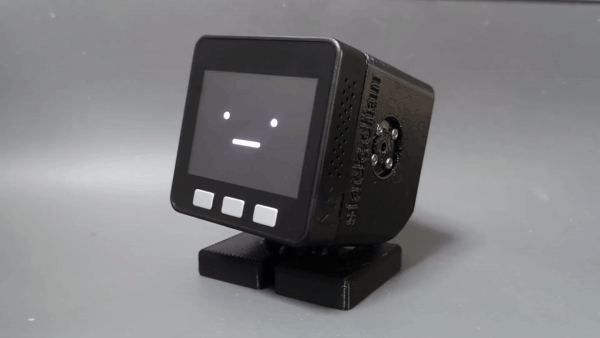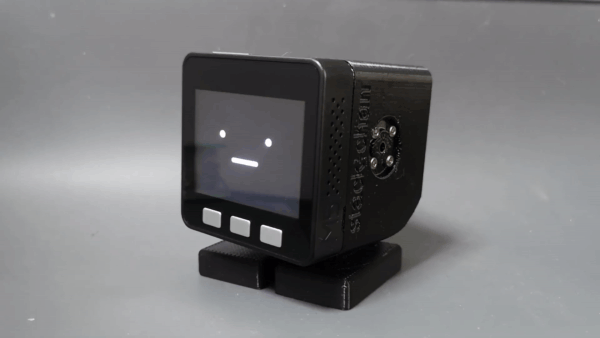
    Stack-chan

    A JavaScript-driven, super-kawaii desktop robot built on the M5Stack platform, with open-source firmware, MODs, and printable cases.

    • Works with AI
    Level
    Beginner
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

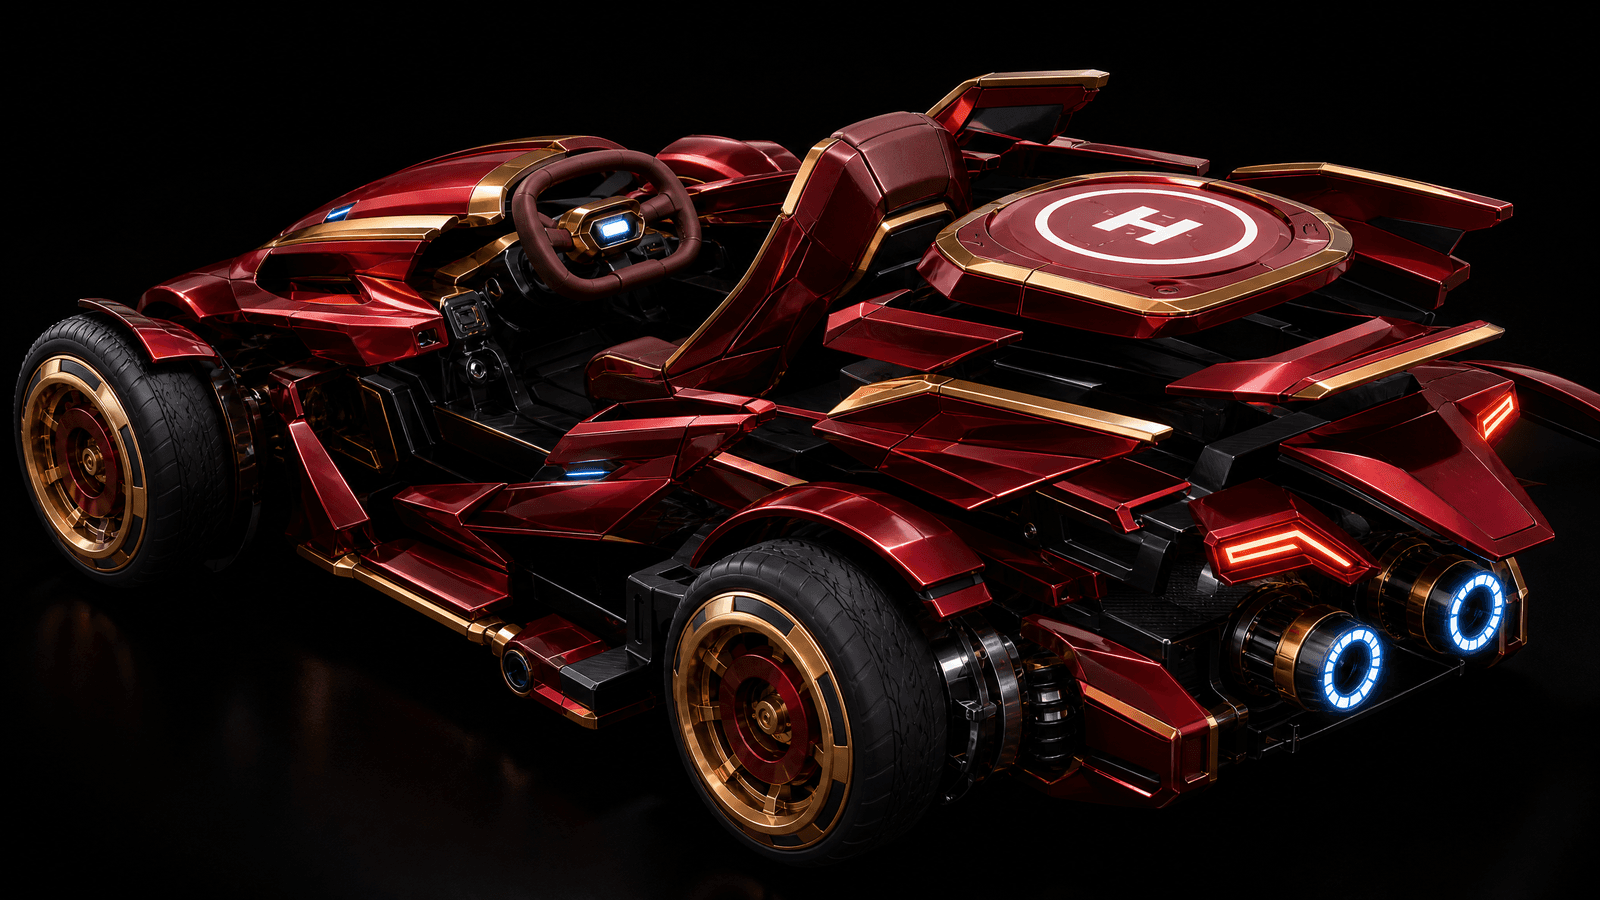
    OpenKidCar (Ganbei No.1)

    An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.

    • Work in progress
    • Works with AI
    Level
    Intermediate
    Buildability
    48/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Hexapod

    A family of 18-DOF, 3D-printed hexapod walking robots powered by an ESP32, controlled over WiFi or live pose streaming.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Hexapod v2 (Linkit 7697)

    A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Penny#3

    A low-budget three-servo hexapod robot that walks, dances and avoids obstacles using infrared proximity sensors.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    €10
  • Other

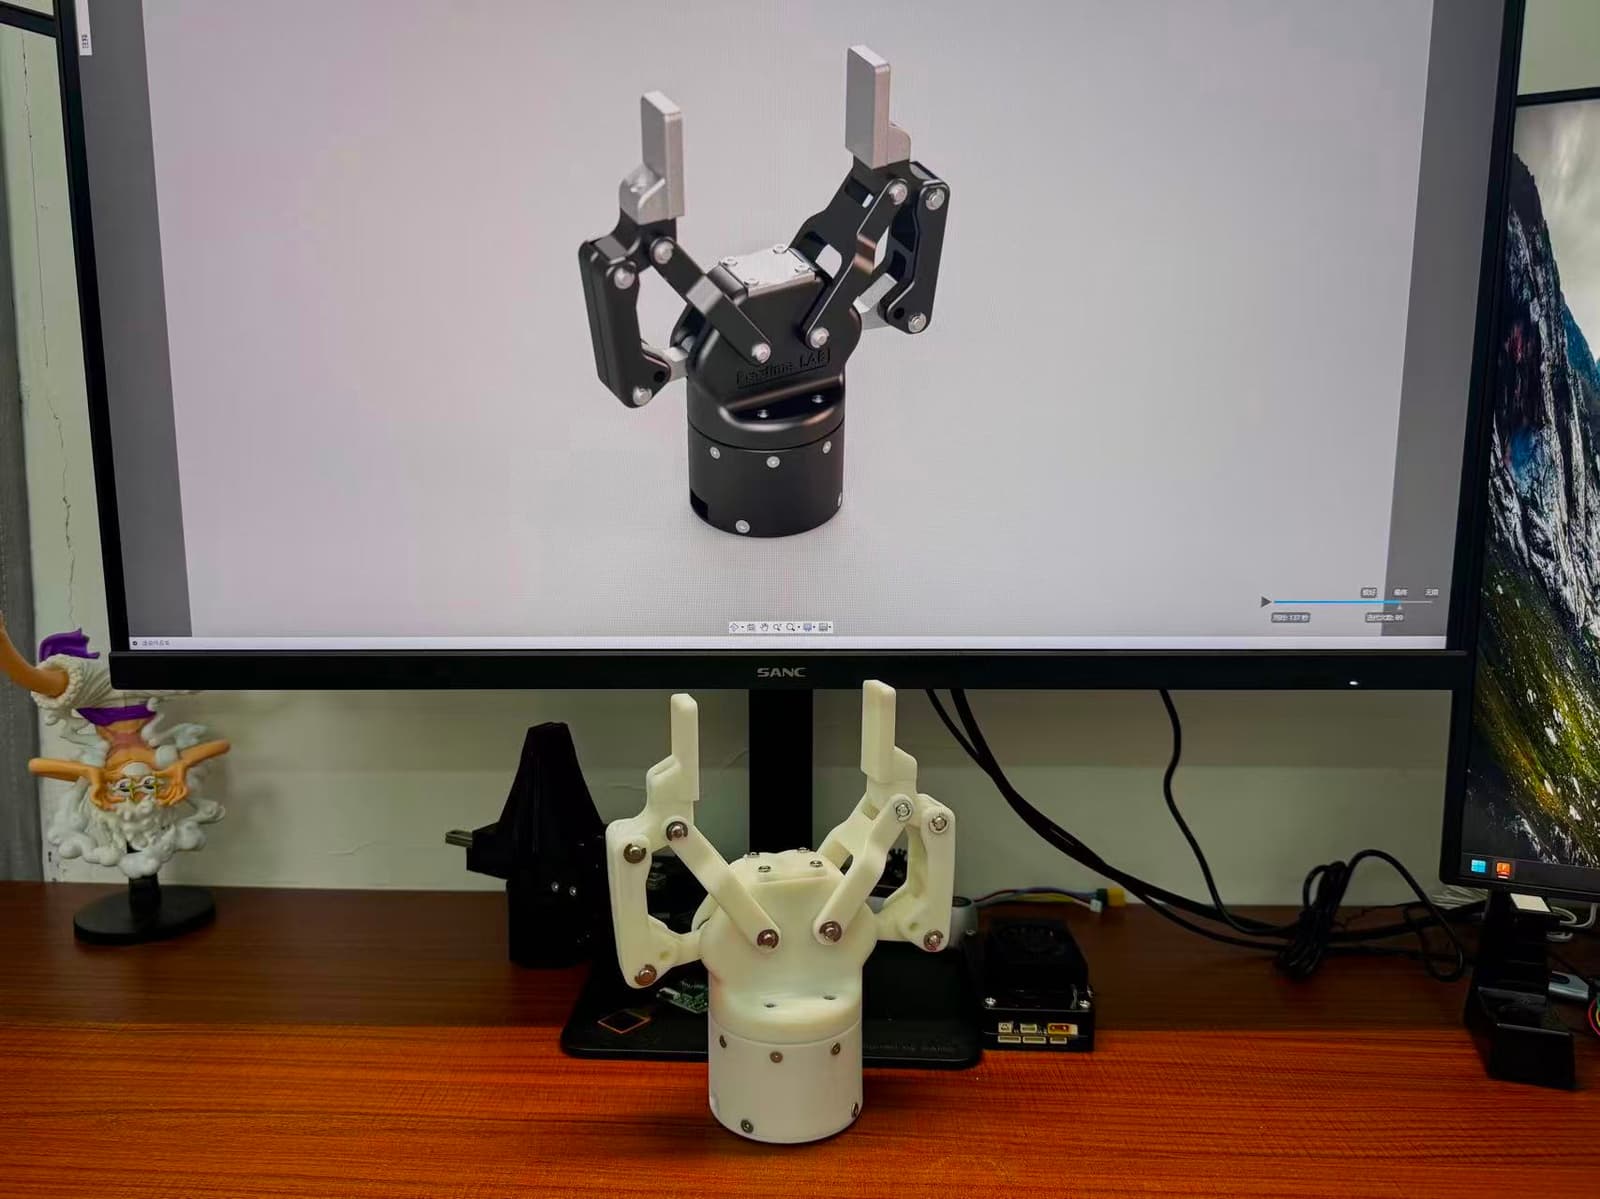
    RhinoV2.0 Adaptive Gripper

    An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Other

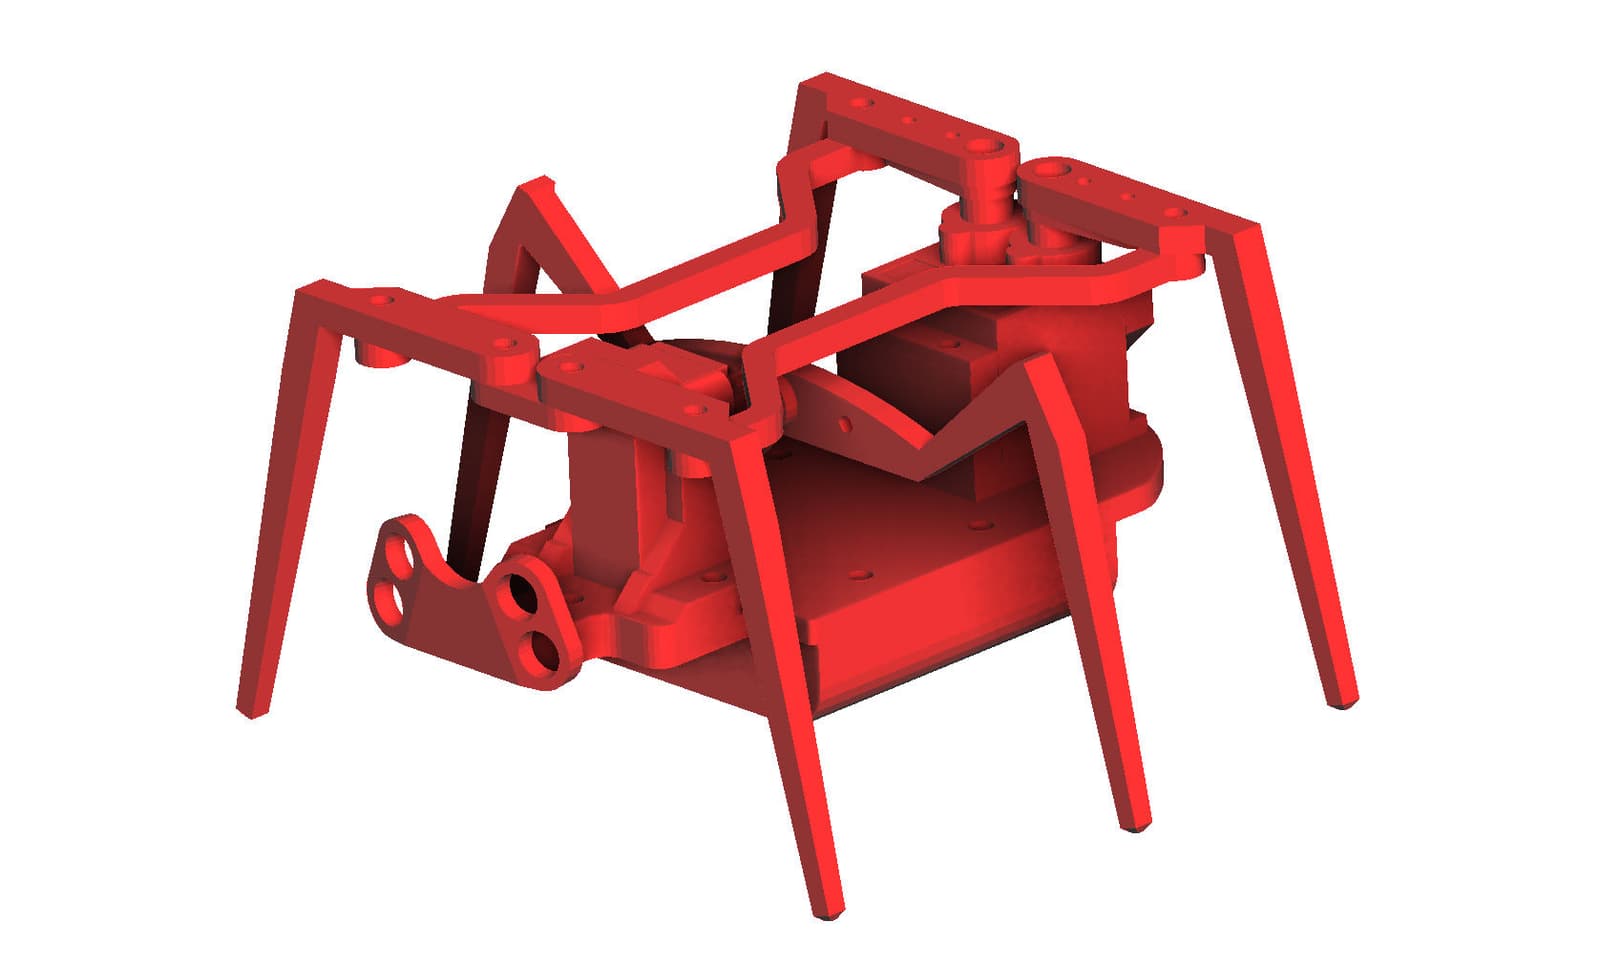
    ZeroBug

    A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    TipTap

    A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    ZGPS-01

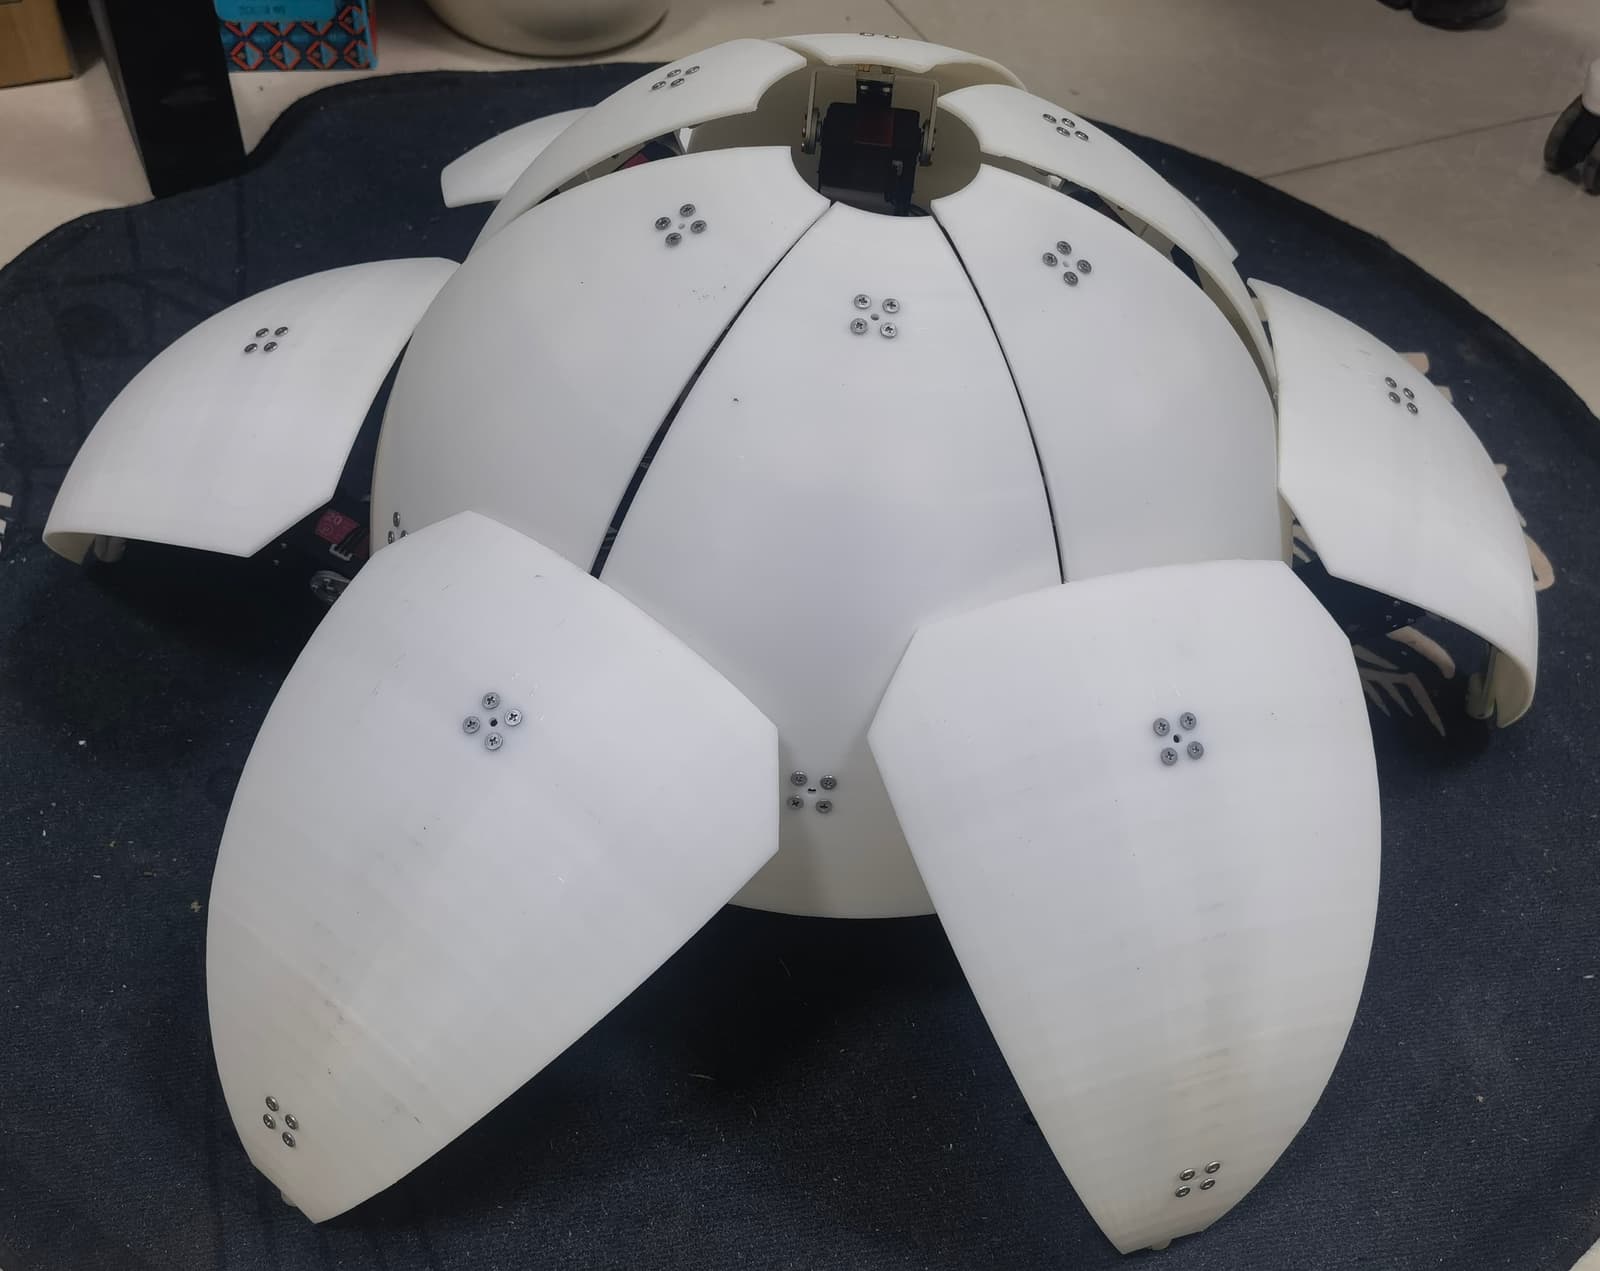
    A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Combat Robot

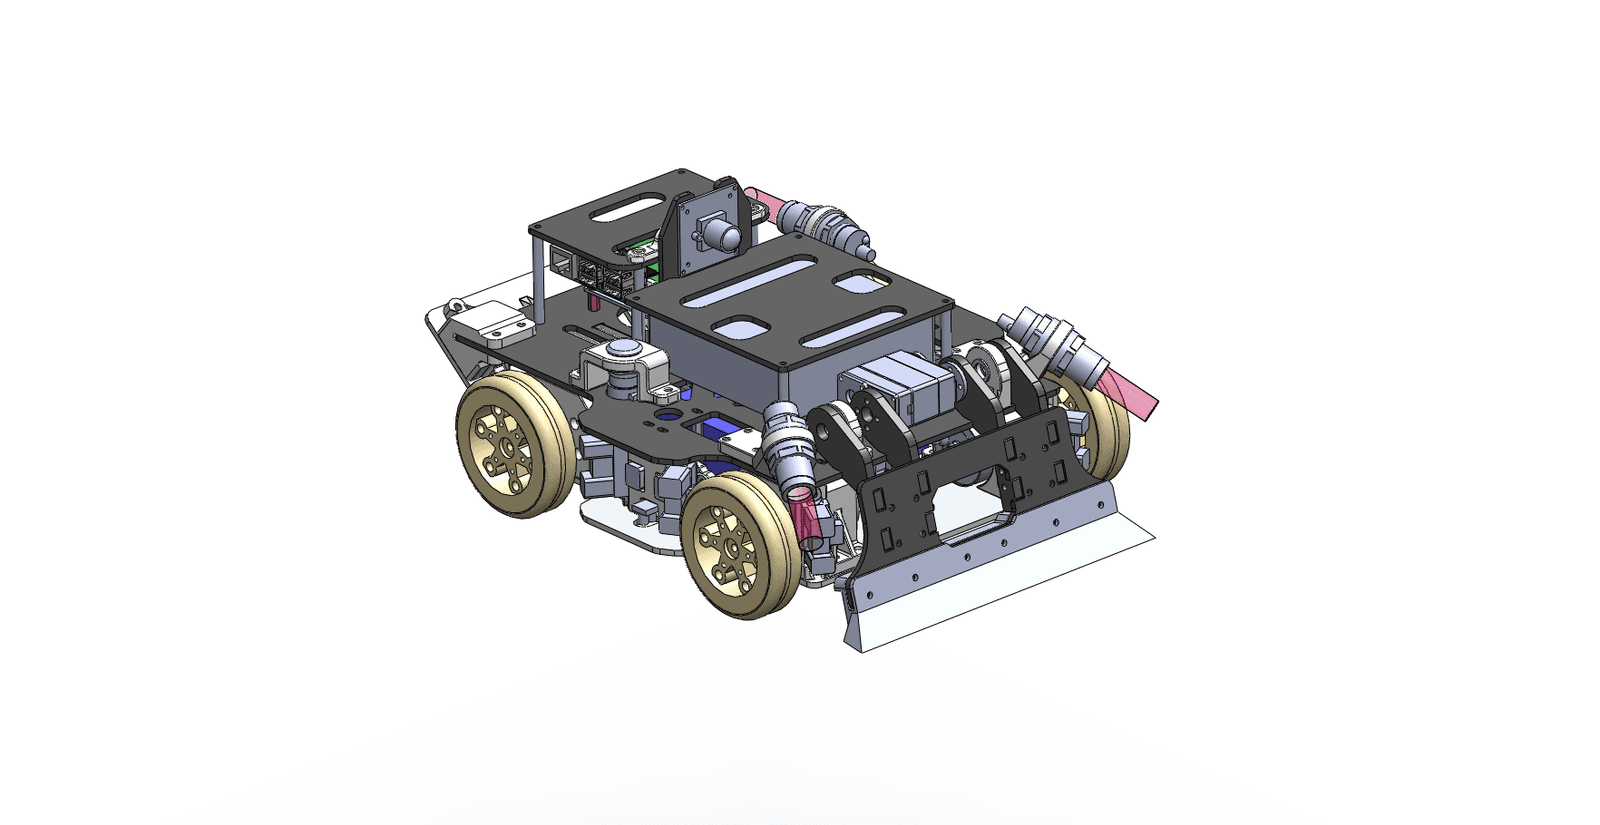
    A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.

    • Competition robot
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Stepping Balancer

    A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.

    Level
    Advanced
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated

More to explore