Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

270 robots

Page 11 of 12 · Ready to build first, then by buildability

  • Photo on GitHub
    Humanoid

    WALL-E Desktop Robot

    A desktop-scale WALL-E robot project with 3D-printable parts and CAD files.

    • No license
    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    KunPeng

    KunPeng is a dual-rotor drone that can achieve stable hovering at a fixed point and altitude.

    • No license
    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Robot arm

    Panthera-HT

    Mechanical model and parts list of HighTorque's Panthera-HT robot arm: SolidWorks 2024 sources, STEP files and a BOM spreadsheet.

    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Humanoid

    pib

    A repository of 3D printable STL parts for the pib robot, currently including C-Arm components.

    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Robotcup-Home

    A home service robot designed during undergraduate studies, featuring mechanical hardware and 3D modeling.

    • No license
    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Quadruped

    Six-legged Robot

    A six-legged robot controlled by STM32 microcontrollers with multi-modal control including cloud, WiFi, Bluetooth, voice, and gesture recognition.

    • No license
    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Swashplateless Twin Rotor Micro Aircraft

    A micro-scale swashplateless twin-rotor flying robot with its own flight controller hardware, control software and mechanical design.

    • Work in progress
    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    Triple-J UAV

    A quadrotor UAV based on STM32F103C8T6, FreeRTOS, and cascaded PID for experimental flight control and remote operation.

    • Work in progress
    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Wheeled

    UGV LiDAR Platform

    An open-source, cost-efficient unmanned ground vehicle (UGV) platform equipped with multiple LiDAR sensors for mapping and navigation.

    • Competition robot
    • No license
    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Wuhu TakeOff Quadcopter

    A DIY quadcopter drone built from scratch using an STM32F411CEU6 microcontroller.

    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Zhuge Liang Four-Wheel Car Kart Hardware

    Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.

    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    F4 Flight Controller ESC

    An open-source quadcopter flight controller and electronic speed controller with CAD files for a drone frame.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    F405 PCB FPV

    A quadcopter built entirely with integrated PCB components for FPV flight.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    HeiGuan

    A quadcopter drone built by a student group for educational purposes, featuring STM32F401-Nucleo64 flight control.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    OmniT-Hand

    A minimalist underactuated robotic hand with one motor per finger, achieving adaptive grasping for humanoid robots.

    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    ¥1,230≈ €164 (ECB rate, 14 Oct 2026)
  • Photo on GitHub
    Drone

    Quadcopter

    A small homemade quadcopter using an F411 and NRF51822 flight controller based on the open-source MiniFly design.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    Rhino Gripper

    An open-source two-finger adaptive gripper inspired by the Robotiq design.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Wheeled

    STM32 Balance Car

    A two-wheeled self-balancing robot based on STM32 microcontroller.
    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    TABV-Platform

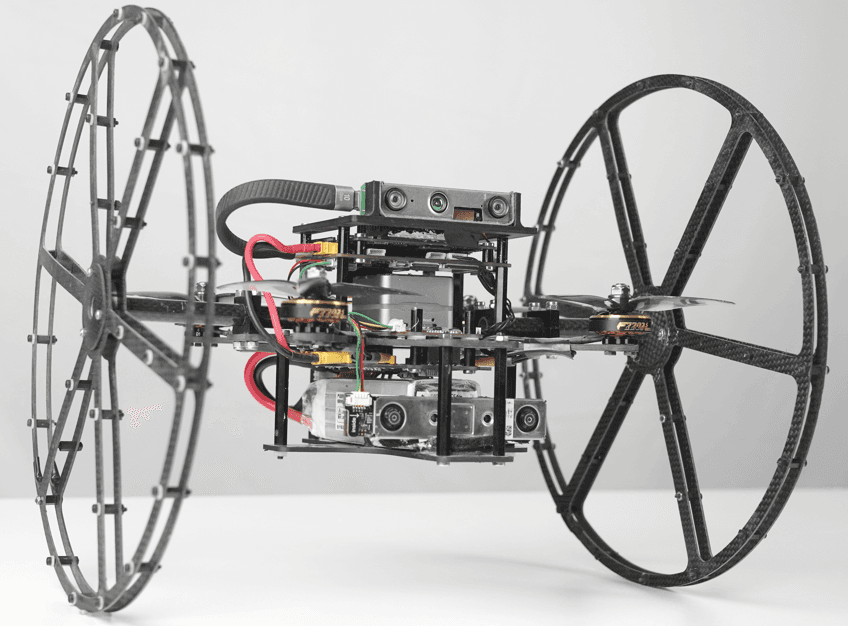
    A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.

    Level
    Advanced
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Wheeled

    Two-wheel RC smart car

    A two-wheel remote-control smart car: schematic, circuit board pictures, program, soldering tutorial, manual and how it works.

    • No license
    Level
    Beginner
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Balance Car 2

    A two-wheeled self-balancing car based on STM32.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Hoverboard

    A self-balancing hoverboard project that includes STM32 firmware and PCB designs.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    PCB Quadrotor

    A PCB-based quadrotor drone designed for research experiments, featuring 8520 coreless motors and 55mm propellers as a simple aerial mobility platform.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    SmartCar

    An open-source smart car designed for the 18th Smart Car Competition, featuring camera-based recognition and control.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated

Robots 241–264 of 270

More to explore