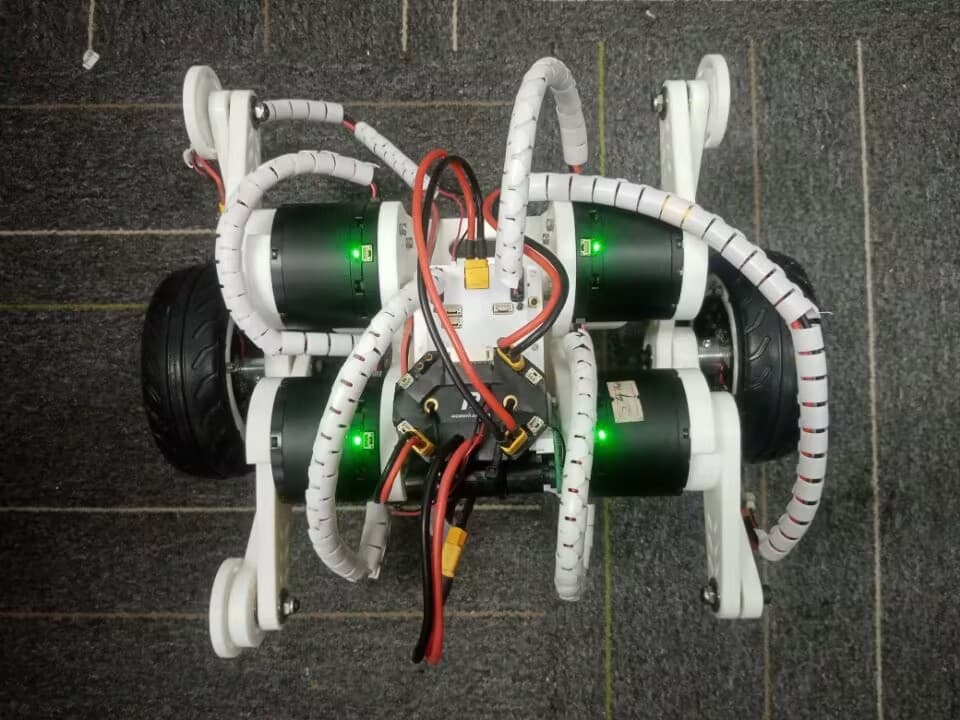
Cybergear Mechanical DOG
An 8-degree-of-freedom parallel quadruped robot using Xiaomi CyberGear motors and STM32F427 control.
- Work in progress
- Competition robot
- No license
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 4 of 4 · Ready to build first, then by buildability
An 8-degree-of-freedom parallel quadruped robot using Xiaomi CyberGear motors and STM32F427 control.
A low-cost quadruped robot built with 35 kg servo motors and 3D-printed parts.
An open-source ESP-FLY drone with CAD models, Crazyflie-based flight firmware, a PyQt6 PC debugging tool and an Android control app.
An open-source quadcopter drone with a self-built frame and flight controller, designed for indoor flight and formation experiments.
A 12-DOF quadruped robot dog with a 6-DOF manipulator, featuring five-bar linkage legs and a BeagleBone Black + STM32 control system.
An open-source autonomous car using pure inertial navigation for path collection, planning, and reproduction with TC2xx main controller and dual AI8051U motor drivers.
A full-size humanoid robot with 43 degrees of freedom, designed for bionic motion and autonomous navigation in complex environments.
The Ruishi modular exoskeleton: joint and slip-ring modules, the hardware and joint-motor lists, and installation examples.
An open-source hardware solution for the 20th National University Intelligent Vehicle Competition unicycle category Q-car model, featuring integrated PCB and 3D-printed parts.
FreeCAD hardware source files for the Sprite humanoid robot's structure.
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.
An autonomous bicycle that uses an ESP32-based controller and CAN bus to drive actuators for self-driving functionality.
An open-source bipedal robot designed for dynamic walking with a cost-effective and rational structure.
A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.
Mechanical model and parts list of HighTorque's Panthera-HT robot arm: SolidWorks 2024 sources, STEP files and a BOM spreadsheet.
A micro-scale swashplateless twin-rotor flying robot with its own flight controller hardware, control software and mechanical design.
A quadrotor UAV based on STM32F103C8T6, FreeRTOS, and cascaded PID for experimental flight control and remote operation.
A DIY quadcopter drone built from scratch using an STM32F411CEU6 microcontroller.
Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.
A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.
An underwater robot made by team 105, sea version: its control programs and the circuit boards of the main board and the power compartment.
AgiBot's open hardware design of its X1 (Lingxi X1) humanoid robot, in three dated versions (2024-10-24, 2025-01-08 and 2025-03-07).
An all-in-one car for electronics design contests and Huawei's hardware challenge: schematics (core, power, charger, peripherals) and circuit board, as an Altium project.
Robots 73–95 of 95