No photo yet
WheeledRaspberry Pi Cat
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
- Level
- Intermediate
- Buildability
- 35/100
- Incomplete documentation
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
A small wheeled mobile robot built around a Raspberry Pi, with 3D-printed parts and CAD files for rebuilding its hardware.
A small two-wheeled differential-drive mobile robot platform built on a Raspberry Pi, with 3D CAD data for the robot and its optional parts.
A universal electronic control software architecture for a Mecanum wheel chassis robot based on STM32F427, designed for Robocon 2024 R1.
A line-following robot hardware documentation set with CAD files, 3D printable parts and circuit schematics for the TrainingTracer Ver.3 educational robot.
 Wheeled
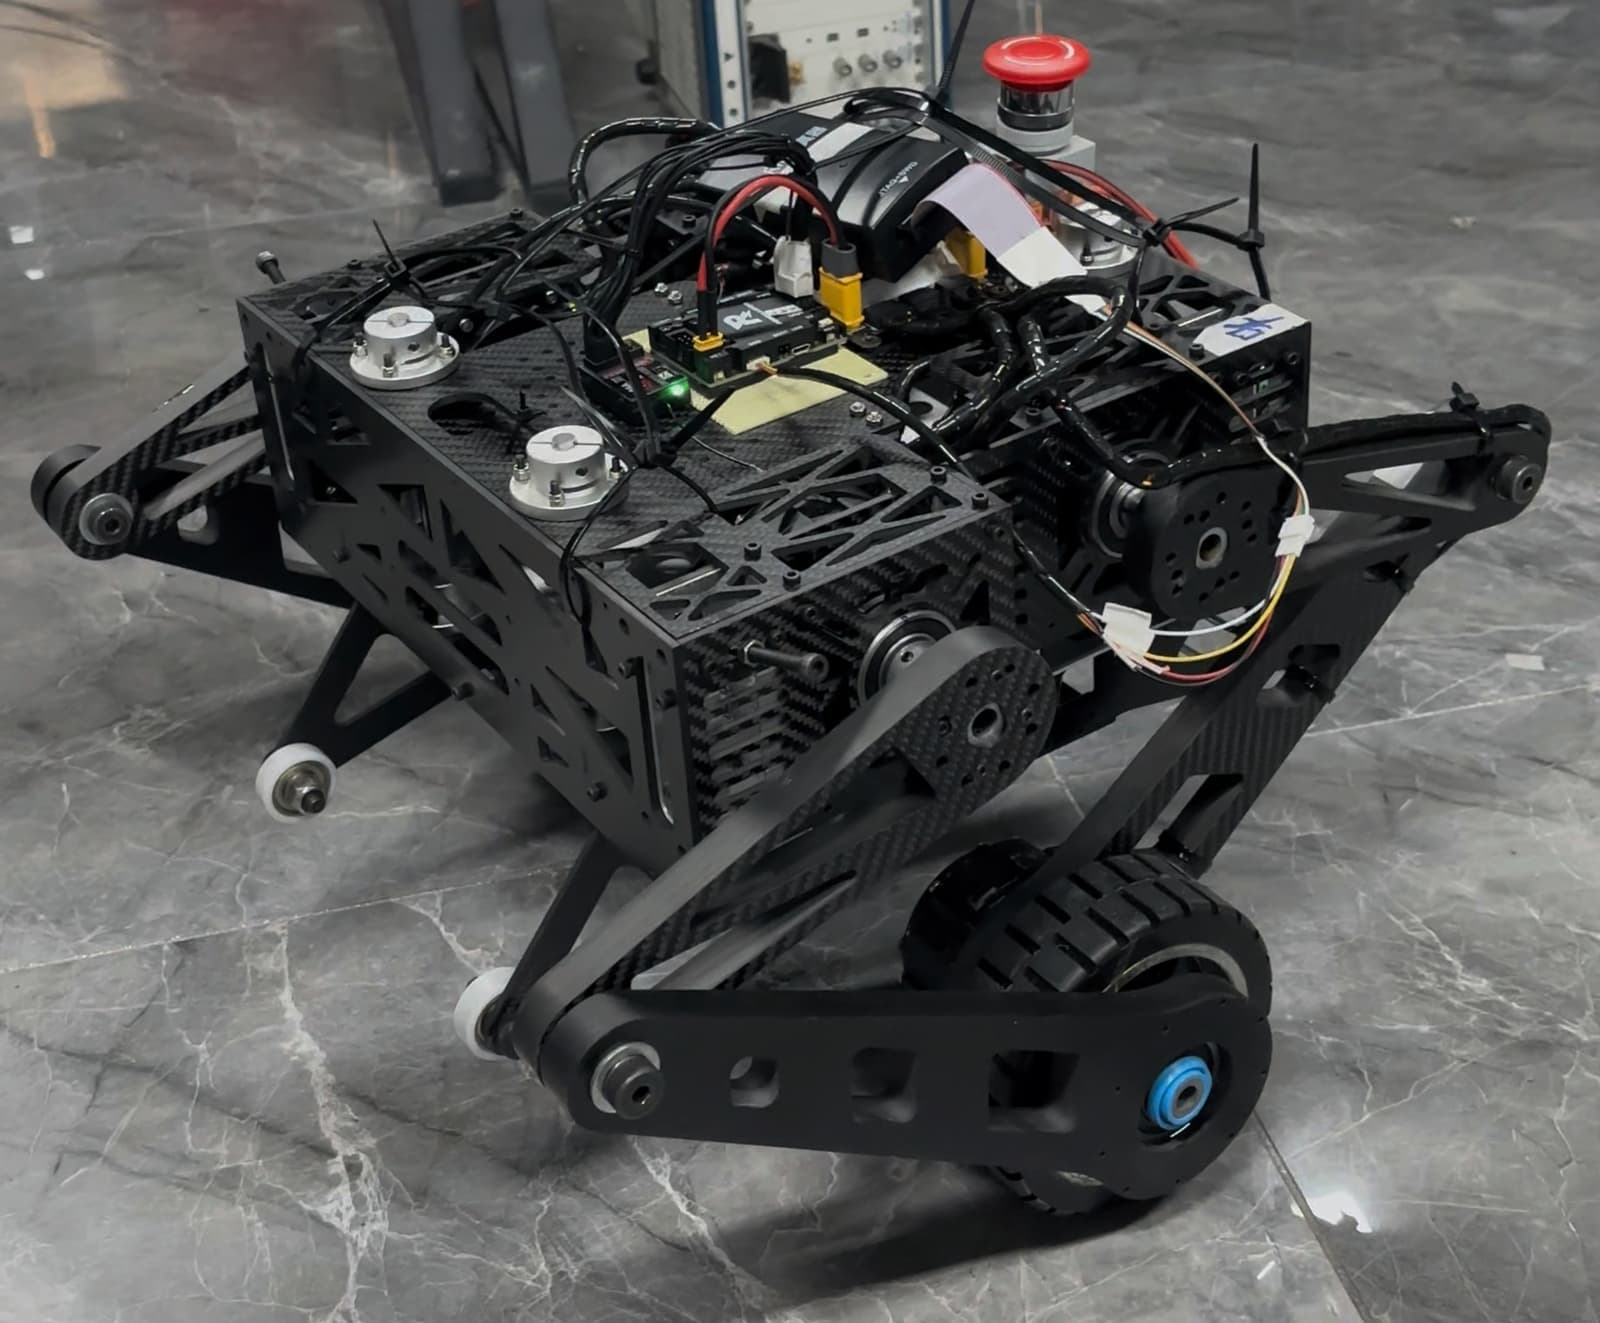
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
A two-wheeled self-balancing robot controlled by an LQR algorithm on an STM32F103C8T6, with a custom-drawn control board and mechanical structure.
An ESP32-based self-balancing robot car with dual wheels, open-source hardware and software, including 3D models and BOM.
An open-source Mars rover robot with ESP32-based electronics and Arduino firmware for remote control and sensor integration.
A self-balancing robot car built with STM32F103C8T6, MPU6050, MX1508, ESP8266, and OLED.
A self-balancing robot car that uses PID control and features ultrasonic obstacle avoidance, ultrasonic following, and Bluetooth remote control.
A two-wheeled differential-drive robot using ROS Noetic for SLAM navigation with Gmapping, Hector, and Cartographer.
A home service robot designed during undergraduate studies, featuring mechanical hardware and 3D modeling.
An open-source, cost-efficient unmanned ground vehicle (UGV) platform equipped with multiple LiDAR sensors for mapping and navigation.
A two-wheeled self-balancing robot based on STM32 microcontroller.
A self-balancing hoverboard project that includes STM32 firmware and PCB designs.
Robots 25–39 of 39