Icebot
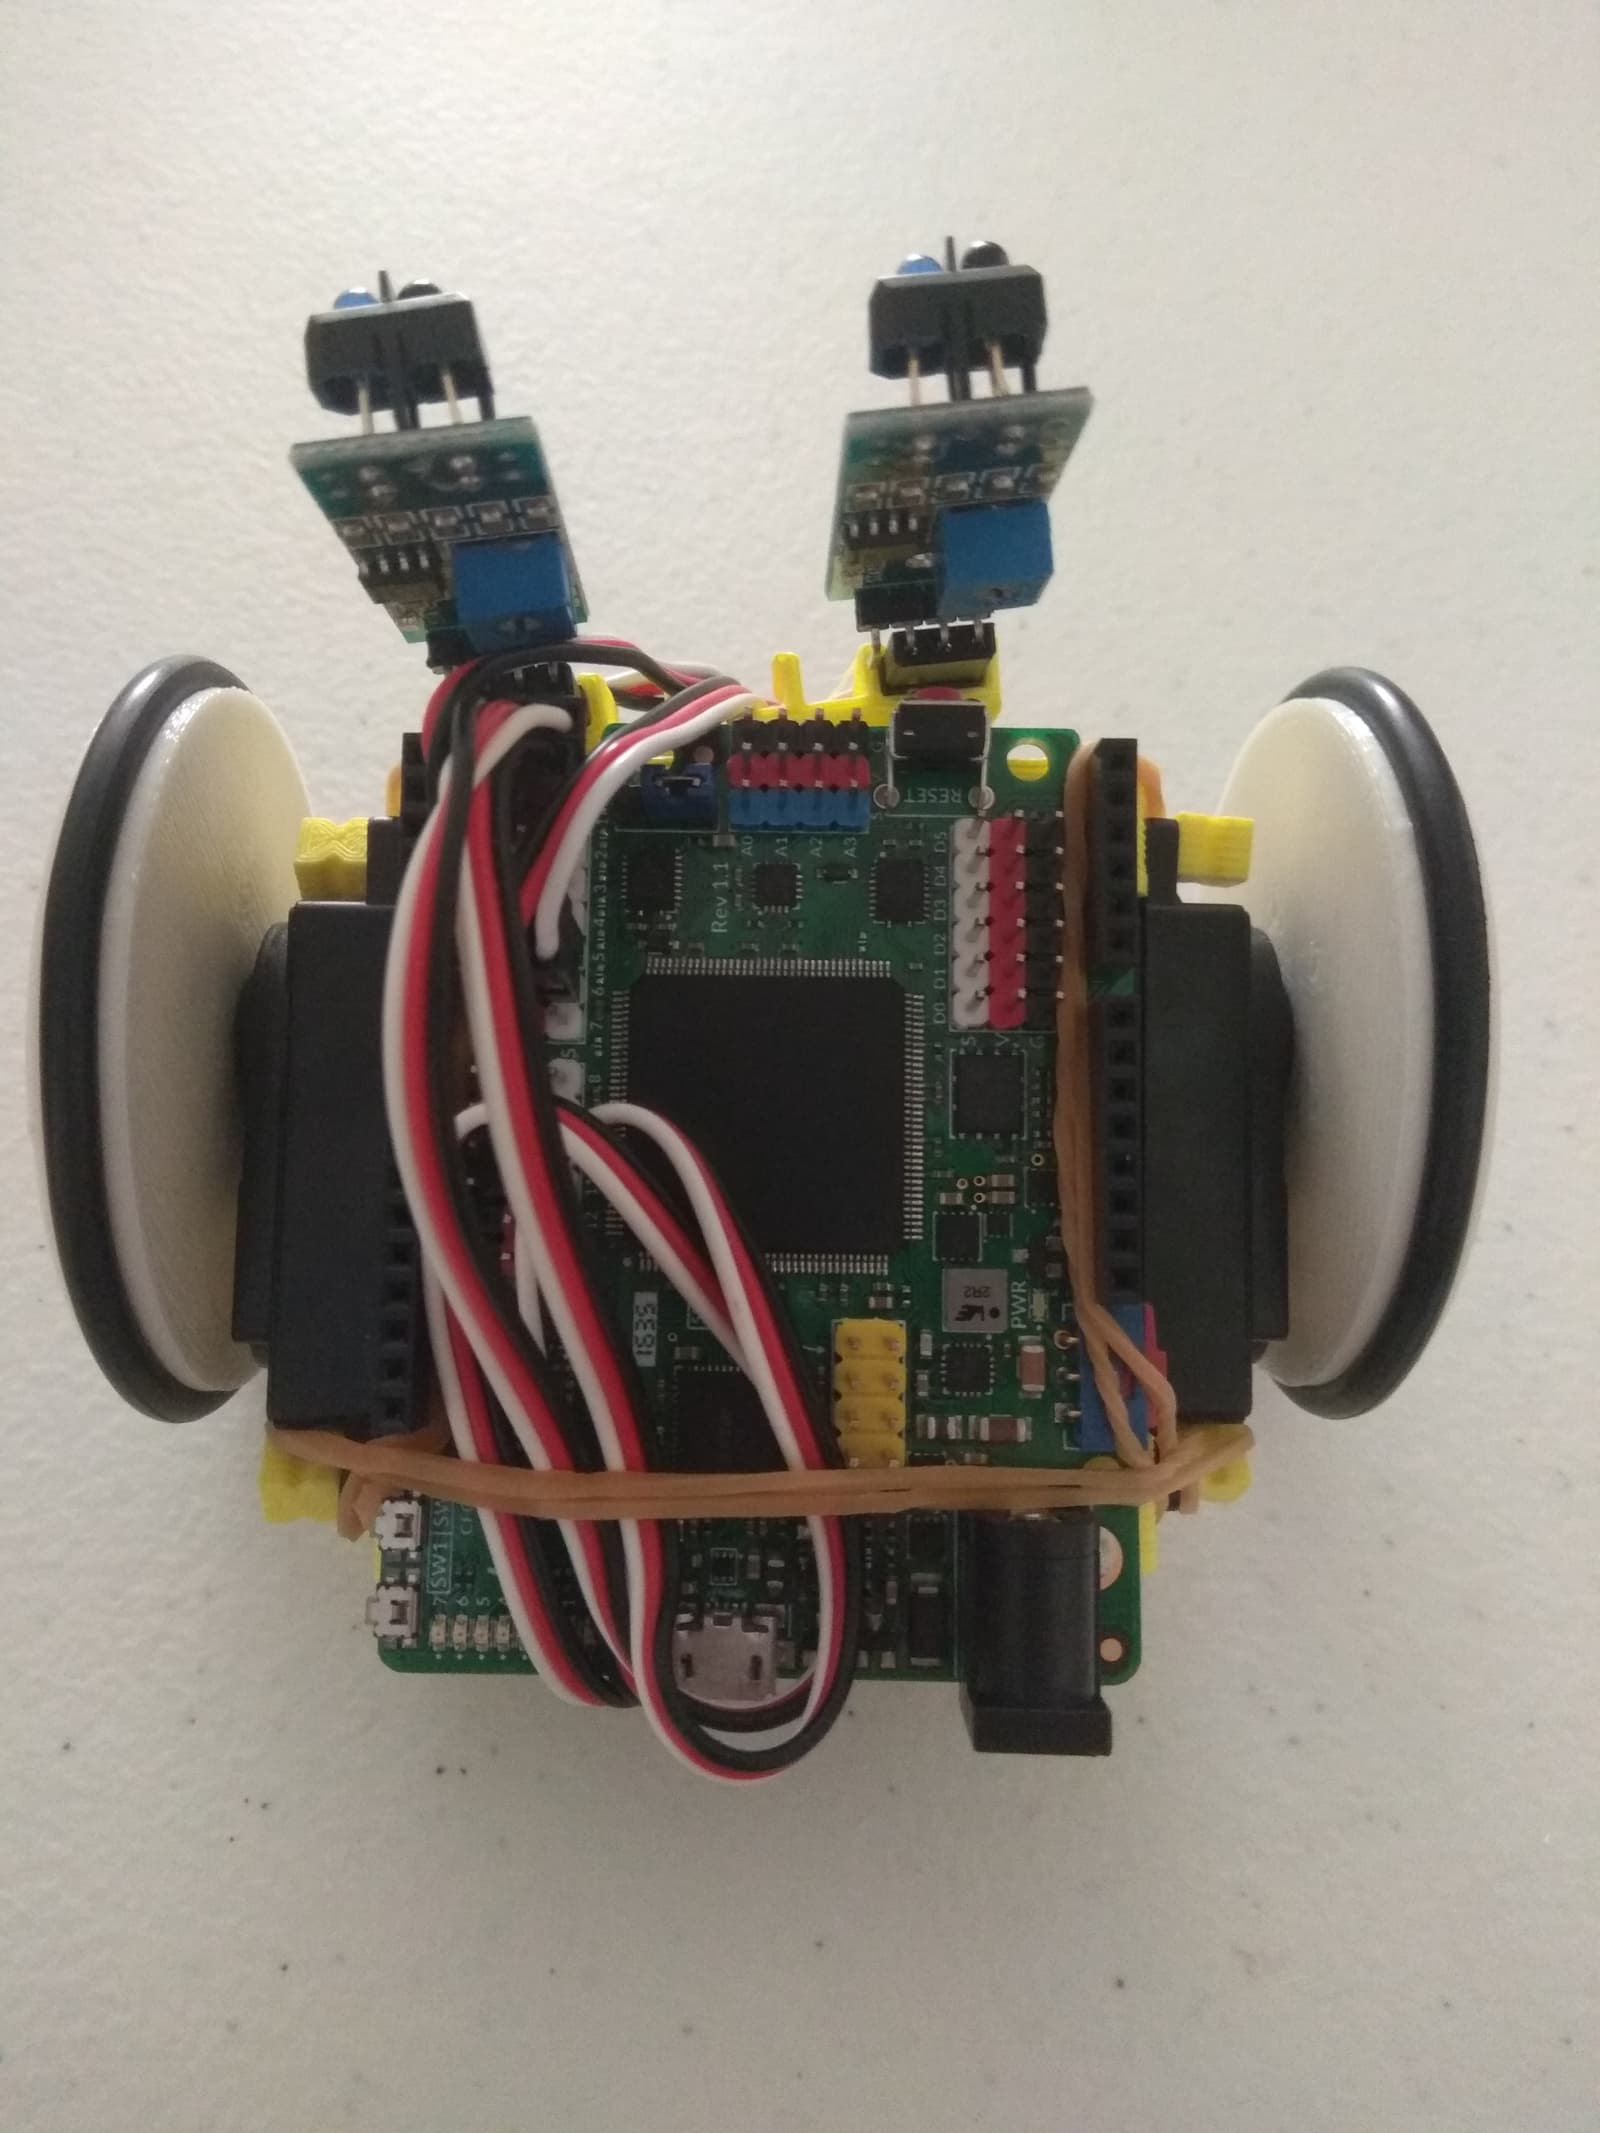
A simple printable robot (printbot) designed to be controlled by the Icezum Alhambra FPGA board.
- Wheeled
- Open source
- 3D printable
Suggested by Robotheca, created by @Obijuan (opens in a new tab), from github.com/Obijuan/icebot (opens in a new tab). Pinned to commit d56222a (opens in a new tab).
- Hardware license
- LGPL-3.0-only (opens in a new tab)
- Software license
- LGPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
3D preview converted from github.com/Obijuan/icebot at d56222a, under LGPL-3.0-only. View the original files from GitHub (940 KB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Printable mobile robot built from 3D-printed parts, designed as a block-based robot with parts attached by two screws each.
- Drives on two continuous-rotation servo wheels, with the wheels mounted reversed so the hub sits inside the chassis.
- Has a sensor accessory with holes for mounting various sensors, and a power bank accessory mount.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Obijuan (README.md), under LGPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Two continuous-rotation servos for the wheels.
- Icezum Alhambra FPGA board (a similar board such as an Arduino is also mentioned as an option).
- Optional 2600mAh power bank for power, held by a 25x25 cm accessory.
- Velcro strips used to hold the electronics in place.
Connections
- Electronics are held on the chassis with Velcro rather than elastic bands; no wiring connections are described in the documents.