Photo on GitHub
OtherTdrone
An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
- No license
- Level
- Advanced
- Buildability
- 40/100
- Incomplete documentation
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
 Other
A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.
A low-cost DIY writing machine that draws on a vertical surface using two stepper motors and a servo-controlled pen.
A collection of 3D-printable accessories and decorations for the ElectronBot robot.
A desktop robot that responds entirely in its own voice, built from 3D-printed parts and custom electronics.
An ultra cheap, simple two-motor robot with four sensors that a middle schooler can build in several hours.
A wheel-legged balancing robot with leg-joint motors and hub-wheel motors, controlled by a custom STM32H723 board using LQR and VMC.
A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
 Other
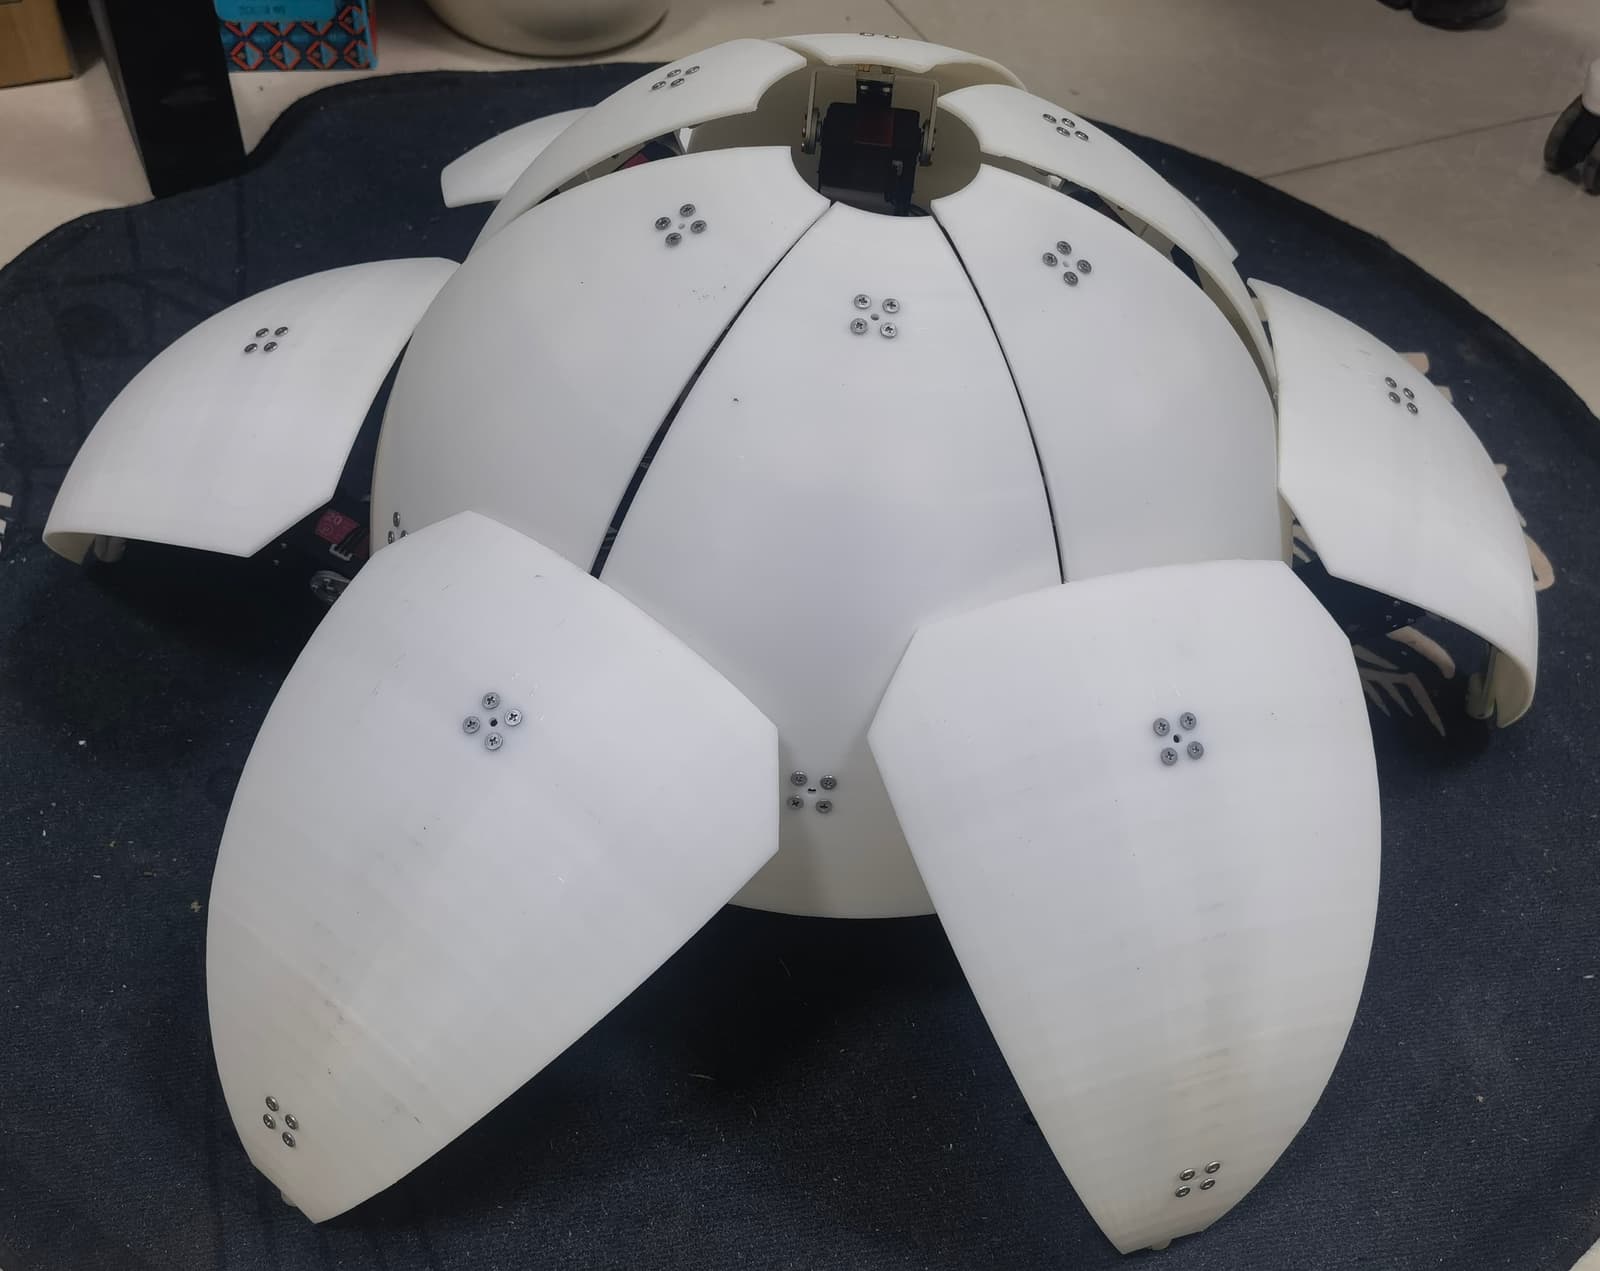
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
An open-source 6-DOF anthropomorphic robotic hand with linkage-based fingers and worm-and-rack transmissions, intended as a low-cost platform for research and education.
 Other
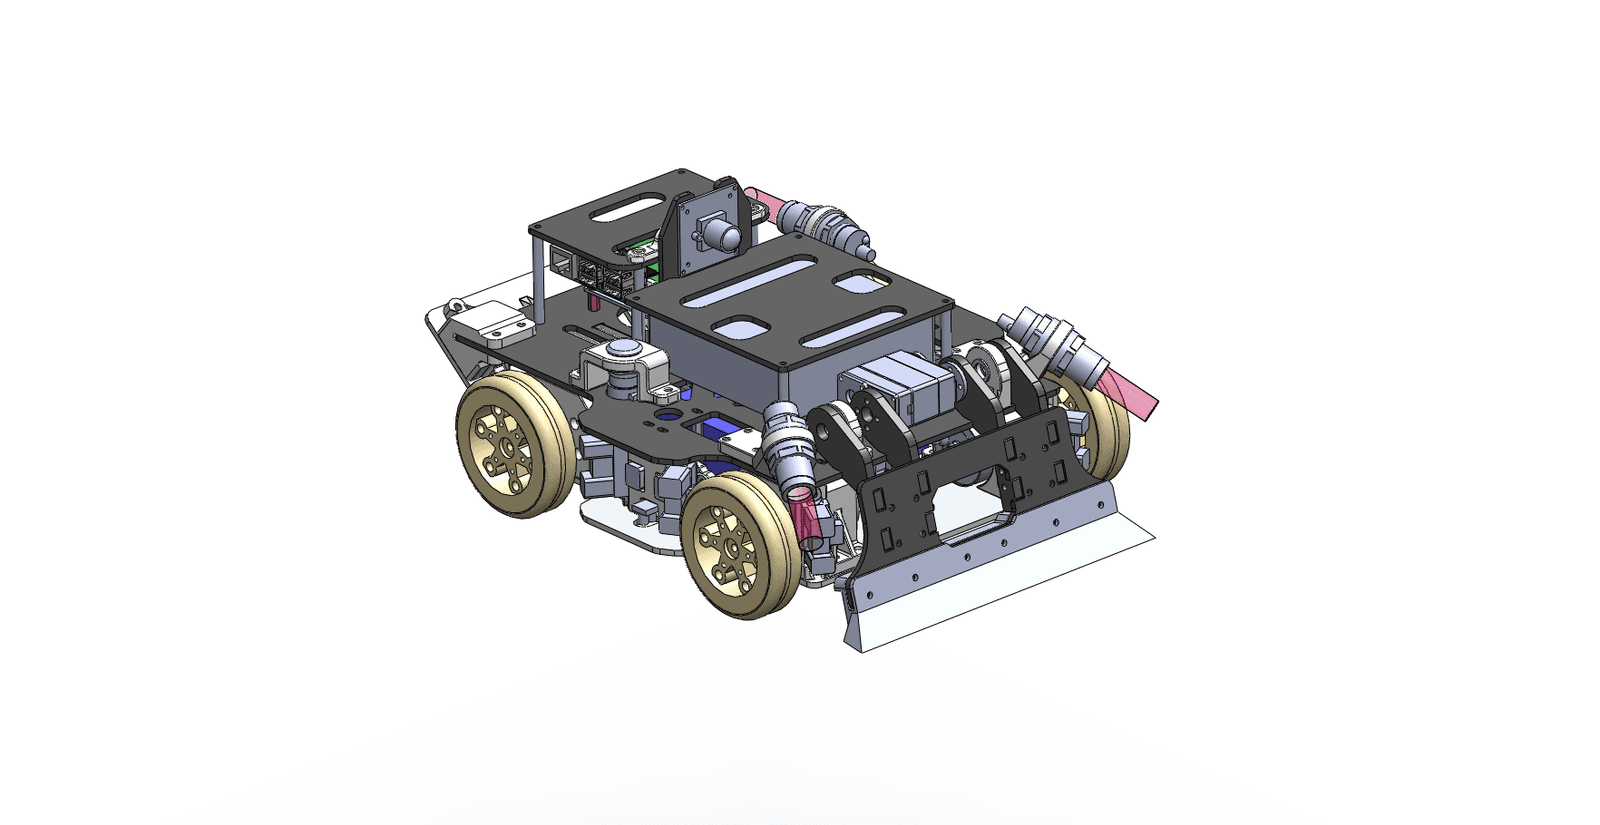
A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.
A hexapod robot controlled by an STC15 microcontroller, featuring a 21-channel servo controller and 3D-printable parts.
A self-balancing unicycle robot based on IMU and STM32.
An AI-powered robot hand that can be rebuilt by 3D printing its parts.
A compact robot that solves a scrambled 3x3 Rubik's Cube using a STM32F407 microcontroller.
A low-cost ROS2 robot designed for students and hobbyists to learn robotics and ROS2 development through hands-on assembly and programming.
 Other
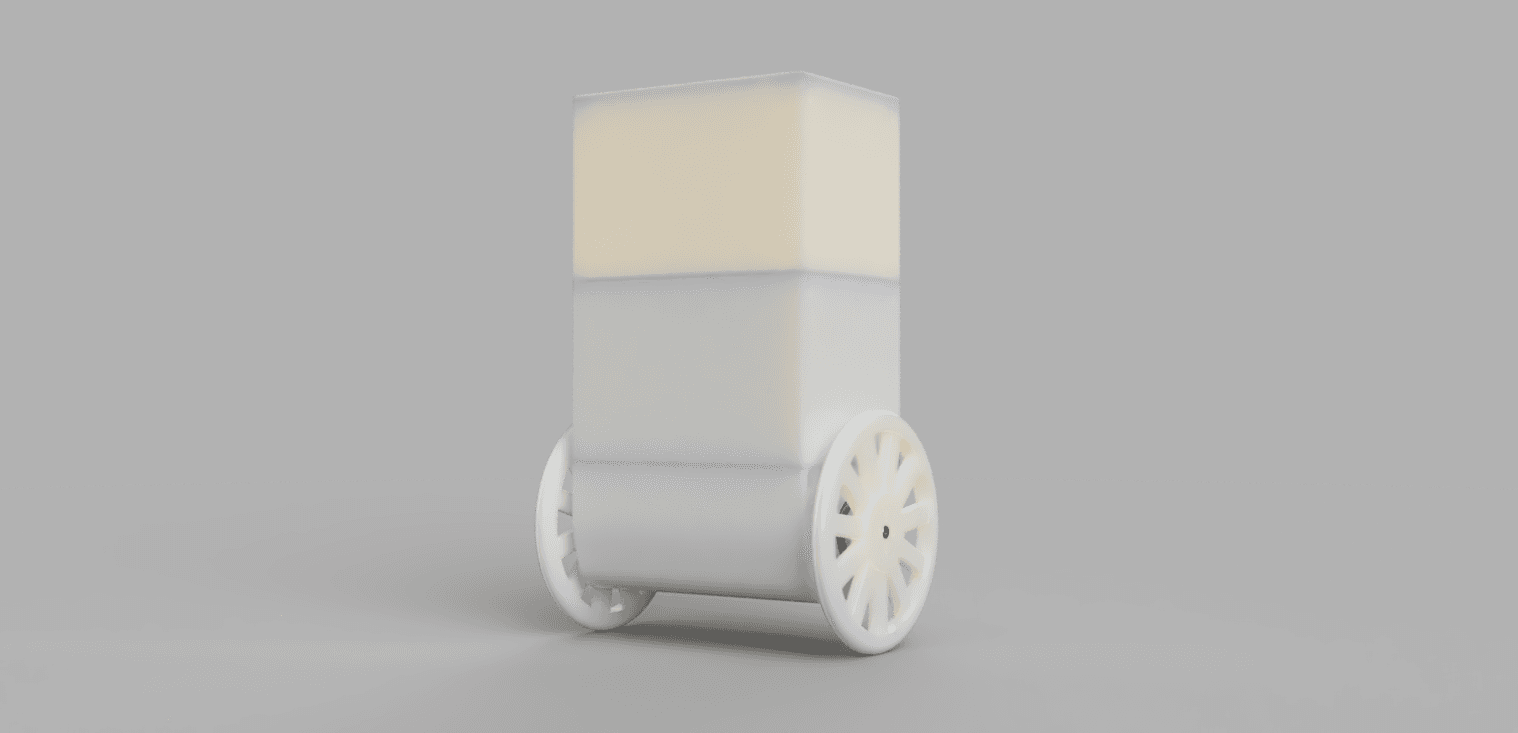
A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.
An open-source two-finger adaptive gripper inspired by the Robotiq design.
Robots 25–42 of 42