SoftRafts
A modular soft robot that bends, steers, connects with magnets and swims with a propeller, usable as a gripper, floating raft or snake-like chain.
- Other
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @smile-robotics-lab (opens in a new tab), from github.com/smile-robotics-lab/SoftRafts (opens in a new tab). Pinned to commit 08b94d5 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
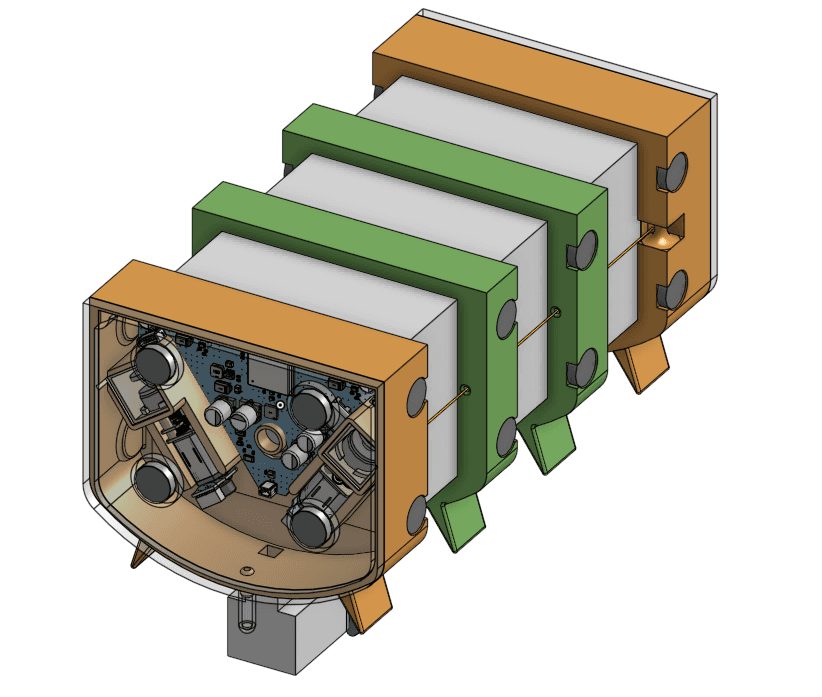
The 3D files are too large to show here. View the original files from GitHub (117.2 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Modules can bend, steer, connect magnetically, and work together as a swarm
- Acts as a gripper to retrieve debris from water
- Can assemble into a floating raft for drone landing
- Can form a snake-like chain transitioning between land and water
- Can collaboratively transport payloads
- Controlled over Wi-Fi via HTTP commands on port 80 for setting motor targets and power, reading status, calibrating, and pausing
- Controls three motors: two actuators and one propulsion motor
- Reports battery voltage, motor errors, and pause state
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @smile-robotics-lab (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-S2 microcontroller on each module
- Two quadrature encoders for motors M1 and M2
- Three motors: two actuators and one propulsion
- Battery with voltage reporting
- PCB designs (Main, Encoder, Power) provided as Gerber archives, contents not described in documents
- 3D-printed structural parts, soft foam, cable-driven winch, and a propeller
Connections
- Encoders provide quadrature position feedback for M1 and M2
- Separate Gerber files suggest a main board, an encoder board, and a power board, but connections are not described