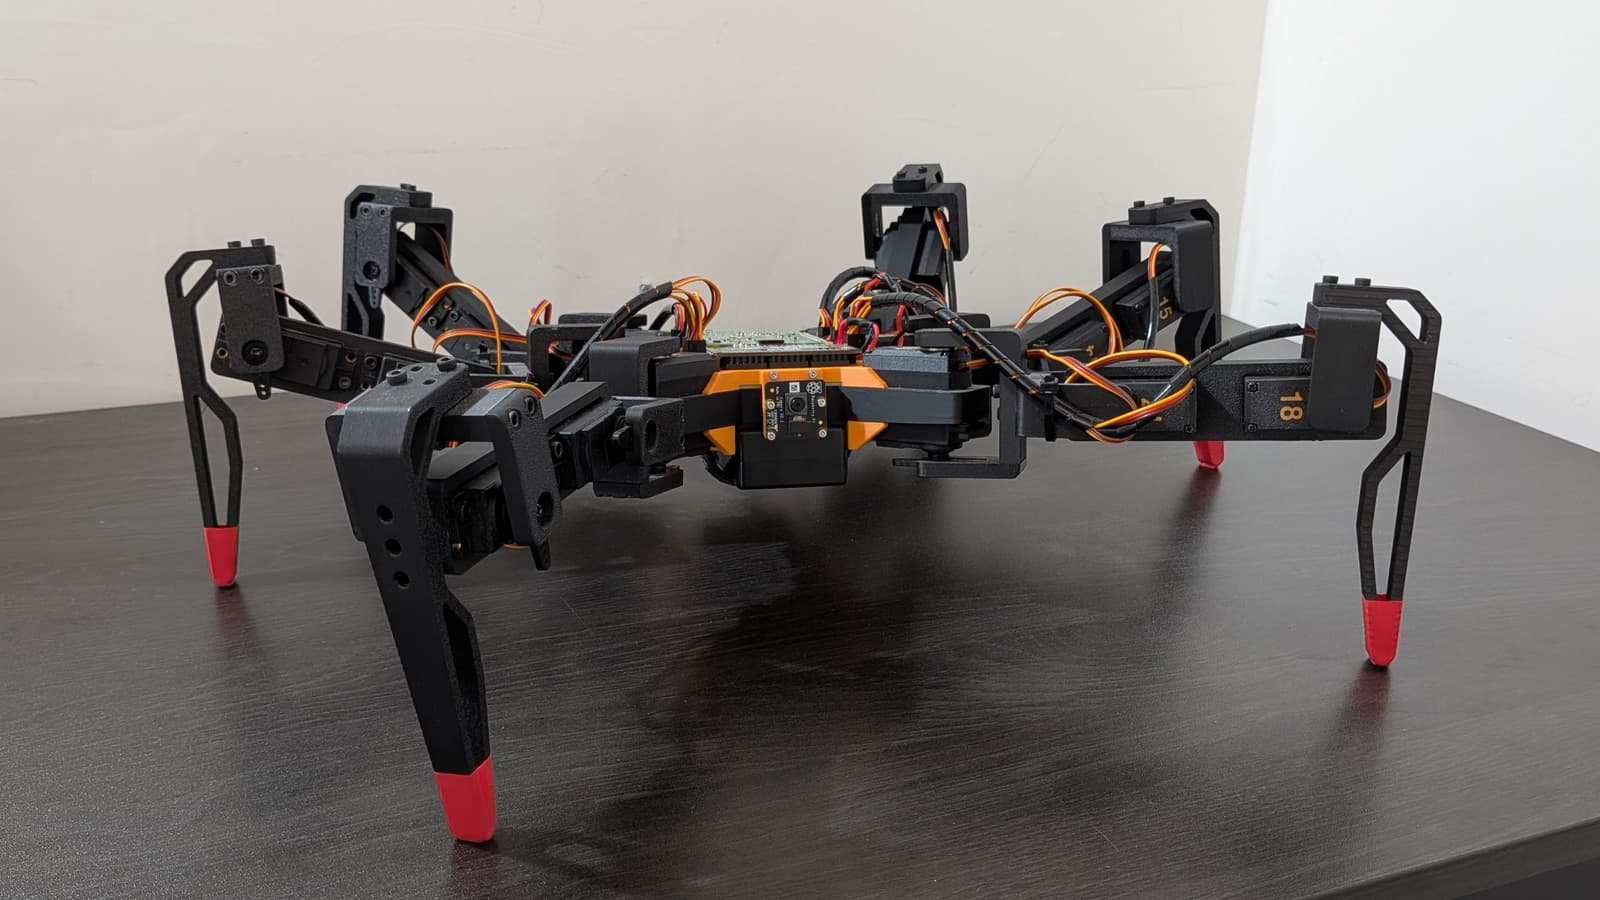
Hexapod
A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.
OtherAdvancedBuildability 71/100 · Buildable with some effort
€280
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.
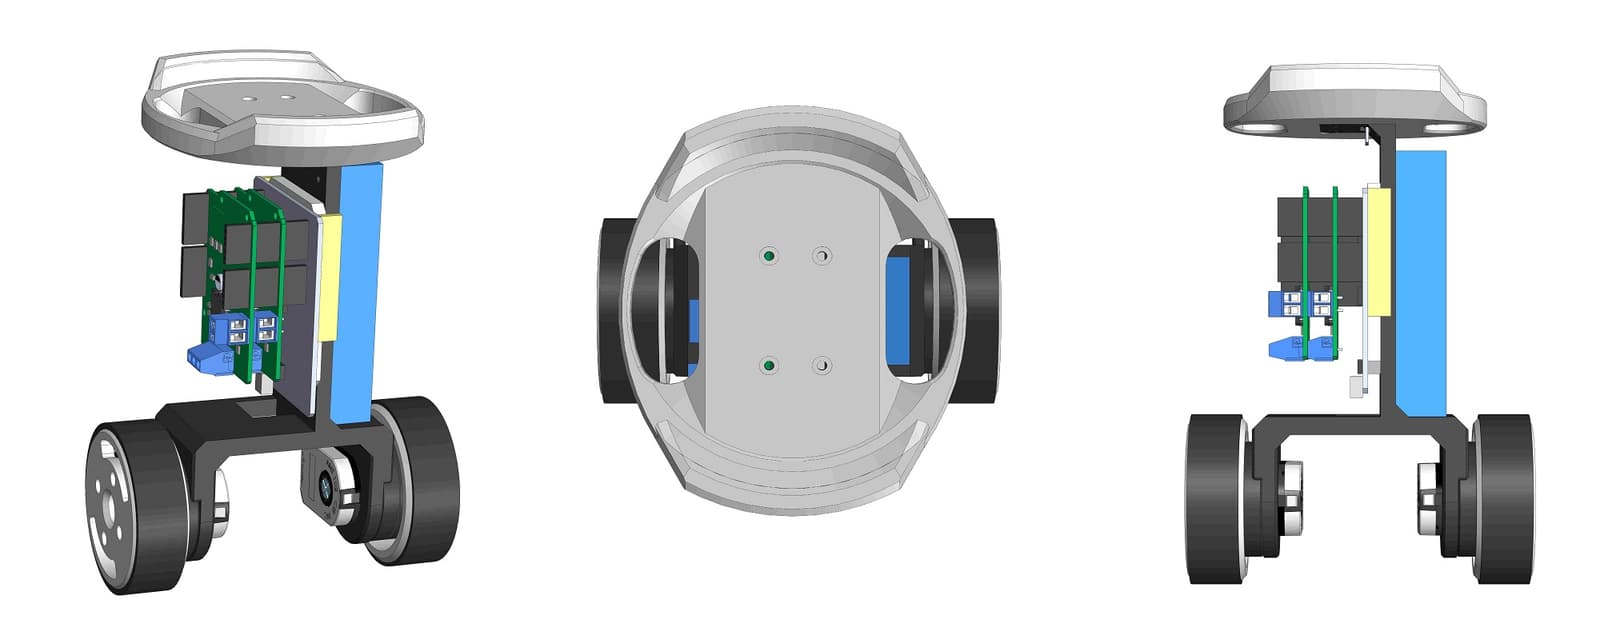
A modular two-wheel self-balancing robot driven by gimbal BLDC motors and the SimpleFOC library.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
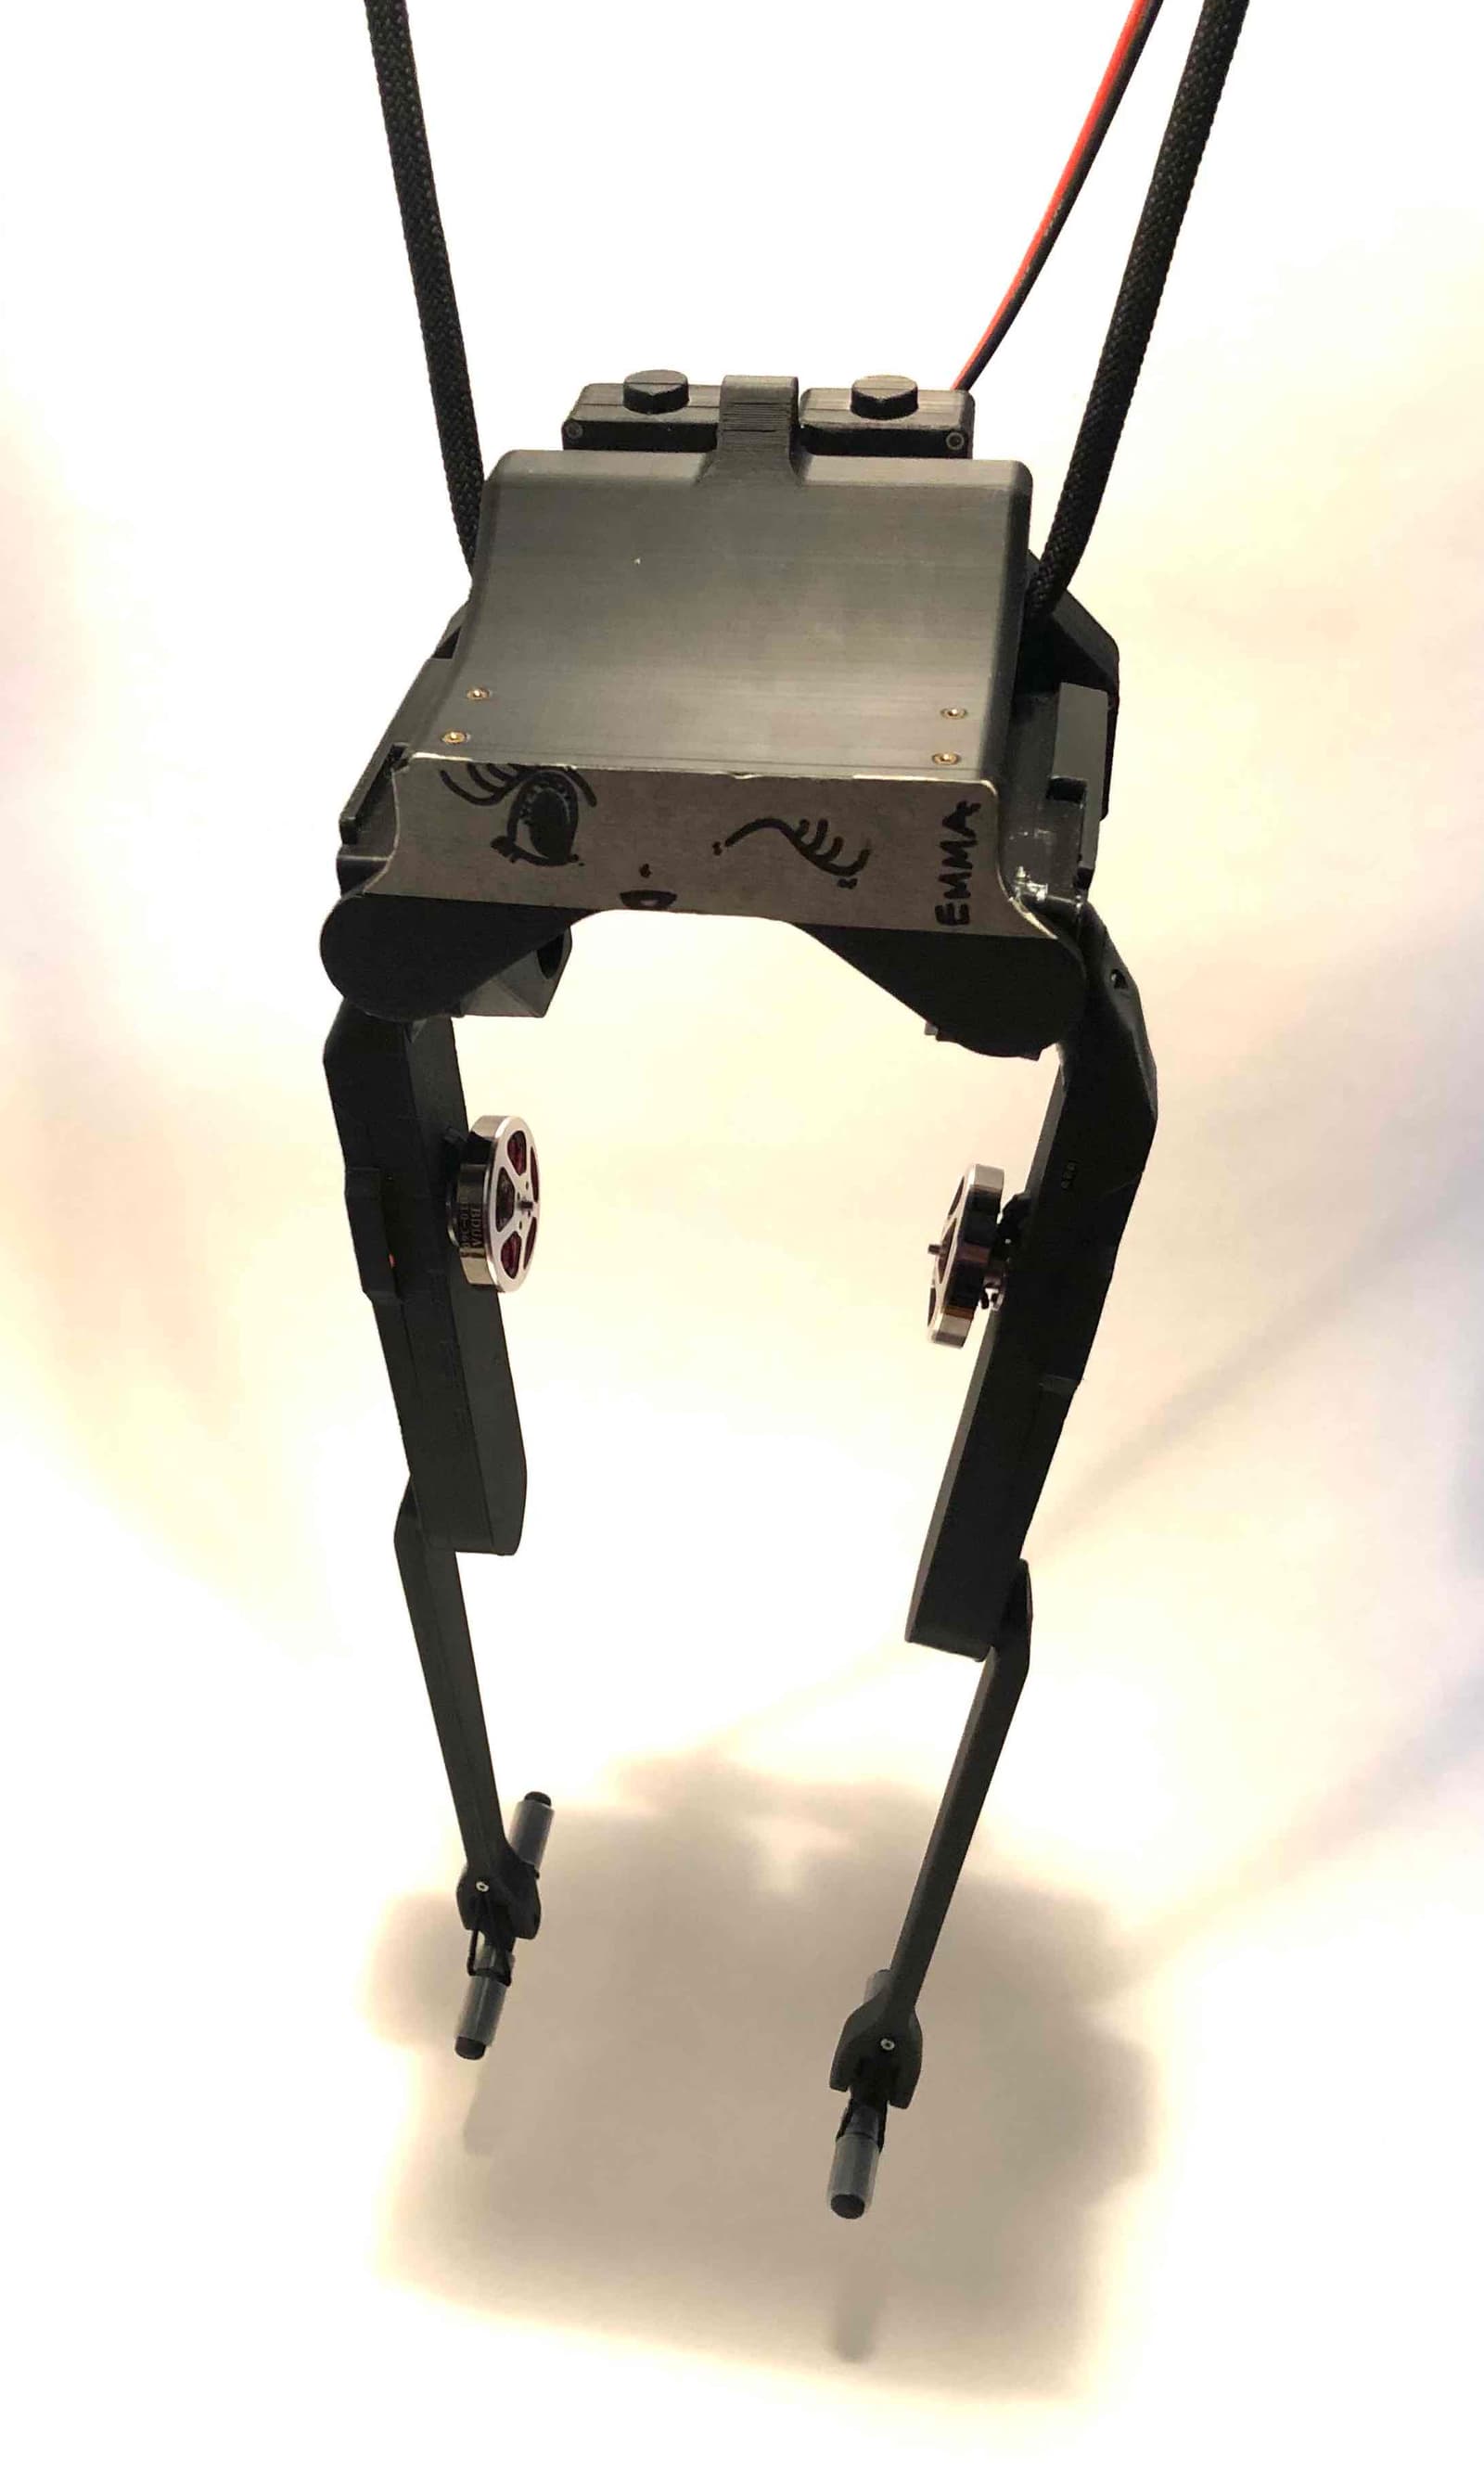
A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.
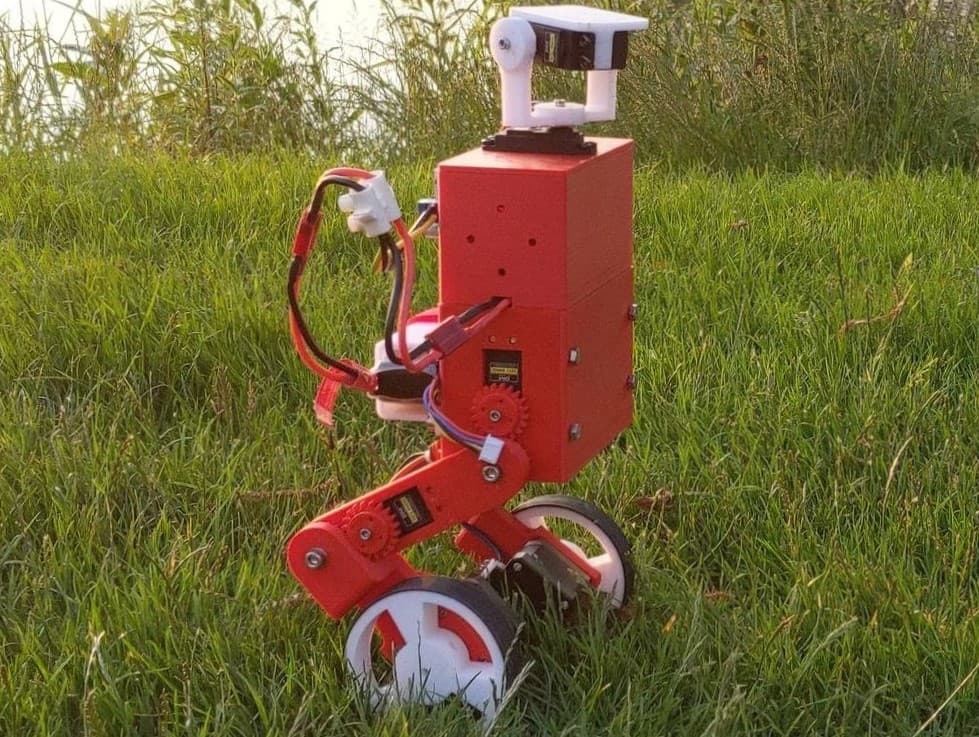
MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.

A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.

A minimalist underactuated brachiating robot that swings along a horizontal ladder bar using one quasi-direct drive actuator and passive grippers.
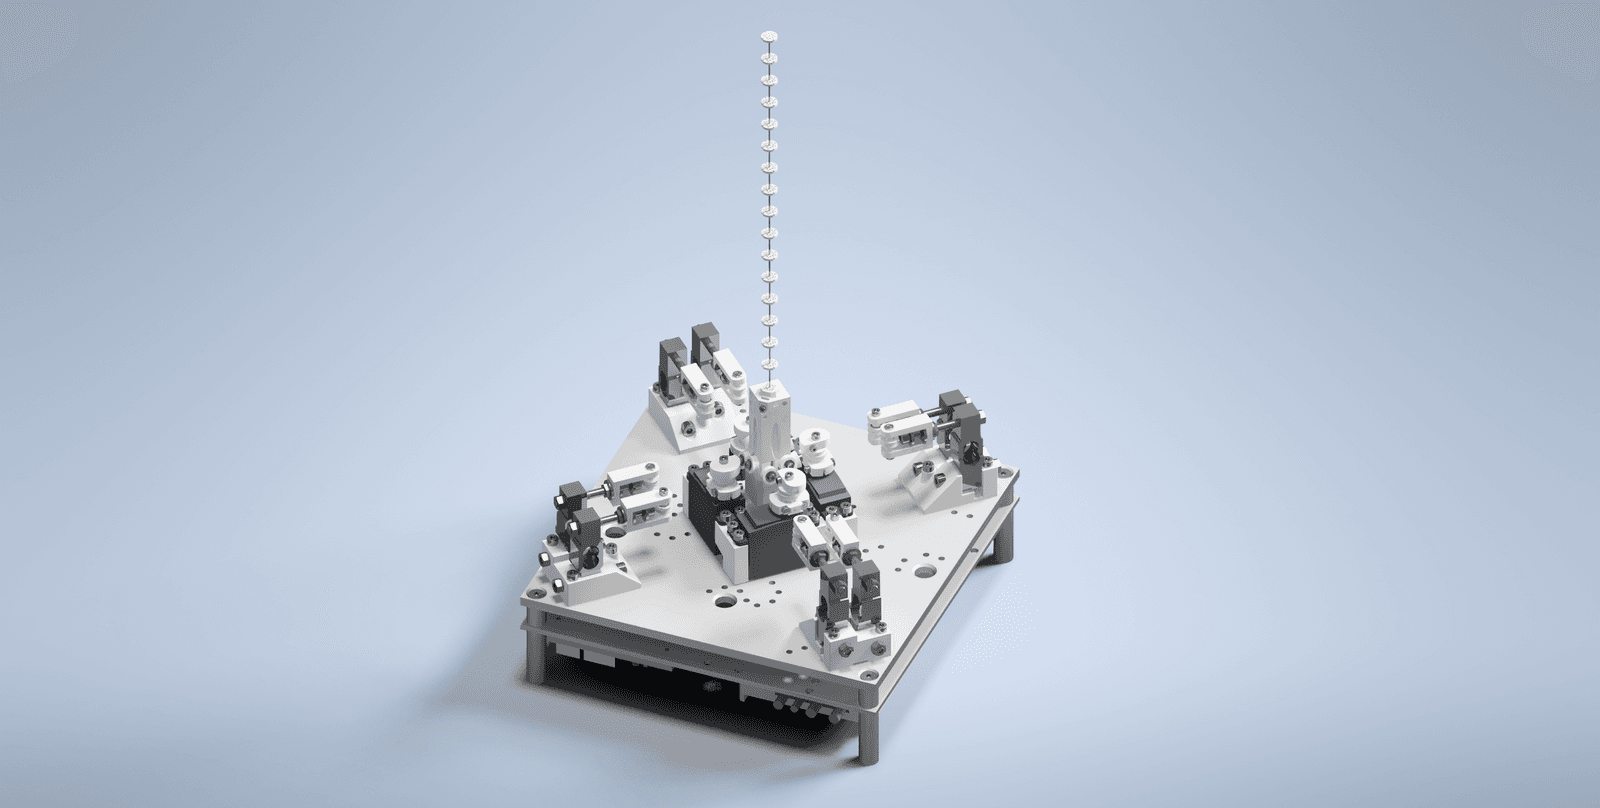
A research continuum robot with 4 degrees of freedom that drives two tendons per antagonistic pair with a single servo and measures tendon force with load cells.
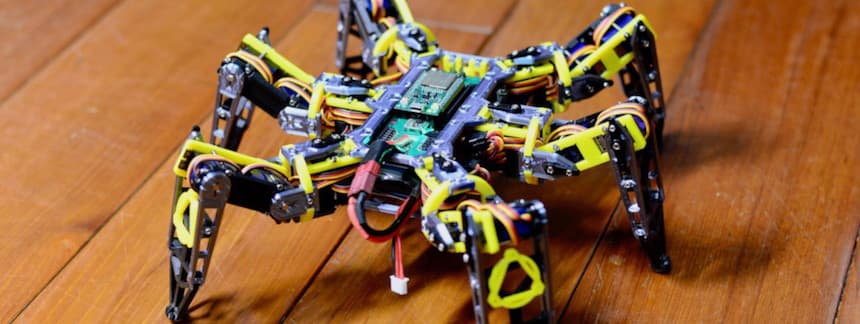
A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.
A two-wheeled, four-bar-linkage wheel-leg balancing robot modeled on the ASCENTO, controlled with LQR on an STM32H723 board.

A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.
An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
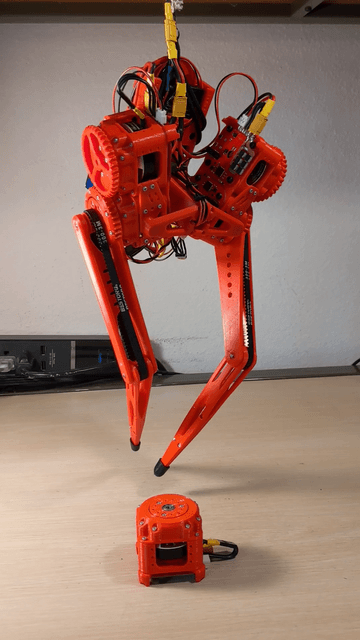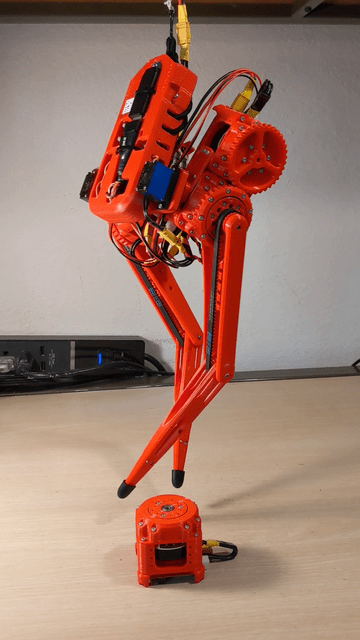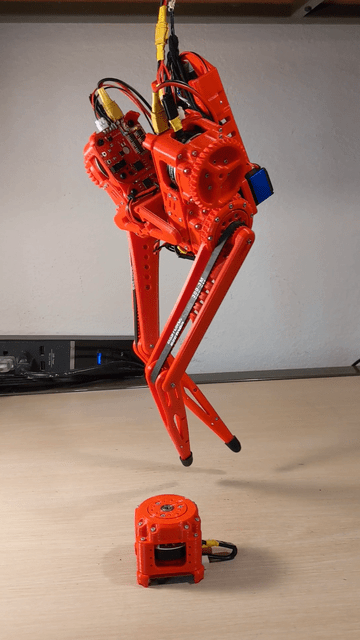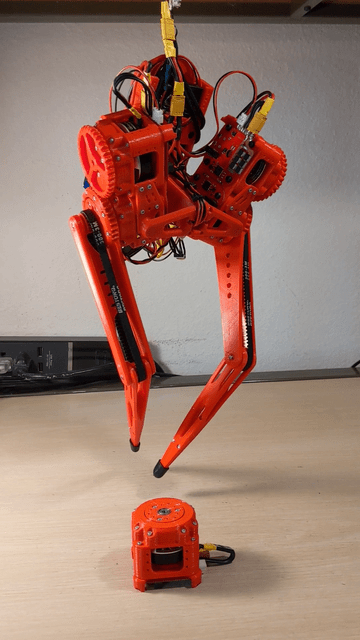
A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.
Open-source wheeled biped robot with wheels for balance and legs for uneven terrain, controllable in simulation and on hardware.
A wheel-legged balancing robot with leg-joint motors and hub-wheel motors, controlled by a custom STM32H723 board using LQR and VMC.
A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
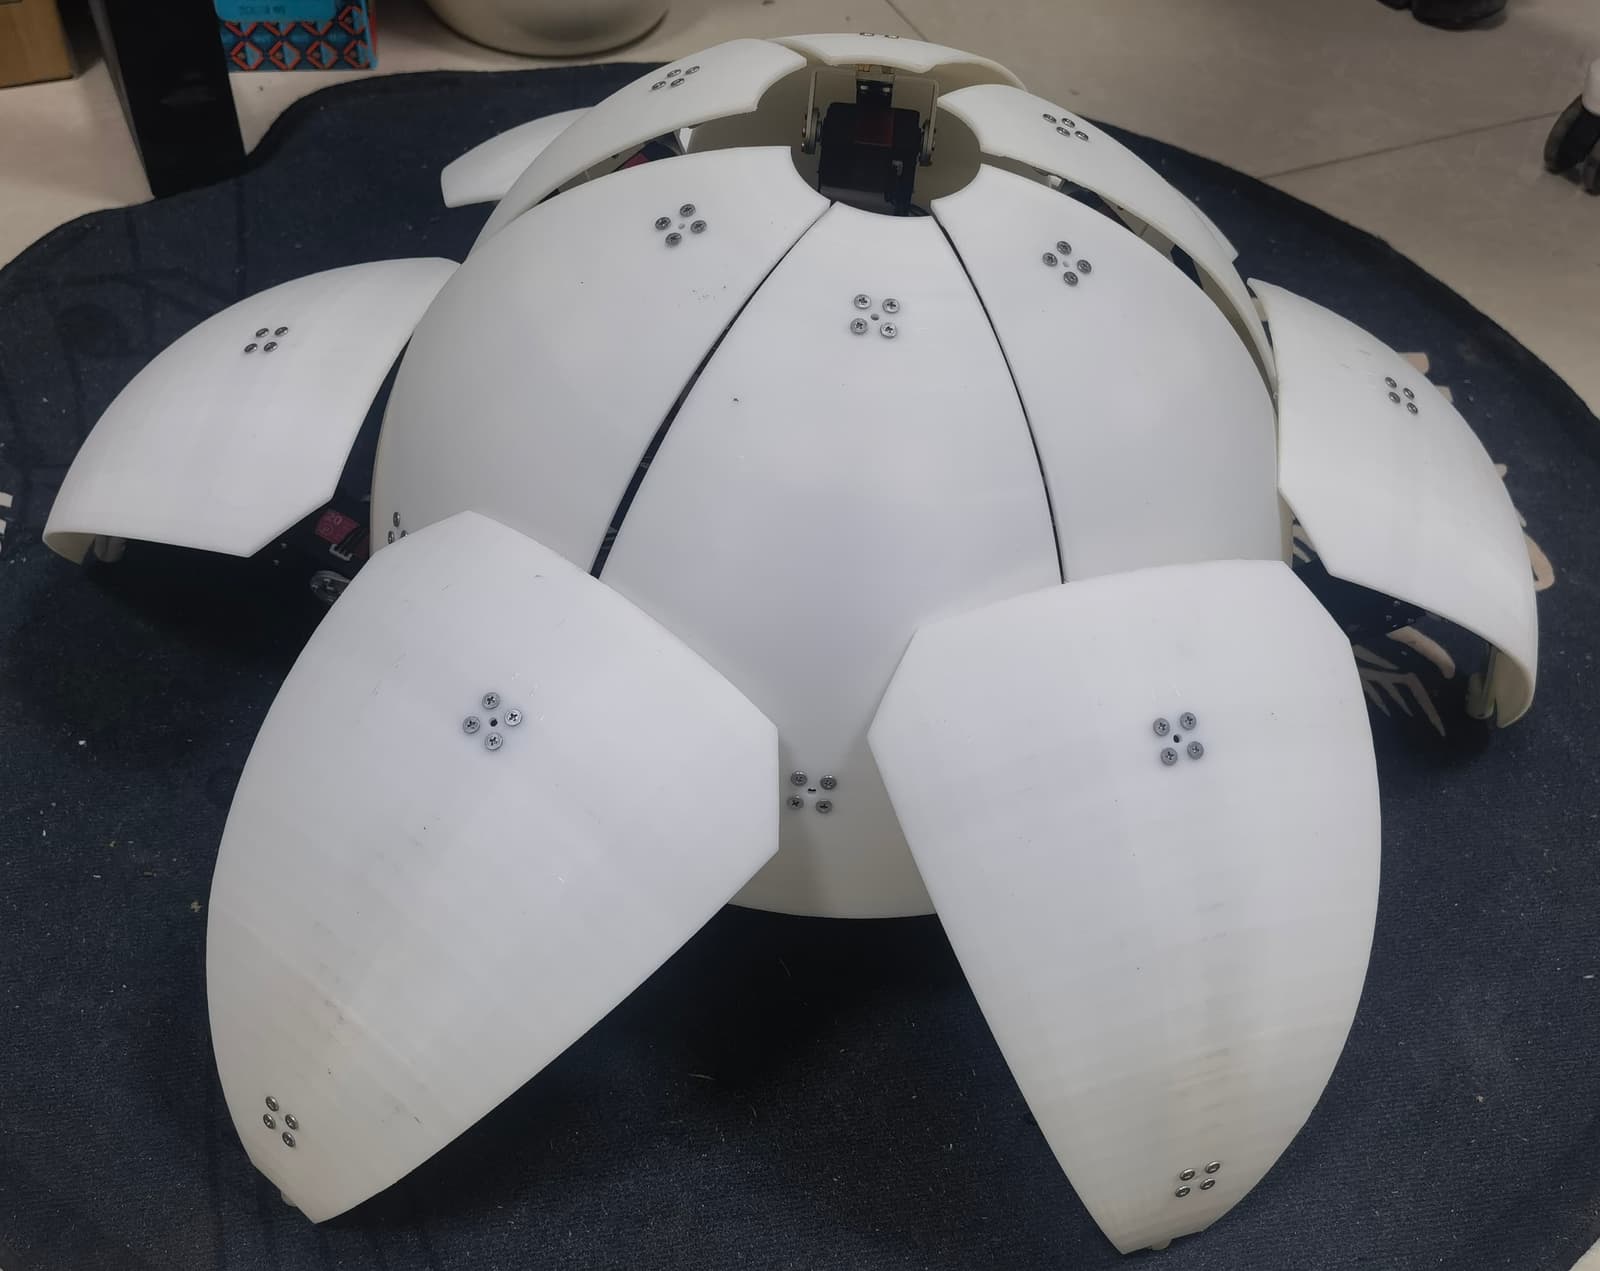
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
An open-source 6-DOF anthropomorphic robotic hand with linkage-based fingers and worm-and-rack transmissions, intended as a low-cost platform for research and education.
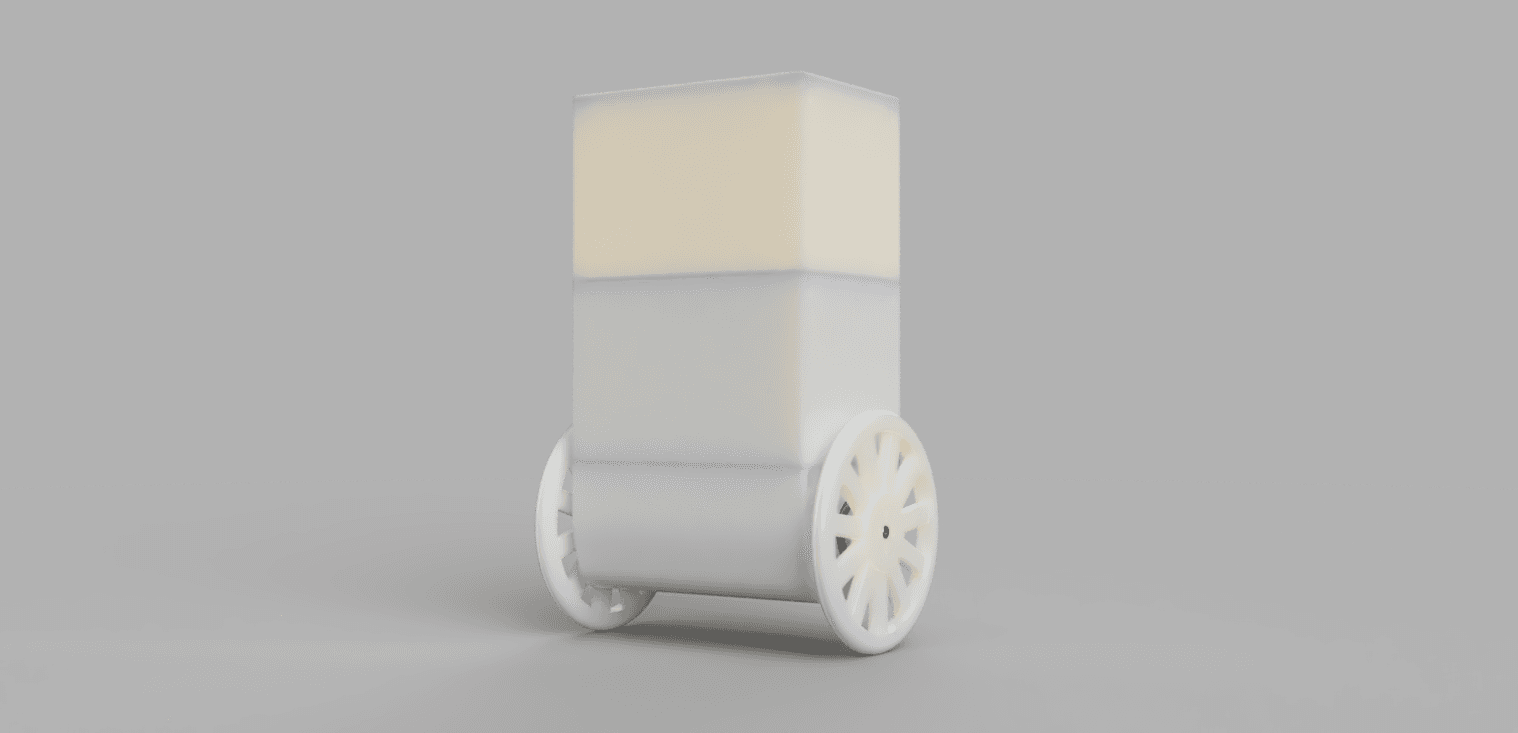
A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.
Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.
An underwater robot made by team 105, sea version: its control programs and the circuit boards of the main board and the power compartment.