 Drone
SUPER MAV
A safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
- Level
- Advanced
- Buildability
- 64/100
- Buildable with some effort
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
DroneA safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
 Drone
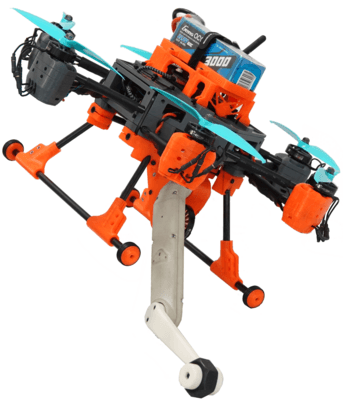
An open-source, torque-controlled aerial loco-manipulator whose extremity can be reconfigured as a tail for flight, a hand for manipulation, or a leg for hybrid aerial-contact locomotion.
 Drone
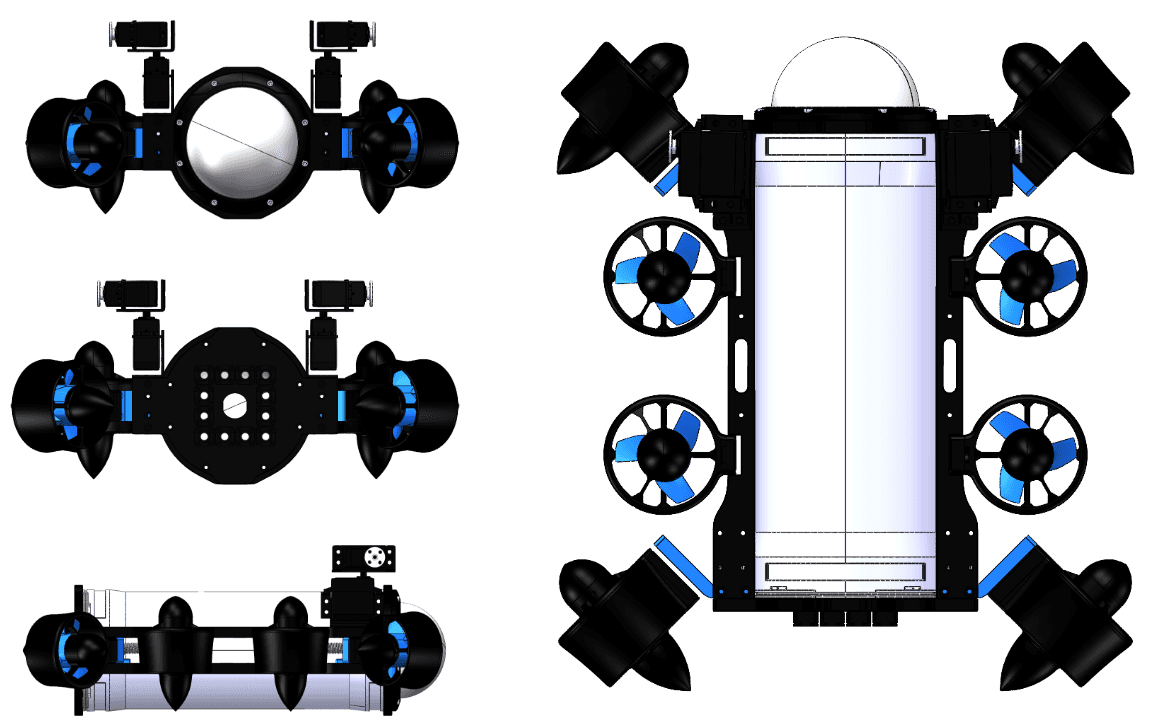
FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
 Drone
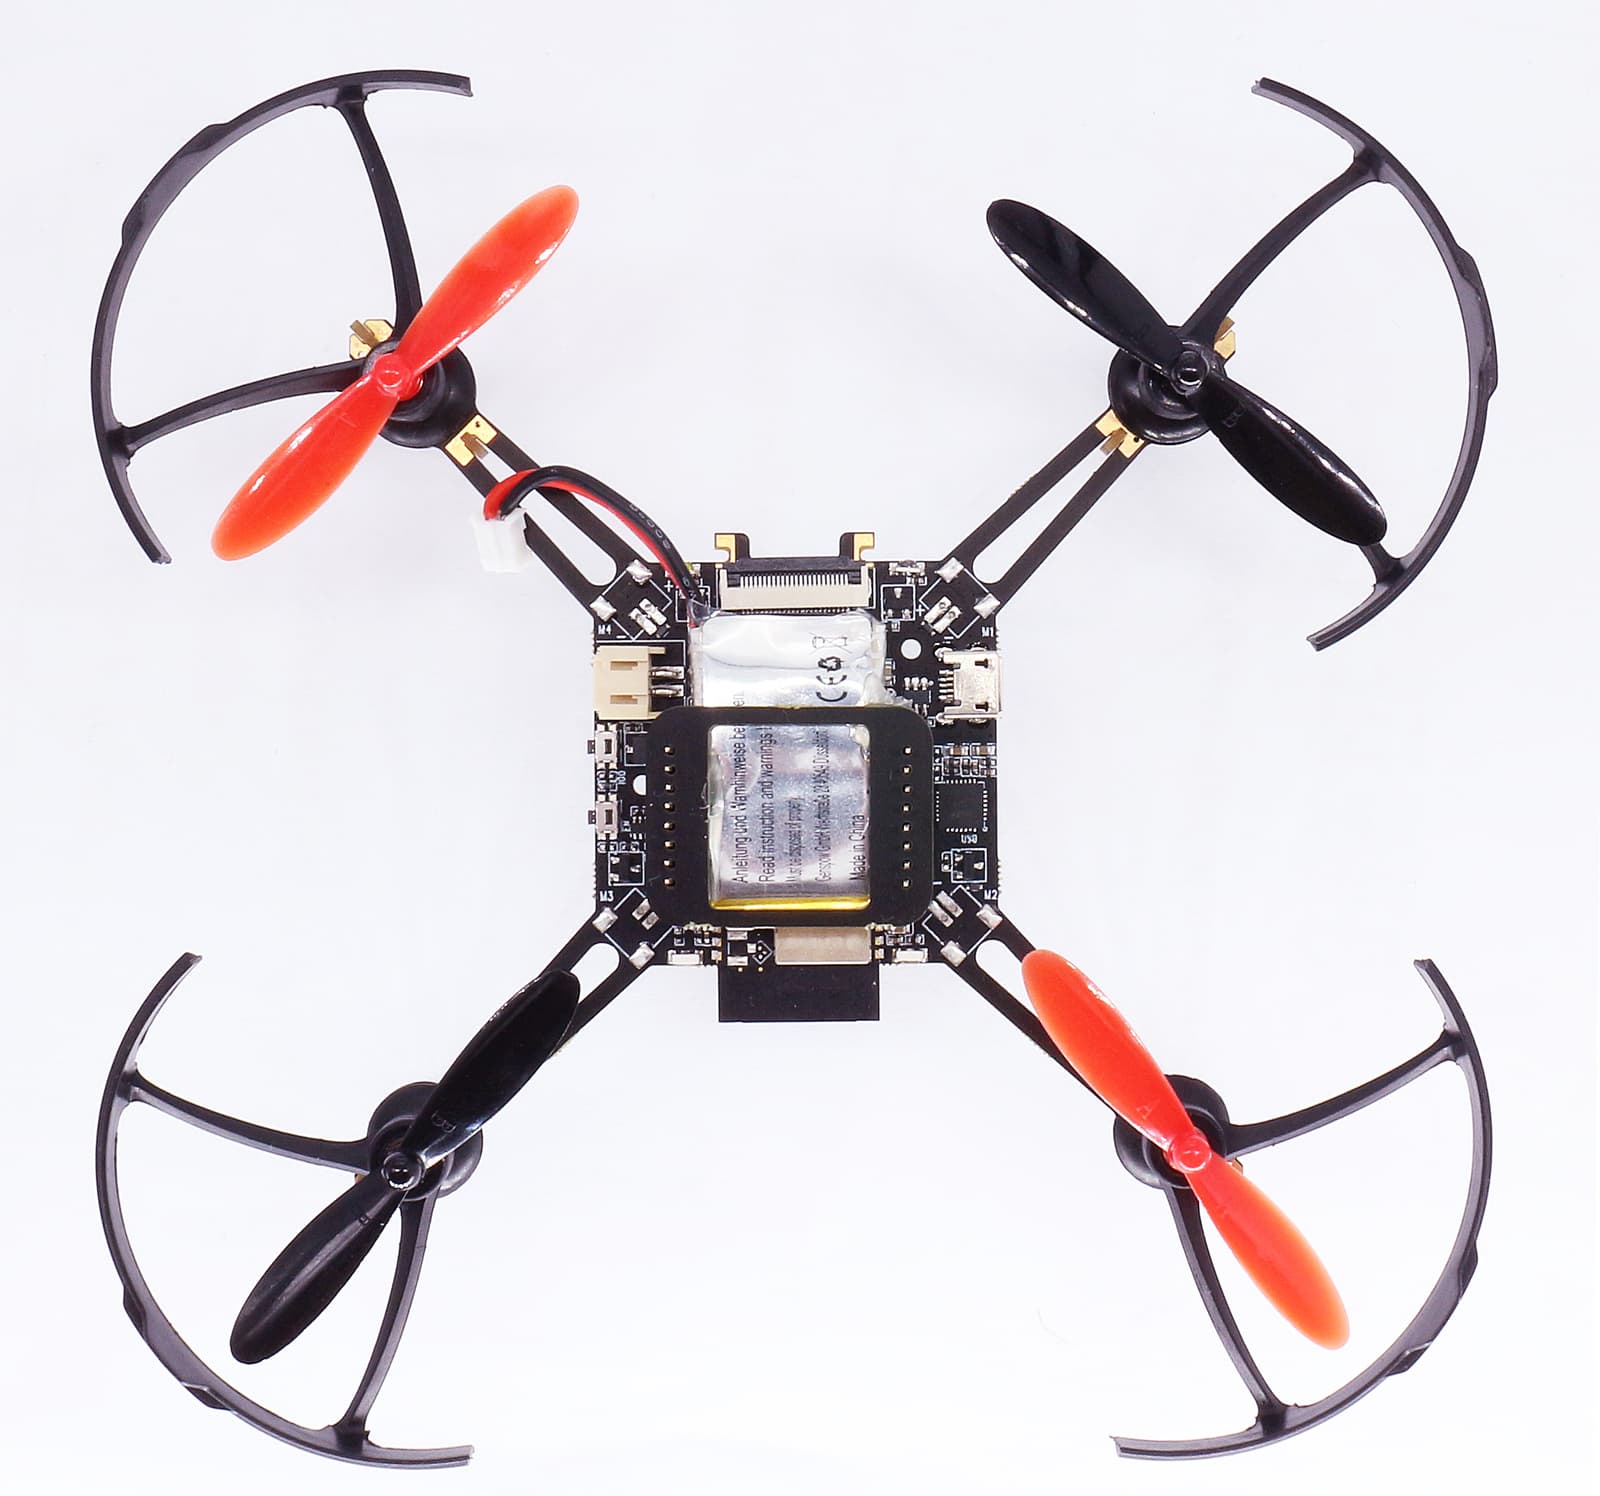
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
A small quadrotor drone based on STM32 that can fly stably.
 Drone
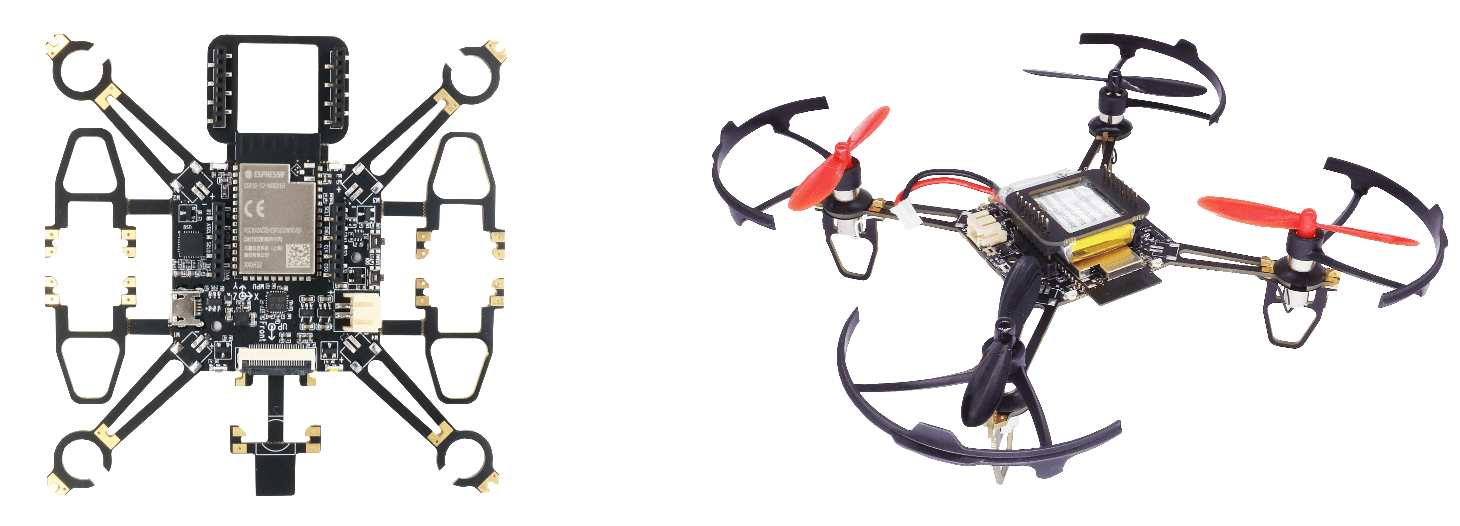
An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.
 Drone
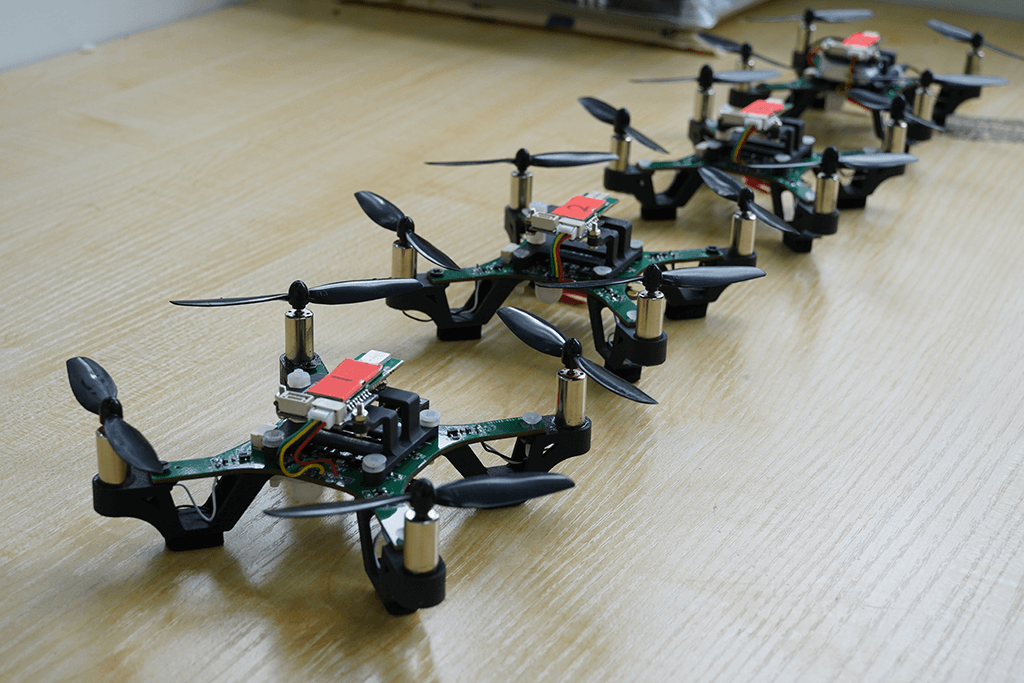
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.
 Drone
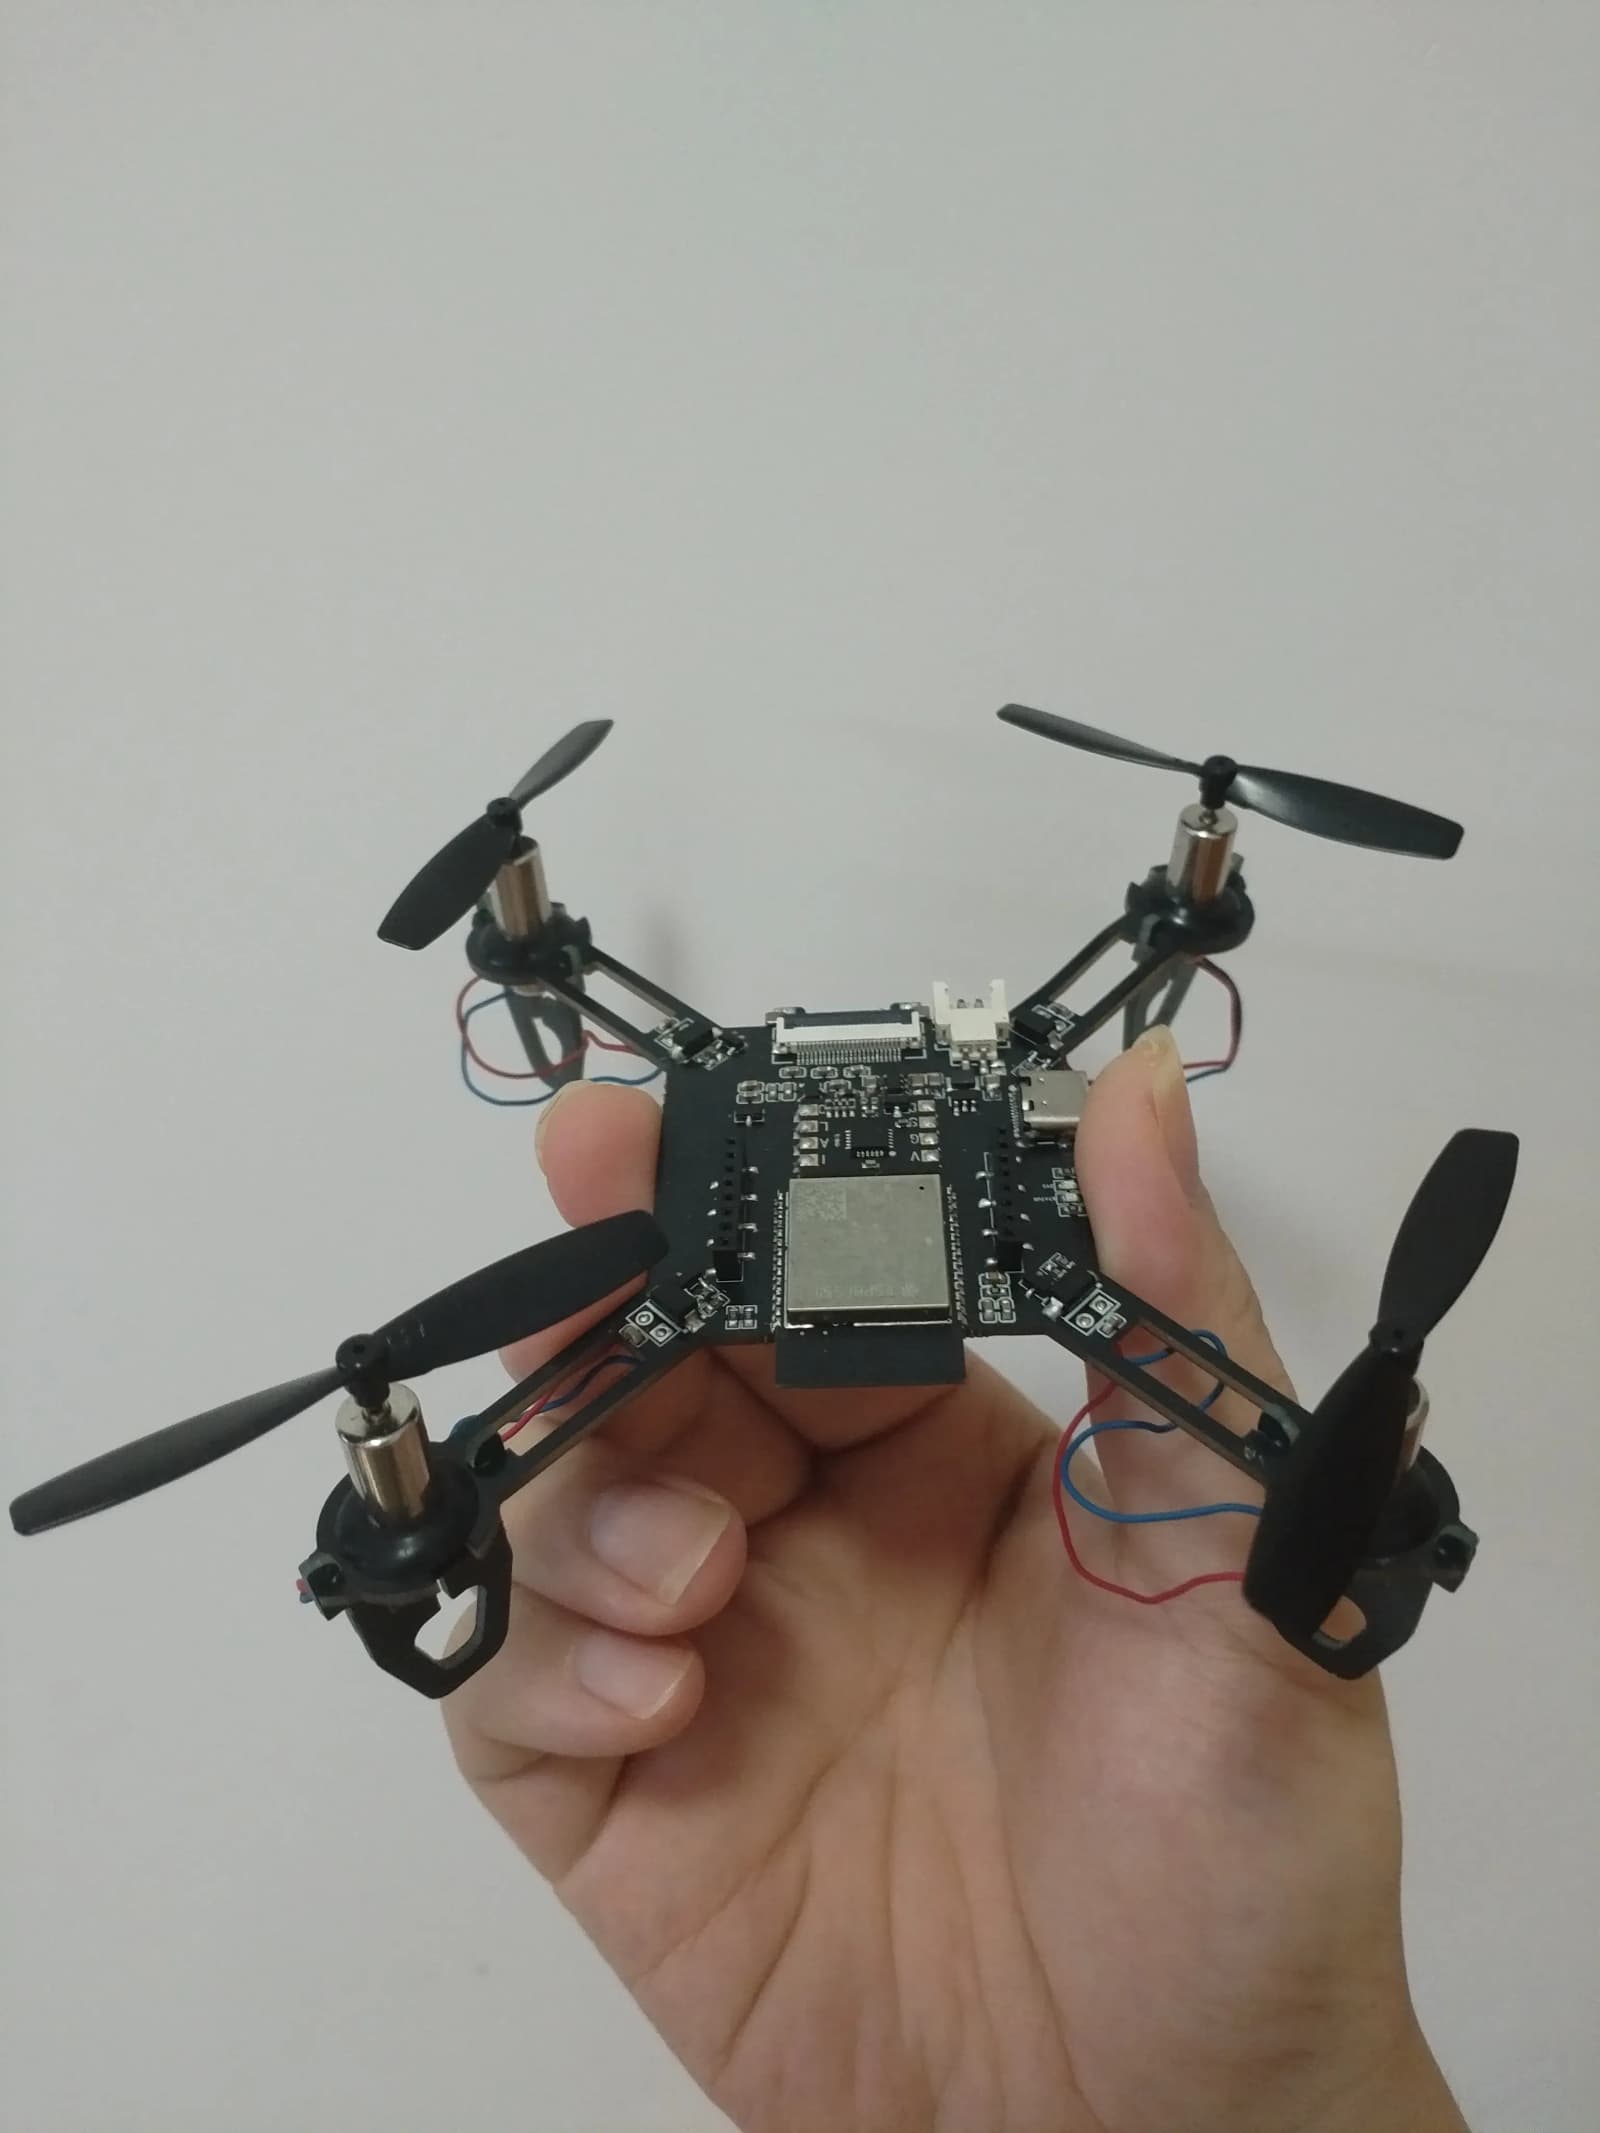
An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.
An open-source quadcopter framework providing schematics and flight control source code.
 Drone
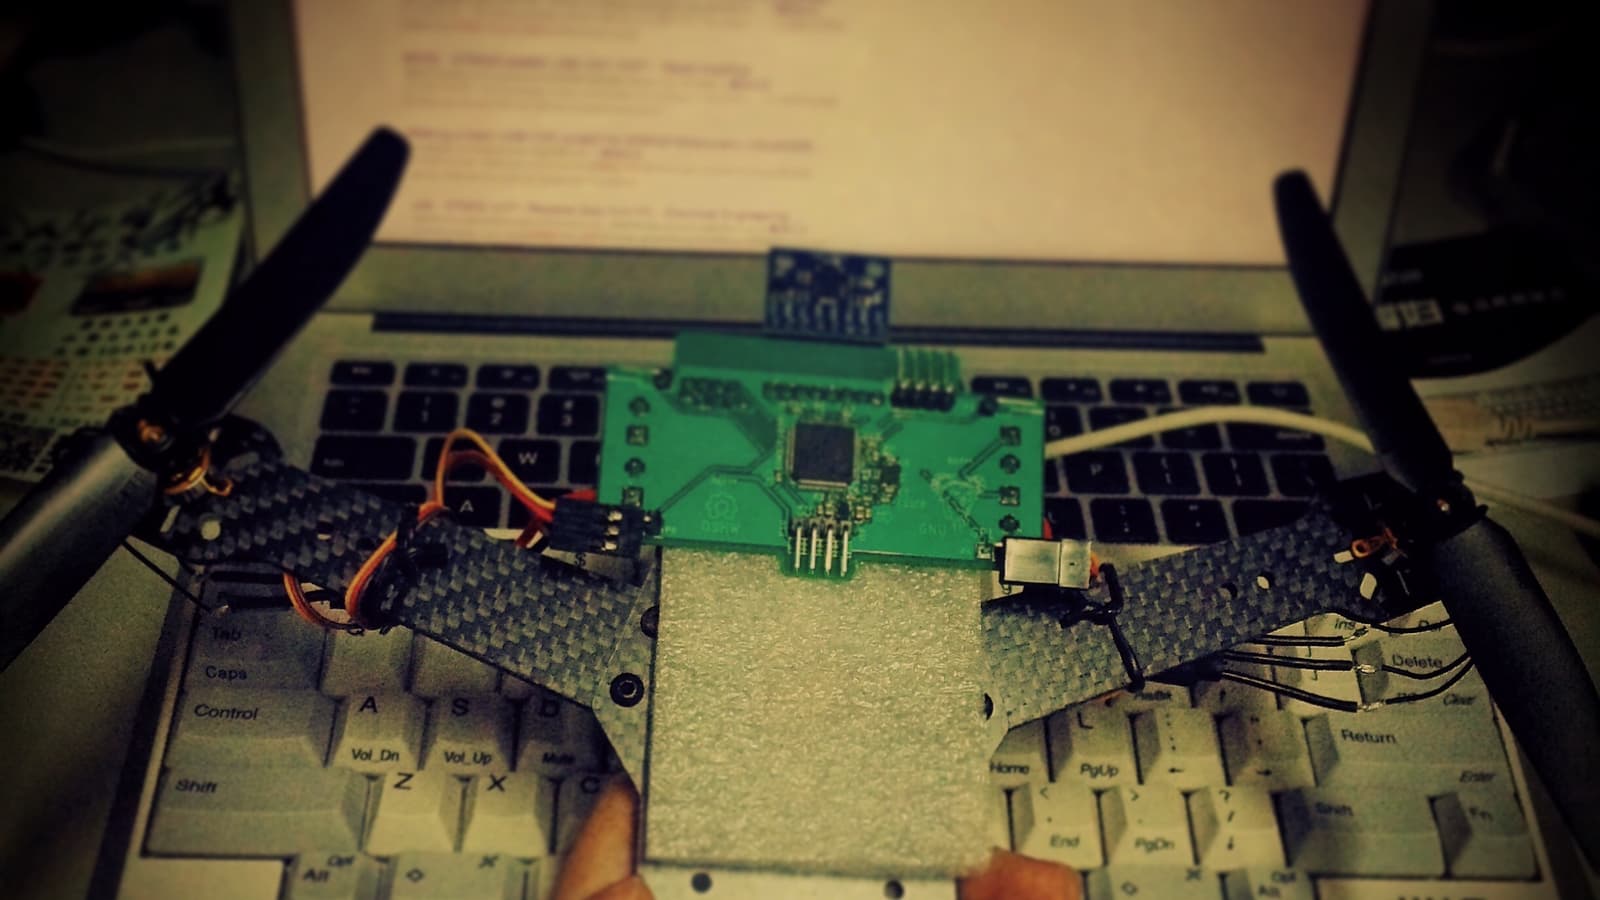
A lightweight drone flight controller using STM32, PID control, and BLDC motors.
A 400mm wheelbase quadcopter drone with full protection, designed for university electronic design competitions.
 Drone
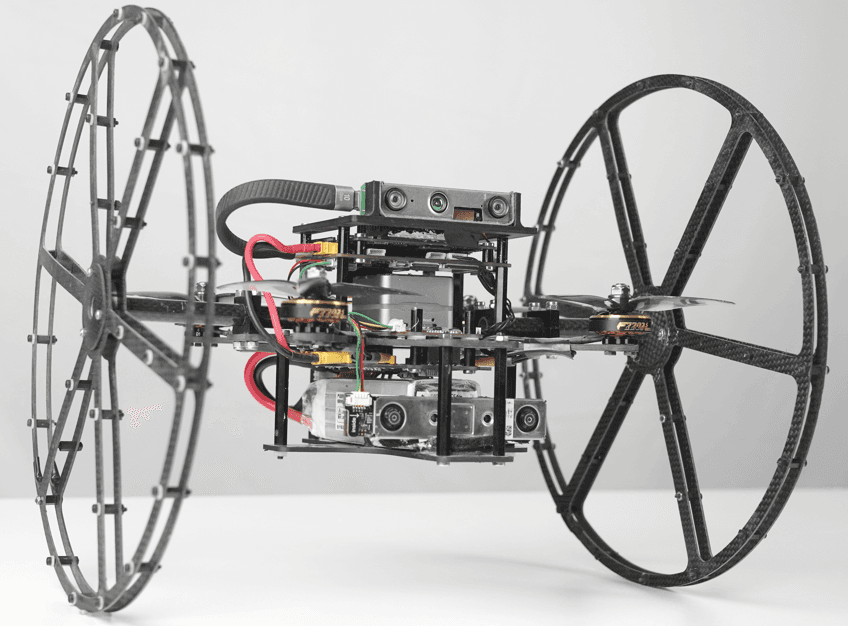
A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.