Tiny-Drone
An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.
- Drone
- Open source
- Work in progress
Suggested by Robotheca, created by @jonny-lekaiwu (opens in a new tab), from github.com/jonny-lekaiwu/Tiny-Drone (opens in a new tab). Pinned to commit 56d88a3 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Some folders have their own license: components/espressif__esp_jpeg/ (Apache-2.0), components/espressif__esp32-camera/ (Apache-2.0).
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (2 scripts, 1 program or installer, 8 firmware images)
- all_flash.bin (opens in a new tab)
- assets/bin/bootloader.bin (opens in a new tab)
- assets/bin/nvs.bin (opens in a new tab)
- assets/bin/ota_data_initial.bin (opens in a new tab)
- assets/bin/partition-table.bin (opens in a new tab)
- assets/bin/Tiny-Drone.bin (opens in a new tab)
- assets/TinyDrone-v0.7.19.apk (opens in a new tab)
- build.bat (opens in a new tab)
- combine.bat (opens in a new tab)
- flash_all.bin (opens in a new tab)
- nvs.bin (opens in a new tab)
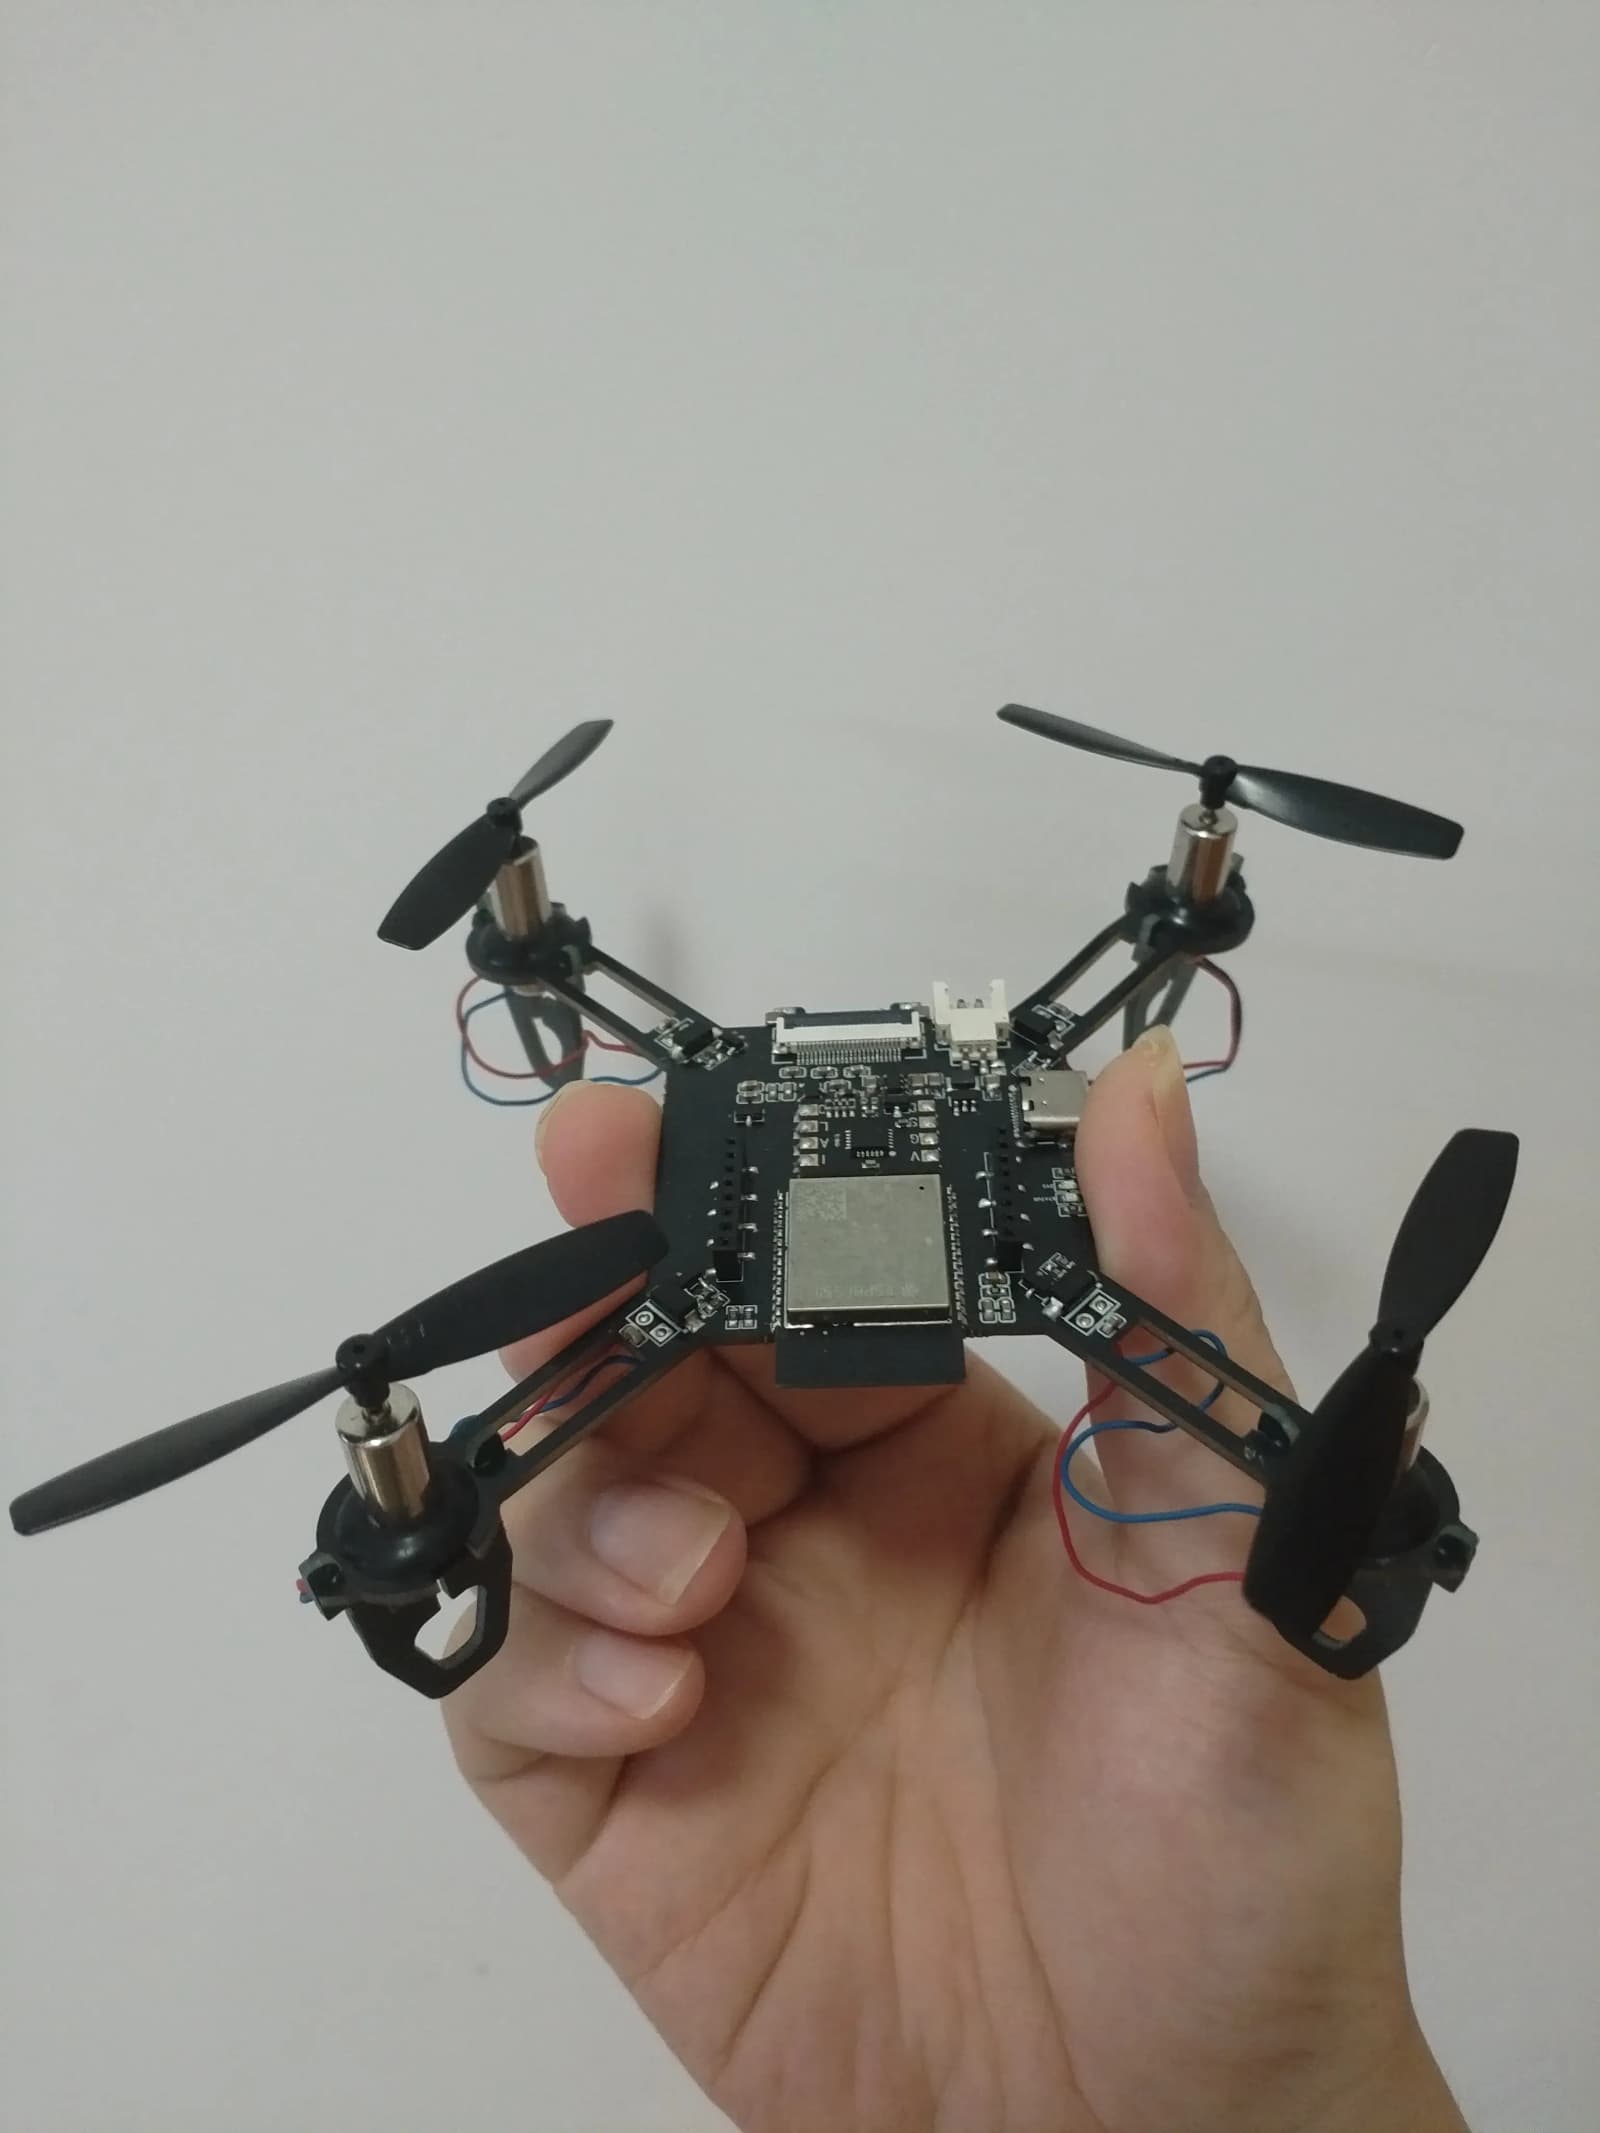
Photo
What it can do
Written by Robotheca from the project's documents.
- Autonomous flight with altitude hold
- Manual flight via Android app
- Manual flight via mobile browser
- Manual flight via remote controller
- Wi-Fi video transmission to phone
- Remote ID broadcasting for outdoor flights
- Supports barometer for altitude hold
- Supports laser ranging for precise height
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Prepare components
- 2Order PCB
- 3Solder components
- 4Assemble hardware
- 5Adjust motor positions and propeller depth
- 6Compile and flash firmware
- 7Perform one-click flashing
- 8Troubleshoot issues
The guide appears here as you scroll.
Guide by @jonny-lekaiwu (README_EN.md), under GPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-S3 microcontroller
- ZY-MPU6050 IMU module
- OV2640 camera module
- 4 brushed DC motors with drivers
- Lithium battery with boost converter and LDO regulator
- SPL06-001 barometer sensor
- VL53L1X laser ranging sensor
- Status and power LEDs
- Wi-Fi radio for control and video
Connections
- ESP32-S3 I2C bus connects to ZY-MPU6050 and SPL06-001
- ESP32-S3 I2S bus connects to OV2640 camera
- ESP32-S3 PWM outputs drive motor drivers
- ESP32-S3 ADC measures battery voltage via voltage divider
- Motor drivers connect to 4 brushed DC motors
- Boost converter output powers ESP32-S3 and sensors
- LDO regulator powers IMU and other low-voltage sensors
