Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

19 robots of 270

Page 1 of 1 · Ready to build first, then by buildability

  • Drone

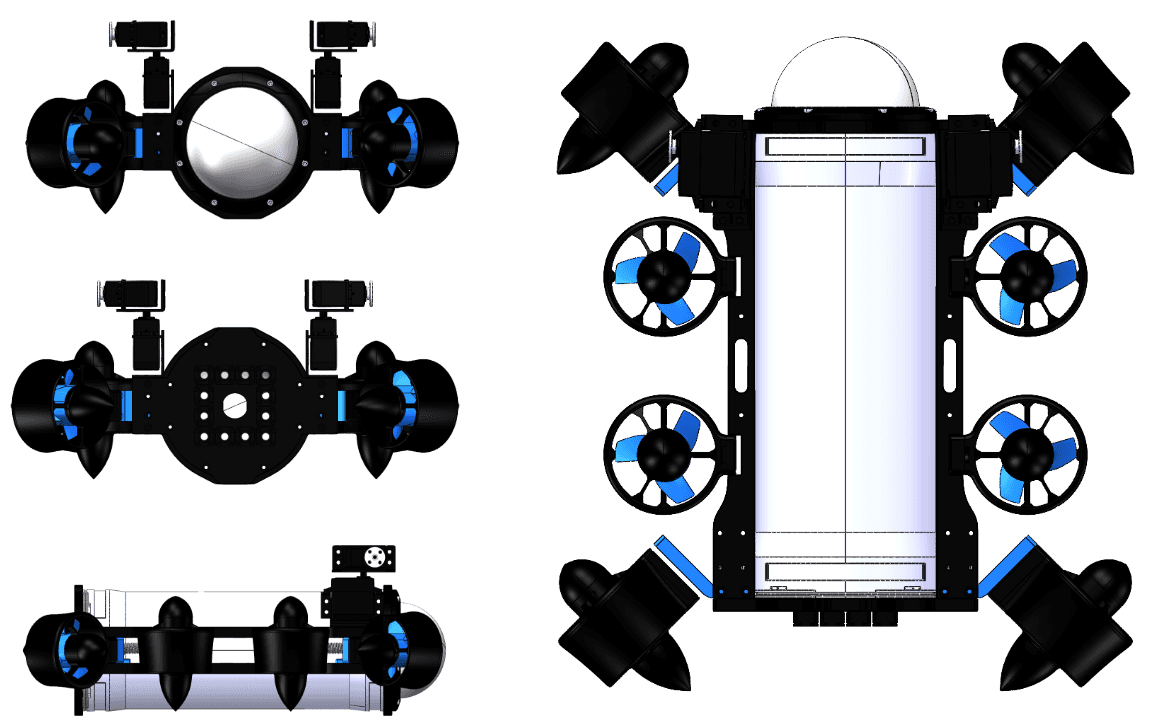
    FinsROV

    FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

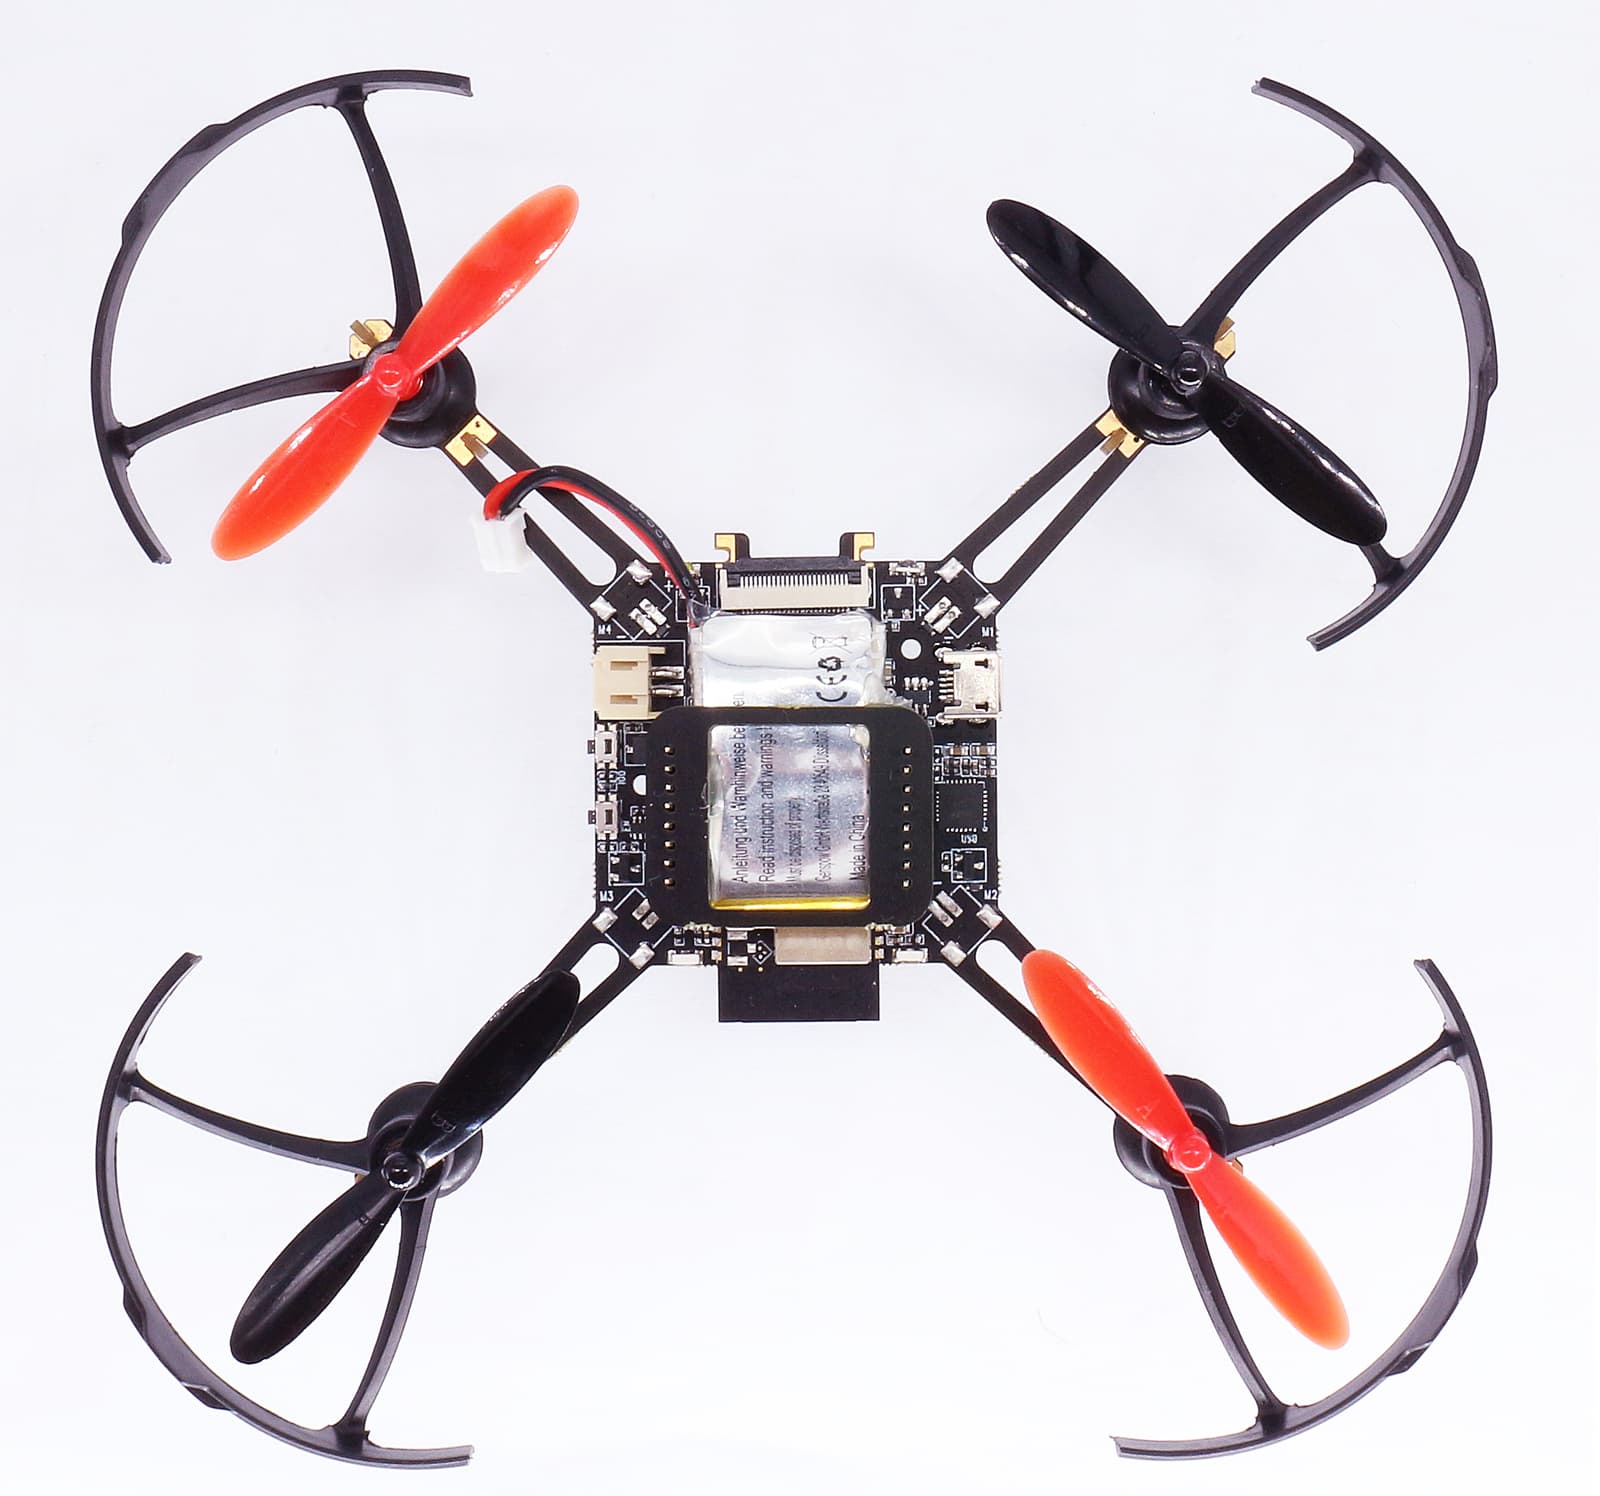
    ESP-Drone

    A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    ziFly Quadcopter Flight Controller

    A quadcopter flight controller based on STM32F103 with remote control, PCB, 3D models, and ROS 2/PX4 simulation support.

    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

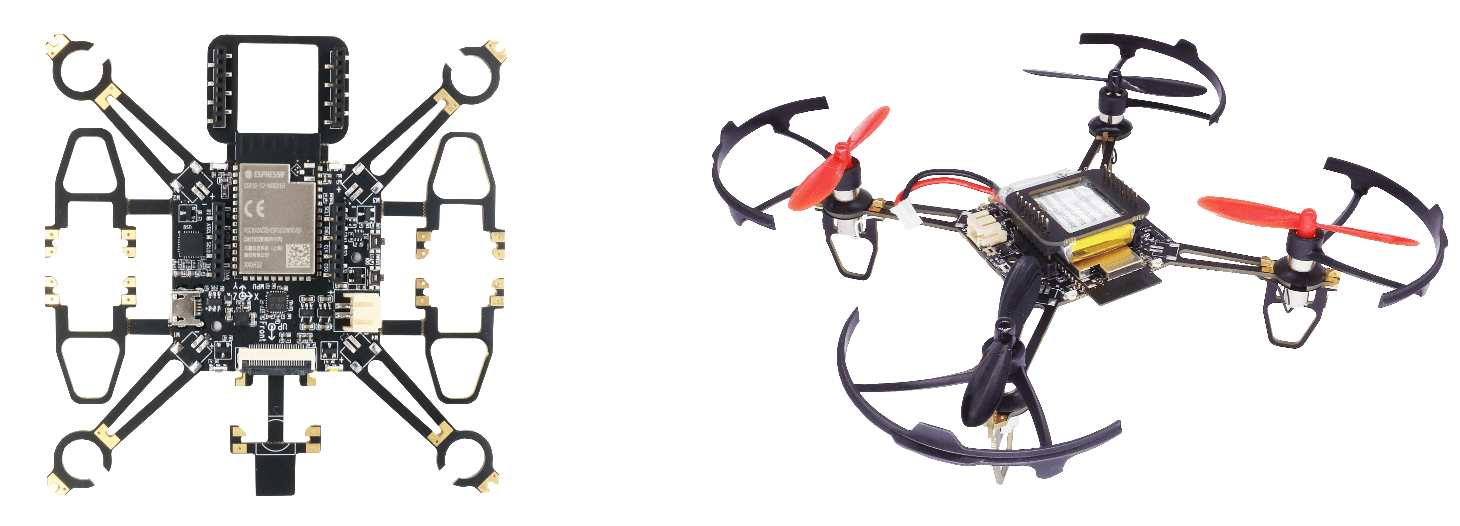
    Airplane

    A small quadrotor drone based on STM32 that can fly stably.
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

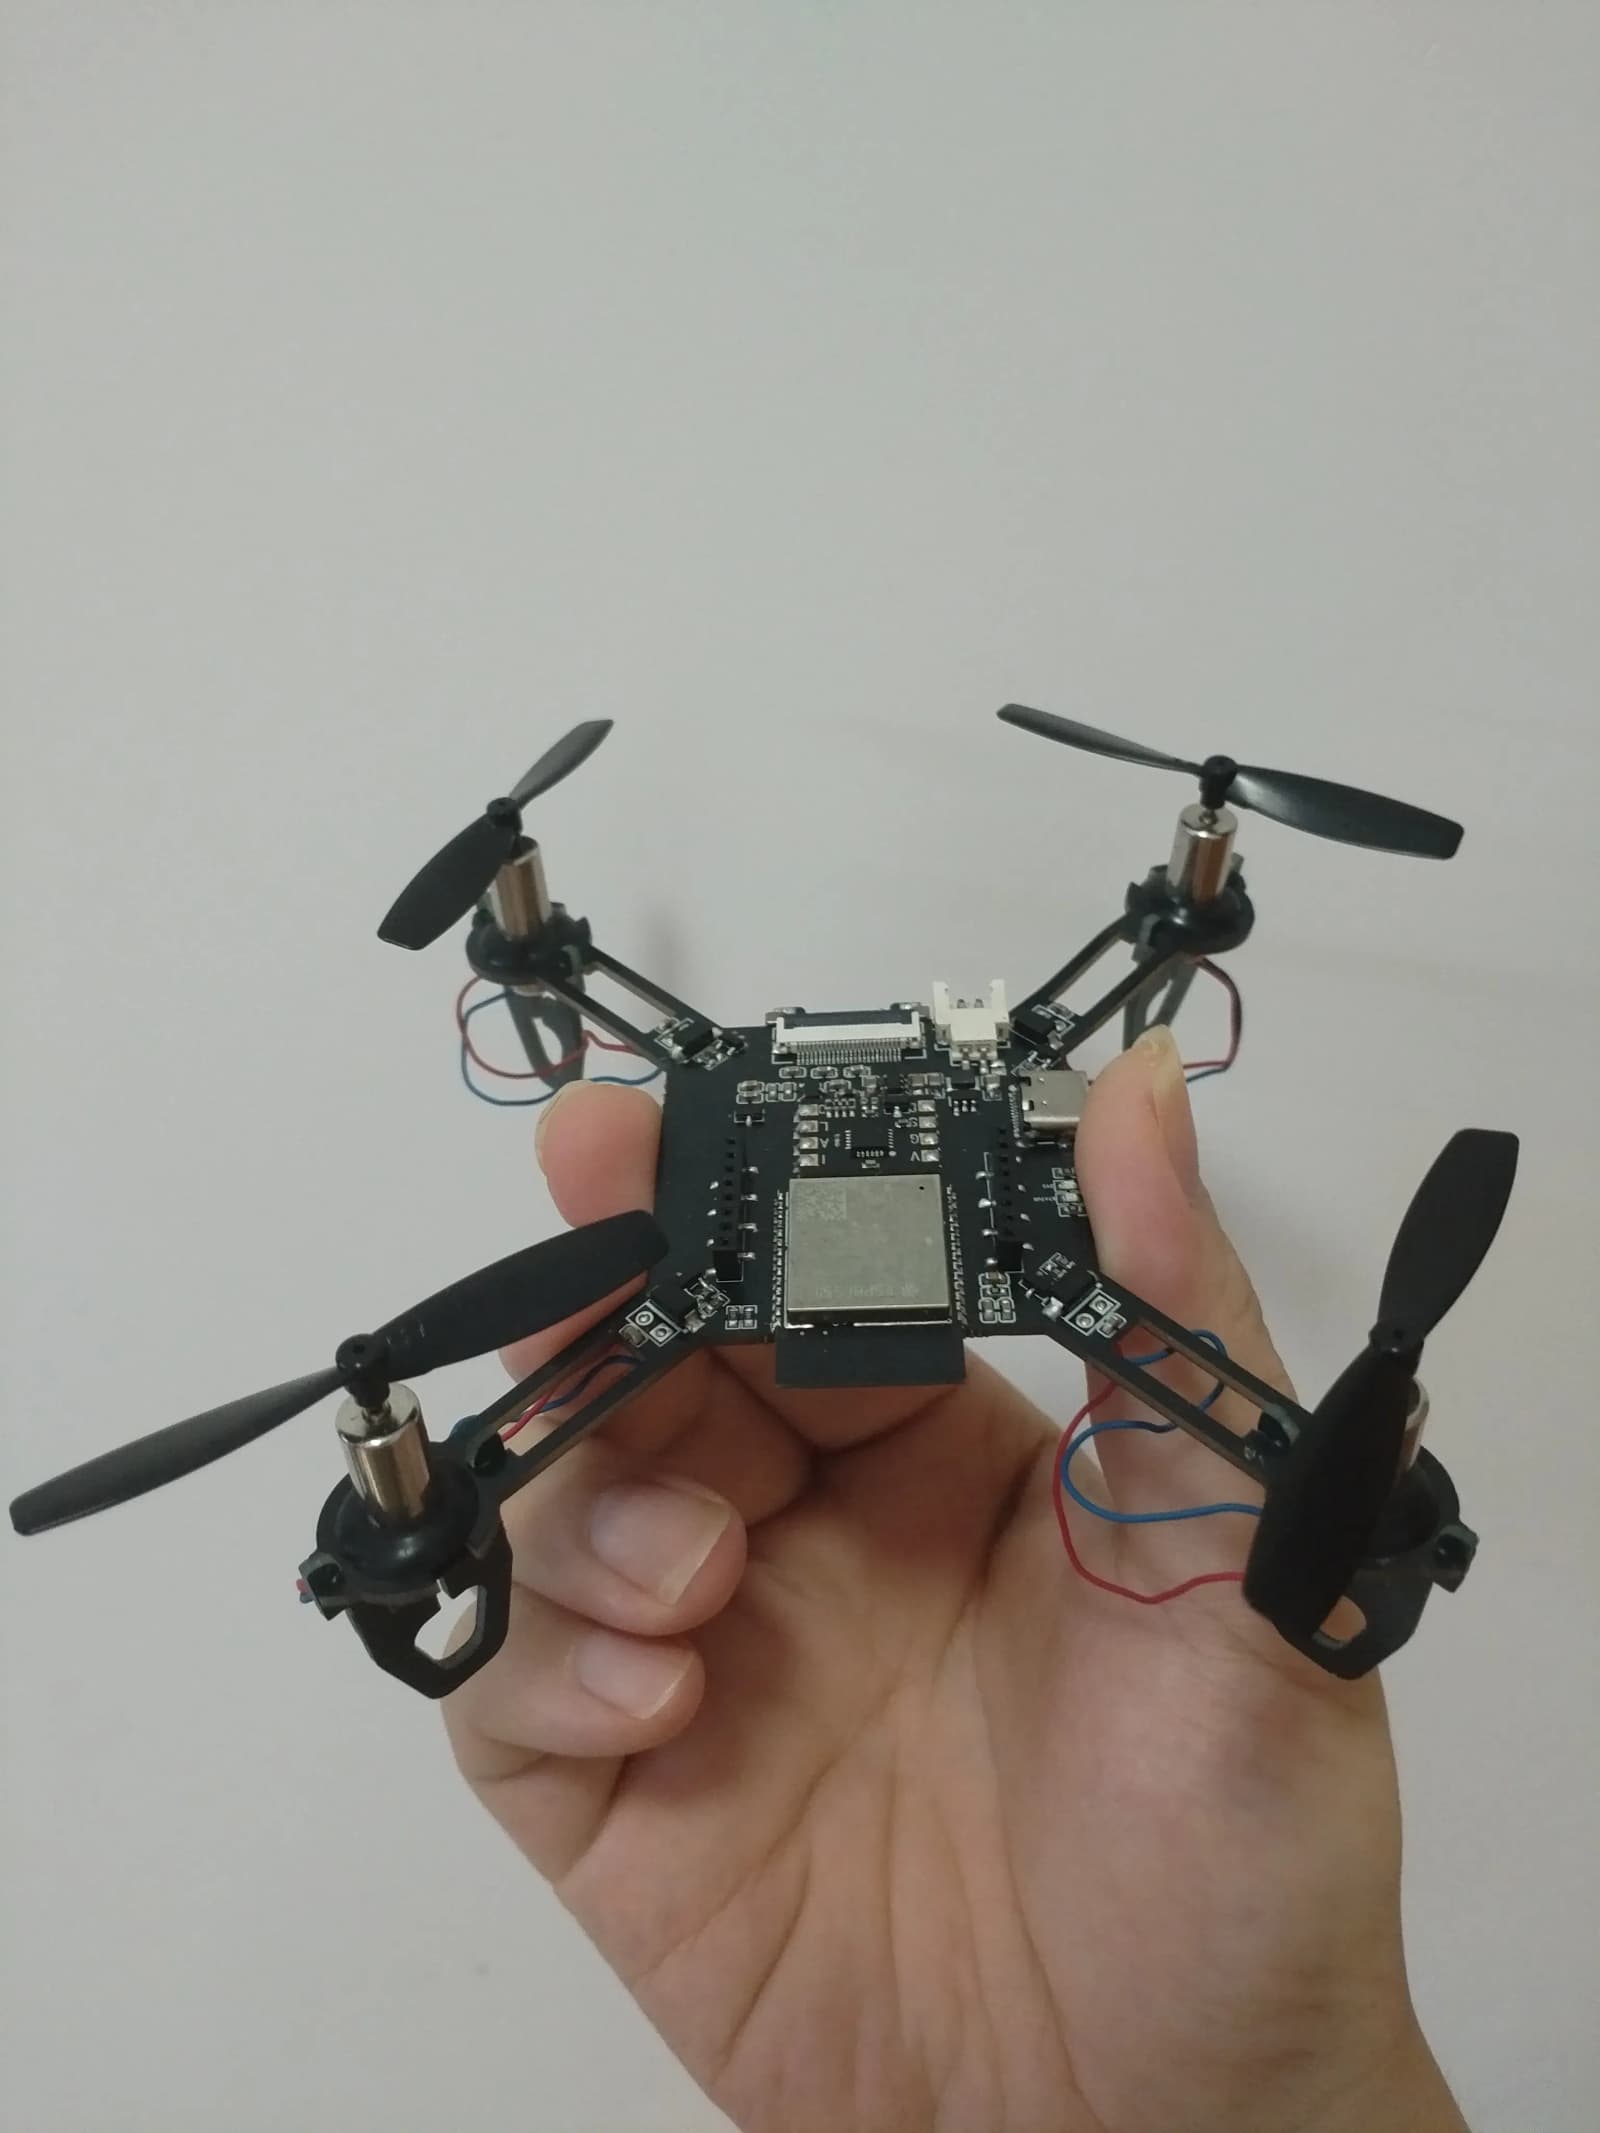
    ESP-Drone

    An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    Tiny-Drone

    An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.

    • Work in progress
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

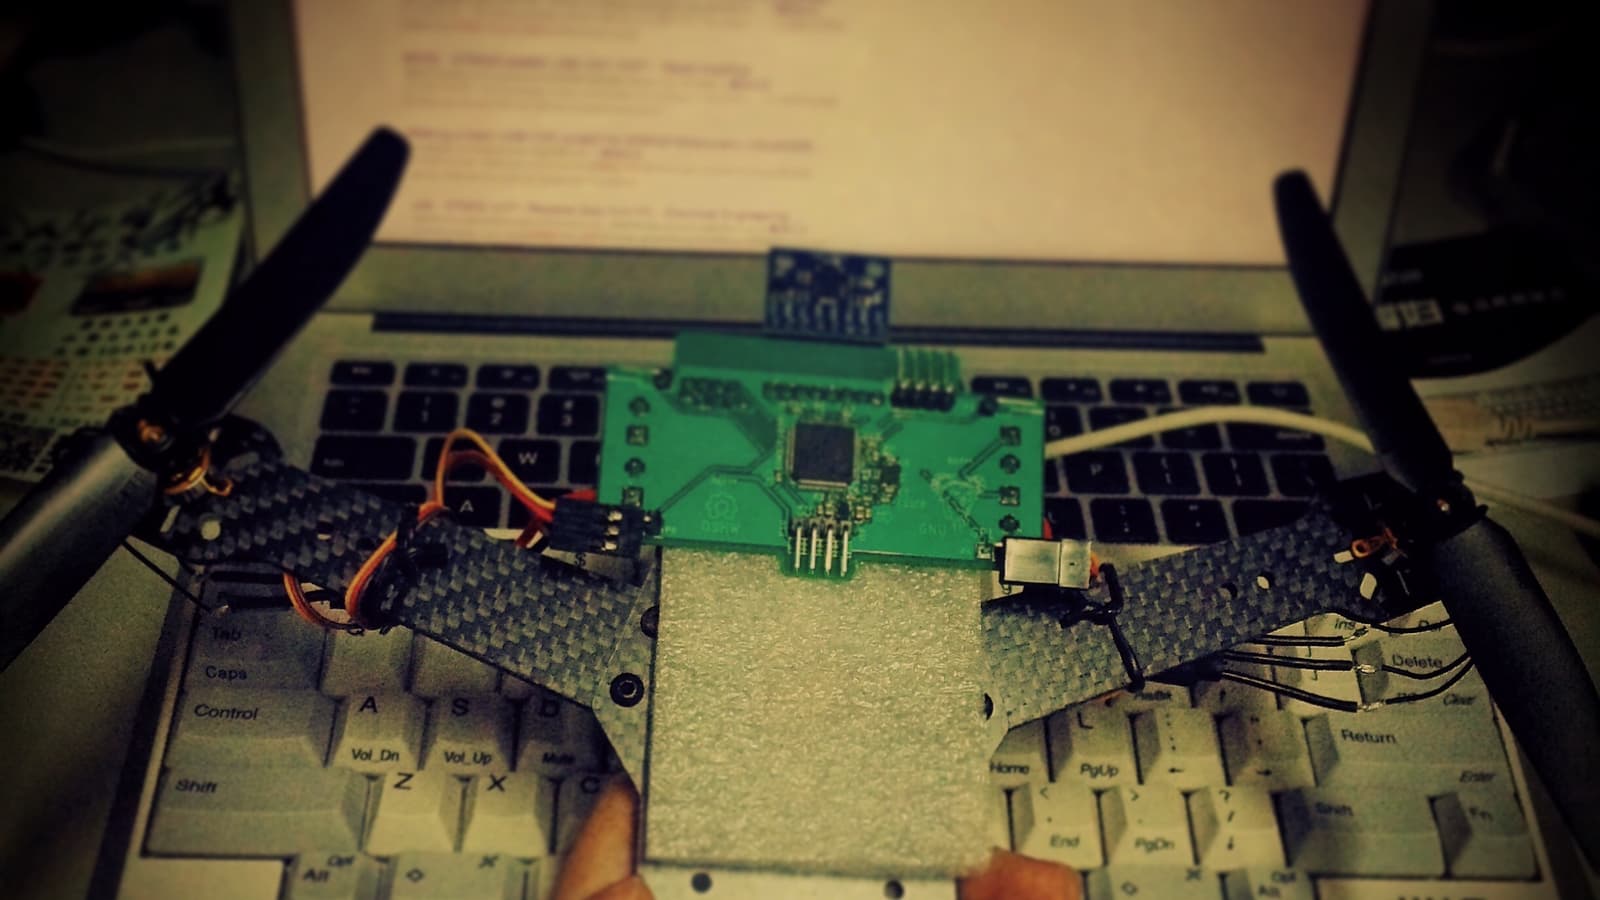
    Acme-Flight

    An open-source quadcopter framework providing schematics and flight control source code.
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    Avem

    A lightweight drone flight controller using STM32, PID control, and BLDC motors.

    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    Tensegrity Quadrotor Model

    A mechanical model combining tensegrity structure with a quadrotor drone.

    • No license
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    UniQuad

    A unified and versatile quadrotor platform series designed for UAV research and applications.

    • No license
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    400mm Quadcopter Model

    A 400mm wheelbase quadcopter drone with full protection, designed for university electronic design competitions.

    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    7-inch Ducted Fan UAV

    A 7-inch ducted fan unmanned aerial vehicle designed for vertical takeoff and landing with a payload capacity of approximately 2 kg.

    • No license
    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    KunPeng

    KunPeng is a dual-rotor drone that can achieve stable hovering at a fixed point and altitude.

    • No license
    Level
    Intermediate
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    F4 Flight Controller ESC

    An open-source quadcopter flight controller and electronic speed controller with CAD files for a drone frame.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    F405 PCB FPV

    A quadcopter built entirely with integrated PCB components for FPV flight.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    HeiGuan

    A quadcopter drone built by a student group for educational purposes, featuring STM32F401-Nucleo64 flight control.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    Quadcopter

    A small homemade quadcopter using an F411 and NRF51822 flight controller based on the open-source MiniFly design.

    • No license
    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    PCB Quadrotor

    A PCB-based quadrotor drone designed for research experiments, featuring 8520 coreless motors and 55mm propellers as a simple aerial mobility platform.

    • No license
    Level
    Intermediate
    Buildability
    10/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Quadrotor Main Control Board

    An STM32-based flight control board for quadrotors with schematics and PCB design.

    • No license
    Level
    Intermediate
    Buildability
    5/100
    Incomplete documentation
    Cost
    Not stated

More to explore