Triple-J UAV
A quadrotor UAV based on STM32F103C8T6, FreeRTOS, and cascaded PID for experimental flight control and remote operation.
- Work in progress
- No license
- Level
- Advanced
- Buildability
- 20/100
- Incomplete documentation
- Cost
- Not stated
Flying robots and their flight controllers. 33 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
A quadrotor UAV based on STM32F103C8T6, FreeRTOS, and cascaded PID for experimental flight control and remote operation.
A DIY quadcopter drone built from scratch using an STM32F411CEU6 microcontroller.
An open-source quadcopter flight controller and electronic speed controller with CAD files for a drone frame.
A quadcopter built entirely with integrated PCB components for FPV flight.
A quadcopter drone built by a student group for educational purposes, featuring STM32F401-Nucleo64 flight control.
A small homemade quadcopter using an F411 and NRF51822 flight controller based on the open-source MiniFly design.
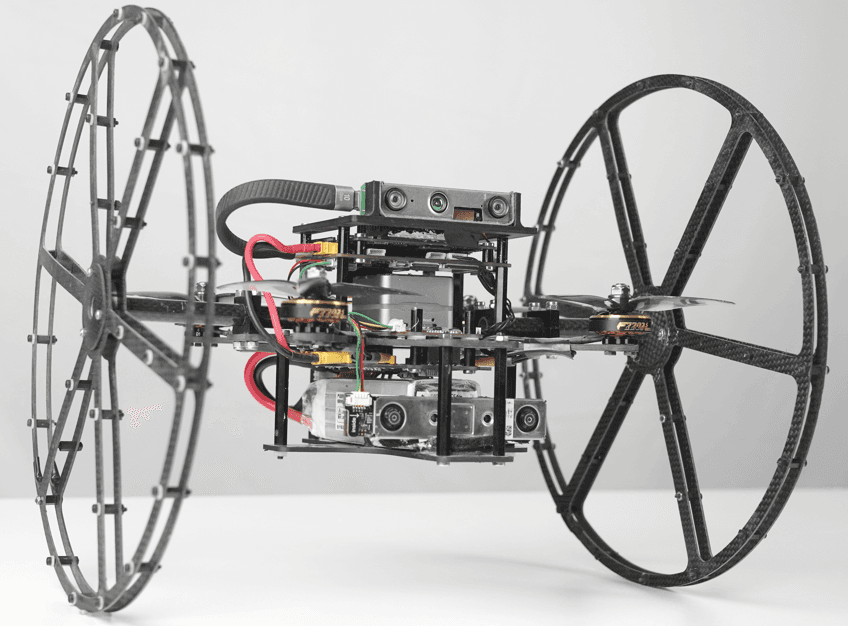
DroneA customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.
A PCB-based quadrotor drone designed for research experiments, featuring 8520 coreless motors and 55mm propellers as a simple aerial mobility platform.
An STM32-based flight control board for quadrotors with schematics and PCB design.
Robots 25–33 of 33