Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

14 robots of 270

Page 1 of 1 · Ready to build first, then by buildability

  • Wheeled

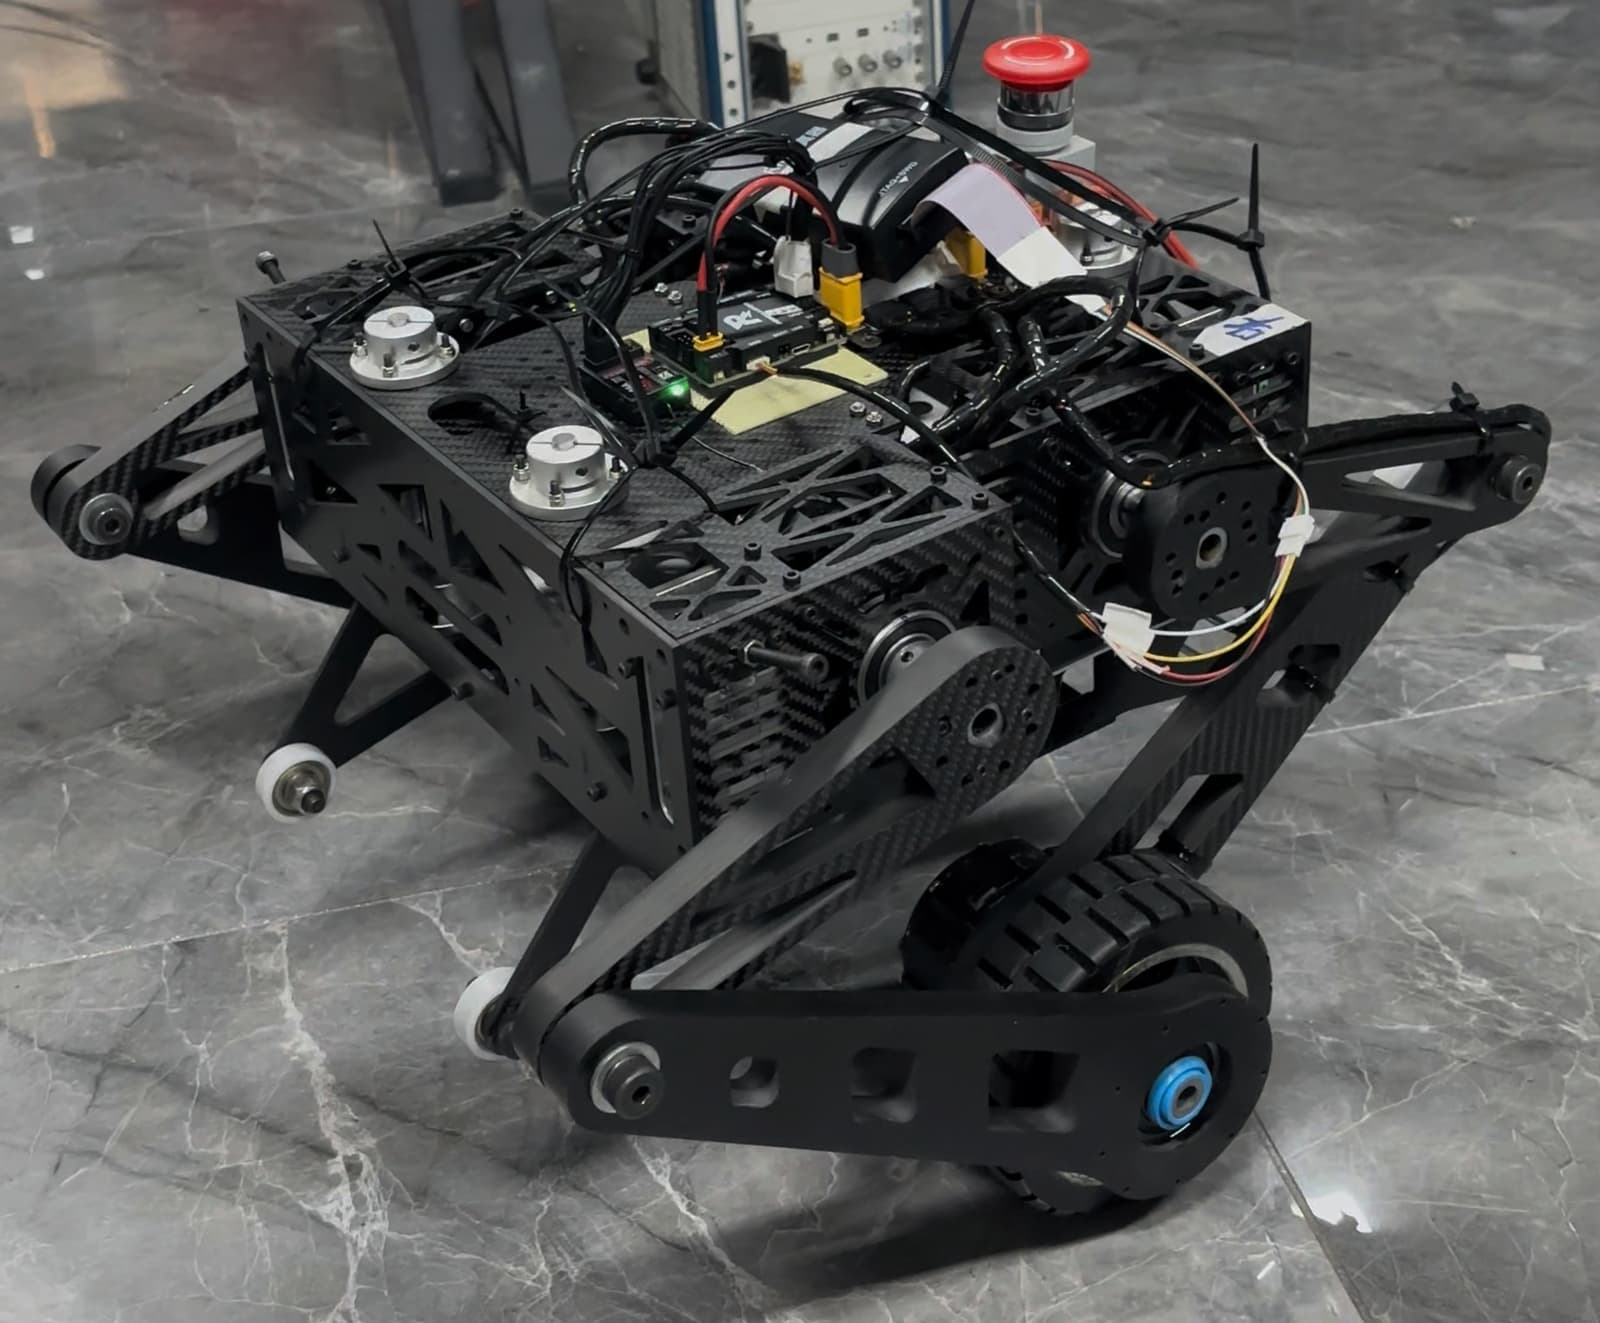
    RC WheelLeg

    A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.

    • Works with AI
    Level
    Advanced
    Buildability
    65/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Wheeled

    SimpleFOC Balance Car

    A self-balancing robot car driven by two BLDC motors using the SimpleFOC library and ESP32 microcontroller.

    Level
    Intermediate
    Buildability
    60/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

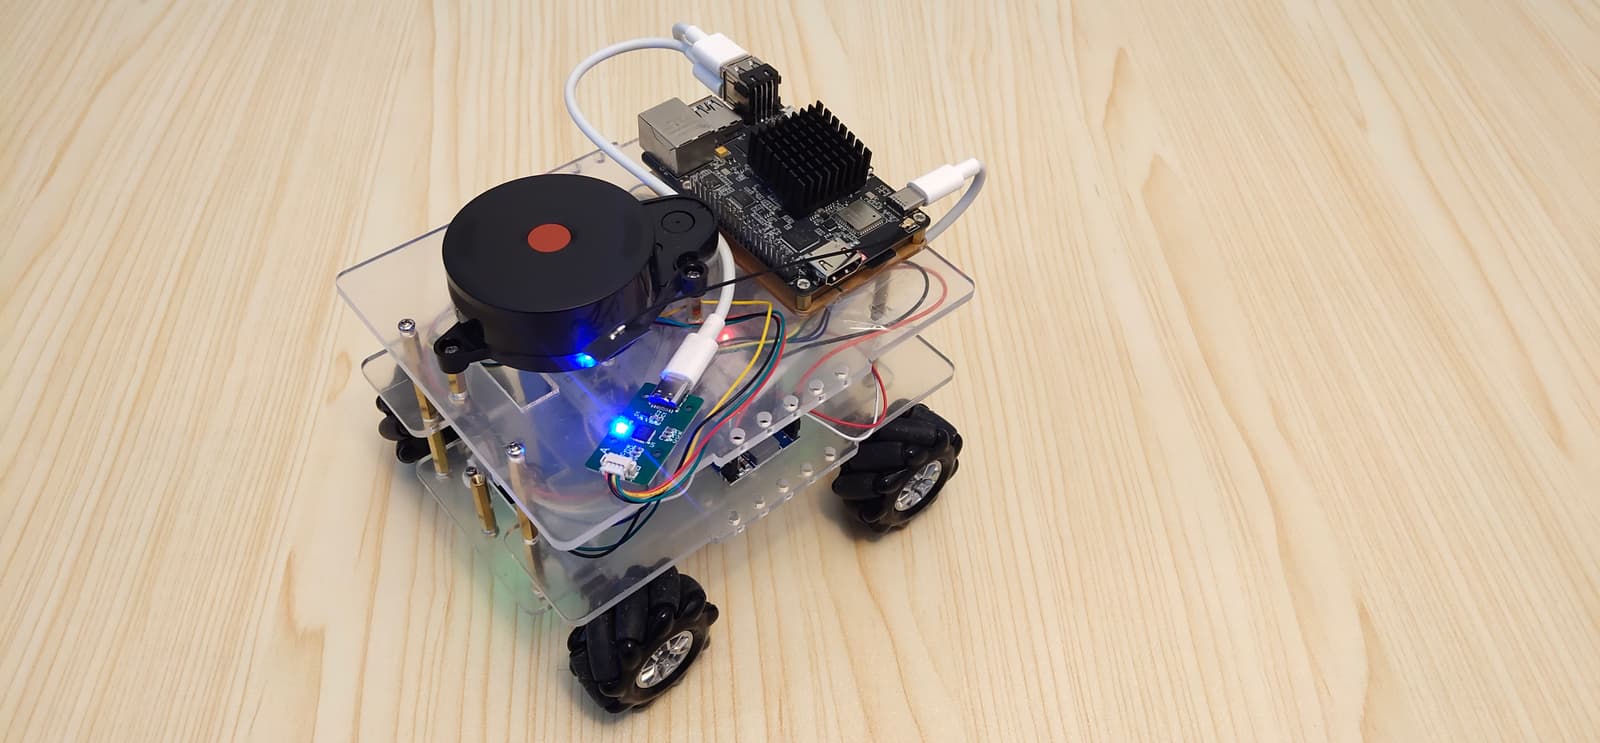
    T-Robot

    A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.

    Level
    Intermediate
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

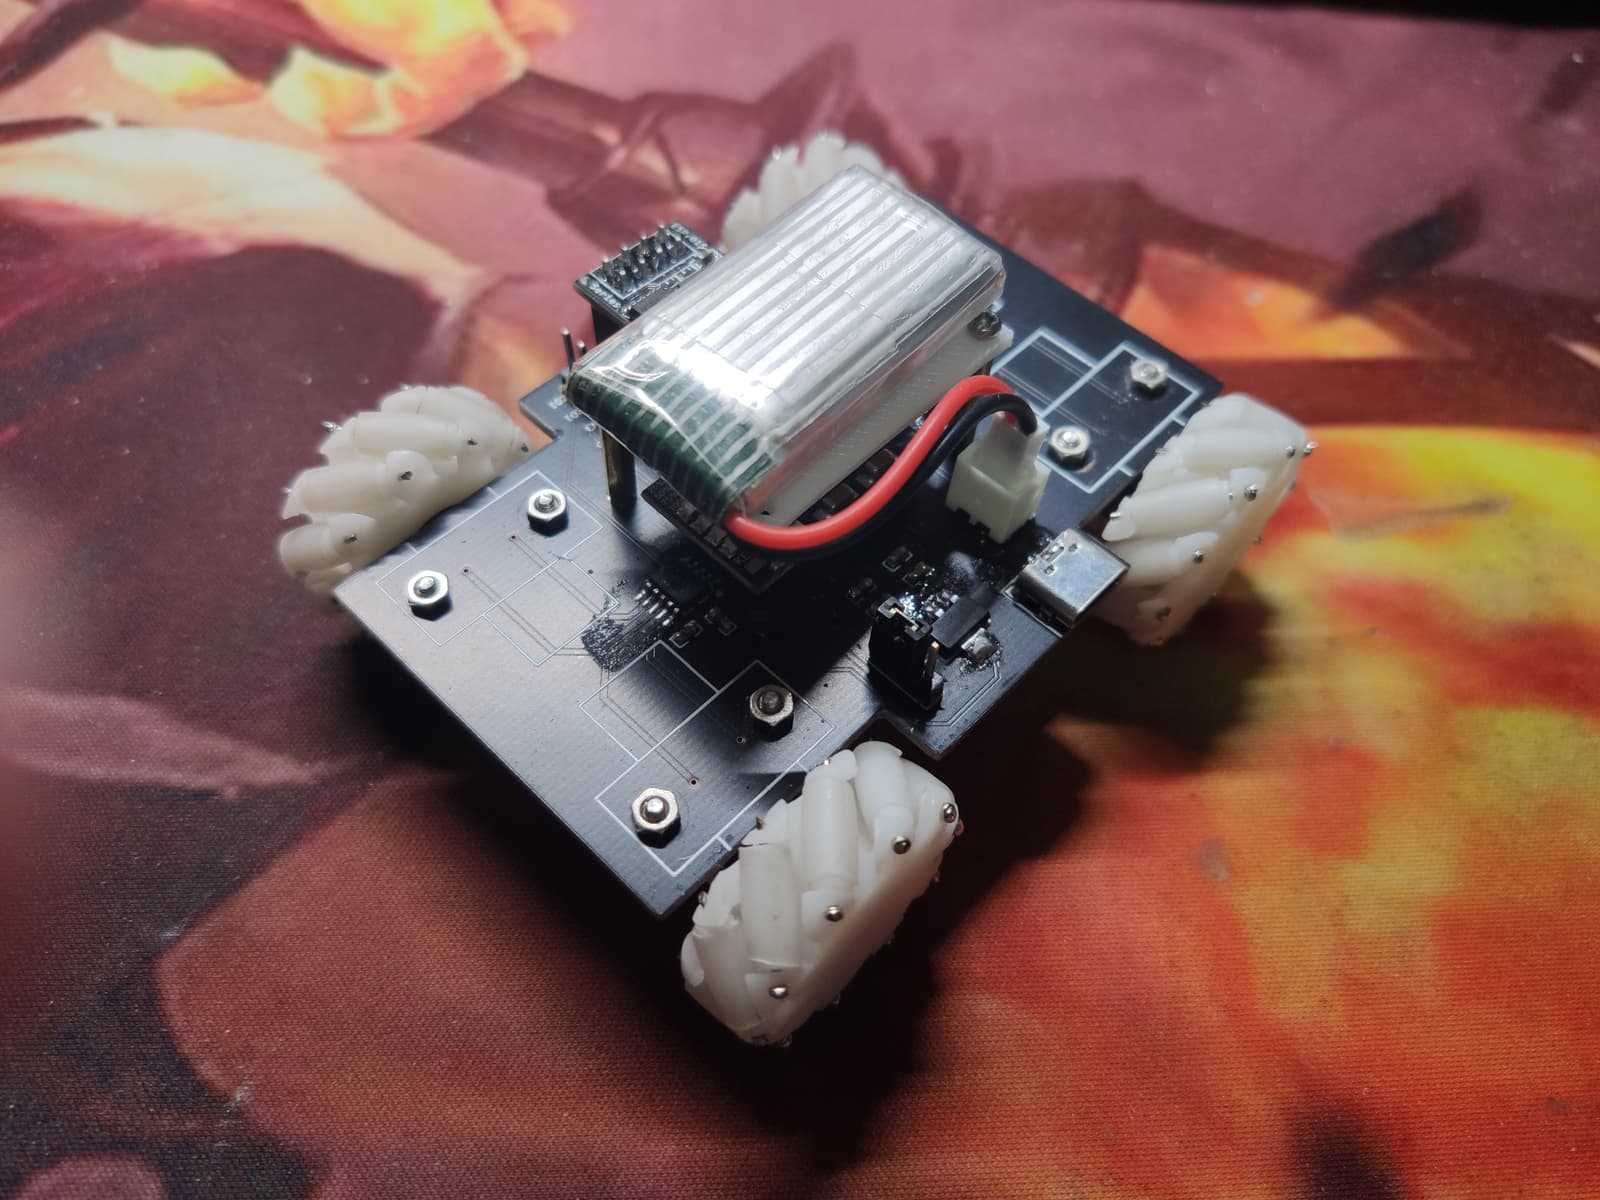
    MCar

    A small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.

    Level
    Intermediate
    Buildability
    50/100
    Buildable with some effort
    Cost
    ¥40≈ €5 (ECB rate, 14 Oct 2026)
  • Wheeled

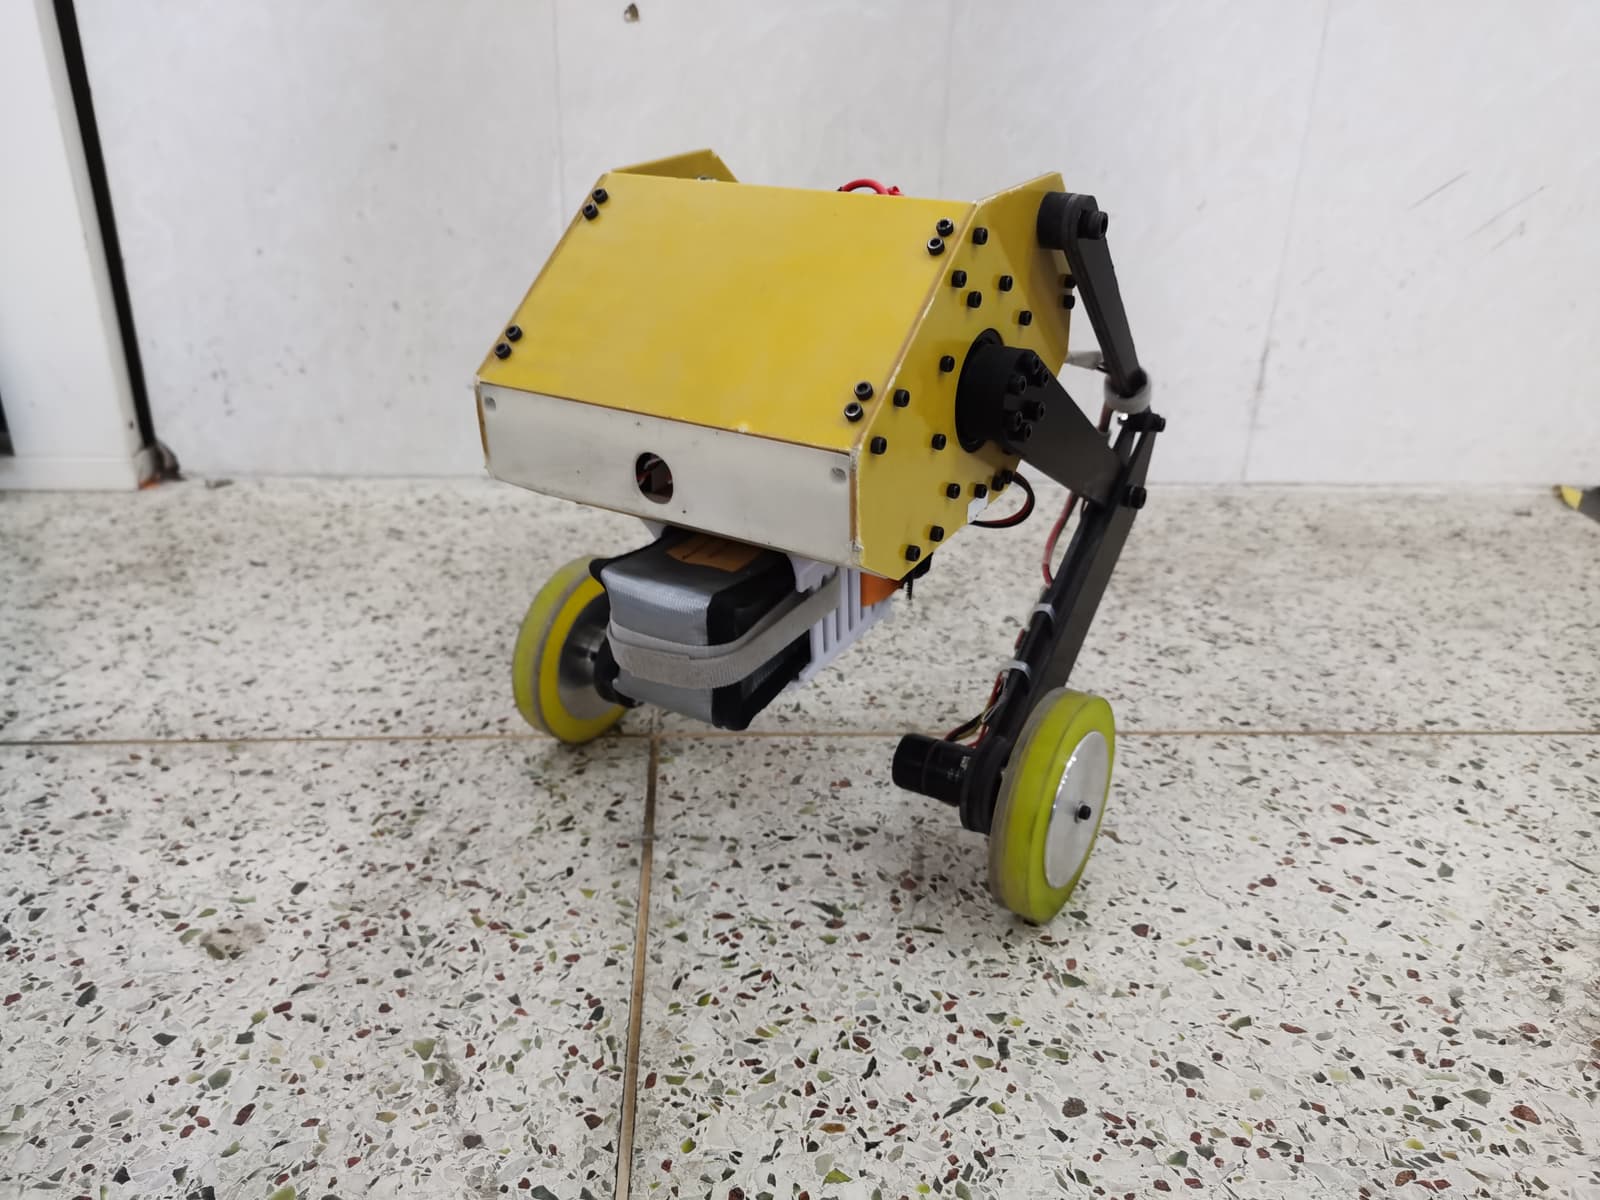
    Venus-1 Four-link Wheel-legged Robot

    A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

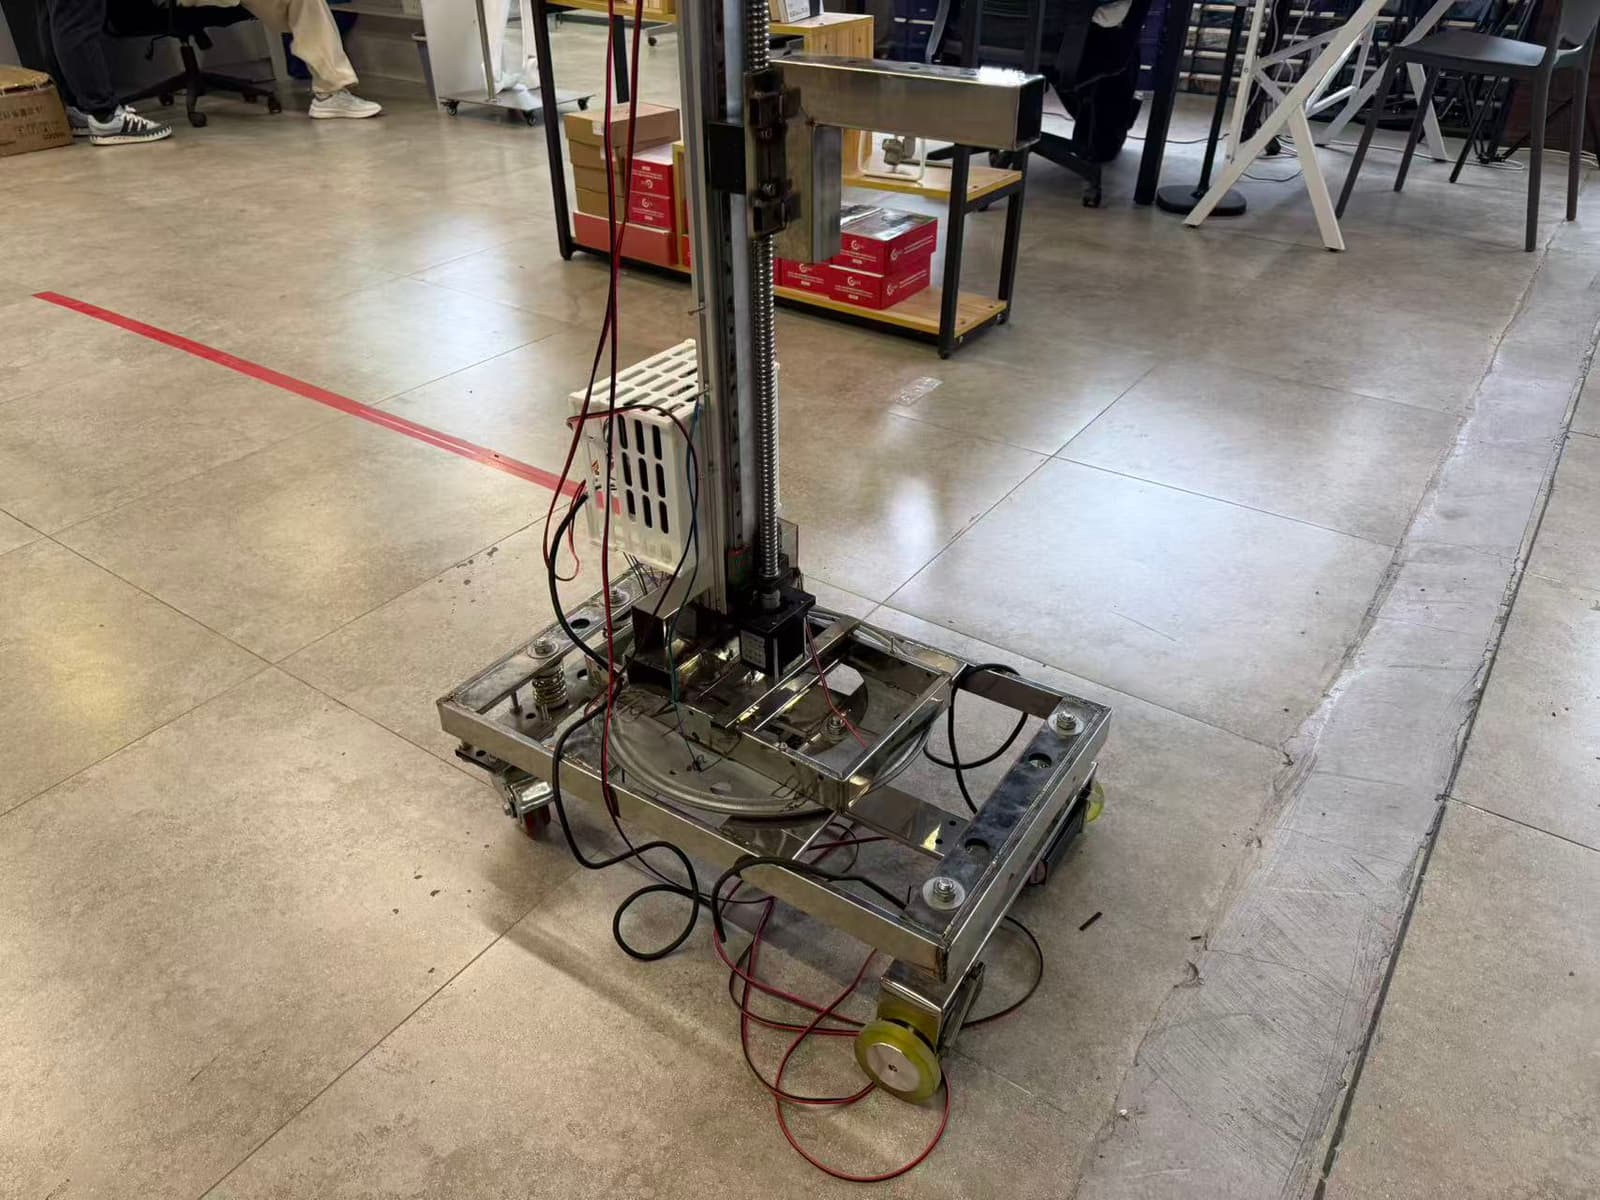
    VLS-AGV

    An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.

    Level
    Intermediate
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

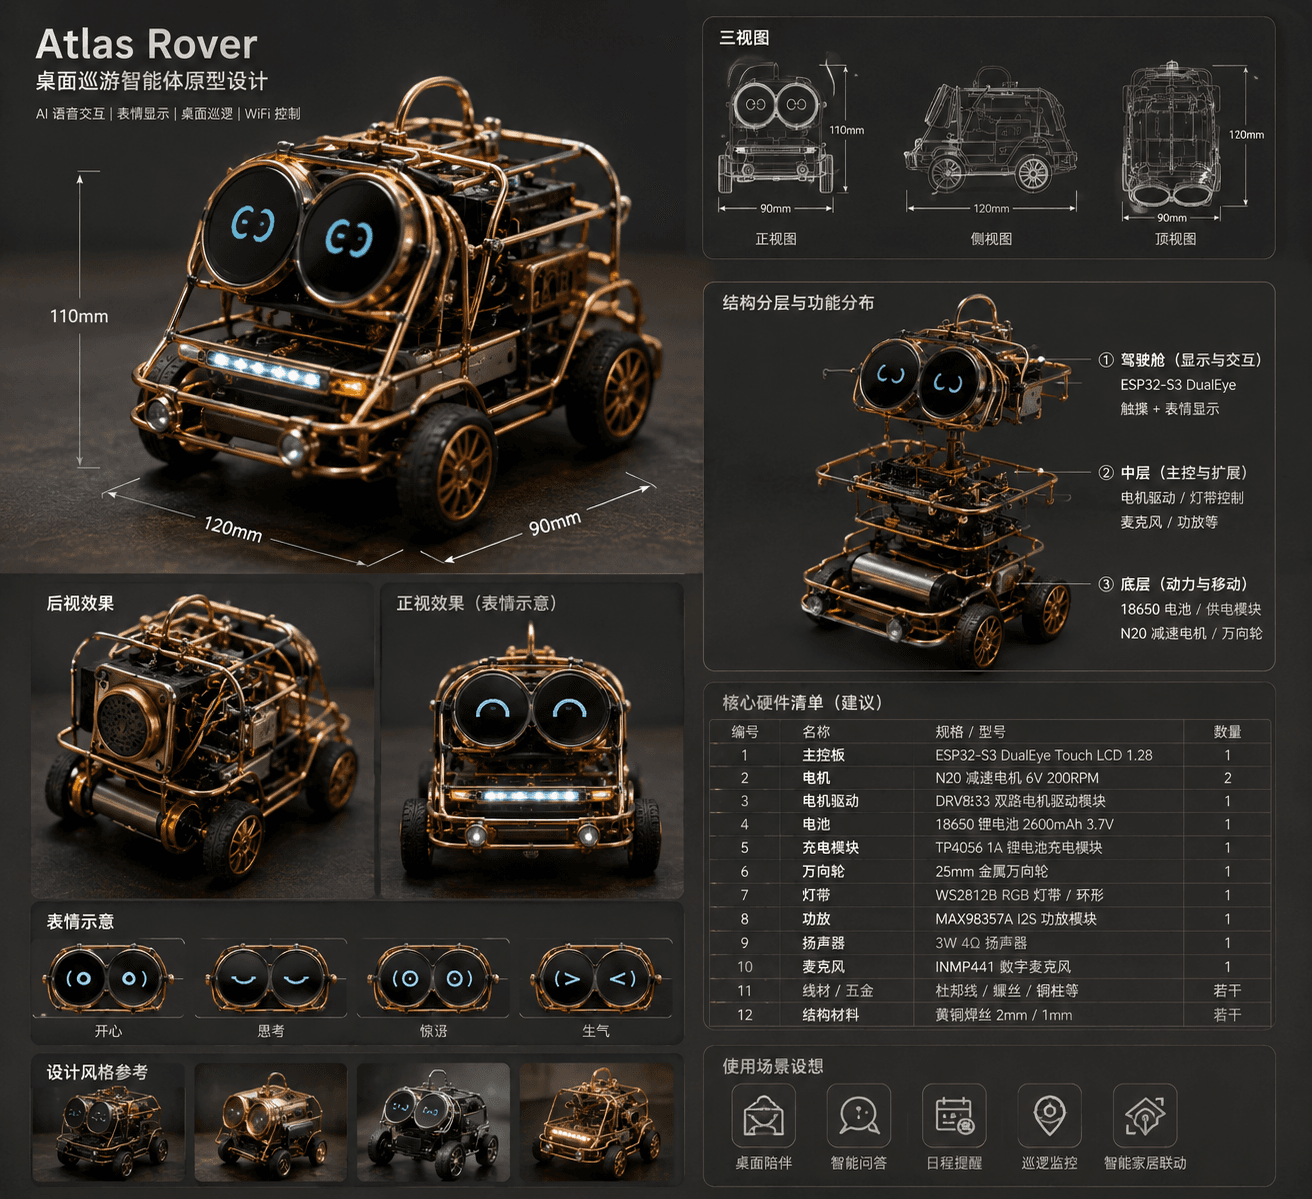
    Atlas Rover Mk.1

    A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.

    • Work in progress
    • Works with AI
    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Balance Car

    A self-balancing robot car controlled via Bluetooth with STM32 and Android support.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    OpenMover

    An open-source AGV chassis based on ROS for learning and practical applications.

    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    WhaleBot

    An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.

    • Work in progress
    • Works with AI
    Level
    Beginner
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    DengFOC Balance Bot

    A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

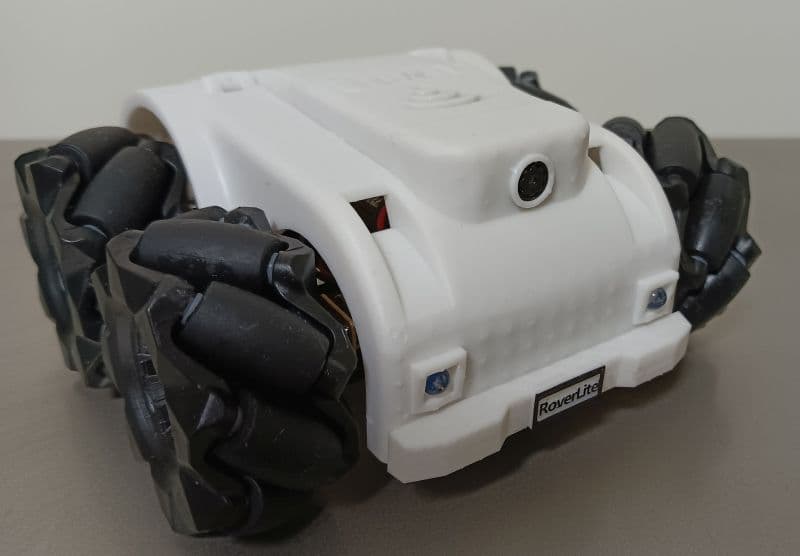
    RoverLite32

    A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Wheel-legged Robot

    A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Wheel-legged

    A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.

    Level
    Advanced
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated

More to explore