Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

14 robots of 270

Page 1 of 1 · Ready to build first, then by buildability

  • Drone

    SUPER MAV

    A safety-assured high-speed navigation micro aerial vehicle (MAV) with modular hardware components for research and development.
    Level
    Advanced
    Buildability
    64/100
    Buildable with some effort
    Cost
    Not stated
  • Drone

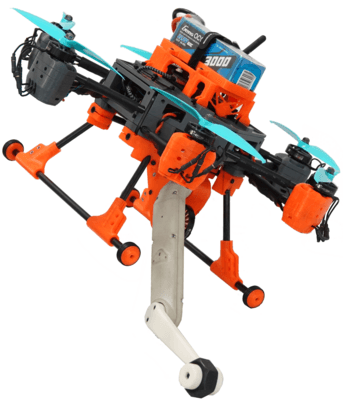
    Borinot

    An open-source, torque-controlled aerial loco-manipulator whose extremity can be reconfigured as a tail for flight, a hand for manipulation, or a leg for hybrid aerial-contact locomotion.

    Level
    Advanced
    Buildability
    51/100
    Buildable with some effort
    Cost
    Not stated
  • Photo on GitHub
    Drone

    REAL Drone 400

    An open-source autonomous quadrotor drone built by the NEU REAL Lab, with a high-load, stable-localization design for autonomous obstacle avoidance flight.

    • No license
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Drone

    Fast-Drone-250

    An open-source 250mm autonomous quadrotor drone that flies in unknown environments and avoids obstacles using VINS visual-inertial odometry and EGO-Planner.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    OLDX-FC Open-source Multicopter Flight Controller

    An open-source flight controller platform for multicopters with dual-processor redundancy, supporting GPS, optical flow, UWB, and vision-based navigation.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

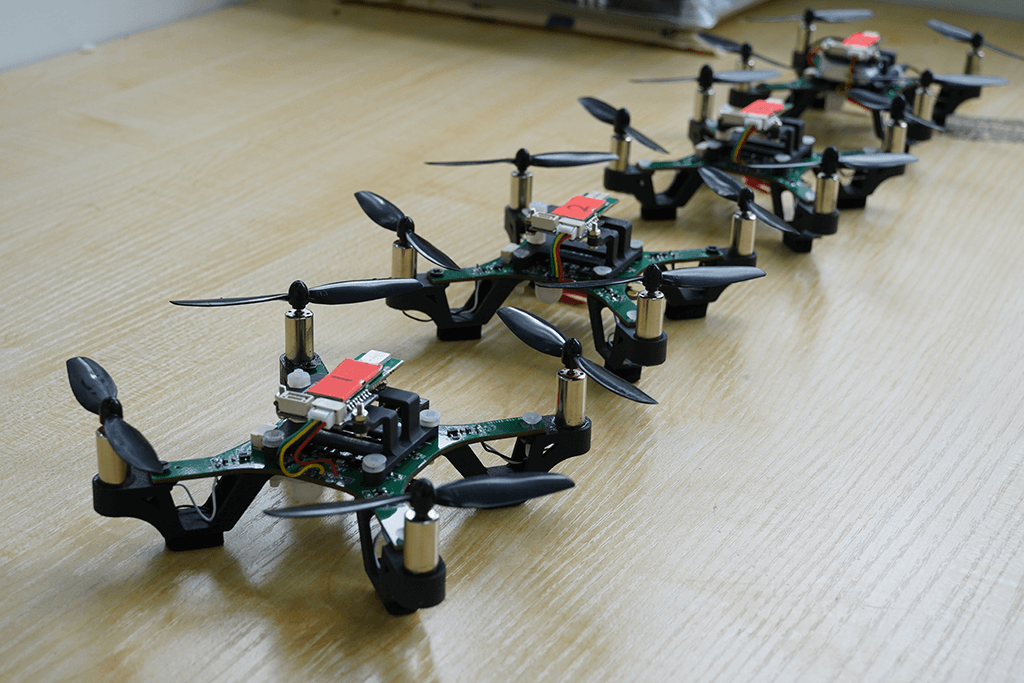
    Underwater Vehicle

    An ROV/AUV underwater robot controlled by STM32 and Raspberry Pi for navigation and sensor data processing.
    • No license
    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    GEARdrones

    A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    OmniNxt

    A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    ESP-FLY

    An open-source ESP-FLY drone with CAD models, Crazyflie-based flight firmware, a PyQt6 PC debugging tool and an Android control app.

    • Work in progress
    • No license
    Level
    Advanced
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    GLDrone

    An open-source quadcopter drone with a self-built frame and flight controller, designed for indoor flight and formation experiments.

    • No license
    Level
    Advanced
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Swashplateless Twin Rotor Micro Aircraft

    A micro-scale swashplateless twin-rotor flying robot with its own flight controller hardware, control software and mechanical design.

    • Work in progress
    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    Triple-J UAV

    A quadrotor UAV based on STM32F103C8T6, FreeRTOS, and cascaded PID for experimental flight control and remote operation.

    • Work in progress
    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Wuhu TakeOff Quadcopter

    A DIY quadcopter drone built from scratch using an STM32F411CEU6 microcontroller.
    • No license
    Level
    Advanced
    Buildability
    20/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

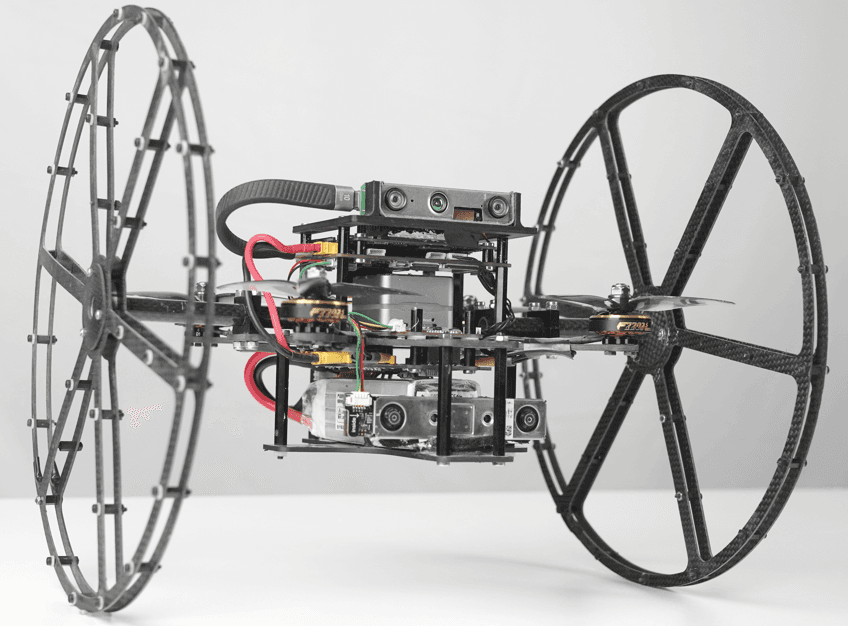
    TABV-Platform

    A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.

    Level
    Advanced
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated

More to explore