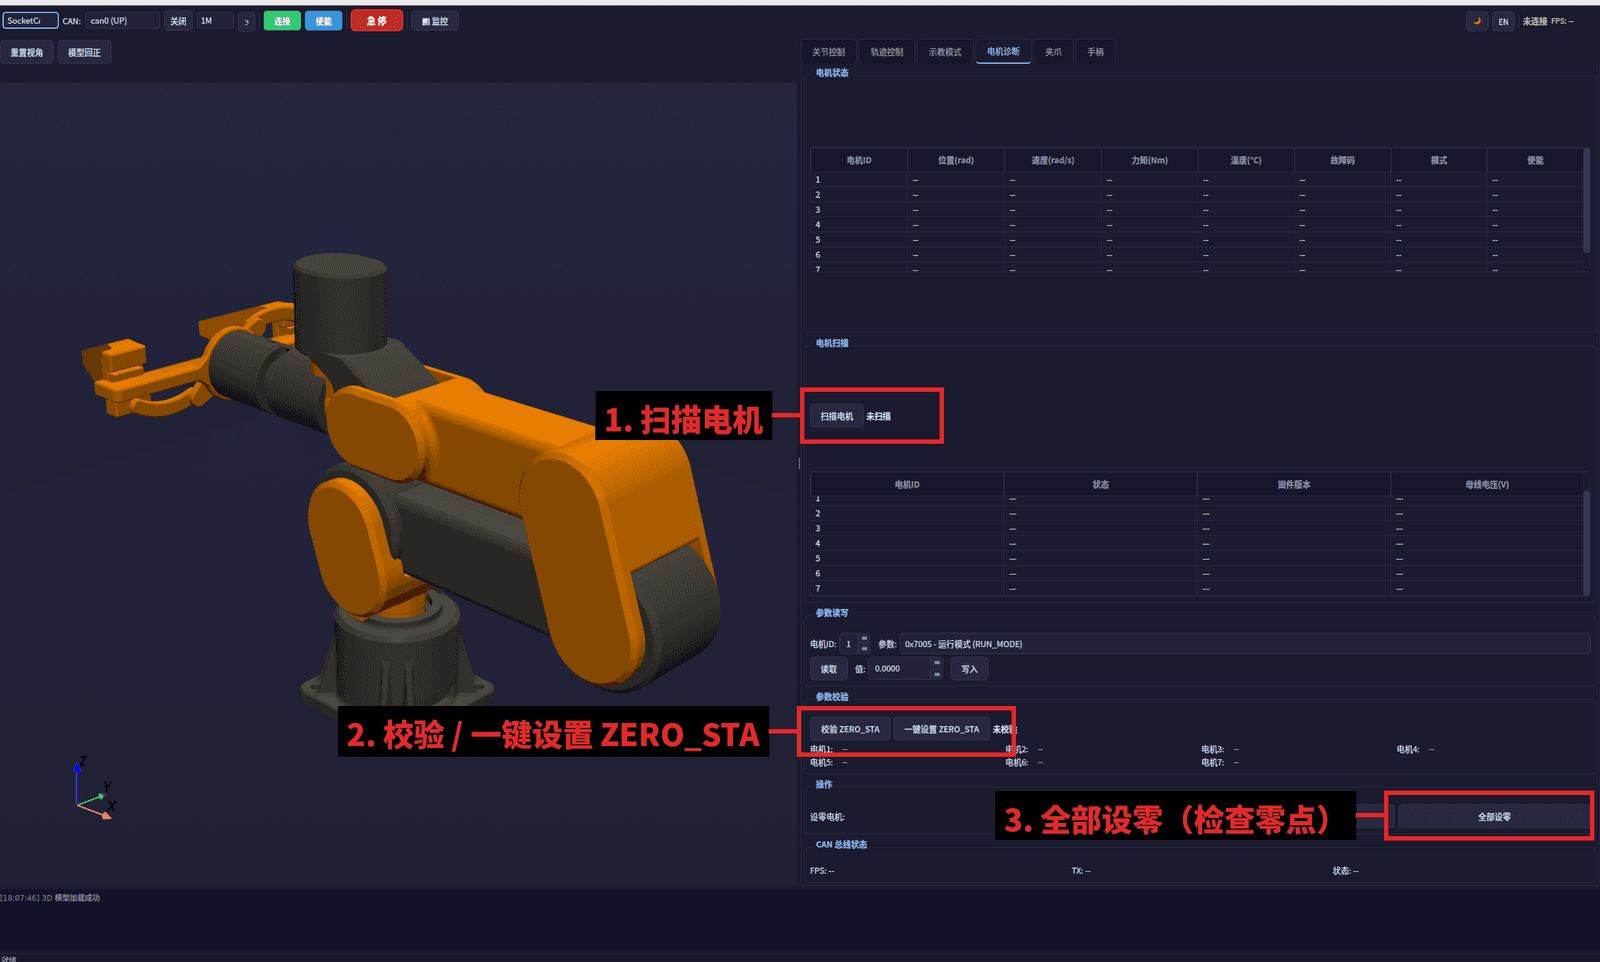
EL-A3
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
Robot armAdvancedBuildability 75/100 · Buildable with some effort
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
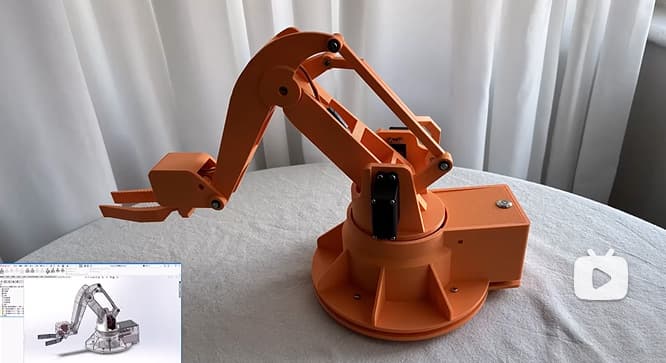
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
A low-cost six-axis robotic arm using DAMIAO motors and sheet metal structural parts, designed for students and hobbyists.

A 7-DOF personal robotic arm with ROS-based simulation and control.
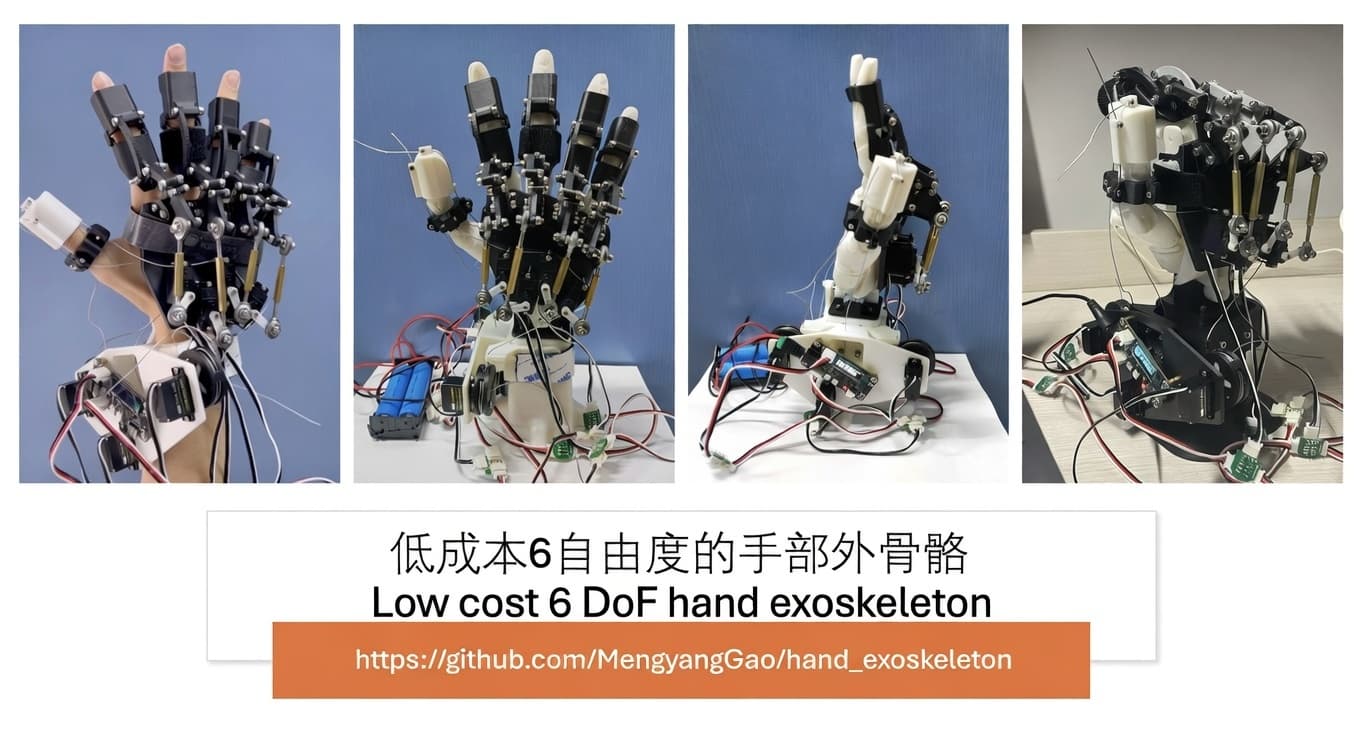
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
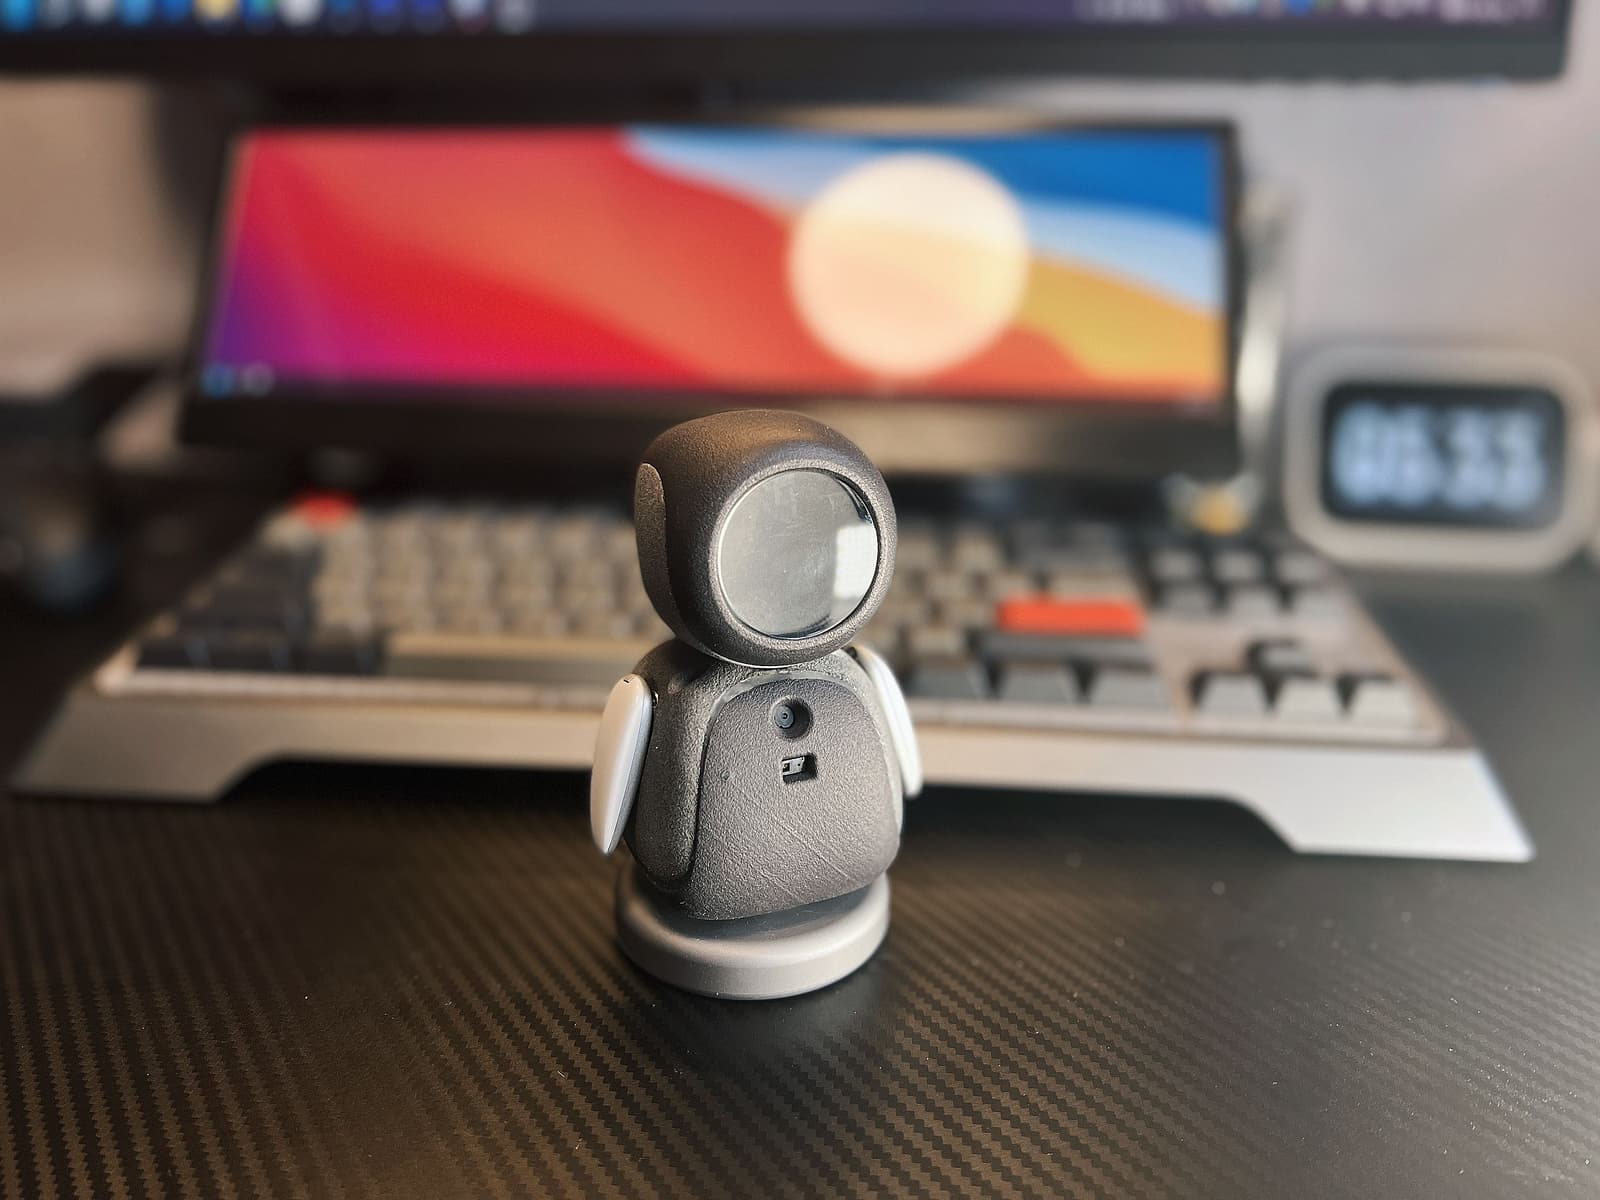
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.

A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
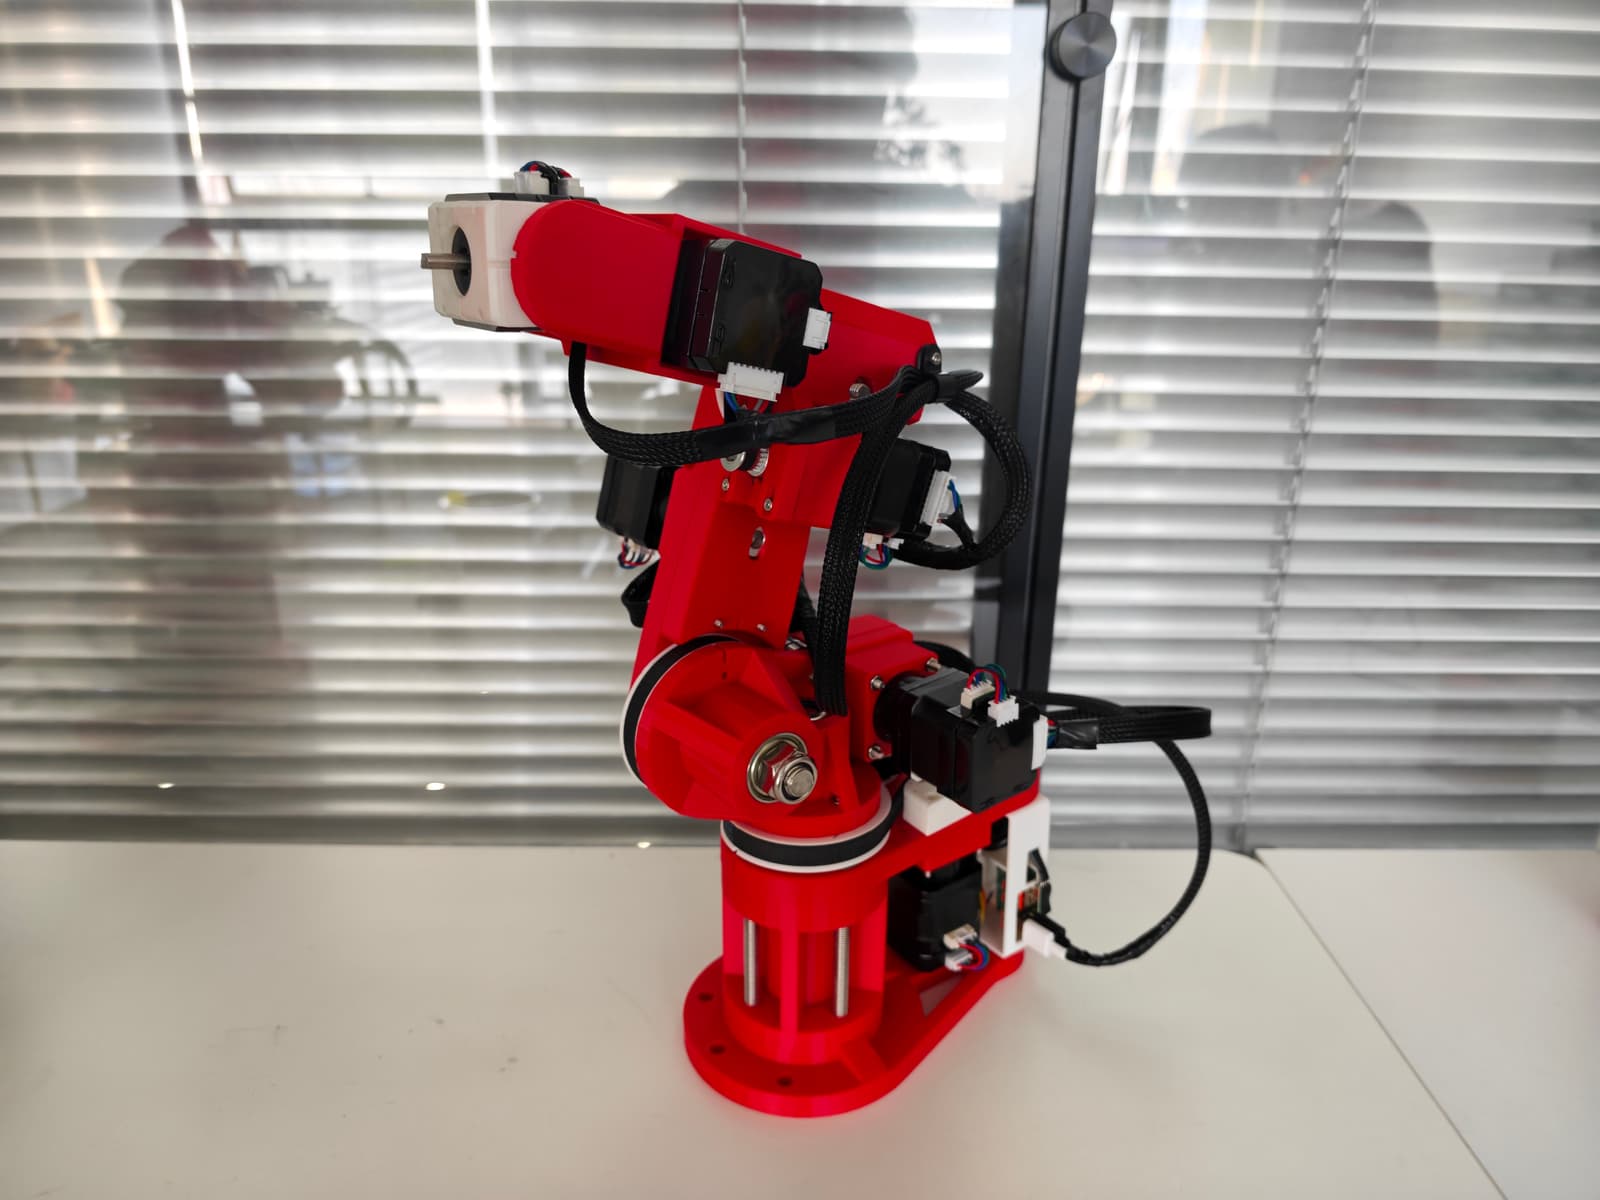
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
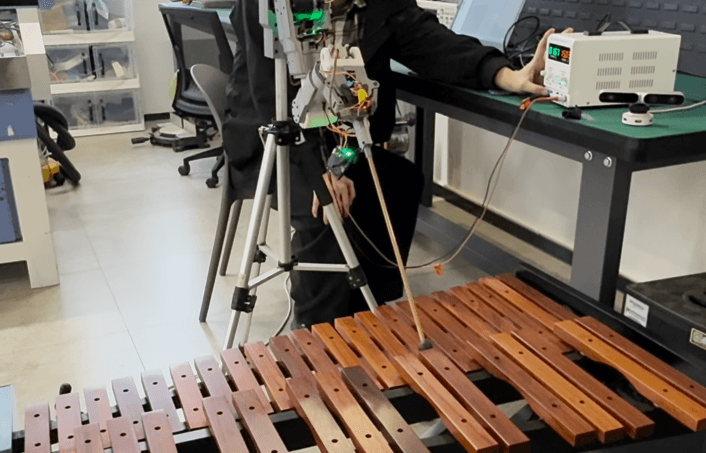
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
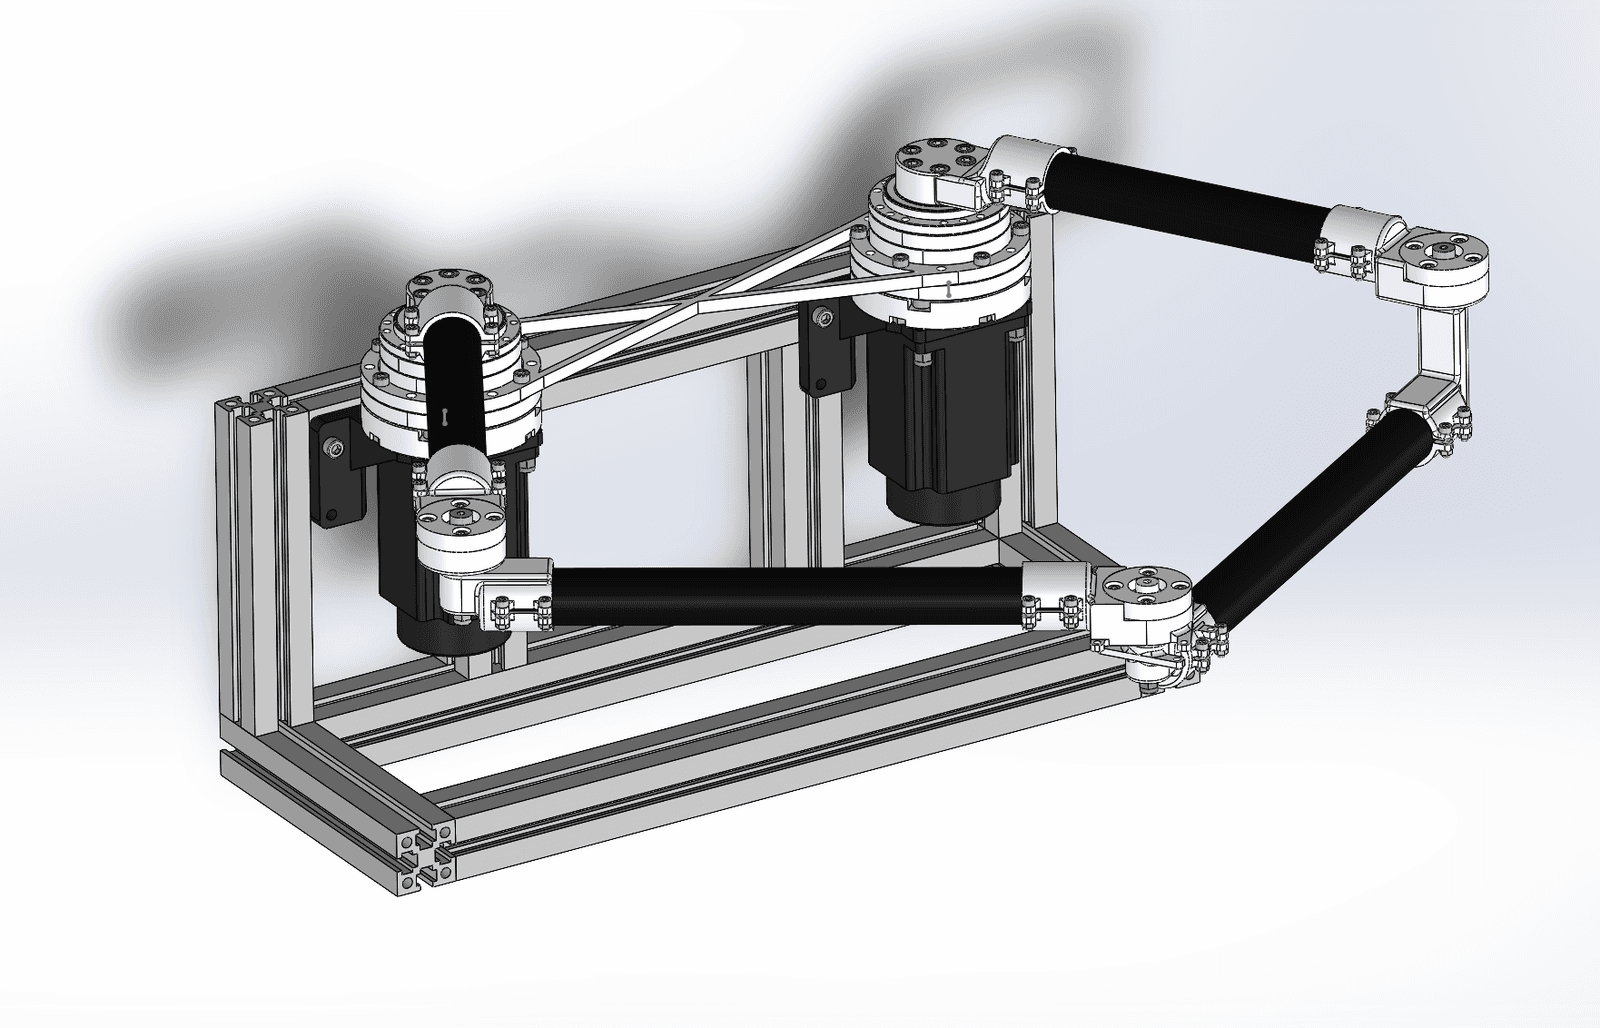
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
Mechanical model and parts list of HighTorque's Panthera-HT robot arm: SolidWorks 2024 sources, STEP files and a BOM spreadsheet.