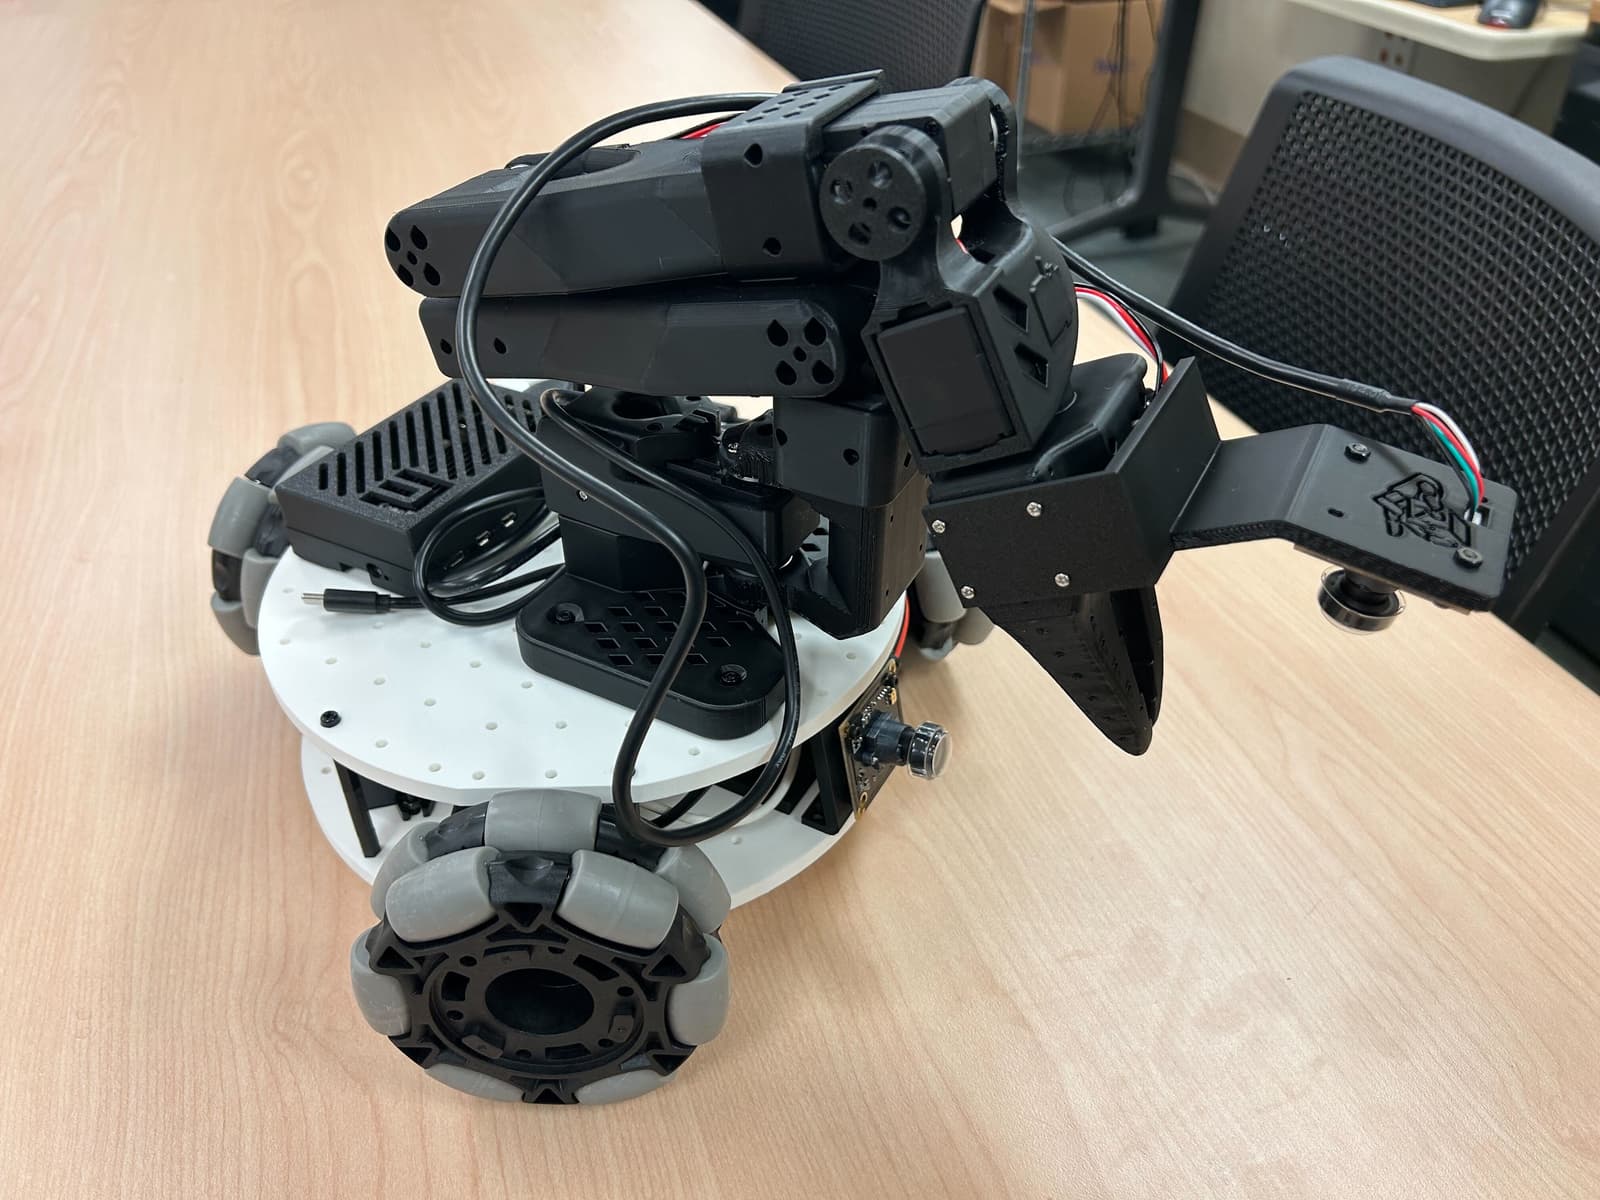
LeKiwi
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
WheeledIntermediateBuildability 90/100 · Ready to build
- Works with AI
€537.65
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
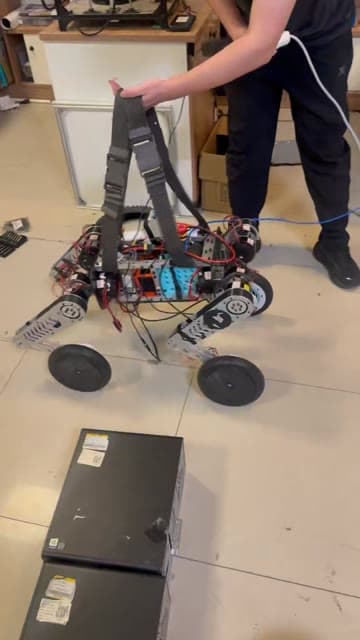
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.
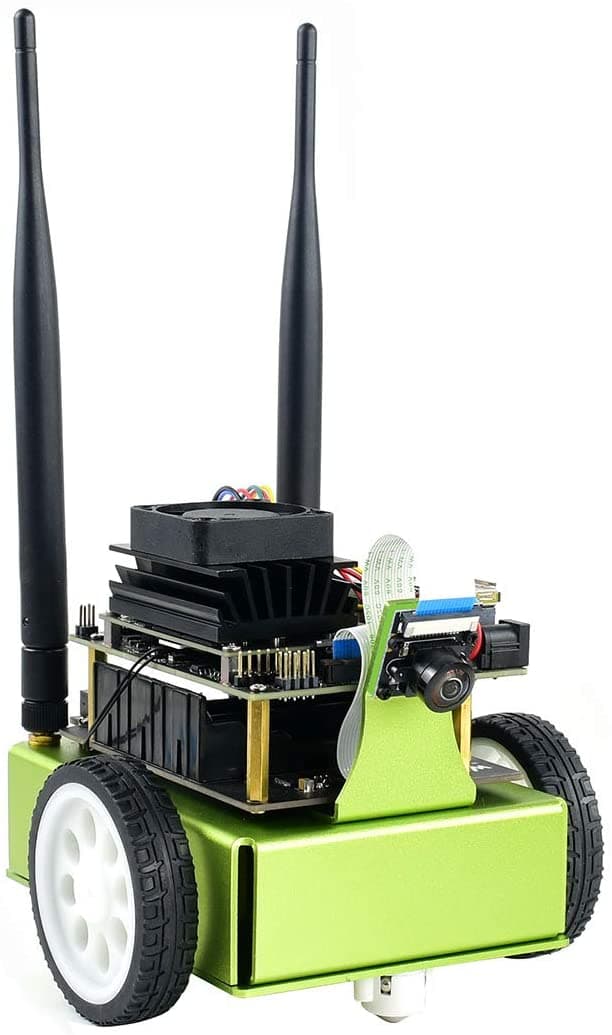
An educational open-source AI robot platform built on NVIDIA Jetson Nano for learning and experimenting with AI-based motion and collision avoidance.
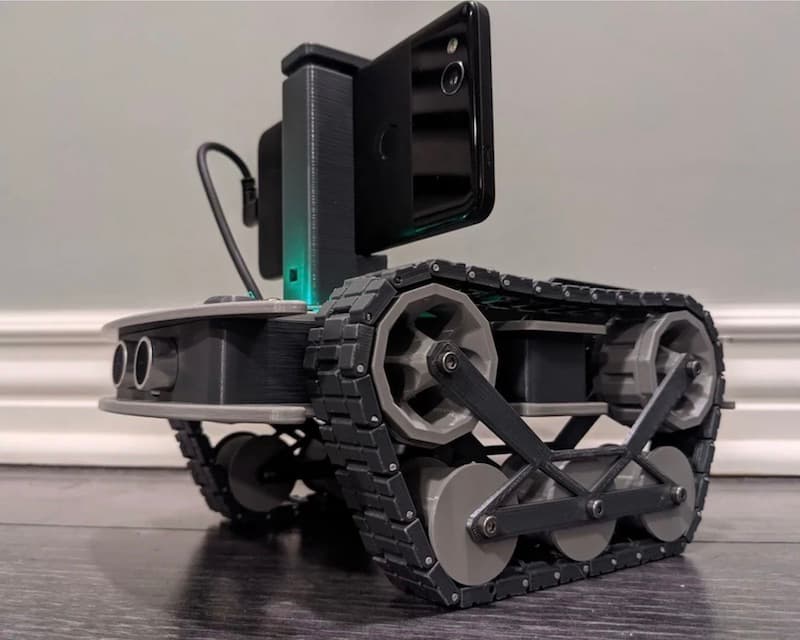
A low-cost small electric vehicle body that uses an Android smartphone as its brain, supporting person following and autonomous navigation.
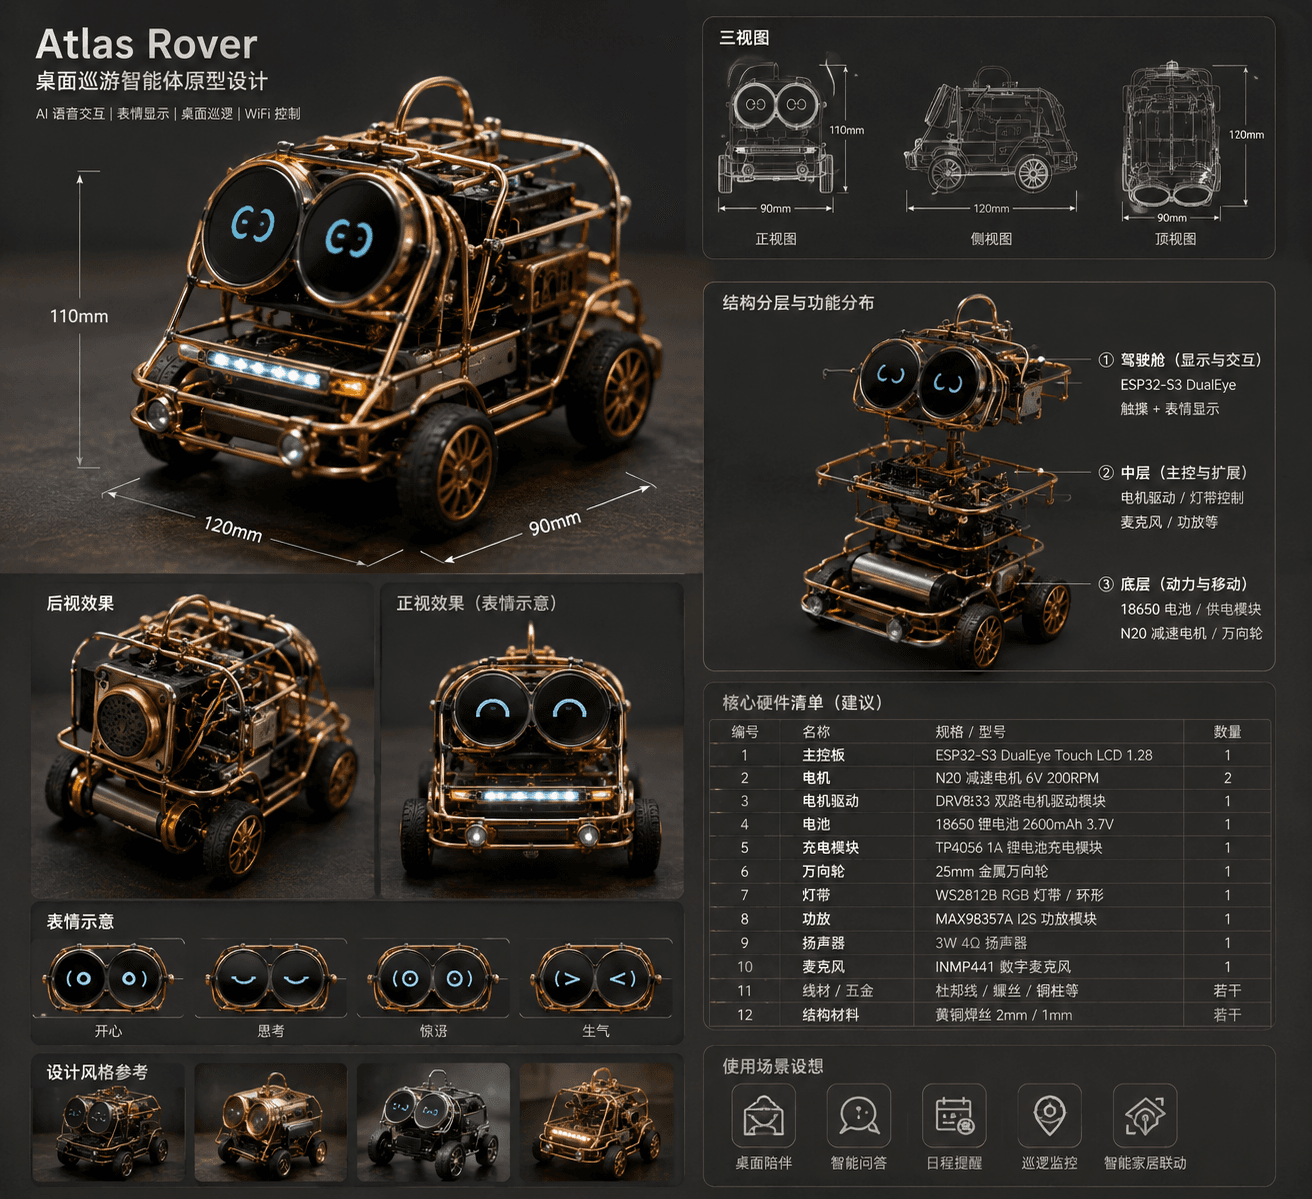
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
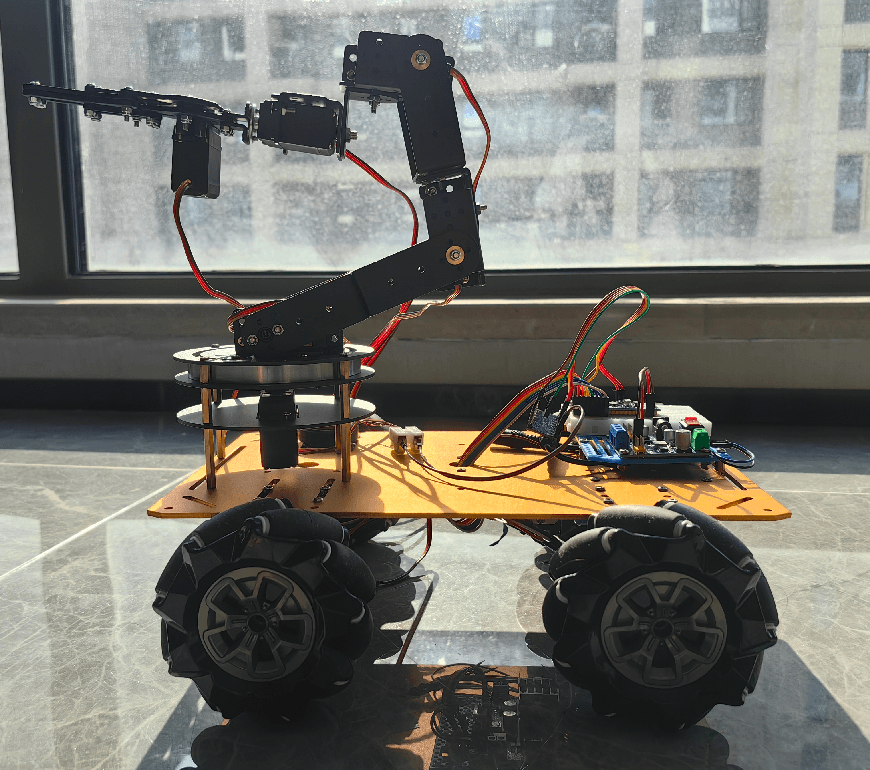
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
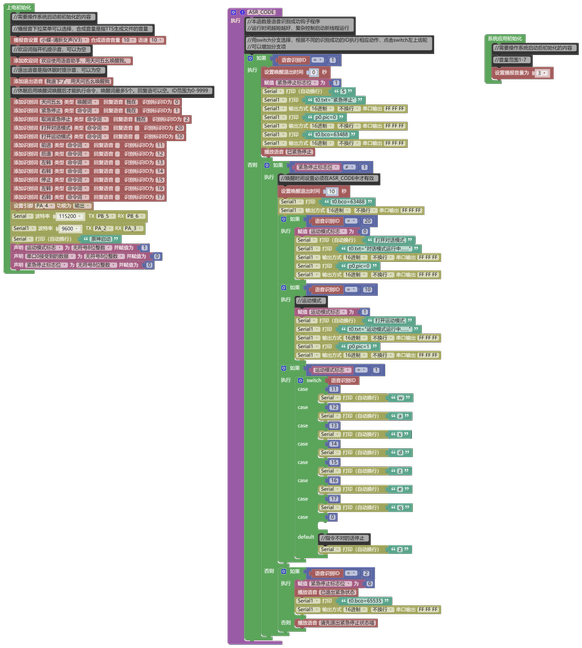
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
A fully autonomous mobile robot designed for counter-terrorism, bomb disposal, and rescue tasks, featuring a four-wheel drive chassis, five-degree-of-freedom robotic arm, and multi-vision systems.