WheelLeg FullStack Challenge Robot
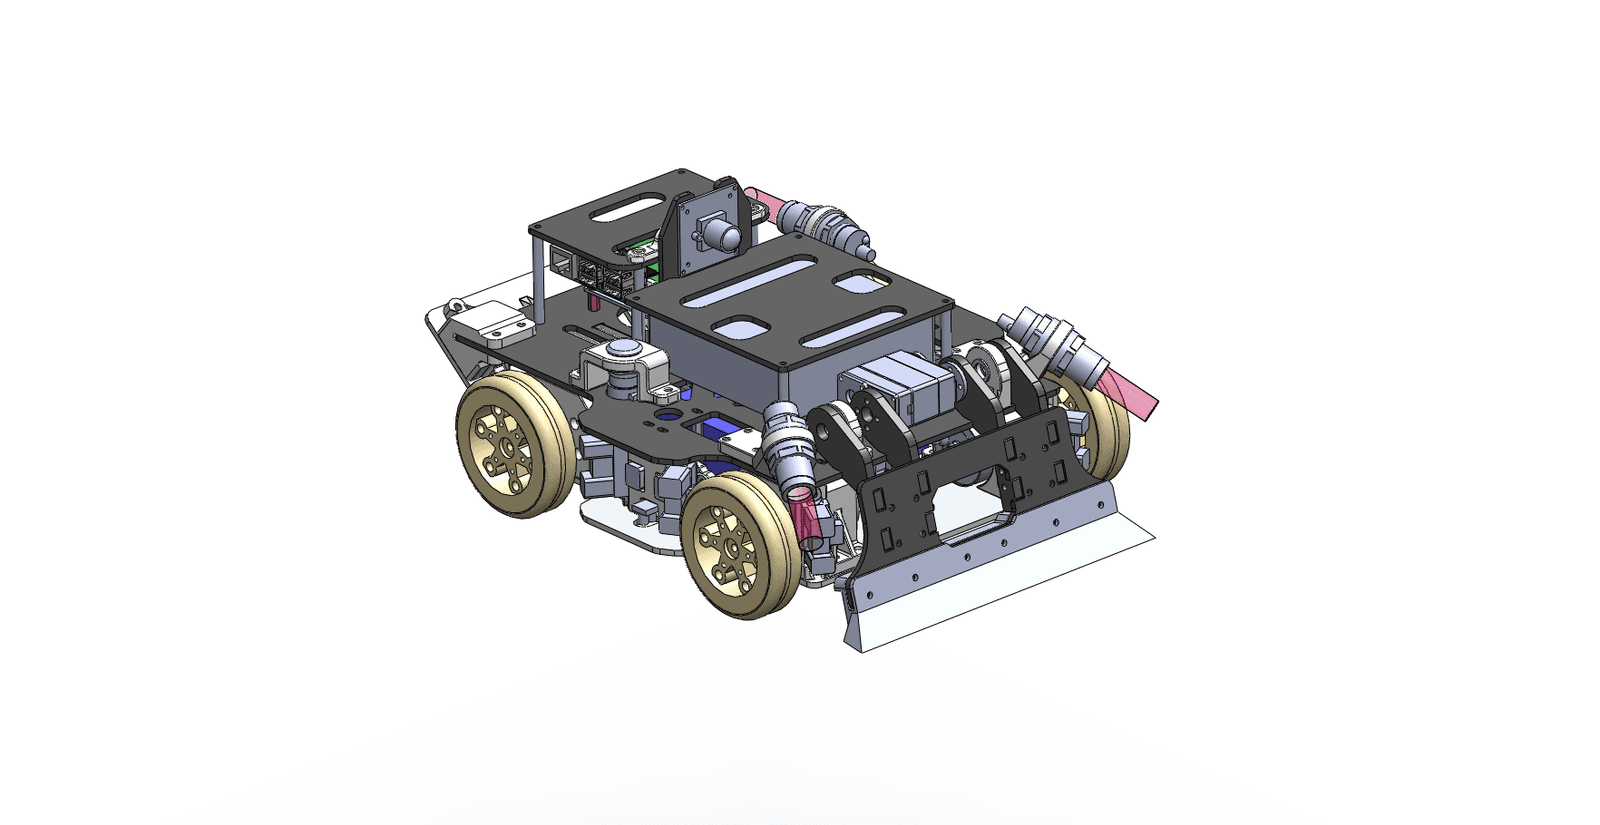
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
- Work in progress
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
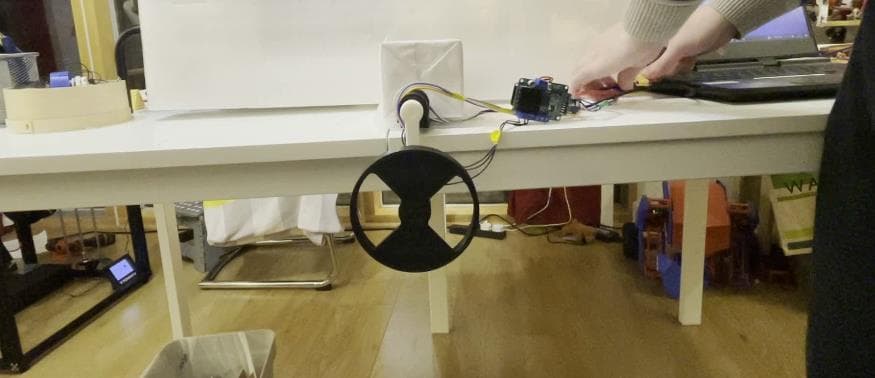
A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
A low-cost, small inverted pendulum robot using DengFOC motor driver and SimpleFOC for balance control.
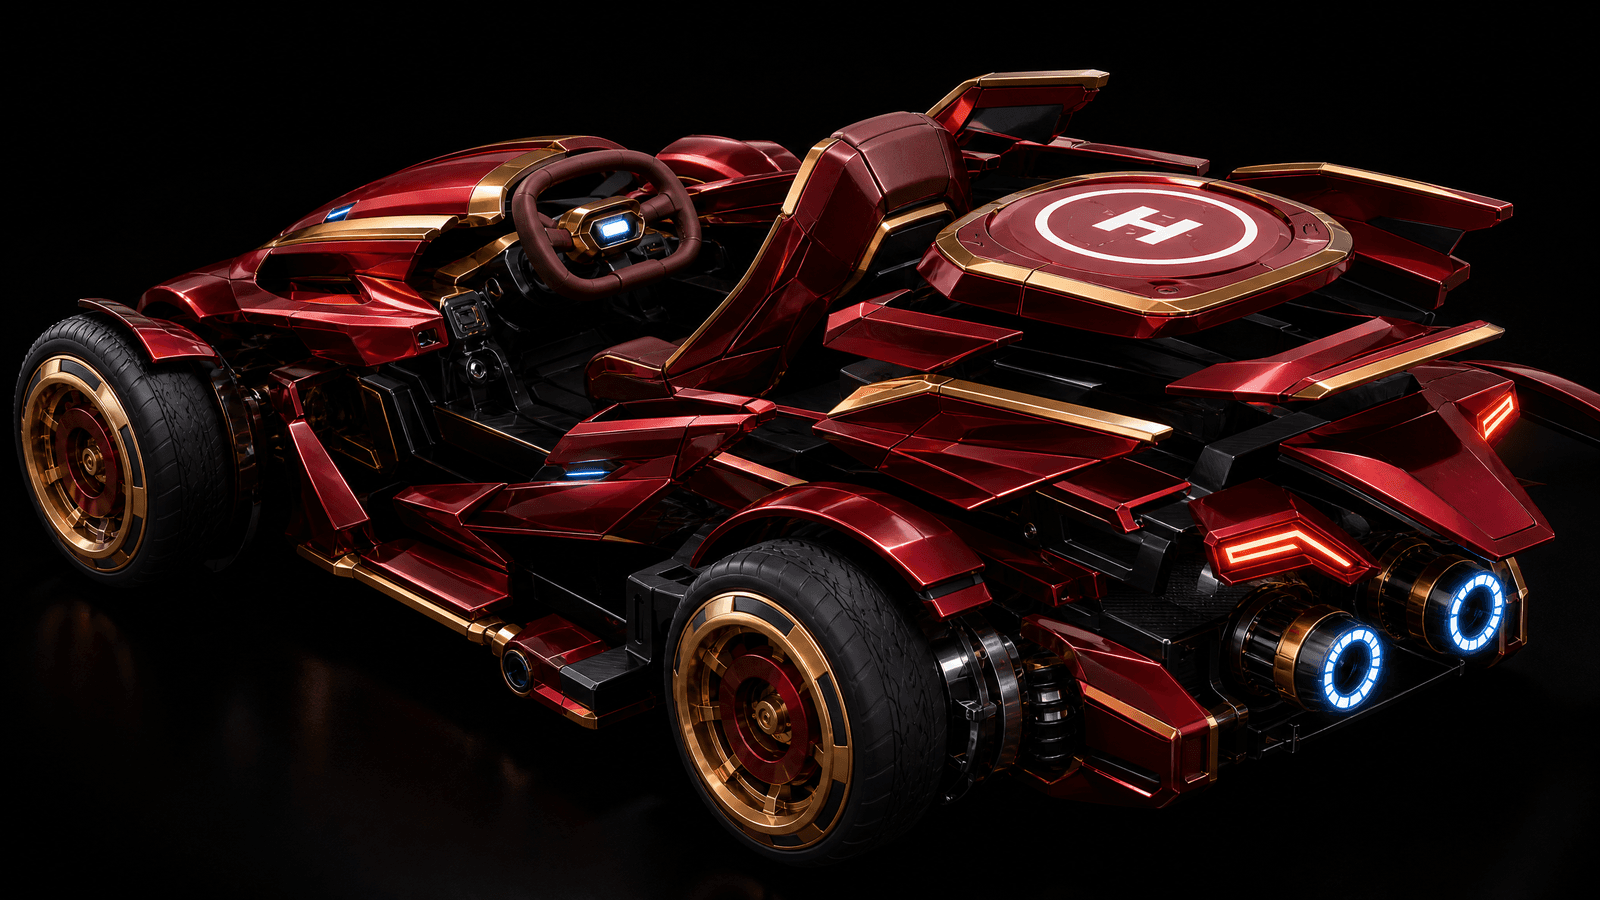
An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.
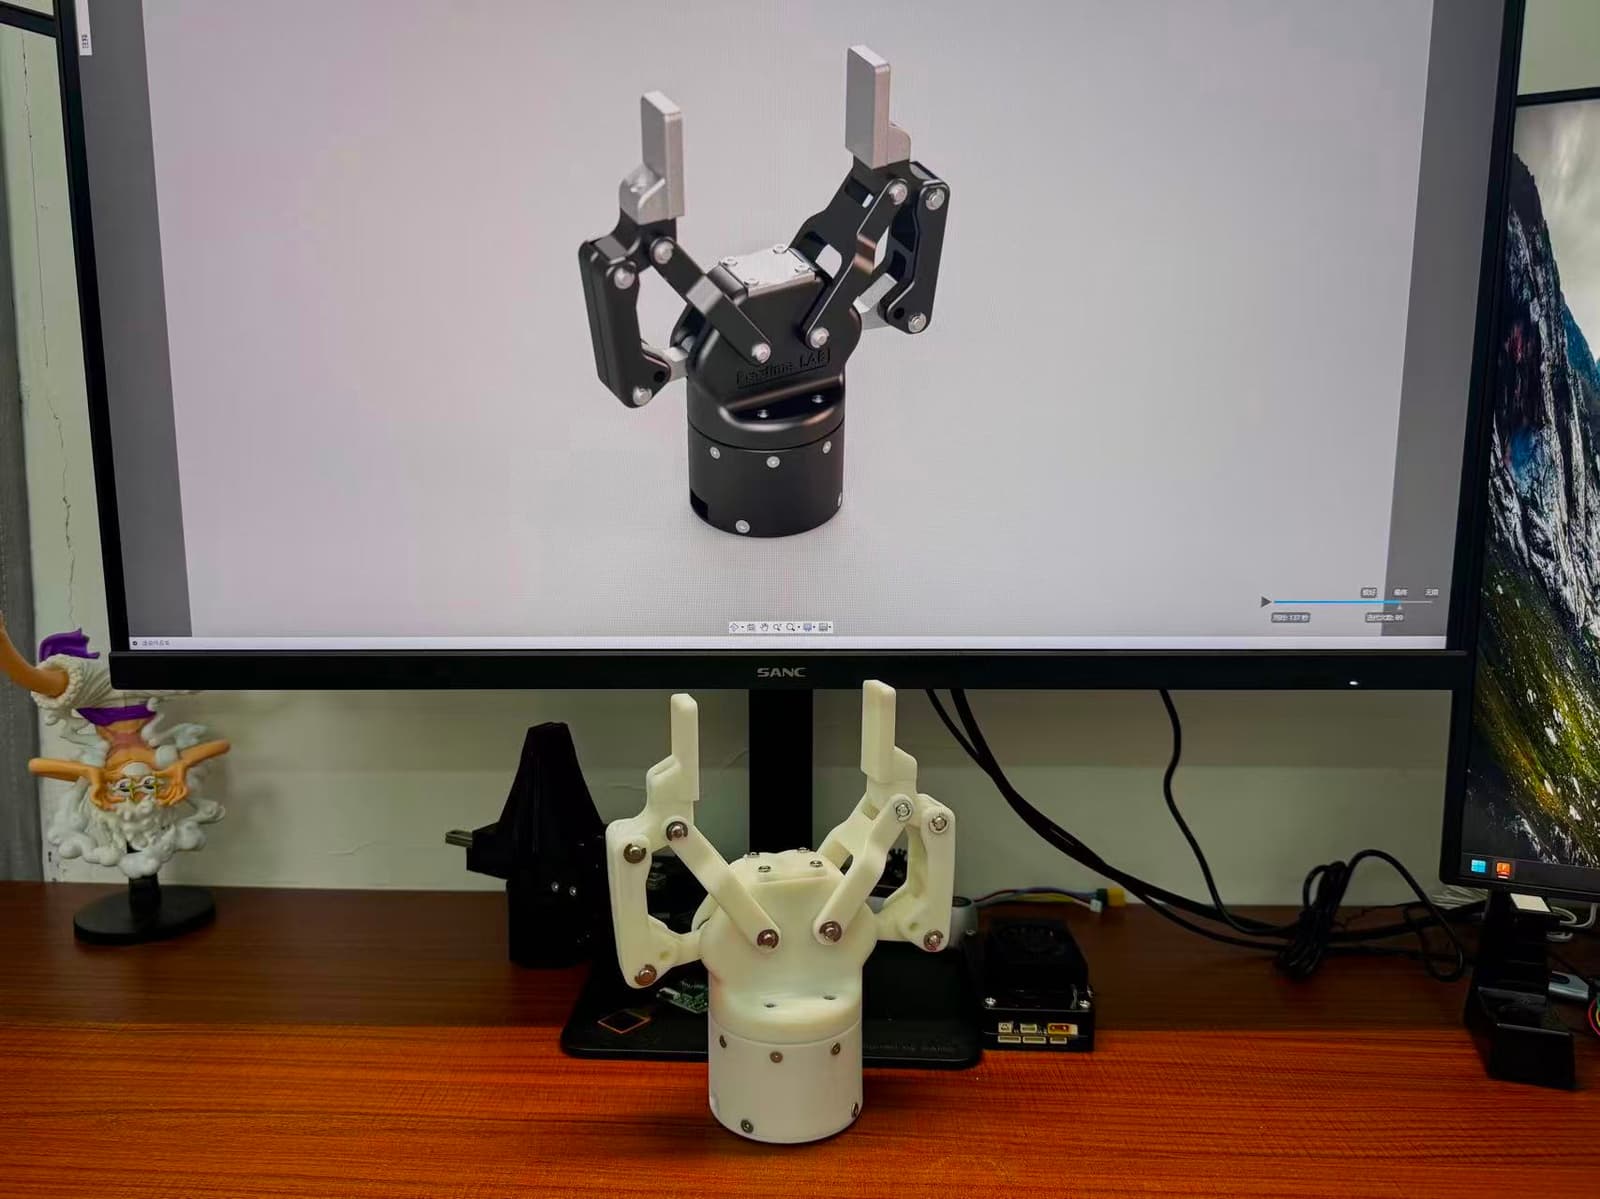
An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.
A writing robot with a 2040 aluminum frame and Core-XY structure that automates handwriting tasks.
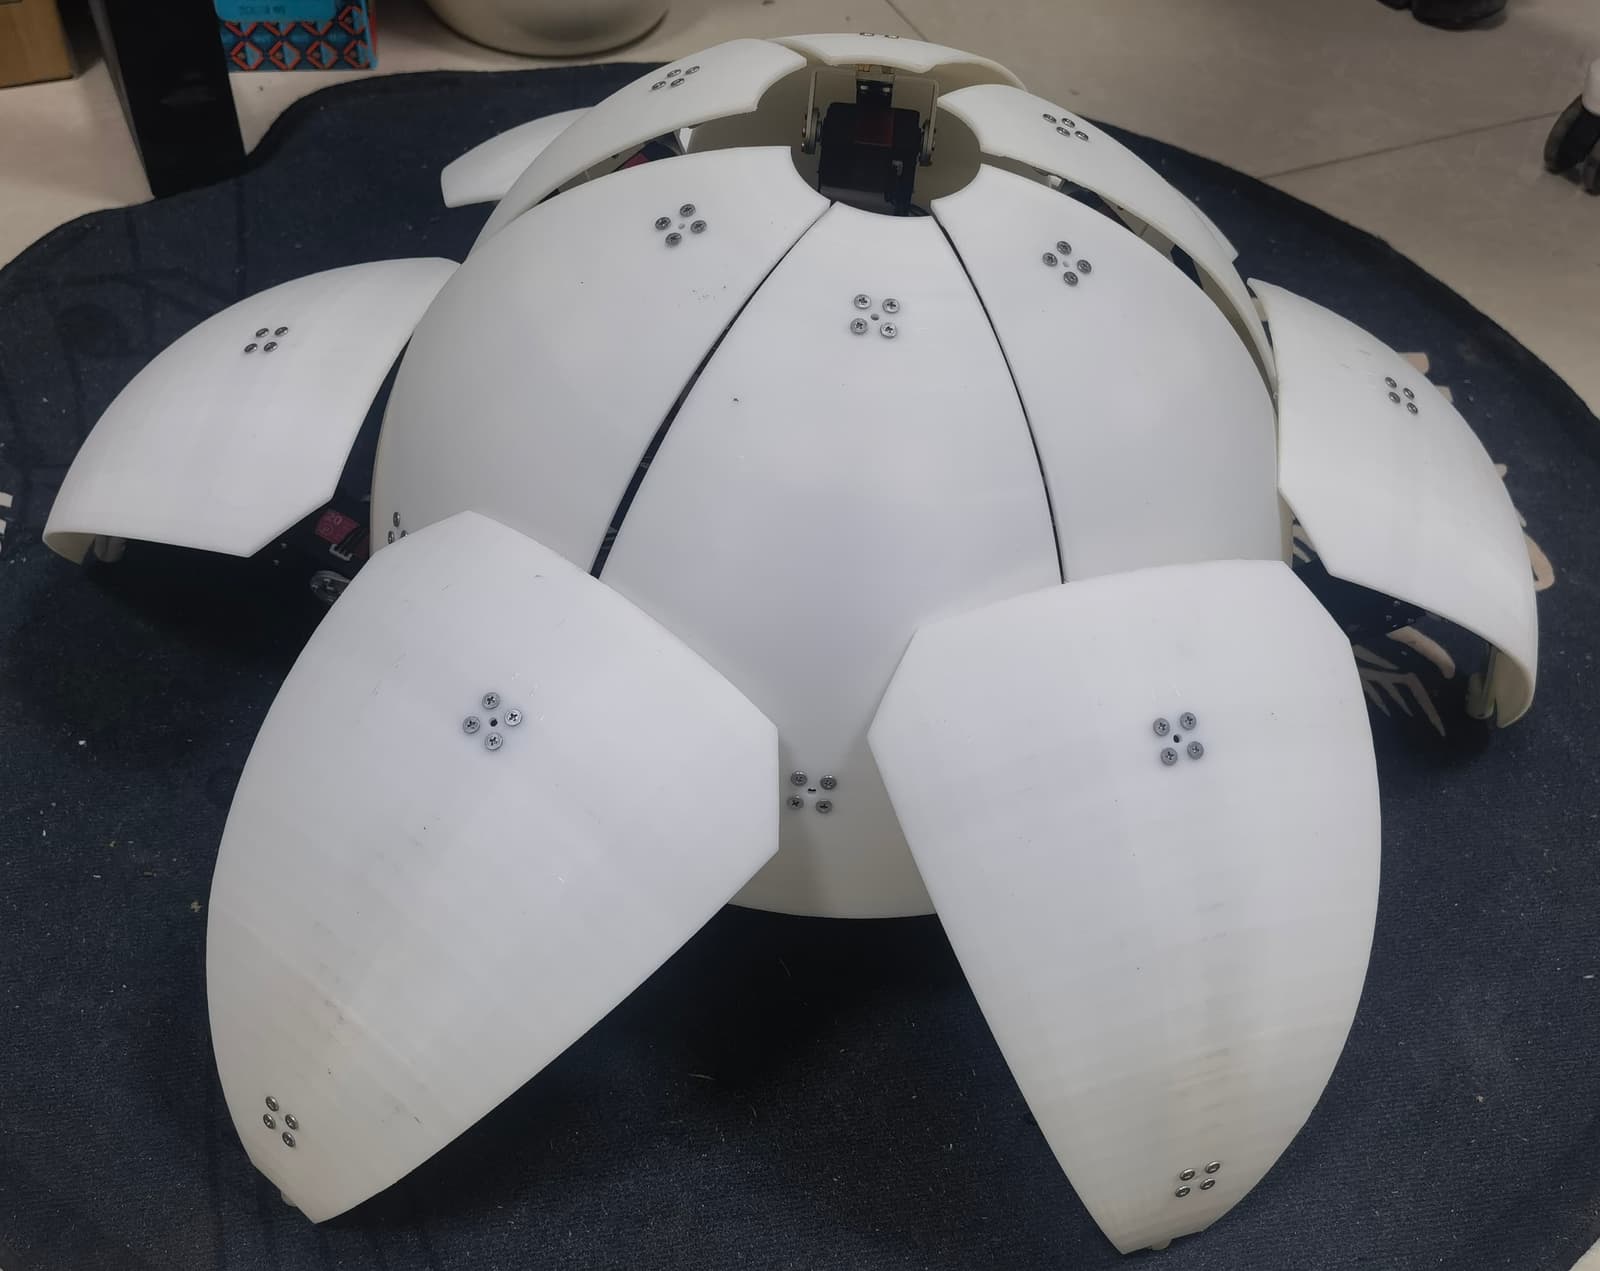
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.
A low-cost ROS2 robot designed for students and hobbyists to learn robotics and ROS2 development through hands-on assembly and programming.
Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.