 Humanoid
Roboto Origin
A fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
- Work in progress
- Works with AI
- Level
- Advanced
- Buildability
- 81/100
- Well documented, not finished yet
- Cost
- Not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
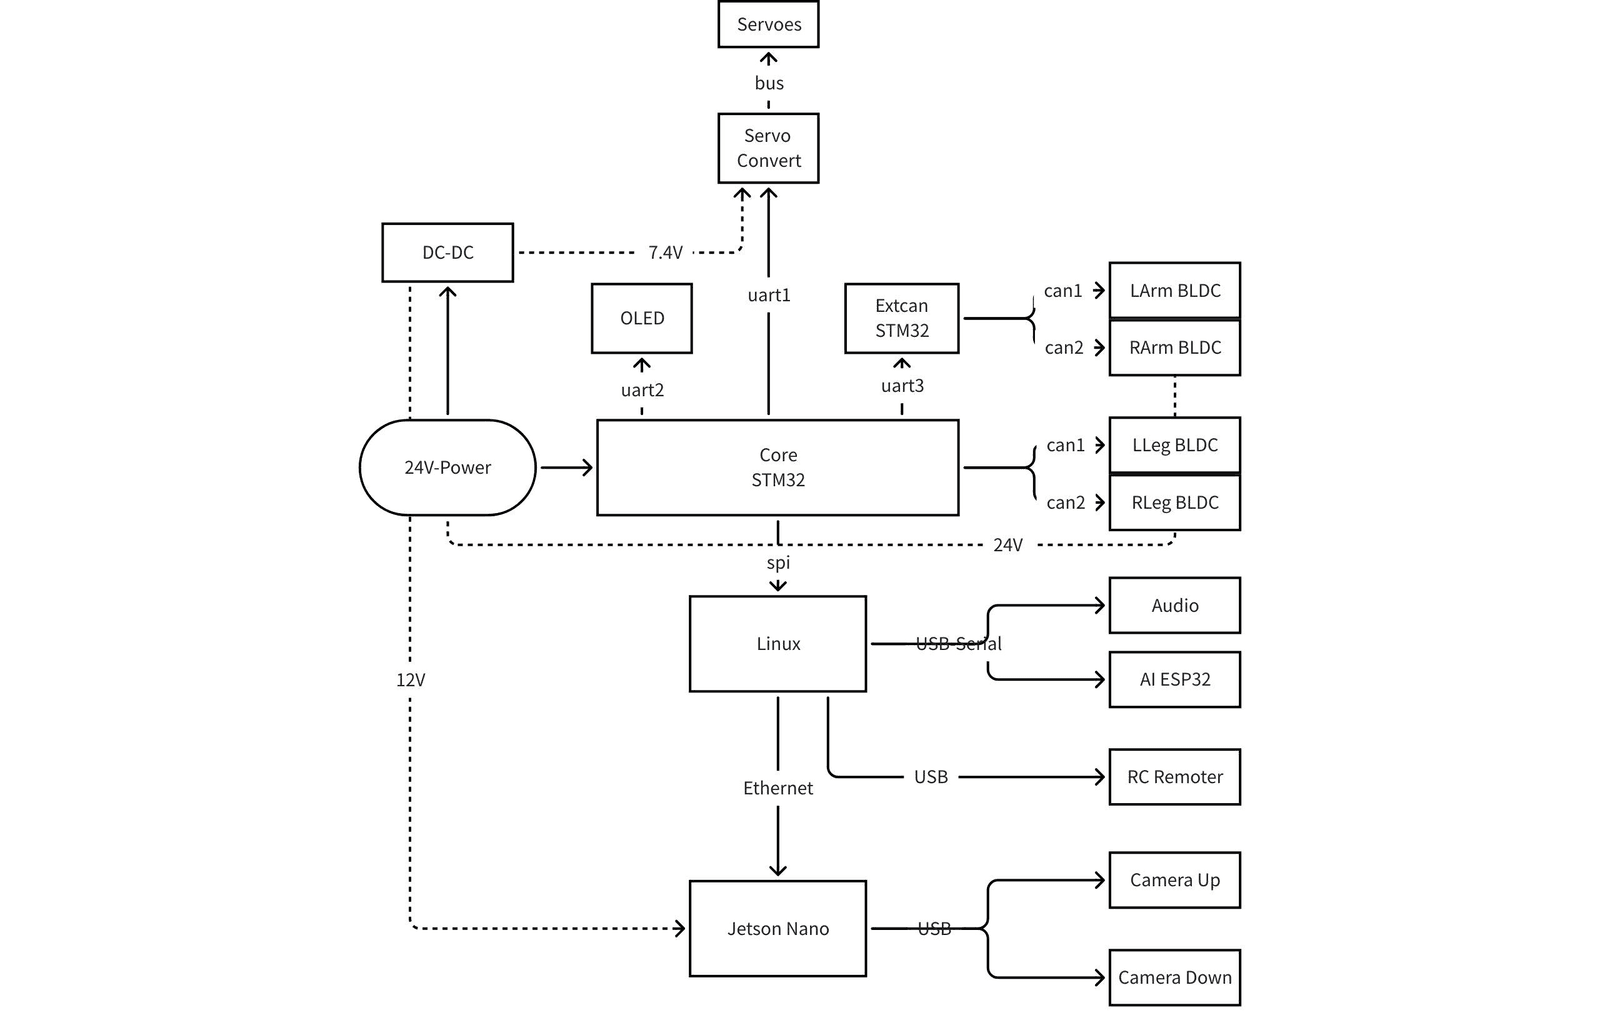
HumanoidA fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
 Humanoid
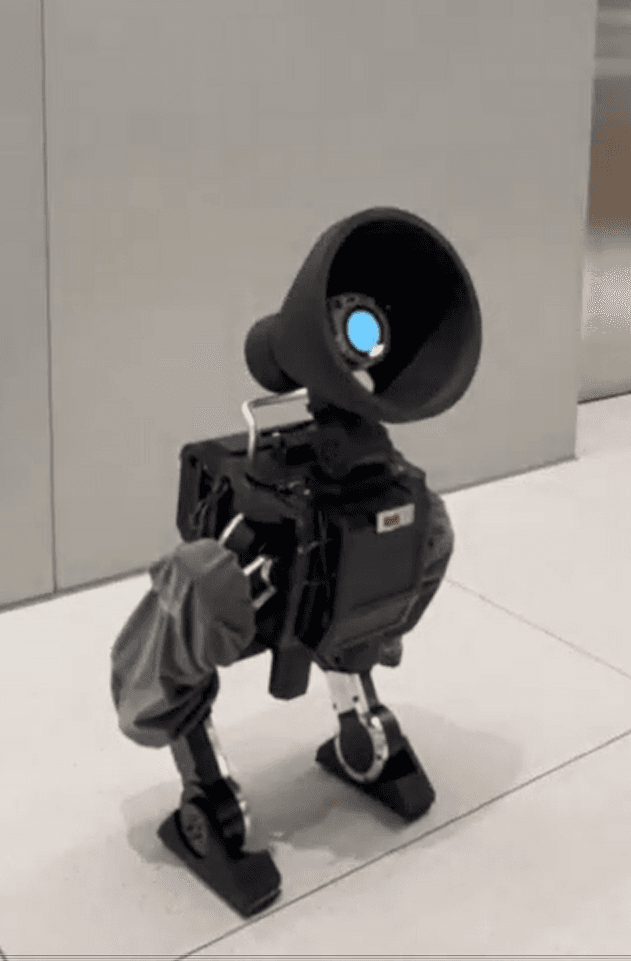
A small 22-degree-of-freedom humanoid robot designed for reinforcement learning and imitation learning, featuring a rotatable waist, head, and upper limbs.
 Humanoid
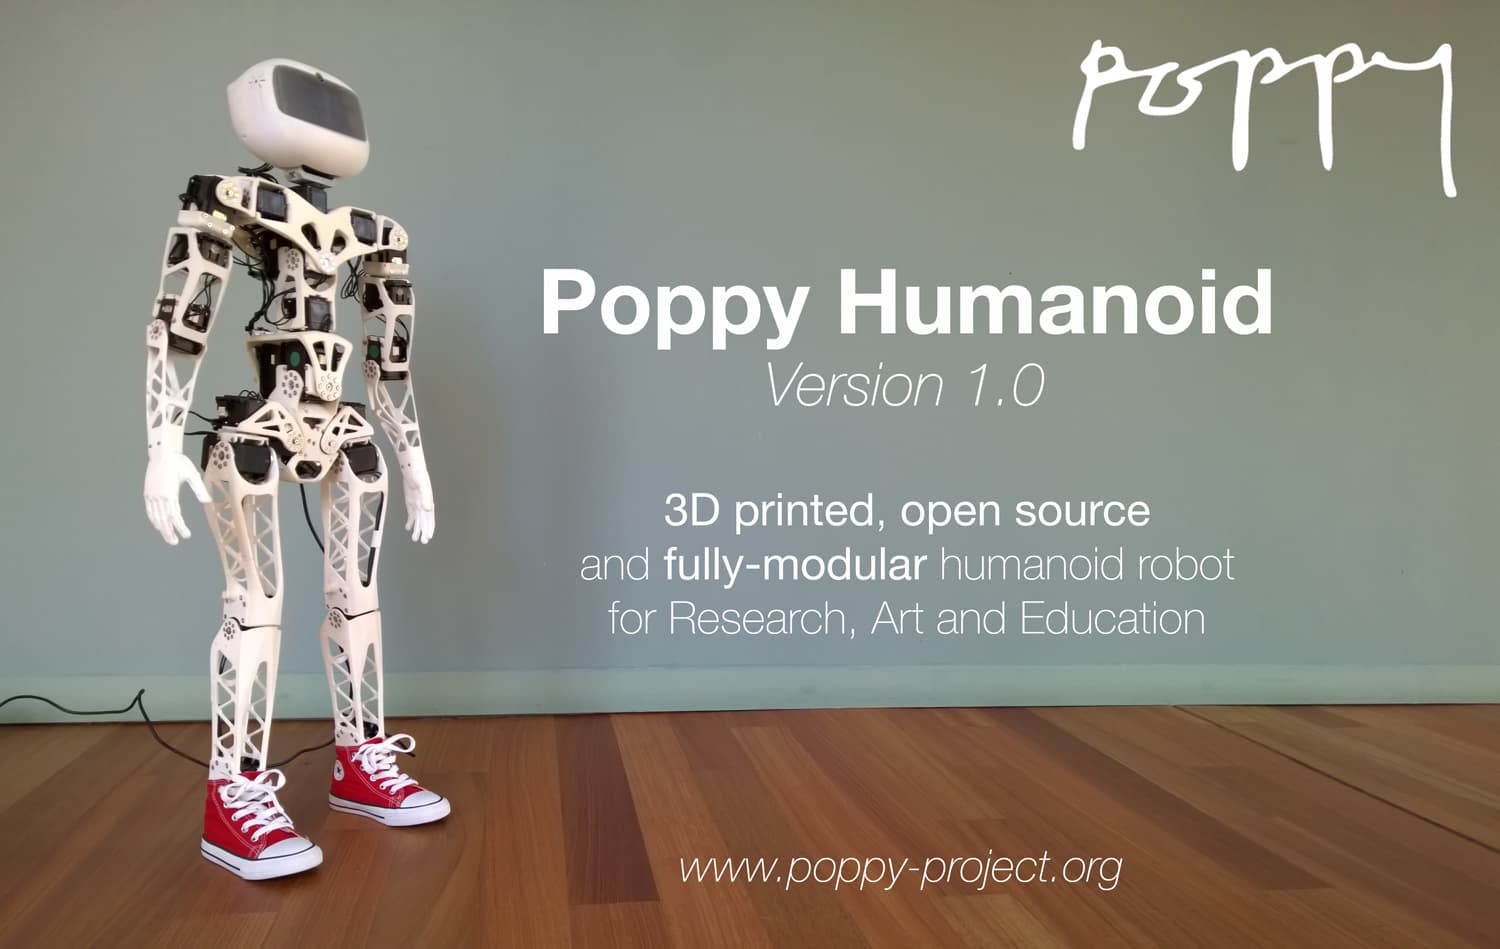
A 60 cm tall bipedal robot combining Pixar-style and Disney BDX designs, using brushless motors and reinforcement learning.
 Humanoid
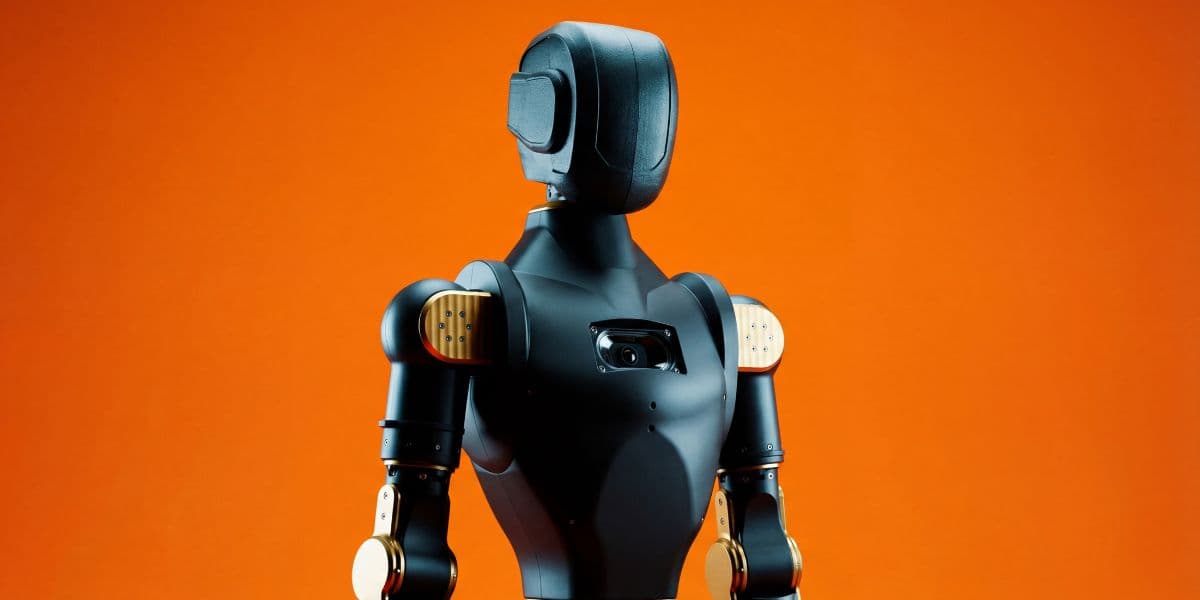
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
A modular humanoid robot designed for research and education with ROS2 integration.
 Humanoid
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
 Humanoid
An open-source, low-cost humanoid robot designed for AI experimentation and education.
An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.
 Humanoid
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
A fully open-source, low-cost, 3D-printable bipedal robot designed for hobbyists, educators, and researchers.
A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.