
Hexapod-ROS
An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
QuadrupedAdvancedBuildability 75/100 · Buildable with some effort
- Work in progress
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
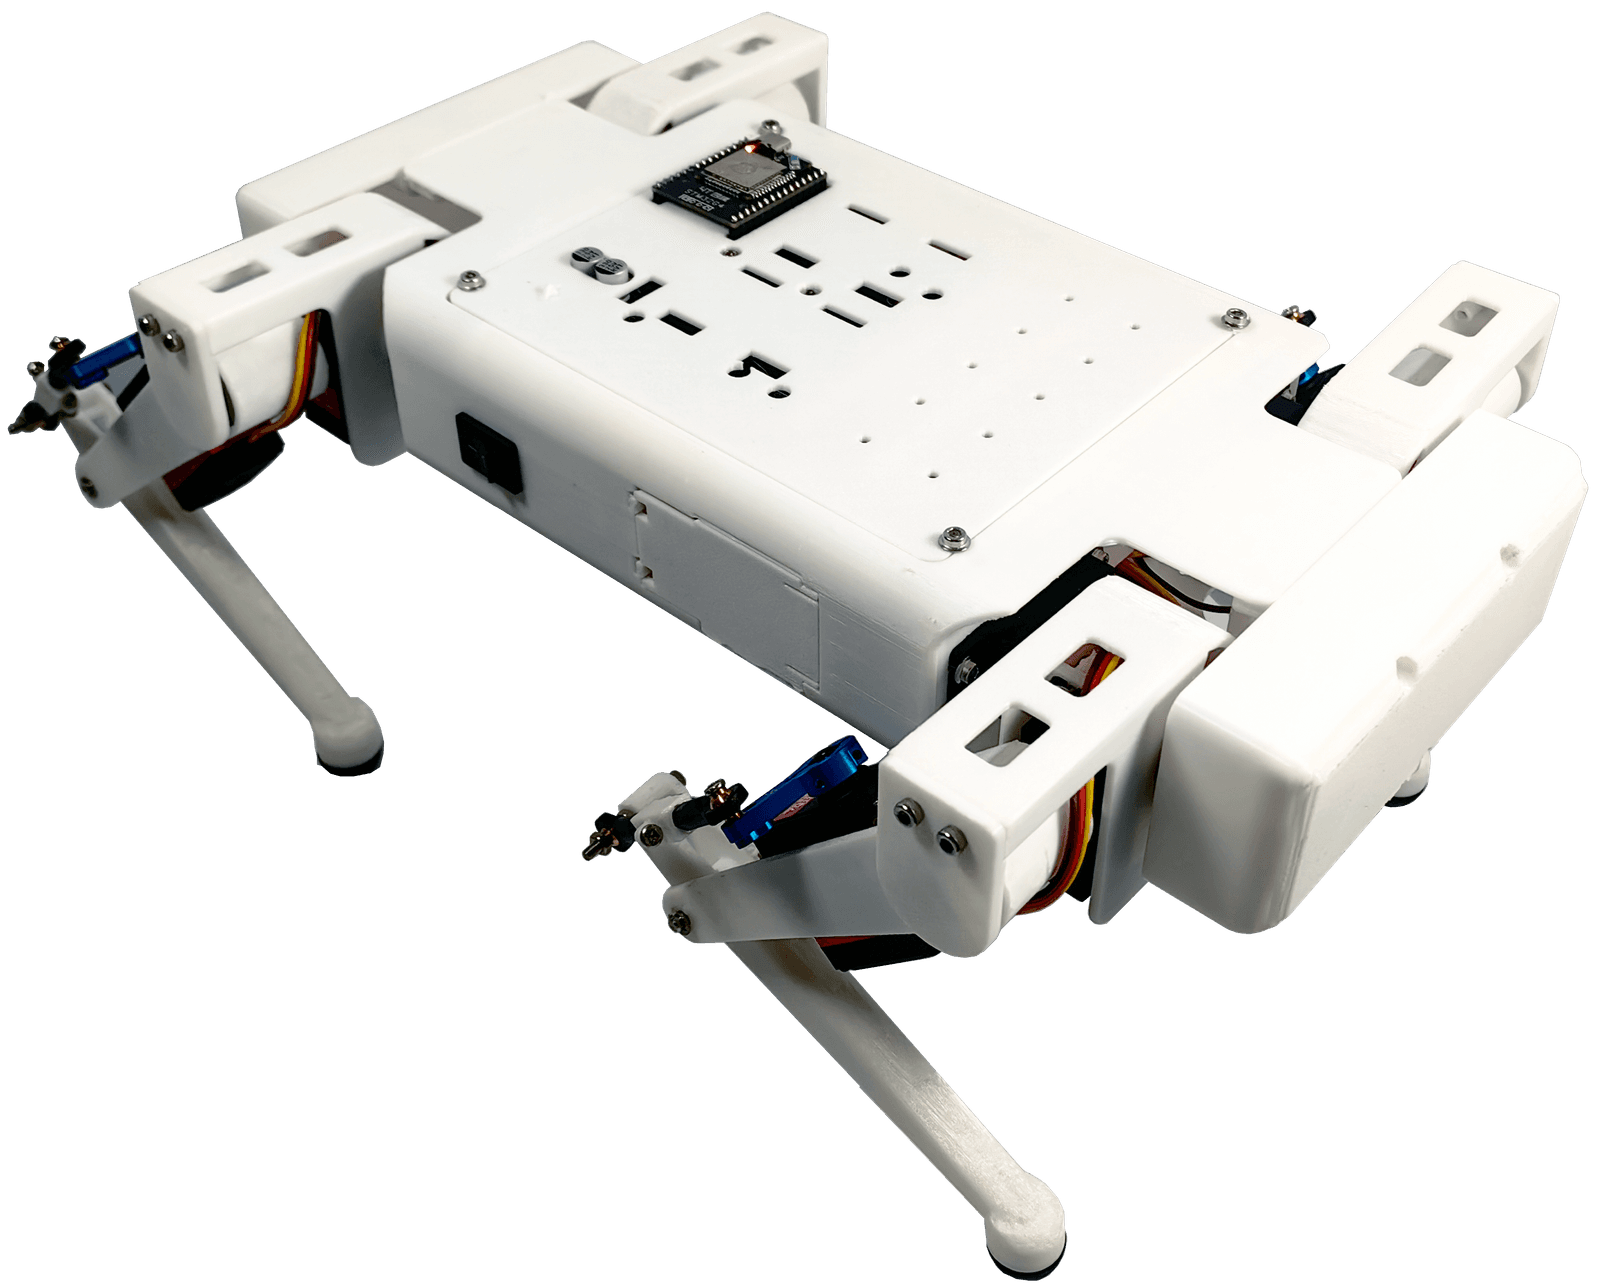
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
A desktop quadruped robot based on ESP8266 with voice control, gesture recognition, web remote, and AI conversation.
A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
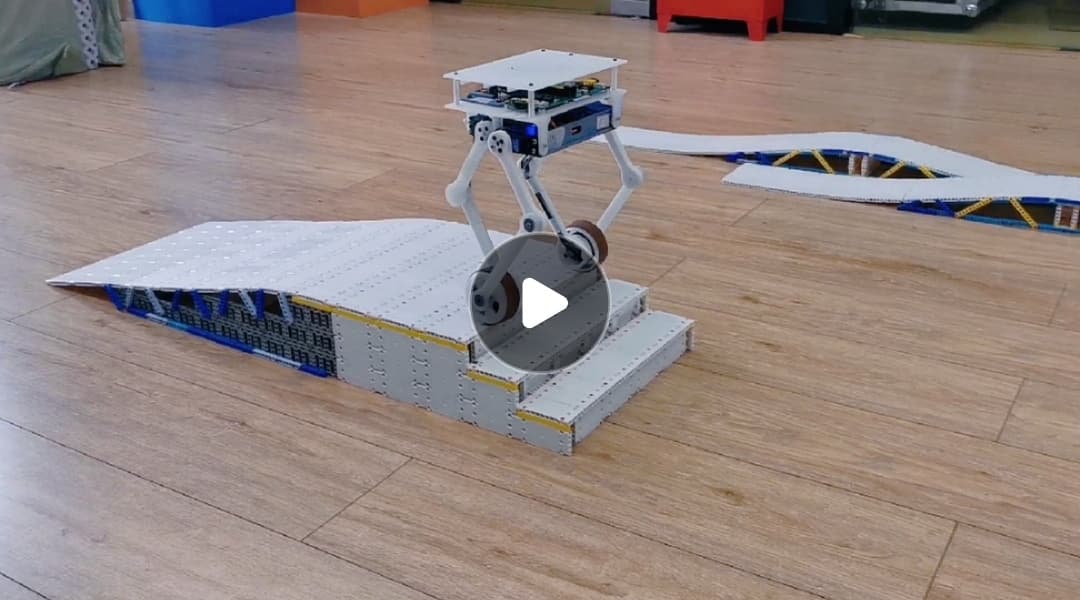
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
A beginner-friendly open-source quadruped robot with 3D-printable parts and ROS-based control software.
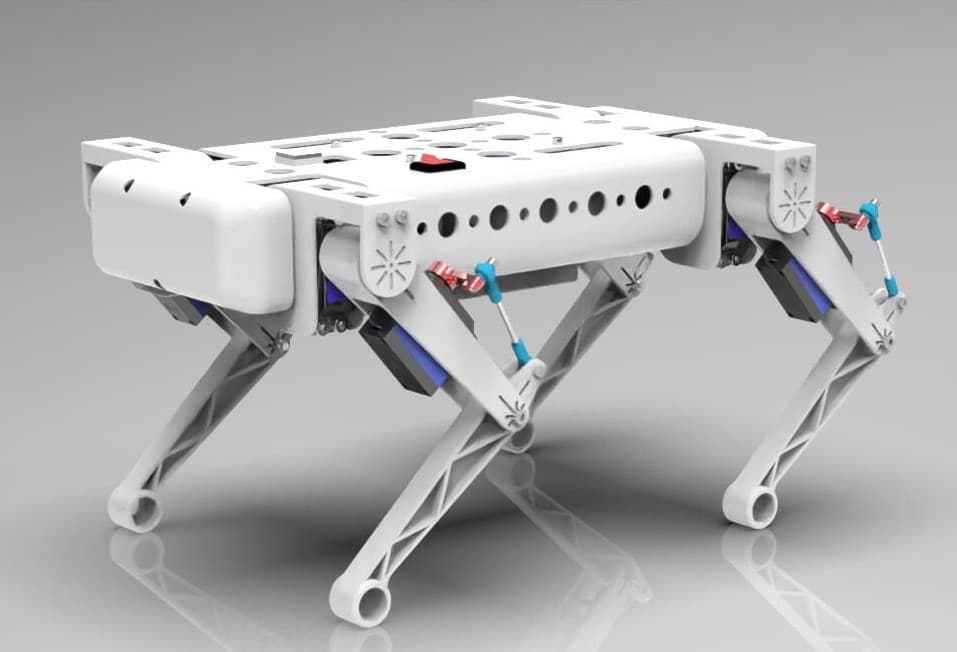
A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
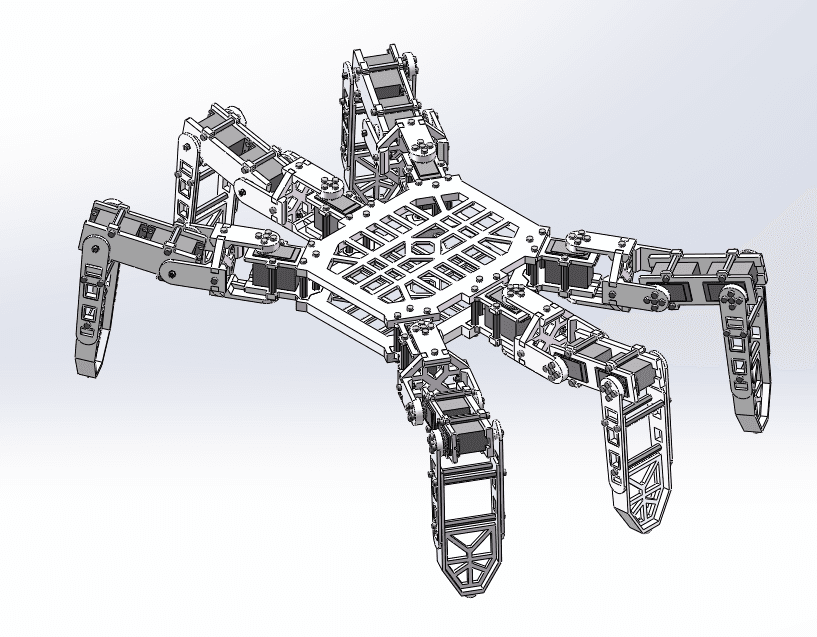
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.

A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
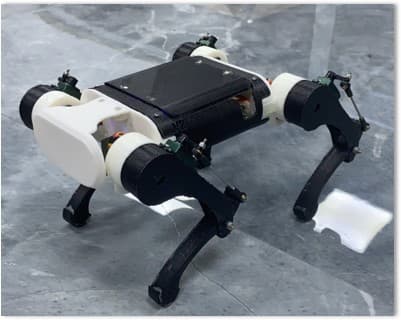
An open-source quadruped robot designed for easy DIY with low-cost hardware and software.
An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.
A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.
A compact quadruped robot designed as a desk pet, featuring FreeRTOS-based control, tomato timer, expression display, and interactive motions like walking, turning, waving, and bowing.
An open-source parallel four-legged robot with eight motors designed to achieve four gaits from slow to fast.
An open-source quadruped robot controller based on ESP32, designed to support the Py-Apple Dynamics software suite for controlling quadruped robots.