Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

5 robots of 270

Page 1 of 1 · Ready to build first, then by buildability

  • Balance Ball

    A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.

    OtherAdvancedBuildability 55/100 · Buildable with some effort
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
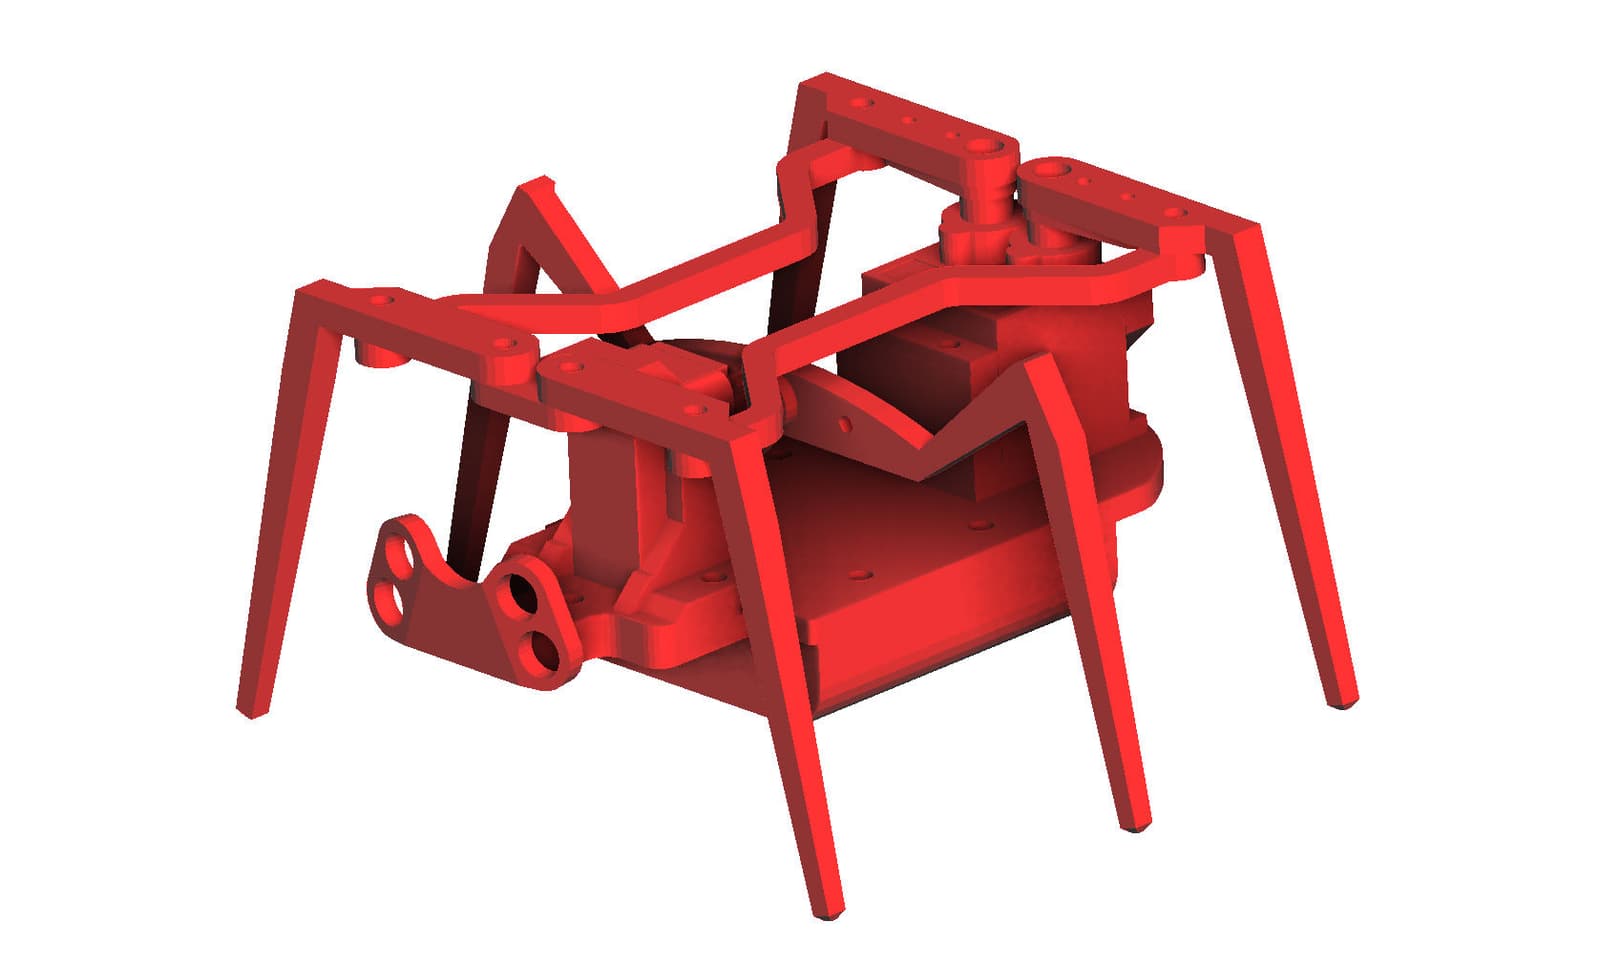
  • Penny#3

    A low-budget three-servo hexapod robot that walks, dances and avoids obstacles using infrared proximity sensors.

    OtherIntermediateBuildability 45/100 · Incomplete documentation
    €10
  • RhinoV2.0 Adaptive Gripper

    An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.

    OtherIntermediateBuildability 45/100 · Incomplete documentation
    ¥1,000≈ €133 (ECB rate, 14 Oct 2026)
  • Woodpecker Writing Machine

    A low-cost DIY writing machine that draws on a vertical surface using two stepper motors and a servo-controlled pen.

    OtherIntermediateBuildability 40/100 · Incomplete documentation
    • Work in progress
    • No license
    ¥25.80≈ €3 (ECB rate, 14 Oct 2026)
  • LEAP ROS2

    A low-cost ROS2 robot designed for students and hobbyists to learn robotics and ROS2 development through hands-on assembly and programming.

    OtherIntermediateBuildability 25/100 · Incomplete documentation
    ¥200≈ €27 (ECB rate, 14 Oct 2026)

More to explore