Open source · free files
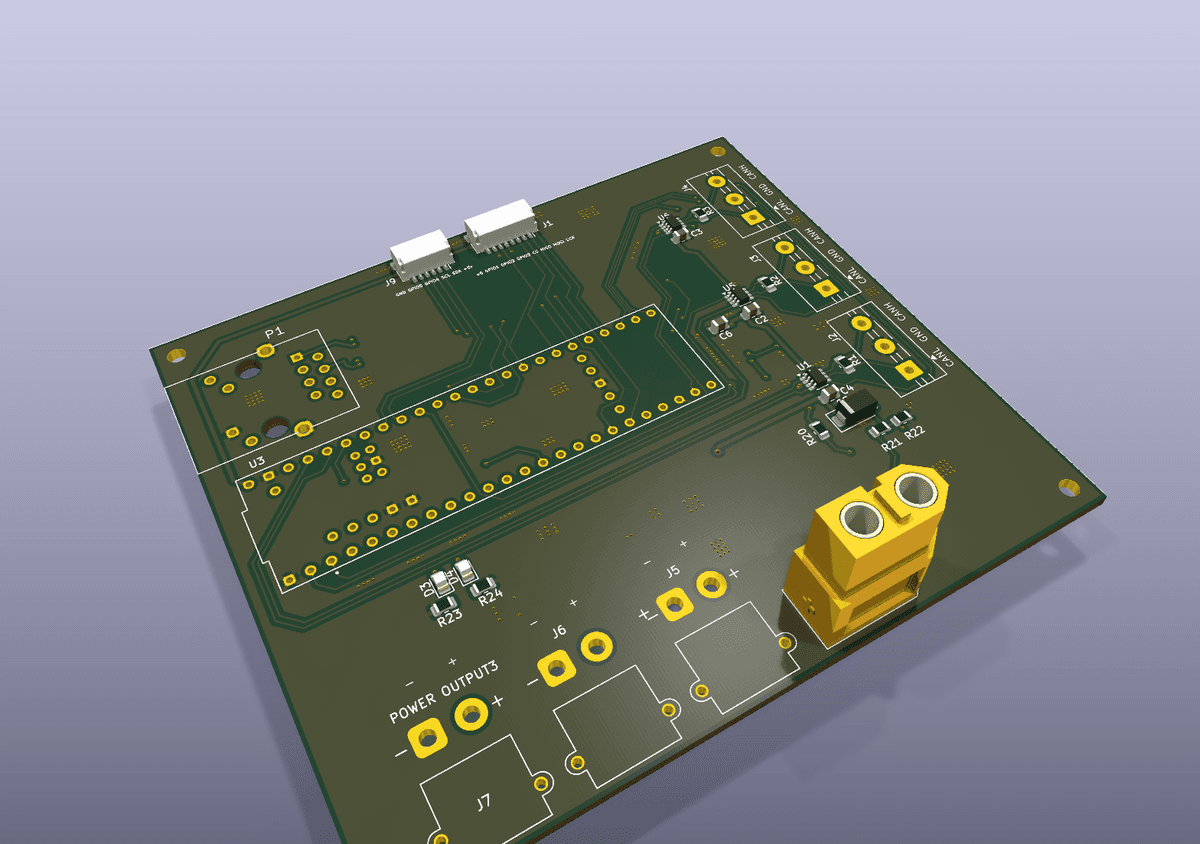
MABEL
Home · Advanced
- Score
- Buildability 96 out of 100
- Cost
- $8,056.03≈ €7,330without what the creator lists as not costed yet: the hands' frames and tendons, two Teensy 4.1 boards, the custom PCBs
Ambitious open projects that work. Not all are easy or cheap to rebuild.
Open source · free files
Home · Advanced
Open source · free files
Humanoid · Advanced
Open source · free files
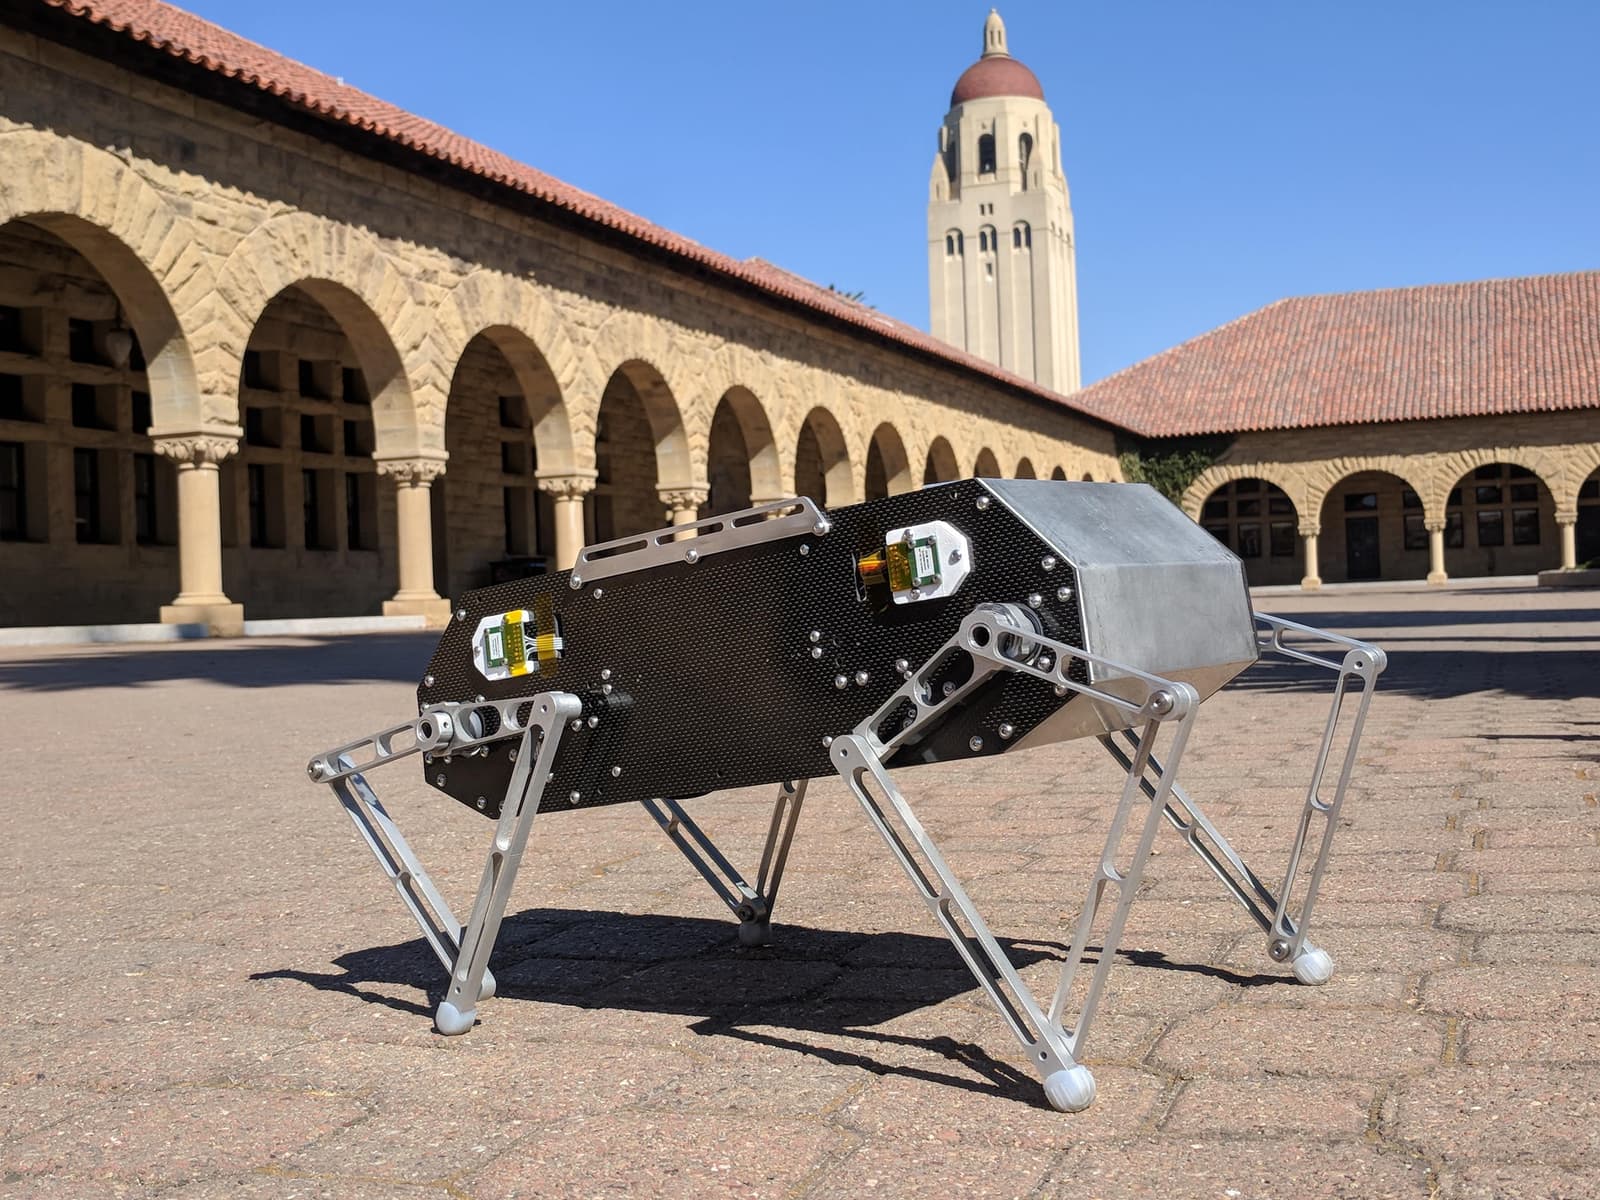
Quadruped · Advanced
Open source · free files
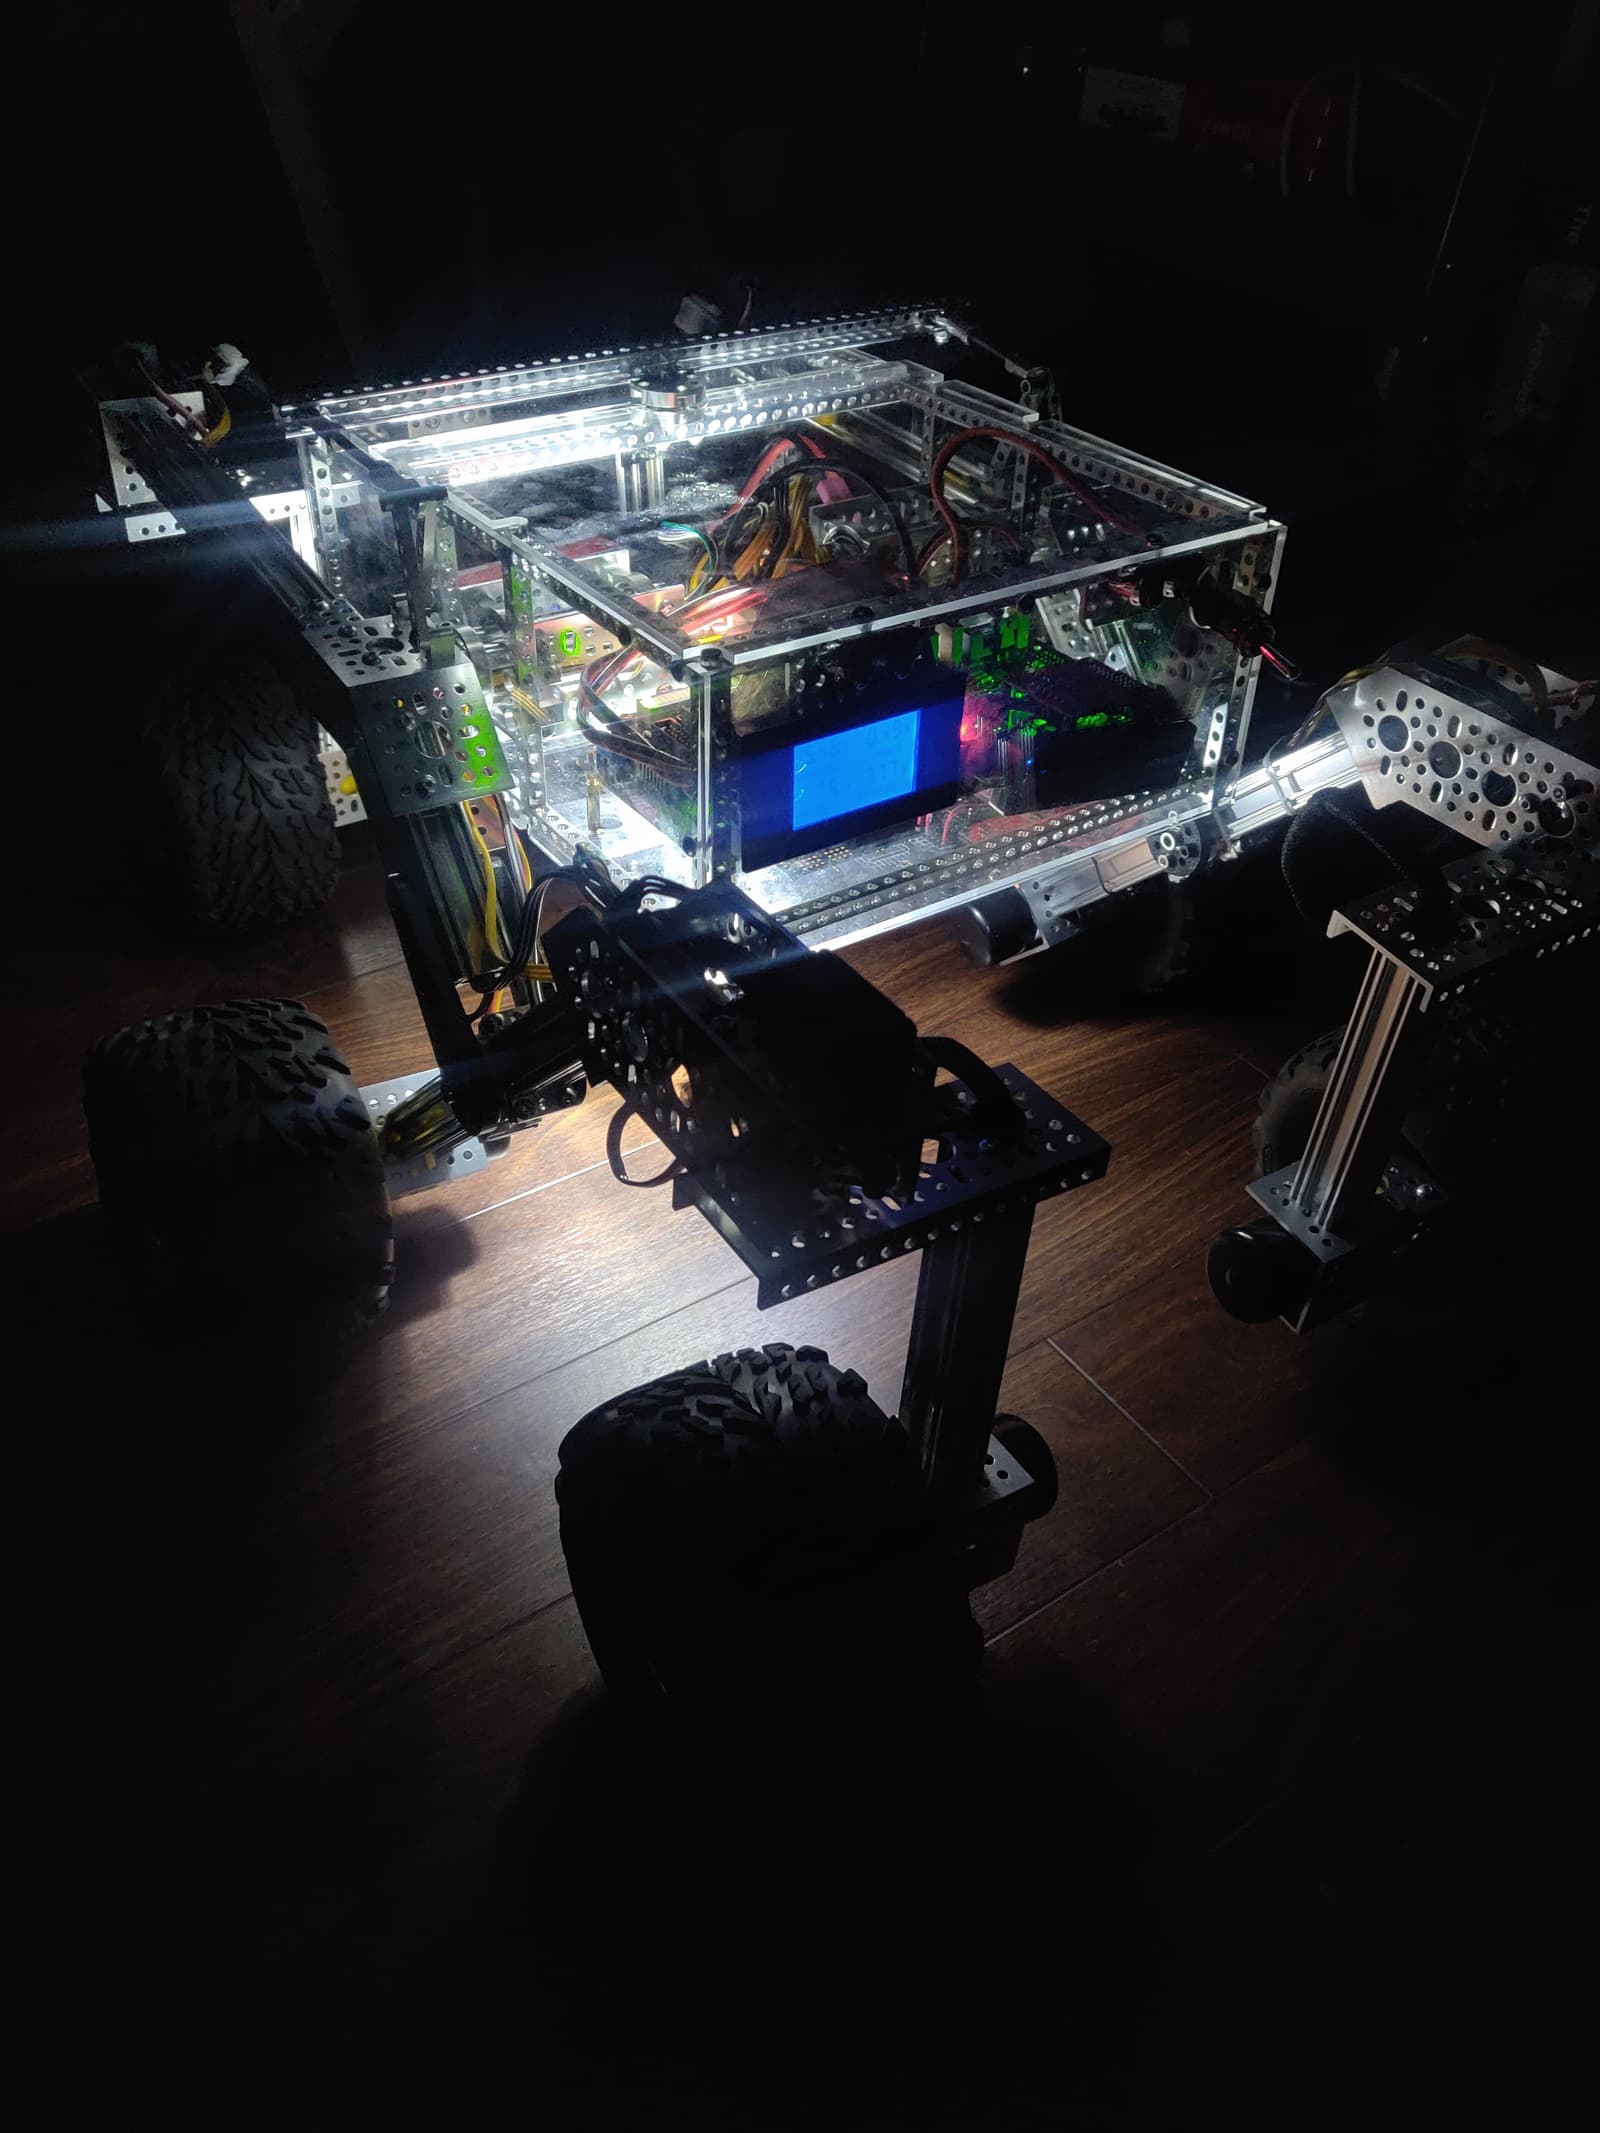
Wheeled · Intermediate

Open source · free files
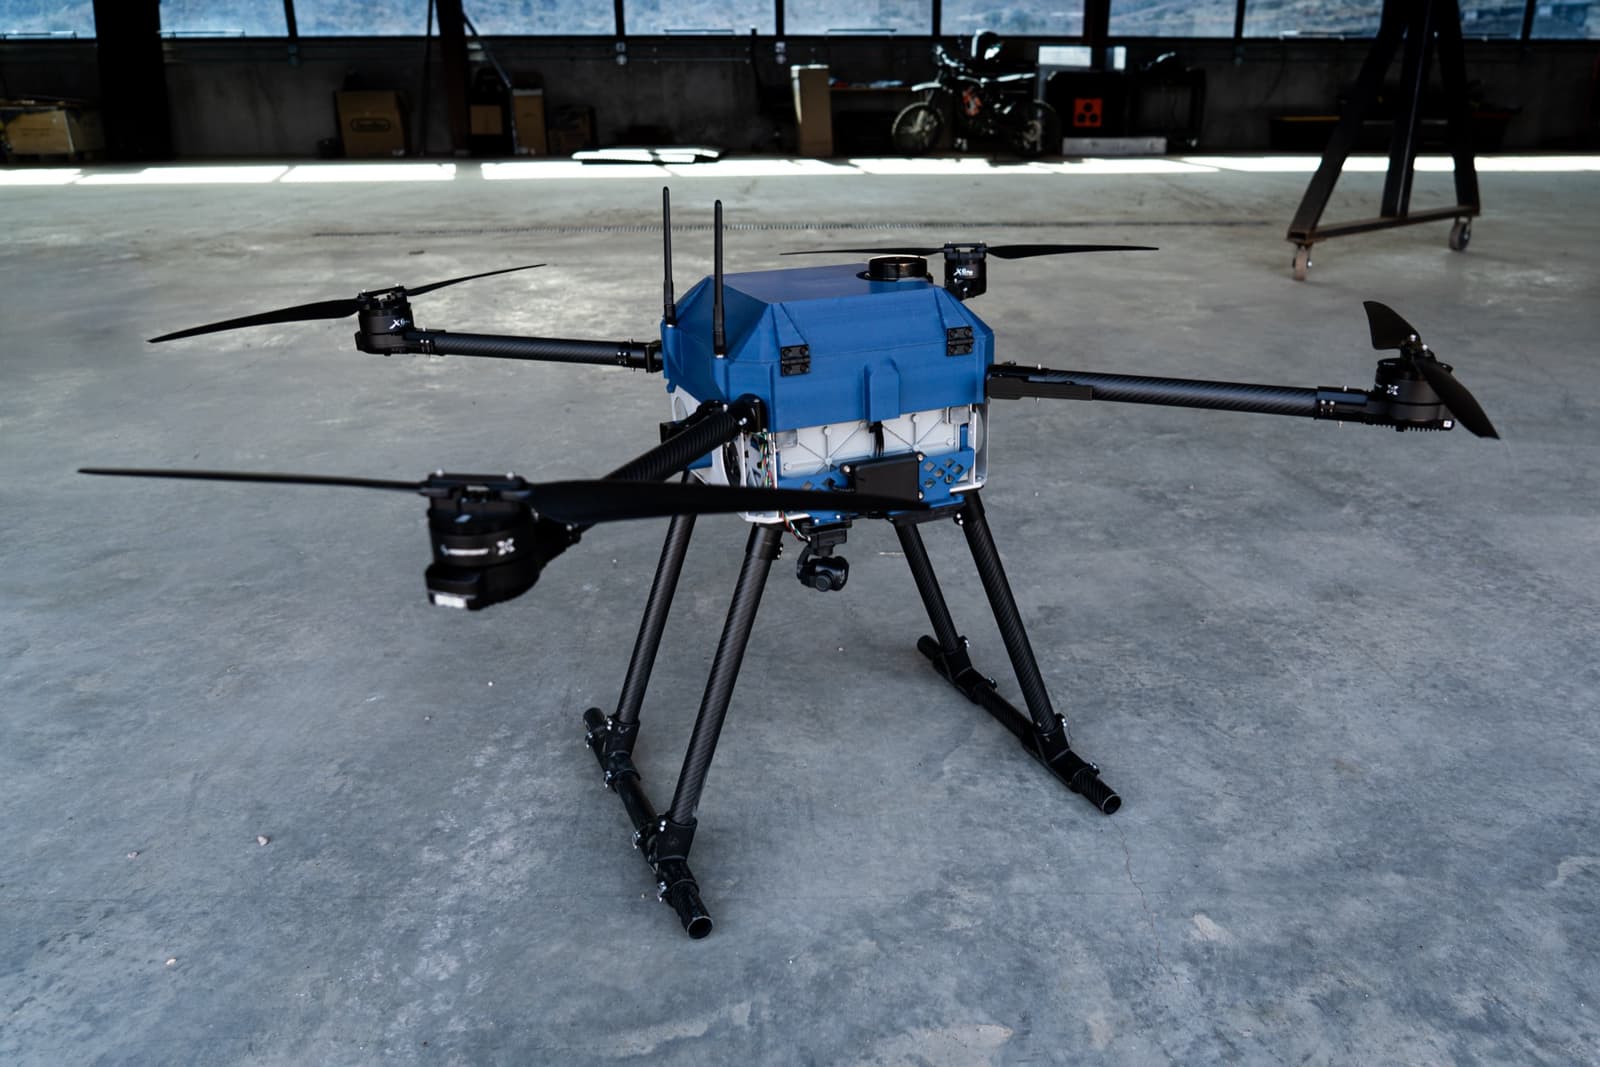
Drone · Advanced
Experimental, check your local rules
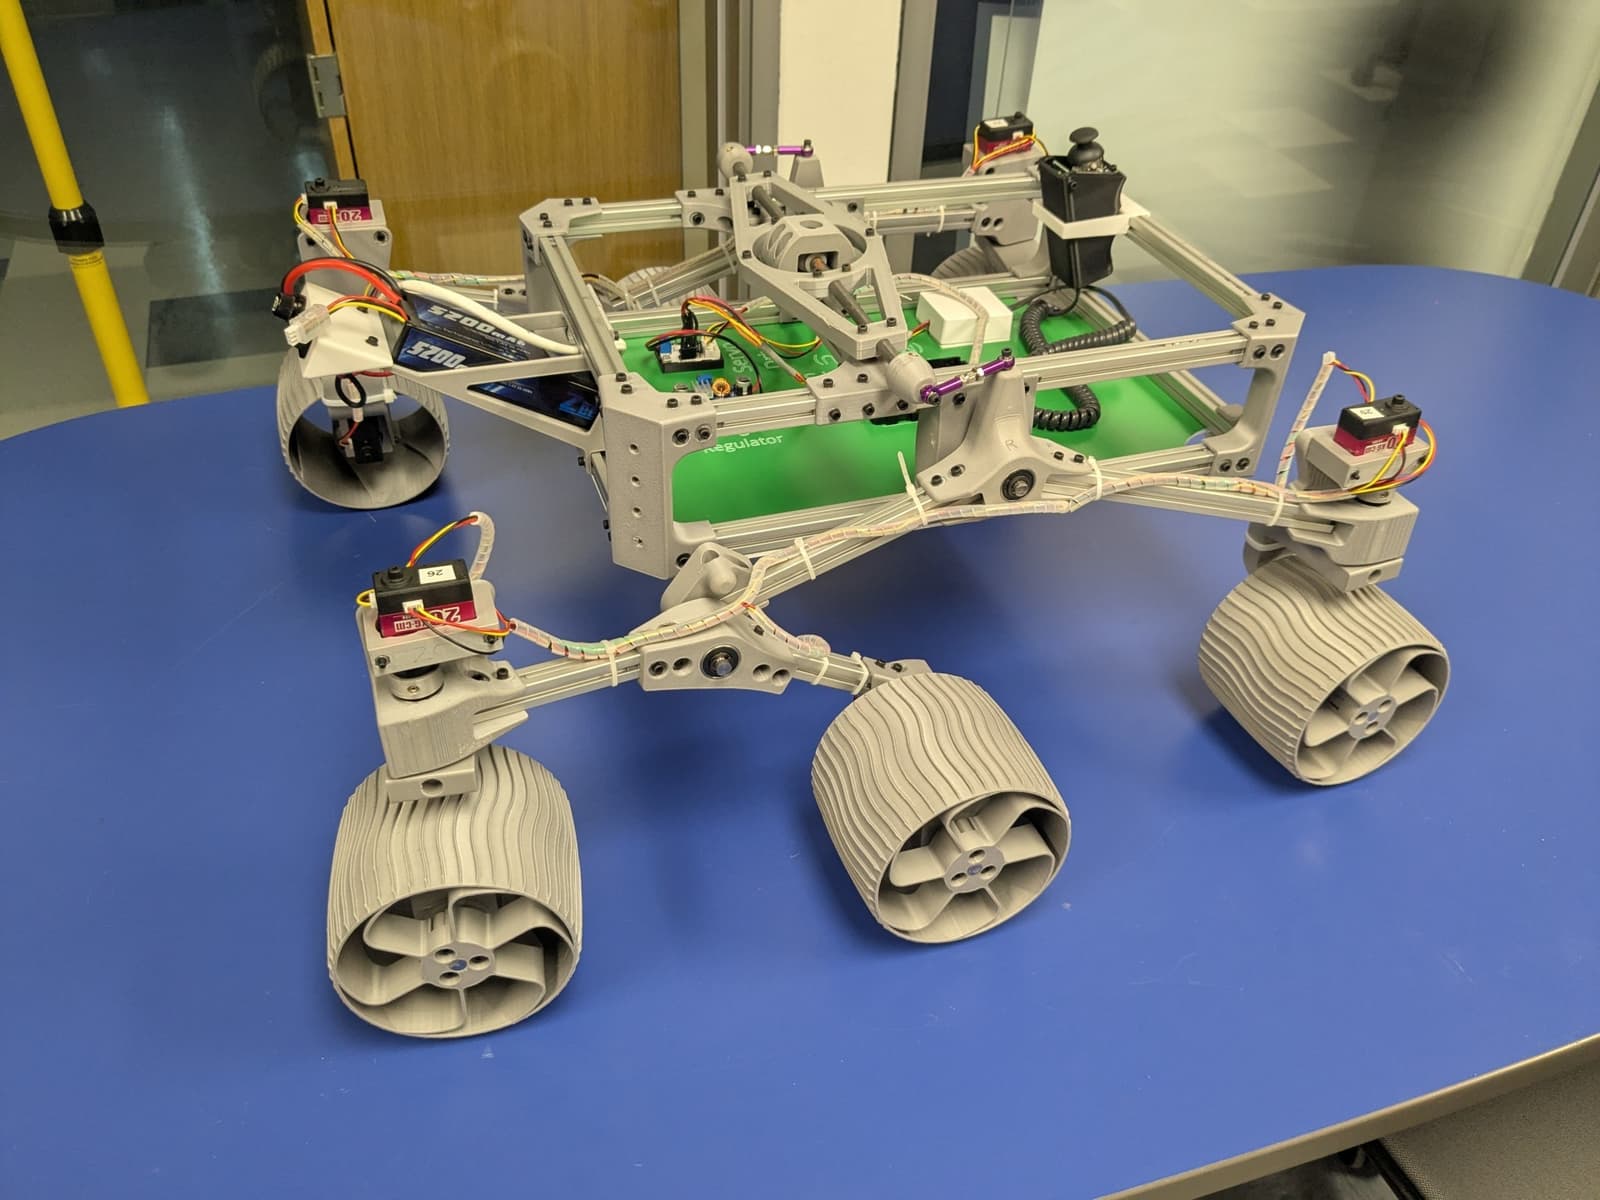
Open source · free files
Wheeled · Intermediate
F´ is a component-driven C++ framework for building flight software and other embedded applications, originally developed at JPL and aimed at small spacecraft like CubeSats.
ASAP is a framework for training agile whole-body skills on humanoid robots, transferring policies from simulation to real hardware. It builds on the HumanoidVerse and Human2Humanoid codebases.
A Python graph-based local trajectory planner for vehicles that returns a set of cost-optimal actions such as keep straight, pass left, or pass right. It was used on a real race vehicle.
Experimental, check your local rules
Computes an optimal racing line for a race track, using several objectives such as shortest path, minimum curvature, or minimum time, including powertrain effects.
Experimental, check your local rules
Code for training and flying a learned navigation policy that lets a quadrotor fly at high speed through cluttered simulated environments, using a neural network with a pre-trained checkpoint.
A learning framework that trains quadruped robots to perform parkour-style skills such as climbing, leaping and crawling over obstacles, with policies trained in simulation and deployed on hardware.
Training and playback code for a legged-robot policy that learns extreme parkour skills, built on Isaac Gym and the legged_gym framework.
VideoMimic learns humanoid robot control by imitating human motion seen in single-camera videos, reconstructing both the scene and the motion. It is a CoRL 2025 research project from UC Berkeley.
Precision mapping and section control software for agricultural guidance, reading GPS NMEA data to steer vehicles along reference lines and control implement sections.
Experimental, check your local rules
PyTorch code for training humanoid robots to stand up from diverse postures, using reinforcement learning in simulation. It targets the Unitree G1 and H1 and was presented at RSS 2025.
Flightmare is a modular quadrotor simulator pairing a configurable Unity-based rendering engine with a separate physics engine for flight dynamics.
Research code that trains and deploys reinforcement-learning locomotion policies for the Unitree Go1 quadruped, using Isaac Gym simulation and multiplicity-of-behavior tuning.
A framework that lets humanoid robots perform long-horizon, vision-based parkour across obstacle courses by chaining retargeted human skills via motion matching.
A MuJoCo simulation codebase for tracking human motions with a Unitree G1 humanoid robot, using a pretrained whole-body control policy. Intended for research use.
A whole-body control model for humanoid robots that lets them move with coordinated legs and arms, shown running in the MuJoCo simulator.