Software
Robot Parkour Learning
From github.com/ZiwenZhuang/parkour (opens in a new tab)
- Humanoids and robot learning
- Framework
- MIT
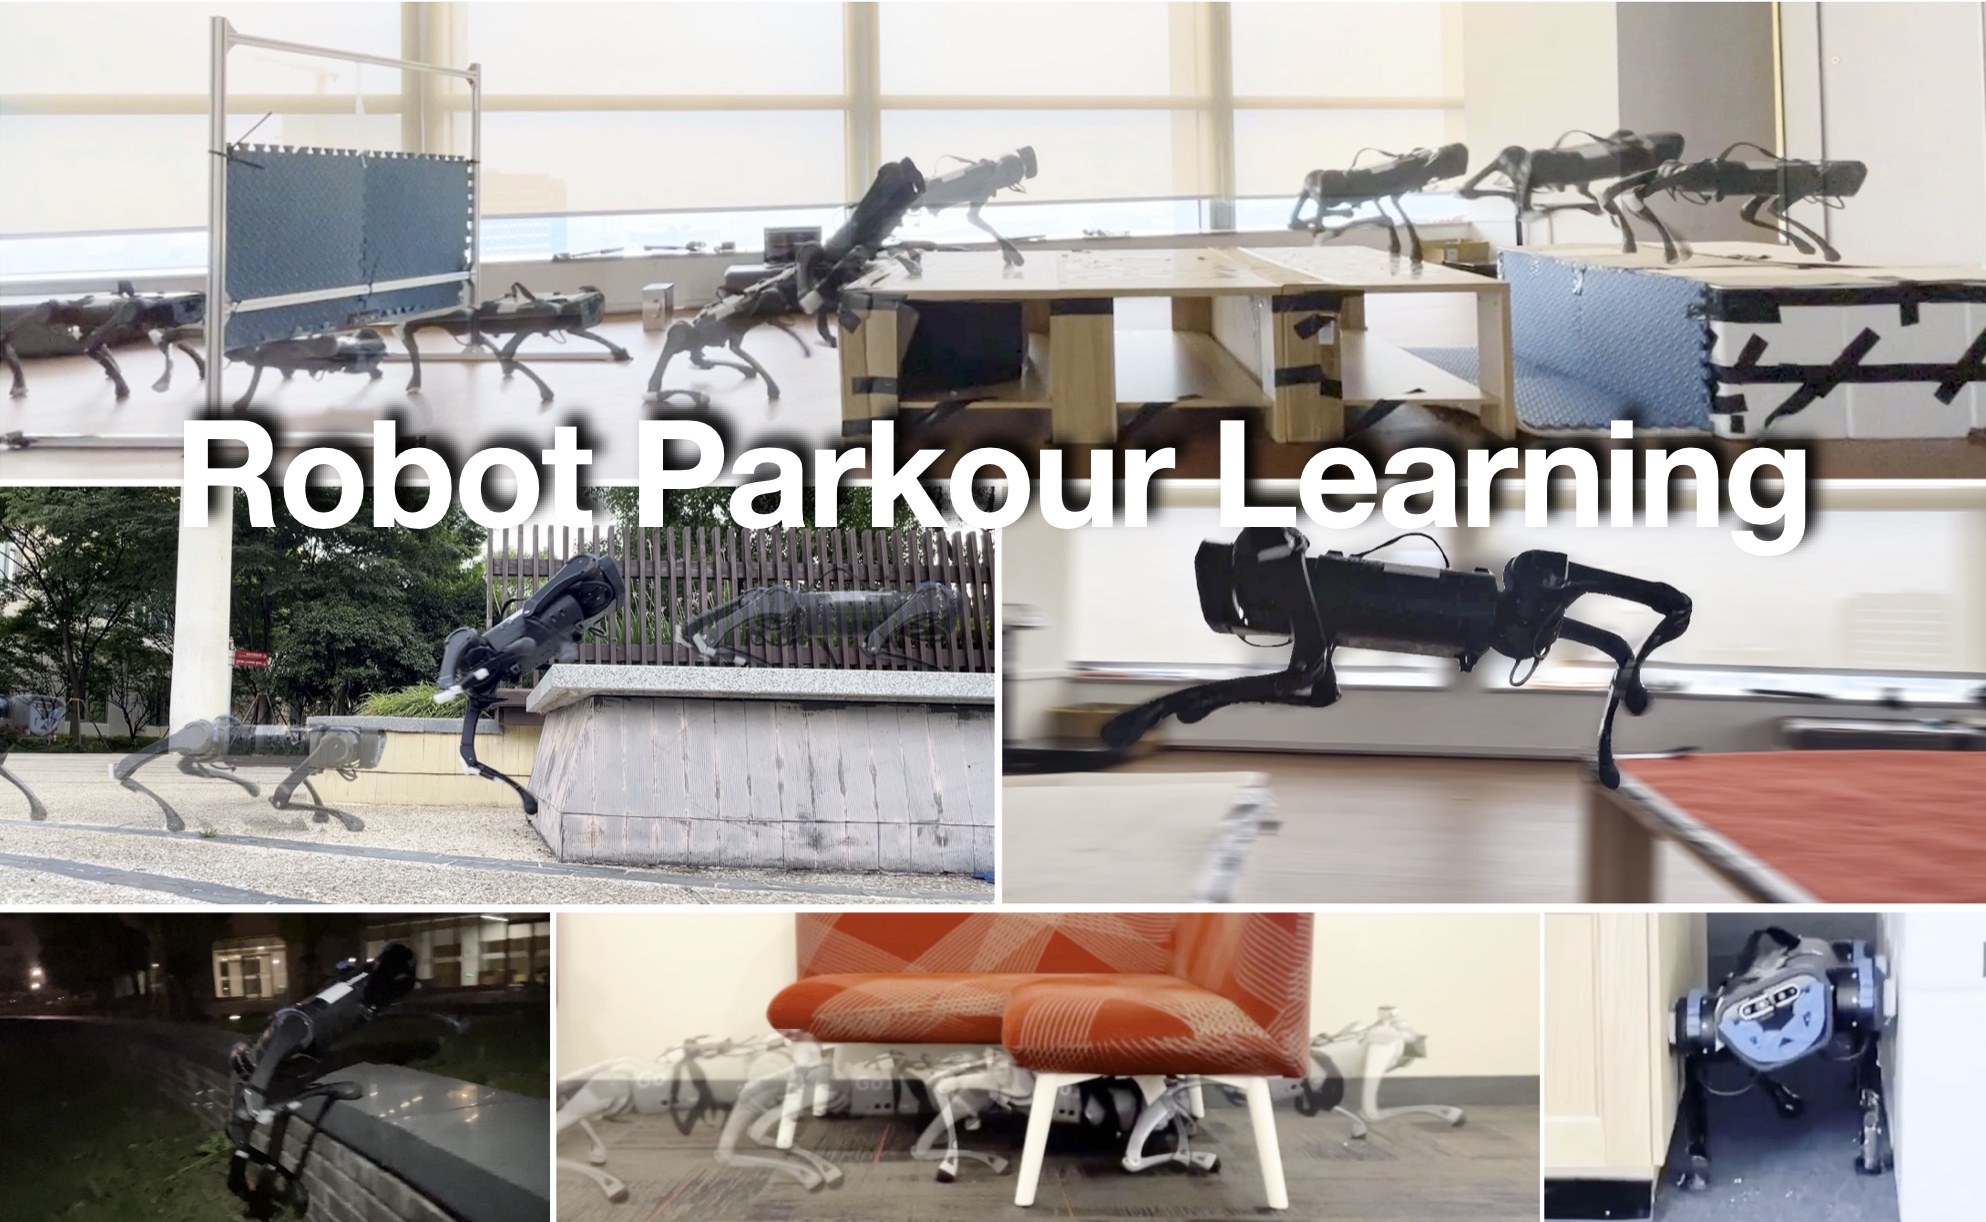
A learning framework that trains quadruped robots to perform parkour-style skills such as climbing, leaping and crawling over obstacles, with policies trained in simulation and deployed on hardware.
- Closed core. It needs closed parts: NVIDIA Isaac Gym.
- Stale. No commit in 12 months: the newest is from 26 Oct 2025.
Facts
- GitHub stars
- 1,142read on 6 Nov 2026
- Last update
- 26 Oct 2025Newest commit on main
- Maintenance
- Staleno commit in 12 months
- Difficulty
- Advanced
- Hardware it needs, as the project states it
- Training runs in simulation with isaacgym; deployment targets Unitree Go1 and Go2 robots.
Checked on GitHub on 6 Nov 2026.
Licenses
- Code
- MIT (opens in a new tab)
Read by Robotheca from LICENSE (opens in a new tab) (MIT) at commit 5e1f413 (opens in a new tab), on 4 Nov 2026.
- Commercial use
- Unknown
It needs closed parts under their own terms: read them before any commercial use.
One part it needs is closed
- Needs NVIDIA Isaac Gym: The legged_gym training environments run in Isaac Gym, a closed NVIDIA download (README).
Overview
What it does: Robotheca's summary
- Trains locomotion policies for legged robots in an isaacgym simulation environment, using the legged_gym package.
- Includes terrain generation code for simulated obstacle courses.
- Provides an rsl_rl network module and algorithm implementation that can be copied onto a robot.
- Offers training configurations for Unitree Go1 and Go2 robots, including example setups.
- Includes deployment code for running trained models on Unitree Go1 and Go2 robots.
- Covers distillation of the trained policy, with notes on configuring the runner for playback in simulation.
Written by Robotheca from the project's README (opens in a new tab) at commit 5e1f413, not by its creator.
The README
The creator's own README, copied as written: README.md by @ZiwenZhuang, at commit 5e1f413, under MIT (opens in a new tab). The original on GitHub (opens in a new tab).
Read the README here
Robot Parkour Learning
Project website: https://robot-parkour.github.io/ (opens in a new tab)
Authors: Ziwen Zhuang* (opens in a new tab), Zipeng Fu* (opens in a new tab), Jianren Wang (opens in a new tab), Christopher Atkeson (opens in a new tab), Sören Schwertfeger (opens in a new tab), Chelsea Finn (opens in a new tab), Hang Zhao (opens in a new tab)
Conference on Robot Learning (CoRL) 2023, Oral, Best Systems Paper Award Finalist (top 3)
Repository Structure
legged_gym: contains the isaacgym environment and config files.legged_gym/legged_gym/envs/{robot}/: contains all the training config files for a specific robotlegged_gym/legged_gym/envs/base/: contains all the environment implementation.legged_gym/legged_gym/utils/terrain/: contains the terrain generation code.
rsl_rl: contains the network module and algorithm implementation. You can copy this folder directly to your robot.rsl_rl/rsl_rl/algorithms/: contains the algorithm implementation.rsl_rl/rsl_rl/modules/: contains the network module implementation.
Training in Simulation
To install and run the code for training A1/Go2 in simulation, please clone this repository and follow the instructions in legged_gym/README.md (opens in a new tab).
Hardware Deployment
To deploy the trained model on your unitree Go1 robot, please follow the instructions in Deploy-Go1.md (opens in a new tab) for deploying on the Unittree Go1 robot.
To deploy the trained model on your unitree Go2 robot, please follow the instructions in Deploy-Go2.md (opens in a new tab) for deploying on the Unittree Go2 robot.
Trouble Shooting
If you cannot run the distillation part or all graphics computing goes to GPU 0 dispite you have multiple GPUs and have set the CUDA_VISIBLE_DEVICES, please use docker to isolate each GPU.
NOTE: When playing the distilled policy in simulation, DO remember to set ckpt_manipulator = None when configuring the runner. Please refer to #82 (opens in a new tab) for more detail.
To Do
- Go1 training configuration (does not guarantee the same performance as the paper)
- A1 deployment code
- Go1 deployment code
- Go2 training configuration example (does not guarantee the same performance as the paper)
- Go2 deployment code example
Citation
If you find this project helpful to your research, please consider cite us! This is really important to us.
@inproceedings{
    zhuang2023robot,
    title={Robot Parkour Learning},
    author={Ziwen Zhuang and Zipeng Fu and Jianren Wang and Christopher G Atkeson and S{\"o}ren Schwertfeger and Chelsea Finn and Hang Zhao},
    booktitle={Conference on Robot Learning {CoRL}},
    year={2023}
}
Files and versions
- Repository on GitHubgithub.com/ZiwenZhuang/parkour (opens in a new tab)
- The version Robotheca read5e1f413 (opens in a new tab)
- Latest releaseNone published on GitHub
Robotheca never hosts the code: each link goes to the creator's own page.
Use it
How to install it, in the creator's words: The project's website (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.