Software
Learning High-Speed Flight in the Wild (agile_autonomy)
By Robotics and Perception Group, from github.com/uzh-rpg/agile_autonomy (opens in a new tab)
- Drones and boats
- Framework
- GPL-3.0-only
Code for training and flying a learned navigation policy that lets a quadrotor fly at high speed through cluttered simulated environments, using a neural network with a pre-trained checkpoint.
- Closed core. It needs closed parts: Unity (Flightmare renderer).
- Stale. No commit in 12 months: the newest is from 23 Jan 2023.
Facts
- GitHub stars
- 816read on 6 Nov 2026
- Last update
- 23 Jan 2023Newest commit on main
- Maintenance
- Staleno commit in 12 months
- Difficulty
- Advanced
Checked on GitHub on 6 Nov 2026.
Licenses
- Code
- GPL-3.0-only (opens in a new tab)
Read by Robotheca from LICENSE (opens in a new tab) (GPL-3.0-only) at commit 958c0d2 (opens in a new tab), on 4 Nov 2026.
- Commercial use
- Unknown
It needs closed parts under their own terms: read them before any commercial use.
One part it needs is closed
- Needs Unity (Flightmare renderer): Simulation uses the Flightmare renderer, built on Unity and installed separately (README).
Copyleft: Modified source must be published.
Overview
What it does: Robotheca's summary
- Provides a pre-trained neural network checkpoint for high-speed flight in simulation, usable across speeds from 1 to 10 m/s.
- Runs in a ROS Noetic simulation built on the Flightmare simulator, with a Python TensorFlow policy.
- Can be trained from a pre-collected dataset of flights at about 7 m/s, or from data collected in simulation with DAgger.
- Lets you change the average flight speed and the environment type, such as trees or objects, through configuration files.
- Includes scripts to visualize the generated trajectories and to test a newly trained network.
Written by Robotheca from the project's README (opens in a new tab) at commit 958c0d2, not by its creator.
The README
The creator's own README, copied as written: README.md by Robotics and Perception Group, at commit 958c0d2, under GPL-3.0-only (opens in a new tab). The original on GitHub (opens in a new tab).
Read the README here
Learning High-Speed Flight in the Wild
This repo contains the code associated with the paper Learning Agile Flight in the Wild. For more information, please check the project webpage (opens in a new tab).
Paper, Video, and Datasets
If you use this code in an academic context, please cite the following publication:
Paper: Learning High-Speed Flight in the Wild (opens in a new tab)
Video (Narrated): YouTube (opens in a new tab)
Datasets: Zenodo (opens in a new tab)
Science Paper: DOI (opens in a new tab)
@inproceedings{Loquercio2021Science,
  title={Learning High-Speed Flight in the Wild},
    author={Loquercio, Antonio and Kaufmann, Elia and Ranftl, Ren{\'e} and M{\"u}ller, Matthias and Koltun, Vladlen and Scaramuzza, Davide},
      booktitle={Science Robotics},
      year={2021},
      month={October},
}
Installation
Requirements
The code was tested with Ubuntu 20.04, ROS Noetic, Anaconda v4.8.3., and gcc/g++ 7.5.0.
Different OS and ROS versions are possible but not supported.
Before you start, make sure that your compiler versions match gcc/g++ 7.5.0. To do so, use the following commands:
sudo update-alternatives --install /usr/bin/g++ g++ /usr/bin/g++-7 100
sudo update-alternatives --install /usr/bin/gcc gcc /usr/bin/gcc-7 100
Step-by-Step Procedure
Use the following commands to create a new catkin workspace and a virtual environment with all the required dependencies.
export ROS_VERSION=noetic
mkdir agile_autonomy_ws
cd agile_autonomy_ws
export CATKIN_WS=./catkin_aa
mkdir -p $CATKIN_WS/src
cd $CATKIN_WS
catkin init
catkin config --extend /opt/ros/$ROS_VERSION
catkin config --merge-devel
catkin config --cmake-args -DCMAKE_BUILD_TYPE=Release -DCMAKE_CXX_FLAGS=-fdiagnostics-color
cd src

git clone git@github.com:uzh-rpg/agile_autonomy.git
vcs-import < agile_autonomy/dependencies.yaml
cd rpg_mpl_ros
git submodule update --init --recursive

#install extra dependencies (might need more depending on your OS)
sudo apt-get install libqglviewer-dev-qt5

# Install external libraries for rpg_flightmare
sudo apt install -y libzmqpp-dev libeigen3-dev libglfw3-dev libglm-dev

# Install dependencies for rpg_flightmare renderer
sudo apt install -y libvulkan1 vulkan-utils gdb

# Add environment variables (Careful! Modify path according to your local setup)
echo 'export RPGQ_PARAM_DIR=/home/<path/to/>catkin_aa/src/rpg_flightmare' >> ~/.bashrc
Now open a new terminal and type the following commands.
# Build and re-source the workspace
catkin build
. ../devel/setup.bash

# Create your learning environment
roscd planner_learning
conda create --name tf_24 python=3.7
conda activate tf_24
pip install tensorflow-gpu==2.4
pip install rospkg==1.2.3 pyquaternion open3d opencv-python
Now download the flightmare standalone available at this link (opens in a new tab), extract it and put in the flightrender (opens in a new tab) folder.
Let's Fly!
Once you have installed the dependencies, you will be able to fly in simulation with our pre-trained checkpoint. You don't need necessarily need a GPU for execution. Note that if the network can't run at least at 15Hz, you won't be able to fly successfully.
Launch the simulation! Open a terminal and type:
cd agile_autonomy_ws
source catkin_aa/devel/setup.bash
roslaunch agile_autonomy simulation.launch
Run the Network in an other terminal:
cd agile_autonomy_ws
source catkin_aa/devel/setup.bash
conda activate tf_24
python test_trajectories.py --settings_file=config/test_settings.yaml
Change execution speed or environment
You can change the average speed at which the policy will fly as well as the environment type by changing the following files.
Environment Change:
rosed agile_autonomy flightmare.yaml
Set either the spawn_trees or spawn_objects to true. Doing both at the same time is possible but would make the environment too dense for navigation. Also adapt the spacings parameter in test_settings.yaml (opens in a new tab) to the environment.
Speed Change:
rosed agile_autonomy default.yaml
Edit the test_time_velocity and maneuver_velocity to the required speed. Note that the ckpt we provide will work for all speeds in the range [1,10] m/s. However, to reach the best performance at a specific speed, please consider finetuning the ckpt at the desired speed (see code below).
Train your own navigation policy
There are two ways in which you can train your own policy. One easy and one more involved. The trained checkpoint can then be used to control a physical platform (if you have one!).
Use pre-collected dataset
The first method, requiring the least effort, is to use a dataset that we pre-collected. The dataset can be found at this link (opens in a new tab). This dataset was used to train the model we provide and collected at an average speed of 7 m/s. To do this, adapt the file train_settings.yaml (opens in a new tab) to point to the train and test folder and run:
cd agile_autonomy_ws
source catkin_aa/devel/setup.bash
conda activate tf_24
python train.py --settings_file=config/train_settings.yaml
Feel free to ablate the impact of each parameter!
Collect your own dataset
You can use the following commands to generate data in simulation and train your model on it. Note that training a policy from scratch could require a lot of data, and depending on the speed of your machine this could take several days. Therefore, we always recommend finetuning the provided checkpoint to your use case. As a general rule of thumb, you need a dataset with comparable size to ours to train a policy from scratch, but only 1/10th of it to finetune.
Generate data
To train or finetune a policy, use the following commands: Launch the simulation in one terminal
cd agile_autonomy_ws
source catkin_aa/devel/setup.bash
roslaunch agile_autonomy simulation.launch
Launch data collection (with dagger) in an other terminal
cd agile_autonomy_ws
source catkin_aa/devel/setup.bash
conda activate tf_24
python dagger_training.py --settings_file=config/dagger_settings.yaml
It is possible to change parameters (number of rollouts, dagger constants, tracking a global trajectory, etc. ) in the file dagger_settings.yaml (opens in a new tab). Keep in mind that if you change the network or input, you will need to adapt the file test_settings.yaml (opens in a new tab) for compatibility.
When training from scratch, follow a pre-computed global trajectory to give consistent labels. To activate this, you need to put to true the flag perform_global_planning in default.yaml (opens in a new tab) and label_generation.yaml (opens in a new tab). Note that this will make the simulation slower (a global plan has to be computed at each iteration). The network will not have access to this global plan, but only to the straight (possibly in collision) reference.
Visualize the Data
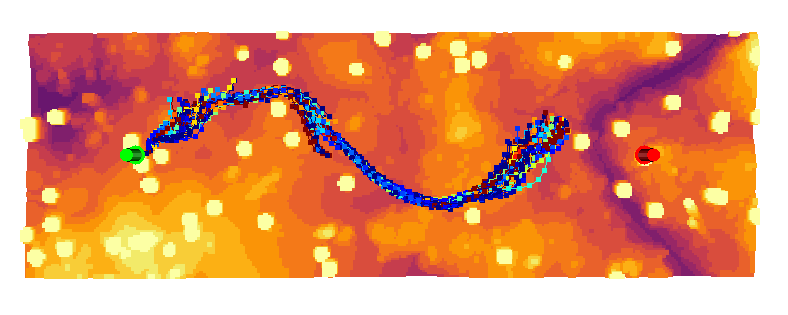
You can visualize the generated trajectories in open3d using the visualize_trajectories.py (opens in a new tab) script.
python visualize_trajectories.py --data_dir /PATH/TO/rollout_21-09-21-xxxx --start_idx 0 --time_steps 100 --pc_cutoff_z 2.0 --max_traj_to_plot 100
The result should more or less look as the following:
Test the Network
To test the network you trained, adapt the test_settings.yaml (opens in a new tab) with the new checkpoint path. You might consider putting back the flag perform_global_planning in default.yaml (opens in a new tab) to false to make the simulation faster. Then follow the instructions in the above section (Let's Fly!) to test.
Ackowledgements
We would like to thank Yunlong Song and Selim Naji for their help with the implementations of the simulation environment. The code for global planning is strongly inspired by the one of Search-based Motion Planning for Aggressive Flight in SE(3) (opens in a new tab).
Files and versions
- Repository on GitHubgithub.com/uzh-rpg/agile_autonomy (opens in a new tab)
- The version Robotheca read958c0d2 (opens in a new tab)
- Latest releaseNone published on GitHub
Robotheca never hosts the code: each link goes to the creator's own page.
Use it
How to install it, in the creator's words: The project's README (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.