Software
Flightmare
By Robotics and Perception Group, from github.com/uzh-rpg/flightmare (opens in a new tab)
- Drones and boats
- Simulator
- MIT
Flightmare is a modular quadrotor simulator pairing a configurable Unity-based rendering engine with a separate physics engine for flight dynamics.
- Closed core. It needs closed parts: Unity.
- Stale. No commit in 12 months: the newest is from 15 May 2023.
Facts
- GitHub stars
- 1,446read on 6 Nov 2026
- Last update
- 15 May 2023Newest commit on master
- Maintenance
- Staleno commit in 12 months
- Difficulty
- Advanced
Checked on GitHub on 6 Nov 2026.
Licenses
- Code
- MIT (opens in a new tab)
Read by Robotheca from LICENSE (opens in a new tab) (MIT) at commit d4218ae (opens in a new tab), on 4 Nov 2026.
- Commercial use
- Unknown
It needs closed parts under their own terms: read them before any commercial use.
One part it needs is closed
- Needs Unity: The rendering engine is built on Unity, a proprietary engine, as a separate download (README).
Overview
What it does: Robotheca's summary
- Rendering and physics components are decoupled and can run independently of each other.
- Offers a multi-modal sensor suite, including extraction of 3D point clouds from the scene.
- Provides a reinforcement learning API that can simulate hundreds of quadrotors in parallel.
- Integrates with a virtual-reality headset for interaction with the simulated environment.
- Suited to path planning, reinforcement learning, visual-inertial odometry, deep learning and human-robot interaction.
Written by Robotheca from the project's README (opens in a new tab) at commit d4218ae, not by its creator.
The README
The creator's own README, copied as written: README.md by Robotics and Perception Group, at commit d4218ae, under MIT (opens in a new tab). The original on GitHub (opens in a new tab).
Read the README here
Flightmare - 左青龙
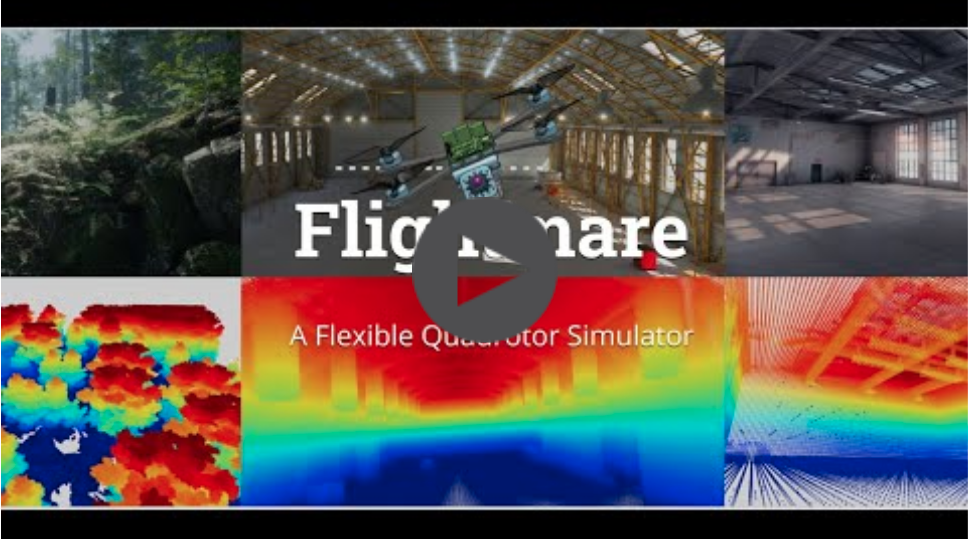
Flightmare is a flexible modular quadrotor simulator. Flightmare is composed of two main components: a configurable rendering engine built on Unity and a flexible physics engine for dynamics simulation. Those two components are totally decoupled and can run independently from each other. Flightmare comes with several desirable features: (i) a large multi-modal sensor suite, including an interface to extract the 3D point-cloud of the scene; (ii) an API for reinforcement learning which can simulate hundreds of quadrotors in parallel; and (iii) an integration with a virtual-reality headset for interaction with the simulated environment. Flightmare can be used for various applications, including path-planning, reinforcement learning, visual-inertial odometry, deep learning, human-robot interaction, etc.
Website (opens in a new tab) & Documentation (opens in a new tab)
Installation
Installation instructions can be found in our Wiki (opens in a new tab).
Updates
- 17.11.2020 Spotlight (opens in a new tab) Talk at CoRL 2020
- 04.09.2020 Release Flightmare
Publication
If you use this code in a publication, please cite the following paper PDF (opens in a new tab)
@inproceedings{song2020flightmare,
    title={Flightmare: A Flexible Quadrotor Simulator},
    author={Song, Yunlong and Naji, Selim and Kaufmann, Elia and Loquercio, Antonio and Scaramuzza, Davide},
    booktitle={Conference on Robot Learning},
    year={2020}
}
License
This project is released under the MIT License. Please review the License file (opens in a new tab) for more details.
Files and versions
- Repository on GitHubgithub.com/uzh-rpg/flightmare (opens in a new tab)
- The version Robotheca readd4218ae (opens in a new tab)
- Latest release0.0.5 (1 Dec 2020)
Robotheca never hosts the code: each link goes to the creator's own page.
Use it
How to install it, in the creator's words: The project's website (opens in a new tab)
Robotheca doesn't review code. Read it before running it.
Robotheca lists software as a reference: nothing is hosted or run here, and every fact links to where it was read.