Fast-Drone-250
An open-source 250mm autonomous quadrotor drone that flies in unknown environments and avoids obstacles using VINS visual-inertial odometry and EGO-Planner.
- No license
Robots published by organisations and labs based in China, from the location they state, or on a platform based there, such as Gitee. Robotheca never guesses where an individual maker lives. 6 robots on Robotheca, each with its licenses and its source on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
An open-source 250mm autonomous quadrotor drone that flies in unknown environments and avoids obstacles using VINS visual-inertial odometry and EGO-Planner.
A fully open-source, low-cost, 3D-printable bipedal robot designed for hobbyists, educators, and researchers.
A collection of 3D-printable accessories and decorations for the ElectronBot robot.
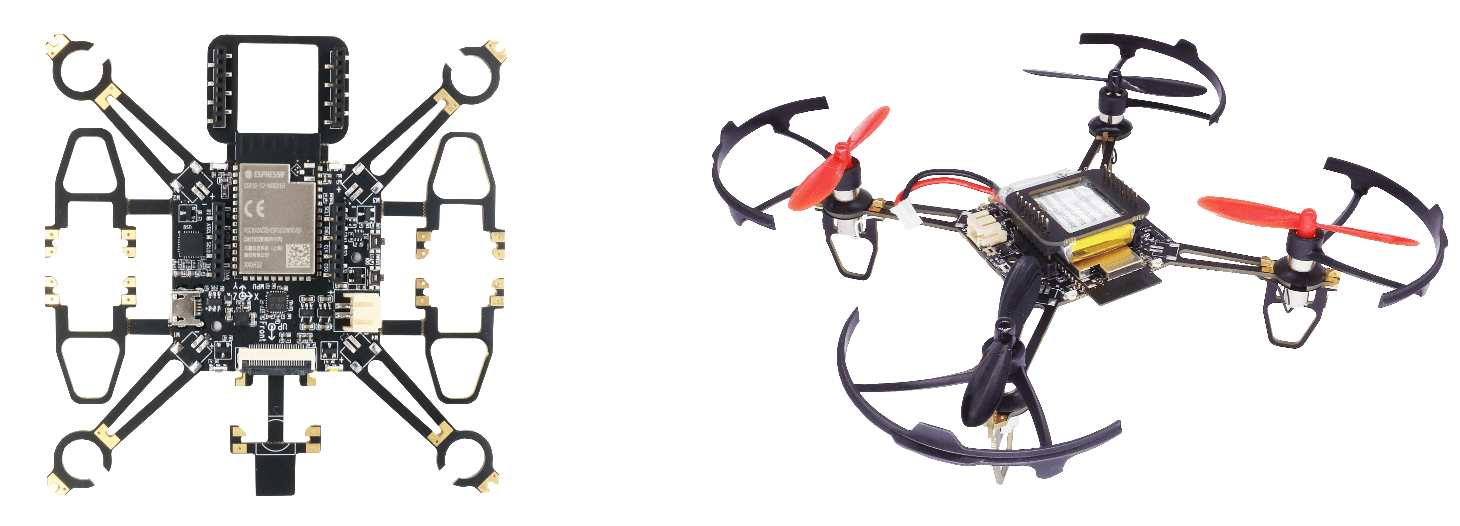
An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.
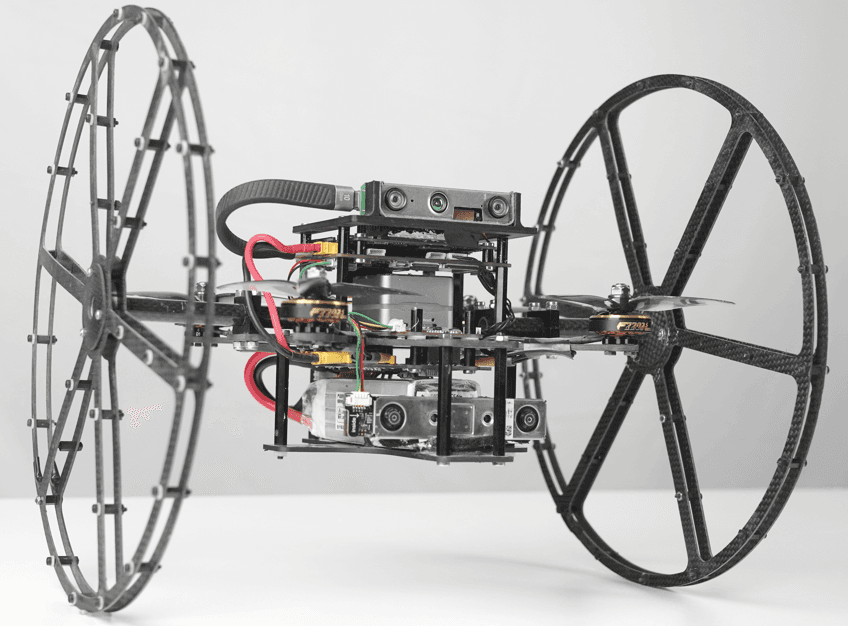
A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.
AgiBot's open hardware design of its X1 (Lingxi X1) humanoid robot, in three dated versions (2024-10-24, 2025-01-08 and 2025-03-07).