TABV-Platform
A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.
- Drone
- Open source
- 3D printable
Suggested by Robotheca, created by @ZJU-FAST-Lab (opens in a new tab), from github.com/ZJU-FAST-Lab/TABV-Platform (opens in a new tab). Pinned to commit afe6c50 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo
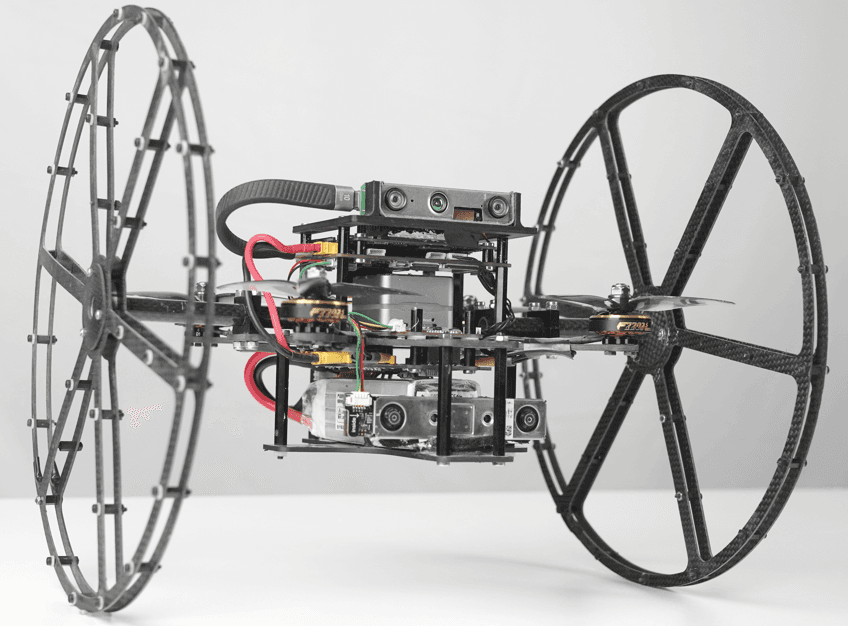
What it can do
Written by Robotheca from the project's documents.
- Navigates on land and in the air as a hybrid terrestrial-aerial vehicle
- Performs autonomous navigation using integrated sensors and control systems
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @ZJU-FAST-Lab (README.md), under GPL-3.0-only.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Custom PCBs for power distribution and signal processing
- Flight controller for aerial mode
- Ground navigation controller for terrestrial mode
- Battery and power management system
Connections
- PCB-to-motor connections for propulsion
- Sensor-to-controller signal lines
- Power distribution from battery to PCBs and motors